

ProductPRODUCT
Featured products

Contact Us
- Allen Bradley
- 2198-H2DCK
- Hiperface-to-DSL Feedback Converter Kit
- USA
- 130 × 42 × 76 mm
- 0.1 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 20
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
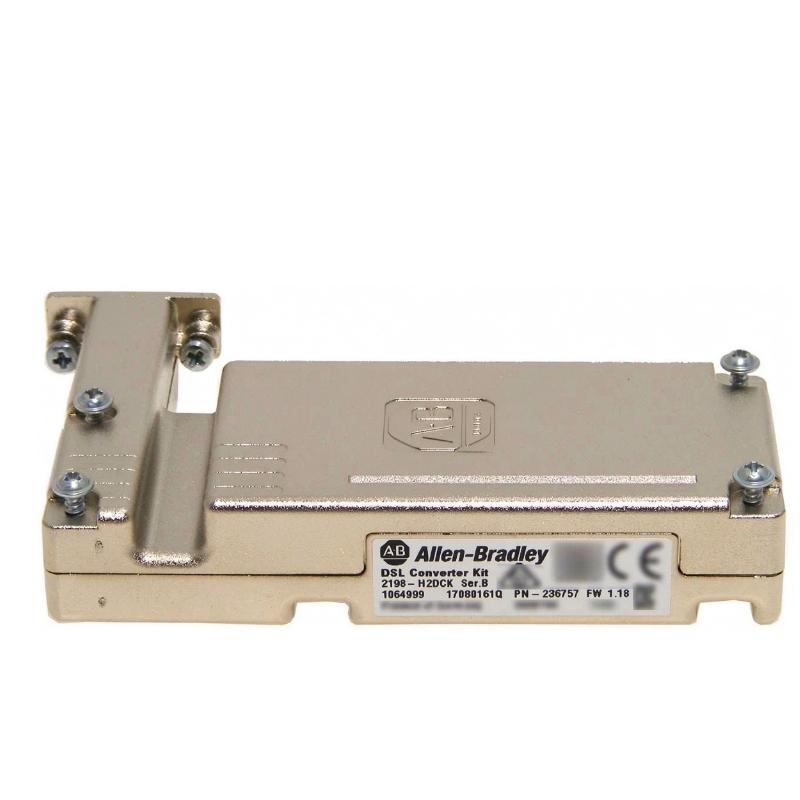
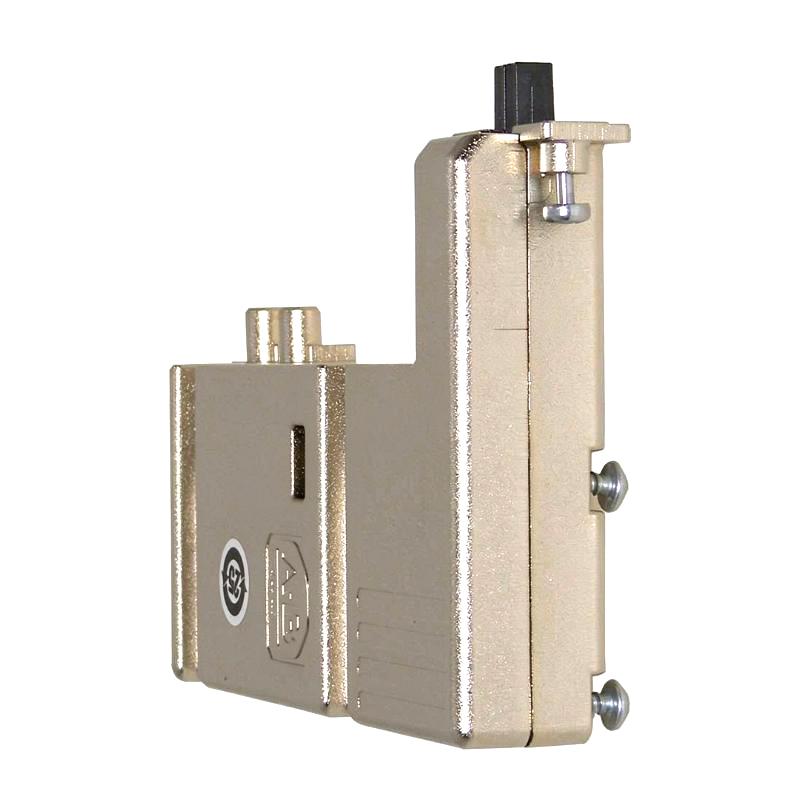
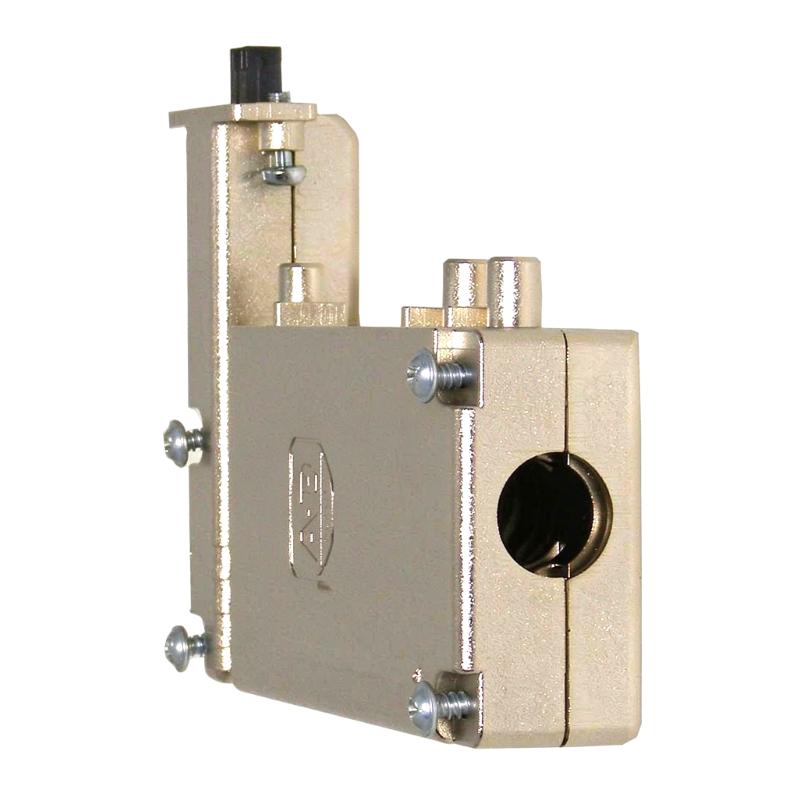
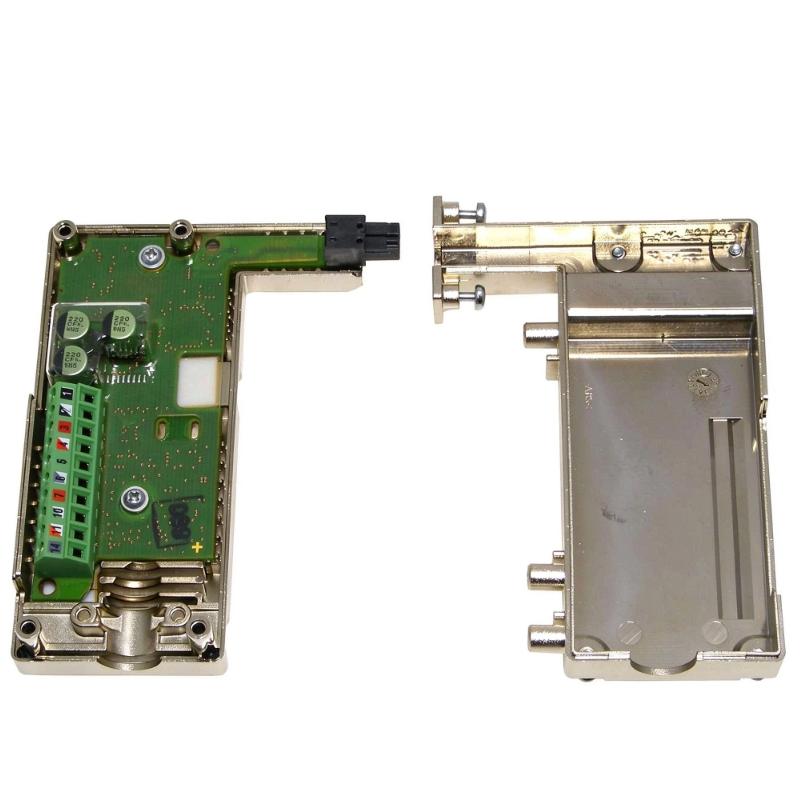
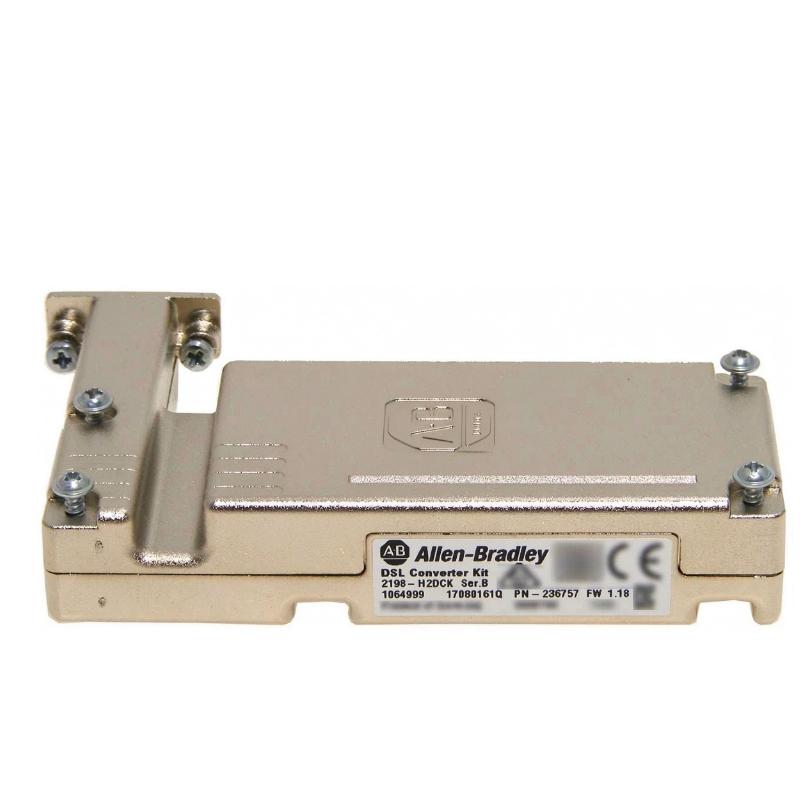
The Allen Bradley 2198-H2DCK Hiperface-to-DSL Feedback Converter Kit is a feedback interface accessory used to connect compatible Hiperface encoder feedback systems with Allen-Bradley Kinetix servo drives that accept DSL feedback. Rather than controlling motor power or generating motion commands, the kit handles the conversion and connection of encoder feedback signals required by the servo-control system.
This accessory is particularly useful when integrating compatible MP-Series motors or linear actuators into a Kinetix 5500 installation. These applications may already have an established motor and feedback cable arrangement, but the selected drive uses a different feedback interface. The converter kit bridges that interface difference, allowing supported Hiperface encoder signals to reach the drive through its motor-feedback connection.
The 2198-H2DCK accepts the relevant signals from a 15-pin Hiperface feedback connection and converts them into the two-pin Digital Servo Link (DSL) interface. The kit includes termination provisions for the encoder conductors and a connector assembly that mates with the drive-side feedback connection. Proper cable preparation and shield termination are essential because feedback signals must remain electrically sound in an environment where motor power cables and switching electronics can introduce interference.
The kit is also relevant to certain Kinetix 5700 applications that require auxiliary encoder feedback. In these arrangements, a Hiperface encoder can supply feedback for a secondary control loop or load-position measurement when the drive’s universal feedback connector is already being used for another compatible feedback source. The intended feedback role and supported drive configuration determine how the kit should be applied.
Compatibility depends on more than matching the connector shape. The encoder must use a supported Hiperface feedback format, and the associated motor or actuator, cable, drive hardware, and firmware must be suitable for the intended configuration. High-resolution absolute single-turn and multi-turn feedback are supported use cases; incremental feedback devices should not be assumed compatible.
During commissioning, the 2198-H2DCK helps establish the feedback path between the encoder and the servo drive. If the drive cannot establish feedback, the investigation should include the encoder type, cable preparation, terminal assignments, shield connection, connector engagement, and drive configuration. These checks are particularly important when retrofitting an existing machine or replacing a drive while retaining its original motor.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Allen-Bradley |
| Model | 2198-H2DCK |
| Product Type | Hiperface-to-DSL Feedback Converter Kit |
| Product Family | Kinetix Servo Drive Accessories |
| Application | Encoder feedback interface conversion |
| Input Feedback Interface | 15-pin Hiperface |
| Output Feedback Interface | 2-pin Digital Servo Link (DSL) |
| Supported Feedback Types | Compatible high-resolution absolute single-turn and multi-turn Hiperface encoders |
| Kinetix 5500 Application | Compatible motor feedback connection |
| Kinetix 5700 Application | Supported auxiliary feedback configurations, subject to drive requirements |
| Cable Compatibility | Applicable Allen-Bradley 2090-Series feedback cables |
| Connector Termination | 10-pin converter-side termination arrangement |
| Mounting | Bracket-mounted to a compatible servo drive |
| Shielding | Feedback cable shield termination provided |
| Series Requirement | Series B or later for the documented converter-kit applications |
| Dimensions | 130 × 42 × 76 mm |
| Weight | 0.1 kg |
Product Features
- Hiperface-to-DSL conversion: Converts compatible 15-pin Hiperface encoder feedback signals into the two-pin DSL interface.
- Kinetix drive integration: Supports documented feedback arrangements for compatible Kinetix servo drives.
- Absolute encoder support: Accommodates supported high-resolution single-turn and multi-turn Hiperface feedback.
- Existing cable integration: Works with applicable Allen-Bradley 2090-Series feedback cables.
- Defined wire termination: Provides connection points for the encoder signals and a structured assembly process.
- Shield termination provisions: Helps establish the intended cable-shield connection when assembled correctly.
- Drive-mounted installation: Uses a mounting bracket to secure the converter kit in the appropriate drive position.
- Retrofit applications: Can support compatible motor and actuator installations when upgrading to a supported Kinetix drive system.
Working Principle
The 2198-H2DCK acts as an interface between two different feedback connection formats. The Hiperface encoder supplies position-related feedback signals through a 15-pin connection. The converter kit provides the required signal termination and conversion arrangement so that compatible DSL feedback can be presented to the servo drive.
Hiperface Encoder → Feedback Cable → 2198-H2DCK → DSL Connection → Kinetix Servo Drive
During normal operation, the encoder generates feedback associated with the motor’s rotor position. In supported absolute encoder configurations, the feedback includes position information that the drive can use to establish and maintain the axis position. The converter kit connects this feedback path to the drive’s DSL interface; the drive itself performs the motor-control calculations and regulates motor power.
For example, a machine may use an existing MP-Series servo motor with a compatible Hiperface absolute encoder. When that motor is integrated into a supported Kinetix 5500 system, the original feedback interface may not connect directly to the drive’s DSL input. The 2198-H2DCK provides the required interface conversion, allowing the compatible encoder feedback to be received by the drive.
The kit’s wiring arrangement must be assembled carefully. The feedback conductors need the correct strip lengths and routing, while the cable shield must be positioned properly under the shield clamp. Stray shield strands can short adjacent terminals, and poorly prepared conductors can create intermittent feedback faults. The cable jacket and service loop must also be positioned so that the connection is not subjected to unnecessary mechanical strain.
Once installed, the converter becomes part of the drive’s feedback path. If the encoder signals are not received correctly, the drive may report a feedback-related fault or fail to complete commissioning. In that situation, replacing the converter immediately is not always the right first step. The cable, encoder type, terminal arrangement, connector seating, and drive compatibility should be checked systematically.
The kit does not convert an unsupported incremental encoder into a compatible absolute feedback device. It also does not replace the servo drive’s control algorithms or provide an independent motion-control function. Its role is limited to establishing the required feedback interface for supported equipment.
Role in a Kinetix Servo Drive System
The 2198-H2DCK sits between a compatible Hiperface encoder feedback cable and the servo drive’s DSL feedback connection. Its role is to make the feedback interface compatible with the selected drive arrangement while preserving the required signal and shield connections.
Motor or Actuator Encoder → 2090-Series Feedback Cable → 2198-H2DCK → DSL Feedback Connector → Kinetix Drive → Motor Control
| System Component | Function |
|---|---|
| Allen-Bradley 2198-H2DCK | Converts compatible Hiperface feedback signals into the DSL interface |
| Hiperface Absolute Encoder | Supplies motor or actuator position feedback |
| MP-Series Servo Motor | Provides controlled rotary motion in a compatible application |
| Compatible Linear Actuator | Converts motor rotation into controlled linear movement |
| 2090-Series Feedback Cable | Carries encoder signals to the converter kit |
| DSL Feedback Connection | Connects the converted feedback interface to the drive |
| Kinetix 5500 Servo Drive | Uses compatible feedback for motor control |
| Kinetix 5700 Servo Drive | Supports documented auxiliary feedback applications |
| Mounting Bracket | Secures the converter kit to the appropriate drive mounting position |
| Cable Shield Clamp | Establishes the intended shield termination |
| Machine Controller | Coordinates motion commands and machine sequencing |
The correct feedback architecture depends on whether the converter is used for the primary motor-feedback connection or a supported auxiliary-feedback function. Those arrangements should be configured according to the selected drive and application.
Industrial Applications
| Application | Typical Use |
|---|---|
| Servo System Upgrades | Connecting supported Hiperface encoder feedback to a compatible Kinetix drive interface |
| Packaging Machinery | Retaining compatible servo motor feedback during a drive-system upgrade |
| Automated Assembly | Supporting feedback integration for positioning axes |
| Material Handling | Connecting supported motor or actuator feedback in automated transfer equipment |
| Machine Tools | Integrating compatible absolute encoder feedback into servo-controlled axes |
| Linear Positioning Systems | Supporting feedback connections for compatible linear actuators |
| Multi-Axis Motion Systems | Establishing the required feedback interface within a coordinated servo installation |
| Precision Automation | Maintaining the encoder feedback path used by the servo drive |
| Retrofit Projects | Adapting supported existing motor feedback arrangements to a compatible drive |
| Auxiliary Feedback Applications | Connecting supported Hiperface feedback for load or secondary-loop measurement on compatible Kinetix 5700 configurations |
The kit is intended for documented encoder and drive combinations. An application should not be considered compatible solely because the motor has a Hiperface connector or because the drive accepts DSL feedback.
Installation and Maintenance
- Confirm the feedback application: Determine whether the kit is being used for a Kinetix 5500 motor-feedback connection or a supported Kinetix 5700 auxiliary-feedback arrangement.
- Check encoder compatibility: Confirm that the motor or actuator uses a supported high-resolution absolute Hiperface encoder rather than an unsupported incremental feedback device.
- Verify the drive requirements: Check the drive model, firmware requirements, converter-kit series, and intended feedback connector before installation.
- Inspect the feedback cable: Examine the cable jacket, conductors, connector, and shield for damage before preparing the connection.
- Prepare the conductors carefully: Follow the applicable installation procedure for conductor length and insulation stripping to ensure that the terminals are assembled correctly.
- Trim the cable shield correctly: Prevent stray shield strands from contacting adjacent terminals or creating an electrical short.
- Secure the shield clamp: Position the exposed cable shield in the designated channel and secure the clamp according to the applicable installation instructions.
- Install the mounting bracket: Attach the kit in the mounting position appropriate for the drive frame and secure the assembly as specified.
- Check connector engagement: Confirm that the converter-side termination and drive-side DSL connection are fully seated and correctly oriented.
- Inspect cable routing: Provide a suitable service loop and strain relief, and avoid routing the feedback cable in a way that exposes it to unnecessary interference or mechanical damage.
- Test feedback during commissioning: Verify that the drive recognizes the encoder feedback and completes the appropriate startup procedure before releasing the axis for normal operation.
- Record the installation details: Document the encoder type, cable designation, converter-kit series, drive configuration, and any feedback faults observed during commissioning.
If a feedback fault appears after installation, inspect the wiring and shield termination before changing drive parameters. A converter kit cannot compensate for incorrect encoder wiring, an incompatible feedback device, or a cable that does not meet the application’s requirements.
Related Components
| Component | Function |
|---|---|
| Allen-Bradley 2198-H2DCK | Converts supported Hiperface feedback to DSL |
| Kinetix 5500 Servo Drive | Receives the converted feedback through its motor-feedback connection |
| Kinetix 5700 Servo Drive | Supports documented auxiliary-feedback arrangements |
| MP-Series Rotary Servo Motor | Provides motor motion and compatible encoder feedback in supported configurations |
| MP-Series Linear Actuator | Provides controlled linear movement in compatible applications |
| LDAT-Series Linear Thruster | Supports compatible absolute encoder feedback applications |
| 2090-Series Feedback Cable | Carries the encoder signals to the converter kit |
| Feedback Connector Assembly | Provides the electrical interface between the converter and drive |
| Mounting Bracket | Secures the kit to the appropriate drive frame |
| Cable Shield Clamp | Maintains the specified feedback-cable shield termination |
| Machine Controller | Coordinates servo motion and machine sequencing |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| Allen-Bradley 2198-H2DCK | Hiperface-to-DSL Feedback Converter Kit | Converting supported Hiperface encoder feedback for compatible Kinetix drives |
| Allen-Bradley 2198-H003-ERS | Kinetix 5500 Servo Drive | Lower-power servo applications using a compatible feedback arrangement |
| Allen-Bradley 2198-H008-ERS | Kinetix 5500 Servo Drive | Compact servo axes with supported motor-feedback configurations |
| Allen-Bradley 2198-H015-ERS | Kinetix 5500 Servo Drive | Servo applications requiring a compatible Kinetix 5500 feedback interface |
| Allen-Bradley 2198-H025-ERS | Kinetix 5500 Servo Drive | Mid-range servo-axis applications |
| Allen-Bradley 2198-H040-ERS | Kinetix 5500 Servo Drive | Higher-current Kinetix 5500 servo applications |
| Allen-Bradley 2198-H070-ERS | Kinetix 5500 Servo Drive | Higher-power Kinetix 5500 applications using supported feedback arrangements |
Key Advantages
- Converts supported Hiperface encoder feedback into a DSL interface.
- Supports documented Kinetix servo-drive feedback configurations.
- Helps integrate compatible existing motors and actuators into supported drive systems.
- Provides a defined termination arrangement for encoder conductors and cable shielding.
- Supports primary or auxiliary feedback applications where the drive configuration permits.
- Simplifies feedback-interface integration without replacing the encoder solely to match the connector format.
Technical FAQs
Which encoder feedback signals can the 2198-H2DCK convert?
The kit supports compatible high-resolution absolute Hiperface feedback, including single-turn and multi-turn encoder types. Compatibility depends on the encoder, motor or actuator, cable, and drive configuration. Incremental encoder feedback should not be assumed to work with this converter.
Can the 2198-H2DCK be used with both Kinetix 5500 and Kinetix 5700 systems?
Yes, in documented configurations, but the application differs. For Kinetix 5500 systems, the kit can provide the required interface for compatible motor feedback. In Kinetix 5700 systems, supported applications include auxiliary feedback arrangements, such as load or secondary-loop feedback. The drive’s connector availability and feedback configuration determine the appropriate use.
Why is correct cable-shield termination important for this kit?
The feedback cable carries encoder signals used by the drive to control motor movement. Incorrect shield placement, loose connections, or stray shield strands can introduce interference or electrical shorts. Proper conductor preparation, shield-clamp installation, and cable routing help prevent intermittent feedback faults.
Will this converter allow any Hiperface encoder to connect to a DSL drive?
No. The kit converts the interface for supported Hiperface feedback systems; it does not make every encoder electrically or functionally compatible. The encoder must provide a supported feedback format, and the associated drive, firmware, cable, and motor or actuator must meet the applicable compatibility requirements.