ProductPRODUCT
Featured products
Contact Us
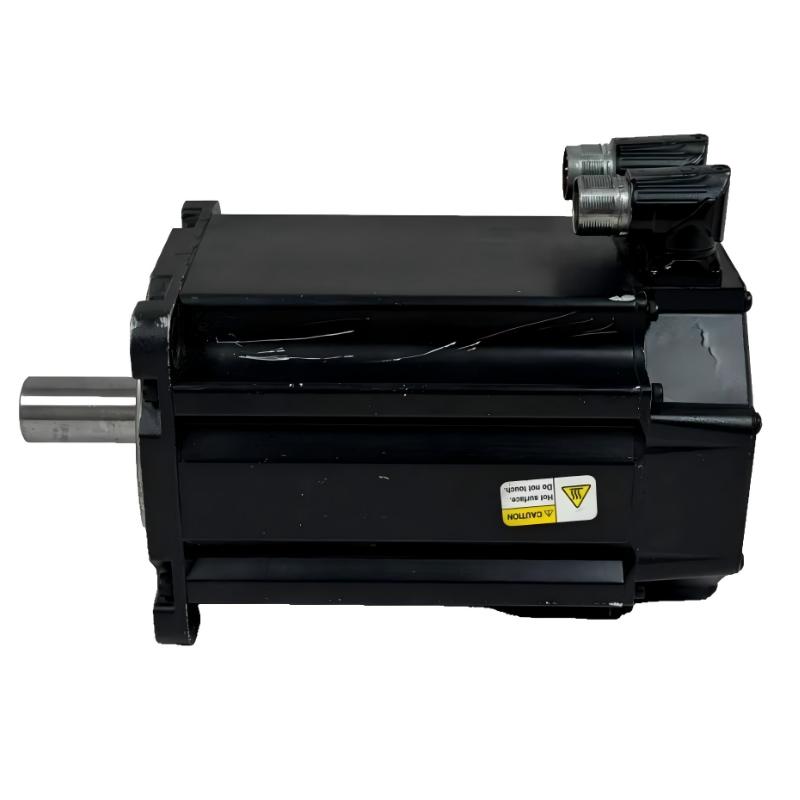
- Allen Bradley
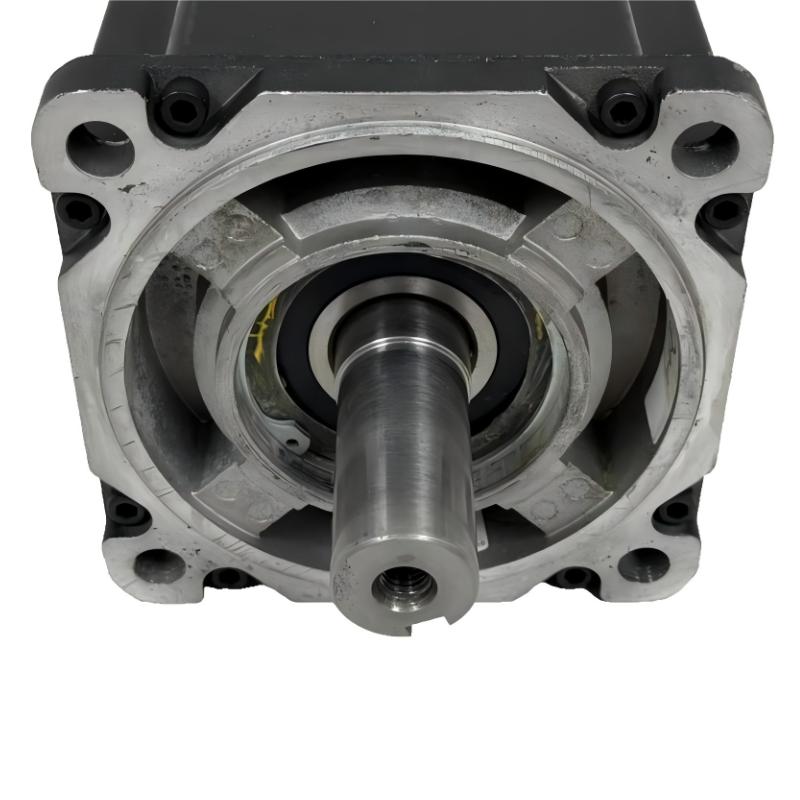
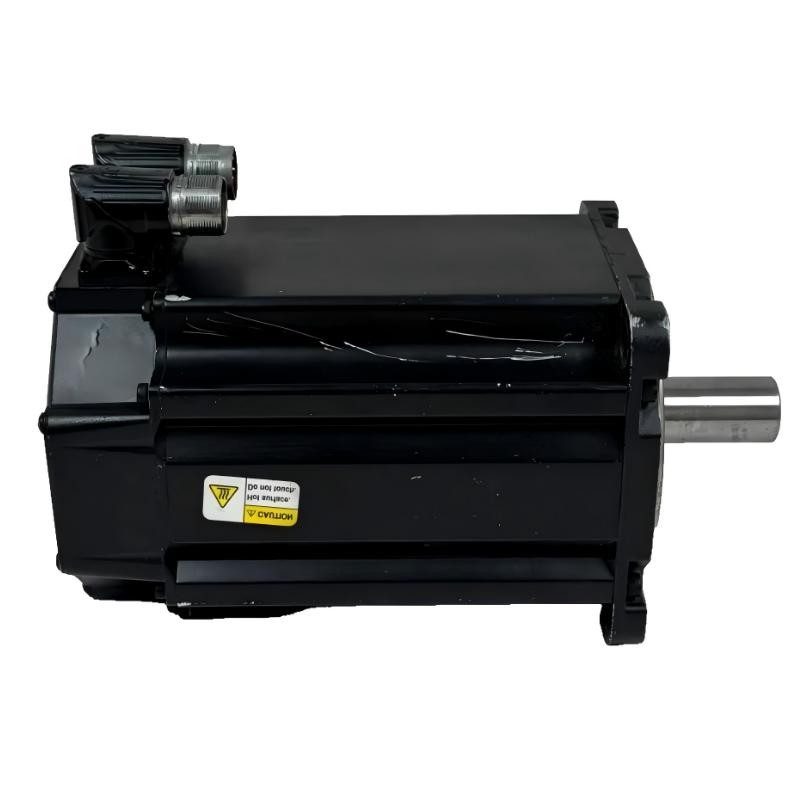
- MPL-B960B-SJ72AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 215 mm ×203.2 mm × 325 mm
- 42.7 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 12
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
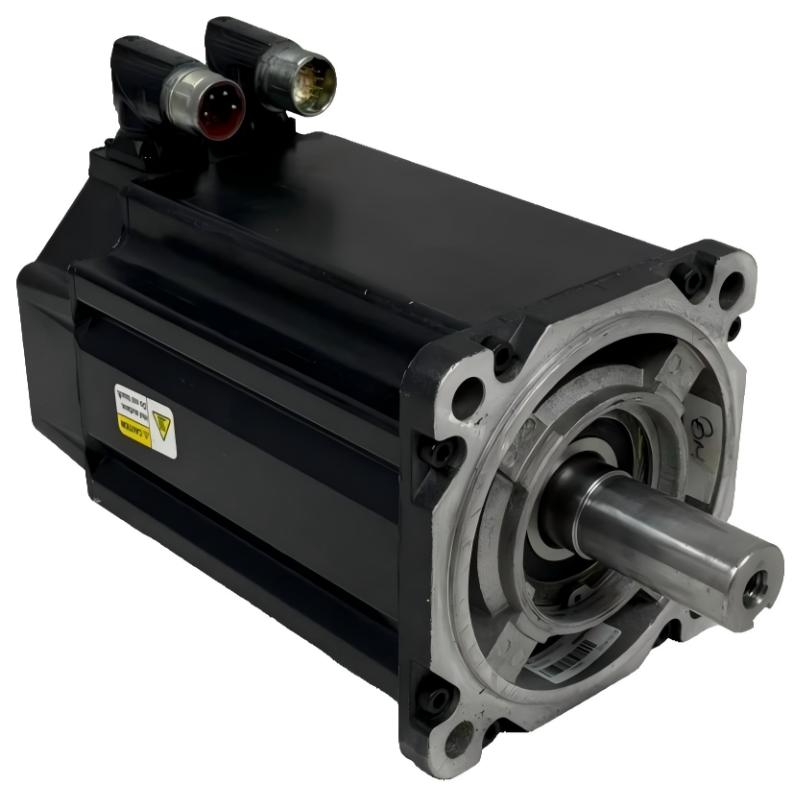
Allen-Bradley MPL-B960B-SJ72AA Servo Motor: Technical Specifications, Product Overview, Applications, Advantages, and Model Recommendations
1. Product Overview
The Allen-Bradley MPL-B960B-SJ72AA is an industrial servo motor model designation associated with the MPL low-inertia permanent-magnet servo motor family. Motors in this family are designed for motion-control systems that require accurate positioning, controlled acceleration and deceleration, repeatable movement, and reliable operation in automated production equipment.
A servo motor is different from a conventional industrial motor because it is intended to operate as part of a closed-loop motion-control system. A compatible servo drive, feedback device, controller, and mechanical transmission work together to regulate the motor’s position, speed, and torque according to the machine’s operating requirements.
The MPL family is commonly associated with applications such as packaging machinery, material handling, automated assembly, precision positioning, and industrial manufacturing equipment. The exact performance and installation requirements depend on the individual motor configuration.
The complete model number is important when selecting a replacement or designing a new system. Different letters and numbers within a servo motor catalog number can identify variations in mechanical construction, feedback configuration, connector arrangement, winding characteristics, and other ordering options. These details should not be assumed interchangeable between similar-looking models.
This technical overview uses English throughout, with separate tables for specifications, product characteristics, applications, advantages, and related model recommendations. Exact catalog-specific measurements that cannot be established confidently are identified as requiring verification rather than being presented as confirmed values.
2. Brand, Product Series, and Product Classification
|
Item |
Details |
|---|---|
|
Brand |
Allen-Bradley |
|
Product family |
MP-Series |
|
Product series |
MPL Low-Inertia Brushless Servo Motors |
|
Model number |
|
|
Product category |
Industrial AC rotary servo motor |
|
Motor technology |
Permanent-magnet brushless servo motor |
|
Electrical class |
460 V AC motor configuration |
|
Frame size |
9 |
|
Frame dimension designation |
300 mm (11.81 in.) |
|
Magnet stack length |
152.4 mm (6.00 in.) |
|
Nominal speed designation |
1,000 RPM |
|
Feedback configuration |
High-resolution single-turn encoder |
|
Shaft configuration |
Keyed shaft extension |
|
Connector configuration |
Right-angle SpeedTEC DIN connector, rotatable through 180° |
|
Brake configuration |
No holding brake |
|
Mounting configuration |
IEC metric flange, free mounting holes, Type FF |
|
Typical system role |
Closed-loop industrial motion control |
|
Primary application class |
Automated machinery and precision motion systems |
The model belongs to the low-inertia MPL family, which is intended for applications where responsive motion and accurate control are important. The 460 V configuration and encoder arrangement must be matched to the intended servo drive and control architecture.
The model’s 1,000 RPM designation is the nominal speed classification in its catalog description. It should not be treated as a complete description of its continuous operating envelope, maximum speed, or permissible load. Those limits depend on the applicable motor specifications and drive configuration.
3. Detailed Technical Specifications
The following table separates identified catalog characteristics from information that needs confirmation from the exact motor datasheet or nameplate. This distinction is particularly important when purchasing a replacement motor or calculating machine loads.
|
Parameter |
Specification |
Engineering notes |
|---|---|---|
|
Model |
MPL-B960B-SJ72AA |
Exact catalog designation |
|
Brand |
Allen-Bradley |
Industrial automation equipment |
|
Series |
MPL |
Low-inertia servo motor family |
|
Motor type |
Brushless rotary servo motor |
Designed for operation with a compatible servo drive |
|
Rated voltage class |
460 V AC |
Confirm drive output and supply compatibility |
|
Frame size |
9 |
Catalog frame designation |
|
Frame dimension |
300 mm (11.81 in.) |
Frame-size designation, not the complete motor length |
|
Magnet stack length |
152.4 mm (6.00 in.) |
Active magnet stack designation |
|
Nominal speed |
1,000 RPM |
Catalog speed designation |
|
Encoder |
High-resolution, single-turn |
Position feedback configuration |
|
Feedback type |
Absolute single-turn encoder |
Position within one revolution; system behavior after power cycling depends on the complete feedback and controller setup |
|
Shaft |
Keyed shaft extension |
Requires a compatible coupling or driven component |
|
Connector |
SpeedTEC DIN, right-angle |
Connector orientation is adjustable |
|
Connector rotation |
180° rotatable |
Helps accommodate cable routing |
|
Holding brake |
Not fitted |
A separate mechanical holding solution may be required |
|
Mounting flange |
IEC metric, Type FF |
Verify bolt pattern and shaft alignment |
|
Overall length |
Exact dimension to be verified |
Depends on the detailed mechanical drawing |
|
Overall width and height |
Exact dimension to be verified |
Confirm flange, connector, and shaft clearances |
|
Shaft diameter |
Verify against dimensional drawing |
Essential for coupling selection |
|
Shaft extension length |
Verify against dimensional drawing |
Essential for mechanical fit |
|
Net motor weight |
Not confirmed in kg |
Obtain the exact model’s mechanical data before calculating support loads |
|
Rated continuous torque |
Verify against the exact motor data |
Do not infer a continuous rating from the model number alone |
|
Peak torque |
Verify against the exact motor data |
Depends on permitted operating duration and drive limits |
|
Rated current |
Verify against the exact motor data |
Required for electrical and drive selection |
|
Rated output power |
Verify against the exact motor data |
Must be matched to the correct speed and load conditions |
|
Protection rating |
Verify on the nameplate or technical data |
Important for dust, moisture, and washdown environments |
|
Operating temperature |
Verify in the applicable technical documentation |
Depends on installation and cooling conditions |
3.1 Dimensions and Weight
For mechanical design, the distinction between the motor frame size, magnet stack length, and total installed envelope is essential.
The 300 mm designation identifies the frame-size class, while the 152.4 mm designation identifies the magnet stack length. Neither figure, by itself, represents the motor’s complete installed length.
A machine designer should account for the mounting flange, shaft extension, connector body, cable bend radius, and any coupling or adapter. These features can determine whether a motor fits within an existing machine even when its basic frame designation matches the original unit.
|
Dimensional or mass item |
Value |
|---|---|
|
Frame-size designation |
300 mm (11.81 in.) |
|
Magnet stack length |
152.4 mm (6.00 in.) |
|
Complete motor length |
Requires exact dimensional drawing |
|
Motor body width |
Requires exact dimensional drawing |
|
Motor body height |
Requires exact dimensional drawing |
|
Shaft diameter |
Requires exact dimensional drawing |
|
Shaft extension length |
Requires exact dimensional drawing |
|
Net weight |
Requires confirmation; kg value not established here |
|
Shipping weight |
Not established; may include packaging and accessories |
Weight specification note: A verified weight in kilograms is not available in the information established for this exact catalog configuration. Providing an invented weight would risk incorrect equipment-support calculations. For procurement documents, record the net weight from the manufacturer’s dimensional drawing or the actual unit’s identification label. Do not substitute the shipping weight for the motor’s net weight.
3.2 Electrical and Motion Characteristics
The motor is designed to function as one component of a servo-control system. Its performance depends on more than the motor itself: the selected drive, feedback interface, tuning parameters, load inertia, mechanical transmission, and duty cycle all influence the final result.
|
Characteristic |
Description |
|---|---|
|
Electrical architecture |
AC servo motor supplied through a compatible servo drive |
|
Motion control |
Closed-loop position, velocity, and torque control |
|
Feedback function |
Reports motor position to the control system |
|
Torque generation |
Permanent-magnet synchronous motor principle |
|
Acceleration response |
Influenced by rotor inertia, load inertia, and drive capacity |
|
Positioning accuracy |
Depends on feedback resolution, tuning, transmission, and mechanical rigidity |
|
Speed regulation |
Managed by the servo drive and feedback loop |
|
Thermal performance |
Depends on current, duty cycle, ambient temperature, and installation |
|
Dynamic performance |
Depends on the selected drive and the total mechanical system |
|
Holding under power loss |
No integral holding brake is fitted to this configuration |
These characteristics make the model suitable for controlled industrial movement, provided that the motor and drive are correctly matched and commissioned.
4. Product Introduction and Operating Principle
The MPL-B960B-SJ72AA is intended for applications in which machine movement must be controlled precisely rather than simply switched on and off. Its brushless design and feedback-based operation allow it to work with a compatible servo drive to deliver coordinated rotary motion.
During operation, the controller issues a motion command. The servo drive converts that command into electrical output for the motor, while the feedback system reports the motor’s position. The drive uses the feedback signal to regulate the motor’s response to the command.
This process supports repeatable movement, controlled acceleration, coordinated positioning, and adjustments to speed or torque as operating conditions change.
4.1 Main Functional Features
Low-inertia motion design
Low-inertia servo motors are suited to applications involving frequent starts, stops, direction changes, and acceleration cycles. Lower motor inertia can make dynamic control easier, although the total system response also depends on the connected load and mechanical transmission.
High-resolution feedback
The single-turn encoder provides position feedback within one revolution. This is useful for motion applications where the controller needs detailed information about shaft position. Applications requiring absolute position retention across multiple revolutions should evaluate the complete feedback architecture and the controller’s position-reference strategy before selecting a replacement.
Keyed shaft connection
The keyed shaft provides a mechanical interface for a compatible coupling, pulley, gearbox, or other driven component. The key and coupling must be selected for the actual shaft dimensions, torque, operating speed, and expected mechanical loads.
Flexible connector orientation
The right-angle connector can be rotated through 180°, helping accommodate cable routing in compact machine assemblies. Adequate clearance is still required to prevent excessive cable bending, connector strain, and interference with adjacent equipment.
No integral holding brake
This configuration does not include a holding brake. That can be appropriate for mechanisms that do not need the motor to hold a load mechanically when power is removed. Vertical axes and gravity-loaded mechanisms require a separate assessment of holding and stopping requirements.
5. Product Applications

5.1 Packaging and Filling Equipment
Servo motors are used in indexing tables, cutting mechanisms, film-feeding assemblies, filling systems, and product-positioning units. Controlled acceleration and repeatable positioning help synchronize product movement with packaging operations.
The appropriate motor and drive combination depends on the required cycle rate, acceleration profile, mechanical load, and accuracy requirements.

5.2 Automated Assembly Lines
Assembly machinery may use servo motors to move fixtures, position components, rotate workpieces, or coordinate multiple machine axes.
Repeatable movement can improve process consistency, particularly when a machine performs the same operation across many production cycles.

5.3 Machine Tools and Positioning Systems
Servo motors can drive rotary tables, indexing mechanisms, feed axes, and auxiliary positioning systems. Actual suitability depends on torque requirements, shaft loading, operating speed, and the precision required by the machine.

5.4 Material Handling Equipment
Transfer units, sorting mechanisms, automated handling stations, and indexing conveyors may use servo motors to control movement and synchronize equipment.
Gearboxes, belts, pulleys, and couplings must be sized for the load and the motor’s permitted radial and axial shaft forces.

5.5 Printing, Labeling, and Converting Machinery
Servo-controlled rollers, web-feeding assemblies, cutting units, and registration mechanisms benefit from coordinated speed and position control. The motor can be integrated into a larger motion system that synchronizes several machine operations.
5.6 Additional Potential Applications
Other possible applications include automated inspection equipment, rotary indexing stations, industrial test rigs, specialized production machinery, and synchronized mechanical transfer systems.
The suitability of this particular model should always be determined by the required torque, speed, inertia, duty cycle, environment, and electrical compatibility. An application being technically suitable for the MPL family does not automatically mean that this specific model has sufficient capacity for the load.
6. Main Product Advantages
|
Advantage |
Practical benefit |
Important consideration |
|---|---|---|
|
Brushless motor construction |
Supports controlled industrial operation without conventional brush wear |
Bearings and other mechanical components still require maintenance |
|
Low-inertia design |
Can support rapid acceleration and deceleration |
Total load inertia remains a major design factor |
|
High-resolution feedback |
Provides detailed shaft-position information |
Resolution does not guarantee system-level accuracy |
|
Closed-loop control |
Helps regulate position and speed against changing loads |
Requires a compatible drive and correct tuning |
|
Keyed shaft |
Provides a conventional mechanical coupling interface |
Shaft dimensions and key specifications must match |
|
Rotatable connector |
Provides flexibility when arranging motor cables |
Cable clearance and bend radius must be respected |
|
Established industrial motor family |
Can be suitable for integration into existing motion-control machinery |
Compatibility must be checked against the installed drive and firmware |
|
No integral brake |
Avoids an unnecessary brake component where mechanical holding is not required |
Gravity-loaded axes may need a separate holding mechanism |
|
Multiple related configurations |
Offers alternatives for different speed, feedback, and brake requirements |
Catalog variants are not necessarily direct replacements |
6.1 Motion Performance
A servo motor’s practical value lies in how well it controls a mechanical load. When correctly sized and commissioned, a suitable servo system can provide repeatable movement, controlled stopping, and predictable response during changes in commanded speed or position.
For machines with frequent motion cycles, these characteristics can help reduce positioning variation and improve coordination between mechanical stations.
6.2 Integration Flexibility
The keyed shaft, metric mounting arrangement, and rotatable connector provide useful mechanical integration options. These details may simplify installation in equipment designed around a compatible motor configuration.
However, an existing mounting arrangement should be checked against the complete dimensional drawing. A matching frame designation alone is insufficient to guarantee a drop-in replacement.
6.3 Maintenance Considerations
Brushless construction eliminates routine brush replacement, but it does not make the motor maintenance-free. Bearing condition, connector integrity, cable routing, shaft alignment, contamination, vibration, and temperature remain important inspection points.
In a production environment, maintaining correct motor alignment and avoiding excessive shaft loads can help reduce mechanical wear and unexpected downtime.
7. Five Recommended Models from the Same MPL Series
The following five models are related MPL low-inertia servo motor configurations. They are useful comparison candidates when evaluating speed, feedback, motor length, or brake requirements.
The specifications below distinguish catalog characteristics from values that still require verification. Dimensions and weights are particularly important for replacement projects, so unconfirmed measurements are not presented as exact engineering values.
|
Model |
Voltage |
Frame size |
Stack length |
Speed |
Feedback |
Brake |
Overall dimensions |
Weight (kg) |
|---|---|---|---|---|---|---|---|---|
|
MPL-B960B-MJ72AA |
460 V |
9 / 300 mm |
152.4 mm |
1,000 RPM |
High-resolution multi-turn |
No |
Drawing required |
Not verified |
|
MPL-B960B-MJ74AA |
460 V |
9 / 300 mm |
152.4 mm |
1,000 RPM |
High-resolution multi-turn |
24 V DC |
Drawing required |
Not verified |
|
MPL-B960C-MJ72AA |
460 V |
9 / 300 mm |
152.4 mm |
1,500 RPM |
High-resolution multi-turn |
No |
Drawing required |
Not verified |
|
MPL-B960D-MJ72AA |
460 V |
9 / 300 mm |
152.4 mm |
2,000 RPM |
High-resolution multi-turn |
No |
Drawing required |
Not verified |
|
MPL-B980B-MJ72AA |
460 V |
9 / 300 mm |
203.2 mm |
1,000 RPM |
High-resolution multi-turn |
No |
Drawing required |
Not verified |
The frame and stack values are catalog designations, not complete external dimensions. The exact weight in kg must be confirmed from the mechanical data for each complete catalog number.
7.1 MPL-B960B-MJ72AA
This model shares the B960B motor configuration and nominal speed classification with the main model. Its principal difference is the multi-turn feedback configuration.
Multi-turn feedback can be useful when an application must account for position across multiple shaft revolutions. The actual handling of absolute position after power interruption depends on the encoder, drive, and controller arrangement.
Recommended for: Equipment where multi-turn feedback is required and an integral brake is not needed.
7.2 MPL-B960B-MJ74AA
This model combines the B960B configuration with a 24 V DC holding brake. A holding brake can help secure a stationary axis when the motor is not energized, subject to the brake’s specified operating conditions.
A holding brake should not automatically be treated as a dynamic emergency stopping device. Its permitted engagement conditions and holding capacity must be evaluated separately.
Recommended for: Suitable axes where a compatible holding-brake function is required.
7.3 MPL-B960C-MJ72AA
The B960C variant has a 1,500 RPM catalog speed classification. This makes it a candidate for applications that need a different speed-performance balance from the B960B configuration.
A higher nominal speed designation does not by itself establish that the motor will deliver greater torque at every operating point. The load profile and the complete torque-speed characteristics should be reviewed.
Recommended for: Applications requiring a higher nominal speed while retaining the same general frame and stack-length class.
7.4 MPL-B960D-MJ72AA
The B960D variant has a 2,000 RPM catalog speed classification. It may be worth evaluating for faster rotary positioning, higher-speed machine cycles, or applications with different motion profiles.
The drive’s permitted operating range, acceleration requirements, and mechanical transmission limits must be checked before selecting this variant.
Recommended for: Applications where the required speed range favors the D configuration.
7.5 MPL-B980B-MJ72AA
The B980B variant retains the general 300 mm frame designation but uses a 203.2 mm magnet stack, compared with 152.4 mm for the B960B configuration.
The longer stack changes the motor’s physical envelope and may affect its torque and electrical characteristics. It should therefore be evaluated as a distinct motor configuration rather than as a mechanically identical substitute.
Recommended for: Applications where the B980B performance characteristics are appropriate and the additional motor length can be accommodated.
8. Five Additional Popular Allen-Bradley Models
The following table provides five additional model candidates from the same broad industrial motion-control brand. The selections cover related MPL configurations and other MP-Series motor families.
These are comparison candidates, not a verified sales ranking. They should not be assumed to have identical electrical, mechanical, or feedback compatibility.
|
Model |
Product family |
Voltage class |
Frame size |
Stack length |
Speed classification |
Feedback / configuration |
Brake |
Overall dimensions |
Weight (kg) |
|---|---|---|---|---|---|---|---|---|---|
|
MPL-B880D-SJ72AA |
MPL |
460 V |
8 / 265 mm |
203.2 mm |
2,000 RPM |
Single-turn, high-resolution |
No |
Drawing required |
Not verified |
|
MPL-B960C-MJ72AA |
MPL |
460 V |
9 / 300 mm |
152.4 mm |
1,500 RPM |
Multi-turn, high-resolution |
No |
Drawing required |
Not verified |
|
MPL-B960D-MJ72AA |
MPL |
460 V |
9 / 300 mm |
152.4 mm |
2,000 RPM |
Multi-turn, high-resolution |
No |
Drawing required |
Not verified |
|
MPL-B980B-MJ72AA |
MPL |
460 V |
9 / 300 mm |
203.2 mm |
1,000 RPM |
Multi-turn, high-resolution |
No |
Drawing required |
Not verified |
|
MPF-B540K-SJ72AA |
MPF |
Verify exact configuration |
Verify drawing |
Verify drawing |
Verify exact catalog data |
Verify feedback configuration |
Verify exact catalog data |
Drawing required |
Not verified |
The first four models are identified MPL configurations. The MPF model is an additional family-level comparison candidate; its full electrical and mechanical specifications should be confirmed before procurement. No exact weight figures are supplied where the corresponding data has not been established.
8.1 MPL-B880D-SJ72AA
The B880D configuration is a frame-size-8 MPL motor with a 203.2 mm stack designation and a 2,000 RPM nominal speed classification.
It may be worth evaluating for a system whose required frame and motor characteristics differ from the B960B. Its smaller frame designation means that mounting and shaft compatibility must be checked carefully.
8.2 MPL-B960C-MJ72AA
This is a useful comparison for applications requiring the B960 frame class with a 1,500 RPM speed classification and multi-turn feedback.
It is not automatically interchangeable with the B960B-SJ72AA because the feedback configuration and motor characteristics differ.
8.3 MPL-B960D-MJ72AA
This configuration offers the B960 frame class with a 2,000 RPM speed classification and multi-turn feedback.
It is worth considering when the application calls for a higher nominal speed, provided the load, drive, mechanical system, and required torque characteristics are compatible.
8.4 MPL-B980B-MJ72AA
The B980B configuration has a longer magnet stack than the B960B. It may be suitable for a different performance requirement, but its additional length can affect the machine’s installation envelope.
A full dimensional comparison is recommended before selecting it for a retrofit.
8.5 MPF-B540K-SJ72AA
This model is included as a broader family comparison rather than a confirmed direct substitute. Before considering it, verify that the exact catalog designation exists in the required configuration and obtain its voltage, speed, feedback, shaft, connector, brake, dimensions, and weight specifications.
For a replacement project, staying within the same MPL configuration family is generally a more straightforward starting point than switching to another motor family.
9. Comparison of the Recommended Models
The following comparison summarizes the main reasons to evaluate each of the five closely related MPL models.
|
Model |
Main difference from the reference model |
Potential selection reason |
Main item to verify |
|---|---|---|---|
|
MPL-B960B-MJ72AA |
Multi-turn feedback |
Application requires multi-turn position feedback |
Encoder and controller compatibility |
|
MPL-B960B-MJ74AA |
Multi-turn feedback and holding brake |
Holding-brake function is required |
Brake wiring, control, and mechanical holding requirements |
|
MPL-B960C-MJ72AA |
1,500 RPM classification |
Different nominal speed requirement |
Torque-speed curve and drive limits |
|
MPL-B960D-MJ72AA |
2,000 RPM classification |
Higher nominal speed requirement |
Maximum permitted speed and load inertia |
|
MPL-B980B-MJ72AA |
Longer magnet stack |
Different motor-performance requirement |
Overall length, mounting clearance, and drive compatibility |
10. How to Select the Right Model
Choosing a servo motor based solely on its catalog number or nominal speed can lead to an unsuitable installation. The motor, drive, feedback system, and mechanical load should be evaluated together.
10.1 Check the Voltage and Servo Drive
Confirm that the existing drive supports the required motor configuration and voltage class. Matching the nominal voltage alone does not establish full compatibility.
Check the motor-drive combination, feedback interface, permitted current, motor identification settings, and controller requirements.
10.2 Compare Torque and Speed
Determine the required continuous torque, peak torque, operating speed, acceleration, deceleration, and duty cycle.
A motor that reaches the desired speed may still be unsuitable if it cannot deliver the required torque throughout the operating range.
10.3 Verify Feedback Compatibility
The reference model uses high-resolution single-turn feedback. A multi-turn alternative may offer a different position-feedback arrangement, but the drive must support the selected encoder type and protocol.
Do not assume that two motors with similar catalog numbers can use the same feedback settings without reconfiguration.
10.4 Confirm Mechanical Dimensions
Before ordering, verify:
-
Mounting flange dimensions and bolt pattern.
-
Shaft diameter and shaft extension length.
-
Key and coupling dimensions.
-
Complete motor length and body envelope.
-
Connector orientation and cable clearance.
-
Permitted radial and axial shaft loads.
-
Net motor weight in kilograms.
For a retrofit, compare the replacement motor’s dimensional drawing with the original motor’s actual installation measurements. Frame size alone is insufficient.
10.5 Determine Whether a Brake Is Necessary
Applications with vertical loads, gravity-driven movement, or a need for stationary holding require a dedicated safety and holding assessment.
The reference model has no integral holding brake. If a brake-equipped variant is considered, verify its electrical requirements, holding capacity, release behavior, and compatibility with the control system.
10.6 Review Environmental and Maintenance Requirements
Consider ambient temperature, dust, moisture, vibration, cable condition, connector access, and available maintenance space.
For demanding environments, verify the exact enclosure rating rather than assuming that all motors in the same series have identical protection characteristics.
11. Final Product Summary
The Allen-Bradley MPL-B960B-SJ72AA is a 460 V-class, low-inertia brushless rotary servo motor in the MPL series. Its key identified characteristics are the 300 mm frame designation, 152.4 mm magnet stack length, 1,000 RPM catalog speed classification, high-resolution single-turn feedback, keyed shaft extension, rotatable right-angle connector, and absence of an integral holding brake.
Its primary role is controlled industrial motion, particularly where the machine requires repeatable rotary movement and integration with a compatible servo drive.
The most relevant alternatives are the B960B multi-turn configurations, the B960C and B960D speed variants, and the longer-stack B980B configuration. The appropriate choice depends on feedback requirements, torque-speed performance, brake requirements, mechanical dimensions, and drive compatibility.
Important procurement note: The complete external dimensions and verified net weight in kg have not been established for every listed catalog number. These values should be obtained from the exact model’s dimensional documentation before finalizing a quotation, replacement order, or machine design. This is especially important where mounting fit, lifting arrangements, structural support, or shipping calculations depend on accurate measurements.