

ProductPRODUCT
Featured products
Contact Us
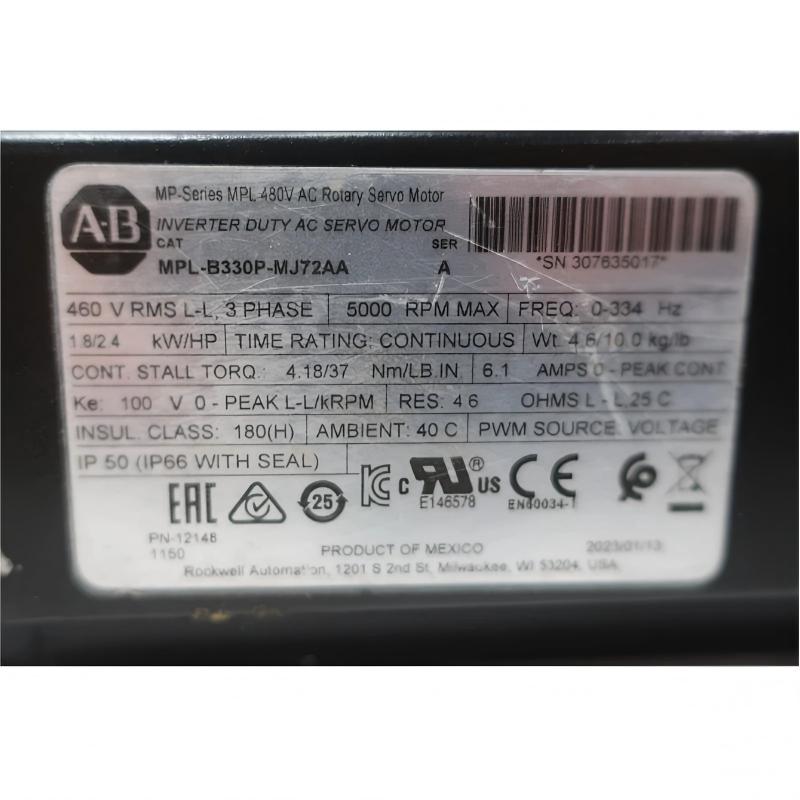
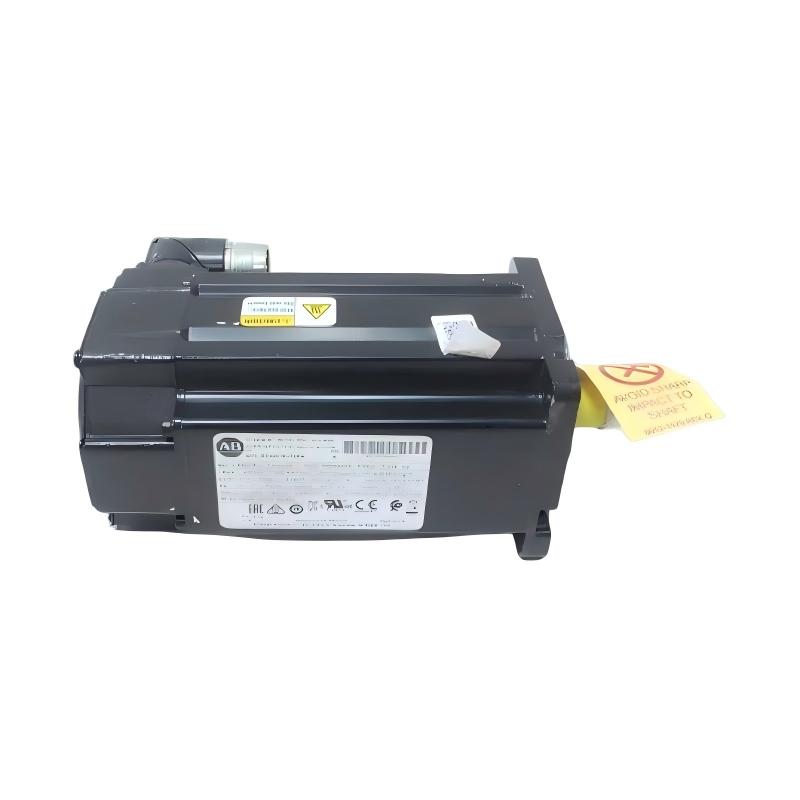
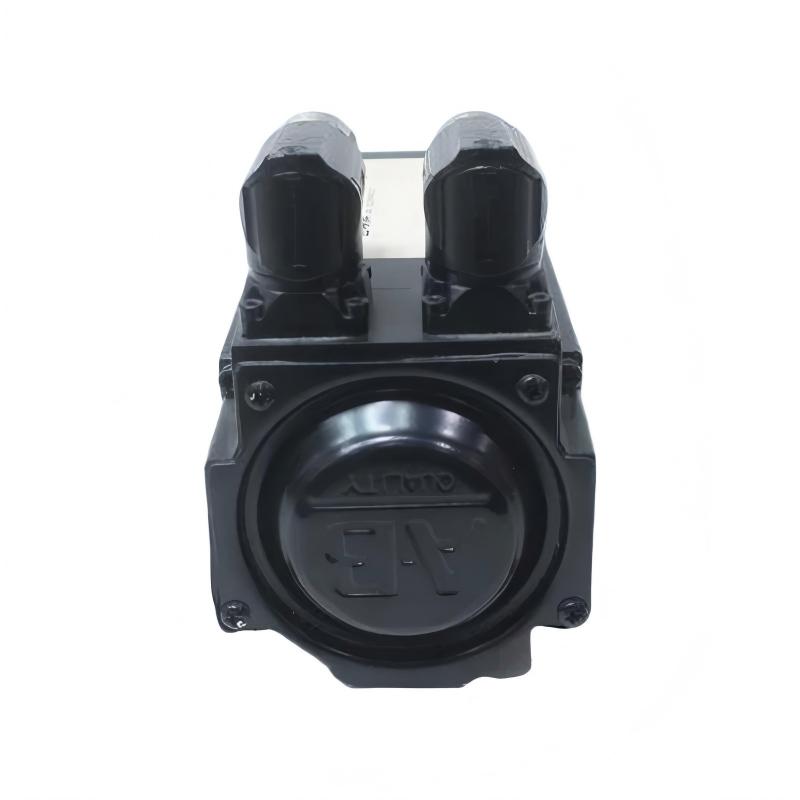
- Allen Bradley
- MPL-B330P-MJ72AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 63 mm × 63 mm × 150 mm
- 4.82kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 40
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
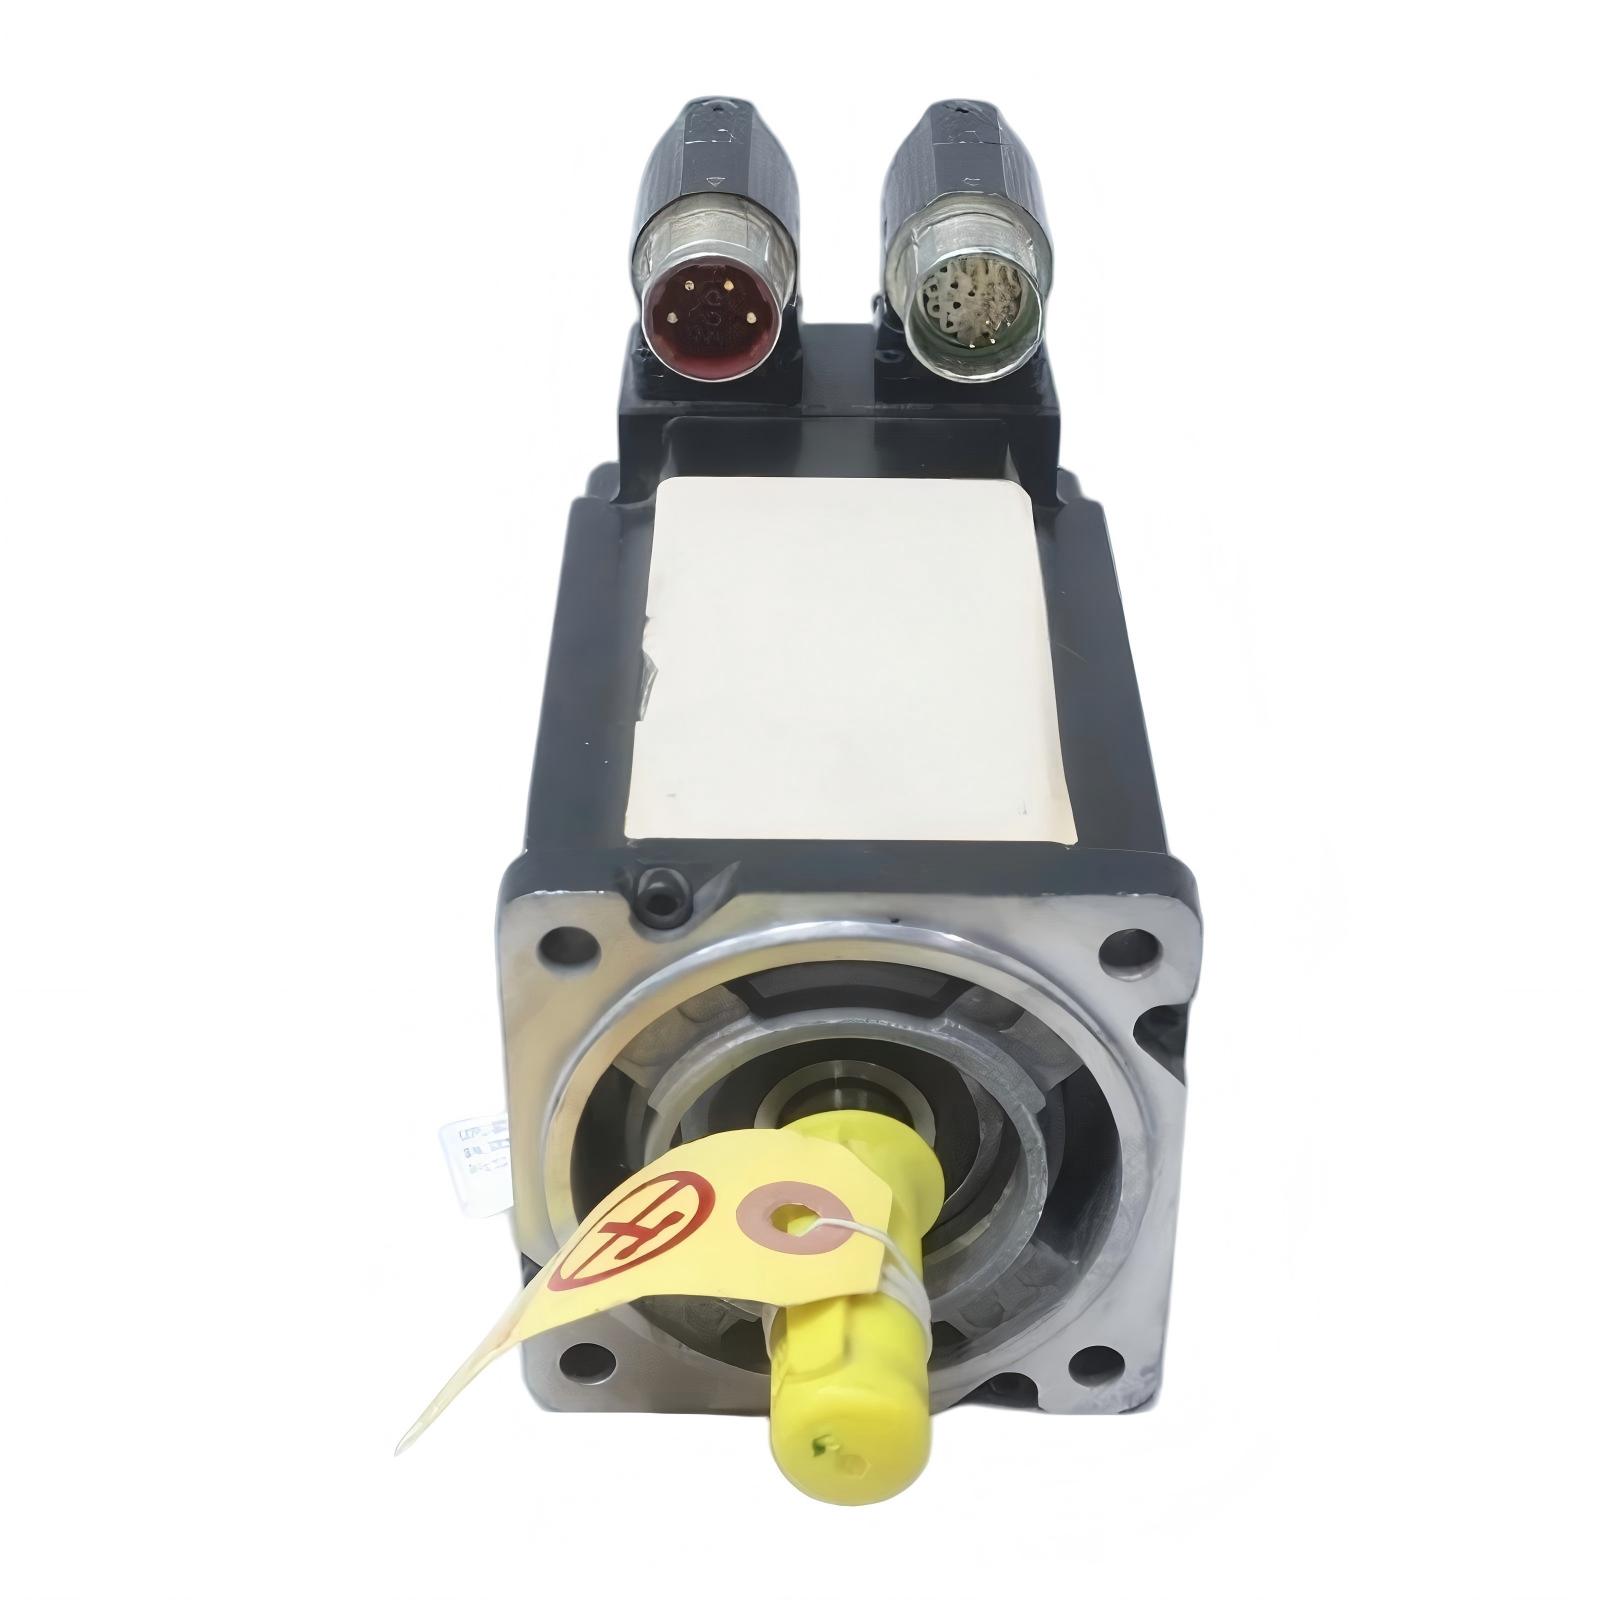
Allen-Bradley MPL-B330P-MJ72AA Servo Motor
1. Product Overview
The MPL-B330P-MJ72AA is a low-inertia brushless permanent-magnet AC rotary servo motor from the MP-Series MPL family.
It is designed for industrial motion-control systems that require accurate positioning, high rotational speed, rapid acceleration and deceleration, repeatable indexing, and stable closed-loop operation.
The motor is rated for 5000 rpm and provides approximately 4.18 N·m of continuous torque with approximately 1.8 kW of continuous rated power.
The motor uses a 100 mm frame size and a 76.2 mm magnetic stack length, giving it a compact mechanical format relative to its speed and torque capability.
The MPL-B330P-MJ72AA uses a multi-turn high-resolution absolute encoder for motor feedback. The encoder provides position information to the servo control system and allows the motor to operate as part of a closed-loop positioning system.
The motor has a keyed shaft extension, a right-angle SpeedTEC DIN connector that can be rotated through 180 degrees, and no integral holding brake.
Its mechanical mounting arrangement uses IEC metric mounting with free mounting holes, making it suitable for a broad range of industrial machine structures.
The motor is primarily intended for dynamic motion rather than simple constant-speed operation. It is therefore well suited to machines that repeatedly accelerate, decelerate, stop, reverse, index, and reposition.
2. Brand and Product Classification
| Item | Specification |
|---|---|
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Brushless Servo Motors |
| Model | MPL-B330P-MJ72AA |
| Product Type | Rotary Servo Motor |
| Motor Technology | Brushless Permanent-Magnet AC Servo |
| Voltage Class | 400 V AC |
| Armature Voltage | 460 V |
| Rated Speed | 5000 rpm |
| Continuous Rated Power | Approximately 1.8 kW |
| Continuous Torque | Approximately 4.18 N·m |
| Peak Torque | Approximately 11.1 N·m |
| Frame Size | 100 mm |
| Magnetic Stack Length | 76.2 mm / 3.0 in |
| Feedback | Multi-turn High-Resolution Absolute Encoder |
| Shaft | Keyed Shaft Extension |
| Brake | No Integral Brake |
| Connector | SpeedTEC DIN |
| Connector Style | Right Angle, 180° Rotatable |
| Mounting | IEC Metric |
| Mounting Holes | Free Mounting Holes, Type FF |
| Shaft Seal | No Shaft Seal |
| Rotor Design | Low Inertia |
3. Detailed Technical Parameters
| Parameter | MPL-B330P-MJ72AA |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Servo |
| Motor Type | Brushless Permanent-Magnet AC Servo Motor |
| Voltage Class | 400 V AC |
| Armature Voltage | 460 V |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Continuous Rated Power | Approximately 1.8 kW |
| Continuous Stall Torque | Approximately 4.18 N·m |
| Peak Stall Torque | Approximately 11.1 N·m |
| Rotor Inertia | Approximately 0.00012 kg·m² |
| Feedback | Multi-turn Absolute Encoder |
| Encoder Resolution | 1024 sin/cos cycles per revolution |
| Feedback Protocol | Hiperface-type feedback |
| Shaft Configuration | Keyed Shaft Extension |
| Shaft Seal | No Shaft Seal |
| Integral Brake | No |
| Connector | SpeedTEC DIN |
| Connector Orientation | Right Angle |
| Connector Rotation | 180° Rotatable |
| Frame Size | 100 mm |
| Frame Classification | Frame 3 |
| Magnetic Stack | 76.2 mm |
| Magnetic Stack | 3.0 in |
| Mounting | IEC Metric Flange |
| Mounting Holes | Type FF, Free Mounting Holes |
| Approximate Weight | Approximately 4.82 kg |
| Overall Envelope | Configuration-dependent; verify mechanical drawing |
| Motor Construction | Low-Inertia Brushless |
| Intended Control | Closed-Loop Servo Control |
4. Dimensions and Weight
The MPL-B330P-MJ72AA uses a 100 mm frame with a 76.2 mm magnetic stack.
The 100 mm frame dimension is one of the most important mechanical characteristics when determining whether the motor can fit an existing machine.
The magnetic stack is 76.2 mm, or 3.0 inches.
The motor’s complete envelope also includes the front mounting flange, keyed shaft extension, rear housing, and connector assembly. The exact overall motor length should therefore be checked against the applicable mechanical drawing before installation or replacement.
The approximate product weight is 4.82 kg.
| Mechanical Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Frame Size | 100 mm |
| Frame Classification | Frame 3 |
| Frame Width Class | 100 mm / 3.94 in |
| Magnetic Stack Length | 76.2 mm |
| Magnetic Stack Length | 3.0 in |
| Mounting Standard | IEC Metric |
| Mounting Hole Type | Type FF |
| Shaft Type | Keyed |
| Shaft Seal | None |
| Connector Position | Right-angle connector arrangement |
| Connector Rotation | 180° |
| Approximate Weight | 4.82 kg |
| Overall Length | Configuration-dependent |
| Shaft Diameter | Verify mechanical drawing |
| Shaft Extension | Keyed configuration; verify detailed drawing |
| Flange Dimensions | 100 mm frame class; verify detailed mounting drawing |
For replacement applications, the 100 mm frame alone should not be treated as proof of interchangeability. The shaft, encoder, connector, stack length, brake configuration, and drive compatibility must also match.
5. Electrical Characteristics
The MPL-B330P-MJ72AA is a 400 V-class servo motor intended for use with compatible high-voltage servo-drive systems.
Its armature voltage is specified at approximately 460 V.
Unlike a conventional induction motor, this servo motor is intended to operate through a servo amplifier or compatible motion-control drive.
The drive regulates motor current and uses encoder feedback to control torque, velocity, and position.
| Electrical Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Voltage Class | 400 V AC |
| Armature Voltage | 460 V |
| Motor Type | Permanent-Magnet AC Servo |
| Rated Power | Approx. 1.8 kW |
| Rated Speed | 5000 rpm |
| Continuous Torque | Approx. 4.18 N·m |
| Peak Torque | Approx. 11.1 N·m |
| Feedback | Multi-turn absolute encoder |
| Brake | No integral brake |
| Control | Closed-loop servo |
| Rotor Type | Low inertia |
The actual current drawn by the motor depends on operating torque, acceleration, load, duty cycle, and servo-drive configuration.
6. Torque and Speed Performance
The MPL-B330P-MJ72AA combines a 5000 rpm rated speed with approximately 4.18 N·m continuous torque.
Its peak torque capability is approximately 11.1 N·m, allowing the motor to handle short-duration acceleration and dynamic load requirements when operated within the appropriate servo-drive and thermal limits.
This combination makes the motor suitable for machines where rapid movement is required without moving to a substantially larger motor frame.
| Performance Parameter | Value |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Continuous Torque | Approx. 4.18 N·m |
| Peak Torque | Approx. 11.1 N·m |
| Rated Power | Approx. 1.8 kW |
| Rotor Inertia | Approx. 0.00012 kg·m² |
| Dynamic Response | High |
| Motion Type | Position, velocity and torque control |
| Application Class | High-cycle industrial automation |
The peak torque figure should not be treated as a continuous operating torque. Peak torque is normally associated with acceleration, deceleration, transient load conditions, or short-duration motion requirements.
7. Low-Inertia Rotor Design
The MPL-B330P-MJ72AA belongs to the MPL low-inertia motor family.
Low rotor inertia is especially valuable in applications with frequent changes in speed.
When the motor has relatively low rotating inertia, less torque is required to accelerate the rotor itself. More of the available motor torque can therefore be used to accelerate the external machine load.
This is useful for indexing systems, pick-and-place equipment, packaging machines, high-speed assembly equipment, and other machines that perform repetitive movements.
The approximately 0.00012 kg·m² rotor inertia places this motor within the low-inertia performance category of the MPL family.
8. Encoder and Feedback System
The MPL-B330P-MJ72AA uses a multi-turn high-resolution absolute encoder.
The encoder is an important part of the servo system because it provides feedback about the actual motor position.
The multi-turn function allows the feedback system to track motor movement across multiple revolutions.
The encoder uses high-resolution sinusoidal feedback and is associated with a Hiperface-type communication protocol.
| Feedback Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Feedback Type | Absolute Multi-turn |
| Encoder Class | High Resolution |
| Encoder Resolution | 1024 sin/cos cycles/revolution |
| Feedback Protocol | Hiperface-type |
| Position Feedback | Yes |
| Speed Feedback | Yes |
| Closed-Loop Operation | Yes |
| Primary Function | Position and velocity feedback |
This feedback arrangement makes the motor suitable for applications where accurate position control and repeatability are important.
9. Shaft Configuration
The MPL-B330P-MJ72AA has a keyed shaft extension.
The keyed shaft provides a mechanical interface for compatible couplings, pulleys, gearboxes, sprockets, and other transmission components.
The shaft configuration should be matched carefully when replacing an existing motor.
A mechanically similar motor with a different shaft configuration may require a different coupling or mechanical adapter.
The motor does not include a shaft seal. For machinery exposed to dust, oil, coolant, moisture, or washdown conditions, the complete machine sealing arrangement should therefore be evaluated.
10. Connector Configuration
The MPL-B330P-MJ72AA uses a SpeedTEC DIN connector in a right-angle configuration.
The connector can be rotated through approximately 180 degrees.
This feature is useful when the motor is installed in a confined machine enclosure.
Instead of requiring a fixed cable direction, the connector can be positioned to better suit the machine’s cable routing arrangement.
| Connector Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Connector Type | SpeedTEC DIN |
| Connector Configuration | Right Angle |
| Connector Rotation | 180° |
| Connection Type | Quick Connect |
| Cable Routing | Flexible orientation |
| Installation Benefit | Easier cable routing in confined spaces |
| Maintenance Consideration | Connector should remain clean and securely locked |
The connector should not be subjected to excessive cable pulling force or sharp cable bends.
11. Brake Configuration
The MPL-B330P-MJ72AA is supplied without an integral brake.
This is an important characteristic when selecting the motor for vertical axes.
A vertical load may continue moving when motor torque is removed. If the machine requires the motor to mechanically hold the load when power is removed, an appropriate external holding mechanism or a motor configuration with an integral brake should be considered.
For horizontal axes or applications where a separate mechanical holding mechanism already exists, the absence of an integral brake may simplify the motor configuration.
| Brake Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Integral Brake | No |
| Brake Voltage | Not applicable |
| Holding Brake | Not included |
| Vertical Axis | Requires separate load-holding consideration |
| Emergency Stop | Machine-level safety system required |
12. Mounting Configuration
The motor uses an IEC metric flange mounting arrangement.
The mounting holes are identified as Type FF free mounting holes.
The mounting structure should be sufficiently rigid to maintain motor alignment under acceleration and deceleration loads.
Incorrect mounting alignment can cause excessive coupling forces, vibration, bearing loading, and positioning errors.
| Mounting Parameter | Specification |
|---|---|
| Model | MPL-B330P-MJ72AA |
| Mounting Type | Flange Mount |
| Standard | IEC Metric |
| Mounting Hole Type | Type FF |
| Frame Size | 100 mm |
| Shaft | Keyed |
| Installation Orientation | Machine-dependent |
| Mounting Requirement | Rigid and accurately aligned |
13. Typical Industrial Applications
Packaging Machinery
The MPL-B330P-MJ72AA is well suited to packaging equipment requiring fast and repeatable motion.
Typical applications include product indexing, film feeding, cutting mechanisms, sealing mechanisms, conveyor synchronization, label positioning, and rotary indexing.
The combination of 5000 rpm speed and low rotor inertia is useful for machines that operate through repeated high-speed cycles.
Material Handling
Material-handling systems can use servo motors for precise positioning and controlled acceleration.
Typical applications include conveyor indexing, transfer units, pick-and-place mechanisms, positioning tables, automated feeders, and controlled rotary mechanisms.
The absolute encoder provides feedback required for accurate servo positioning.
Electronic Assembly
Electronic assembly machinery often requires accurate and repeatable positioning.
The MPL-B330P-MJ72AA can be used for positioning axes, feeder mechanisms, indexing mechanisms, assembly heads, and transfer systems.
The low-inertia rotor supports quick movement between successive machine positions.
Machine Tools
The motor can be used for suitable machine-tool positioning and auxiliary axes.
Its suitability depends on the required torque, speed, load inertia, duty cycle, mechanical transmission, and control architecture.
Printing and Converting
Printing and converting equipment often requires synchronized movement between multiple machine sections.
Servo motors can provide controlled speed, position, and acceleration for rollers, feeders, indexing mechanisms, and other rotary or linear motion systems.
The 5000 rpm operating class provides useful speed capability for selected high-cycle applications.
Robotics and Automated Mechanisms
The motor can be used in selected robotic or automated mechanisms where its torque, speed, feedback, and mechanical configuration are appropriate.
The motor’s multi-turn feedback is useful for motion systems that require accurate tracking of rotational position.
14. Application Advantages
| Application Requirement | MPL-B330P-MJ72AA Characteristic |
|---|---|
| High-speed motion | 5000 rpm rated speed |
| Rapid acceleration | Low rotor inertia |
| Accurate position control | Multi-turn absolute encoder |
| Repetitive indexing | Closed-loop servo control |
| Compact machine installation | 100 mm frame |
| Moderate power requirement | Approx. 1.8 kW |
| Mechanical coupling | Keyed shaft |
| Flexible cable routing | 180° rotatable connector |
| Metric machine construction | IEC metric mounting |
| High-cycle operation | Brushless servo design |
15. Main Product Advantages
High-Speed 5000 rpm Operation
The 5000 rpm rating makes the MPL-B330P-MJ72AA suitable for machinery where rapid rotary movement is required.
High rotational speed can help reduce cycle time when the machine transmission and load are designed appropriately.
Low-Inertia Performance
The low-inertia rotor helps the motor respond quickly to changes in commanded speed.
This is particularly valuable for machines with frequent acceleration and deceleration.
Absolute Multi-Turn Feedback
The multi-turn absolute encoder provides detailed motor-position information to the servo controller.
This supports accurate positioning and repeatable motion.
Compact 100 mm Frame
The 100 mm frame provides a relatively compact mechanical package for a motor with approximately 1.8 kW of rated power and 4.18 N·m continuous torque.
This can be useful when machine space is limited.
Keyed Shaft
The keyed shaft provides a conventional mechanical interface and can simplify integration with compatible couplings and transmission components.
Rotatable Right-Angle Connector
The 180° rotatable right-angle connector provides additional flexibility during machine installation.
This can be especially useful in compact machine cabinets or assemblies where cable clearance is limited.
No Integral Brake
The absence of an integral brake can be appropriate for horizontal axes and applications that use a separate mechanical holding method.
It also differentiates the MJ72AA configuration from related braked motor configurations.
16. Thermal and Environmental Considerations
Servo motor temperature depends on continuous torque, acceleration profile, ambient temperature, installation conditions, and machine duty cycle.
A motor operating at high speed with frequent acceleration may experience different thermal behavior from the same motor operating at a steady speed.
The motor should therefore be evaluated according to the actual machine duty cycle rather than only its nominal power rating.
Adequate heat dissipation around the motor housing should be maintained.
The motor should also be protected from environmental conditions outside its intended operating range.
Because this configuration has no shaft seal, applications involving direct exposure to liquids or contaminated environments require particular attention to machine enclosure and sealing arrangements.
17. Installation Considerations
Before installation, verify the following:
- Servo-drive compatibility.
- Motor voltage class.
- Encoder and feedback compatibility.
- Motor frame size.
- Magnetic stack length.
- Mounting hole arrangement.
- Shaft diameter and extension.
- Keyway configuration.
- Coupling compatibility.
- Connector clearance.
- Cable compatibility.
- Load inertia.
- Continuous torque requirement.
- Peak torque requirement.
- Acceleration and deceleration profile.
- Duty cycle.
- Machine safety requirements.
The motor should be mounted on a rigid surface.
The coupling should be aligned carefully.
Excessive shaft misalignment can produce additional bearing loads and may reduce machine accuracy.
18. Load and Inertia Matching
Servo motor selection should consider the relationship between motor inertia and reflected load inertia.
A motor can have sufficient rated torque while still being unsuitable for a particular application if the load inertia is excessive.
The transmission ratio can have a significant effect on reflected load inertia.
For applications with frequent acceleration and deceleration, the acceleration torque should be evaluated in addition to the continuous running torque.
The peak torque rating should also be used carefully. Peak torque is intended for short-duration dynamic requirements and should not be treated as the normal continuous operating point.
19. Maintenance
Routine maintenance should include inspection of the motor housing, mounting hardware, coupling, shaft, cables, connectors, and machine structure.
The motor should be checked for abnormal vibration or unusual operating noise.
Changes in vibration may indicate coupling misalignment, mechanical looseness, bearing problems, or load-related issues.
The connector should be checked for secure engagement and signs of contamination.
Servo-drive alarms should be reviewed if the machine develops unexpected positioning errors, overcurrent conditions, following errors, or abnormal acceleration behavior.
The motor’s thermal condition should also be monitored in demanding high-cycle applications.
20. Replacement Considerations
When replacing another motor with the MPL-B330P-MJ72AA, the complete catalog number should be compared.
A motor with the same MPL-B330P designation may still have a different feedback system, shaft arrangement, connector configuration, or brake option.
The MJ72AA configuration is particularly important because it combines a multi-turn absolute encoder, keyed shaft, right-angle rotatable SpeedTEC DIN connector, and no integral brake.
Therefore, replacement selection should consider both the motor’s electrical performance and its mechanical configuration.
21. Five Related or Same-Series Models
The following models are useful for comparison within the MPL family or closely related MP-Series servo-motor range.
| Model | Series | Voltage Class | Rated Speed | Continuous Torque | Rated Power | Feedback | Frame / Stack | Brake | Weight |
|---|---|---|---|---|---|---|---|---|---|
| MPL-B310P-MJ72AA | MPL Low-Inertia | 400 V AC | 5000 rpm | Approx. 1.58 N·m | Approx. 0.77 kW | Multi-turn configuration | Smaller frame class | No | Approx. 2.7 kg |
| MPL-B320P-MJ72AA | MPL Low-Inertia | 400 V AC | 5000 rpm | Approx. 3.05 N·m | Approx. 1.5 kW | Multi-turn configuration | Approx. 80 mm class | No | Approx. 3.7 kg |
| MPL-B330P-MJ72AA | MPL Low-Inertia | 400 V AC | 5000 rpm | Approx. 4.18 N·m | Approx. 1.8 kW | Multi-turn absolute | 100 mm / 76.2 mm | No | Approx. 4.82 kg |
| MPL-B420P-MJ72AA | MPL Low-Inertia | 400 V AC | 5000 rpm | Approx. 4.74 N·m | Approx. 1.9 kW | Multi-turn configuration | 100 mm class | No | Approx. 4.3 kg |
| MPL-B430P-MJ72AA | MPL Low-Inertia | 400 V AC | 5000 rpm | Approx. 6.55 N·m | Approx. 2.2 kW | Multi-turn configuration | Approx. 115 mm class | No | Approx. 5.5 kg |
The MPL-B310P is suitable for lower torque requirements and provides a smaller overall motor package.
The MPL-B320P provides a higher torque level while maintaining the 5000 rpm speed class.
The MPL-B330P-MJ72AA provides approximately 4.18 N·m of continuous torque in a 100 mm frame.
The MPL-B420P provides slightly higher continuous torque and can be considered when the B330P torque range is insufficient.
The MPL-B430P provides a higher torque capability and is suitable for applications requiring additional motor capacity.
22. Five Same-Brand Popular Models for Comparison
The following models provide a useful comparison range within the same brand’s industrial servo-motor portfolio.
| Model | Product Type | Voltage Class | Rated Speed | Continuous Torque | Rated Power | Feedback | Dimensions / Frame | Weight |
|---|---|---|---|---|---|---|---|---|
| MPL-B320P-MJ72AA | Low-Inertia Servo Motor | 400 V AC | 5000 rpm | Approx. 3.05 N·m | Approx. 1.5 kW | Multi-turn | Approx. 80 mm class | Approx. 3.7 kg |
| MPL-B330P-MJ72AA | Low-Inertia Servo Motor | 400 V AC | 5000 rpm | Approx. 4.18 N·m | Approx. 1.8 kW | Multi-turn absolute | 100 mm / 76.2 mm stack | Approx. 4.82 kg |
| MPL-B420P-MJ72AA | Low-Inertia Servo Motor | 400 V AC | 5000 rpm | Approx. 4.74 N·m | Approx. 1.9 kW | Multi-turn | 100 mm class | Approx. 4.3 kg |
| MPL-B430P-MJ72AA | Low-Inertia Servo Motor | 400 V AC | 5000 rpm | Approx. 6.55 N·m | Approx. 2.2 kW | Multi-turn | Approx. 115 mm class | Approx. 5.5 kg |
| MPL-B4560F-MJ72AA | Low-Inertia Servo Motor | 400 V AC | 3000 rpm | Approx. 14.1 N·m | Approx. 3.2 kW | Multi-turn configuration | Larger frame / longer stack | Approx. 11.8 kg |
The smaller B320P model is appropriate where approximately 3 N·m of continuous torque is sufficient.
The B330P is a useful middle-range option for applications requiring approximately 4.18 N·m continuous torque and 5000 rpm.
The B420P and B430P increase the available torque while maintaining the high-speed 5000 rpm class.
The B4560F represents a substantially larger motor class, providing significantly higher continuous torque but also requiring more installation space and a larger mechanical structure.
23. Related MPL-B330P Configurations
The MPL-B330P family includes multiple suffix configurations.
Although several models share the same general motor frame and performance class, their feedback, shaft, connector, or brake arrangements can differ.
| Model | Rated Speed | Continuous Torque | Feedback | Shaft | Brake | General Configuration |
|---|---|---|---|---|---|---|
| MPL-B330P-MJ72AA | 5000 rpm | Approx. 4.18 N·m | Multi-turn absolute | Keyed | No | SpeedTEC DIN, right-angle, rotatable |
| MPL-B330P-MJ74AA | 5000 rpm | Approx. 4.18 N·m | Multi-turn absolute | Keyed | Brake configuration | Related B330P configuration |
| MPL-B330P-HJ72AA | 5000 rpm | Approx. 4.18 N·m | Encoder configuration | Keyed | No | Related B330P configuration |
| MPL-B330P-HJ74AA | 5000 rpm | Approx. 4.18 N·m | Encoder configuration | Keyed | Brake configuration | Related B330P configuration |
| MPL-B330P-HK72AA | 5000 rpm | Approx. 4.18 N·m | Encoder configuration | Keyed | No | Related B330P configuration |
The complete suffix should always be checked before selecting a replacement.
For example, a change in feedback type can require different drive parameters or feedback cabling even if the motor frame and torque ratings appear similar.
24. Comparison with the MPL-A330P Family
A particularly relevant comparison is the MPL-A330P family.
The MPL-A330P-MJ72AA and MPL-B330P-MJ72AA have similar general mechanical characteristics, including a 100 mm frame, 76.2 mm stack length, 5000 rpm speed class, multi-turn feedback, keyed shaft, and no brake.
The principal difference is the voltage class.
| Parameter | MPL-A330P-MJ72AA | MPL-B330P-MJ72AA |
|---|---|---|
| Model | MPL-A330P-MJ72AA | MPL-B330P-MJ72AA |
| Voltage Class | 230 V class | 400 V class |
| Armature Voltage | Approx. 230 V | Approx. 460 V |
| Frame | 100 mm | 100 mm |
| Stack | 76.2 mm | 76.2 mm |
| Rated Speed | 5000 rpm | 5000 rpm |
| Feedback | Multi-turn absolute | Multi-turn absolute |
| Shaft | Keyed | Keyed |
| Brake | No | No |
| Connector | Right-angle SpeedTEC DIN | Right-angle SpeedTEC DIN |
| Mounting | IEC Metric | IEC Metric |
| Approx. Weight | Similar class | Approx. 4.82 kg |
This comparison demonstrates why voltage compatibility must be checked before replacing a servo motor.
A motor with the same frame and mechanical configuration may still require a different servo-drive system because of its voltage class.
25. Machine Design Benefits
The MPL-B330P-MJ72AA provides several characteristics that are valuable in automated machine design.
The 100 mm frame allows the motor to fit into a relatively compact machine envelope.
The 5000 rpm speed rating allows the motor to support rapid rotary movement.
The low rotor inertia helps the machine achieve rapid acceleration and deceleration.
The absolute multi-turn encoder provides the feedback required for precise closed-loop control.
The keyed shaft provides a conventional mechanical connection.
The rotatable right-angle connector allows more flexible cable routing.
The absence of an integral brake keeps this particular configuration intended for applications where a motor holding brake is not required.
26. Recommended Application Matching
| Application | Suitability Characteristics |
|---|---|
| Packaging | High speed, rapid indexing, repeatable positioning |
| Material Handling | Controlled acceleration and positioning |
| Pick-and-Place | Low inertia and high-speed movement |
| Electronic Assembly | High-resolution feedback and repeatability |
| Converting Machinery | High-speed rotary motion and synchronization |
| Printing Equipment | Controlled speed and positioning |
| Machine Tools | Servo positioning and dynamic response |
| Automated Feeders | Rapid indexing and repeatable movement |
| Rotary Indexing | High speed and controlled acceleration |
| General Factory Automation | Closed-loop motion control |
27. Important Engineering Notes
The MPL-B330P-MJ72AA should be selected based on the complete machine motion profile rather than rated power alone.
The following factors should be evaluated during engineering:
Load torque: The continuous load torque should remain within the motor’s continuous operating capability.
Peak torque: Acceleration and transient requirements should remain within the allowable peak torque capability.
Load inertia: The reflected load inertia should be compatible with the servo system’s tuning range and dynamic response requirements.
Speed: The operating speed should remain within the motor and application limits.
Duty cycle: Repetitive high-load operation may create substantially more heat than continuous low-load operation.
Mechanical transmission: Gearboxes, belts, pulleys, couplings, and screws all affect the actual load seen by the motor.
Feedback compatibility: The absolute encoder configuration must be compatible with the selected servo drive and controller.
Mechanical compatibility: Frame, shaft, flange, mounting holes, stack length, and connector clearance should all be checked.
28. Product Advantages Summary
| Advantage | Description |
|---|---|
| High Speed | 5000 rpm rated operating speed |
| Strong Continuous Torque | Approximately 4.18 N·m |
| High Peak Torque | Approximately 11.1 N·m |
| Compact Frame | 100 mm frame |
| Low Inertia | Approximately 0.00012 kg·m² rotor inertia |
| Absolute Feedback | Multi-turn high-resolution encoder |
| Keyed Shaft | Conventional mechanical coupling interface |
| Flexible Connector | Right-angle connector with 180° rotation |
| Metric Mounting | IEC metric flange |
| No Integral Brake | Suitable for non-braked applications |
| Industrial Servo Design | Designed for closed-loop machine motion |
| Broad Application Range | Packaging, assembly, handling, indexing and automation |
29. Final Technical Summary
| Category | MPL-B330P-MJ72AA |
|---|---|
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Brushless Servo Motors |
| Model | MPL-B330P-MJ72AA |
| Motor Type | Permanent-Magnet AC Rotary Servo Motor |
| Voltage Class | 400 V AC |
| Armature Voltage | 460 V |
| Rated Power | Approx. 1.8 kW |
| Continuous Torque | Approx. 4.18 N·m |
| Peak Torque | Approx. 11.1 N·m |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Rotor Inertia | Approx. 0.00012 kg·m² |
| Feedback | Multi-turn High-Resolution Absolute Encoder |
| Encoder Resolution | 1024 sin/cos cycles/revolution |
| Feedback Protocol | Hiperface-type |
| Shaft | Keyed Shaft Extension |
| Brake | No Integral Brake |
| Connector | SpeedTEC DIN |
| Connector Style | Right Angle |
| Connector Rotation | 180° |
| Frame Size | 100 mm |
| Magnetic Stack | 76.2 mm / 3.0 in |
| Mounting | IEC Metric |
| Mounting Holes | Type FF |
| Shaft Seal | No Shaft Seal |
| Approximate Weight | 4.82 kg |
| Overall Dimensions | Configuration-dependent; verify mechanical drawing |
| Typical Applications | Packaging, material handling, assembly, converting, printing, indexing, machine tools and automation |
| Main Characteristics | High speed, low inertia, absolute feedback, keyed shaft and flexible connector |
30. Overall Product Description
The MPL-B330P-MJ72AA is a 100 mm-frame, 5000 rpm low-inertia servo motor designed for industrial automation and precision motion-control applications.
Its approximately 1.8 kW rated power, 4.18 N·m continuous torque, and 11.1 N·m peak torque provide a useful combination of continuous output and short-duration dynamic capability.
The motor’s low rotor inertia supports fast acceleration and deceleration, making it suitable for machines that perform repetitive positioning and indexing movements.
Its multi-turn high-resolution absolute encoder provides the feedback required for accurate closed-loop servo control.
The keyed shaft extension provides a conventional mechanical interface for compatible couplings and transmission systems.
The right-angle SpeedTEC DIN connector can be rotated through approximately 180 degrees, giving machine builders additional flexibility when routing motor cables around compact mechanical structures.
The 100 mm frame and 76.2 mm magnetic stack provide a relatively compact package for this performance level.
The motor has no integral brake, so applications requiring mechanical holding after servo power removal should incorporate a suitable external holding mechanism or use an appropriate braked motor configuration.
Overall, the MPL-B330P-MJ72AA is characterized by a combination of high rotational speed, low rotor inertia, absolute multi-turn feedback, moderate-to-high servo torque, compact 100 mm mechanical construction, keyed shaft coupling, and flexible connector orientation.
It is particularly appropriate for high-cycle industrial machinery where fast and repeatable motion is required, including packaging equipment, indexing machines, automated assembly systems, material-handling equipment, converting machinery, printing-related mechanisms, and general factory automation.