

ProductPRODUCT
Featured products
Contact Us
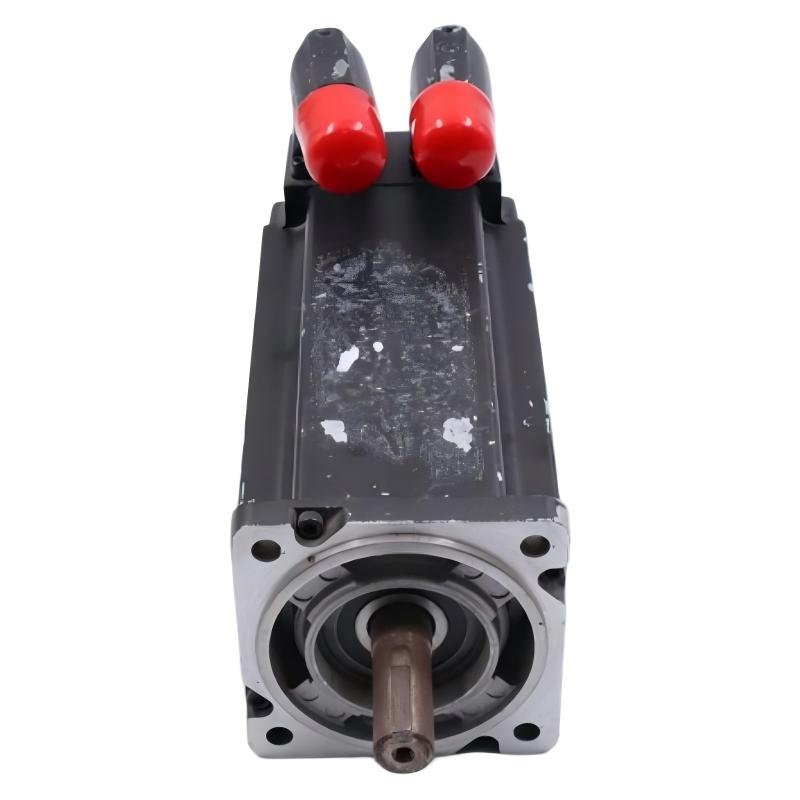
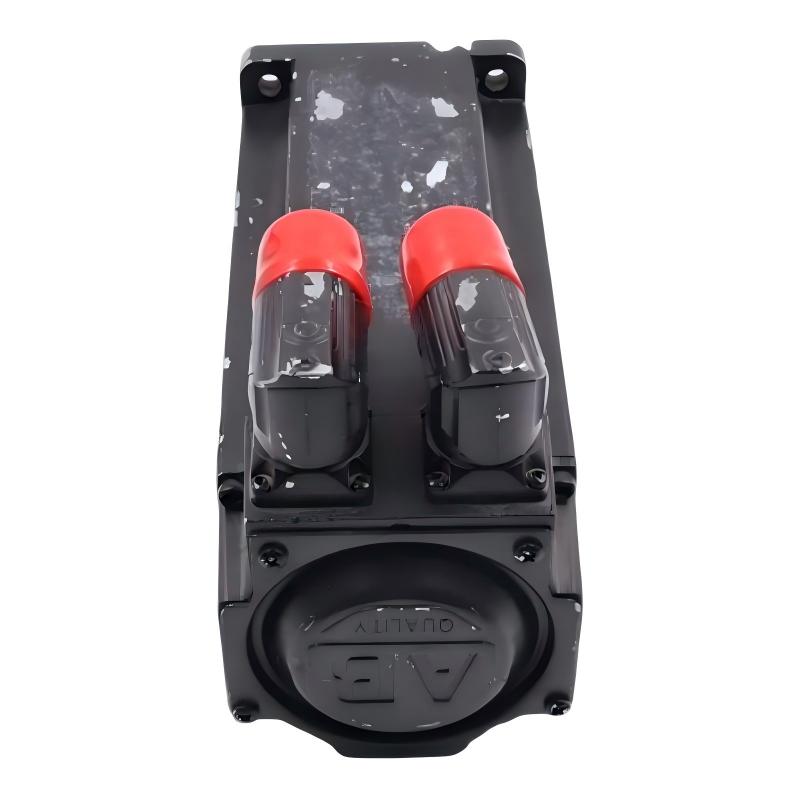
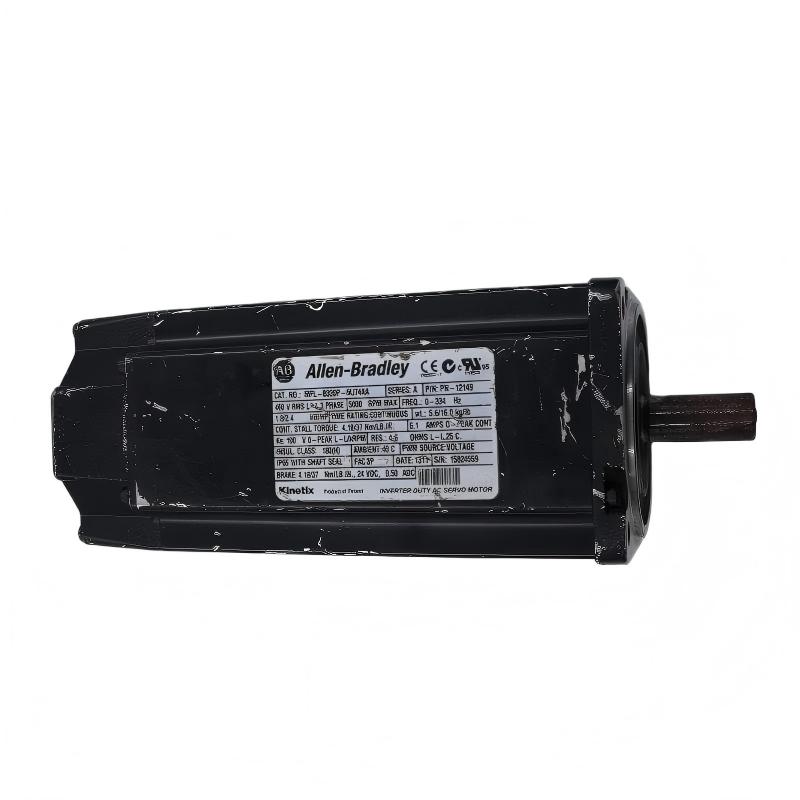
- Allen Bradley
- MPL-B330F-M-X223
- Low-Inertia Brushless Servo Motors Product
- USA
- 63 mm × 63 mm × 150 mm
- 5.44kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 27
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
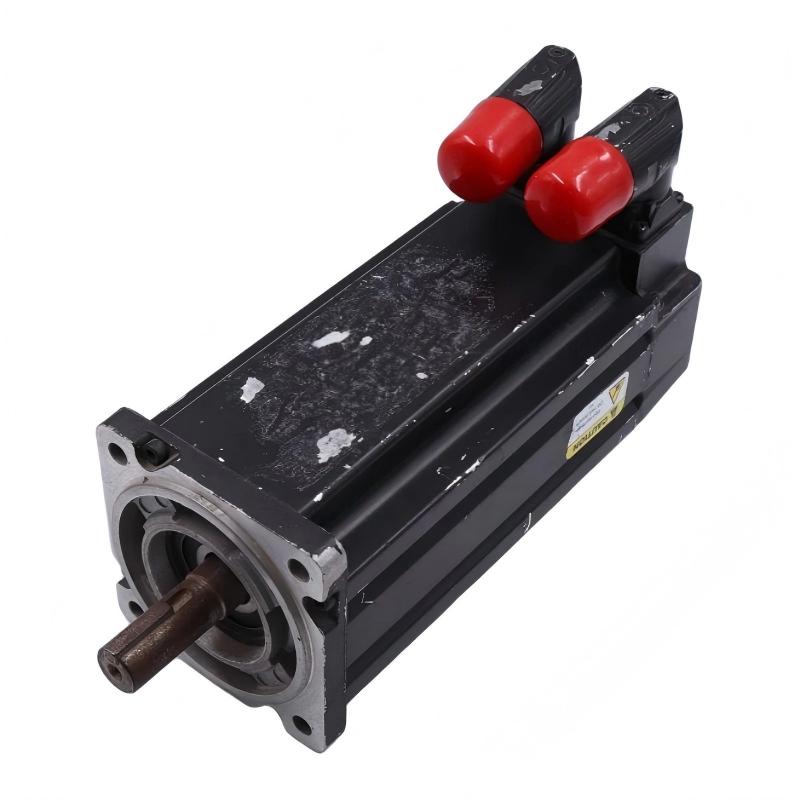
MPL-B330F-M-X223 Servo Motor
1. Product Overview
The MPL-B330F-M-X223 is a low-inertia servo motor designed for precision motion-control applications. It is part of the MPL Series servo motor family and is intended for automated machinery that requires accurate positioning, rapid acceleration and deceleration, stable speed control, and reliable repetitive operation.
The motor is particularly suitable for applications where dynamic response is important. Its low-inertia rotor design allows the motor to respond quickly to commands from the servo drive, making it appropriate for machinery with frequent starts, stops, reversals, and positioning movements.
The MPL-B330F-M-X223 is also associated with electric-cylinder and linear-motion applications. When connected to a suitable mechanical transmission or actuator, the rotary output of the servo motor can be converted into controlled linear movement. This makes it useful in equipment where positioning accuracy and repeatability are more important than simply providing continuous rotary motion.
The model is identified by the MPL-B330F-M-X223 catalog designation. The suffix configuration identifies the particular motor arrangement, feedback configuration, mechanical characteristics, and application-related options associated with this model.
2. Brand and Product Series
| Item | Information |
|---|---|
| Brand | Allen Bradley |
| Product Family | Servo Motor |
| Product Series | MPL Series |
| Motor Type | Low-Inertia Servo Motor |
| Application Category | Industrial Motion Control |
| Feedback | High-resolution absolute feedback configuration |
| Typical System | Servo drive and motion-control system |
| Primary Function | Precision rotary motion and actuator positioning |
| Typical Industry | Industrial automation and machinery |
The MPL Series is designed for applications requiring controlled motion rather than conventional fixed-speed motor operation. Servo motors in this family are normally selected according to torque, speed, inertia, feedback, shaft configuration, brake requirements, voltage class, and the mechanical requirements of the machine.
3. Main Technical Specifications
| Parameter | MPL-B330F-M-X223 |
|---|---|
| Model | MPL-B330F-M-X223 |
| Motor Type | Brushless permanent-magnet servo motor |
| Servo Class | Low-inertia servo motor |
| Voltage Class | 400 VAC class |
| Rated Speed | Approximately 3,000 rpm |
| Maximum Speed | Approximately 5,000 rpm, depending on system configuration |
| Feedback | High-resolution multi-turn absolute encoder configuration |
| Feedback Function | Absolute position feedback |
| Frame Size | Approximately 100 mm class |
| Rotor Type | Permanent-magnet rotor |
| Cooling | Natural / surface cooling |
| Mounting | Flange-mounted |
| Shaft | Servo motor output shaft |
| Brake | No brake in the stated configuration |
| Shaft Seal | No shaft seal in the stated configuration |
| Connector | Circular industrial servo connector |
| Intended Motion | Rotary servo motion / actuator motion |
| Typical Application | Electric cylinder, positioning mechanism, automated machinery |
| Approximate Weight | 5.44 kg |
| Dimensions | Approximately 100 mm frame class; exact overall length and shaft dimensions depend on the specific mechanical configuration |
| Operating Environment | Industrial automation environment |
| Control Method | Closed-loop servo control |
| Position Control | Supported through compatible servo drive and motion controller |
| Speed Control | Supported |
| Torque Control | Supported through compatible servo system |
The dimensions should be treated as a mechanical envelope reference rather than a substitute for a mechanical drawing. The 100 mm-class frame designation describes the motor mounting size, while the actual overall motor length, shaft extension, connector arrangement, and mounting-hole dimensions may vary according to the exact configuration.
4. Dimensions and Weight
Physical dimensions are especially important when replacing an existing servo motor. A motor can have the same frame designation as another model while having a different overall length, shaft configuration, connector arrangement, or mounting requirement.
For the MPL-B330F-M-X223, the available general specification information places the motor in the approximately 100 mm frame class.
| Mechanical Parameter | Specification |
|---|---|
| Frame Size | Approx. 100 mm class |
| Motor Body Width | Approx. 100 mm class |
| Motor Body Height | Approx. 100 mm class |
| Overall Length | Configuration-dependent |
| Shaft Diameter | Configuration-dependent |
| Shaft Extension | Configuration-dependent |
| Mounting Pattern | Servo flange mounting |
| Connector Position | Configuration-dependent |
| Brake Housing | Not applicable to the stated no-brake configuration |
| Approximate Weight | 5.44 kg |
For equipment replacement, the exact mechanical drawing should be checked before installation. In particular, the shaft diameter, shaft extension, key arrangement, flange dimensions, mounting-hole pattern, and overall length should not be assumed solely from the model number.
5. Product Construction
The motor uses a permanent-magnet rotor and a brushless servo construction. Unlike a conventional induction motor that is normally operated primarily for continuous-speed applications, a servo motor is designed to operate as part of a closed-loop control system.
The motor’s feedback device continuously provides position information to the control system. The servo drive uses this information to determine whether the motor is following the commanded position, velocity, or torque.
This closed-loop structure is one of the main reasons servo motors are widely used in automated machinery.
The low-inertia construction is particularly useful when the driven mechanism has to change speed rapidly. A lower rotor inertia generally allows the control system to accelerate and decelerate the motor more quickly, provided that the complete mechanical system is correctly sized.
6. Feedback System
The MPL-B330F-M-X223 is associated with a high-resolution absolute feedback configuration.
An absolute feedback system provides the motion controller with detailed information about the motor’s position. Multi-turn feedback is especially useful in applications where the motor may rotate through multiple revolutions and the controller needs to distinguish the absolute position across those revolutions.
This type of feedback can be advantageous in machinery that performs repeated positioning operations.
Typical benefits include:
- Accurate position detection
- Improved repeatability
- High-resolution motion control
- Better synchronization between motor and machine
- Reduced dependence on simple open-loop positioning
- Improved response to position errors
- Better control during acceleration and deceleration
7. Product Introduction
The MPL-B330F-M-X223 can be considered a precision motion component rather than simply a motor.
In a complete machine, the motor normally works together with a servo drive, motion controller, feedback device, mechanical transmission, and machine-load system.
The controller generates the desired motion command. The servo drive converts this command into electrical power for the motor. The motor produces the required torque and speed, while the feedback system continuously reports the actual motor position.
The control system then compares the commanded position with the actual position and makes corrections as required.
This arrangement allows the machine to perform highly repeatable movement sequences.
8. Typical Applications
8.1 Electric Cylinder Systems
One important application area is electric-cylinder equipment.
The servo motor can drive a screw mechanism that converts rotary motion into linear movement. This arrangement is useful for controlled pushing, pulling, positioning, clamping, lifting, and pressing.
Typical applications include:
- Electric actuators
- Precision positioning cylinders
- Servo presses
- Clamping mechanisms
- Linear positioning systems
- Automated adjustment mechanisms
8.2 Automated Assembly Equipment
Servo motors are frequently used in assembly machinery where components must be moved to predetermined positions.
The MPL-B330F-M-X223 can be applied to mechanisms that require:
- Rapid positioning
- Repeated movement
- Controlled acceleration
- Controlled deceleration
- Accurate stopping
- Coordinated movement between multiple axes
8.3 Packaging Machinery
Packaging equipment often requires frequent and repetitive movement.
Servo-controlled mechanisms can be used for:
- Product positioning
- Feeding mechanisms
- Cutting mechanisms
- Indexing systems
- Film positioning
- Label positioning
- Material handling
8.4 Material Handling
The motor can be used in automated material-handling equipment where the machine must move components to defined positions.
Examples include:
- Transfer mechanisms
- Pick-and-place equipment
- Conveyor positioning systems
- Automated storage mechanisms
- Machine loading and unloading systems
8.5 Inspection Equipment
Precision inspection equipment may require stable and repeatable positioning.
The servo motor can be used for:
- Camera positioning
- Sensor positioning
- Workpiece movement
- Inspection-stage positioning
- Automated measurement systems
8.6 Machine Tools and Production Equipment
Servo motors are commonly used for controlled machine-axis movement.
Possible applications include:
- Feed mechanisms
- Positioning axes
- Automatic adjustment systems
- Tool-positioning mechanisms
- Automated production stations
9. Main Product Advantages
9.1 Low-Inertia Design
The low-inertia rotor is one of the important characteristics of this motor family.
A low-inertia motor can change its rotational speed quickly, which is useful when the machine performs frequent acceleration and deceleration.
This can contribute to shorter machine cycles and smoother dynamic operation when the motor is correctly matched to the mechanical load.
9.2 High-Resolution Feedback
High-resolution feedback allows the control system to obtain detailed information about motor position.
This is important in applications where small positioning errors can affect product quality or machine performance.
9.3 Good Dynamic Response
Servo motors are designed for rapid changes in speed and torque.
The MPL-B330F-M-X223 is therefore suitable for machinery where the motor cannot simply run at one fixed speed for long periods.
9.4 Closed-Loop Control
Closed-loop operation allows the controller to compare commanded movement with actual motor movement.
This provides a major advantage over basic open-loop motor systems when accurate positioning is required.
9.5 Suitable for Repetitive Automation
Industrial machinery often performs the same movement thousands or millions of times.
A properly sized servo motor can repeatedly execute the same motion profile with controlled acceleration, velocity, position, and stopping behavior.
9.6 Flexible Motion Control
Depending on the associated drive and controller, the servo system can be configured for:
- Position control
- Velocity control
- Torque control
- Electronic gearing
- Electronic camming
- Coordinated multi-axis motion
- Point-to-point positioning
10. Installation Considerations
Before replacing an existing servo motor with the MPL-B330F-M-X223, the following items should be checked carefully.
| Check Item | Importance |
|---|---|
| Motor model | Must match the intended application |
| Rated voltage | Must match the servo system |
| Motor power requirements | Must be compatible with the drive |
| Feedback type | Must be supported by the drive |
| Shaft diameter | Must match the mechanical coupling |
| Shaft length | Must provide sufficient engagement |
| Mounting flange | Must match the machine |
| Mounting-hole pattern | Must match the mounting plate |
| Overall motor length | Must fit available installation space |
| Motor weight | Must be acceptable for the machine structure |
| Brake requirement | Must match the application |
| Cable/connector | Must match the servo system |
| Load inertia | Must be within the appropriate servo sizing range |
| Operating speed | Must meet machine requirements |
| Continuous torque | Must satisfy the actual load |
| Peak torque | Must satisfy acceleration requirements |
11. Five Related Models for Consideration
The following models are presented as related MPL-family or application-related models. Exact suffix configurations can change the electrical, feedback, brake, shaft, or mechanical specifications, so they should be treated as selection references rather than direct drop-in replacements.
| Model | Series / Family | Typical Characteristics | Voltage Class | Speed Class | Feedback | Brake | Approx. Weight | Dimensions |
|---|---|---|---|---|---|---|---|---|
| MPL-B330F-M-X224 | MPL Series | Similar electric-cylinder-oriented configuration | 400 VAC class | Approx. 3,000 rpm | Absolute feedback configuration | Configuration-dependent | Approx. 5–6 kg | Approx. 100 mm frame class |
| MPL-B420F-M-X225 | MPL Series | Larger-capacity related actuator configuration | 400 VAC class | Approx. 3,000 rpm class | Absolute feedback configuration | Configuration-dependent | Approx. 6–7 kg | Approx. 115 mm class |
| MPL-B420F-M-X226 | MPL Series | Higher-capacity related configuration | 400 VAC class | Approx. 3,000 rpm class | Absolute feedback configuration | Brake configuration | Approx. 6–7 kg | Approx. 115 mm class |
| MPL-B220F-V-X221 | MPL Series | More compact electric-cylinder-oriented configuration | 400 VAC class | Approx. 3,000 rpm class | Absolute feedback configuration | No-brake configuration | Approx. 3–4 kg | Approx. 80 mm class |
| MPL-B220F-V-X222 | MPL Series | Compact related configuration with different option set | 400 VAC class | Approx. 3,000 rpm class | Absolute feedback configuration | Configuration-dependent | Approx. 3–4 kg | Approx. 80 mm class |
When choosing one of these alternatives, the most important factors are not simply the motor model number. The required continuous torque, peak torque, operating speed, load inertia, acceleration time, duty cycle, screw pitch, mechanical transmission ratio, and available installation space should all be considered together.
12. Five Popular Models from the Same Brand
The following models are useful as additional product-selection references within the broader servo-motor range.
| Model | Product Family | Typical Application | Voltage Class | Frame / Size Class | Feedback | Speed Class | Approx. Weight | Dimensions |
|---|---|---|---|---|---|---|---|---|
| MPL-B320P-MJ72AA | MPL Series | General precision rotary motion | 480 VAC class | Approx. 80 mm class | High-resolution feedback | High-speed servo operation | Approx. 5 kg | Approx. 80 mm frame class |
| MPL-B330P-MJ72AA | MPL Series | Industrial automation and positioning | 480 VAC class | Approx. 100 mm class | High-resolution feedback | High-speed servo operation | Approx. 7 kg | Approx. 100 mm frame class |
| MPL-B420P-MJ72AA | MPL Series | Higher-load motion applications | 480 VAC class | Approx. 115 mm class | High-resolution feedback | High-speed servo operation | Approx. 9 kg | Approx. 115 mm frame class |
| MPL-B310P-MJ72AA | MPL Series | Compact positioning equipment | 480 VAC class | Approx. 63 mm class | High-resolution feedback | High-speed servo operation | Approx. 3 kg | Approx. 63 mm frame class |
| MPL-B220F-V-X221 | MPL Series | Electric actuator and linear positioning | 400 VAC class | Approx. 80 mm class | Absolute feedback | Approx. 3,000 rpm class | Approx. 3–4 kg | Approx. 80 mm frame class |
The models above should not automatically be regarded as interchangeable. Servo motors with similar physical dimensions can have substantially different electrical characteristics, feedback systems, torque ratings, winding specifications, shaft configurations, or drive requirements.
13. Comparison with Conventional Motors
The MPL-B330F-M-X223 is intended for applications where controlled motion is required.
A conventional motor is often selected primarily according to power, voltage, speed, and mechanical installation requirements. A servo motor requires a broader selection process.
| Selection Factor | Conventional Motor | MPL-Type Servo Motor |
|---|---|---|
| Position control | Limited without additional equipment | Core application |
| Speed control | Possible with drive | High-precision closed-loop control |
| Acceleration control | General-purpose | Highly controllable |
| Position feedback | Normally not integral | Integral feedback system |
| Repeated positioning | Limited | Designed for repetitive positioning |
| Dynamic response | Application-dependent | Designed for rapid response |
| Multi-axis synchronization | Requires additional control | Well suited to coordinated motion |
| Torque control | Limited | Precisely controllable |
| Machine automation | General | Highly suitable |
14. Why Low Inertia Matters
Motor inertia affects how quickly the motor can change speed.
When the machine repeatedly accelerates and decelerates, excessive motor inertia can increase the amount of effort required from the servo system.
A lower-inertia rotor can make rapid movement easier to control.
For example, in an indexing machine, the motor may need to accelerate rapidly, reach a commanded speed, decelerate, stop at a precise location, and immediately begin the next movement.
This type of operating cycle is exactly where a low-inertia servo design can be useful.
15. Suitability for Linear Motion
When used with an appropriate ball screw or other mechanical transmission, the motor’s rotary movement can be converted into linear movement.
For a screw-driven actuator, the basic relationship can be expressed as:
Linear Travel per Revolution = Screw Lead
Therefore, a 10 mm screw lead means that one complete revolution of the screw produces approximately 10 mm of theoretical linear travel, before considering mechanical losses and other system characteristics.
This type of arrangement can be used for controlled:
- Extension
- Retraction
- Pressing
- Clamping
- Lifting
- Positioning
- Feeding
16. Maintenance Considerations
The motor itself normally requires less routine mechanical maintenance than many conventional mechanical drive systems, but the complete servo system still needs periodic inspection.
Important inspection items include:
- Motor mounting bolts.
- Coupling condition.
- Shaft alignment.
- Cable condition.
- Connector condition.
- Feedback cable condition.
- Abnormal vibration.
- Abnormal noise.
- Motor temperature.
- Servo drive alarm history.
- Mechanical backlash.
- Load condition.
- Repeated positioning accuracy.
A motor that suddenly develops excessive vibration, abnormal noise, overheating, or positioning errors should not simply be replaced without checking the mechanical load and servo drive system.
17. Selection Guide
When selecting an MPL Series servo motor, the following procedure is recommended.
Step 1 — Determine the Load
Calculate the actual machine load, including the weight of moving components, friction, acceleration requirements, and external forces.
Step 2 — Determine Required Speed
Establish the normal operating speed and maximum required speed.
Step 3 — Determine Continuous Torque
The motor must be capable of producing the required continuous torque during normal operation.
Step 4 — Determine Peak Torque
Acceleration, deceleration, pressing, clamping, or sudden load changes may require significantly more torque than normal running conditions.
Step 5 — Check Inertia
The motor and load inertia should be considered together when designing the servo system.
Step 6 — Check Feedback
The encoder type must be compatible with the selected servo drive and controller.
Step 7 — Check Mechanical Dimensions
Verify the flange, mounting holes, shaft diameter, shaft extension, overall length, and connector position.
Step 8 — Check Weight
The motor’s mass should be considered when the motor is installed on a moving axis.
Step 9 — Check Brake Requirements
Vertical axes and applications where the load must remain stationary after power removal may require a motor with an appropriate holding brake.
Step 10 — Verify the Complete System
The motor, servo drive, controller, feedback cable, power cable, mechanical transmission, and load should be treated as one complete motion-control system.
18. Key Specification Summary
| Category | MPL-B330F-M-X223 |
|---|---|
| Model | MPL-B330F-M-X223 |
| Brand | Allen Bradley |
| Series | MPL Series |
| Motor Type | Low-inertia brushless servo motor |
| Voltage Class | 400 VAC class |
| Rated Speed | Approx. 3,000 rpm |
| Maximum Speed | Approx. 5,000 rpm class |
| Feedback | High-resolution absolute multi-turn feedback configuration |
| Frame Size | Approx. 100 mm class |
| Mounting | Flange mounting |
| Brake | No brake configuration |
| Shaft Seal | No shaft seal configuration |
| Cooling | Natural / surface cooling |
| Main Application | Precision motion control |
| Linear Application | Electric cylinder / actuator systems |
| Approx. Weight | 5.44 kg |
| Dimensions | Approx. 100 mm frame class; exact overall dimensions are configuration-dependent |
19. Overall Product Description
The MPL-B330F-M-X223 is a precision-oriented servo motor intended for industrial motion-control equipment.
Its low-inertia construction makes it suitable for machinery requiring rapid acceleration and deceleration. Its high-resolution absolute feedback configuration provides the control system with detailed position information, supporting accurate and repeatable machine movement.
The motor is particularly relevant to automated equipment where rotary motion must be precisely controlled or converted into linear movement.
Typical applications include electric cylinders, automated assembly equipment, packaging machinery, positioning mechanisms, inspection equipment, material-handling systems, and other industrial automation machinery.
When selecting this motor as a replacement component, physical compatibility alone is not sufficient. Electrical specifications, feedback compatibility, motor winding characteristics, drive compatibility, torque requirements, speed requirements, load inertia, shaft dimensions, mounting dimensions, and cable connections should all be checked.
For purchasing and engineering purposes, the MPL-B330F-M-X223 can therefore be described as a 100 mm-class, low-inertia industrial servo motor designed for high-response closed-loop motion control and precision positioning applications, with an approximate weight of 5.44 kg.