

ProductPRODUCT
Featured products
Contact Us
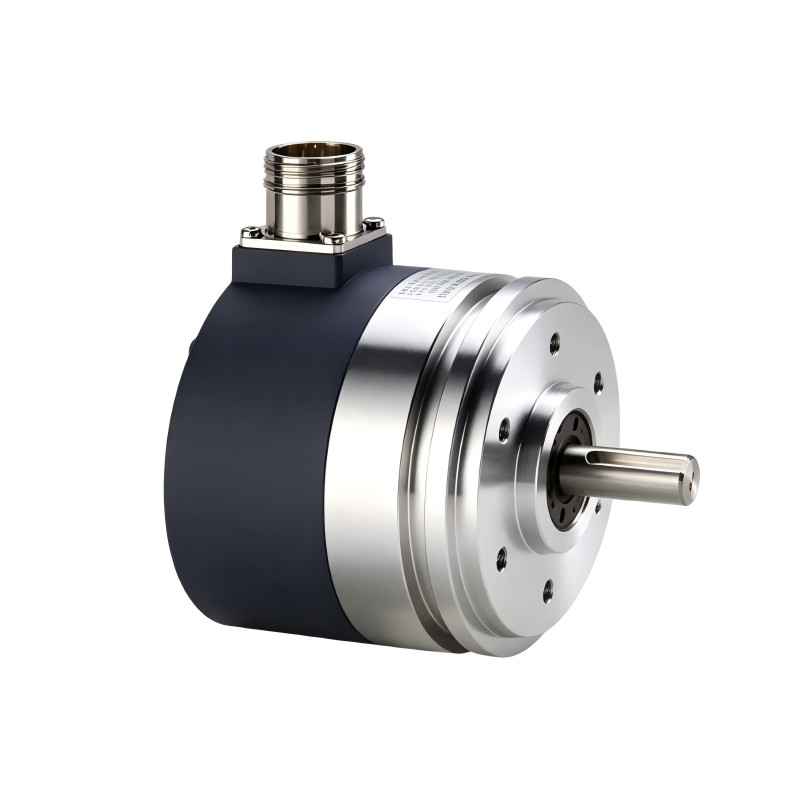
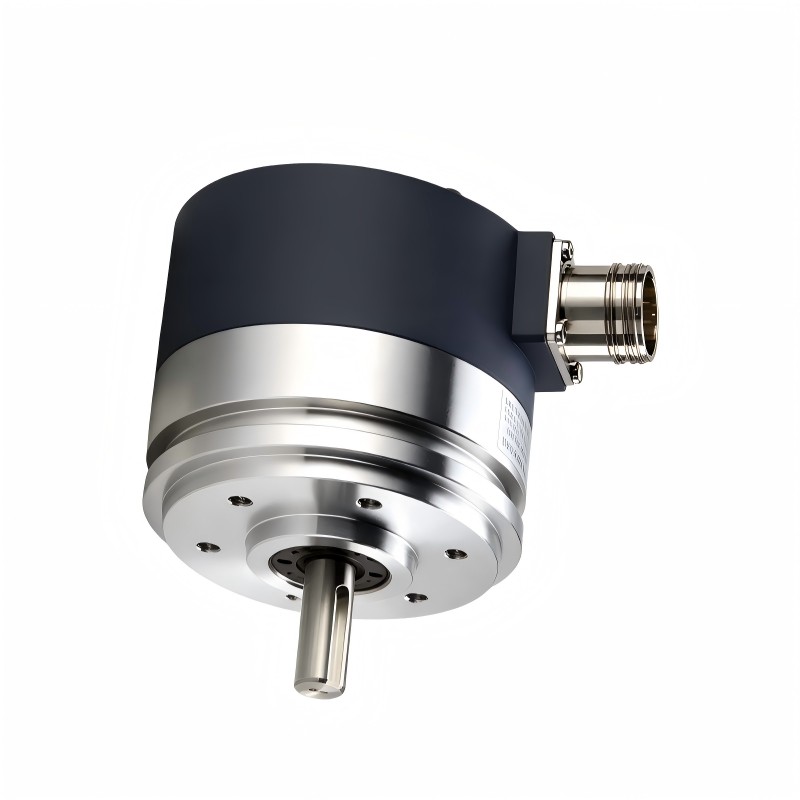
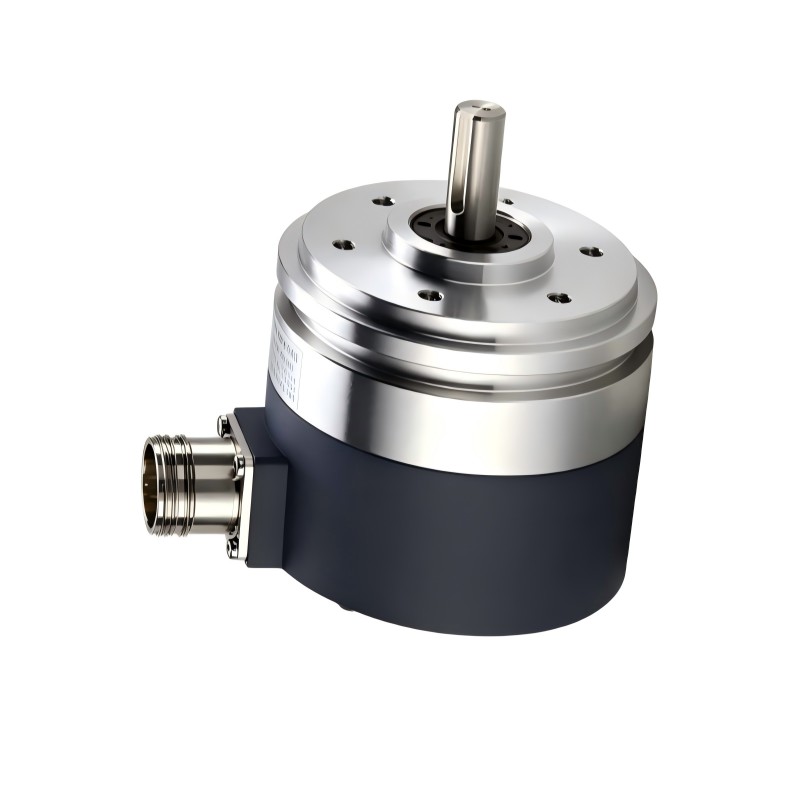
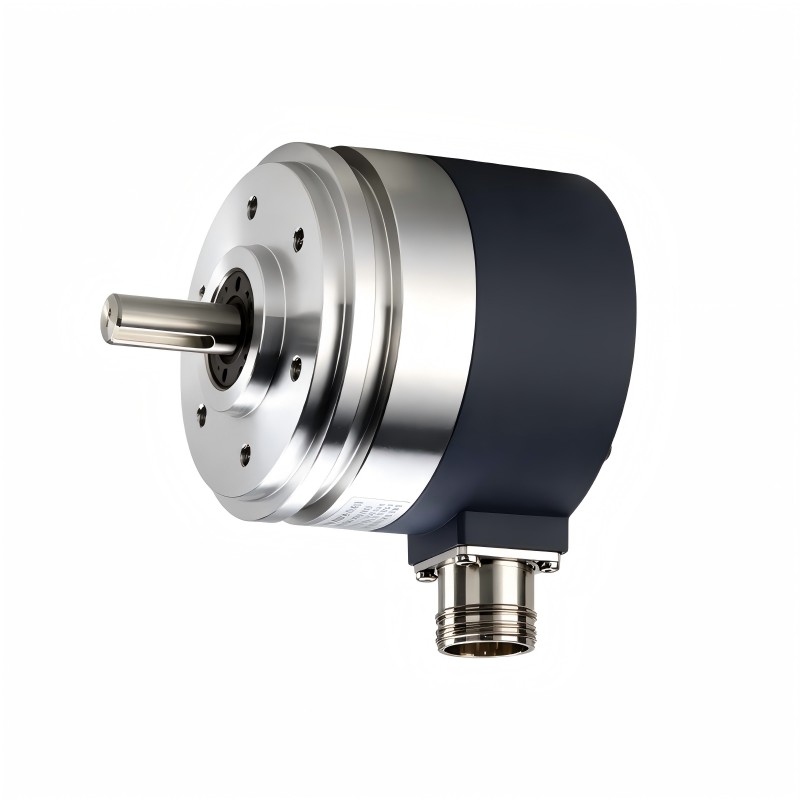
- Schneider
- XCC-2912PS81SGN
- XCC Single-Turn Absolute Encoder
- France
- 90 mm
- 1.37 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 9
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
1. Product Overview
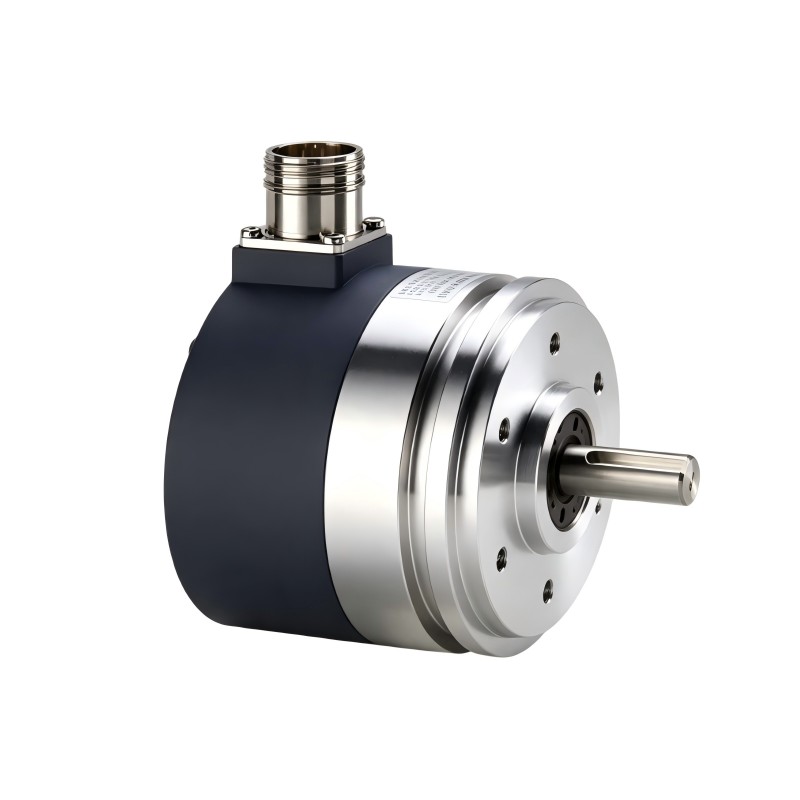
The Schneider Electric XCC2912PS81SGN is a single-turn absolute rotary encoder designed for industrial automation systems that require reliable rotational position feedback. Part of the OsiSense XCC encoder family, this device measures the angular position of a rotating shaft and transmits the corresponding position value to a compatible PLC, motion controller, or industrial control system.
Unlike an incremental encoder, which produces pulses representing relative movement, an absolute encoder provides a coded position value for the shaft’s position within one complete revolution. This makes absolute encoders useful in applications where the controller needs to identify the current angular position without relying solely on counting pulses from a previously established reference.
The XCC2912PS81SGN features a 90 mm housing, a 12 mm solid shaft, and an 8192-position resolution corresponding to 13-bit position data. Its output uses an SSI (Synchronous Serial Interface) with Gray code, allowing the encoder to communicate absolute position data to a compatible receiving device.
The encoder operates from an 11–30 V DC supply and uses a radial 16-pin M23 male connector. Its specified weight is 1.37 kg, making it suitable for industrial installations designed around its mechanical dimensions and mounting requirements.
The Gray-code output is particularly relevant to absolute position measurement. In Gray code, adjacent position values differ by one bit, which can reduce ambiguity during transitions between neighboring positions when the interface is implemented correctly.
For automation engineers, maintenance teams, and industrial spare-parts buyers, the most important selection factors include the SSI interface, Gray-code format, 13-bit resolution, shaft dimensions, supply voltage, and connector arrangement. A model with the same housing size but a different output interface or code format should not automatically be considered a direct replacement.
2. Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Schneider Electric |
| Product family | OsiSense XCC |
| Model | XCC2912PS81SGN |
| Product type | Single-turn absolute rotary encoder |
| Housing diameter | 90 mm |
| Shaft type | Solid shaft |
| Shaft diameter | 12 mm |
| Resolution | 8192 positions per revolution |
| Resolution format | 13-bit |
| Output interface | SSI, Synchronous Serial Interface |
| Position coding | Gray code |
| Output stage | Type SGN |
| Supply voltage | 11–30 V DC |
| Electrical connection | Radial M23 male connector, 16 pins |
| Maximum rotational speed | 6000 rpm |
| Output frequency | Up to 100 kHz for the specified SSI interface, subject to the applicable timing requirements |
| No-load current consumption | Up to 100 mA |
| Enclosure material | Zamak |
| Product weight | 1.37 kg |
Confirm the exact electrical and mechanical specifications against the documentation supplied with the unit before installation. In particular, verify SSI clock timing, signal wiring, receiver compatibility, and the encoder’s permissible mechanical loads.
3. Function and Working Principle
The XCC2912PS81SGN converts shaft angle into a digital absolute position value. Its internal sensing system identifies the shaft’s angular position and encodes that information for transmission to a compatible controller.
Single-Turn Absolute Position Measurement
A single-turn absolute encoder reports position within one revolution. The XCC2912PS81SGN provides 8192 distinguishable position values across a complete revolution.
With 13-bit resolution, the number of available codes is:
[
2^{13}=8192
]
The nominal angular increment between adjacent codes is:
[
\frac{360^\circ}{8192}\approx 0.04395^\circ
]
This represents the nominal digital position increment, not a guarantee of total system accuracy. Actual positioning performance also depends on the encoder’s accuracy specification, mounting, mechanical transmission, control system, and operating conditions.
SSI Communication
SSI is a synchronous serial communication interface commonly used with absolute encoders. The receiving controller provides a clock signal, and the encoder returns position data in synchronization with that clock.
This arrangement allows the controller to obtain a digital position value without interpreting a continuous train of incremental pulses. Correct communication depends on compatible SSI hardware, suitable clock timing, and accurate signal wiring.
The XCC2912PS81SGN should therefore be connected to an SSI-capable receiving device rather than assumed to work with a standard incremental encoder input.
Gray-Code Position Output
The model uses Gray-coded position data. In a Gray-code sequence, adjacent numerical positions differ by one bit. This property can reduce the chance of an ambiguous multi-bit transition when reading neighboring positions.
The receiving controller must interpret the incoming data using the correct Gray-code format. If the controller expects binary data, the system may need a compatible conversion function or interface.
Position After Power-Up
An absolute encoder provides a position code for the current angle within its single revolution. Unlike an incremental encoder, it does not need to reconstruct that angle solely by counting movement after power-up.
However, a single-turn encoder does not independently identify how many complete revolutions have occurred. If a machine needs to track multi-turn movement, the system must use a multi-turn encoder or another method of tracking revolutions.
4. Role in Industrial Control Systems
The XCC2912PS81SGN serves as a position-feedback device within a wider automation architecture. It provides digital position information to the controller responsible for machine sequencing, positioning, monitoring, or motion control.
PLC Position Feedback
A PLC equipped with a compatible SSI interface can read the encoder’s position value and use it in the control program.
Possible functions include:
- Monitoring the angular position of a rotating mechanism.
- Comparing actual position against a target position.
- Triggering actions at defined angular points.
- Supporting machine sequencing.
- Providing position data for diagnostic and supervisory systems.
The PLC or interface module must support the encoder’s SSI communication and Gray-code format. Ordinary digital inputs are not a substitute for an SSI receiver.
Motion Control and Positioning
In a compatible motion-control system, absolute position feedback can help the controller determine the current shaft angle and compare it with the commanded position.
This can be useful in rotary indexing equipment, positioning tables, and other machines where the angular position must be identified and monitored. The encoder itself does not perform closed-loop control; the connected controller and drive execute the required control functions.
Machine Synchronization
Some industrial machines coordinate the movement of several mechanical sections. An absolute position value can provide a reference for determining the position of a rotating shaft at a particular point in the machine cycle.
The usefulness of this feedback depends on the control system’s timing, mechanical transmission, and synchronization strategy.
Diagnostics and Status Monitoring
Absolute position feedback can help maintenance teams identify unexpected movement, incorrect positioning, or communication problems. For example, a controller may detect that a shaft position differs from the expected value.
Such a discrepancy can have several causes, including mechanical slip, mounting problems, an incorrect scaling configuration, communication errors, or a genuine position change. Further diagnostics are required to determine the cause.
5. Industrial Applications
Rotary Indexing Tables
Rotary indexing tables move workpieces between defined stations. An absolute encoder can provide angular position feedback to a compatible controller, helping it monitor the table’s current position and coordinate subsequent operations.
The encoder’s 13-bit resolution offers 8192 nominal position values per revolution. Whether this is sufficient for a particular indexing task depends on the required positioning tolerance and mechanical system.
Packaging Machinery
Packaging equipment may use rotary mechanisms to coordinate filling, sealing, cutting, or product transfer. Absolute position feedback can help the controller identify the angular position of a rotating component and coordinate actions within the machine cycle.
The encoder must be paired with compatible SSI hardware and configured for the required code format.
Printing and Processing Equipment
Rotating shafts and rollers in printing or continuous-processing systems may require position monitoring for synchronization and process control. An absolute encoder can supply a digital position reference to the control system.
Application suitability depends on operating speed, mechanical coupling, environmental conditions, and the accuracy required by the process.
Material Handling Systems
Rotary mechanisms used in material handling may require position feedback for controlled movement. A compatible control system can use the absolute position value to monitor shaft angle or coordinate movement between machine stages.
If the mechanism moves through multiple full revolutions and must retain a revolution count, a single-turn encoder alone may not provide all the required information.
Industrial Machinery and Automated Equipment
The XCC2912PS81SGN can be considered for industrial equipment that requires single-turn absolute position measurement and supports SSI communication. The actual application must be checked against the encoder’s mechanical, electrical, and environmental specifications.
6. Installation and System Integration
Correct installation is essential for reliable position measurement and communication.
Mechanical Installation
The XCC2912PS81SGN has a 90 mm housing and a 12 mm solid shaft. Its shaft must be connected to the machine using an appropriate coupling or mounting arrangement.
Before installation:
- Confirm the shaft diameter and specified tolerance.
- Check the mounting dimensions and available clearance.
- Align the encoder and driven shaft correctly.
- Avoid excessive radial or axial loading.
- Use suitable mounting hardware and coupling components.
- Prevent unnecessary vibration, impact, or mechanical stress.
- Ensure that the connector and cable have sufficient clearance.
Mechanical misalignment or excessive shaft loading can damage the encoder or affect measurement performance. Follow the applicable mounting instructions and load limits.
Electrical Connection
The encoder uses a radial M23 male connector with 16 pins. A matching mating connector or suitable cable assembly is required.
Before wiring, confirm:
- The supply voltage and polarity.
- The SSI clock and data signal assignments.
- The signal reference and shielding arrangement.
- The connector pinout for the exact model.
- The receiving device’s SSI electrical requirements.
- The cable length and signal-integrity requirements.
- The grounding and routing instructions for the installation.
Do not assume that all XCC encoder models use the same pin assignments. Always follow the connection diagram for the XCC2912PS81SGN.
SSI Interface Compatibility
The encoder uses SSI communication and Gray-coded position data. The receiving device must support the relevant SSI timing and be configured to interpret the position code correctly.
Before commissioning, confirm the receiver’s supported clock frequency, data length, timing requirements, and code format. If the receiver expects binary data, determine whether it can convert Gray code or whether an appropriate interface is needed.
Resolution and Position Scaling
The 13-bit resolution provides 8192 nominal position codes per revolution. A controller can convert these values into angular units or machine-specific position coordinates.
For example, a control program may convert the position code into degrees. If the encoder is coupled to a gearbox, indexing mechanism, or other transmission, the program must also account for the mechanical ratio between encoder rotation and the machine’s actual movement.
The encoder is single-turn, so the reported value repeats when the shaft completes a full revolution. Applications that need continuous multi-turn position tracking require an additional strategy.
Commissioning and Testing
During commissioning, verify that the controller can communicate with the encoder and receives stable position values.
Recommended checks include:
- Confirm the encoder’s supply voltage and connector wiring.
- Verify the SSI clock and data connections.
- Confirm that the receiver is configured for 13-bit Gray-code data.
- Rotate the shaft slowly and observe the position value.
- Check that the displayed position changes consistently with shaft movement.
- Verify angular scaling and the direction convention.
- Test the installation under normal operating conditions.
If the position value is invalid or unstable, inspect the wiring, communication timing, receiver configuration, and mechanical mounting before replacing the encoder.
7. Compatible System Components
The XCC2912PS81SGN is typically used with other industrial automation components. The following categories may be required, depending on the machine architecture.
| Component category | Function | Compatibility consideration |
|---|---|---|
| PLC with SSI interface | Reads absolute position data and executes control logic | Must support the encoder’s SSI protocol and Gray-code format |
| Motion controller | Uses position feedback in motion applications | Confirm interface, timing, and data-format support |
| SSI interface module | Connects the encoder to the control system | Must support the required electrical signals and data length |
| M23 mating connector | Provides the electrical connection | Must match the radial 16-pin connector |
| Encoder cable | Transmits clock, data, and power connections | Select suitable cable construction and routing |
| Industrial DC power supply | Supplies the encoder | Must meet the 11–30 V DC requirement |
| Mechanical coupling | Connects the solid shaft to the machine | Must match the shaft dimensions and load requirements |
| Mounting hardware | Secures the encoder to the machine | Must match the specified mounting arrangement |
These are component categories rather than a guarantee of direct compatibility with every PLC, drive, or interface module. Check the technical documentation for the complete system before connecting the encoder.
8. Recommended Alternative Models
Related XCC absolute encoders may offer similar mechanical configurations but different code formats or output stages. The following models are relevant comparison points within the XCC2912 family.
| Model | Output stage | Position format | Key consideration |
|---|---|---|---|
| XCC2912PS81SBN | SSI | 13-bit binary | Same general interface family, but uses binary rather than Gray code |
| XCC2912PS81SGN | SSI | 13-bit Gray code | Reference model |
| XCC2912PS81KBN | Push-pull | 13-bit binary | Different output interface and code format |
| XCC2912PS81KGN | Push-pull | 13-bit Gray code | Different output interface |
| XCC2930TS81SGN | SSI | 13-bit Gray code | Through-shaft design; mechanical configuration differs |
These models are comparison options, not guaranteed drop-in replacements. Before selecting an alternative, verify the complete part number, shaft design, mounting dimensions, connector pinout, output interface, code format, supply voltage, and receiver compatibility.
The difference between SSI and push-pull outputs is especially important. A controller configured for SSI cannot necessarily read a push-pull absolute encoder directly, even if both devices provide a similar number of position codes.
9. Key Advantages
Absolute Position Feedback
The encoder provides a position code for the shaft’s current angle within one revolution. This can simplify position identification compared with systems that rely exclusively on incremental pulse counting.
13-Bit Resolution
With 8192 nominal position values per revolution, the encoder provides a defined digital position increment for compatible industrial control systems.
SSI Communication
SSI provides a synchronous serial method for transmitting absolute position data. It allows the encoder to communicate with suitable industrial interfaces without relying on an incremental pulse train for position reconstruction.
Gray-Code Output
Gray-coded position data changes one bit at a time between adjacent codes. This characteristic can help reduce ambiguity during transitions when the receiver and communication timing are correctly implemented.
Industrial Mechanical Configuration
The 90 mm housing and 12 mm solid shaft are intended for installations designed around this encoder format. Appropriate mounting and coupling components remain essential for reliable operation.
Integration into Automation Systems
When paired with a compatible PLC or motion controller, the XCC2912PS81SGN can provide position data for rotary positioning, machine sequencing, movement monitoring, and other automation functions.
10. Technical FAQs
What is the Schneider XCC2912PS81SGN?
It is a single-turn absolute rotary encoder from the OsiSense XCC family. It provides 13-bit, 8192-position feedback using SSI communication and Gray-code output.
What is the resolution of the XCC2912PS81SGN?
The encoder provides 8192 positions per revolution, corresponding to 13-bit resolution.
What is the difference between an absolute encoder and an incremental encoder?
An absolute encoder reports a coded position within its measurement range. An incremental encoder generates pulses representing movement, which the controller counts to determine relative position. A single-turn absolute encoder does not independently track the number of complete revolutions.
What output interface does this model use?
The XCC2912PS81SGN uses an SSI synchronous serial interface with Gray-coded position data. The receiving device must support the relevant SSI communication and code format.
What is the supply voltage?
The specified supply voltage range is 11–30 V DC. Confirm the supply and wiring requirements against the exact product documentation.
What is the shaft diameter?
The encoder has a 12 mm solid shaft. The mechanical coupling and mounting arrangement must be compatible with the shaft dimensions.
What connector does it use?
It uses a radial 16-pin M23 male connector. A matching connector or suitable cable assembly is required.
Can it connect directly to a standard PLC?
Only if the PLC or an associated interface module supports the encoder’s SSI signals and Gray-code data. A standard digital input or incremental encoder input is not necessarily compatible.
Can it measure multiple revolutions?
The XCC2912PS81SGN is a single-turn absolute encoder. It reports position within one revolution but does not independently provide a multi-turn revolution count. A multi-turn encoder or additional tracking method is required if the application needs that information.
What is the weight of the XCC2912PS81SGN?
The specified product weight is 1.37 kg. Shipping weight may differ depending on packaging and accessories.
What should be checked before ordering a replacement?
Verify the complete model number, 13-bit resolution, SSI interface, Gray-code format, supply voltage, solid-shaft dimensions, connector pinout, and compatibility with the receiving controller.
11. Procurement and Maintenance Recommendations
When sourcing the Schneider XCC2912PS81SGN, verify the complete model number and the output format. Similar XCC encoders may use binary code, Gray code, SSI, or push-pull outputs, and these differences can affect whether a replacement works with the existing control system.
For maintenance purposes, retain the encoder’s model identification, connection diagram, controller configuration, and mechanical mounting details. This information can reduce troubleshooting time if the encoder needs to be replaced.
During inspection, check the shaft coupling, mounting hardware, connector, and cable condition. If the position data becomes unstable or invalid, investigate the power supply, SSI clock and data signals, receiver settings, and mechanical installation before assuming the encoder has failed.
For international spare-parts procurement, confirm the unit’s condition, identification, included accessories, packaging, and warranty arrangements with the supplier. If the encoder is being used in an existing machine, compare its specifications with the original unit before placing an order.
12. Conclusion
The Schneider Electric XCC2912PS81SGN is a single-turn absolute encoder with a 90 mm housing, a 12 mm solid shaft, 13-bit resolution, and SSI Gray-code output. It operates from an 11–30 V DC supply, uses a radial 16-pin M23 male connector, and has a specified product weight of 1.37 kg.
When connected to a compatible SSI receiver, it can provide absolute angular-position information for industrial automation, rotary positioning, machine sequencing, and motion monitoring.
Before installation or replacement, confirm the interface type, Gray-code configuration, supply requirements, connector wiring, shaft dimensions, and mechanical mounting. These checks help ensure that the encoder can operate correctly within the intended industrial control system.