

ProductPRODUCT
Featured products
Contact Us
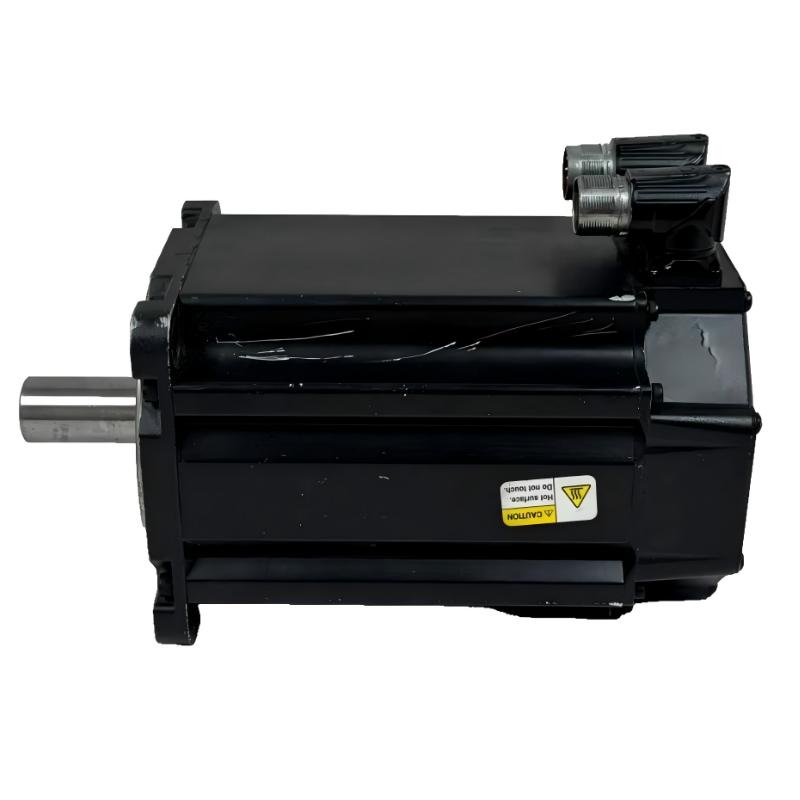
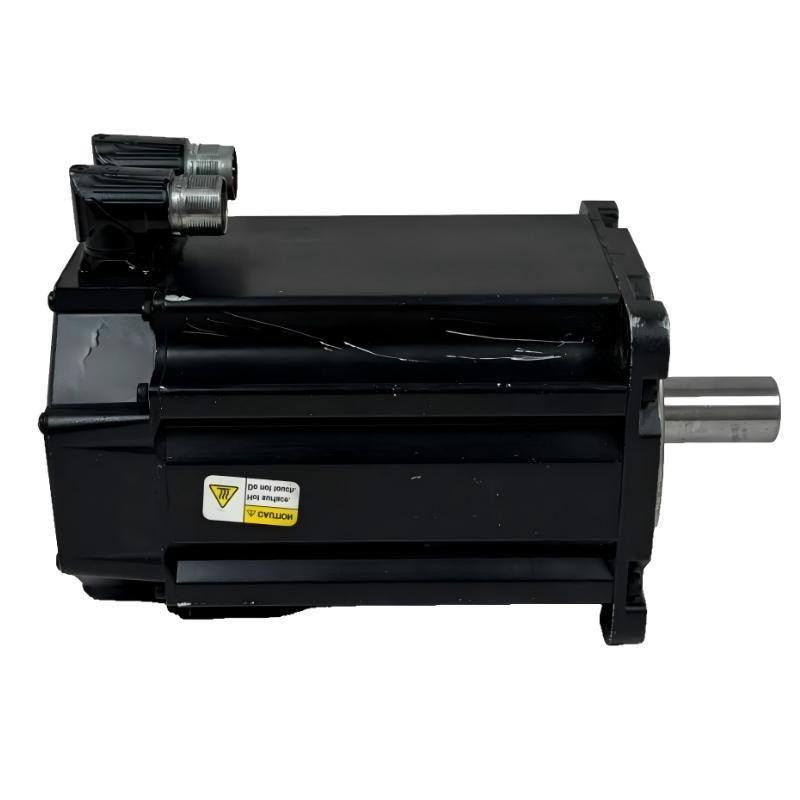
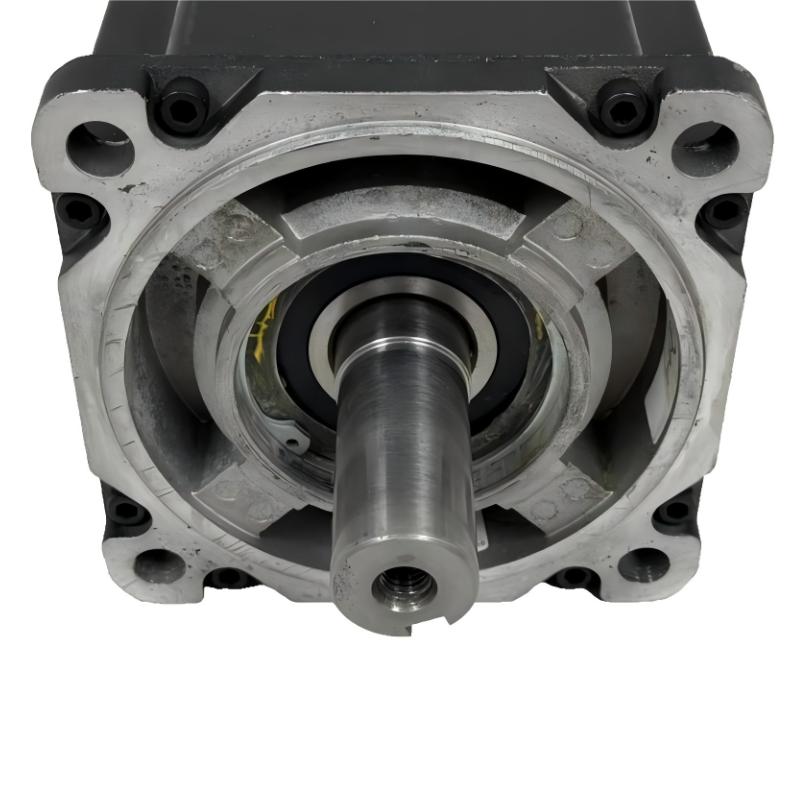
- Allen Bradley
- MPL-B660F-MJ74AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 215 mm × 150 mm × 35 mm
- 42.9 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 34
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
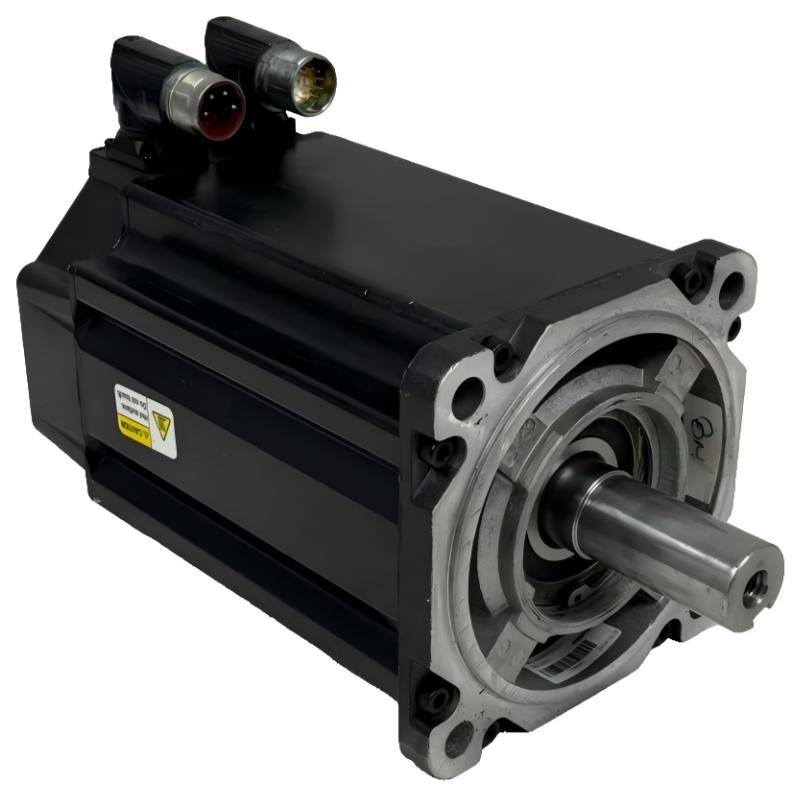
Allen-Bradley MPL-B660F-MJ74AA Low-Inertia Servo Motor — Detailed Product Information and Model Selection Guide
1. Product Overview
The Allen-Bradley MPL-B660F-MJ74AA is a high-performance AC rotary servo motor belonging to the MP-Series MPL low-inertia brushless servo motor family. It is designed for industrial motion-control applications where high torque density, accurate position feedback, rapid acceleration, and reliable dynamic response are important.
This model uses a 460 V-class AC supply, a 215 mm frame size, and a 152.4 mm magnet stack length. Its rated speed is 3000 rpm, making it suitable for a wide range of medium- and high-performance servo axes.
A major feature of the MPL-B660F-MJ74AA is its multi-turn high-resolution absolute encoder. Unlike a simple incremental encoder, an absolute feedback system provides the motion controller with absolute position information, which is particularly useful in applications where position retention and accurate startup behavior are important.
The motor also includes a 24 V DC holding brake, making this configuration particularly useful for vertical or gravity-loaded axes where the motor shaft may need to be mechanically held when the servo drive is disabled.
2. Basic Product Information
| Parameter | Specification |
|---|---|
| Brand | Allen-Bradley |
| Product Series | MP-Series |
| Product Family | MPL Low-Inertia Brushless Servo Motors |
| Model | MPL-B660F-MJ74AA |
| Product Type | AC Rotary Servo Motor |
| Motor Type | Permanent-Magnet Brushless Servo Motor |
| Voltage Class | 460 V AC / 480 V class |
| Rated Speed | 3000 rpm |
| Frame Size | 6 / 215 mm |
| Magnet Stack Length | 152.4 mm / 6.0 in |
| Continuous Rated Torque | Approximately 48 N·m |
| Peak Torque | Approximately 101 N·m class |
| Rated Output Power | Approximately 6.15 kW |
| Feedback | Multi-turn high-resolution absolute encoder |
| Feedback Resolution | 1024 Sin/Cos cycles per revolution |
| Feedback Protocol | Hiperface |
| Shaft | Keyed shaft extension |
| Brake | 24 V DC holding brake |
| Connector | SpeedTEC DIN, right-angle |
| Connector Rotation | Approximately 180° rotatable |
| Mounting | IEC metric flange, free mounting holes |
| Bolt Circle | Approximately 215 mm |
| Enclosure | IP50 class as standard configuration; higher protection can depend on shaft-seal configuration |
| Operating Temperature | Approximately 0 to 40 °C |
| Dimensions | 215 mm frame; 152.4 mm magnet stack length; complete envelope is configuration dependent |
| Weight | Approximately 42.9 kg; actual shipping/product configuration may vary |
3. Brand and Product Series
Brand: Allen-Bradley
The MPL-B660F-MJ74AA belongs to the Allen-Bradley industrial motion-control product portfolio. Allen-Bradley servo motors are commonly used together with industrial servo drives, motion controllers, PLC-based motion systems, and machine automation equipment.
For users selecting a complete motion system, the important point is that the motor is not intended to operate as a stand-alone motor in the conventional sense. It is designed as part of a coordinated servo system consisting of the motor, servo drive, feedback system, power cabling, feedback cabling, controller, and mechanical load.
Product Series: MP-Series MPL
The model belongs to the MP-Series MPL family, specifically the low-inertia brushless servo motor range.
The MPL family is designed around a relatively low rotor inertia and high torque density. This makes it particularly suitable for applications requiring frequent acceleration and deceleration, rapid positioning, indexing, electronic gearing, and coordinated motion.
4. Understanding the Model Number
The model number MPL-B660F-MJ74AA contains useful information about the motor configuration.
| Model Code | General Meaning |
|---|---|
| MPL | MPL low-inertia brushless servo motor family |
| B | 460 V-class motor |
| 6 | Frame size 6 / approximately 215 mm |
| 60 | 152.4 mm magnet stack length |
| F | 3000 rpm speed class |
| M | Multi-turn high-resolution absolute feedback |
| J | Keyed shaft extension |
| 7 | SpeedTEC DIN right-angle connector |
| 4 | 24 V DC brake |
| AA | Product configuration suffix |
The model code is useful when comparing closely related motors. For example, the M in the feedback position differentiates this motor from models using a single-turn feedback configuration, while the 4 in the brake position identifies the 24 V DC holding-brake configuration.
5. Detailed Technical Parameters
| Parameter | MPL-B660F-MJ74AA |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Motor Technology | Brushless permanent-magnet servo |
| Voltage | 460 V AC |
| Voltage Class | 400/460 V class |
| Phase | Three-phase |
| Rated Speed | 3000 rpm |
| Maximum Speed | 3000 rpm class |
| Continuous Torque | Approximately 48 N·m |
| Peak Torque | Approximately 101 N·m |
| Rated Power | Approximately 6.15 kW |
| Frame Size | 215 mm |
| Magnet Stack | 152.4 mm |
| Bolt Circle | Approximately 215 mm |
| Rotor Inertia | Approximately 0.0058 kg·m² |
| Feedback | Multi-turn absolute |
| Encoder | High-resolution Sin/Cos |
| Feedback Resolution | 1024 cycles/rev |
| Feedback Protocol | Hiperface |
| Shaft Type | Keyed |
| Holding Brake | 24 V DC |
| Brake Type | Holding brake |
| Connector | SpeedTEC DIN |
| Connector Style | Right-angle |
| Connector Adjustment | Approximately 180° rotatable |
| Mounting | IEC metric flange |
| Mounting Holes | Free mounting holes / Type FF |
| Shaft Seal | Standard configuration does not include a shaft seal |
| Protection | Approximately IP50 standard; higher protection depends on shaft-seal configuration |
| Duty | S1 continuous-duty class |
| Operating Temperature | Approximately 0 to 40 °C |
| Dimensions | 215 mm frame × 152.4 mm magnet-stack length; complete envelope configuration dependent |
| Weight | Approximately 42.9 kg |
6. Dimensions and Mechanical Configuration
Dimensions are particularly important when replacing an existing servo motor because two motors with similar electrical ratings can have completely different mechanical mounting arrangements.
For the MPL-B660F-MJ74AA, the most important dimensional parameters are the 215 mm frame size and 152.4 mm magnet stack length.
| Mechanical Parameter | Specification |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Frame Size | 6 |
| Frame Dimension | Approximately 215 mm |
| Magnet Stack Length | 152.4 mm |
| Magnet Stack | 6.0 in |
| Bolt Circle | Approximately 215 mm |
| Mounting Standard | IEC Metric |
| Mounting Type | Free Mounting Holes / Type FF |
| Shaft | Keyed shaft extension |
| Shaft Seal | Not standard |
| Connector | Right-angle SpeedTEC DIN |
| Connector Rotation | Approximately 180° |
| Brake | 24 V DC |
| Overall Length | Configuration dependent |
| Overall Width | Configuration dependent |
| Overall Height | Configuration dependent |
| Weight | Approximately 42.9 kg |
The 215 mm frame size should be treated as a key mechanical selection parameter. When replacing another motor, the flange, bolt pattern, shaft diameter, shaft length, shaft key arrangement, and motor-body clearance should all be checked rather than relying only on the frame designation.
The complete overall motor envelope can vary according to connector arrangement, brake configuration, shaft configuration, and installation requirements. Therefore, it is safer to use the manufacturer’s dimensional drawing for final mechanical replacement work rather than assuming that the frame size alone represents the entire motor envelope.
7. Weight
The MPL-B660F-MJ74AA is a relatively large industrial servo motor.
| Parameter | Value |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Approximate Product Weight | 42.9 kg |
| Weight Class | Approximately 40–45 kg |
| Frame Size | 215 mm |
| Magnet Stack Length | 152.4 mm |
| Brake | Integrated 24 V DC holding brake |
The actual delivered weight can vary depending on packaging, connector configuration, shaft accessories, and other configuration details. For machine design and shipping calculations, using approximately 43 kg for the motor itself is a reasonable planning value, while a higher allowance should be used for packaging and handling equipment.
Because of the motor’s weight, installation should be planned carefully. For a machine with a horizontally mounted motor, the mechanical support structure must be sufficiently rigid to prevent flange deformation or vibration.
8. Torque Performance
One of the most important characteristics of the MPL-B660F-MJ74AA is its relatively high torque capability.
The motor provides approximately 48 N·m of continuous torque, with a peak torque capability in the 101 N·m class.
| Torque Parameter | Approximate Value |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Continuous Torque | 48 N·m |
| Peak Torque | 101 N·m class |
| Continuous-to-Peak Ratio | Approximately 2.1:1 |
| Rated Speed | 3000 rpm |
| Rated Power | Approximately 6.15 kW |
The difference between continuous torque and peak torque is important in servo applications.
Continuous torque is associated with the motor’s ability to sustain a load under continuous operating conditions, while peak torque is available for shorter periods during acceleration, deceleration, rapid positioning, or temporary load changes.
This makes the motor suitable for machinery where the load is not constant and where short periods of high torque are required.
9. Speed and Power
The rated speed of the MPL-B660F-MJ74AA is approximately 3000 rpm.
Its rated power is approximately 6.15 kW, placing it in a relatively high-power servo motor class compared with smaller MPL models.
| Performance Parameter | Value |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Rated Speed | 3000 rpm |
| Maximum Speed | 3000 rpm class |
| Rated Power | Approximately 6.15 kW |
| Continuous Torque | Approximately 48 N·m |
| Peak Torque | Approximately 101 N·m |
| Voltage | 460 V AC |
| Motor Type | Brushless permanent-magnet servo |
The combination of approximately 48 N·m continuous torque and 3000 rpm operation makes the motor useful for applications that need both meaningful torque and relatively fast rotational movement.
10. Low-Inertia Rotor Design
The MPL family is based on a low-inertia servo motor design.
Low rotor inertia is valuable because the servo drive does not need to accelerate a very large internal rotating mass every time the commanded speed changes.
The approximate rotor inertia of this model is in the 0.0058 kg·m² range.
| Parameter | Value |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Motor Family | MPL Low-Inertia |
| Rotor Inertia | Approximately 0.0058 kg·m² |
| Rated Speed | 3000 rpm |
| Continuous Torque | Approximately 48 N·m |
| Peak Torque | Approximately 101 N·m |
In practical machine operation, the low-inertia design can contribute to faster acceleration and deceleration, improved response to speed commands, and better performance in repetitive positioning applications.
However, motor inertia should never be evaluated independently. The actual system inertia also includes the gearbox, coupling, rollers, screws, belts, pulleys, tooling, workpiece, and reflected load inertia.
11. Multi-Turn Absolute Encoder
The MPL-B660F-MJ74AA uses a multi-turn high-resolution absolute encoder.
This is one of the most important differences between this model and some simpler feedback configurations.
| Feedback Parameter | Specification |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Feedback Type | Multi-turn absolute |
| Resolution | 1024 Sin/Cos cycles/rev |
| Encoder Type | High-resolution |
| Protocol | Hiperface |
| Feedback Function | Absolute position feedback |
| Multi-Turn Capability | Yes |
A multi-turn encoder provides information about the motor’s position across multiple revolutions. This is particularly useful when the mechanical axis can travel through more than one motor revolution and the control system needs reliable position information.
For machinery such as linear axes, rotary indexing systems, lifting mechanisms, automated positioning systems, and multi-revolution mechanical transmissions, multi-turn feedback can provide a significant practical advantage.
12. 24 V DC Holding Brake
The MPL-B660F-MJ74AA includes a 24 V DC holding brake.
| Brake Parameter | Specification |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Brake | Yes |
| Brake Voltage | 24 V DC |
| Brake Type | Holding brake |
| Main Purpose | Hold motor shaft when servo is disabled |
| Typical Application | Vertical and gravity-loaded axes |
| Brake Function | Mechanical holding rather than normal dynamic stopping |
The brake is particularly useful for vertical axes.
For example, if a servo motor is used to move a vertical slide, platform, lifting mechanism, or other gravity-loaded component, the load may tend to move downward when motor torque is removed.
The holding brake can mechanically hold the shaft when the servo system is not actively driving the motor.
It is important to understand that a holding brake should not normally be treated as a substitute for the servo drive’s controlled deceleration function. The servo system should normally decelerate the machine electrically, while the mechanical brake is used primarily for holding.
13. Keyed Shaft
The motor uses a keyed shaft extension.
| Shaft Parameter | Specification |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Shaft Type | Keyed shaft |
| Shaft Extension | Keyed |
| Mechanical Connection | Key and shaft/hub arrangement |
| Typical Uses | Couplings, pulleys, gearboxes, mechanical transmission |
A keyed shaft is a conventional and widely used mechanical interface.
It is particularly convenient for applications using traditional keyed couplings, pulleys, gearboxes, or other mechanical transmission components.
When replacing a motor, however, the shaft diameter, shaft length, key dimensions, and shaft extension must still be checked carefully.
14. SpeedTEC DIN Connector
The motor uses a right-angle SpeedTEC DIN connector configuration.
| Connector Parameter | Specification |
|---|---|
| Model | MPL-B660F-MJ74AA |
| Connector Type | SpeedTEC DIN |
| Connector Style | Right-angle |
| Connector Rotation | Approximately 180° |
| Connection Type | Quick-connect style |
| Application Benefit | Easier cable routing |
The right-angle connector arrangement can be helpful in compact machine installations.
The ability to rotate the connector arrangement provides additional flexibility when the motor is installed in a location where cable routing space is limited.
Correct cable bending radius should always be considered during installation. Even when the connector itself can be rotated, the cable should not be sharply bent or placed under excessive mechanical stress.
15. Product Introduction
The MPL-B660F-MJ74AA can be considered a higher-torque member of the MPL low-inertia servo motor family.
Its combination of a 215 mm frame, 152.4 mm magnet stack, 3000 rpm speed rating, approximately 48 N·m continuous torque, multi-turn absolute feedback, and 24 V DC holding brake gives it a strong position in applications requiring both high dynamic performance and substantial mechanical output.
The motor is particularly suitable when a machine needs repeated acceleration and deceleration without moving into an extremely large motor frame.
Compared with smaller MPL configurations, the B660F configuration provides a longer magnet stack and higher torque capability while retaining the 3000 rpm speed class.
16. Main Advantages
16.1 High Continuous Torque
The approximately 48 N·m continuous torque rating provides substantial output for medium-to-heavy industrial motion applications.
This allows the motor to drive larger mechanical loads than smaller low-inertia servo motors in the same general family.
16.2 High Peak Torque
The approximately 101 N·m peak torque capability provides additional torque reserve during acceleration and rapid positioning.
This is useful in machines with significant transient load requirements.
16.3 Low-Inertia Design
The low-inertia rotor design helps the motor respond quickly to changes in commanded speed and position.
This is particularly beneficial for repetitive motion, indexing, packaging, and automated assembly equipment.
16.4 Multi-Turn Absolute Feedback
The multi-turn absolute encoder provides high-resolution position information.
This is especially valuable in applications where accurate position information must be maintained across multiple motor revolutions.
16.5 Integrated 24 V DC Brake
The integrated brake is a major advantage for vertical and gravity-loaded applications.
It allows the motor shaft to be mechanically held when the servo drive is not actively controlling the motor.
16.6 3000 rpm Speed Class
The 3000 rpm rating provides a useful balance between torque and rotational speed.
It is suitable for many machine axes without requiring the motor to operate at an extremely high speed.
16.7 Flexible Connector Arrangement
The right-angle connector with rotational adjustment makes cable installation easier in many machine layouts.
This can be especially useful in machines with limited rear clearance.
16.8 Robust Industrial Mechanical Construction
The 215 mm frame and IEC metric flange mounting provide a substantial mechanical interface for industrial equipment.
The motor is suitable for machines where mechanical rigidity is important.
17. Typical Applications
Packaging Machinery
The MPL-B660F-MJ74AA can be used for packaging machine axes where rapid acceleration, accurate positioning, and repeated movement are required.
Typical applications include indexing mechanisms, feed systems, rotary positioning, cutting mechanisms, and material-handling axes.
Automated Assembly
Automated assembly equipment often requires precise movement and repeatability.
The combination of low inertia and high-resolution absolute feedback makes this type of motor suitable for assembly machinery where the axis repeatedly moves between defined positions.
Material Handling
The motor can be used in conveyors, transfer mechanisms, rollers, indexing systems, and other material-handling machinery.
The relatively high continuous torque is useful when the load is substantial or when acceleration requirements are demanding.
Vertical Motion
The 24 V DC holding brake makes this configuration especially relevant for vertical axes.
Possible applications include lifting tables, vertical slides, automated storage equipment, elevators within machines, and other gravity-loaded mechanisms.
The mechanical design must still provide the appropriate safety provisions for the specific application.
Machine Tools
The motor can be used for selected machine-tool axes and auxiliary motion systems where the required torque, speed, feedback, and mechanical interface are compatible.
Printing and Converting Equipment
Printing, film processing, web handling, cutting, and converting machinery often require precise synchronization between multiple axes.
The MPL-B660F-MJ74AA’s feedback and dynamic characteristics make it suitable for these types of coordinated motion systems.
Rotary Indexing Equipment
Rotary indexing systems require controlled acceleration, deceleration, and accurate stopping.
The combination of high torque and absolute feedback is useful for this type of application.
18. Five Related Models in the Same Series
The following models are useful comparison choices when selecting an MPL servo motor. They are not necessarily interchangeable without checking the complete electrical and mechanical specifications.
| Model | Frame / Stack | Speed | Feedback | Brake | Shaft | Continuous Torque | Power | Dimensions | Weight |
|---|---|---|---|---|---|---|---|---|---|
| MPL-B660F-MJ72AA | 215 mm / 152.4 mm | 3000 rpm | Multi-turn absolute | No | Keyed | Approx. 48 N·m | Approx. 6.15 kW | 215 mm frame × 152.4 mm stack | Approx. 41–43 kg |
| MPL-B660F-SJ72AA | 215 mm / 152.4 mm | 3000 rpm | Single-turn absolute | No | Keyed | Approx. 48 N·m | Approx. 6.15 kW | 215 mm frame × 152.4 mm stack | Approx. 41 kg class |
| MPL-B660F-SJ74AA | 215 mm / 152.4 mm | 3000 rpm | Single-turn absolute | 24 V DC | Keyed | Approx. 48 N·m | Approx. 6.15 kW | 215 mm frame × 152.4 mm stack | Approx. 41–43 kg |
| MPL-B640F-MJ74AA | 215 mm / 101.6 mm | 3000 rpm | Multi-turn absolute | 24 V DC | Keyed | Approx. 36.7 N·m | Approx. 6.1 kW | 215 mm frame × 101.6 mm stack | Approx. 31–32 kg |
| MPL-B560F-MJ72AA | 165 mm / 152.4 mm | 3000 rpm | Multi-turn absolute | No | Keyed | Lower than B660F | Configuration dependent | 165 mm frame × 152.4 mm stack | Approx. 30 kg class |
How to Choose Among These Five
MPL-B660F-MJ72AA is a good choice when the same basic B660F torque package is required but the holding brake is not needed.
MPL-B660F-SJ72AA is suitable when single-turn absolute feedback is acceptable and the application does not require a motor holding brake.
MPL-B660F-SJ74AA adds the 24 V DC brake while retaining the single-turn feedback configuration.
MPL-B640F-MJ74AA is useful when the machine requires a smaller magnet stack and somewhat lower torque while retaining the 215 mm frame and 3000 rpm class.
MPL-B560F-MJ72AA moves toward a smaller frame arrangement and can be considered when the B660F’s torque capacity is not necessary.
19. Five Commonly Compared Allen-Bradley Models
The following five models are useful for broader selection within the same brand and motion-control product range.
| Model | Series / Family | Voltage Class | Speed | Feedback | Brake | Continuous Torque | Dimensions | Weight |
|---|---|---|---|---|---|---|---|---|
| MPL-B640F-MJ72AA | MP-Series MPL | 460 V class | 3000 rpm | Multi-turn absolute | No | Approx. 36.7 N·m | 215 mm × 101.6 mm stack | Approx. 31 kg |
| MPL-B640F-MJ74AA | MP-Series MPL | 460 V class | 3000 rpm | Multi-turn absolute | 24 V DC | Approx. 36.7 N·m | 215 mm × 101.6 mm stack | Approx. 31–32 kg |
| MPL-B660F-MJ72AA | MP-Series MPL | 460 V class | 3000 rpm | Multi-turn absolute | No | Approx. 48 N·m | 215 mm × 152.4 mm stack | Approx. 41–43 kg |
| MPL-B660F-SJ72AA | MP-Series MPL | 460 V class | 3000 rpm | Single-turn absolute | No | Approx. 48 N·m | 215 mm × 152.4 mm stack | Approx. 41 kg class |
| MPL-B580J-MJ72AA | MP-Series MPL | 460 V class | Approx. 3750 rpm class | Multi-turn absolute | No | Approx. 34 N·m class | 165 mm frame × 203.2 mm stack | Approx. 30–34 kg |
These models are better viewed as selection and comparison references rather than direct drop-in replacements.
A motor should only be substituted after checking voltage class, drive compatibility, feedback interface, brake wiring, shaft dimensions, flange pattern, torque-speed characteristics, inertia, cable configuration, and environmental requirements.
20. MPL-B660F-MJ74AA vs. MPL-B660F-MJ72AA
These two models are mechanically very close and therefore make an especially useful comparison.
| Parameter | MPL-B660F-MJ74AA | MPL-B660F-MJ72AA |
|---|---|---|
| Frame | 215 mm | 215 mm |
| Magnet Stack | 152.4 mm | 152.4 mm |
| Speed | 3000 rpm | 3000 rpm |
| Feedback | Multi-turn absolute | Multi-turn absolute |
| Shaft | Keyed | Keyed |
| Brake | 24 V DC | None |
| Continuous Torque | Approx. 48 N·m | Approx. 48 N·m |
| Peak Torque | Approx. 101 N·m | Approx. 101 N·m |
| Power | Approx. 6.15 kW | Approx. 6.15 kW |
| Rotor Inertia | Approx. 0.0058 kg·m² | Approx. 0.0058 kg·m² |
| Dimensions | 215 mm frame × 152.4 mm stack | 215 mm frame × 152.4 mm stack |
| Weight | Approx. 42.9 kg | Approx. 41 kg |
| Best Use | Vertical/gravity-loaded axes | Horizontal axes where brake is unnecessary |
The main difference is the brake configuration.
If the axis is horizontal and the mechanical system does not require a holding brake, the MJ72AA configuration may be more appropriate.
If the axis is vertical or has a tendency to move under gravity when the motor is disabled, the MJ74AA configuration is generally more attractive.
21. MPL-B660F-MJ74AA vs. MPL-B640F-MJ74AA
These two models are also useful for understanding the relationship between magnet-stack length and torque.
| Parameter | MPL-B660F-MJ74AA | MPL-B640F-MJ74AA |
|---|---|---|
| Frame | 215 mm | 215 mm |
| Magnet Stack | 152.4 mm | 101.6 mm |
| Speed | 3000 rpm | 3000 rpm |
| Feedback | Multi-turn absolute | Multi-turn absolute |
| Brake | 24 V DC | 24 V DC |
| Shaft | Keyed | Keyed |
| Continuous Torque | Approx. 48 N·m | Approx. 36.7 N·m |
| Peak Torque | Approx. 101 N·m | Approx. 72.3 N·m |
| Power | Approx. 6.15 kW | Approx. 6.1 kW |
| Rotor Inertia | Approx. 0.0058 kg·m² | Approx. 0.004 kg·m² |
| Frame Dimension | 215 mm | 215 mm |
| Stack Length | 152.4 mm | 101.6 mm |
| Weight | Approx. 42.9 kg | Approx. 31 kg |
The B660F has the longer magnet stack and consequently provides greater torque capability.
The B640F is physically lighter and has a shorter motor body, making it attractive where the machine’s torque requirement does not justify the larger B660F configuration.
22. Why the MPL-B660F-MJ74AA Is Attractive for Vertical Axes
The brake is one of the strongest reasons to select the MJ74AA configuration.
Consider a vertical machine axis.
The servo motor has to overcome the force caused by gravity during normal movement. When the servo drive is disabled, however, the mechanical load may attempt to move downward.
A holding brake provides an additional mechanical means of keeping the shaft stationary.
The basic operating concept is:
Servo drive active → motor produces controlled torque → brake released
Servo drive disabled → brake engages → shaft is mechanically held
The exact brake-control sequence should be determined by the servo drive and machine safety design rather than treating the brake as an emergency stopping device.
23. Advantages in High-Duty-Cycle Machinery
The MPL-B660F-MJ74AA is well suited to machinery that performs repeated movement.
For example, a packaging machine may accelerate a mechanism, move it to a defined position, decelerate, stop, reverse direction, and repeat the cycle thousands of times.
A low-inertia servo motor is useful in this situation because the rotor itself does not represent an excessively large rotating mass.
At the same time, the motor’s approximately 48 N·m continuous torque and approximately 101 N·m peak torque provide useful torque reserve for acceleration and transient load conditions.
24. Installation Considerations
When installing the MPL-B660F-MJ74AA, several points should be checked carefully.
Mechanical Mounting
The mounting flange should be properly aligned with the machine.
The mounting structure should be sufficiently rigid to prevent vibration and mechanical resonance.
The 215 mm frame size and bolt-circle arrangement should be checked against the machine drawing before installation.
Shaft Coupling
The keyed shaft should be correctly matched to the coupling, gearbox, pulley, or other mechanical transmission component.
Misalignment should be avoided because excessive radial or axial load can reduce bearing life.
Cable Installation
The SpeedTEC DIN connector should be positioned to provide adequate cable clearance.
Cable bending radius should be respected, particularly where the motor is mounted in a confined space.
Brake Wiring
The 24 V DC brake must be connected according to the intended control sequence.
The brake should not simply be treated as another motor winding.
Feedback Wiring
The high-resolution absolute encoder requires the correct feedback cable and compatible servo-drive feedback interface.
Incorrect feedback wiring can prevent the drive from establishing a valid motor position signal.
25. Maintenance Considerations
The MPL-B660F-MJ74AA is designed for industrial service, but maintenance remains important.
The motor should be inspected for abnormal vibration, unusual bearing noise, excessive temperature, cable damage, connector damage, and mechanical coupling problems.
The shaft and flange should also be checked periodically for signs of misalignment.
For applications with frequent acceleration and deceleration, monitoring motor temperature and drive load can provide useful information about whether the motor is operating within the expected thermal range.
The brake should also be checked in applications where the holding function is important.
26. Important Selection Factors
Before purchasing or replacing an MPL-B660F-MJ74AA, the following parameters should be checked.
| Selection Item | What to Check |
|---|---|
| Voltage | 460 V-class compatibility |
| Servo Drive | Drive must be compatible with the motor |
| Rated Speed | 3000 rpm requirement |
| Continuous Torque | Approximately 48 N·m requirement |
| Peak Torque | Approximately 101 N·m transient requirement |
| Power | Approximately 6.15 kW class |
| Feedback | Multi-turn absolute encoder compatibility |
| Encoder | 1024 Sin/Cos / Hiperface compatibility |
| Brake | 24 V DC brake requirement |
| Shaft | Keyed shaft compatibility |
| Flange | 215 mm frame and mounting pattern |
| Stack Length | 152.4 mm |
| Connector | SpeedTEC DIN configuration |
| Environment | Temperature and enclosure requirements |
| Shaft Seal | Determine whether additional sealing is required |
| Weight | Approximately 42.9 kg |
| Mechanical Load | Radial and axial load requirements |
| Inertia | Motor/load inertia matching |
27. Recommended Applications by Motor Characteristic
| Motor Characteristic | Recommended Application |
|---|---|
| 48 N·m continuous torque | Medium/heavy servo axes |
| ~101 N·m peak torque | High-acceleration machinery |
| 3000 rpm | General industrial motion |
| Low rotor inertia | Rapid positioning |
| Multi-turn absolute feedback | Multi-revolution positioning |
| 24 V DC brake | Vertical axes |
| Keyed shaft | Conventional mechanical transmission |
| 215 mm frame | Larger industrial machinery |
| 152.4 mm stack | Higher torque applications |
| Right-angle connector | Space-constrained cable routing |
28. Main Advantages at a Glance
| Advantage | Explanation |
|---|---|
| High torque | Approximately 48 N·m continuous torque |
| High peak output | Approximately 101 N·m peak torque class |
| Low inertia | Good dynamic response |
| Absolute feedback | Accurate position information |
| Multi-turn feedback | Useful for multi-revolution axes |
| Integrated brake | Suitable for holding gravity-loaded axes |
| 3000 rpm | Good balance of speed and torque |
| Keyed shaft | Conventional mechanical connection |
| Flexible connector | Easier machine cable routing |
| Industrial construction | Suitable for demanding automation equipment |
29. Overall Evaluation
The Allen-Bradley MPL-B660F-MJ74AA is a strong choice when a machine requires a combination of high servo torque, 3000 rpm operation, low-inertia response, multi-turn absolute feedback, and a 24 V DC holding brake.
Its approximately 48 N·m continuous torque and approximately 101 N·m peak torque place it above the smaller B640F configuration in terms of torque capability, while the 215 mm frame keeps it within a manageable industrial servo-motor size class.
The multi-turn absolute encoder is another major advantage. It provides the feedback characteristics needed for sophisticated motion-control systems and is particularly useful when the mechanical axis operates through multiple motor revolutions.
The integrated 24 V DC holding brake makes the MJ74AA version especially attractive for vertical or gravity-loaded machinery.
The main trade-off is physical size and weight. At approximately 42.9 kg, this is not a lightweight servo motor, and machine designers should provide adequate mechanical support and consider installation and maintenance access.
30. Final Specification Summary
| Category | MPL-B660F-MJ74AA |
|---|---|
| Brand | Allen-Bradley |
| Series | MP-Series MPL |
| Family | MPL Low-Inertia Brushless Servo Motors |
| Model | MPL-B660F-MJ74AA |
| Motor Type | AC rotary permanent-magnet brushless servo |
| Voltage | 460 V AC |
| Frame | 6 / 215 mm |
| Magnet Stack | 152.4 mm |
| Rated Speed | 3000 rpm |
| Continuous Torque | Approximately 48 N·m |
| Peak Torque | Approximately 101 N·m |
| Rated Power | Approximately 6.15 kW |
| Rotor Inertia | Approximately 0.0058 kg·m² |
| Feedback | Multi-turn high-resolution absolute |
| Encoder Resolution | 1024 Sin/Cos cycles/rev |
| Protocol | Hiperface |
| Shaft | Keyed |
| Brake | 24 V DC holding brake |
| Connector | SpeedTEC DIN right-angle |
| Connector Rotation | Approximately 180° |
| Mounting | IEC metric flange / Type FF |
| Bolt Circle | Approximately 215 mm |
| Dimensions | 215 mm frame × 152.4 mm stack; complete envelope configuration dependent |
| Weight | Approximately 42.9 kg |
| Typical Applications | Packaging, assembly, material handling, vertical axes, indexing, machine tools, printing/converting |
| Main Strength | High torque + low inertia + multi-turn feedback + holding brake |
Conclusion
Overall, the MPL-B660F-MJ74AA is best regarded as a high-torque, low-inertia industrial servo motor for demanding motion-control applications.
Its combination of a 215 mm frame, 152.4 mm magnet stack, 3000 rpm rating, approximately 48 N·m continuous torque, approximately 101 N·m peak torque, multi-turn absolute feedback, keyed shaft, and 24 V DC holding brake makes it particularly well suited to machines where dynamic performance and reliable position control are more important than minimizing motor size and weight.
For a direct replacement, the most important checks are not simply the model number. The servo drive compatibility, feedback type, brake configuration, flange dimensions, shaft dimensions, torque-speed requirements, cable arrangement, and overall motor envelope should all match the existing machine design.