

ProductPRODUCT
Featured products
Contact Us
- Allen Bradley
- MPL-B320P-HJ72AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 63 mm × 63 mm × 150 mm
- 3.8kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 36
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
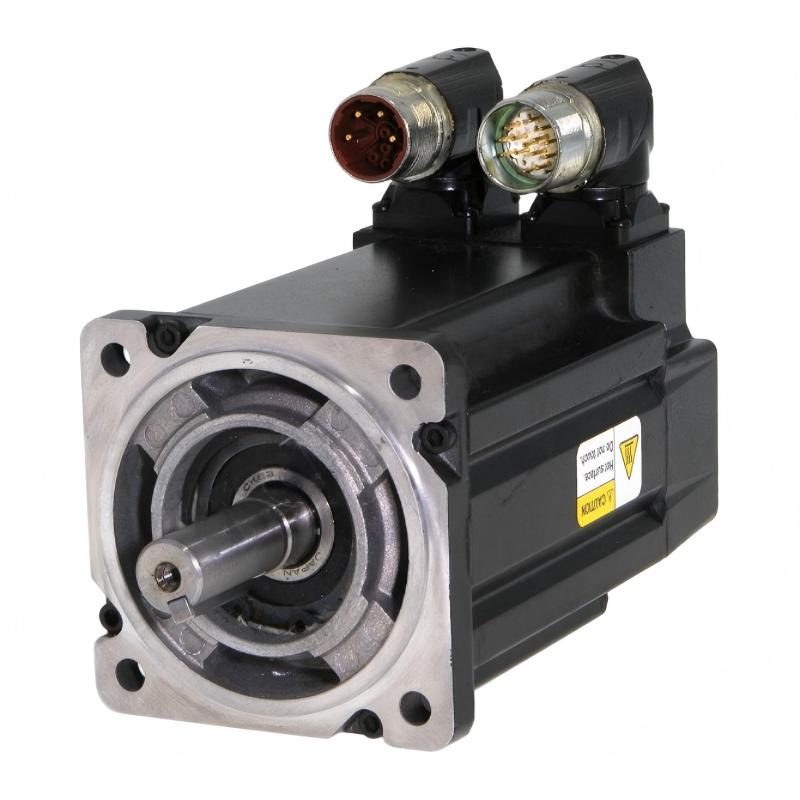
Allen-Bradley MPL-B320P-HJ72AA Servo Motor
1. Product Overview
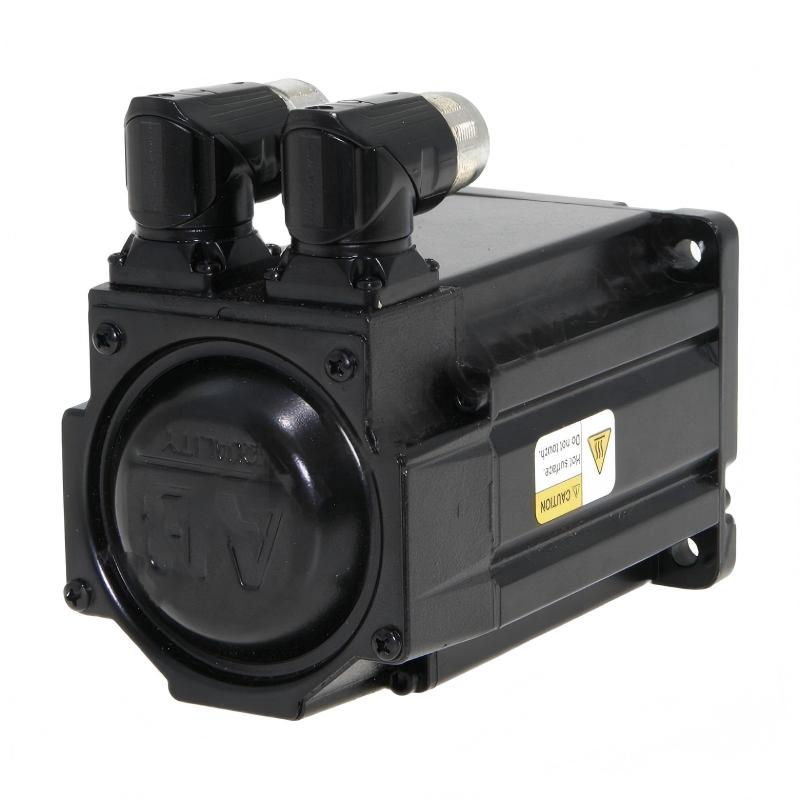
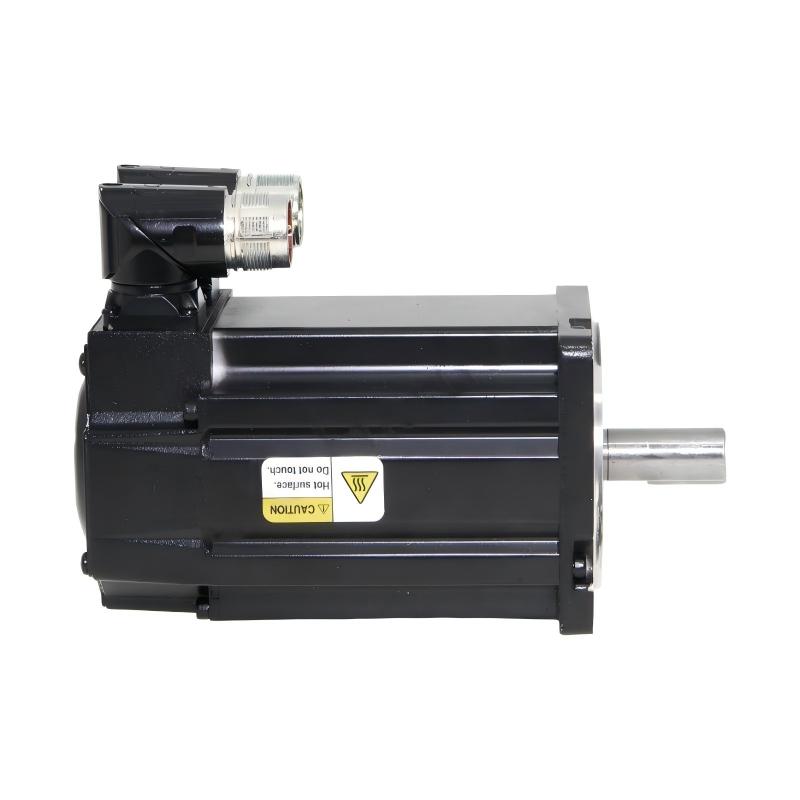
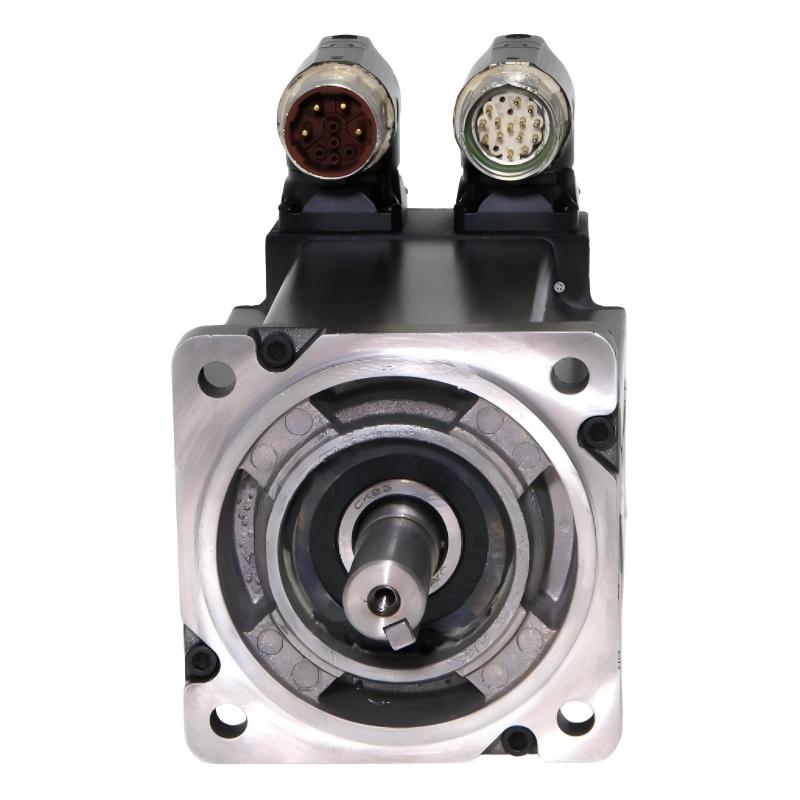
The Allen-Bradley MPL-B320P-HJ72AA is an MP-Series MPL low-inertia brushless AC rotary servo motor designed for high-speed, responsive motion-control applications. It uses a 460 V-class electrical system, a 100 mm frame, a 50.8 mm magnet stack, a rated speed of 5000 rpm, a keyed shaft extension, and a 2000-line incremental encoder. The motor is supplied without an integral brake and uses a SpeedTEC DIN connector with a right-angle, rotatable configuration.
The HJ72AA configuration is particularly suitable for machines that require rapid acceleration and deceleration, repeatable positioning, coordinated rotary motion, and reliable feedback from the motor shaft. Its low-inertia construction allows the motor to respond quickly to command changes, which is especially useful in applications where short cycle times and frequent positioning corrections are important.
The model belongs to the MPL low-inertia servo motor family and is built around a 100 mm metric flange frame. Its 50.8 mm magnet stack provides substantially more active motor length than shorter B320P configurations, resulting in a continuous torque rating of approximately 3.05 Nm and a peak torque rating of approximately 7.91 Nm.
The model is also notable for its 2000 pulses/revolution incremental encoder. Unlike absolute single-turn or multi-turn encoder configurations, the incremental feedback arrangement provides pulse-based position and speed feedback to the servo drive. This makes it a practical choice for motion systems where the drive and control architecture are designed around incremental feedback.
2. Basic Product Parameters
| Parameter | Specification |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Brand | Allen-Bradley |
| Series | MP-Series MPL |
| Product Family | MPL Low-Inertia Brushless Servo Motors |
| Product Type | AC Rotary Servo Motor |
| Motor Type | Brushless Permanent-Magnet Servo Motor |
| Voltage Class | 400 V AC class |
| Armature Voltage | 460 V |
| Frame Size | 3 / 100 mm |
| Magnet Stack Length | 20 / 50.8 mm |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Continuous Output Torque | Approximately 3.05 Nm |
| Peak Output Torque | Approximately 7.91 Nm |
| Continuous Rated Power | Approximately 1.5 kW |
| Feedback | Incremental Encoder |
| Feedback Resolution | 2000 pulses/revolution |
| Shaft | Keyed Shaft Extension |
| Brake | No integral brake |
| Connector | SpeedTEC DIN, right-angle configuration |
| Connector Orientation | 180° rotatable |
| Mounting | Metric flange mounting |
| Mounting Hole Style | Free mounting holes / Type FF |
| Shaft Seal | Not fitted as standard |
| Standard Enclosure | IP50 |
| Optional Sealed Configuration | IP66 when correctly configured with shaft seal and environmentally sealed cable/connector arrangement |
| Rotor Inertia | Approximately 7.8 × 10⁻⁵ kg·m² |
| Weight | Approximately 3.7 kg |
| Operating Temperature | Approximately 0 to 40 °C |
| Storage Temperature | Approximately -30 to 70 °C |
| Model Configuration | Incremental encoder, keyed shaft, no brake |
The technical data identifies the motor as a 5000 rpm, 3.05 Nm continuous-torque incremental-encoder servo motor with a 100 mm frame and 50.8 mm magnet stack. The listed reference weight is approximately 3.7 kg.
3. Brand
Brand: Allen-Bradley
Allen-Bradley is widely associated with industrial automation, motion control, servo systems, programmable controllers, and factory automation equipment. The MPL-B320P-HJ72AA belongs to its MP-Series servo motor family and is intended to operate as part of an integrated servo motion-control system.
For replacement work, the complete catalog number should be used rather than selecting a motor only by frame size or torque. The HJ72AA suffix identifies important characteristics such as the incremental encoder, keyed shaft arrangement, connector configuration, and absence of an integral brake.
4. Product Series
Series: MP-Series MPL Low-Inertia Brushless Servo Motors
The MPL series is designed around a low-inertia motor construction. This design approach is useful where the motor needs to change speed quickly and follow frequent motion commands without excessive mechanical inertia.
The MPL family includes different voltage classes, frame sizes, magnet stack lengths, feedback systems, shaft configurations, connector arrangements, and brake options. Consequently, two motors that appear similar physically can have significantly different electrical and feedback requirements.
The MPL-B320P-HJ72AA specifically combines the 100 mm frame with the longer 50.8 mm magnet stack and an incremental encoder. This configuration provides a higher torque level than shorter B320P stack versions while maintaining the responsive characteristics expected from the MPL family.
5. Product Type
The MPL-B320P-HJ72AA is a brushless AC rotary servo motor.
It is not simply a conventional constant-speed industrial motor. A servo motor is intended to operate with a compatible servo drive and feedback system so that speed, position, acceleration, and torque can be controlled accurately.
The motor’s incremental encoder supplies feedback to the drive. The drive uses this feedback together with the motion command to regulate motor operation. This closed-loop arrangement is fundamental to servo positioning systems.
The motor’s low rotor inertia also makes it suitable for applications involving repeated acceleration, deceleration, indexing, positioning, and rapid direction changes.
6. Model Number Explanation
The model number can be understood as a configuration code rather than simply a product name.
| Model Code | Meaning |
|---|---|
| MPL | MPL low-inertia brushless servo motor family |
| B | 400/460 V-class motor configuration |
| 3 | Frame size 3 / approximately 100 mm |
| 20 | Magnet stack length 20 / 50.8 mm |
| P | 5000 rpm speed class |
| H | Incremental encoder feedback configuration |
| J | Keyed shaft configuration |
| 7 | SpeedTEC DIN connector configuration |
| 2 | No integral brake |
| AA | Catalog configuration / version designation |
This coding structure is important when selecting a replacement. Changing only one letter or number can change the feedback type, shaft arrangement, brake configuration, or mechanical characteristics.
For example, an HJ72AA motor should not automatically be replaced by an SK72AA motor simply because both may have the same general frame size. The HJ configuration uses incremental feedback, while the SK configuration uses a different feedback arrangement.
7. Detailed Technical Specifications
| Technical Parameter | MPL-B320P-HJ72AA Specification |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Servo Motor Type | Brushless AC rotary servo |
| Voltage | 460 V |
| Voltage Class | 400 V AC class |
| Frame Size | 100 mm |
| Magnet Stack | 50.8 mm |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Continuous Torque | 3.05 Nm |
| Peak Torque | 7.91 Nm |
| Continuous Power | 1.5 kW |
| Rotor Inertia | 7.8 × 10⁻⁵ kg·m² |
| Feedback | Incremental encoder |
| Encoder Resolution | 2000 pulses/revolution |
| Shaft | Keyed |
| Brake | No brake |
| Connector | SpeedTEC DIN |
| Connector Direction | Right-angle |
| Connector Rotation | 180° rotatable |
| Mounting | Metric flange |
| Standard Protection | IP50 |
| Optional Protection | IP66 with appropriate shaft-seal and sealed-cable configuration |
| Dimensions | 100 mm frame size; 50.8 mm magnet-stack length; complete external envelope depends on mechanical configuration |
| Weight | Approximately 3.7 kg |
The 3.05 Nm continuous torque, 7.91 Nm peak torque, 1.5 kW continuous power, and 7.8 × 10⁻⁵ kg·m² rotor inertia are representative technical values published for this exact configuration.
8. Frame Size and Dimensions
The MPL-B320P-HJ72AA uses a Frame Size 3 / 100 mm motor body.
The 100 mm frame designation is an important mechanical dimension because it determines the general mounting interface and helps define the physical relationship between the motor and machine structure.
The motor also has a 50.8 mm magnet stack length, corresponding to the “20” section of the model designation.
For catalog purposes, the most useful dimensional values are therefore:
| Dimension Parameter | Value |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Frame Size | 100 mm |
| Magnet Stack Length | 50.8 mm |
| Frame Classification | Frame 3 |
| Mounting Style | Metric flange |
| Mounting Hole Type | Free mounting holes / Type FF |
| Shaft Configuration | Keyed shaft |
| Overall Housing Dimensions | Refer to the mechanical installation drawing for exact envelope |
| Approximate Weight | 3.7 kg |
It is important not to confuse the 50.8 mm magnet stack length with the complete motor body length. The stack length describes the active magnetic section of the motor and is not necessarily the total outside dimension from the mounting face to the rear of the motor.
For cabinet layout, machine guarding, cable routing, coupling selection, and interference checking, the complete mechanical drawing should be used rather than estimating the total motor length from the stack dimension alone.
9. Torque Characteristics
The MPL-B320P-HJ72AA provides approximately 3.05 Nm of continuous output torque and approximately 7.91 Nm of peak torque.
The continuous torque rating represents the torque that the motor can provide under the specified continuous operating conditions. Peak torque is available for shorter periods when the application requires additional acceleration or transient load capability.
This distinction is particularly important in servo applications.
A machine may only require a moderate amount of continuous torque but still need considerably higher torque during acceleration. For example, a positioning axis can operate at a relatively steady torque during travel but require a higher torque value when rapidly accelerating a carriage, indexing a rotary table, or overcoming short-duration load disturbances.
The 50.8 mm stack version provides a useful increase in torque capability while retaining the low-inertia servo design of the MPL family.
10. Rated Power
The reference continuous power rating for this configuration is approximately 1.5 kW.
Power, torque, and speed should not be considered separately when selecting a servo motor.
At high rotational speed, relatively modest torque can correspond to significant mechanical power. Conversely, a machine may require high torque at lower speeds without continuously demanding the motor’s maximum power.
The MPL-B320P-HJ72AA is therefore better understood as a complete motion component rather than simply a 1.5 kW motor. The encoder, rotor inertia, torque curve, drive compatibility, speed requirement, load inertia, acceleration profile, and duty cycle all affect the suitability of the motor for a particular machine.
11. Incremental Encoder Feedback
One of the defining characteristics of the HJ72AA configuration is its incremental encoder.
The published specification identifies the feedback as an incremental encoder with a resolution of approximately 2000 pulses per revolution.
Incremental feedback is commonly used in servo systems that need accurate information about motor movement and rotational speed while relying on the control system and drive architecture to establish the operating position reference.
This arrangement is well suited to applications where:
- High-speed motion is required.
- Repeatable positioning is required.
- The servo drive is designed for incremental feedback.
- The machine performs repeated indexing operations.
- The control system manages the machine reference or homing sequence.
- Cost and system architecture favor an incremental feedback solution.
12. Keyed Shaft
The HJ72AA configuration uses a keyed shaft extension.
A keyed shaft provides a positive mechanical interface between the motor shaft and the coupling, pulley, gearbox, or other driven component.
This can be advantageous in applications where the mechanical coupling arrangement is designed around a shaft key and matching keyway.
The shaft configuration must always be considered when replacing an existing servo motor. A keyless motor and a keyed motor are not automatically interchangeable even if their frame dimensions and torque ratings appear similar.
13. No Integral Brake
The MPL-B320P-HJ72AA is configured without an integral motor brake.
This configuration can be useful when the machine does not require motor-mounted holding torque during power-off conditions.
A no-brake servo motor can also reduce mechanical complexity and motor weight compared with a brake-equipped version.
However, vertical axes and gravity-loaded mechanisms require special consideration. If a machine must hold a load when power is removed, the control system and mechanical design may require an external holding mechanism, counterbalance, mechanical brake, or another suitable safety-rated solution.
14. Speed Rating
The motor has a rated speed of 5000 rpm, with the published technical data also listing 5000 rpm as the maximum speed.
The 5000 rpm rating makes the motor suitable for high-speed motion applications where rapid cycle times are important.
High-speed operation is particularly useful in:
- Packaging machinery.
- Pick-and-place equipment.
- Indexing systems.
- Printing and converting equipment.
- Material handling.
- Electronic assembly machinery.
- Rotary positioning equipment.
- Automated production equipment.
The actual operating speed in a machine should be selected based on load torque, acceleration requirements, duty cycle, drive capability, mechanical balance, coupling limits, and the machine manufacturer’s design requirements.
15. Rotor Inertia
The rotor inertia is approximately 7.8 × 10⁻⁵ kg·m².
Rotor inertia is one of the most important servo-motor characteristics because it influences how quickly the motor can accelerate and decelerate.
A low-inertia motor can respond quickly to changes in commanded speed and position. This is especially beneficial for machines that repeatedly start, stop, reverse, or perform short indexing movements.
However, the motor’s own inertia is only one part of the overall inertia calculation. The reflected inertia of the gearbox, coupling, pulley, screw, rotary load, conveyor, tooling, or other mechanical components must also be considered.
A correctly matched motor-load inertia relationship helps improve servo tuning and machine response.
16. Connector Configuration
The MPL-B320P-HJ72AA uses a SpeedTEC DIN connector in a right-angle configuration. The connector arrangement is designed to allow flexible orientation, with the configuration described as 180° rotatable.
This arrangement can be useful in compact machine designs because the cable exit direction can be managed to reduce interference with nearby mechanical components.
Proper cable routing remains important.
Servo cables should be routed in accordance with the drive and machine wiring requirements, with attention to bending radius, grounding, shielding, separation from high-noise circuits, and mechanical protection.
17. Enclosure and Environmental Protection
The standard technical listing identifies an IP50 configuration without a shaft seal. An IP66 configuration is possible when the appropriate shaft seal and environmentally sealed cable/connector arrangement are used.
This distinction is important.
The motor should not be treated as an IP66 motor merely because an optional sealing configuration exists. The actual motor configuration, shaft seal, cable, connector arrangement, and installation method must all satisfy the required environmental protection level.
For applications involving coolant, washdown, dust, moisture, or other contaminants, the environmental specification should be checked carefully before installation.
18. Operating Environment
The technical reference data lists an operating temperature range of approximately 0 to 40 °C for the motor configuration. Storage temperature is listed from approximately -30 to 70 °C.
The machine environment should also be evaluated for:
- Ambient temperature.
- Humidity.
- Dust.
- Oil and coolant exposure.
- Mechanical vibration.
- Shock.
- Cable routing.
- Mounting orientation.
- Shaft sealing.
- Ventilation and heat dissipation.
A servo motor may operate correctly electrically while still experiencing reduced service life if it is installed in an environment that exceeds its mechanical or thermal limits.
19. Electrical Characteristics
| Electrical Parameter | Specification |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Armature Voltage | 460 V |
| Voltage Class | 400 V AC class |
| Rated Speed | 5000 rpm |
| Maximum Speed | 5000 rpm |
| Continuous Power | Approximately 1.5 kW |
| Continuous Torque | Approximately 3.05 Nm |
| Peak Torque | Approximately 7.91 Nm |
| Feedback | Incremental encoder |
| Encoder Resolution | 2000 pulses/rev |
| Brake | None |
| Motor Connection | SpeedTEC DIN |
| Connector Orientation | Right-angle, 180° rotatable |
| Motor Type | Brushless AC servo |
| Rotor Inertia | 7.8 × 10⁻⁵ kg·m² |
The motor should be paired with a compatible servo drive and feedback interface. The published technical data identifies compatibility with several drive families, including Kinetix 5500, Kinetix 6200/6500, Kinetix 6000, Kinetix 300, Kinetix 350, Kinetix 2000, Kinetix 7000, and Ultra 3000 families.
20. Mechanical Parameters
| Mechanical Parameter | Specification |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Frame | 3 / 100 mm |
| Magnet Stack | 50.8 mm |
| Mounting | Metric flange mount |
| Shaft | Keyed shaft extension |
| Brake | No brake |
| Shaft Seal | No standard shaft seal |
| Standard IP Rating | IP50 |
| Optional Sealed Rating | IP66 with suitable shaft seal and sealed cable/connector arrangement |
| Connector | SpeedTEC DIN |
| Connector Style | Right-angle |
| Connector Rotation | 180° |
| Weight | Approximately 3.7 kg |
| Frame Dimension | 100 mm |
| Stack Dimension | 50.8 mm |
| Overall Envelope | Must be confirmed from the mechanical drawing |
The 3.7 kg reference weight is useful for machine design and shipping calculations, but mounting hardware, cable, coupling, and optional sealing components should be considered separately.
21. Typical Applications
Packaging Machinery
The motor is well suited to packaging machinery where rapid indexing, accurate positioning, and repeated acceleration and deceleration are required.
Typical functions can include film feeding, cutting, sealing, indexing, product positioning, and rotary synchronization.
The incremental encoder provides the feedback required for closed-loop motion control, while the 5000 rpm speed rating supports high-cycle machine operation.
Material Handling
The motor can be used in automated material-handling equipment where precise movement and repeatable positioning are required.
Examples include conveyor indexing, transfer mechanisms, roller systems, automated handling axes, and positioning equipment.
Pick-and-Place Systems
Pick-and-place machines often require rapid acceleration and deceleration.
The low-inertia design of the MPL family can help the motor respond quickly to command changes, making the configuration appropriate for repetitive motion applications where cycle time is important.
Electronic Assembly Equipment
Electronic manufacturing machinery often requires controlled positioning and repeatability.
The MPL-B320P-HJ72AA can be applied to rotary positioning mechanisms, feeders, indexing mechanisms, inspection equipment, and automated assembly equipment when the mechanical load and feedback architecture are properly matched.
Printing and Converting Machinery
Printing, slitting, web handling, and converting machinery can require coordinated rotary motion.
The 5000 rpm speed rating and servo feedback make this type of motor useful where controlled speed and position are required.
Machine Tools and Automated Machinery
The motor can also be applied to automated machine tools, rotary positioning equipment, indexing axes, and other industrial machinery requiring closed-loop motion control.
Actual suitability depends on the axis load, speed profile, acceleration, inertia ratio, duty cycle, and servo-drive compatibility.
22. Main Advantages
22.1 Low-Inertia Construction
The MPL low-inertia design provides fast dynamic response.
This is particularly valuable for machines that repeatedly accelerate, decelerate, stop, and reverse.
22.2 5000 rpm High-Speed Operation
The 5000 rpm speed rating gives the motor a useful operating range for high-cycle automation.
It can support fast machine movements when the mechanical system, coupling, and drive are designed for the required speed.
22.3 3.05 Nm Continuous Torque
The approximately 3.05 Nm continuous torque rating provides a useful balance between motor size and output capability.
The 50.8 mm stack length allows the B320P configuration to deliver more continuous torque than shorter-stack configurations in the same general frame family.
22.4 7.91 Nm Peak Torque
The approximately 7.91 Nm peak torque capability allows the motor to handle short-duration acceleration and transient torque demands.
This can be useful for indexing mechanisms and dynamic positioning axes.
22.5 Incremental Encoder Feedback
The 2000 pulses/revolution incremental encoder provides motion feedback for closed-loop servo control.
This allows the drive to monitor motor movement and regulate the motor according to the commanded motion profile.
22.6 Keyed Shaft
The keyed shaft provides a familiar mechanical coupling method for many industrial applications.
It is particularly convenient when the machine design already uses keyed couplings, pulleys, gearboxes, or other keyed mechanical components.
22.7 Flexible Connector Orientation
The right-angle SpeedTEC DIN connector can be rotated through the specified orientation range.
This can simplify cable routing in compact machine assemblies.
22.8 No Integral Brake
For horizontal axes or applications where a motor brake is not required, the no-brake configuration can simplify the motor arrangement.
It also avoids unnecessary brake wiring and brake control requirements.
23. Installation Considerations
The motor should be mounted on a rigid, properly aligned machine surface.
Misalignment between the motor shaft and driven equipment can introduce excessive radial or axial loading. Over time, this can affect bearings, coupling components, and motor performance.
The mounting face should be clean and free of burrs, chips, paint buildup, or other material that could prevent proper seating.
The keyed shaft should be matched with an appropriate coupling or mechanical transmission component. The coupling should be correctly aligned before the system is operated.
24. Servo Tuning Considerations
Servo tuning should take the complete mechanical system into account.
Important factors include:
- Motor inertia.
- Reflected load inertia.
- Gear ratio.
- Coupling stiffness.
- Mechanical backlash.
- Friction.
- Acceleration.
- Deceleration.
- Maximum speed.
- Load torque.
- Position-loop requirements.
- Machine resonance.
The motor’s low rotor inertia can provide excellent dynamic response, but the complete system still needs suitable servo tuning.
A mechanically flexible load, excessive backlash, or a large inertia mismatch can reduce the benefits of a high-response servo motor.
25. Maintenance Considerations
Servo motors generally require less routine mechanical maintenance than many traditional motor systems, but they should still be inspected periodically.
Important inspection points include:
- Motor mounting bolts.
- Shaft coupling condition.
- Shaft and keyway condition.
- Encoder cable condition.
- Connector condition.
- Grounding and shielding.
- Signs of overheating.
- Bearing noise.
- Excessive vibration.
- Oil or coolant contamination.
- Cable strain.
The motor should be kept within its specified operating environment, particularly with respect to temperature and contamination.
26. Five Related Models from the Same MPL Series
The following models are closely related configurations within the MPL servo family. They should be treated as related options rather than automatically interchangeable replacements because feedback, shaft, brake, or stack configurations can differ.
| Related Model | Frame / Stack | Speed | Feedback | Shaft | Brake | Approx. Torque / Key Parameters | Dimensions / Weight |
|---|---|---|---|---|---|---|---|
| MPL-B320P-SJ72AA | 100 mm / 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyed | No brake | Similar B320P high-torque configuration | 100 mm frame; 50.8 mm stack; verify exact weight |
| MPL-B320P-SJ74AA | 100 mm / 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyed | 24 V DC brake | Brake-equipped B320P configuration | 100 mm frame; 50.8 mm stack; verify exact weight |
| MPL-B320P-SK72AA | 100 mm / 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyless | No brake | Keyless-shaft alternative | 100 mm frame; 50.8 mm stack; verify exact weight |
| MPL-B320P-HK72AA | 100 mm / 50.8 mm | 5000 rpm | Incremental encoder | Keyless | No brake | Incremental-feedback alternative | 100 mm frame; 50.8 mm stack; verify exact weight |
| MPL-B320P-MJ72AA | 100 mm / 50.8 mm | 5000 rpm | Multi-turn high-resolution | Keyed | No brake | Absolute multi-turn feedback configuration | 100 mm frame; 50.8 mm stack; verify exact weight |
The closest engineering comparison to the HJ72AA is generally another B320P configuration because the frame and stack dimensions remain closely related. The major differences are normally associated with feedback type, shaft configuration, and brake option.
27. Same-Series Comparison
| Model | Frame | Stack | Speed | Feedback | Shaft | Brake | Application Difference |
|---|---|---|---|---|---|---|---|
| MPL-B320P-HJ72AA | 100 mm | 50.8 mm | 5000 rpm | Incremental | Keyed | No | High-speed incremental servo axis |
| MPL-B320P-HK72AA | 100 mm | 50.8 mm | 5000 rpm | Incremental | Keyless | No | Same general feedback, keyless mechanical interface |
| MPL-B320P-SJ72AA | 100 mm | 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyed | No | Absolute single-turn feedback configuration |
| MPL-B320P-SJ74AA | 100 mm | 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyed | 24 V DC | Adds integral holding brake |
| MPL-B320P-SK72AA | 100 mm | 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyless | No | Keyless shaft and high-resolution feedback |
This comparison shows why the complete catalog number matters. The motors can share the same frame and stack while having different feedback systems or mechanical interfaces.
28. Five Common Allen-Bradley Servo Models
The following are additional MPL servo motor models that are commonly encountered in industrial motion-control applications. Their parameters are included as a practical reference when comparing motor families.
| Model | Series / Type | Voltage Class | Frame / Stack | Speed | Feedback | Shaft | Brake | Dimensions / Weight |
|---|---|---|---|---|---|---|---|---|
| MPL-B210V-VJ72AA | MPL Low-Inertia Servo | 400/460 V class | Smaller frame / short stack configuration | 5000 rpm class | High-resolution feedback configuration | Keyed | No brake | Smaller MPL frame; exact envelope and weight to be verified |
| MPL-B220T-VJ72AA | MPL Low-Inertia Servo | 400/460 V class | Mid-size frame / stack configuration | High-speed servo class | High-resolution feedback configuration | Keyed | No brake | Frame and stack depend on exact configuration |
| MPL-B230P-VJ72AA | MPL Low-Inertia Servo | 400/460 V class | 100 mm-class configuration | 5000 rpm class | High-resolution feedback | Keyed | No brake | Exact mechanical envelope and weight depend on configuration |
| MPL-B320P-SJ72AA | MPL Low-Inertia Servo | 400/460 V class | 100 mm / 50.8 mm | 5000 rpm | Single-turn high-resolution | Keyed | No brake | 100 mm frame; 50.8 mm stack; exact weight to be verified |
| MPL-B330P-MJ72AA | MPL Low-Inertia Servo | 400/460 V class | Larger MPL configuration | 5000 rpm class | Multi-turn high-resolution | Keyed | No brake | Larger frame; exact dimensions and weight depend on configuration |
When selecting one of these models as a replacement, the frame size, stack length, feedback type, shaft style, brake, voltage class, connector arrangement, and motor inertia should all be checked before ordering.
29. HJ72AA Compared With SJ72AA
The HJ72AA and SJ72AA can look very similar mechanically because both are associated with the B320P, 100 mm frame, 50.8 mm stack, 5000 rpm class, keyed shaft, and no-brake configuration.
The major distinction is the feedback system.
| Parameter | MPL-B320P-HJ72AA | MPL-B320P-SJ72AA |
|---|---|---|
| Frame | 100 mm | 100 mm |
| Stack | 50.8 mm | 50.8 mm |
| Speed | 5000 rpm | 5000 rpm |
| Shaft | Keyed | Keyed |
| Brake | No brake | No brake |
| Feedback | Incremental encoder | Single-turn high-resolution encoder |
| Feedback Architecture | Pulse-based incremental | High-resolution absolute single-turn |
| Mechanical Envelope | Similar family | Similar family |
| Weight | Approx. 3.7 kg for HJ72AA; verify exact SJ72AA configuration | Verify exact configuration |
Therefore, the SJ72AA should not be considered a direct electrical replacement simply because the mechanical dimensions are similar.
30. HJ72AA Compared With HK72AA
The HJ72AA and HK72AA are closer from a feedback perspective because both use incremental feedback.
The major mechanical difference is the shaft configuration.
| Parameter | MPL-B320P-HJ72AA | MPL-B320P-HK72AA |
|---|---|---|
| Frame | 100 mm | 100 mm |
| Stack | 50.8 mm | 50.8 mm |
| Speed | 5000 rpm | 5000 rpm |
| Feedback | Incremental encoder | Incremental encoder |
| Encoder Resolution | 2000 pulses/rev | Configuration-dependent; verify exact catalog data |
| Shaft | Keyed | Keyless |
| Brake | No brake | No brake |
| Mounting | Metric flange | Metric flange |
| Weight | Approx. 3.7 kg reference | Verify exact configuration |
If the machine coupling requires a key, the HJ72AA configuration is the more appropriate mechanical match than a keyless version.
31. HJ72AA Compared With a Brake Version
A brake-equipped B320P configuration can be useful for vertical axes or applications that require the motor shaft to be mechanically held when power is removed.
The HJ72AA itself does not contain an integral brake.
| Parameter | MPL-B320P-HJ72AA | MPL-B320P-SJ74AA |
|---|---|---|
| Frame | 100 mm | 100 mm |
| Stack | 50.8 mm | 50.8 mm |
| Speed | 5000 rpm | 5000 rpm |
| Shaft | Keyed | Keyed |
| Feedback | Incremental | Single-turn high-resolution |
| Brake | No brake | 24 V DC brake |
| Typical Use | Horizontal / unbraked motion axes | Axes requiring motor-mounted holding function |
| Weight | Approx. 3.7 kg | Verify exact configuration |
Brake selection should be based on the machine’s actual safety and holding requirements rather than simply selecting a brake because it is available.
32. Advantages for Industrial Automation
The MPL-B320P-HJ72AA offers a useful combination of speed, torque, feedback resolution, and mechanical flexibility.
Its 5000 rpm operating capability makes it appropriate for high-cycle automation, while the 3.05 Nm continuous torque rating gives the motor enough output for a broad range of machine axes.
The 7.91 Nm peak torque rating also provides additional short-duration torque capacity for acceleration and transient load conditions.
The 2000-pulse/revolution incremental encoder gives the servo system continuous movement feedback, while the keyed shaft makes the motor straightforward to integrate into many traditional industrial mechanical arrangements.
The low-inertia design is another important advantage. It allows the motor to respond quickly to changes in the commanded motion profile, which is especially useful for indexing and repetitive positioning applications.
33. Replacement Selection Checklist
Before replacing an MPL-B320P-HJ72AA, the following items should be checked:
| Check Item | Requirement |
|---|---|
| Model | MPL-B320P-HJ72AA |
| Voltage | 460 V class |
| Frame | 100 mm |
| Stack | 50.8 mm |
| Speed | 5000 rpm |
| Continuous Torque | Approx. 3.05 Nm |
| Peak Torque | Approx. 7.91 Nm |
| Power | Approx. 1.5 kW |
| Feedback | 2000-pulse/rev incremental encoder |
| Shaft | Keyed |
| Brake | No integral brake |
| Connector | SpeedTEC DIN |
| Mounting | Metric flange |
| Weight | Approx. 3.7 kg |
| Dimensions | 100 mm frame; 50.8 mm stack; verify complete mechanical envelope |
| Drive Compatibility | Verify servo-drive and feedback compatibility |
| Cable | Verify correct motor and feedback cable configuration |
| Application | Check speed, torque, inertia and duty cycle |
This checklist is particularly useful when an existing motor has failed and a replacement must be selected without changing the machine’s mechanical design.
34. Product Advantages at a Glance
| Feature | Advantage |
|---|---|
| 100 mm Frame | Compact industrial servo package with standardized metric mounting |
| 50.8 mm Stack | Higher torque capability within the B320P family |
| 5000 rpm | Suitable for fast machine cycles |
| 3.05 Nm Continuous Torque | Suitable for continuous industrial axis loading |
| 7.91 Nm Peak Torque | Supports short-duration acceleration demands |
| 1.5 kW Power | Useful power level for medium-duty servo axes |
| Incremental Encoder | Reliable closed-loop motion feedback |
| 2000 pulses/rev | Suitable resolution for many positioning systems |
| Keyed Shaft | Convenient mechanical coupling arrangement |
| No Brake | Simplified configuration for axes not requiring holding brake |
| Low Rotor Inertia | Fast acceleration and responsive servo control |
| Rotatable DIN Connector | Flexible cable routing |
| 3.7 kg Approx. Weight | Manageable motor mass for machine integration |
35. Final Technical Summary
The Allen-Bradley MPL-B320P-HJ72AA is a 460 V-class, 5000 rpm MPL low-inertia brushless AC servo motor with a 100 mm frame and 50.8 mm magnet stack.
It provides approximately 3.05 Nm continuous torque, approximately 7.91 Nm peak torque, approximately 1.5 kW continuous power, and approximately 7.8 × 10⁻⁵ kg·m² rotor inertia. The motor uses a 2000 pulses/revolution incremental encoder, a keyed shaft, and a SpeedTEC DIN right-angle connector. It is configured without an integral brake.
Its combination of high rotational speed, low-inertia construction, incremental feedback, keyed mechanical interface, and 100 mm metric frame makes it well suited to industrial motion-control applications requiring repeatable positioning and rapid dynamic response.
The motor’s approximate reference weight is 3.7 kg, while its principal dimensional identifiers are the 100 mm frame size and 50.8 mm magnet stack length. For machine clearance, shaft projection, mounting-hole position, connector clearance, and total motor envelope, the exact mechanical drawing for the particular revision should be used.
The most important point when selecting a replacement is that the model number must be matched as a complete configuration. Feedback type, shaft design, brake option, stack length, connector arrangement, voltage class, torque capability, and mechanical dimensions can all affect interchangeability.
For a machine originally designed around the MPL-B320P-HJ72AA, another B320P motor may be mechanically close while still being electrically incompatible because of a different encoder or feedback architecture. Therefore, the complete servo system should be considered as one matched system rather than selecting a replacement based only on horsepower or frame size.
Final Product Description
The Allen-Bradley MPL-B320P-HJ72AA is a high-speed, low-inertia industrial servo motor designed for precise closed-loop motion control. With its 100 mm frame, 50.8 mm magnet stack, 5000 rpm speed rating, approximately 3.05 Nm continuous torque, approximately 7.91 Nm peak torque, 1.5 kW continuous output, 2000-pulse/revolution incremental encoder, keyed shaft, and no-brake configuration, it provides a practical combination of dynamic response and mechanical integration for automated machinery.
It is particularly appropriate for packaging, material handling, indexing, electronic assembly, printing and converting, pick-and-place equipment, and other automated production systems where fast and repeatable rotary motion is required.
The MPL-B320P-HJ72AA is therefore best regarded as a complete servo-axis component whose performance depends not only on the motor itself, but also on correct drive selection, feedback compatibility, cable configuration, mechanical coupling, load inertia, servo tuning, and application duty cycle.