ProductPRODUCT
Featured products
Contact Us
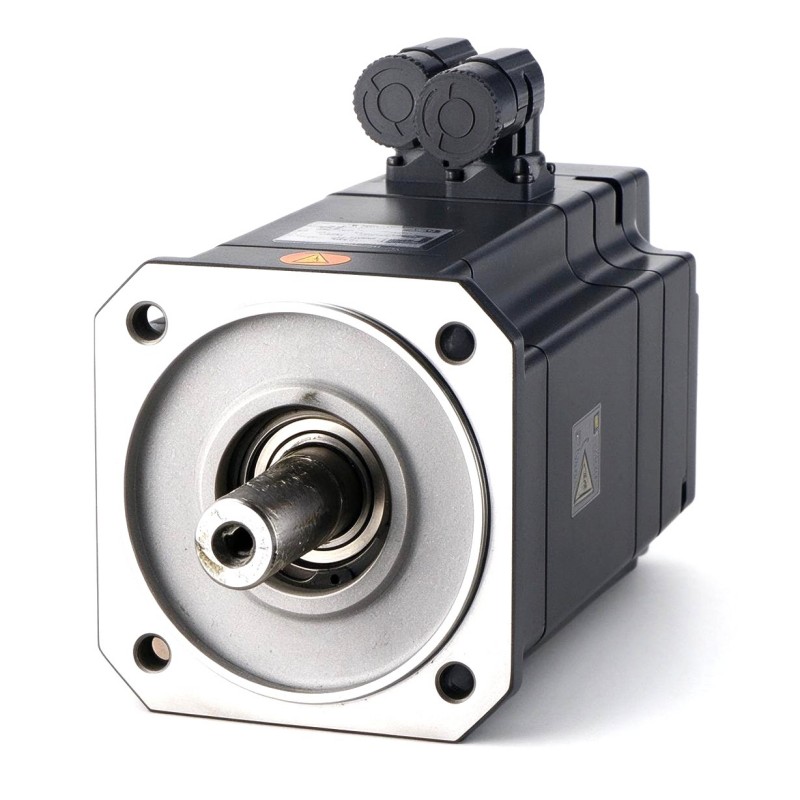
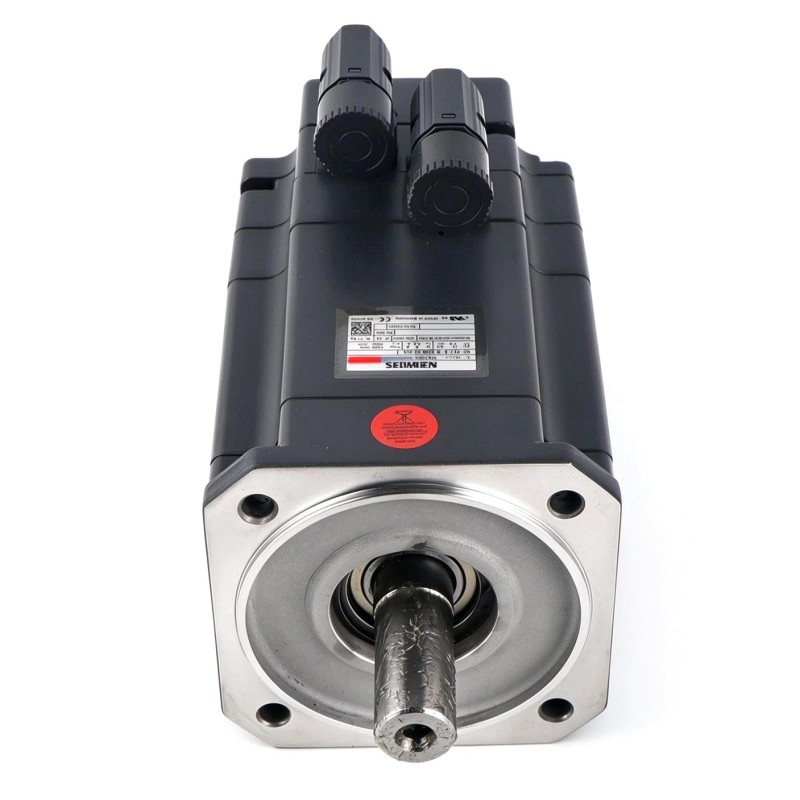
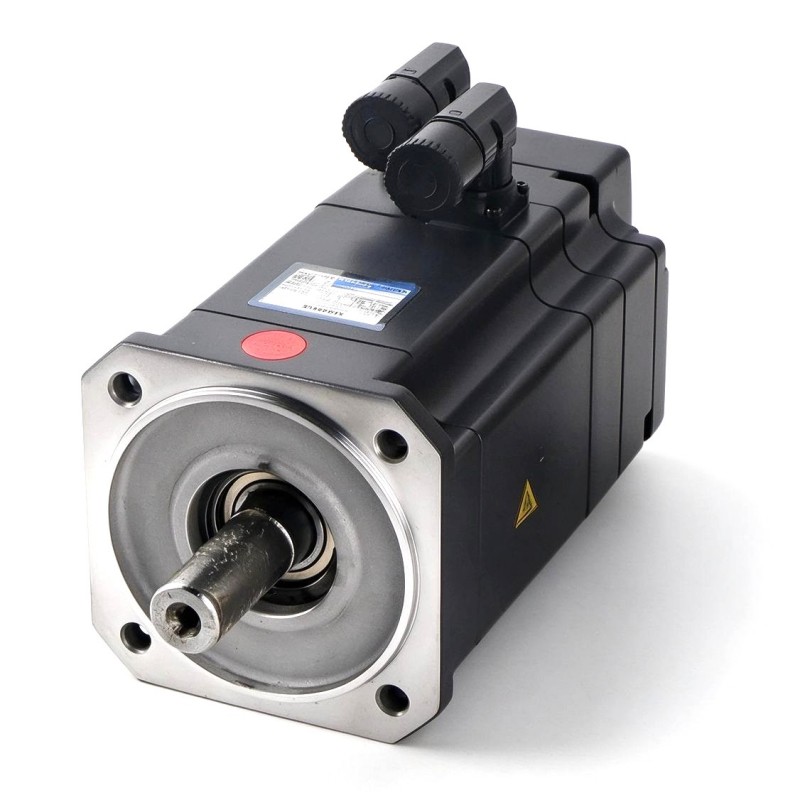
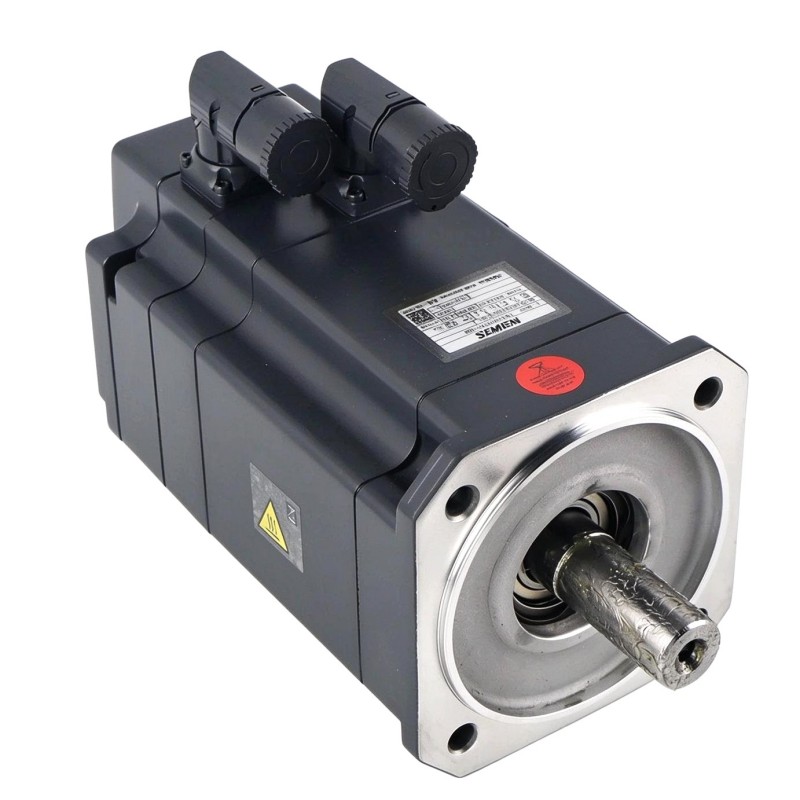
- Siemens
- 1FK7063-5AF71-1AG0
- Synchronous Servo Motor
- Germany
- 63 mm
- 11.503 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 7
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
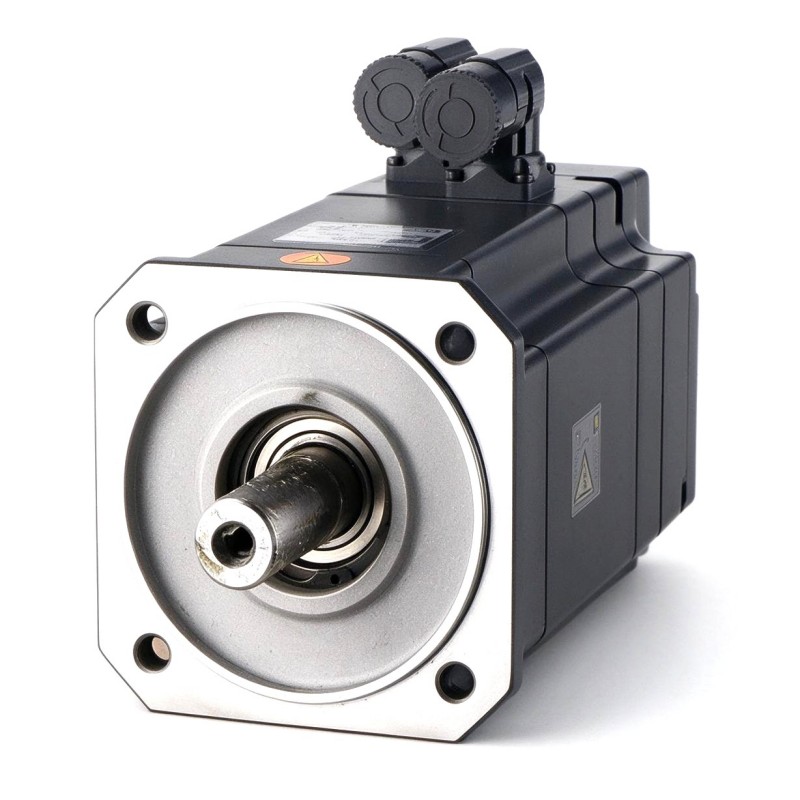
The Siemens 1FK7063-5AF71-1AG0 is a SIMOTICS S-1FK7 Compact permanent-magnet synchronous servo motor for industrial machinery requiring controlled rotary motion and repeatable positioning. Its rated operating point is 3,000 rpm with an output power of 2.29 kW and a rated torque of 7.3 Nm at the specified thermal condition. These characteristics suit servo axes that repeatedly accelerate, travel to a target position, and decelerate as part of a machine cycle.
In an automated assembly system, the motor can drive a transfer mechanism that moves components between processing stations. A compatible servo drive regulates the motor current and speed, while the incremental encoder supplies motion feedback. The controller uses this information to coordinate the axis with sensors, grippers, and other machine functions.
The 1AG0 configuration uses an incremental Sin/Cos encoder with 1 Vpp signals and 2,048 pulses per revolution. It has a plain shaft, naturally cooled construction, and no integrated holding brake. These details matter when replacing a motor in an established machine: the encoder interface must match the drive, the coupling must suit the shaft, and the control system must account for the incremental feedback and its referencing procedure.
The power and signal connectors can be rotated through 270 degrees, allowing their orientation to be adjusted to the installation. The motor is intended for integration into a compatible servo system rather than direct connection to a standard fixed-frequency supply.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Siemens |
| Model | 1FK7063-5AF71-1AG0 |
| Product Family | SIMOTICS S-1FK7 Compact |
| Product Type | Synchronous Servo Motor |
| Motor Technology | Permanent-Magnet Synchronous Motor |
| Rated Power | 2.29 kW |
| Rated Speed | 3,000 rpm |
| Rated Torque at 100 K | 7.3 Nm |
| Rated Current | 5.6 A |
| Static Torque at 60 K | 9.1 Nm |
| Static Torque at 100 K | 11 Nm |
| Stall Current at 60 K | 6.6 A |
| Stall Current at 100 K | 8 A |
| Number of Poles | 8 |
| Maximum Permissible Mechanical Speed | 7,200 rpm |
| Maximum Torque | 35 Nm |
| Maximum Current | 28 A |
| Torque Constant | 1.37 Nm/A |
| Cooling | Natural cooling |
| Degree of Protection | IP64 |
| Mounting Design | IM B5 (IM V1, IM V3) |
| Shaft Configuration | Plain shaft, tolerance N |
| Holding Brake | Without holding brake |
| Encoder Type | Incremental encoder, Sin/Cos 1 Vpp |
| Encoder Resolution | 2,048 pulses per revolution |
| Electrical Connections | Power and signal connectors, rotatable by 270° |
| Shaft Height | 63 mm |
| Weight | 11.503 kg |
Product Features
- 2.29 kW rated output: Suitable for servo applications requiring controlled mechanical power.
- 3,000 rpm rated speed: Supports cyclic movement and positioning tasks within the motor’s operating limits.
- 11 Nm static torque at 100 K: Defines the specified static torque capability under the stated thermal condition.
- Incremental Sin/Cos feedback: Uses 1 Vpp encoder signals with 2,048 pulses per revolution.
- Plain shaft: Accommodates suitable shaft couplings selected for the mechanical load.
- Natural cooling: Uses the specified cooling arrangement without a separate forced-air motor cooling unit.
- IP64 protection: Protects against dust ingress and water splashes under the defined test conditions.
- 270° rotatable connectors: Helps accommodate different cable-routing requirements.
- No integrated holding brake: Requires a separate holding solution if the application needs the axis secured when motor torque is removed.
Working Principle
The 1FK7063-5AF71-1AG0 generates rotary motion through the interaction between its permanent-magnet rotor and the magnetic field produced by the stator windings. A compatible servo drive regulates the three-phase current supplied to the motor, controlling the torque and speed according to commands from the motion controller.
The control arrangement typically follows this path:
PLC / Motion Controller → Servo Drive → 1FK7063-5AF71-1AG0 → Mechanical Load
Incremental Encoder → Servo Drive → Closed-Loop Motion Control
When the controller commands a movement, the drive adjusts motor current to accelerate the load, maintain the required speed, or decelerate toward the target. The incremental encoder returns Sin/Cos feedback, allowing the drive to evaluate motor movement and regulate the axis.
For example, a packaging machine may use this motor to advance a feed roller before a cutting operation. The controller defines the motion profile, and the servo drive regulates the motor as the mechanism moves through the programmed sequence. The final positioning behavior depends on the feedback evaluation, drive tuning, mechanical transmission, load inertia, and machine cycle requirements.
Unlike an absolute encoder, an incremental encoder does not independently provide the same absolute multiturn position information after power-up. Depending on the machine architecture, the axis may need to reference a home sensor or perform a homing movement before position-dependent operations can begin. This should be considered when configuring a replacement motor or commissioning a new axis.
The plain shaft transfers torque through a compatible coupling. Shaft alignment, coupling condition, and the applied radial and axial loads should be checked during installation because mechanical problems can cause vibration, bearing wear, and positioning errors even when the electrical control system is operating normally.
Role in a SINAMICS Servo Control Architecture
The motor forms the electromechanical output stage of a closed-loop servo axis. The controller coordinates machine operations, the servo drive regulates motor torque and speed, and the incremental encoder supplies motion feedback.
Motion Controller → Compatible SINAMICS Drive → Servo Motor → Mechanical Transmission
Incremental Encoder Feedback → Drive Feedback Interface → Axis Control
| System Element | Function |
|---|---|
| PLC or Motion Controller | Generates position, speed, and sequencing commands |
| Compatible SINAMICS Servo Drive | Supplies controlled motor power and regulates axis movement |
| 1FK7063-5AF71-1AG0 | Converts electrical energy into controlled rotary motion |
| Incremental Sin/Cos Encoder | Supplies motion feedback through 1 Vpp signals |
| Motor Power Cable | Connects the drive output to the motor |
| Encoder Signal Cable | Transfers feedback signals to the drive |
| Mechanical Coupling | Transfers torque to the driven mechanism |
| Gearbox, Where Required | Adapts speed and torque to the application |
| Reference Sensor, Where Required | Establishes the axis reference position during homing |
| PLC Interlocks and Sensors | Coordinate axis movement with machine conditions |
The drive configuration must match the motor’s electrical characteristics and incremental encoder interface. When replacing an absolute-encoder motor, the feedback hardware and homing procedure require particular attention.
Industrial Applications
| Application | Typical Use |
|---|---|
| Packaging Machinery | Driving feed mechanisms and cyclic positioning axes |
| Automated Assembly | Moving workpieces between fastening and inspection stations |
| Material Handling | Operating transfer mechanisms and positioning equipment |
| Indexing Tables | Advancing components through programmed production steps |
| Labeling Systems | Coordinating product movement with labeling operations |
| Printing Equipment | Driving selected feed and registration mechanisms |
| Inspection Machinery | Positioning fixtures and components for inspection |
| Electronics Manufacturing | Operating automated component-handling mechanisms |
| Machine Tools | Driving compatible auxiliary and positioning axes |
| General Factory Automation | Providing controlled rotary motion in programmable machinery |
This motor is suited to machinery that uses incremental encoder feedback and a compatible servo drive. Selection should account for the complete motion profile, including acceleration, peak torque, operating speed, duty cycle, and load inertia. Where the mechanism must remain stationary after the drive removes torque, the machine’s holding arrangement must be evaluated separately.
Installation and Maintenance
- Verify the complete order number: Confirm 1FK7063-5AF71-1AG0 and check that the required configuration uses an incremental encoder, plain shaft, and no integrated holding brake.
- Check drive compatibility: Verify that the servo drive supports the motor’s electrical ratings and Sin/Cos 1 Vpp feedback interface.
- Inspect the mounting flange: Check the mounting surface, fasteners, and alignment before securing the motor.
- Check the plain shaft connection: Confirm that the selected coupling is suitable for the shaft and that the connection does not introduce excessive mechanical stress.
- Connect the motor power circuit: Follow the applicable wiring diagram and verify the motor connections and protective-earth continuity.
- Inspect the encoder cable: Check the signal connector, shielding, routing, and drive-side feedback connection.
- Confirm the referencing procedure: Determine whether the machine requires a home sensor or homing movement after startup or loss of position reference.
- Assess the mechanical load: Review load inertia, friction, coupling alignment, and expected peak torque before commissioning.
- Configure the drive: Verify motor identification, encoder settings, current limits, and control mode against the installed configuration.
- Test at reduced operating demand: Confirm rotation direction, encoder feedback, acceleration, and stopping behavior before using the full production motion profile.
- Monitor vibration and temperature: Investigate abnormal noise, heating, position deviation, or recurring drive faults rather than changing parameters without diagnosis.
- Document the final configuration: Record the motor reference, drive settings, encoder interface, referencing procedure, and coupling details for future maintenance.
Before servicing the motor, isolate the drive and follow the site’s electrical safety procedures. A rotating permanent-magnet motor can generate voltage when driven mechanically, so secure the shaft and assess electrical hazards before disconnecting the motor.
Compatible System Components
The 1FK7063-5AF71-1AG0 must be paired with a compatible servo drive, incremental feedback interface, power and signal cables, and mechanical transmission. The final component selection depends on the control architecture and the motion requirements of the machine.
| Component | Function |
|---|---|
| Compatible SINAMICS Servo Drive | Regulates motor current, speed, and position |
| SINAMICS S120 Drive System | Supports servo-axis integration in a compatible configuration |
| Motor Power Cable | Carries controlled electrical power from the drive to the motor |
| Incremental Encoder Cable | Transmits Sin/Cos feedback to the drive |
| PLC or Motion Controller | Coordinates axis movement and production sequencing |
| Reference Sensor | Establishes the axis reference position where required |
| Mechanical Coupling | Transfers torque from the plain motor shaft to the driven mechanism |
| Gearbox, Where Required | Adapts output speed and torque to the application |
| Mounting Hardware | Secures the motor and maintains alignment |
| Machine Sensors and Interlocks | Coordinate movement with process and safety conditions |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| Siemens 1FK7063-5AF71-1AA0 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Incremental Sin/Cos encoder configuration with a keyed shaft |
| Siemens 1FK7063-5AF71-1SA0 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Multipole resolver configuration with a keyed shaft |
| Siemens 1FK7063-5AF71-1AG1 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Related incremental encoder motor configuration |
| Siemens 1FK7063-5AF71-1FH0 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Absolute encoder configuration with a holding brake |
| Siemens 1FK7063-5AF71-1FG0 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Related absolute encoder configuration without a holding brake |
| Siemens 1FK7063-5AF71-1SH0 | SIMOTICS S-1FK7 Compact Synchronous Servo Motor | Resolver configuration with a holding brake |
Key Advantages
- 2.29 kW rated output and 3,000 rpm rated speed.
- 7.3 Nm rated torque at the specified thermal condition.
- Incremental Sin/Cos feedback with 2,048 pulses per revolution.
- Plain shaft for compatible coupling arrangements.
- Natural cooling and IP64 protection.
- Power and signal connectors rotatable through 270°.
- Suitable for servo axes using an incremental feedback and referencing strategy.
Technical FAQs
What is the difference between the 1AG0 and 1AA0 configurations?
Both configurations use incremental Sin/Cos encoder feedback, but the 1AG0 version has a plain shaft, while the 1AA0 version has a shaft with a fitted key. The mechanical coupling must match the installed shaft configuration when replacing one version with the other.
Does the 1FK7063-5AF71-1AG0 provide absolute position feedback?
No. This version uses an incremental Sin/Cos encoder with 1 Vpp signals and 2,048 pulses per revolution. Depending on the machine’s control architecture, a reference sensor or homing procedure may be needed to establish the axis position after startup.
Can this motor be installed in a machine that previously used an absolute encoder?
Not necessarily as a direct replacement. The drive’s feedback interface, motor configuration, and controller’s position-reference strategy must be reviewed. Changing from absolute to incremental feedback may require control-system changes and a different startup procedure.
What should be checked if the motor rotates but the positioning sequence is inconsistent?
Inspect the encoder signal, cable shielding, drive feedback configuration, mechanical coupling, and reference procedure. Also check load inertia and drive tuning. If the axis loses its reference after restart, verify that the machine’s homing strategy is appropriate for incremental feedback.