ProductPRODUCT
Featured products
Contact Us
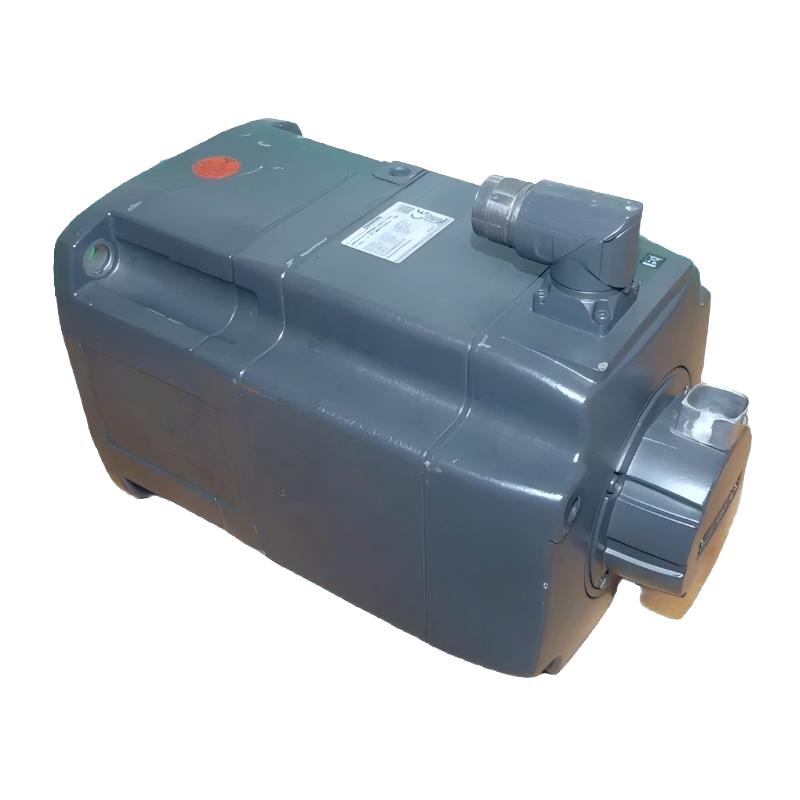
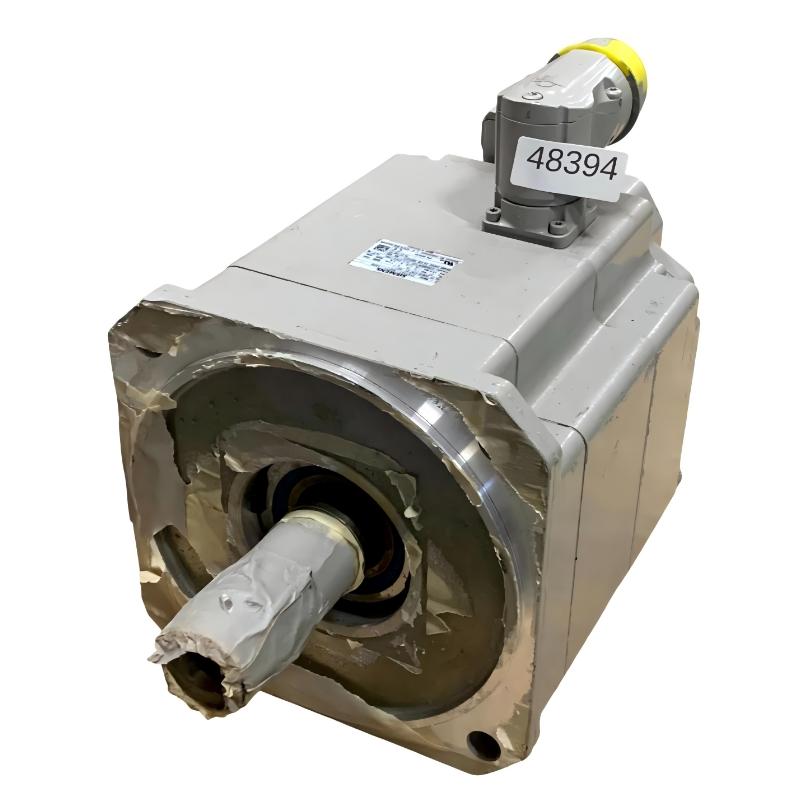
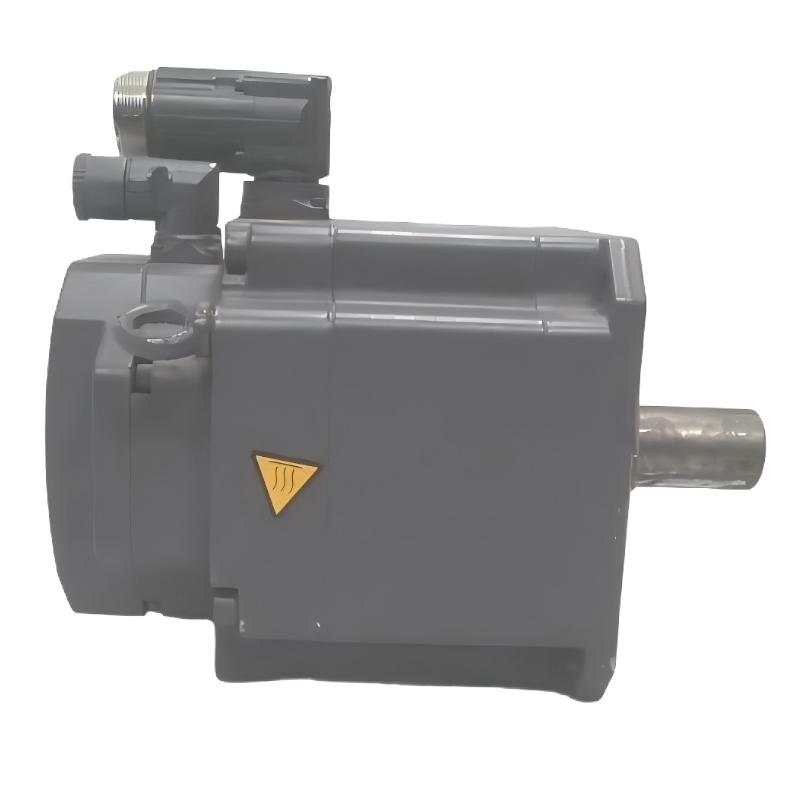
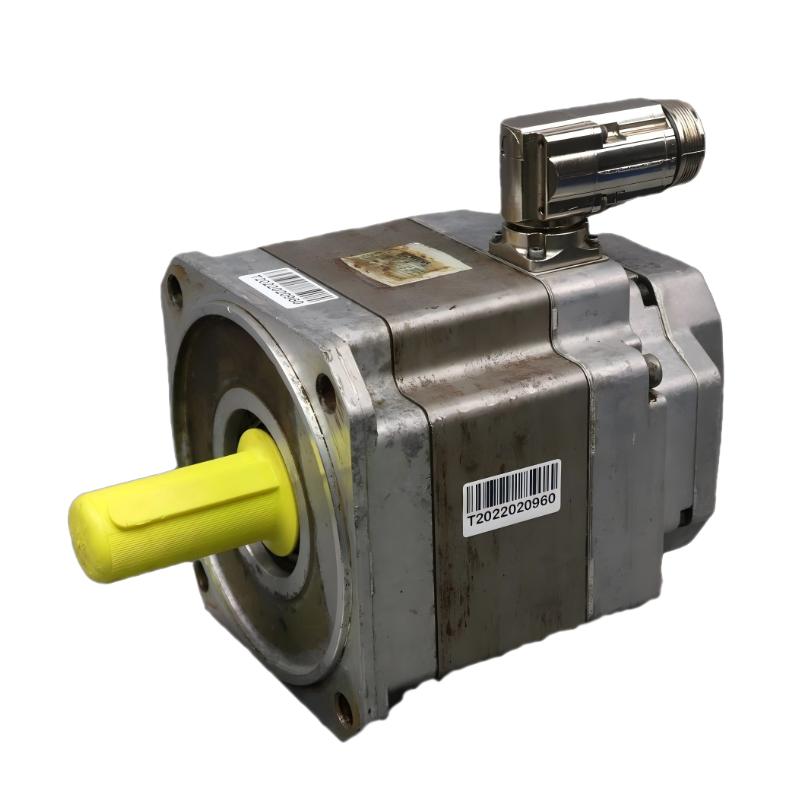
- Siemens
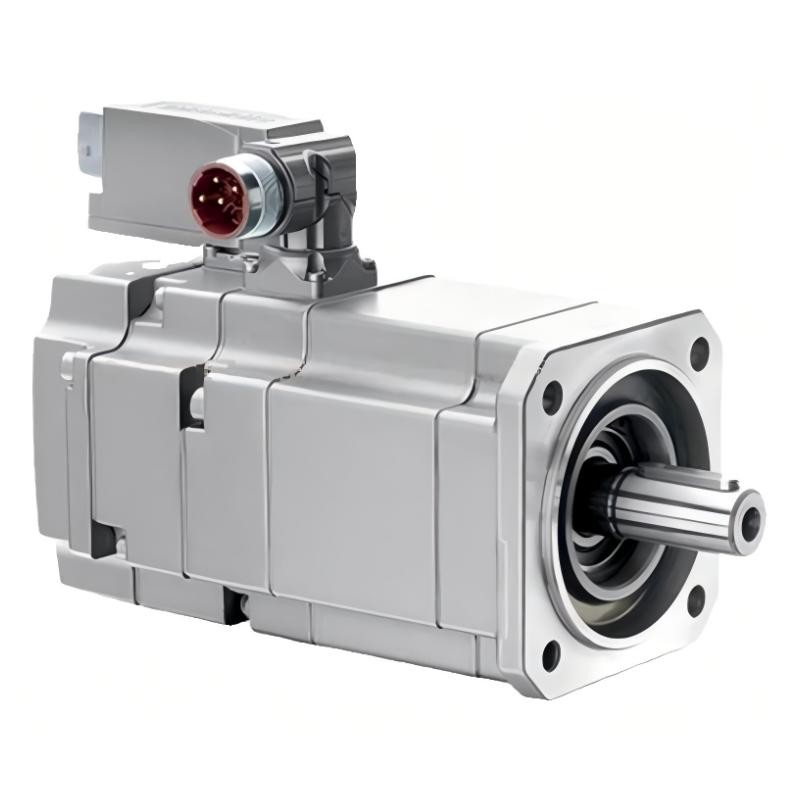
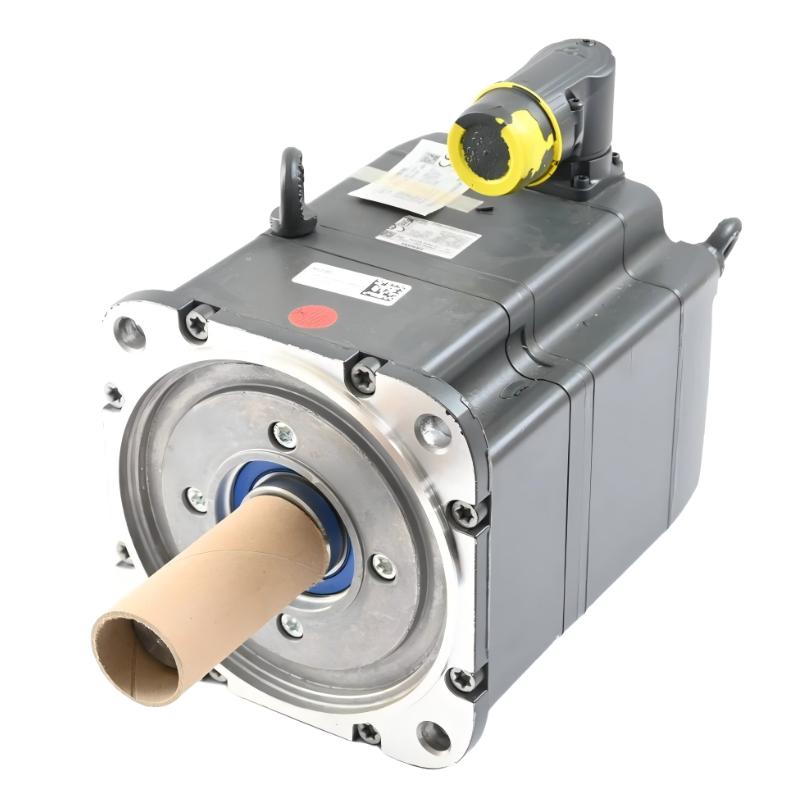
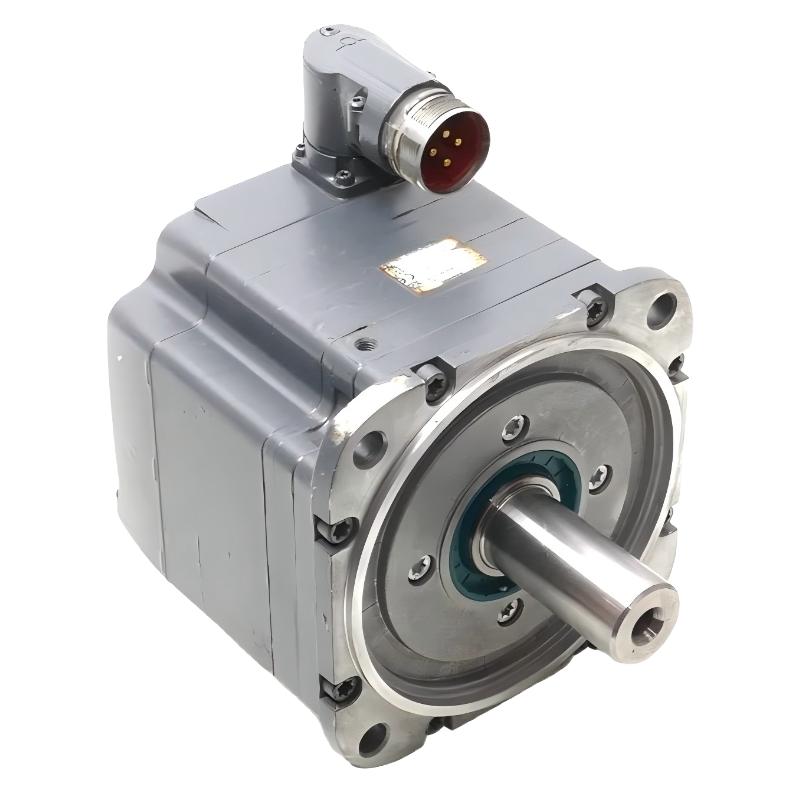
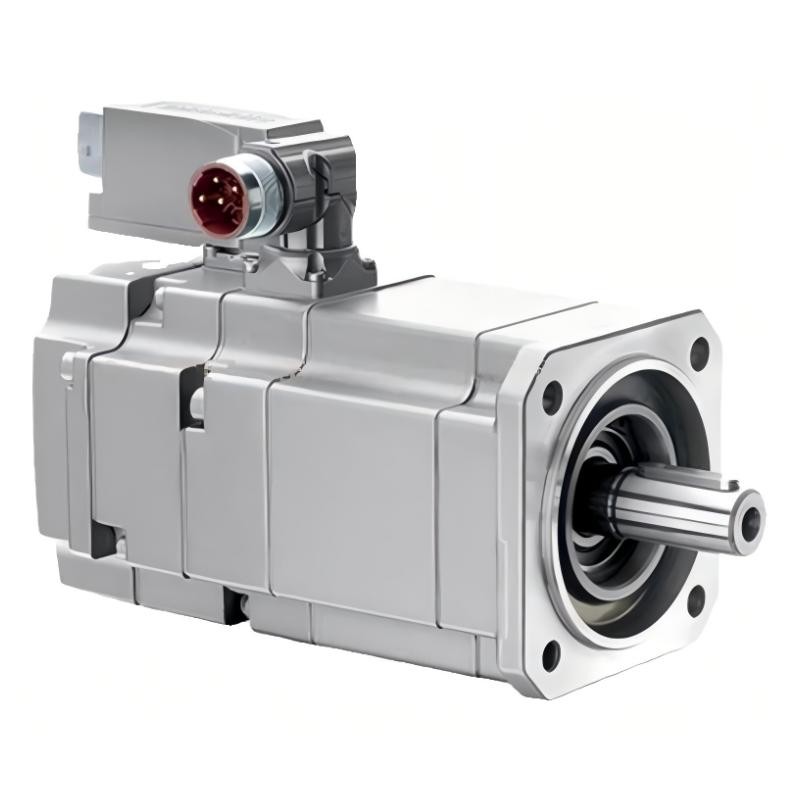
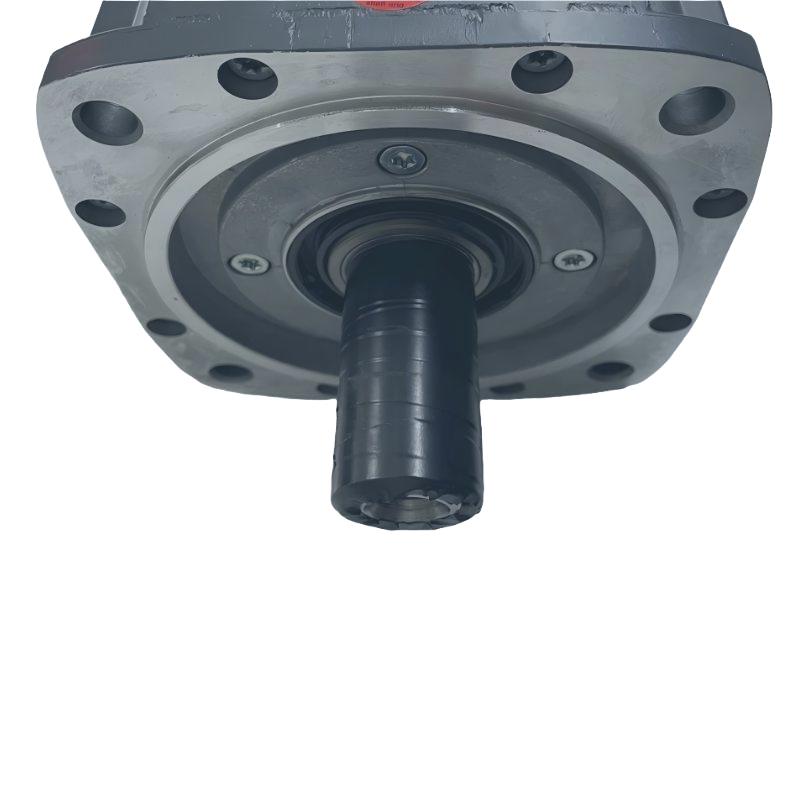
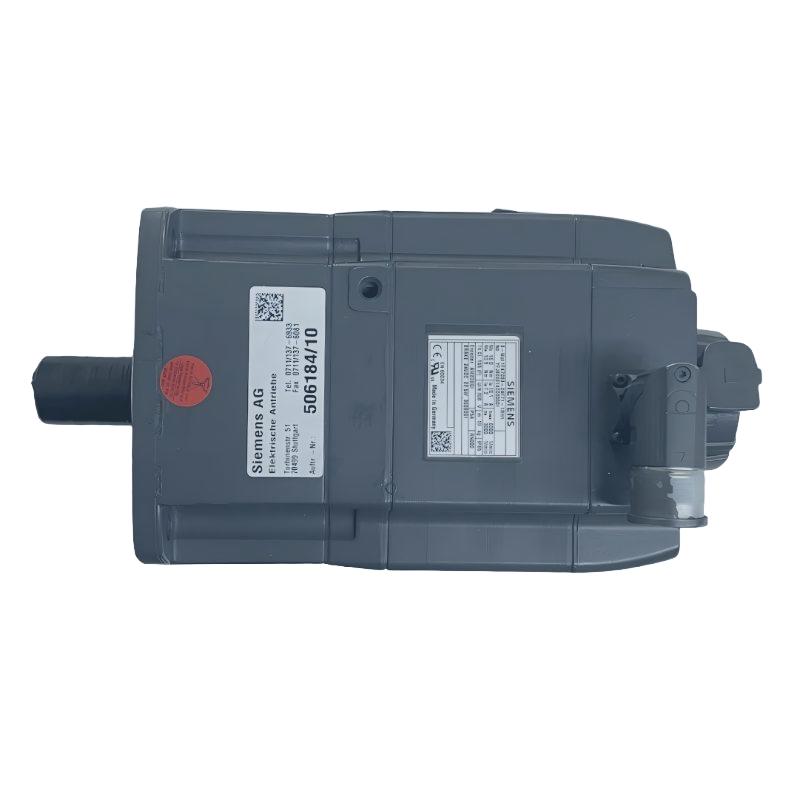
- 1FK7083-2AF71-1RH1
- Compact Synchronous Motor
- Germany
- 310 × 150 × 200 mm
- 15.9kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 6
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
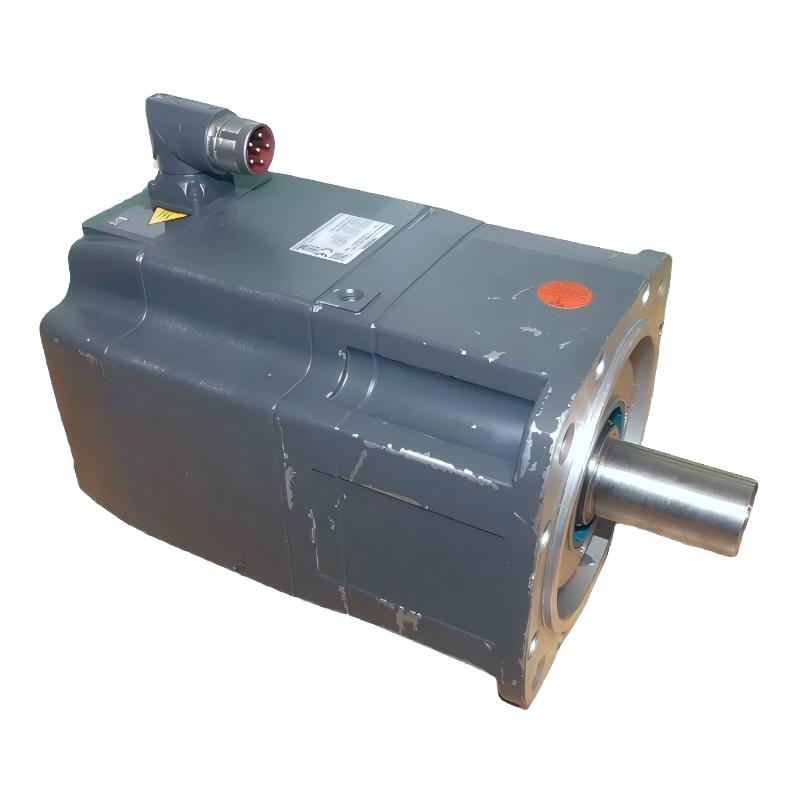
Siemens 1FK7083-2AF71-1RH1 Servo Motor: Product Overview, Technical Specifications, Applications, Advantages, and Related Models
1. Product Introduction
The Siemens 1FK7083-2AF71-1RH1 is a high-performance synchronous servo motor belonging to the SIMOTICS S 1FK7 series. It is designed for industrial motion-control applications that require accurate positioning, stable torque output, reliable speed regulation, and repeatable operation.
With a rated speed of 3,000 rpm and an optimum power rating of 3.3 kW, this motor is suitable for machinery that must combine responsive movement with dependable operating performance. Its permanent-magnet synchronous motor design supports precise control when paired with a compatible servo drive and motion-control system.
A key feature of this model is its integrated absolute encoder with a 20-bit single-turn resolution and 12-bit multiturn capability, using a DRIVE-CLiQ interface. This feedback arrangement allows the control system to determine motor position with high resolution and track position across multiple revolutions.
The motor also includes a permanent-magnet holding brake, a smooth shaft, natural cooling, and an IP65 degree of protection. These features make it a practical option for industrial installations where position retention, compact construction, and protection against dust and water jets are important.
The 1FK7083-2AF71-1RH1 is best understood as a precision motion component rather than a standalone drive system. Its actual performance depends on the selected servo drive, control parameters, mechanical transmission, load inertia, installation conditions, and duty cycle.
2. Brand and Product Series
| Item | Description |
|---|---|
| Brand | Siemens |
| Product family | SIMOTICS |
| Product series | SIMOTICS S 1FK7 |
| Motor category | Synchronous servo motor |
| Motor technology | Permanent-magnet synchronous |
| Product configuration | 1FK7-CT |
| Model number | 1FK7083-2AF71-1RH1 |
| Rated operating speed | 3,000 rpm |
| Optimum power | 3.3 kW |
| Rated torque | 10.5 Nm |
| Static torque at 100 K temperature rise | 16 Nm |
| Cooling method | Natural cooling |
| Feedback system | AM20DQI absolute encoder, 20-bit single-turn plus 12-bit multiturn |
| Brake configuration | Integrated permanent-magnet holding brake |
| Protection rating | IP65 |
The SIMOTICS S 1FK7 series is designed for precision motion applications where a servo motor must respond accurately to commands from a drive and control system. Within this family, motor configurations differ according to power, torque, encoder type, shaft design, brake configuration, mounting arrangement, and protection rating.
The exact ordering code is important. Two motors with similar power and speed ratings may not be interchangeable if they use different feedback systems, connectors, brakes, shaft configurations, or protection levels.
3. Detailed Technical Specifications
The following table summarizes the main electrical, mechanical, feedback, and installation characteristics of the 1FK7083-2AF71-1RH1.
3.1 Electrical and Performance Parameters
| Parameter | Specification |
|---|---|
| Model | 1FK7083-2AF71-1RH1 |
| Motor type | Permanent-magnet synchronous servo motor |
| Optimum power | 3.3 kW |
| DC-link voltage designation | 600 V |
| Rated speed | 3,000 rpm |
| Optimum operating speed | 3,000 rpm |
| Rated torque | 10.5 Nm |
| Static torque at 60 K | 13.3 Nm |
| Static torque at 100 K | 16.0 Nm |
| Maximum mechanical speed | 6,000 rpm |
| Maximum speed with inverter | 5,600 rpm |
| Maximum motor torque | 50 Nm |
| Rated current | 7.2 A |
| Static current at 60 K | 8.2 A |
| Static current at 100 K | 10.1 A |
| Maximum current | 37 A |
| Number of poles | 8 |
| Torque constant | 1.58 Nm/A |
| Voltage constant at 20°C | 102.5 V per 1,000 rpm |
| Winding resistance at 20°C | Approximately 0.38 Ω |
| Rotating-field inductance | 7.0 mH |
| Electrical time constant | 18.6 ms |
| Mechanical time constant | 1.18 ms |
| Thermal time constant | Approximately 50 minutes |
| Published efficiency figure | Approximately 93% |
The rated torque of 10.5 Nm describes the motor’s rated operating point under the specified thermal conditions. The static torque of 16 Nm is a separate value and should not be treated as the continuous rated torque for every operating condition.
The maximum torque of 50 Nm is a limiting performance figure, not a guarantee that the motor can sustain that torque continuously. Permissible torque depends on speed, current, drive capability, temperature, and the duration of the load.
The 600 V designation refers to the drive-side DC-link voltage class, not a simple statement of the motor’s direct AC supply voltage. The motor must be operated with a compatible servo drive and correctly configured motor data.
3.2 Mechanical and Installation Parameters
| Parameter | Specification |
|---|---|
| Model | 1FK7083-2AF71-1RH1 |
| Motor construction | Compact synchronous servo motor |
| Shaft height | 80 mm |
| Shaft design | Plain, smooth shaft |
| Shaft tolerance | N |
| Mounting arrangement | IM B5; also listed for IM V1 and IM V3 |
| Flange | Size 1 |
| Cooling | Natural cooling |
| Degree of protection | IP65 |
| Power connector | Rotatable |
| Signal connector | Rotatable |
| Temperature monitoring | Pt1000 temperature sensor |
| Vibration severity | Grade A |
| Radial runout tolerance | 0.050 mm |
| Concentricity tolerance | 0.10 mm |
| Axial runout tolerance | 0.10 mm |
| Shaft torsional stiffness | Approximately 72,000 Nm/rad |
| Approximate dimensions (L × W × H) | 310 × 150 × 190 mm, based on a published product listing |
| Approximate listed weight | 15.9 kg |
| Alternative datasheet net-weight figure | 18.6 kg; confirm against the exact motor configuration and documentation |
Important dimensional and weight note: published listings do not give entirely consistent physical measurements and net weights for this model. The dimensions above are useful for preliminary planning only, not for final mechanical design. The 15.9 kg and 18.6 kg figures also conflict; use the nameplate, order-specific datasheet, and mechanical drawing for the actual unit being purchased or replaced.
For installation planning, allow additional space for connector rotation, cable routing, ventilation, access to mounting bolts, and removal of the motor. The listed motor dimensions do not necessarily include all cable-bend or connector-clearance requirements.
3.3 Encoder and Feedback System
| Parameter | Specification |
|---|---|
| Model | 1FK7083-2AF71-1RH1 |
| Encoder type | Absolute encoder |
| Encoder designation | AM20DQI |
| Single-turn resolution | 20 bit |
| Multiturn resolution | 12 bit |
| Single-turn position steps | 1,048,576 theoretical positions per revolution |
| Multiturn range | 4,096 revolutions |
| Communication interface | DRIVE-CLiQ |
| Position feedback | Absolute position feedback |
| Main benefit | High-resolution position measurement and repeatable motion control |
An absolute encoder provides position information without relying solely on incremental pulse counting from a reference point. The multiturn capability also records the number of revolutions within its specified range.
This can simplify machine start-up and position recovery after power interruption, depending on the control architecture and the way the machine manages reference data. It does not automatically eliminate every homing or referencing requirement; that decision depends on the machine’s safety concept and control configuration.
3.4 Holding Brake Parameters
| Parameter | Specification |
|---|---|
| Model | 1FK7083-2AF71-1RH1 |
| Brake type | Permanent-magnet holding brake |
| Holding torque | 22 Nm |
| Brake supply voltage | 24 V DC ±10% |
| Coil current | Approximately 0.9 A |
| Opening time | Approximately 200 ms |
| Closing time | Approximately 60 ms |
| Maximum specified switching work | 1,400 J |
| Main purpose | Holding the motor shaft when stationary |
The holding brake helps prevent unwanted shaft rotation when the motor is stopped or when the drive is disabled. It is especially useful on vertical axes, lifting mechanisms, and positioning systems where gravity or an external force could move the load.
A holding brake is not intended to replace a properly engineered service brake or emergency-braking system. The load, brake duty, stopping requirements, and applicable safety standards must be evaluated separately.
4. Product Structure and Operating Principle
The 1FK7083-2AF71-1RH1 uses permanent magnets in its rotor and electronically controlled stator currents to generate rotational force. The servo drive regulates current to control torque and adjusts the rotating magnetic field to control speed and position.
The encoder provides feedback to the drive. By comparing the commanded movement with the measured position and speed, the control system can correct errors during operation.
This closed-loop arrangement is useful where the machine must move to a specified location, maintain a stable speed, follow a programmed path, or coordinate movement with other axes.
The motor’s natural-cooling construction avoids the need for a separate forced-cooling unit under its specified operating conditions. Nevertheless, the installation must allow heat to dissipate, and the motor must not be assumed to deliver every rated performance value under every ambient temperature or duty cycle.
The smooth shaft is suited to mechanical arrangements designed around a plain shaft connection. Couplings, pulleys, or other transmission elements must be selected and installed to suit the actual shaft dimensions, permitted radial and axial loads, and the machine’s alignment requirements.
5. Main Applications
5.1 CNC Machine Tools
The motor can be used in CNC equipment where controlled movement and repeatable positioning are required. Potential applications include feed axes, positioning mechanisms, tool-changing mechanisms, and other auxiliary movements, provided the motor torque and speed match the machine’s design.
Its encoder feedback helps the control system track commanded movement, while the servo drive adjusts motor current to respond to changes in load.
5.2 Packaging and Production Machinery
Packaging machinery often combines high-speed movement with repeated stopping and starting. A servo motor can coordinate conveyors, cutting mechanisms, sealing stations, indexing tables, and product-positioning axes.
The 1FK7083-2AF71-1RH1 may be suitable for these duties when its rated torque, peak loading, acceleration profile, and thermal limits meet the application’s requirements.
5.3 Automated Assembly Equipment
Assembly machines may need to move components into precise positions, apply controlled rotational movement, or coordinate several axes within a short cycle.
The absolute encoder provides high-resolution feedback, helping the control system manage repeatable motion. The actual positioning accuracy of the completed machine also depends on mechanical backlash, coupling stiffness, structural rigidity, encoder installation, and controller tuning.
5.4 Material Handling and Transfer Systems
The motor can be considered for transfer mechanisms, indexing units, automated handling equipment, and controlled positioning stages.
The integrated holding brake is particularly relevant when the shaft must remain stationary after movement. For vertical axes, the brake and the complete mechanical system must be designed for the real load, including any external forces and safety requirements.
5.5 Printing and Converting Equipment
Printing, labeling, and converting machinery can require coordinated movement between rollers, feeding mechanisms, cutting systems, and registration axes.
A servo motor with encoder feedback can support synchronized motion and controlled speed changes. Suitability depends on the required cycle speed, load inertia, tension-control strategy, and the response capabilities of the selected drive.
5.6 Industrial Automation and Special-Purpose Machinery
The motor may also be used in custom-built production equipment, automated fixtures, precision positioning devices, and other machine systems requiring controlled rotary motion.
Before selecting it for a new design, engineers should verify the load profile, required acceleration, maximum operating speed, duty cycle, environmental conditions, and compatibility with the control system.
6. Product Advantages
6.1 High-Resolution Position Feedback
The 20-bit single-turn encoder and 12-bit multiturn functionality provide detailed position information to the control system. This supports precise motion commands and repeatable positioning when the mechanical system and servo controller are configured correctly.
6.2 Strong Torque Capability
The motor has a rated torque of 10.5 Nm and a specified static torque of 16 Nm at a 100 K temperature rise. These characteristics make it a candidate for applications that require substantial torque in a compact servo-motor format.
The correct design should distinguish between rated continuous operation, static holding conditions, and short-duration peak loads.
6.3 Integrated Holding Brake
The permanent-magnet holding brake can help retain the motor shaft when the motor is stationary. This is valuable in applications where an axis must remain in position during pauses or when the drive is disabled.
Brake suitability should be assessed against the load’s holding torque, stopping requirements, and duty cycle rather than relying on the motor’s torque rating alone.
6.4 Natural Cooling
Natural cooling simplifies the motor’s cooling arrangement because a separate fan or liquid-cooling circuit is not inherently required for its specified operating conditions.
However, the motor still needs sufficient heat dissipation. Restricted airflow, high ambient temperatures, frequent acceleration, and sustained high loads may affect its permissible output.
6.5 IP65 Protection
The IP65 rating indicates protection against dust ingress and water jets under the conditions defined for that rating. It can be advantageous in industrial environments where airborne dust or water exposure is expected.
IP65 should not be interpreted as permission to immerse the motor in water or expose it to every type of chemical, cleaning process, or corrosive atmosphere.
6.6 Flexible Connector Orientation
The rotatable power and signal connectors can make cable routing easier in different machine layouts. This can help reduce installation conflicts and simplify access to nearby components.
The connector orientation and cable bend radius should still be checked against the machine’s available clearance.
6.7 Compact Industrial Construction
The motor combines its electromagnetic system, feedback device, and holding brake within a single motor assembly. This can simplify system integration compared with arrangements requiring separate external feedback and braking components.
The final installation space must account for connectors, cables, mounting hardware, and any coupling or transmission components.
6.8 Support for Closed-Loop Motion Control
The encoder feedback allows the servo drive to monitor actual movement and adjust its output in response to commanded position or speed. This is important for applications that require controlled acceleration, accurate stopping, and coordinated movement.
The motor’s performance in a complete machine depends on the drive, controller, tuning, transmission, and mechanical load as much as on the motor itself.
7. Recommended Operating and Installation Considerations
Before installing the 1FK7083-2AF71-1RH1, review the following points.
– Drive compatibility: Confirm that the servo drive supports the motor’s electrical characteristics, current requirements, encoder interface, and brake arrangement.
– Load calculations: Calculate continuous torque, peak torque, acceleration torque, and load inertia. Do not select a motor based solely on its rated power.
– Speed limits: Respect the permissible motor speed and the lower limit that may apply with the selected inverter or application configuration.
– Brake control: Verify the brake’s 24 V DC supply, control sequence, holding torque, and response timing. Confirm that the brake is appropriate for the axis’s safety requirements.
– Mechanical alignment: Ensure that the coupling and driven shaft are correctly aligned and that radial and axial loads remain within the applicable limits.
– Cooling and ambient conditions: Provide sufficient space for natural heat dissipation and verify the permissible ambient temperature and operating duty.
– Protection requirements: Check whether IP65 is sufficient for the actual environment, including exposure to cleaning fluids, oil, chemicals, or extreme temperatures.
– Physical dimensions and weight: Confirm the mechanical drawing and the weight of the exact configuration before designing the mounting plate or lifting arrangement.
– Encoder and cabling: Use compatible feedback and power connections, observe cable routing requirements, and verify the correct feedback configuration in the drive.
– Commissioning: Set the motor parameters, encoder settings, brake control, current limits, and motion-control tuning according to the drive and machine requirements.
8. Five Related Models from the Same Series or a Closely Related Configuration
The following models are useful candidates to compare with the 1FK7083-2AF71-1RH1. Models within the same 1FK7 family can have similar mechanical and electrical characteristics, but their exact options must be checked before replacement or interchange.
Dimensions and weights are included where a reliable figure is available. Where exact configuration-specific data have not been established, the table identifies the item as requiring confirmation rather than presenting an estimate as a guaranteed specification.
| Model | Series / configuration | Rated power | Rated speed | Rated torque | Brake / feedback | Dimensions (approx.) | Weight |
|---|---|---|---|---|---|---|---|
| 1FK7083-2AF71-1RH0 | SIMOTICS S 1FK7 | 3.3 kW | 3,000 rpm | 10.5 Nm | Holding brake; AM20DQI absolute encoder | Approx. 310 × 150 × 200 mm; verify drawing | Approx. 15.9 kg listed |
| 1FK7083-2AF71-1RG0 | SIMOTICS S 1FK7 | 3.3 kW | 3,000 rpm | 10.5 Nm | No holding brake; AM20DQI absolute encoder | Verify drawing | 15.601 kg listed |
| 1FK7080-5AF71-1AG0 | SIMOTICS S 1FK7 | Approx. 2.14 kW | 3,000 rpm | Approx. 6.8 Nm | Encoder configuration differs; no brake in the referenced configuration | Verify drawing | Approx. 10 kg; confirm |
| 1FK7080-5AF71-1EG0 | SIMOTICS S 1FK7 | Approx. 2.14 kW | 3,000 rpm | Approx. 6.8 Nm | Absolute encoder configuration; no brake in the referenced configuration | Verify drawing | Approx. 10 kg; confirm |
| 1FK7080-5AF71-1DA0 | SIMOTICS S 1FK7 | Approx. 2.14 kW | 3,000 rpm | Approx. 6.8 Nm | DRIVE-CLiQ feedback configuration; fitted-key shaft | Verify drawing | Approx. 10 kg; confirm |
8.1 Comparison Notes
1FK7083-2AF71-1RH0
This is the closest comparison among the listed models. It shares the 3.3 kW power rating, 3,000 rpm rated speed, 10.5 Nm rated torque, and AM20DQI encoder configuration. Its key difference is the IP64 protection rating rather than the IP65 rating specified for the RH1 version. The brake and shaft configuration should also be checked against the exact ordering data.
1FK7083-2AF71-1RG0
This model has similar core motor ratings and the same general feedback arrangement, but the listed configuration does not include a holding brake. It may be worth considering when the machine’s mechanics can safely retain the load without a motor-mounted holding brake. The brake omission means it should not be treated as a direct replacement where brake functionality is essential.
1FK7080-5AF71-1AG0
This is a lower-rated option within the 1FK7 family. Its approximate power and torque ratings are below those of the RH1 model, so it may be relevant for lighter-duty axes or a redesign where the required output is lower. Confirm the complete encoder and shaft configuration before making a selection.
1FK7080-5AF71-1EG0
This model is another lower-power comparison with a different feedback configuration. Its suitability depends on the servo drive’s encoder compatibility and the required position-feedback functions.
1FK7080-5AF71-1DA0
This option is relevant when the feedback interface and shaft arrangement match the machine requirements. Its fitted-key shaft configuration differs from the smooth shaft of the RH1 model, so coupling and transmission compatibility need particular attention.
Important: These are comparison candidates, not guaranteed drop-in replacements. A replacement decision should be based on the full order code, motor data sheet, mounting drawing, connector arrangement, encoder compatibility, brake configuration, and drive support.
9. Five Popular Siemens Servo Motor Models for Broader Comparison
The following models offer a broader starting point for comparing servo-motor families and application requirements. Their suitability varies by power, torque, feedback configuration, mounting dimensions, and control-system compatibility.
| Model | Product family / category | Main comparison point | Power and speed information | Torque information | Dimensions | Weight |
|---|---|---|---|---|---|---|
| 1FK7042-2AF71-1EB0 | SIMOTICS S 1FK7 | Smaller-frame servo-motor candidate | Verify exact model data | Verify exact model data | Verify mechanical drawing | Verify exact configuration |
| 1FK7063-5AF71-1AG0 | SIMOTICS S 1FK7 | Alternative frame and performance class | Verify exact model data | Verify exact model data | Verify mechanical drawing | Verify exact configuration |
| 1FK7083-5AF71-1AG0 | SIMOTICS S 1FK7 | Same broad frame-size family for comparison | Verify exact model data | Verify exact model data | Verify mechanical drawing | Verify exact configuration |
| 1FT6086-8AH71-3EG1 | SIMOTICS S 1FT6 | Alternative synchronous servo-motor family | Verify exact model data | Verify exact model data | Verify mechanical drawing | Verify exact configuration |
| 1FT6132-6AF71-1AA0 | SIMOTICS S 1FT6 | Larger-machine or different performance-class candidate | Verify exact model data | Verify exact model data | Verify mechanical drawing | Verify exact configuration |
The models above are included as a shortlist for further evaluation, not as a verified sales ranking. Exact power, torque, speed, dimensions, and weight depend on the complete model code and any associated configuration suffixes. It would be misleading to assign detailed numerical ratings without confirming the data for each exact version.
How to Choose Among These Models
– For a close replacement: Start with the 1FK7083-2AF71-1RH0, then compare brake configuration, protection rating, and mounting details.
– For a lower-power design: Investigate the 1FK7080 variants, but first calculate the required continuous and peak torque.
– For a different motor family: Compare the 1FT6 options only after checking the machine’s mounting arrangement, drive compatibility, encoder interface, and performance requirements.
– For a machine with a holding requirement: Confirm that the chosen model includes the required brake and that its holding torque is sufficient for the load.
– For a space-constrained installation: Use dimensioned mechanical drawings rather than relying on general frame descriptions or reseller measurements.
10. Product Selection Summary
The Siemens 1FK7083-2AF71-1RH1 is a 3.3 kW synchronous servo motor in the SIMOTICS S 1FK7 family. Its main characteristics are a 3,000 rpm rated speed, 10.5 Nm rated torque, 16 Nm static torque at a 100 K temperature rise, an AM20DQI absolute multiturn encoder, a permanent-magnet holding brake, natural cooling, and IP65 protection.
Its most important strengths are high-resolution position feedback, substantial torque capability for its size, integrated holding functionality, and compatibility with closed-loop industrial motion-control applications when paired with an appropriate drive.
For replacement projects, the RH0 and RG0 variants are useful comparison points because their main motor ratings are similar, but their protection and brake configurations differ. The lower-rated 1FK7080 models may suit lighter-duty applications, while the broader 1FK7 and 1FT6 families offer additional candidates for different performance requirements.
Before ordering or installing the motor, the final checks should cover the complete ordering code, rated and peak load calculations, encoder compatibility, brake requirements, mounting dimensions, connector clearance, and the actual motor weight. Those details are essential to ensuring that the selected motor fits both the electrical control system and the mechanical design.