ProductPRODUCT
Featured products
Contact Us
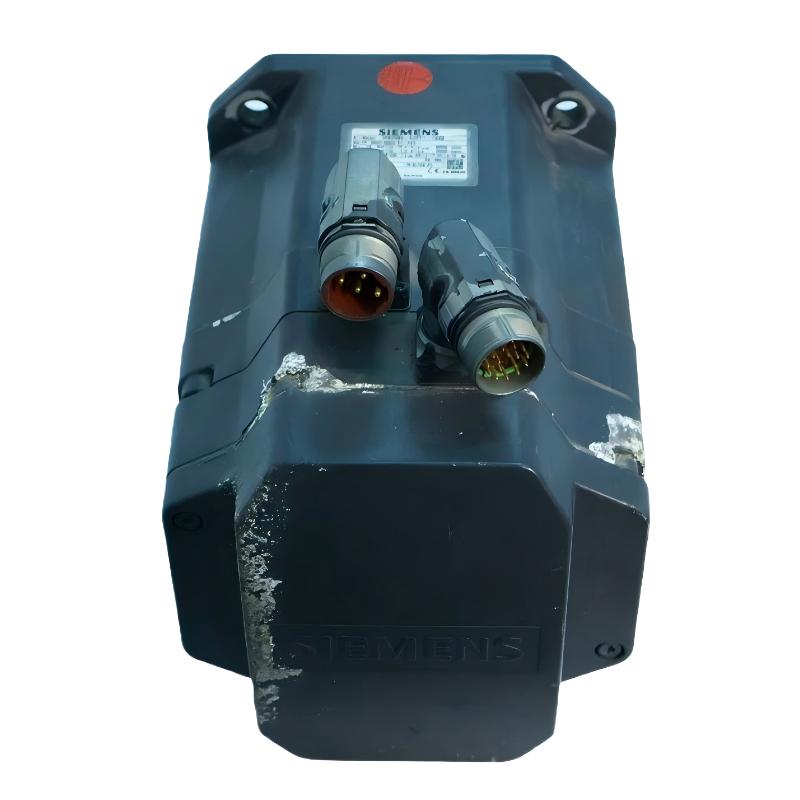
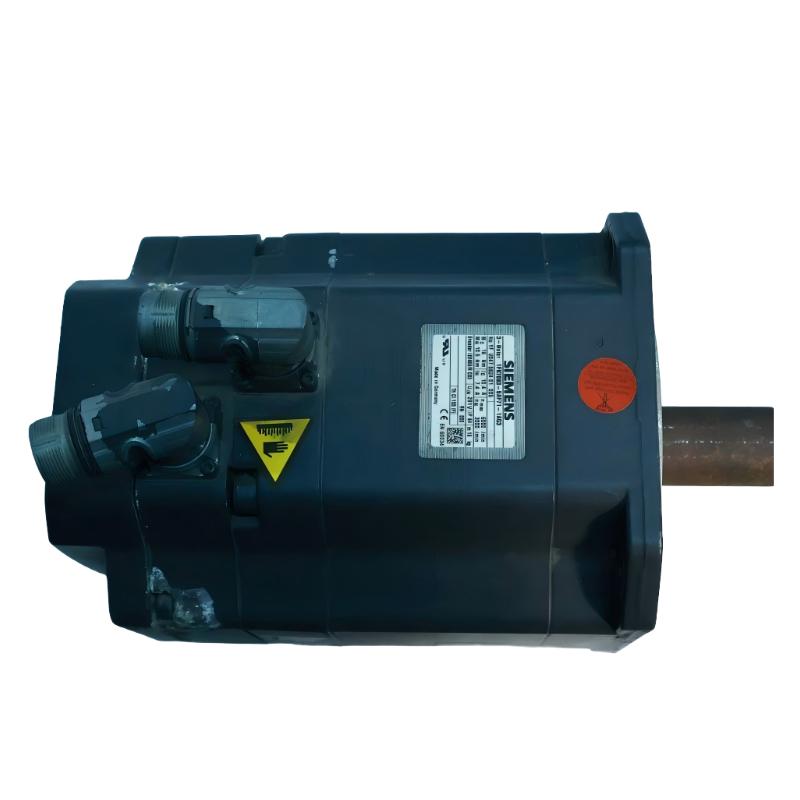
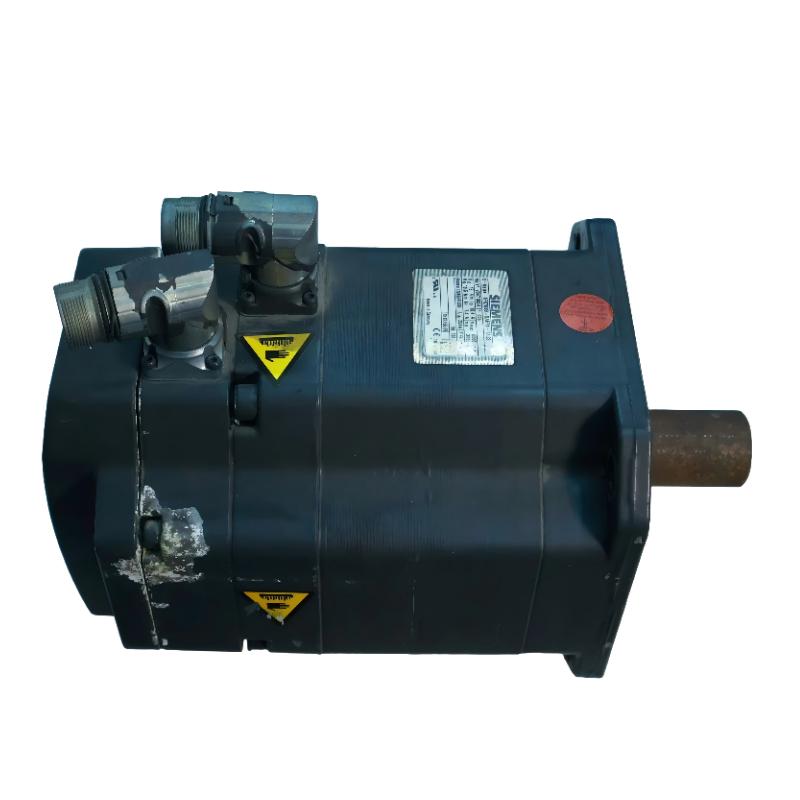
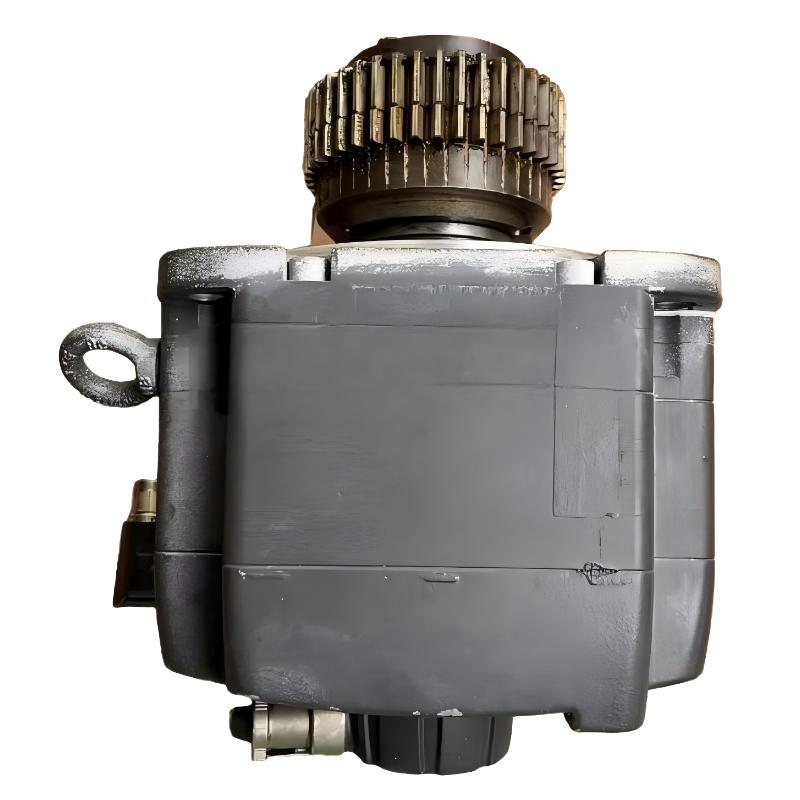
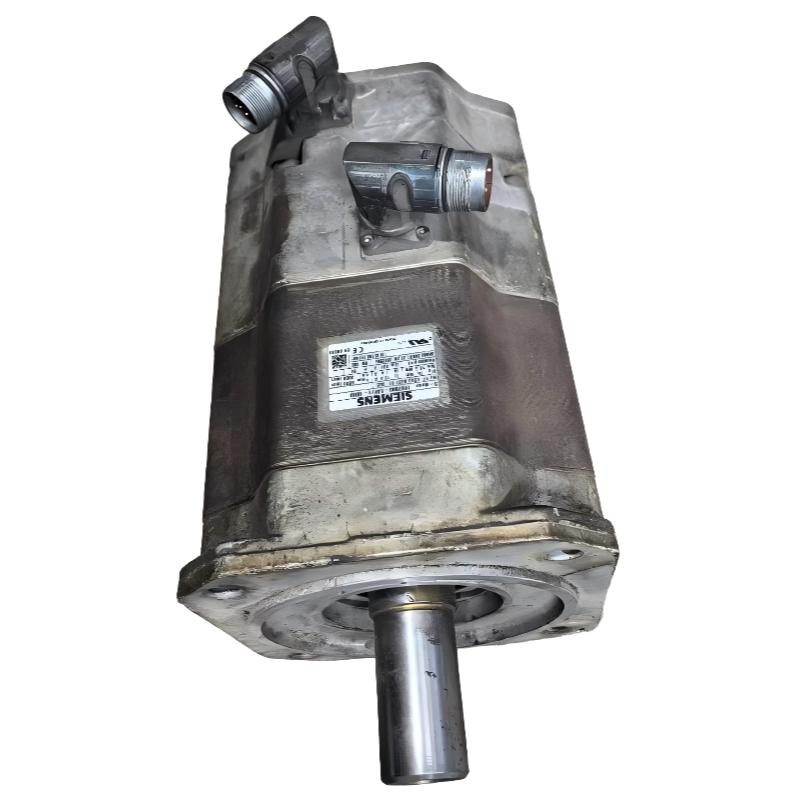
- Siemens
- 1FK7083-5AF71-1AG3
- Compact Synchronous Motor
- Germany
- 186 × 130 × 156 mm
- 16.5kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
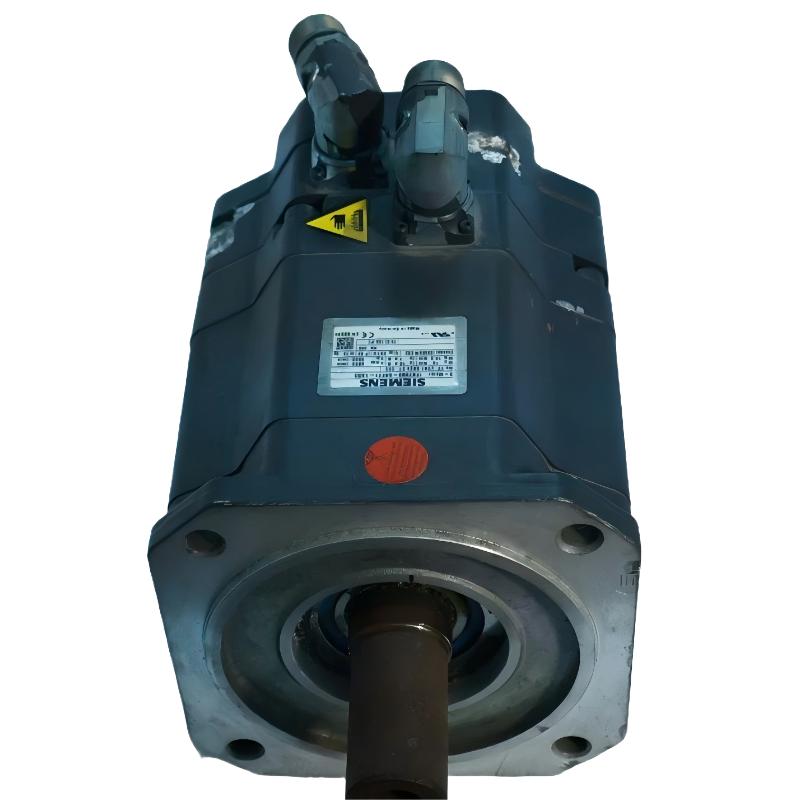
Siemens 1FK7083-5AF71-1AG3 Servo Motor: Detailed Product Description and Technical Specifications
1. Product Overview
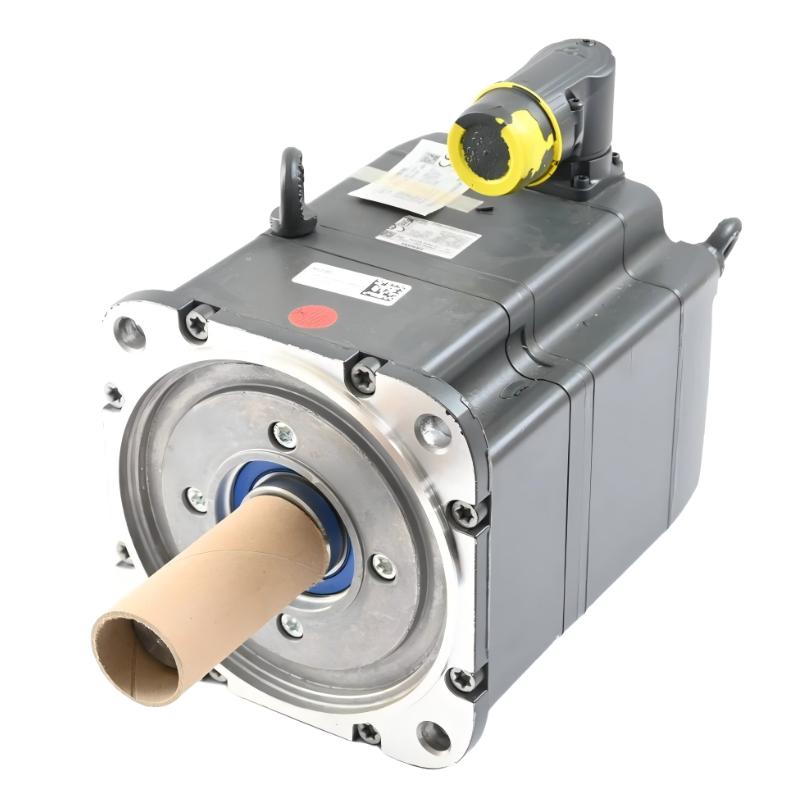
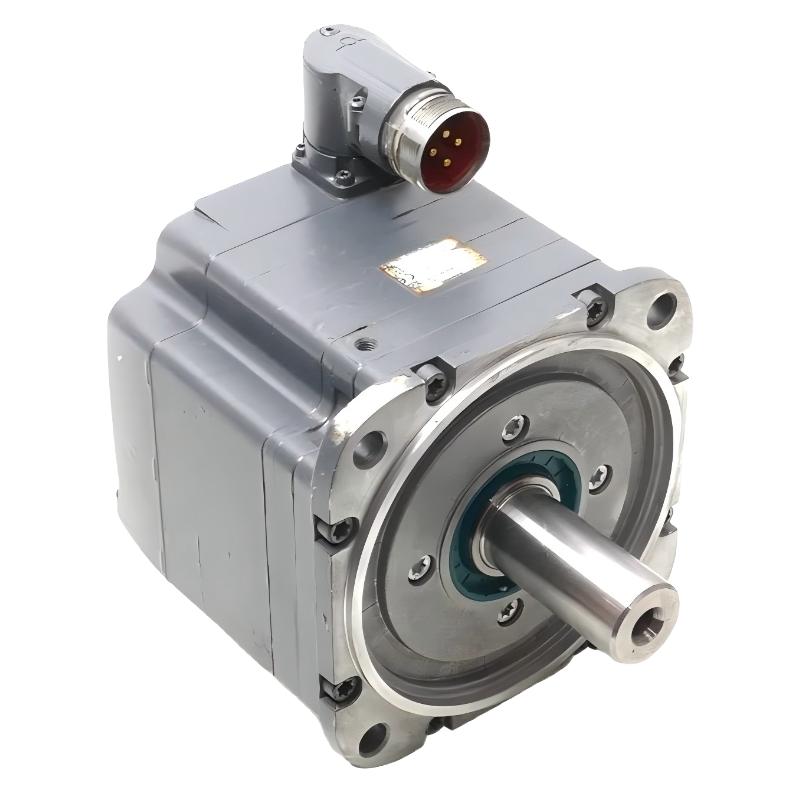
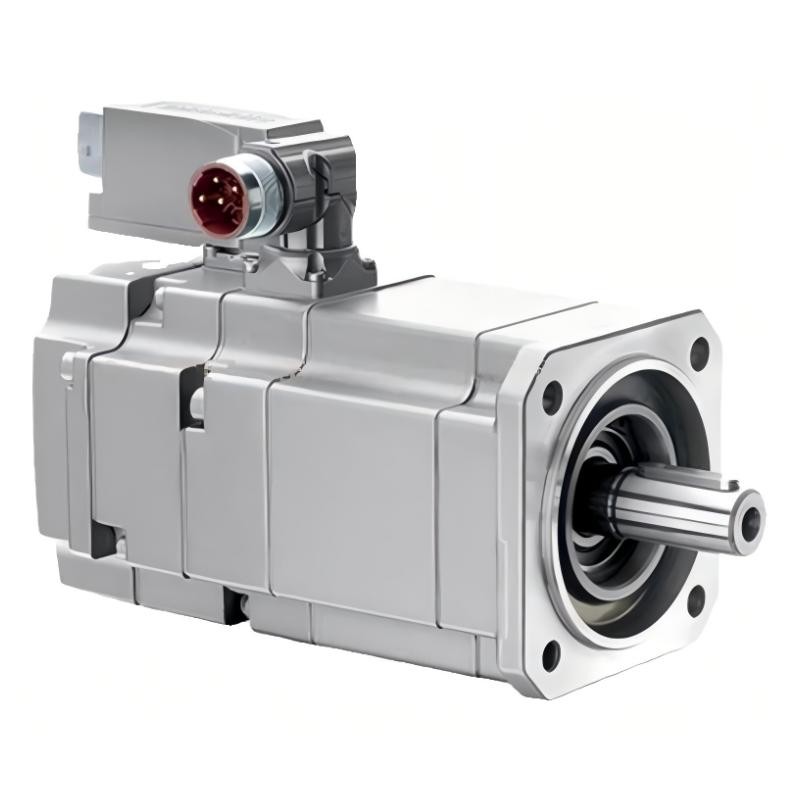
The Siemens 1FK7083-5AF71-1AG3 is a permanent-magnet synchronous servo motor in the SIMOTICS S 1FK7 Compact series. It is designed for industrial automation systems that require controlled rotation, accurate positioning, consistent torque delivery, and reliable performance during repetitive operating cycles.
With an optimum operating power of 3.3 kW and a rated speed of 3,000 rpm, this motor can be considered for machine axes that require responsive motion control in a relatively compact installation space. When paired with a compatible servo drive and controller, it can support closed-loop speed, position, and torque regulation.
This model uses an incremental SIN/COS encoder with a 1 Vpp signal interface and 2,048 signal periods per revolution. It has a plain shaft, natural cooling, and no integrated holding brake. The power and signal connectors can be rotated to help accommodate different mounting positions and cable-routing requirements.
The complete order number is important when selecting or replacing this motor. Related models may look similar but differ in encoder technology, shaft design, holding brake, protection rating, and drive compatibility.
2. Brand, Series, and Product Classification
| Item | Description |
|---|---|
| Brand | Siemens |
| Product family | SIMOTICS S |
| Product series | 1FK7 Compact |
| Model number | 1FK7083-5AF71-1AG3 |
| Product category | Industrial servo motor |
| Motor type | Permanent-magnet synchronous motor |
| Application category | Industrial motion control and automation |
| Cooling method | Natural cooling |
| Feedback system | Incremental SIN/COS encoder |
| Shaft configuration | Plain shaft |
| Holding brake | Not fitted |
| Mounting arrangement | IM B5; IM V1 and IM V3 configurations where applicable |
| Shaft height | 80 mm |
| Protection rating | IP64 |
| Approximate net weight | 14.0 kg |
Brand and product family
Siemens is the brand associated with this motor. The SIMOTICS S family includes synchronous motors intended for controlled industrial motion, while the 1FK7 Compact series focuses on compact servo-motor configurations for machine-building and automation applications.
A servo motor differs from a conventional motor used only for continuous rotation because it operates as part of a control system. A compatible drive uses feedback and command signals to regulate movement, allowing the machine to perform programmed positioning and speed changes.
The 1FK7083-5AF71-1AG3 is therefore best evaluated as part of a complete motion-control system rather than as an isolated motor. The motor, drive, feedback interface, transmission, and controller must all be suitable for the intended task.
3. Detailed Technical Parameters
3.1 Electrical and performance specifications
| Parameter | Specification |
|---|---|
| Optimum operating power | 3.3 kW |
| Rated speed | 3,000 rpm |
| Optimum speed | 3,000 rpm |
| Rated torque | 10.5 Nm |
| Static torque at 60 K temperature rise | 13.3 Nm |
| Static torque at 100 K temperature rise | 16.0 Nm |
| Maximum torque | 50.0 Nm |
| Rated current | 7.4 A |
| Stall current at 60 K | 8.6 A |
| Stall current at 100 K | 10.4 A |
| Maximum current | 37.0 A |
| Number of poles | 8 |
| Torque constant | 1.52 Nm/A |
| Voltage constant at 20°C | 97 V per 1,000 rpm |
| Winding resistance at 20°C | 0.40 Ω |
| Rotating-field inductance | 6.0 mH |
| Electrical time constant | 15.5 ms |
| Mechanical time constant | 1.41 ms |
| Thermal time constant | 50 min |
| Efficiency | 93% |
| Maximum mechanical speed | 6,000 rpm |
| Maximum inverter speed | 5,900 rpm |
The rated torque and current values provide a starting point for motor selection. Actual operating performance depends on the selected drive, load inertia, acceleration profile, cooling conditions, ambient temperature, and duty cycle.
The maximum torque and maximum current are not continuous operating ratings. They must not be treated as values that the motor can sustain indefinitely. The drive’s current limits and the motor’s thermal limits determine the permissible operating envelope.
3.2 Mechanical specifications
| Parameter | Specification |
|---|---|
| Motor construction | Compact synchronous servo motor |
| Frame / shaft-height class | 80 mm |
| Shaft type | Plain shaft |
| Shaft tolerance | N, according to the specified configuration |
| Mounting type | IM B5 |
| Additional mounting positions | IM V1 and IM V3, subject to installation requirements |
| Cooling method | Natural cooling |
| Protection rating | IP64 |
| Connector size | Size 1 |
| Connector rotation | Up to 270° |
| Radial runout tolerance | 0.050 mm |
| Concentricity tolerance | 0.10 mm |
| Axial runout tolerance | 0.10 mm |
| Vibration severity | Grade A |
| Rotor moment of inertia | 27.3 kg·cm² |
| Shaft torsional stiffness | 105,000 Nm/rad |
| Winding temperature sensor | KTY84 |
| Holding brake | No |
| Housing finish | Anthracite, RAL 7016 |
The plain shaft is suitable for compatible couplings and transmission arrangements. The shaft diameter, shaft length, allowable radial and axial loads, and coupling fit must be confirmed against the mechanical drawing before installation.
3.3 Encoder and feedback specifications
| Parameter | Specification |
|---|---|
| Encoder type | Incremental encoder |
| Signal format | SIN/COS |
| Signal amplitude | 1 Vpp |
| Signal periods per revolution | 2,048 |
| Reference tracks | C and D tracks |
| Feedback function | Speed and position feedback |
| Control arrangement | Closed-loop servo control |
| Compatibility requirement | Drive must support the specified encoder interface |
The incremental encoder provides feedback for motion regulation. Unlike an absolute encoder, it does not inherently provide a complete absolute position value after every power cycle. Depending on the machine design, the control system may need to perform a homing or reference procedure before normal positioning operations can resume.
3.4 Dimensions and weight
| Parameter | Specification |
|---|---|
| Shaft height | 80 mm |
| Approximate dimensions without brake | 194 × 129 × 162 mm |
| Approximate comparison dimensions with brake | 245 × 129 × 207 mm |
| Net motor weight | Approximately 14.0 kg |
| Brake fitted to the specified model | No |
| Cooling arrangement | Natural cooling |
| Installation clearance | Follow the applicable mechanical drawing and thermal requirements |
The dimensions above are approximate envelope figures for the relevant motor-frame arrangement, not guaranteed manufacturing dimensions for every configuration. Confirm the exact flange, bolt pattern, shaft, connector clearance, and overall length using the drawing for the complete order number.
The stated weight of approximately 14.0 kg refers to the motor itself. Shipping weight or installed assembly weight may be greater when packaging, cables, couplings, mounting adapters, or other accessories are included.
4. Product Introduction and Operating Characteristics
The 1FK7083-5AF71-1AG3 is designed for applications where a machine needs controlled, repeatable movement rather than simple continuous rotation. Its performance is determined by the combination of motor characteristics, encoder feedback, drive settings, and the mechanical load connected to the shaft.
4.1 Controlled speed and positioning
The motor operates at a specified rated speed of 3,000 rpm. When used with a compatible servo drive, its rotational speed can be regulated according to the machine’s programmed operating requirements.
This makes it suitable for equipment that needs to accelerate, decelerate, stop, and restart in a controlled manner. Examples include indexing mechanisms, automated transfer units, and production machines with repeated movement sequences.
4.2 Torque delivery
The specified rated torque is 10.5 Nm, while the listed maximum torque is 50 Nm. The maximum value represents a limit under applicable operating conditions, not a continuous torque rating.
When selecting the motor, engineers should calculate the torque needed during acceleration, normal running, deceleration, and any temporary load peaks. The drive must also be capable of supplying the necessary current without exceeding the motor’s limits.
4.3 Feedback-based motion control
The incremental SIN/COS encoder supplies movement feedback to the drive. This feedback allows the control system to monitor motor rotation and regulate motion in response to its commands.
The encoder’s 2,048 signal periods per revolution describe the encoder signal specification. They should not be interpreted directly as the final positioning accuracy of the machine, which also depends on the drive’s interpolation, mechanical transmission, backlash, structural stiffness, and control tuning.
4.4 Compact installation
The motor’s 80 mm shaft-height class and natural-cooling arrangement can be useful in machine designs where installation space and service access are important.
The connectors can be rotated within the specified range, helping the installer plan cable routing around the motor and adjacent mechanical parts. Adequate clearance must still be provided for connectors, cables, heat dissipation, and maintenance.
5. Main Advantages
5.1 Balanced power and size
With an optimum operating power of 3.3 kW, the motor provides a useful output level for many medium-duty automated machine axes. Its compact frame can help limit the space required around the drive mechanism.
This can be particularly helpful when a machine has several axes installed close together or when a replacement must fit into an existing structure.
5.2 Suitable for repetitive industrial movement
Servo systems are commonly used where the machine must repeat the same movement many times with consistent control. A compatible drive can regulate acceleration, speed, and stopping behavior according to the configured motion profile.
The practical performance of the complete machine still depends on correct sizing, tuning, and mechanical construction.
5.3 Established incremental feedback technology
The SIN/COS 1 Vpp incremental encoder is a defined feedback interface for compatible motion-control systems. It can support closed-loop speed and position regulation without requiring an absolute multi-turn feedback arrangement.
For machines that already use this feedback type, retaining a compatible configuration may reduce the changes needed during maintenance or replacement.
5.4 Natural cooling
Natural cooling avoids the need for a dedicated motor-mounted cooling fan or liquid-cooling system as part of the standard arrangement.
This can simplify the machine layout and reduce auxiliary equipment. The installation must nevertheless allow the motor to dissipate heat, especially during repeated acceleration or high-load operation.
5.5 Flexible connector positioning
The rotatable power and signal connectors offer flexibility when planning the motor’s mounting orientation and cable route.
Correct routing helps prevent cables from rubbing against moving parts or being bent too tightly. This is especially important in machines with frequent movement, vibration, or limited installation space.
5.6 Integrated temperature monitoring
The KTY84 sensor in the stator winding provides temperature information to a compatible monitoring system.
This supports temperature monitoring during operation and can help the control system respond to abnormal thermal conditions when the relevant protection functions are configured correctly.
5.7 Useful for maintenance of established machinery
When the existing machine was designed around this motor configuration, using the same complete order number may reduce the need to change the mounting arrangement, encoder wiring, or drive configuration.
The replacement must still be checked against the motor nameplate, mechanical drawing, and drive configuration. A similar model number does not guarantee that every connection and operating parameter is identical.
6. Typical Applications
| Application | How the motor may be used | Important selection considerations |
|---|---|---|
| Automated assembly machines | Drives positioning axes, fixtures, and component-transfer mechanisms | Required torque, repeatability, cycle time, and load inertia |
| Packaging equipment | Controls feeding, indexing, cutting, or transfer mechanisms | Acceleration profile, production rate, thermal duty, and synchronization |
| Machine tools | Drives compatible feed axes or positioning mechanisms | Mechanical stiffness, speed range, transmission ratio, and accuracy |
| Pick-and-place systems | Drives gantry axes and transfer mechanisms | Moving mass, travel distance, acceleration, and stopping time |
| Printing and converting machinery | Drives feed mechanisms or compatible roller axes | Speed coordination, load variation, and feedback requirements |
| Automated material handling | Drives rotary indexers and transfer equipment | Load inertia, gearbox ratio, stopping behavior, and brake requirements |
| General industrial automation | Provides controlled rotation in a compatible servo system | Drive compatibility, environment, mechanical interface, and duty cycle |
6.1 Automated assembly
Assembly equipment often relies on repeatable movements to bring components into position, operate tooling, or transfer products between stations.
A servo motor can support these operations when combined with a suitable drive, controller, sensors, and mechanical transmission. The complete system must be designed to meet the required cycle time and positioning performance.
6.2 Packaging machinery
Packaging lines may require coordinated feeding, indexing, sealing, cutting, or product handling. A servo motor can drive an individual mechanism while the controller coordinates it with the rest of the line.
For high-speed production, motor selection should account for repeated acceleration and deceleration, since these can produce significant peak current and heat.
6.3 Machine tools and positioning equipment
In suitable machine tools, the motor may drive a ball screw, gearbox, or other transmission. It can provide controlled movement for feed axes and indexing mechanisms.
The motor encoder alone does not determine the accuracy of the final tool position. Mechanical backlash, screw pitch, coupling stiffness, machine geometry, and any separate linear feedback system must also be considered.
6.4 Material handling
The motor can be considered for transfer units, indexing tables, and other automated handling systems where its speed and torque capabilities match the load.
If the mechanism moves vertically or supports a load that could move when power is removed, the lack of an integrated holding brake must be addressed in the machine’s mechanical and safety design.
7. Five Related Models from the 1FK7 Compact Series
The following models are useful candidates for comparison within the same motor family. The table separates the principal differences so that the encoder, shaft, and braking arrangements can be considered before choosing a model.
Note: Ratings for the closely related 1FK7083 configurations are shown as family-level comparison values where applicable. Confirm each complete order number and its individual datasheet before purchase or installation. Dimensions are approximate envelope dimensions, not certified mounting measurements.
| Model | Power / speed / torque | Feedback and shaft configuration | Approx. dimensions (mm) | Weight (kg) |
|---|---|---|---|---|
| 1FK7083-5AF71-1AG0 | 3.3 kW; 3,000 rpm; 10.5 Nm rated torque | Incremental SIN/COS, 1 Vpp, 2,048 periods/rev; plain shaft; no brake; IP64 | 194 × 129 × 162 | 14.0 |
| 1FK7083-5AF71-1AG5 | 3.3 kW; 3,000 rpm; 10.5 Nm rated torque | Absolute encoder, 22-bit single-turn plus 12-bit multi-turn; plain shaft; no brake; IP65, drive-end flange IP67 | 194 × 129 × 162 | 14.0 |
| 1FK7083-5AF71-1DG3 | Verify exact rated data against the complete order number | Incremental feedback with DRIVE-CLiQ interface; plain shaft; no brake; confirm protection rating | Confirm exact drawing | Confirm exact variant |
| 1FK7083-5AF71-1SB3 | 3.3 kW; 3,000 rpm; 10.5 Nm rated torque | Resolver feedback; keyed shaft; holding brake; IP64 | 245 × 129 × 207 | 16.5 |
| 1FK7083-5AF71-1EH0 | Confirm exact rating and encoder-related operating limits | Absolute EnDat feedback; plain shaft; holding brake; confirm exact protection rating | Confirm exact drawing | Confirm exact variant |
7.1 1FK7083-5AF71-1AG0
This is a close comparison candidate because its listed power, speed, feedback type, shaft configuration, and brake arrangement are similar to those of the target model.
It is worth considering when maintaining an existing machine that uses incremental SIN/COS feedback. Before treating it as a replacement, verify the nameplate, connector details, and drive configuration.
7.2 1FK7083-5AF71-1AG5
This configuration uses an absolute encoder rather than the incremental encoder found on the target model.
Absolute feedback can be useful when a machine’s control architecture requires an absolute position value. However, the drive and controller must support the encoder interface, and the commissioning procedure may differ from that of an incremental-feedback system.
7.3 1FK7083-5AF71-1DG3
This model is a candidate for applications that use the specified DRIVE-CLiQ feedback arrangement.
It should only be considered after checking the control hardware, drive support, wiring, and complete model-specific ratings. Similar mechanical construction does not guarantee feedback compatibility.
7.4 1FK7083-5AF71-1SB3
This configuration has a resolver, a keyed shaft, and a holding brake. These are significant differences from the target model.
It may be worth considering when the machine requires a brake or a keyed shaft interface. The brake’s holding torque, power supply, release behavior, and intended function must be checked before use.
7.5 1FK7083-5AF71-1EH0
This model is a comparison candidate for systems requiring absolute EnDat feedback and a holding brake.
Its encoder and braking configuration differs from the target model, so it should not be treated as a direct substitute without checking the drive, controller, shaft, mounting, and brake requirements.
8. Five Additional Siemens Motor Models to Consider
These models provide a broader comparison across related servo-motor configurations. They are possible alternatives to investigate, not confirmed drop-in replacements for the 1FK7083-5AF71-1AG3.
| Model | Series / category | Key parameters to evaluate | Approx. dimensions (mm) | Weight (kg) |
|---|---|---|---|---|
| 1FK7080-5AF71-1AG0 | SIMOTICS S, 1FK7 Compact | Smaller 1FK7080 frame; verify exact power, torque, speed, and encoder | 186 × 130 × 156, approximate frame envelope | Confirm exact variant |
| 1FK7080-5AF71-1EG0 | SIMOTICS S, 1FK7 Compact | Related frame-size-80 configuration; confirm feedback, shaft, brake, and ratings | 186 × 130 × 156, approximate frame envelope | Confirm exact variant |
| 1FK7080-5AF71-1DA0 | SIMOTICS S, 1FK7 Compact | Related compact servo configuration; check exact suffix-specific specifications | 186 × 130 × 156, approximate frame envelope | Confirm exact variant |
| 1FK7063-5AF71-1AG0 | SIMOTICS S, 1FK7 Compact | Smaller-frame candidate; evaluate whether its torque and power meet the load requirements | Confirm exact drawing | Confirm exact variant |
| 1FT6086-8AH71-3EG1 | SIMOTICS S, 1FT6 family | Different servo motor family; verify complete electrical and mechanical specifications | Confirm exact drawing | Confirm exact variant |
The 1FK7080 models may be worth investigating when a smaller frame or different motor configuration is required. The 1FK7063 may suit a lower-demand application if its torque and thermal ratings are adequate. The 1FT6086 belongs to a different family and should be evaluated as a separate engineering choice.
Exact ratings, dimensions, and weights must be verified for the complete order number before any of these models are specified for a machine.
9. Installation and Compatibility Considerations
9.1 Drive compatibility
The servo drive must support the motor’s feedback interface, rated current, voltage requirements, and control functions. Power rating alone is not enough to establish compatibility.
Check the complete motor order number, drive configuration, encoder wiring, and temperature-sensor connection before commissioning.
9.2 Torque and speed calculations
The required torque varies with the operating cycle. Acceleration, deceleration, friction, external forces, transmission efficiency, and load inertia all affect the motor’s demand.
For repetitive production equipment, assess both peak torque and continuous thermal loading. A motor that can handle a short peak may still be unsuitable for a duty cycle that produces excessive average heating.
9.3 Load inertia
The specified rotor moment of inertia is 27.3 kg·cm². The connected mechanism’s inertia should be calculated and reflected through the transmission ratio.
A large mismatch between load inertia and motor inertia may make the system harder to tune or reduce the achievable acceleration and settling performance. The appropriate ratio depends on the application and the capabilities of the drive.
9.4 Holding-brake requirements
The target model has no integrated holding brake. It should not be relied upon to hold a gravity-loaded axis in place when power is removed.
Where uncontrolled movement could create a hazard, the machine must have an appropriate engineered solution, such as a separate brake or mechanical restraint. The design must account for the load, failure conditions, and applicable safety requirements.
9.5 Cooling and protection
Natural cooling requires adequate heat dissipation. Avoid installations that trap excessive heat around the motor, and check the effects of nearby equipment and enclosure temperature.
IP64 provides protection against dust ingress and water splashing under specified test conditions. It does not mean that the motor is suitable for immersion or high-pressure washing.
9.6 Mechanical fit
Before fitting a replacement, compare the flange, bolt pattern, shaft diameter, shaft length, coupling, connector position, and available clearance.
Use the exact dimensioned drawing for final mounting work. Incorrect alignment can cause vibration, increased bearing loads, coupling wear, and reduced service life.
10. Purchasing and Replacement Checklist
11. Final Product Assessment
The Siemens 1FK7083-5AF71-1AG3 is a compact synchronous servo motor intended for industrial applications requiring controlled rotation and repeatable motion. Its 3.3 kW optimum operating power, 3,000 rpm rated speed, 10.5 Nm rated torque, incremental SIN/COS encoder, natural cooling, and flexible connector arrangement make it a useful option for compatible automated machinery.
Its main strengths are the combination of compact construction, established feedback technology, and suitability for closed-loop motion control. Potential applications include assembly machinery, packaging equipment, positioning systems, machine tools, and automated material handling.
The key limitations to consider are the lack of an integrated holding brake, the incremental rather than absolute encoder, the IP64 protection rating, and the need to confirm the exact mechanical dimensions.
For replacement work, matching the complete order number and verifying the drive and mechanical interfaces are essential. For a new machine design, the motor should be selected only after calculating the required torque, speed, acceleration, inertia, and duty cycle.
The related models listed above provide starting points for comparison, but any final selection should be based on the exact configuration and verified technical specifications.