ProductPRODUCT
Featured products
Contact Us
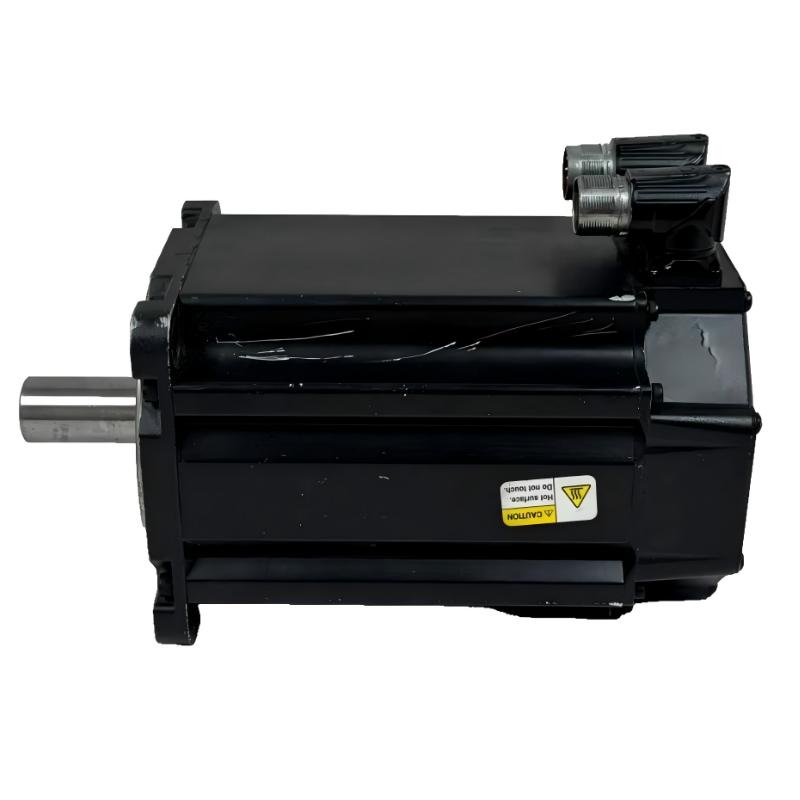
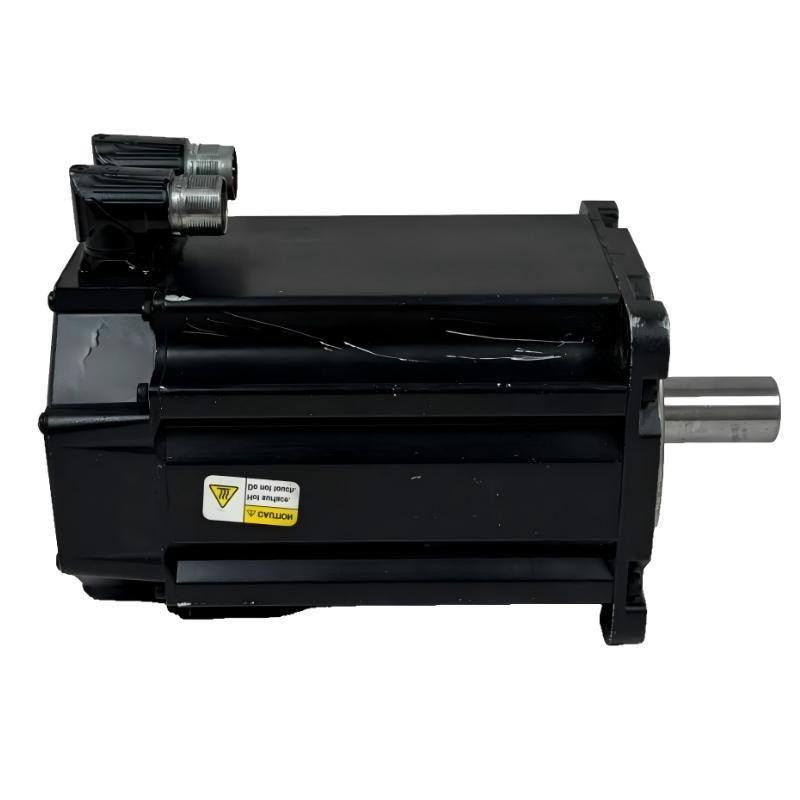
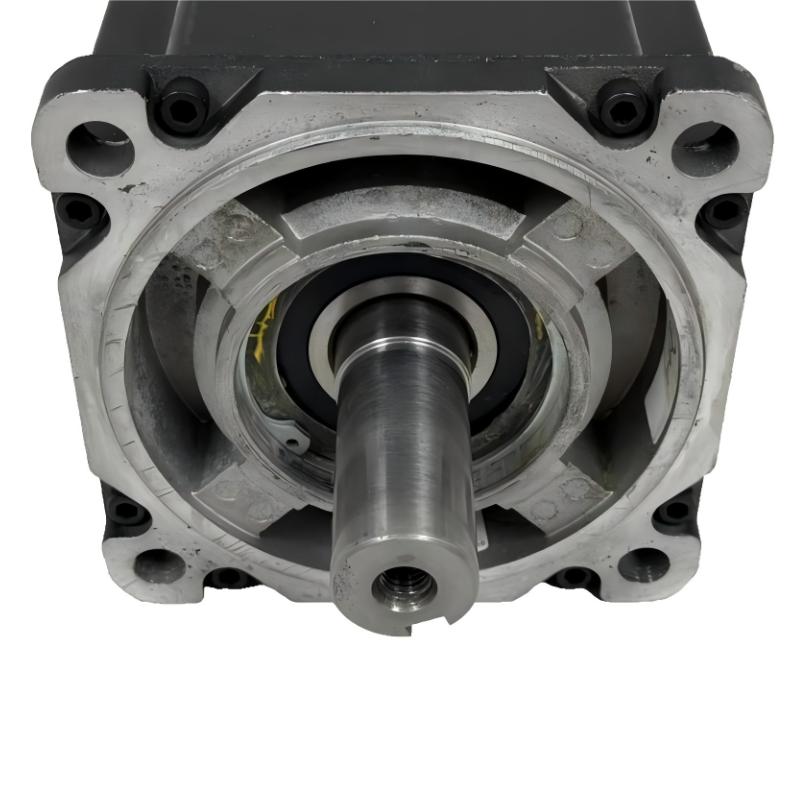
- Allen Bradley
- MPL-B680F-SJ72AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 215 mm ×203.2 mm × 325 mm
- 45.4 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 13
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
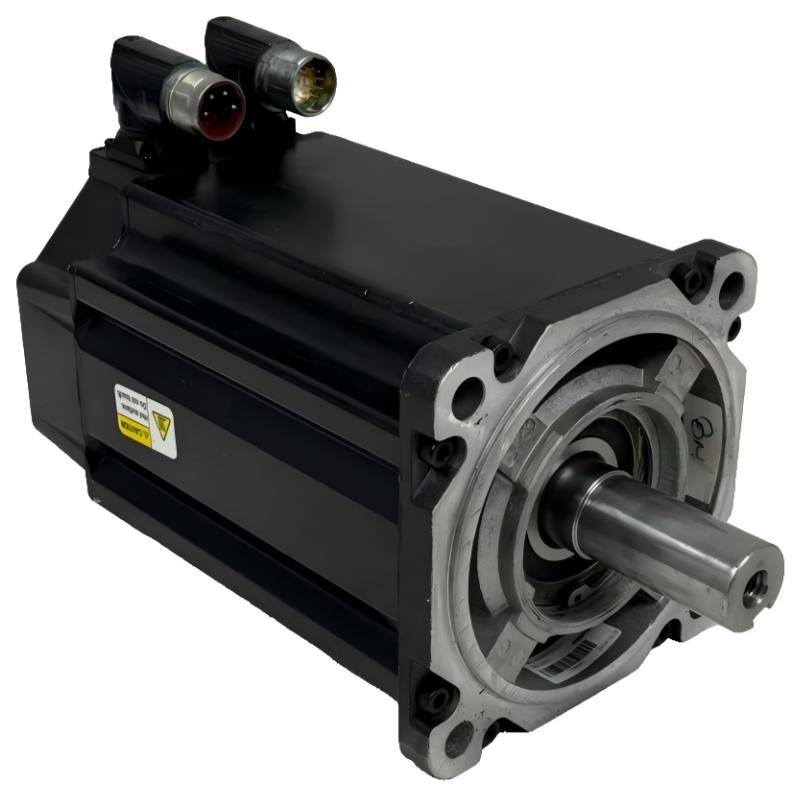
Allen-Bradley MPL-B680F-SJ72AA Low-Inertia Servo Motor – Detailed Product Introduction, Technical Parameters, Applications, Advantages and Model Comparison
1. Product Overview
The Allen-Bradley MPL-B680F-SJ72AA is a high-performance AC rotary servo motor belonging to the MP-Series MPL Low-Inertia Brushless Servo Motor family. It is designed for industrial motion-control systems where accurate positioning, stable torque production, repeatable movement, and relatively fast dynamic response are important.
This model uses a 215 mm frame size with a 203.2 mm magnetic stack length, giving it a substantial torque capability while retaining the low-inertia characteristics associated with the MPL motor family. Its nominal speed class is 3000 rpm, with approximately 60.0 N·m continuous stall torque and approximately 108.5 N·m peak stall torque.
Unlike brake-equipped versions of the same motor family, the MPL-B680F-SJ72AA does not include an integral holding brake. This makes it particularly suitable for horizontal axes and rotary mechanisms where a mechanical holding brake is not required.
The motor also incorporates a single-turn high-resolution absolute encoder, a keyed shaft, and a right-angle SpeedTec DIN connector that can be rotated to accommodate different machine layouts.
2. Basic Product Information
| Parameter | Specification |
|---|---|
| Brand | Allen-Bradley |
| Product Series | MP-Series MPL |
| Series Type | Low-Inertia Brushless Servo Motors |
| Product Model | MPL-B680F-SJ72AA |
| Product Type | AC Rotary Servo Motor |
| Motor Construction | Brushless permanent-magnet servo motor |
| Voltage Class | 460 V AC class |
| Electrical System | Three-phase AC |
| Frame Size | 215 mm |
| Magnet Stack Length | 203.2 mm |
| Rated Speed | 3000 rpm |
| Maximum Speed | 3000 rpm class |
| Continuous Stall Torque | 60.0 N·m |
| Peak Stall Torque | 108.5 N·m |
| Rated Output | 7.5 kW |
| Feedback | Single-turn high-resolution absolute encoder |
| Feedback Resolution | 1024 Sin/Cos cycles/revolution class |
| Feedback Protocol | Hiperface |
| Shaft | Keyed shaft |
| Brake | No integral brake |
| Connector | Right-angle SpeedTec DIN connector |
| Connector Rotation | Approximately 180° rotatable |
| Mounting | IEC metric flange |
| Mounting Hole Style | Free mounting holes, Type FF |
| Shaft Seal | No standard shaft seal |
| Standard Protection | IP50 class |
| Rotor Inertia | Approximately 0.00775 kg·m² |
| Continuous Stall Current | Approximately 48.0 A |
| Peak Stall Current | Approximately 96.0 A |
| Dimensions | 215 mm frame × 203.2 mm stack; complete envelope depends on configuration |
| Weight | Approximately 40–45 kg; approximately 45.4 kg is a commonly listed value |
The exact physical envelope should always be checked against the mechanical drawing for the particular motor revision, connector arrangement, shaft configuration, and installation requirements. The 215 mm frame dimension and 203.2 mm stack length are the key dimensional identifiers for this model.
3. Brand and Product Series
Brand: Allen-Bradley
The MPL-B680F-SJ72AA belongs to the Allen-Bradley motion-control product family and is intended for use as part of an industrial servo system.
Allen-Bradley servo motors are commonly selected in applications where the motor, servo drive, feedback system, motion controller, and machine mechanics need to work together as a coordinated motion system.
The motor itself should therefore not be considered as an isolated component. Its performance depends on correct drive selection, feedback compatibility, motor tuning, mechanical load characteristics, acceleration and deceleration requirements, and the machine’s thermal environment.
Product Series: MP-Series MPL
The product belongs to the MP-Series MPL Low-Inertia Brushless Servo Motor series.
The MPL series is designed around a low-inertia rotor concept. Compared with a motor having a much heavier rotor, a low-inertia servo motor can respond more quickly to changes in commanded speed and position when the mechanical system is appropriately matched.
For machine builders, this is especially useful on axes that repeatedly accelerate, decelerate, stop, reverse, and reposition.
The MPL family includes multiple frame sizes, stack lengths, speed ratings, feedback configurations, shaft configurations, and brake options. This allows engineers to select a motor according to the actual mechanical requirements instead of using one motor size for every axis.
4. Understanding the MPL-B680F-SJ72AA Model Number
The model number contains useful information about the motor configuration.
| Model Code Section | General Meaning |
|---|---|
| MPL | MPL low-inertia servo motor family |
| B | 460 V class motor configuration |
| 6 | Frame size 6 / approximately 215 mm frame |
| 80 | 203.2 mm magnetic stack length |
| F | 3000 rpm speed class |
| S | Single-turn absolute feedback |
| J | Keyed shaft configuration |
| 72 | No integral brake configuration |
| AA | Factory configuration/suffix |
The model number is particularly useful when comparing motors that look similar externally but have different feedback or braking configurations.
For example, MPL-B680F-SJ72AA and MPL-B680F-SJ24AA share the same basic frame, stack length, and speed class, but the latter includes a 24 V DC holding brake.
5. Detailed Technical Parameters
| Technical Parameter | MPL-B680F-SJ72AA |
|---|---|
| Model | MPL-B680F-SJ72AA |
| Brand | Allen-Bradley |
| Series | MP-Series MPL |
| Motor Type | Low-inertia brushless AC servo motor |
| Voltage Class | 460 V AC |
| Rated Speed | 3000 rpm |
| Maximum Speed | 3000 rpm class |
| Rated Output Power | 7.5 kW |
| Continuous Stall Torque | 60.0 N·m |
| Peak Stall Torque | 108.5 N·m |
| Continuous Stall Current | 48.0 A |
| Peak Stall Current | 96.0 A |
| Rotor Inertia | 0.00775 kg·m² |
| Frame Size | 215 mm |
| Magnet Stack | 203.2 mm |
| Feedback | Single-turn absolute |
| Encoder | High-resolution Sin/Cos encoder |
| Encoder Resolution | 1024 cycles/rev class |
| Feedback Protocol | Hiperface |
| Shaft | Keyed |
| Brake | None |
| Shaft Seal | None as standard |
| Connector | SpeedTec DIN |
| Connector Style | Right-angle |
| Connector Rotation | Approximately 180° |
| Mounting | IEC metric flange |
| Mounting Hole Type | Free mounting holes / Type FF |
| Protection | IP50 standard class |
| Maximum Operating Temperature | Approximately 40 °C class |
| Dimensions | 215 mm frame × 203.2 mm stack |
| Weight | Approximately 40–45 kg; approximately 45.4 kg commonly listed |
6. Torque Performance
One of the strongest characteristics of the MPL-B680F-SJ72AA is its torque capability.
The motor provides approximately 60.0 N·m of continuous stall torque and approximately 108.5 N·m of peak stall torque.
The continuous torque figure is important for applications where the motor must repeatedly provide substantial torque without exceeding its thermal operating limits.
The peak torque rating is more relevant to short-duration acceleration, rapid deceleration, positioning, load changes, and other transient operating conditions.
The ratio between continuous and peak torque gives the servo system some additional dynamic capacity. However, peak torque should not be treated as a continuous operating point. The actual permissible duty cycle depends on the drive, motor temperature, ambient temperature, load profile, acceleration/deceleration pattern, and cooling conditions.
7. Speed and Power
The MPL-B680F-SJ72AA is a 3000 rpm-class servo motor with approximately 7.5 kW continuous rated output.
A 3000 rpm motor is a practical choice for many industrial axes because it provides a useful balance between speed and torque.
At the same time, the motor’s substantial 203.2 mm magnetic stack allows it to maintain a high torque capability within its rated operating range.
This makes the motor more appropriate for substantial mechanical loads than smaller MPL motors with shorter stack lengths.
For applications requiring significantly higher speed, another MPL speed configuration may be more appropriate. Likewise, applications emphasizing very high low-speed torque may benefit from a lower-speed motor configuration.
8. Low-Inertia Rotor Design
The rotor inertia is approximately 0.00775 kg·m².
Low rotor inertia is one of the major reasons to select an MPL servo motor instead of a conventional industrial motor.
When a servo axis changes speed, the motor must accelerate or decelerate its own rotor as well as the reflected inertia of the mechanical load.
A lower rotor inertia can make the motor easier to control dynamically, especially when the load inertia is properly matched to the motor.
This characteristic is valuable in machines with frequent start-stop operation, rapid indexing, repeated positioning, and cyclic motion.
It is particularly useful when the machine needs to move from one position to another and settle quickly before the next operation begins.
9. Feedback System
The MPL-B680F-SJ72AA uses a single-turn high-resolution absolute encoder.
The feedback system provides the servo drive with information about the motor’s position and rotational state.
The encoder is based on a Sin/Cos feedback format with approximately 1024 cycles per revolution, and the configuration uses a Hiperface-type feedback protocol.
For motion applications, high-resolution feedback is important because the drive uses encoder information to regulate motor position, velocity, and torque.
The single-turn configuration is particularly appropriate where the application needs precise position information within one mechanical revolution and where the overall machine control strategy does not require the additional absolute multi-turn functionality.
10. Single-Turn Feedback Versus Multi-Turn Feedback
A useful comparison within the MPL family is between single-turn and multi-turn encoder versions.
| Feature | Single-Turn Configuration | Multi-Turn Configuration |
|---|---|---|
| Position within one revolution | Yes | Yes |
| Multi-revolution absolute position | Application dependent / no multi-turn counting | Yes |
| Typical use | Rotary positioning and cyclic axes | Long-travel or multi-revolution positioning |
| Encoder complexity | Lower | Higher |
| Model example | MPL-B680F-SJ72AA | MPL-B680F-MJ72AA |
| Selection consideration | Suitable when one-turn absolute feedback is sufficient | Useful where absolute multi-turn position is required |
The choice should be made according to the machine’s homing requirements and mechanical travel.
If the axis is repeatedly referenced mechanically or electronically during operation, single-turn feedback may be entirely adequate.
For long-travel mechanisms where the motor can rotate through many revolutions and the controller needs to retain absolute position information across those revolutions, a multi-turn configuration may be more appropriate.
11. Shaft Configuration
The MPL-B680F-SJ72AA uses a keyed shaft extension.
The keyed shaft is useful where the machine transmission uses a mechanical coupling, pulley, gear, sprocket, or similar component that requires positive torque transmission through a key.
Correct coupling alignment remains extremely important.
A servo motor should not be expected to compensate for mechanical misalignment. Excessive radial or axial loading can shorten bearing life and negatively affect the overall motion system.
12. No Integral Brake
One of the defining characteristics of this particular model is the absence of an integral motor brake.
The MPL-B680F-SJ72AA is therefore generally better suited to applications where the axis does not need the motor to mechanically hold its position when servo power is removed.
Typical examples include many horizontal rotary axes, conveyors, rollers, indexing mechanisms, and machine axes where gravity does not create a dangerous downward movement.
For vertical axes, suspended loads, lifting mechanisms, or mechanisms where position must be maintained after servo power is removed, a brake-equipped model should be considered.
13. Connector Configuration
The motor uses a right-angle SpeedTec DIN connector.
The connector arrangement is practical for machine installation because the right-angle orientation can reduce the amount of space required around the motor.
The connector can also be rotated through approximately 180 degrees, allowing the cable exit direction to be adapted to the machine layout.
This is useful when motors are installed inside compact machine frames where a straight connector would create unnecessary interference.
Cable routing should still be planned carefully because servo cables should be protected against excessive bending, mechanical abrasion, vibration, and interference.
14. Mounting Configuration
The motor uses an IEC metric flange mounting arrangement with free mounting holes.
The 215 mm frame size places this motor in a relatively large servo motor category.
When installing the motor, the machine designer should check:
- Mounting flange dimensions
- Pilot diameter
- Bolt pattern
- Shaft dimensions
- Shaft key dimensions
- Allowable radial load
- Allowable axial load
- Coupling alignment
- Cable clearance
- Connector clearance
- Motor cooling conditions
The physical space required by the connector and cables should be considered in addition to the motor body itself.
15. Dimensions and Weight
The key dimensional characteristics of the motor are shown below.
| Dimension / Mechanical Parameter | MPL-B680F-SJ72AA |
|---|---|
| Frame Size | 215 mm |
| Frame Diameter/Class | Approximately 215 mm |
| Magnet Stack Length | 203.2 mm |
| Stack Length in Inches | 8.0 in |
| Mounting | IEC metric flange |
| Shaft | Keyed |
| Connector | Right-angle DIN |
| Connector Rotation | Approximately 180° |
| Standard Shaft Seal | No |
| Approximate Overall Motor Length | Configuration dependent |
| Approximate Weight | 40–45 kg |
| Commonly Listed Weight | Approximately 45.4 kg |
The 215 mm frame and 203.2 mm stack length should be regarded as the primary dimensional identifiers.
The complete installed envelope can be larger because the connector, shaft extension, cable bend radius, mounting hardware, and coupling all require additional space.
For an actual machine design, the final mechanical drawing should be used rather than relying only on the nominal frame and stack dimensions.
16. Product Introduction in Practical Terms
In practical terms, the MPL-B680F-SJ72AA is a large-frame, high-torque, 3000 rpm servo motor designed for demanding industrial motion axes.
Its combination of approximately 7.5 kW output, 60.0 N·m continuous stall torque, 108.5 N·m peak stall torque, and low rotor inertia makes it suitable for machines that need both substantial mechanical power and controlled dynamic movement.
It is not simply a high-power motor. Its value comes from the combination of torque, feedback resolution, servo controllability, low rotor inertia, and mechanical integration.
For machine builders, this combination can be especially useful where a conventional induction motor would not provide sufficient positioning performance and where a smaller servo motor would not provide enough torque.
17. Main Product Advantages
17.1 High Continuous Torque
The approximately 60.0 N·m continuous stall torque provides a strong torque reserve for demanding servo axes.
This is useful when the motor must maintain torque for extended periods, especially at low speed or during controlled positioning.
17.2 High Peak Torque
The approximately 108.5 N·m peak stall torque provides additional short-term capacity during acceleration and transient load conditions.
This can be particularly valuable in machines with high acceleration requirements or changing mechanical loads.
17.3 Low-Inertia Design
The approximately 0.00775 kg·m² rotor inertia supports responsive servo operation.
A low-inertia motor can be advantageous in applications where rapid speed changes and short positioning cycles are important.
17.4 High-Resolution Absolute Feedback
The single-turn absolute feedback system provides precise motor position information.
This helps the servo drive regulate the axis accurately and supports applications where repeatable positioning is important.
17.5 3000 rpm Operating Class
The 3000 rpm speed class gives the motor a useful combination of torque and rotational speed.
This makes it suitable for many industrial machine axes without requiring an unusually high-speed motor configuration.
17.6 Keyed Shaft
The keyed shaft is convenient for conventional mechanical power transmission arrangements.
It provides a positive mechanical connection when used with a properly designed keyed coupling or transmission component.
17.7 Flexible Connector Arrangement
The right-angle DIN connector with approximately 180-degree rotational flexibility makes the motor easier to integrate into machines with limited cable-routing space.
17.8 No Brake Can Be an Advantage
Although the absence of a brake can be a disadvantage for vertical axes, it is an advantage when a brake is unnecessary.
A no-brake motor can be simpler and lighter than an otherwise comparable brake-equipped version, and there is no brake coil or brake release mechanism to manage.
18. Typical Applications
The MPL-B680F-SJ72AA can be considered for a wide range of industrial servo applications.
Packaging Machinery
Packaging equipment often requires repeated acceleration, deceleration, indexing, positioning, and synchronization.
The motor’s low-inertia characteristics and high torque capability make it suitable for demanding packaging axes.
Typical applications can include:
- Packaging conveyors
- Indexing mechanisms
- Rotary positioning
- Cutting mechanisms
- Film handling
- Product transfer
- Feeding mechanisms
Material Handling
Material-handling machines frequently require controlled acceleration and accurate positioning.
The motor can be used in:
- Conveyor systems
- Transfer mechanisms
- Positioning tables
- Roller drives
- Automated handling equipment
- Indexing units
Electronic Assembly
Electronic assembly machinery can require precise positioning and repeatable movement.
The high-resolution feedback system can be useful in:
- Assembly stations
- Pick-and-place mechanisms
- Transfer systems
- Component handling
- Automated positioning equipment
Converting Equipment
Converting machinery often includes rollers, feeders, cutters, unwind/rewind mechanisms, and synchronized axes.
The 3000 rpm operating class and high torque capacity can be useful for these applications when properly sized.
Automotive Manufacturing Equipment
Automotive production machinery frequently uses servo motors for controlled positioning and material movement.
Possible applications include:
- Assembly machines
- Transfer systems
- Indexing systems
- Automated fixtures
- Material handling
- Machine-tool auxiliary axes
Machine Tools
The motor can also be considered for certain machine-tool auxiliary axes, positioning systems, rotary mechanisms, and automated machine functions where its torque and speed characteristics match the load.
19. Applications Where the No-Brake Configuration Is Appropriate
The no-brake configuration is generally more appropriate for:
- Horizontal axes
- Rotary indexing systems
- Conveyor drives
- Roller drives
- Horizontal positioning mechanisms
- Material transfer systems
- Applications with an independent mechanical holding mechanism
- Axes that are not exposed to gravity-driven movement
For vertical axes, the engineer should carefully evaluate whether a brake or independent mechanical safety mechanism is required.
20. Five Related Models from the Same MPL Family
The following five models are useful comparison choices because they share substantial mechanical or electrical characteristics with the MPL-B680F-SJ72AA.
The figures below are presented as practical comparison values; exact specifications can vary with configuration and revision.
| Model | Frame / Stack | Speed | Continuous Torque | Peak Torque | Power | Feedback | Brake | Weight |
|---|---|---|---|---|---|---|---|---|
| MPL-B680F-SJ72AA | 215 / 203.2 mm | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Single-turn absolute | No | ~40–45 kg |
| MPL-B680F-SJ24AA | 215 / 203.2 mm | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Single-turn absolute | 24 V DC | ~40–45 kg |
| MPL-B680F-MJ72AA | 215 / 203.2 mm | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Multi-turn absolute | No | ~40–45 kg |
| MPL-B680F-MJ24AA | 215 / 203.2 mm | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Multi-turn absolute | 24 V DC | ~40–45 kg |
| MPL-B680D-SJ24AA | 215 / 203.2 mm | 2000 rpm | ~62.8 N·m | ~154.2 N·m | ~9.3 kW | Single-turn absolute | 24 V DC | ~40–45 kg |
| MPL-B680H-SJ24AA | 215 / 203.2 mm | 3500 rpm | ~60 N·m | ~146.9 N·m | ~7.5 kW class | Single-turn absolute | 24 V DC | ~40–45 kg |
21. Comparison of the Five Related Models
MPL-B680F-SJ24AA
This is probably the most direct comparison to the target model.
The mechanical frame and stack are essentially in the same class, while the major difference is the addition of a 24 V DC holding brake.
For a horizontal axis, the no-brake MPL-B680F-SJ72AA may be sufficient.
For a vertical axis or an axis that needs to maintain its position when servo power is removed, the brake-equipped configuration can be more appropriate.
MPL-B680F-MJ72AA
The MPL-B680F-MJ72AA maintains the same general 3000 rpm, 215 mm frame and 203.2 mm stack configuration, but uses multi-turn absolute feedback.
This makes it a useful alternative where the machine requires absolute position information over multiple motor revolutions.
MPL-B680F-MJ24AA
This combines the multi-turn feedback arrangement with a 24 V DC holding brake.
It is therefore useful when the machine needs both multi-turn absolute position capability and mechanical holding functionality.
MPL-B680D-SJ24AA
The D-speed configuration is oriented toward a lower nominal speed and higher torque capability.
With approximately 62.8 N·m continuous torque and approximately 154.2 N·m peak torque, it can be attractive for applications where acceleration torque and lower-speed mechanical force are more important than 3000 rpm operation.
MPL-B680H-SJ24AA
The H configuration provides a higher speed class, around 3500 rpm.
It can be useful when the machine requires more rotational speed while still maintaining a large 215 mm frame and 203.2 mm stack.
22. Five Same-Brand Models Commonly Compared with This Motor
The following models are useful comparison choices within the same Allen-Bradley servo motor family.
| Model | Frame / Stack | Speed | Continuous Torque | Peak Torque | Rated Power | Feedback | Brake | Approx. Weight |
|---|---|---|---|---|---|---|---|---|
| MPL-B640F-MJ72AA | 215 / 101.6 mm | 3000 rpm | ~36.7 N·m | ~72.3 N·m | ~6.1 kW | Multi-turn absolute | No | ~26.8 kg |
| MPL-B640F-MJ74AA | 215 / 101.6 mm | 3000 rpm | ~36.7 N·m | ~72.3 N·m | ~6.1 kW | Multi-turn absolute | 24 V DC | ~26.8 kg |
| MPL-B660F-MJ72AA | 215 / 152.4 mm | 3000 rpm | ~48 N·m | ~101.1 N·m | ~6.15 kW | Multi-turn absolute | No | ~35 kg |
| MPL-B660F-MJ74AA | 215 / 152.4 mm | 3000 rpm | ~48 N·m | ~101.1 N·m | ~6.15 kW | Multi-turn absolute | 24 V DC | ~35 kg |
| MPL-B680D-MJ74AA | 215 / 203.2 mm | 2000 rpm | ~62.8 N·m | ~154.2 N·m | ~9.3 kW | Multi-turn absolute | 24 V DC | ~40–45 kg |
These are best viewed as commonly compared or useful alternative models, rather than a ranking of current sales popularity.
23. Detailed Comparison of the 640, 660 and 680 Frame Configurations
The stack length is an important factor when comparing MPL motors.
| Model Group | Stack Length | Approx. Continuous Torque | General Position |
|---|---|---|---|
| MPL-B640F | 101.6 mm | ~36.7 N·m | Lower torque / more compact |
| MPL-B660F | 152.4 mm | ~48 N·m | Medium torque |
| MPL-B680F | 203.2 mm | ~60.0 N·m | Higher torque |
| MPL-B680D | 203.2 mm | ~62.8 N·m | High torque / lower speed |
| MPL-B680H | 203.2 mm | ~60 N·m class | High-speed configuration |
This demonstrates why stack length matters.
Two motors may have the same basic frame diameter but different magnetic stack lengths. The longer stack generally provides greater electromagnetic capability, which can translate into higher continuous torque.
Therefore, when replacing an existing motor, simply matching the frame diameter is not enough. The stack length, speed class, feedback, brake, shaft, and connector configuration also need to match.
24. Dimensions and Weight Comparison
| Model | Frame Size | Stack Length | Approx. Weight | Mechanical Size Class |
|---|---|---|---|---|
| MPL-B640F-MJ72AA | 215 mm | 101.6 mm | ~26.8 kg | Medium |
| MPL-B640F-MJ74AA | 215 mm | 101.6 mm | ~26.8 kg | Medium |
| MPL-B660F-MJ72AA | 215 mm | 152.4 mm | ~35 kg | Medium-large |
| MPL-B660F-MJ74AA | 215 mm | 152.4 mm | ~35 kg | Medium-large |
| MPL-B680F-SJ72AA | 215 mm | 203.2 mm | ~40–45 kg | Large |
| MPL-B680D-MJ74AA | 215 mm | 203.2 mm | ~40–45 kg | Large |
The increase in stack length is important when checking machine installation space.
The MPL-B680F-SJ72AA has the longest stack among these comparison models, so it requires more axial installation space than the B640F and B660F configurations.
25. Why Choose MPL-B680F-SJ72AA Instead of a Smaller MPL Motor?
The main reason is torque capacity.
A smaller MPL motor may physically fit the machine but may not provide enough continuous torque or peak torque.
The B680F configuration provides approximately 60.0 N·m continuous stall torque, which gives it a considerable advantage over the shorter-stack B640F and B660F models.
The trade-off is increased physical size and weight.
Therefore, the B680F is most appropriate when the mechanical load justifies its larger motor envelope.
26. Why Choose a B640F or B660F Instead?
A shorter-stack motor can be advantageous when the machine has limited axial space or when the load does not require the torque capacity of the B680F.
For example, the B640F configuration has a 101.6 mm stack and is substantially shorter than the B680F’s 203.2 mm stack.
The B660F sits between the two.
This provides a useful selection progression:
B640F → B660F → B680F
with increasing stack length and generally increasing torque capability.
27. Selecting Between No-Brake and Brake Models
| Requirement | Recommended Direction |
|---|---|
| Horizontal axis | No-brake configuration can be suitable |
| Conveyor | No-brake configuration often suitable |
| Rotary indexer | No-brake configuration often suitable |
| Gravity-loaded vertical axis | Brake configuration should be considered |
| Vertical lifting mechanism | Brake configuration strongly worth evaluating |
| Axis must hold position after servo power loss | Brake configuration or independent mechanical holding system |
| Machine has an external mechanical brake | No-brake motor may be appropriate |
| Safety function requires mechanical holding | Evaluate brake and safety architecture separately |
A servo motor brake should not automatically be treated as the machine’s complete safety system. The machine’s risk assessment, safety circuit, load characteristics, and applicable engineering requirements determine the correct solution.
28. Installation Considerations
The motor should be installed on a rigid, accurately machined mounting surface.
The coupling should be aligned carefully to prevent excessive radial and axial loads.
The shaft should never be subjected to impact loading during installation.
Cable routing should provide sufficient bending radius and should prevent the connector from carrying mechanical cable loads.
The motor should also have adequate heat dissipation. Operating the motor in a confined enclosure without considering thermal conditions can reduce the usable continuous torque.
29. Thermal Considerations
The continuous torque specification is not simply a mechanical rating.
Servo motors generate heat due to winding losses, electrical losses, and mechanical losses.
The actual continuous operating capability can therefore be influenced by:
- Ambient temperature
- Installation orientation
- Machine enclosure
- Cooling conditions
- Duty cycle
- Speed
- Load torque
- Acceleration profile
- Cable configuration
- Drive settings
A motor that works comfortably in an open machine frame may have a different thermal margin when installed inside a compact enclosure.
30. Servo Drive Matching
The motor must be matched with a compatible servo drive.
The drive needs to support the motor’s:
- Voltage class
- Current requirements
- Feedback type
- Encoder protocol
- Motor parameters
- Rated speed
- Torque requirements
- Cable and connector arrangement
The drive also needs sufficient continuous and peak current capacity.
Because the MPL-B680F-SJ72AA has approximately 48 A continuous stall current and approximately 96 A peak stall current, drive sizing is particularly important.
A drive that is technically compatible but undersized for the application’s actual acceleration profile may not deliver the desired performance.
31. Mechanical Load Matching
Servo motor selection should not be based solely on motor power.
A proper selection normally considers:
Load torque + acceleration torque + reflected inertia + operating speed + duty cycle + mechanical transmission ratio.
For example, a machine may require relatively little continuous torque but very high acceleration torque.
Another machine may run continuously at a moderate torque level.
These two machines can require very different motor selections even if their average mechanical power is similar.
32. Inertia Matching
The motor rotor inertia is approximately 0.00775 kg·m².
The mechanical load inertia reflected to the motor shaft should be evaluated together with this value.
A good inertia relationship helps the servo drive achieve stable and responsive control.
If the load inertia is extremely large relative to the motor, acceleration response may become slower and tuning may become more difficult.
If the load is extremely light, servo tuning can also require attention because the motor may respond very aggressively.
Therefore, the goal is not simply to select the lowest possible inertia motor. The goal is to select a motor whose dynamic characteristics are appropriate for the complete mechanical system.
33. Maintenance Considerations
Servo motors generally require less routine maintenance than many conventional mechanical drive systems, but they should still be inspected as part of machine maintenance.
Important inspection points include:
- Motor mounting bolts
- Coupling condition
- Shaft alignment
- Connector condition
- Cable condition
- Encoder feedback stability
- Excessive vibration
- Abnormal noise
- Bearing condition
- Motor temperature
- Contamination around the shaft
- Signs of mechanical overload
Because the standard configuration does not include a shaft seal, applications involving dust, liquid, washdown, or other contaminants require additional environmental consideration.
34. Environmental Protection
The standard motor configuration is generally associated with an IP50-class enclosure.
That means the motor should not simply be assumed to be suitable for direct exposure to water or heavy contamination.
For applications involving liquids, dust, washdown, or harsh environments, the complete motor and cable configuration must be evaluated.
A shaft seal and appropriate environmentally sealed cabling may be required in applications where additional protection is necessary.
35. Advantages and Limitations at a Glance
| Item | Evaluation of MPL-B680F-SJ72AA |
|---|---|
| Torque Capability | Excellent for its motor class |
| Peak Torque | High |
| Rated Speed | Good 3000 rpm class |
| Dynamic Response | Good due to low-inertia design |
| Feedback | High-resolution single-turn absolute |
| Shaft | Keyed |
| Brake | None |
| Installation Flexibility | Good |
| Connector Flexibility | Good |
| Weight | Relatively high |
| Physical Size | Relatively large |
| Environmental Protection | Standard IP50 class |
| Best Use | High-torque industrial servo axes |
| Vertical Axis Suitability | Requires careful brake/holding evaluation |
| Horizontal Axis Suitability | Very good when correctly sized |
36. Model Selection Guide
If the application requires high torque, 3000 rpm operation, single-turn absolute feedback, and no holding brake, the MPL-B680F-SJ72AA is a very logical configuration.
If the same mechanical characteristics are required but a brake is needed, the MPL-B680F-SJ24AA is a more appropriate direction.
If multi-turn absolute position is required, the MPL-B680F-MJ72AA or MPL-B680F-MJ24AA configurations are worth considering.
If higher peak torque at lower speed is more important, the MPL-B680D family is a useful alternative.
If higher rotational speed is important, the MPL-B680H family can be considered.
37. Five Related Models – More Detailed Comparison
| Model | Speed | Continuous Torque | Peak Torque | Power | Feedback | Brake | Frame | Stack | Weight |
|---|---|---|---|---|---|---|---|---|---|
| MPL-B680F-SJ72AA | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Single-turn | No | 215 mm | 203.2 mm | ~40–45 kg |
| MPL-B680F-SJ24AA | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Single-turn | 24 V DC | 215 mm | 203.2 mm | ~40–45 kg |
| MPL-B680F-MJ72AA | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Multi-turn | No | 215 mm | 203.2 mm | ~40–45 kg |
| MPL-B680F-MJ24AA | 3000 rpm | 60.0 N·m | 108.5 N·m | 7.5 kW | Multi-turn | 24 V DC | 215 mm | 203.2 mm | ~40–45 kg |
| MPL-B680D-SJ24AA | 2000 rpm | ~62.8 N·m | ~154.2 N·m | ~9.3 kW | Single-turn | 24 V DC | 215 mm | 203.2 mm | ~40–45 kg |
| MPL-B680H-SJ24AA | 3500 rpm | ~60 N·m | ~146.9 N·m | ~7.5 kW class | Single-turn | 24 V DC | 215 mm | 203.2 mm | ~40–45 kg |
38. Five Same-Brand Comparison Models – More Detailed Parameters
| Model | Speed | Continuous Torque | Peak Torque | Power | Feedback | Brake | Frame / Stack | Rotor Inertia | Weight |
|---|---|---|---|---|---|---|---|---|---|
| MPL-B640F-MJ72AA | 3000 rpm | ~36.7 N·m | ~72.3 N·m | ~6.1 kW | Multi-turn | No | 215 / 101.6 mm | ~0.004 kg·m² | ~26.8 kg |
| MPL-B640F-MJ74AA | 3000 rpm | ~36.7 N·m | ~72.3 N·m | ~6.1 kW | Multi-turn | 24 V DC | 215 / 101.6 mm | ~0.004 kg·m² | ~26.8 kg |
| MPL-B660F-MJ72AA | 3000 rpm | ~48 N·m | ~101.1 N·m | ~6.15 kW | Multi-turn | No | 215 / 152.4 mm | ~0.0058 kg·m² | ~35 kg |
| MPL-B660F-MJ74AA | 3000 rpm | ~48 N·m | ~101.1 N·m | ~6.15 kW | Multi-turn | 24 V DC | 215 / 152.4 mm | ~0.0058 kg·m² | ~35 kg |
| MPL-B680D-MJ74AA | 2000 rpm | ~62.8 N·m | ~154.2 N·m | ~9.3 kW | Multi-turn | 24 V DC | 215 / 203.2 mm | ~0.00775 kg·m² | ~40–45 kg |
39. Overall Evaluation
The Allen-Bradley MPL-B680F-SJ72AA is a substantial industrial servo motor intended for applications where high torque, accurate feedback, controlled acceleration, and reliable positioning are more important than minimizing motor size.
Its main strengths are the combination of 7.5 kW rated output, 60.0 N·m continuous stall torque, 108.5 N·m peak stall torque, 3000 rpm speed capability, approximately 0.00775 kg·m² rotor inertia, single-turn high-resolution absolute feedback, and a 215 mm × 203.2 mm mechanical configuration.
The absence of an integral brake makes it particularly attractive for horizontal or rotary applications that do not require mechanical holding after servo power is removed.
At the same time, its approximately 40–45 kg weight and relatively large 215 mm frame mean that it should be selected based on actual load requirements rather than simply choosing the largest available motor.
For a machine requiring high torque at 3000 rpm with single-turn absolute feedback and a keyed shaft, but without an integral brake, the MPL-B680F-SJ72AA is a strong and practical member of the MPL low-inertia servo motor family.
The most important alternatives are the MPL-B680F-SJ24AA when a brake is required, the MPL-B680F-MJ72AA when multi-turn feedback is preferred, the MPL-B680D-SJ24AA when higher torque at a lower speed is needed, and the MPL-B680H-SJ24AA when a higher-speed configuration is more suitable.