Product Overview
In industrial robotic systems, the wrist unit is one of the most important mechanical assemblies responsible for providing flexible multi-axis movement, accurate positioning, and precise tool orientation. The robotic wrist enables robots to perform complex operations such as welding, assembly, handling, inspection, and machining with high accuracy.
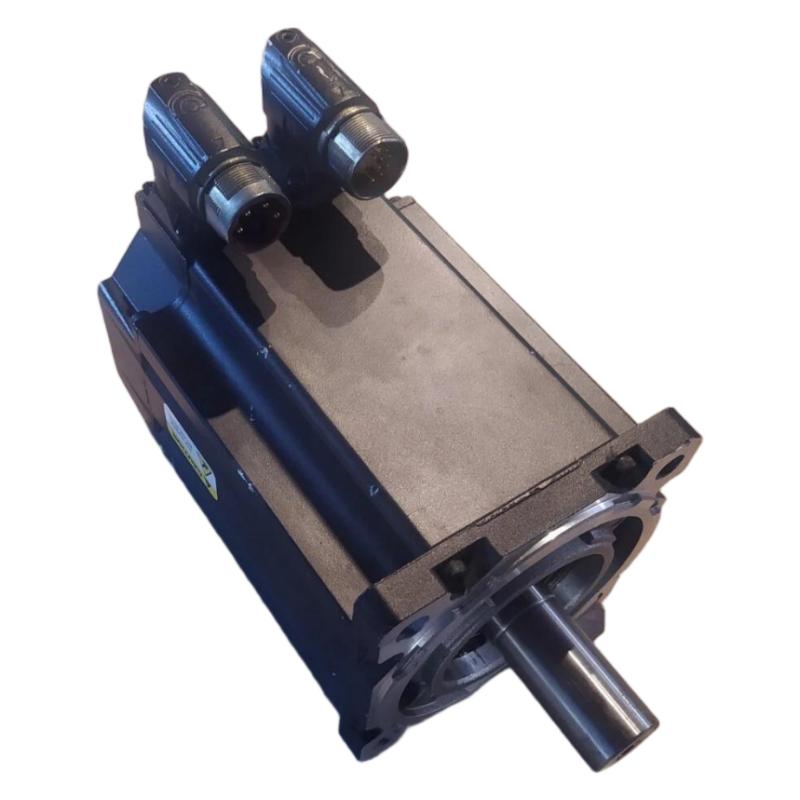
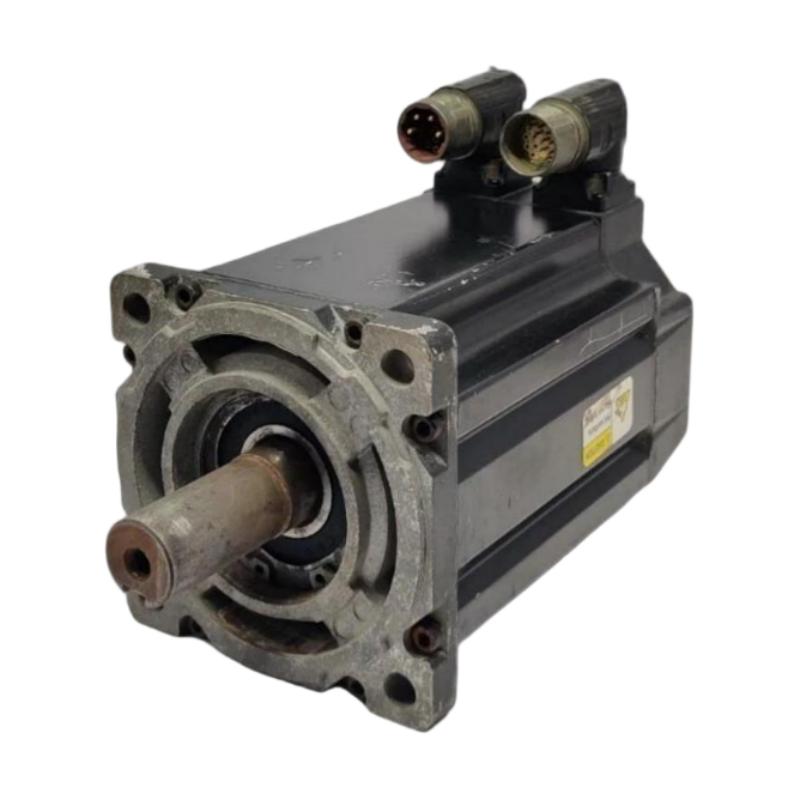
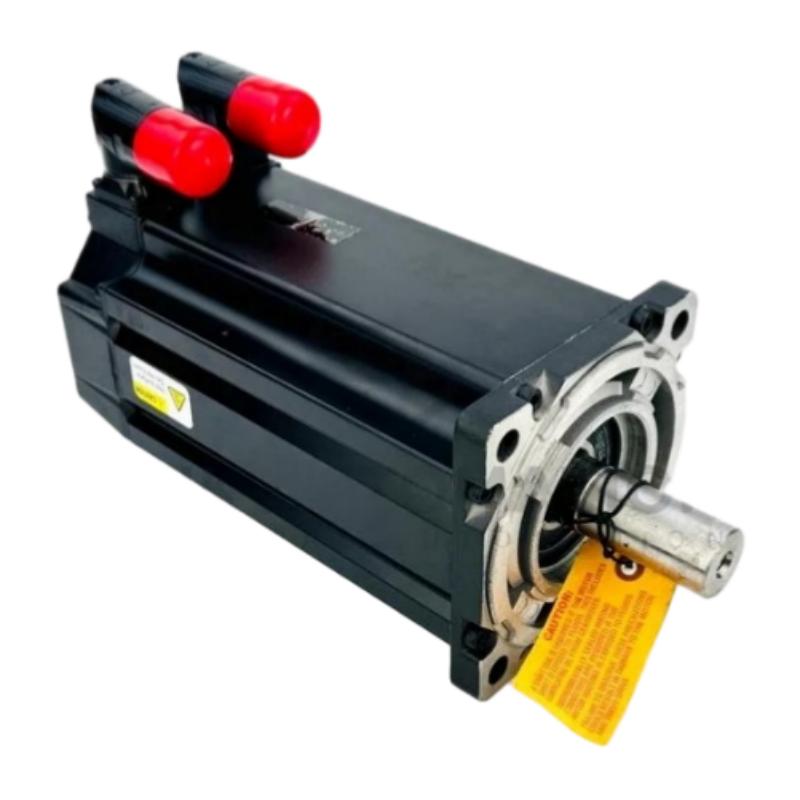
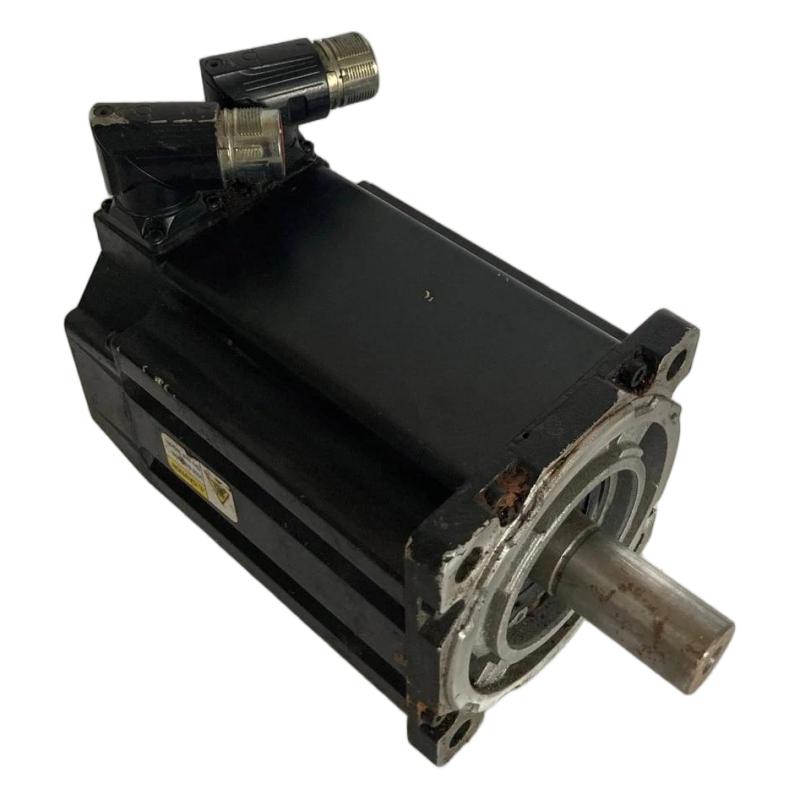
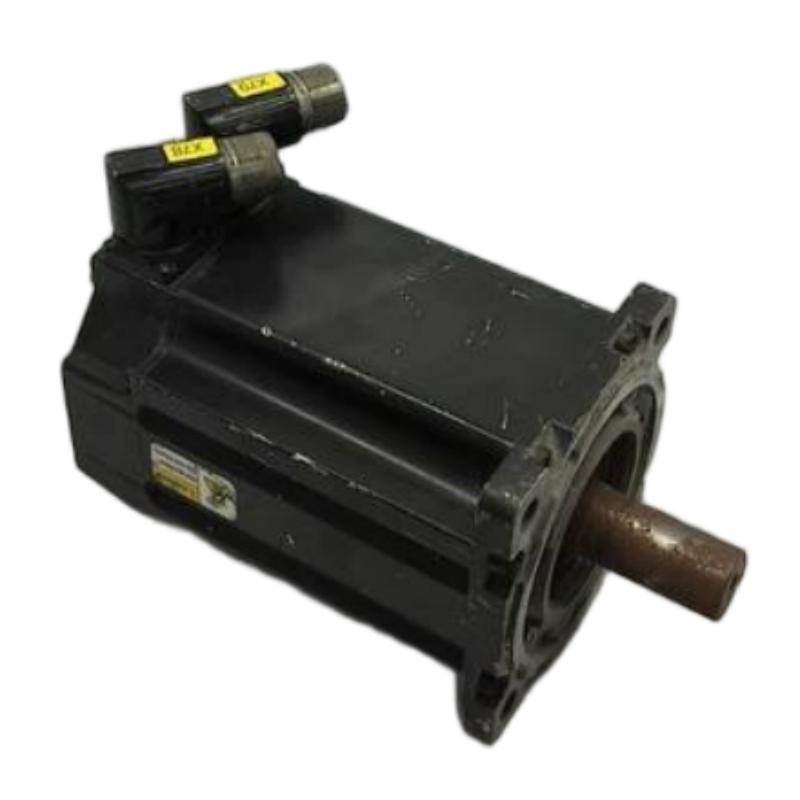
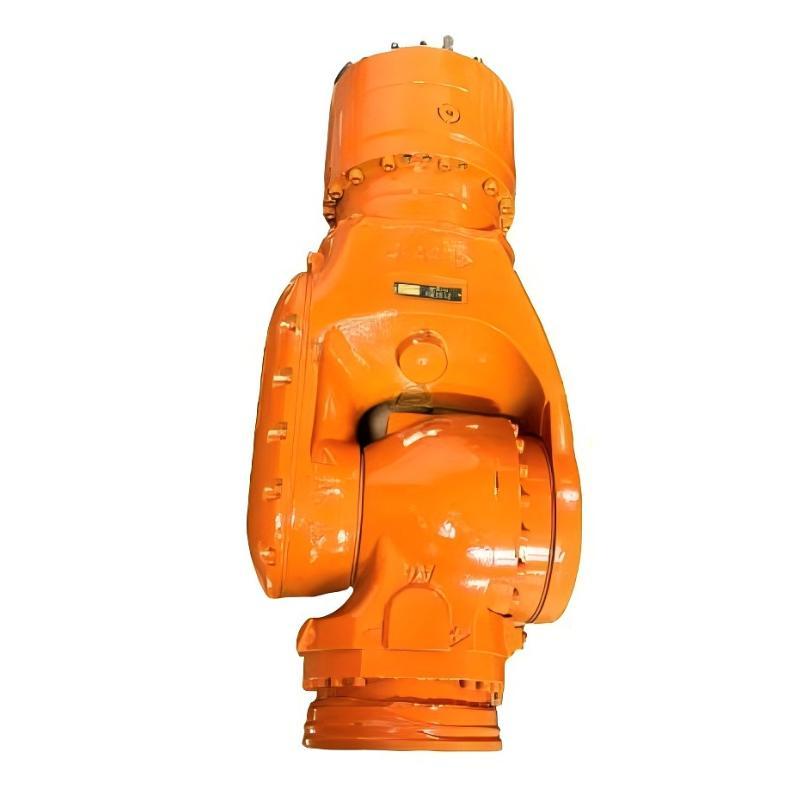
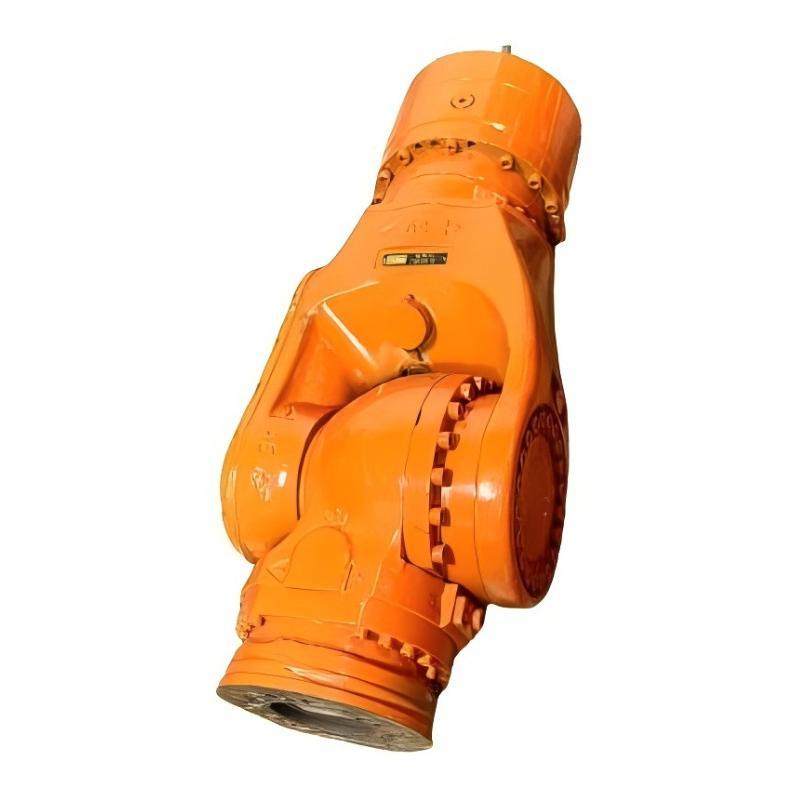
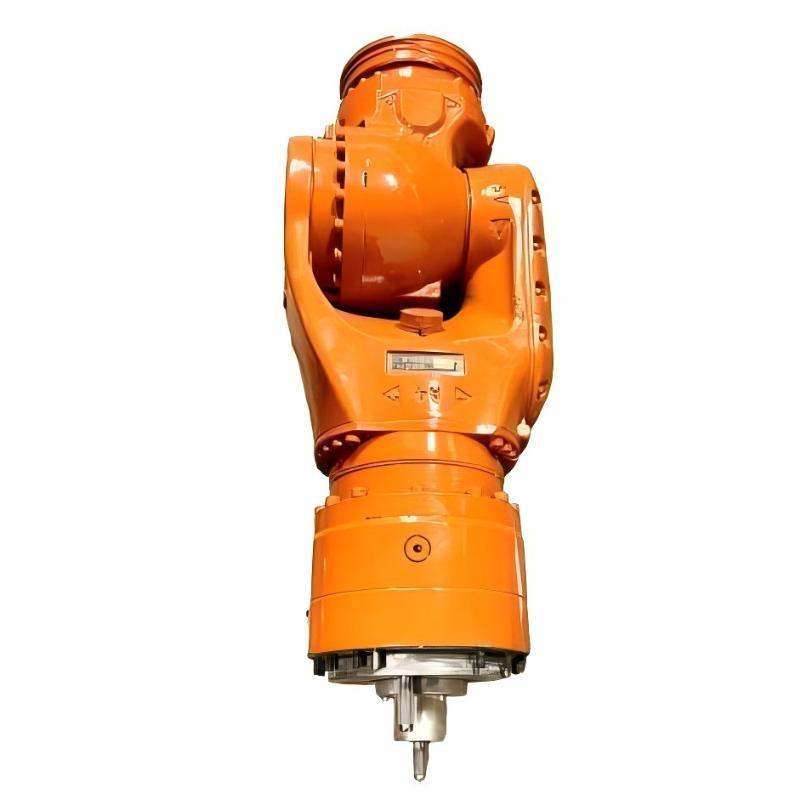
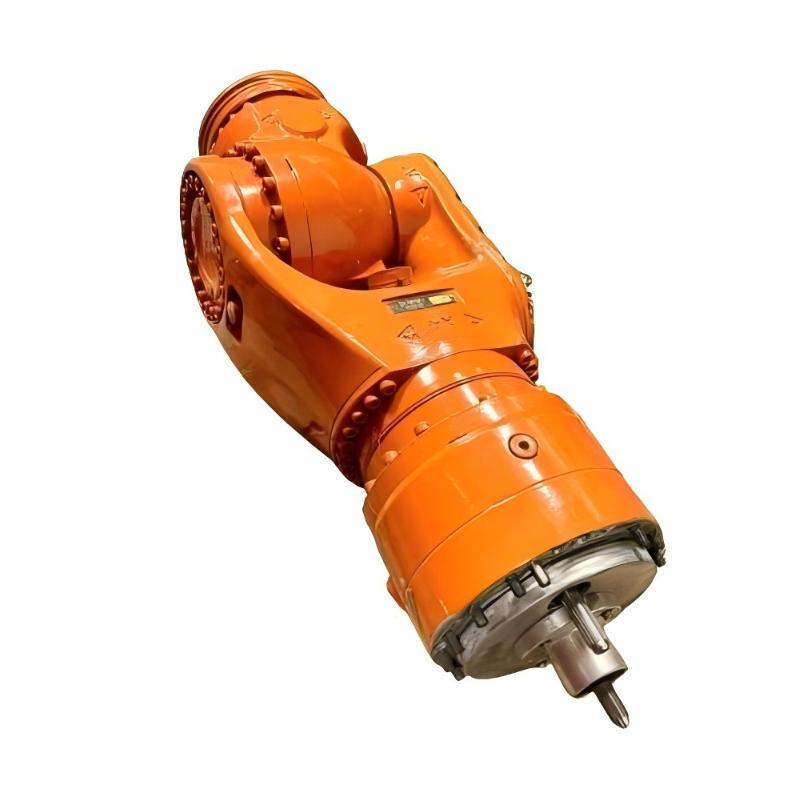
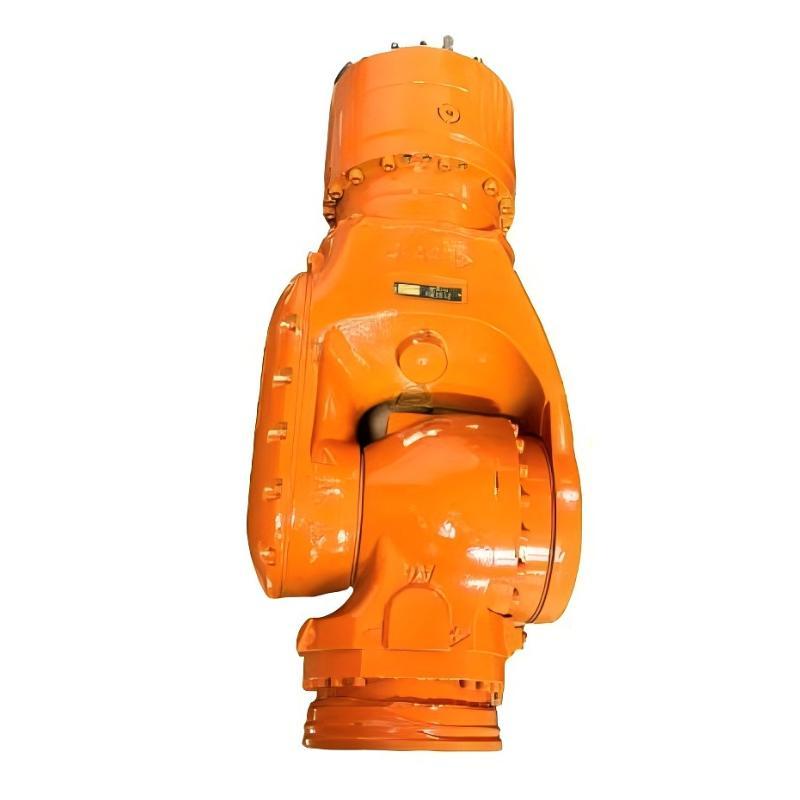
The ABB (KUKA) 00-106-446 Robotic Wrist Unit is an industrial robot mechanical assembly designed for ABB KUKA robotic systems. It provides multi-axis rotational movement at the robot arm end section, allowing the robot tool or end effector to achieve precise orientation and flexible motion.
Designed for demanding industrial automation environments, the 00-106-446 Robotic Wrist Unit delivers reliable mechanical performance, accurate motion transmission, and stable operation for robotic applications requiring high positioning precision.
With dimensions of 410 × 260 × 60 mm and a weight of 50 kg, the ABB (KUKA) 00-106-446 Robotic Wrist Unit features a robust mechanical structure suitable for industrial robot arms and heavy-duty automation applications.
Technical Specifications
| Parameter |
Details |
| Manufacturer |
ABB (KUKA) |
| Model |
00-106-446 |
| Product Type |
Robotic Wrist Unit |
| Application |
Industrial Robot Motion System |
| Function |
Robot End-Axis Motion and Tool Positioning |
| Component Type |
Mechanical Robot Assembly |
| Installation Type |
Robot Arm Wrist Section |
| Dimensions |
410 × 260 × 60 mm |
| Weight |
50 kg |
Function and Working Principle
The ABB (KUKA) 00-106-446 Robotic Wrist Unit operates as the final mechanical motion section of an industrial robot arm.
The operating process is:
Servo Motor Drive → Mechanical Transmission → Wrist Axis Rotation → End Effector Positioning
Main working functions include:
- Receives motion power from robot servo drive systems.
- Transfers torque through internal mechanical transmission components.
- Controls wrist-axis rotational movement.
- Adjusts tool orientation and working angle.
- Supports precise robotic operation.
The wrist unit allows the robot to achieve flexible positioning and accurate movement of tools, improving production efficiency and process accuracy.
Role in Industrial Automation Systems
The 00-106-446 Robotic Wrist Unit plays a critical role in ABB KUKA robot motion systems.
Main functions include:
- Multi-axis rotational movement
- End-effector positioning
- Mechanical torque transmission
- Robot motion flexibility
- Precision operation support
Typical applications include:
- Industrial robotic arms
- Automated manufacturing cells
- Welding robots
- Assembly robots
- Material handling systems
- Precision machining applications
Main Features
High Precision Motion Control
The robotic wrist unit provides accurate movement for complex industrial tasks.
Advantages:
- Precise tool positioning
- Improved repeatability
- Smooth rotational movement
- Enhanced robot performance
Robust Mechanical Construction
With a weight of 50 kg, the wrist unit is designed for industrial robot applications requiring strong mechanical performance.
Advantages:
- High structural strength
- Stable operation under load
- Long service life
- Suitable for continuous production environments
Flexible Tool Orientation
The wrist assembly allows robots to adjust tool angles during operation.
Benefits:
- Greater working flexibility
- Improved access to complex areas
- Supports multiple production processes
- Enhanced automation capability
Reliable Industrial Performance
Designed for demanding robotic applications.
Benefits:
- Stable mechanical operation
- Reduced vibration
- Improved motion accuracy
- Lower maintenance requirements
Industrial Applications
ABB KUKA Industrial Robots
The 00-106-446 Robotic Wrist Unit is used in robotic arm motion assemblies.
Applications include:
- Robot axis control
- Tool orientation adjustment
- End-effector positioning
- Precision movement applications
Automotive Manufacturing
Robotic wrist units are widely used in automotive production.
Applications include:
- Spot welding
- Painting operations
- Component assembly
- Body handling
Industrial Assembly Automation
The wrist unit supports complex automated production processes.
Applications include:
- Precision assembly
- Component installation
- Machine tending
- Inspection operations
Heavy-Duty Material Handling
The robotic wrist provides flexible movement for handling applications.
Applications include:
- Part transfer
- Palletizing
- Loading and unloading
- Industrial logistics automation
Installation Guide
Step 1: Confirm Compatibility
Before installation, verify:
- ABB KUKA robot model compatibility
- Correct wrist unit specification
- Mechanical mounting requirements
- Servo and encoder connections
Ensure the replacement unit matches the original robot configuration.
Step 2: Shut Down Robot System
Before replacement:
- Stop robot operation
- Disconnect electrical power
- Secure robot arm position
- Follow mechanical safety procedures
The wrist unit is a heavy mechanical component and requires proper handling.
Step 3: Remove Existing Wrist Assembly
Carefully:
- Disconnect servo cables
- Remove mechanical fasteners
- Support the wrist unit weight
- Remove the existing assembly
Use suitable lifting equipment when required.
Step 4: Install 00-106-446 Robotic Wrist Unit
Installation steps:
- Position the wrist unit correctly
- Secure mechanical connections
- Connect servo and feedback cables
- Verify alignment
Proper installation is essential for accurate robot movement.
Step 5: Perform Calibration and Testing
After installation:
- Restore system power
- Check axis movement
- Perform robot calibration
- Verify positioning accuracy
- Test production movements
Common Failure Symptoms
| Fault Symptom |
Possible Cause |
| Abnormal wrist movement |
Mechanical wear |
| Excessive vibration |
Bearing or transmission issue |
| Positioning error |
Calibration problem |
| Unusual noise |
Internal component damage |
| Reduced movement accuracy |
Gear wear or backlash |
Troubleshooting Guide
Check Mechanical Condition
Inspect:
- Gear mechanisms
- Bearings
- Housing condition
- Mechanical connections
Wear or damage may affect motion accuracy.
Check Servo and Feedback Connections
Inspect:
- Motor cables
- Encoder connections
- Communication signals
Connection problems may cause axis errors.
Verify Robot Calibration
Check:
- Axis calibration data
- Position accuracy
- Motion parameters
Incorrect calibration can result in positioning deviations.
Replace Damaged Wrist Unit
If the unit is confirmed defective:
- Replace the ABB (KUKA) 00-106-446 Robotic Wrist Unit
- Reconnect mechanical and electrical interfaces
- Perform complete robot calibration
Maintenance Recommendations
To maintain reliable operation of the ABB (KUKA) 00-106-446 Robotic Wrist Unit:
- Perform regular mechanical inspections
- Monitor vibration and noise levels
- Check lubrication conditions
- Inspect servo connections
- Maintain proper robot calibration
Preventive maintenance helps extend service life and maintain robot accuracy.
Compatible Automation Components
| Component |
Function |
| Robotic Wrist Unit |
End-axis motion control |
| Transmission Assembly |
Torque transfer |
| Servo Motor |
Provides rotational power |
| Servo Drive |
Controls motor operation |
| Encoder System |
Position feedback |
| Robot Controller |
Motion command execution |
Key Advantages
- Designed for ABB KUKA robotic systems
- Provides accurate wrist-axis movement
- Supports flexible tool positioning
- Robust industrial mechanical structure
- Suitable for heavy-duty automation
- Improves robot motion performance
Technical FAQs
What is ABB (KUKA) 00-106-446 used for?
The ABB (KUKA) 00-106-446 Robotic Wrist Unit is used to provide rotational movement and tool positioning functions in industrial robot arms.
What is the main function of this wrist unit?
Its main function is to control the orientation and movement of robot end-effectors through precise mechanical motion.
Where is it commonly installed?
It is installed at the wrist section of ABB KUKA industrial robot arms.
What are the dimensions?
The dimensions are 410 × 260 × 60 mm.
What is the weight?
The weight is 50 kg.
Why is the robotic wrist important?
The robotic wrist provides flexibility and precision, allowing industrial robots to perform complex manufacturing operations accurately.
Conclusion
The ABB (KUKA) 00-106-446 Robotic Wrist Unit is a high-performance mechanical component designed for industrial robotic motion systems.
With strong mechanical construction, precise movement capability, and reliable operation, it supports ABB KUKA robots in demanding automation applications requiring accuracy, flexibility, and continuous performance.
For robotics engineers, maintenance professionals, and industrial automation integrators, the 00-106-446 Robotic Wrist Unit provides a dependable solution for maintaining efficient and precise robotic operations.