

ProductPRODUCT
Featured products
Contact Us
- ABB
- 3HAC033411-001
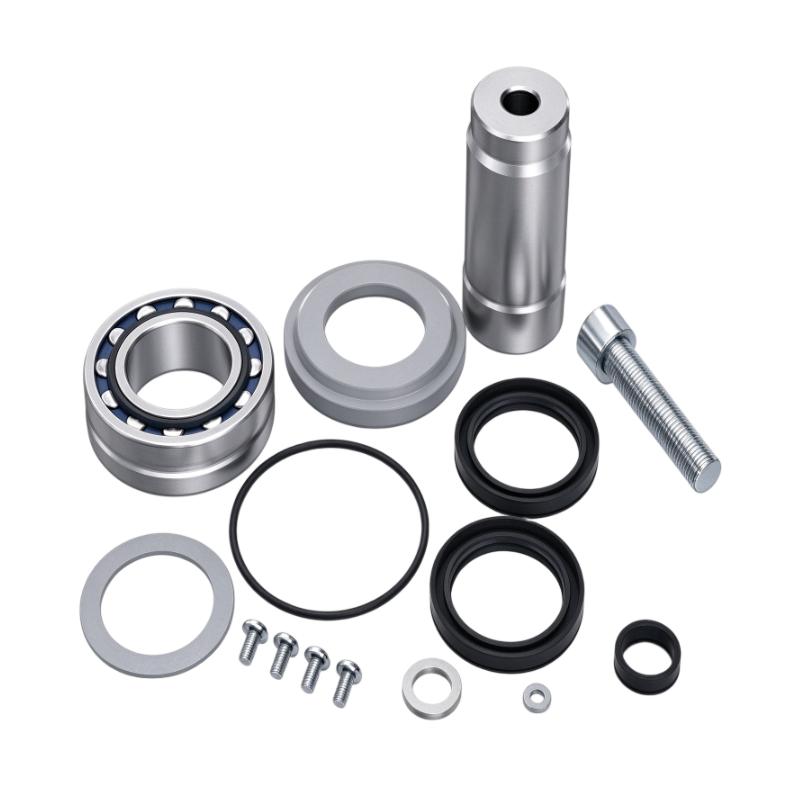
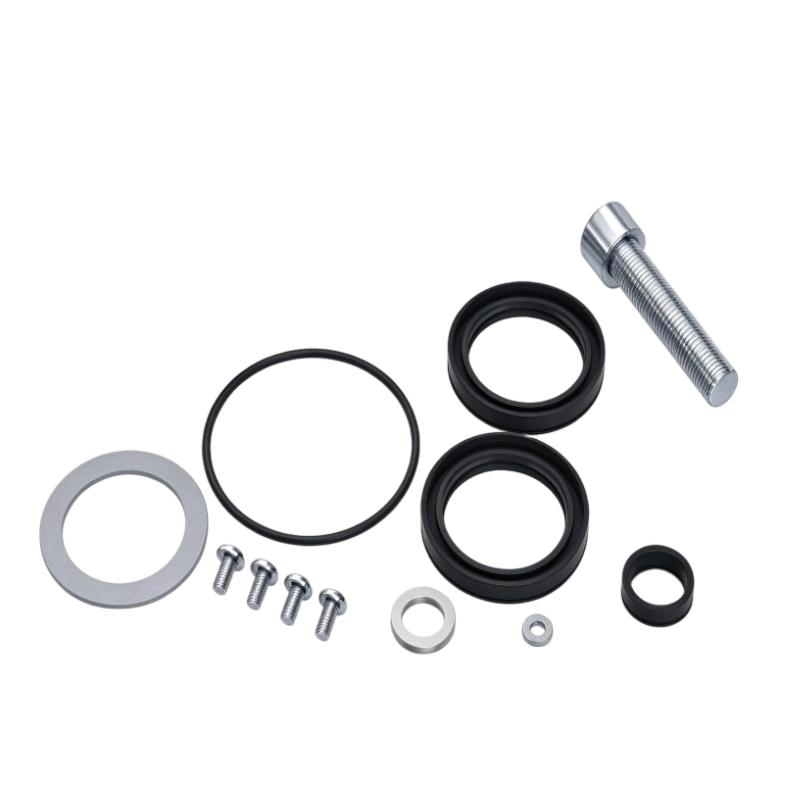
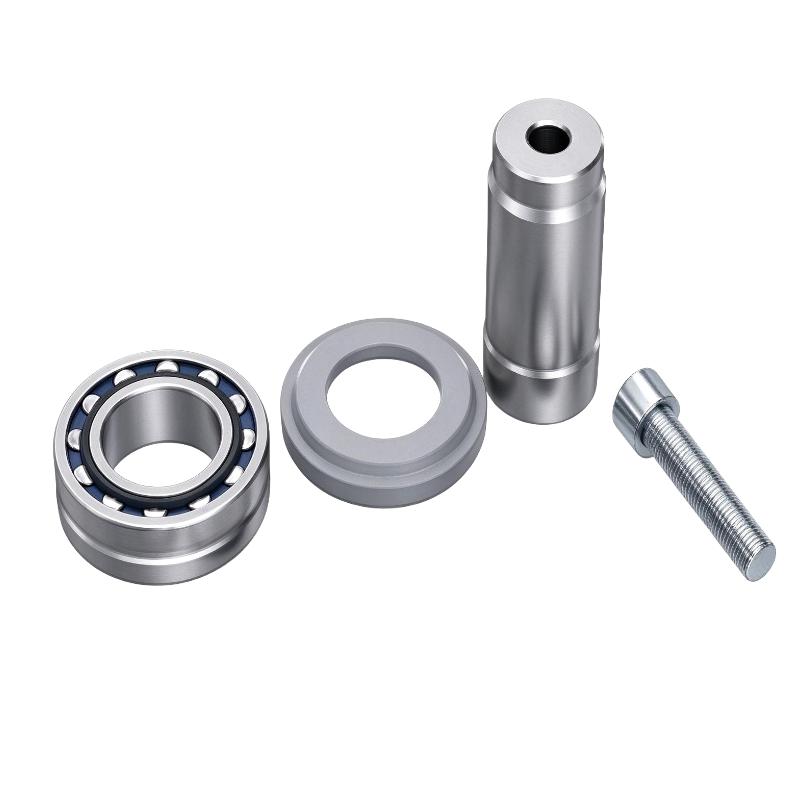
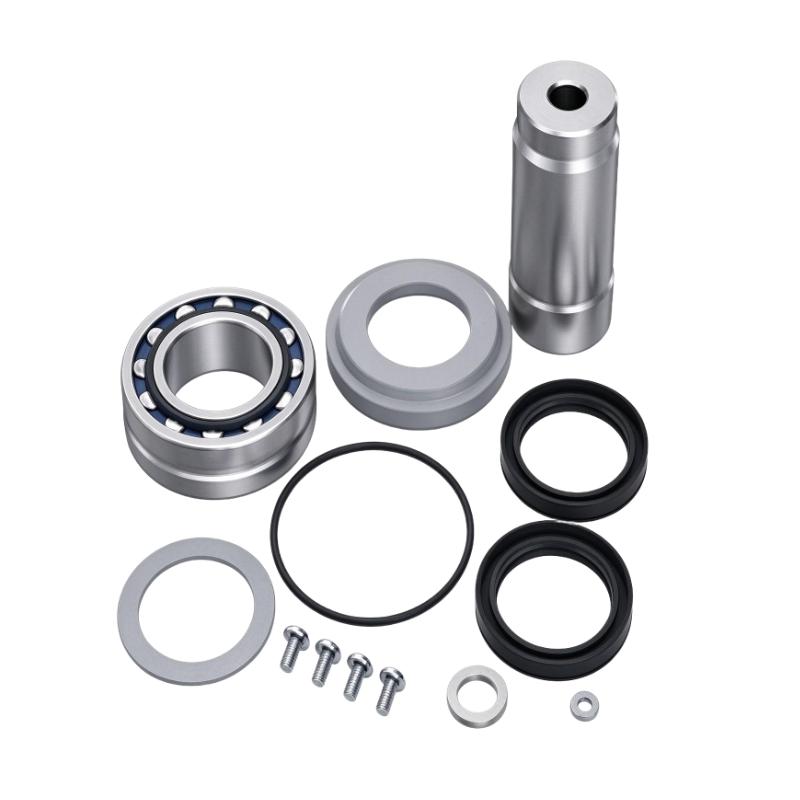
- Industrial Robot Shaft Maintenance Kit
- Sweden (SE)
- 82 × 26 × 55 mm
- 0.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
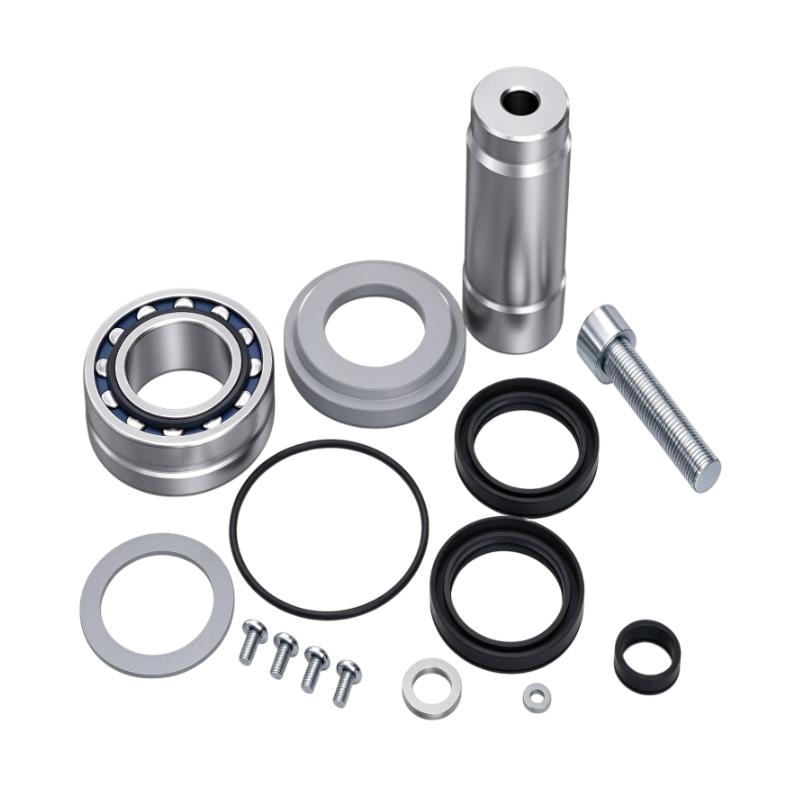
The ABB 3HAC033411-001 Industrial Robot Shaft Maintenance Kit is a mechanical maintenance kit for ABB industrial robot manipulators. It is identified as a Shaft Maintenance Kit for six-axis robots, covering axes J1, J2, J3, J4, J5, and J6, with an associated robot reach of 2550 mm.
The kit is intended for maintenance work involving shaft-related mechanical assemblies in compatible ABB robot systems. These assemblies are part of the mechanical structure responsible for transmitting movement and supporting the positioning of the robot manipulator. Their condition directly affects the mechanical performance of the robot during repeated industrial operations.
Unlike an individual shaft, bearing, or balancing device, a maintenance kit groups the parts required for a specific servicing task. This makes it relevant to planned maintenance activities where technicians need to inspect and service mechanical assemblies according to the robot’s maintenance requirements.
The six-axis configuration is particularly relevant because industrial robots use multiple interconnected mechanical axes to achieve coordinated movement. J1 and J2 contribute to the positioning of the main robot arm, while the remaining axes provide additional articulation and tool orientation. Maintenance requirements can therefore involve different shaft-related assemblies throughout the manipulator.
In automotive manufacturing, for example, ABB six-axis robots may perform spot welding, material handling, machine tending, and assembly operations. These applications involve repeated acceleration, deceleration, and changes in movement direction. Regular mechanical inspection and servicing help identify wear in critical assemblies before it develops into more serious equipment problems.
The 3HAC033411-001 is associated with ABB’s robot maintenance parts catalog under the designation Maintenance Kit, Shaft, 6 Axes (J1, J2, J3, J4, J5, J6), Reach 2550 mm. This identification is important when selecting a replacement kit because the maintenance configuration must correspond to the robot’s axis arrangement and reach.
The kit should not be confused with the ABB 3HAC033413-001 Maintenance Kit, Cradle. Although both belong to the mechanical maintenance category, they address different robot assemblies and should be selected according to the actual servicing requirement.
For maintenance departments operating ABB industrial robots, the 3HAC033411-001 provides a dedicated parts kit for shaft-related servicing across the specified six-axis robot configuration.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | 3HAC033411-001 |
| Product Type | Industrial Robot Shaft Maintenance Kit |
| Official Component Description | Maintenance Kit, Shaft |
| Product Family | ABB Industrial Robotics |
| Component Category | Mechanical Maintenance Kit |
| Robot Configuration | 6 Axes |
| Supported Axes | J1, J2, J3, J4, J5, J6 |
| Associated Robot Reach | 2550 mm |
| Primary Function | Shaft Assembly Maintenance |
| Application | Industrial Robot Mechanical Servicing |
| Dimensions | 82 × 26 × 55 mm |
| Weight | 0.2 kg |
Product Features
- Six-Axis Maintenance Configuration: Identified for shaft maintenance across J1 through J6 in the specified ABB robot configuration.
- Dedicated Shaft Maintenance: Intended for servicing shaft-related mechanical assemblies rather than general electrical or controller maintenance.
- Robot Manipulator Application: Used in maintenance operations involving the mechanical structure of industrial robot arms.
- 2550 mm Reach Configuration: Associated with the ABB six-axis robot configuration specified in the parts catalog.
- Maintenance Kit Format: Provides a dedicated maintenance parts package for the corresponding servicing requirement.
- Mechanical Component Servicing: Supports maintenance activities involving shaft assemblies and their associated mechanical interfaces.
- Industrial Robot Compatibility: Intended for the applicable ABB robot configuration rather than universal use across all ABB robot models.
- Preventive Maintenance Support: Can be incorporated into scheduled robot servicing to help address mechanical wear and maintain equipment condition.
Working Principle
The ABB 3HAC033411-001 is a passive mechanical maintenance kit. It does not generate movement, process signals, or control robot axes. Its function is associated with the servicing of shaft-related mechanical assemblies within the robot manipulator.
Understanding its application requires looking at how the mechanical axes of an industrial robot work together.
Robot Axis Movement and Shaft Assemblies
An ABB six-axis robot uses interconnected mechanical assemblies to position the manipulator and orient the tool mounted at its end.
Each axis operates through a mechanical drive arrangement involving components such as motors, gearboxes, shafts, and supporting mechanical interfaces.
The shaft-related components transfer mechanical movement through the robot structure. Their condition affects the transmission of movement and the mechanical relationship between connected assemblies.
Mechanical Wear and Maintenance Requirements
During repeated robot operation, mechanical components are exposed to cyclic loads, acceleration forces, vibration, and changes in movement direction.
Over time, these operating conditions can contribute to wear in shaft-related interfaces and other mechanical components.
Maintenance personnel therefore inspect relevant assemblies for abnormal movement, mechanical play, noise, lubrication issues, and visible damage according to the applicable ABB service procedure.
The 3HAC033411-001 is intended for the corresponding shaft maintenance work.
Six-Axis Maintenance Scope
The kit designation identifies the J1 through J6 axis configuration. This is important because maintenance requirements differ between robot models and mechanical assemblies.
The six-axis designation provides a clear reference when identifying the intended maintenance package. Technicians must still confirm the exact robot type and reach before ordering or installing the kit.
Maintenance and Component Replacement
During a scheduled service operation, the robot is placed in the required maintenance condition and the relevant mechanical assembly is inspected.
If shaft-related components require servicing, the maintenance procedure determines which parts must be removed, inspected, or replaced.
The 3HAC033411-001 is selected for the corresponding shaft maintenance application. Installation and replacement must follow the applicable ABB mechanical service instructions, including specified fastening, lubrication, and alignment requirements where relevant.
Restoring Mechanical Operation
After maintenance, the serviced assembly is checked for correct positioning and mechanical movement.
The robot can then undergo the required mechanical inspection and operational testing before returning to production.
Proper servicing helps maintain the mechanical condition of the manipulator and reduces the likelihood of unexpected interruptions caused by worn or damaged components.
Role in ABB Industrial Robot Mechanical Architecture
The 3HAC033411-001 belongs to the mechanical maintenance category of ABB industrial robotics. Its application is associated with shaft-related assemblies within the robot manipulator rather than the electrical control or drive electronics.
A simplified robot mechanical arrangement follows this structure:
Robot Controller → Servo Drive System → Axis Motors → Gearboxes and Mechanical Transmission → Robot Manipulator → End-of-Arm Tooling
The maintenance kit is associated with the mechanical servicing of the shaft-related assemblies within this arrangement.
| System Component | Function |
|---|---|
| ABB 3HAC033411-001 | Shaft maintenance kit for the specified six-axis robot configuration |
| Robot Manipulator | Provides the mechanical structure for coordinated robot movement |
| J1 Axis Assembly | Supports the primary robot positioning movement |
| J2 Axis Assembly | Controls movement of the main arm section |
| J3 Axis Assembly | Contributes to arm extension and positioning |
| J4 Axis Assembly | Provides wrist rotation |
| J5 Axis Assembly | Controls additional wrist articulation |
| J6 Axis Assembly | Provides final tool orientation and rotation |
| Servo Motors | Generate the mechanical movement for individual axes |
| Gearbox Assemblies | Transmit and reduce motor speed while providing output torque |
| Shaft Assemblies | Transfer mechanical movement through the robot structure |
| Balancing Device | Supports the mechanical balancing arrangement of the robot |
| Robot Controller | Coordinates axis movement and executes programmed motion |
| Servo Drive Units | Regulate motor operation according to controller commands |
In a typical robotic production cell, the controller coordinates six servo axes to move the manipulator through programmed positions.
The shaft assemblies form part of the mechanical transmission structure. Their condition must be maintained to support the intended movement characteristics of the robot.
The 3HAC033411-001 is relevant when maintenance work involves the corresponding shaft assemblies in the specified ABB robot configuration.
Industrial Applications
| Application | Typical Use |
|---|---|
| Automotive Manufacturing | Mechanical maintenance of six-axis robots used in welding and assembly |
| Robotic Welding | Servicing shaft-related assemblies in repeatedly moving welding robots |
| Material Handling | Maintaining mechanical components in robots performing repetitive handling operations |
| Machine Tending | Supporting shaft maintenance for robots loading and unloading production machines |
| Industrial Assembly | Scheduled mechanical servicing of robots used in automated assembly |
| Metal Fabrication | Maintaining robot manipulator assemblies in cutting and handling applications |
| Packaging Automation | Supporting mechanical maintenance of robots used in production packaging |
| Palletizing Systems | Servicing shaft-related assemblies in robots handling heavy production loads |
| General Manufacturing | Planned maintenance of ABB six-axis robotic equipment |
| Automated Production Cells | Supporting mechanical servicing during scheduled equipment shutdowns |
Installation and Maintenance
- Verify the Robot Model: Confirm that the ABB robot corresponds to the six-axis configuration and 2550 mm reach associated with the 3HAC033411-001.
- Check the Maintenance Scope: Determine whether the required work involves shaft assemblies rather than cradle, gearbox, motor, or electrical components.
- Review ABB Service Documentation: Obtain the applicable robot-specific maintenance instructions before starting mechanical disassembly.
- Prepare the Robot: Place the robot in the prescribed maintenance position and follow the facility’s isolation and safety procedures.
- Inspect the Shaft Assembly: Check the relevant mechanical components for abnormal play, wear, damage, contamination, and other signs of deterioration.
- Verify Kit Identification: Check the 3HAC033411-001 part number against the maintenance documentation and required replacement parts.
- Prepare the Working Area: Organize the required tools and maintenance materials to prevent contamination or loss of small mechanical components.
- Remove Components as Specified: Follow the ABB service procedure when accessing the shaft assembly. Avoid applying force to adjacent mechanical interfaces.
- Inspect Associated Components: Examine relevant bearings, sealing interfaces, fastening points, and mating surfaces according to the maintenance procedure.
- Perform the Shaft Maintenance: Replace or service the designated components using the specified installation sequence, fastening requirements, and lubrication instructions.
- Verify Mechanical Movement: Check the serviced assembly for correct positioning and movement before returning the robot to production.
- Complete Maintenance Records: Record the kit part number, serviced robot axes, replaced components, inspection findings, and post-maintenance test results.
Compatible System Components
| Component | Function |
|---|---|
| ABB 3HAC033411-001 | Maintenance Kit, Shaft |
| ABB 3HAC033413-001 | Maintenance Kit, Cradle |
| ABB 3HAC033413-002 | Balancing Axis with Bearing |
| ABB 3HAC033363-001 | Balancing Device |
| ABB 3HAC033387-001 | Harness Axis 1–6 |
| ABB 3HAC033388-001 | Harness Axis 1–6 |
| ABB 3HAC033389-001 | Cable Harness Manipulator Axis 1–4 |
| ABB 3HAC033434-001 | Manipulator Harness IRB 6620 LX |
| ABB Industrial Robot Manipulator | Six-axis mechanical robot assembly |
| ABB Robot Controller | Coordinates programmed robot movements |
| ABB Servo Motors | Drive individual robot axes |
| ABB Gearbox Assemblies | Transmit mechanical movement to the robot axes |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| ABB 3HAC033413-001 | Maintenance Kit, Cradle | Cradle assembly maintenance |
| ABB 3HAC033413-002 | Balancing Axis with Bearing | Balancing mechanism replacement |
| ABB 3HAC033363-001 | Balancing Device | Robot mechanical balancing |
| ABB 3HAC033387-001 | Harness Axis 1–6 | Robot axis electrical connections |
| ABB 3HAC033389-001 | Cable Harness Manipulator Axis 1–4 | Manipulator cable harness replacement |
Key Advantages
- Dedicated shaft maintenance application for ABB industrial robots.
- Identified for six-axis configurations covering J1 through J6.
- Associated with the 2550 mm robot reach configuration.
- Supports planned mechanical servicing of robot manipulator assemblies.
- Provides a specific maintenance kit reference for spare-parts identification.
- Helps maintenance teams organize shaft-related servicing work.
- Supports mechanical maintenance programs intended to reduce unexpected production interruptions.
Technical FAQs
Which ABB robot configuration is associated with the 3HAC033411-001?
The ABB parts catalog identifies this kit as a Maintenance Kit, Shaft for six axes (J1, J2, J3, J4, J5, and J6), with a corresponding robot reach of 2550 mm. The exact robot model should be checked before ordering.
Is the 3HAC033411-001 the same as the 3HAC033413-001?
No. The 3HAC033411-001 is a Shaft Maintenance Kit, whereas the 3HAC033413-001 is a Cradle Maintenance Kit. They are intended for different mechanical maintenance requirements and should not be substituted for one another without checking the robot service documentation.
Does the 3HAC033411-001 include a complete robot shaft assembly?
The product is identified as a maintenance kit rather than a complete shaft assembly. The exact kit contents should be confirmed against the applicable ABB spare-parts documentation for the robot model and maintenance procedure.
When should the shaft maintenance kit be used?
It should be selected when scheduled or corrective maintenance requires servicing of the corresponding shaft-related mechanical assemblies. Inspection intervals and replacement decisions should follow ABB’s recommendations for the specific robot model, operating hours, and working conditions.