ProductPRODUCT
Featured products
Contact Us
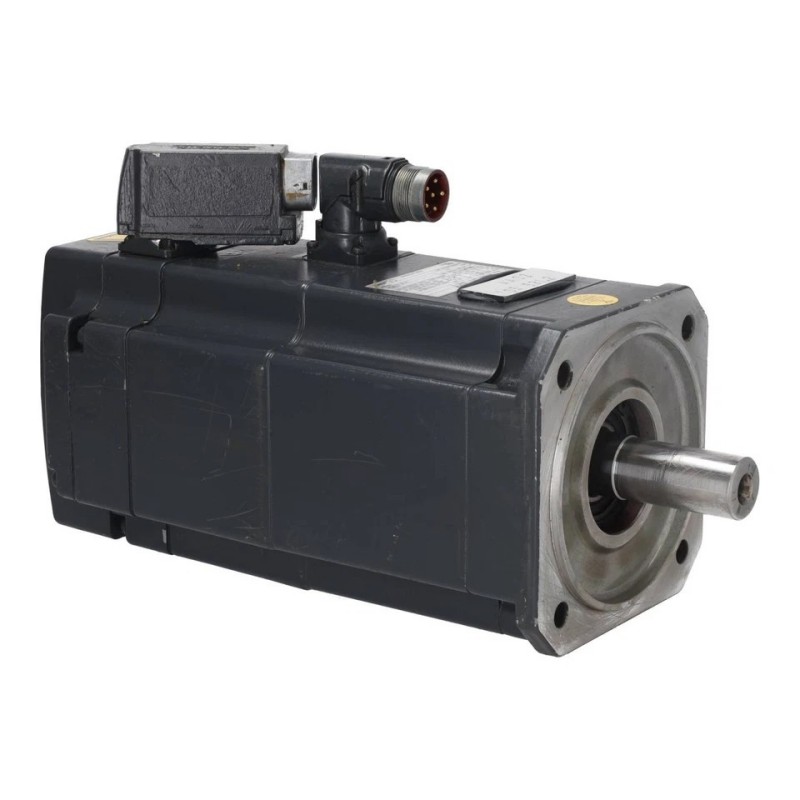
- Siemens
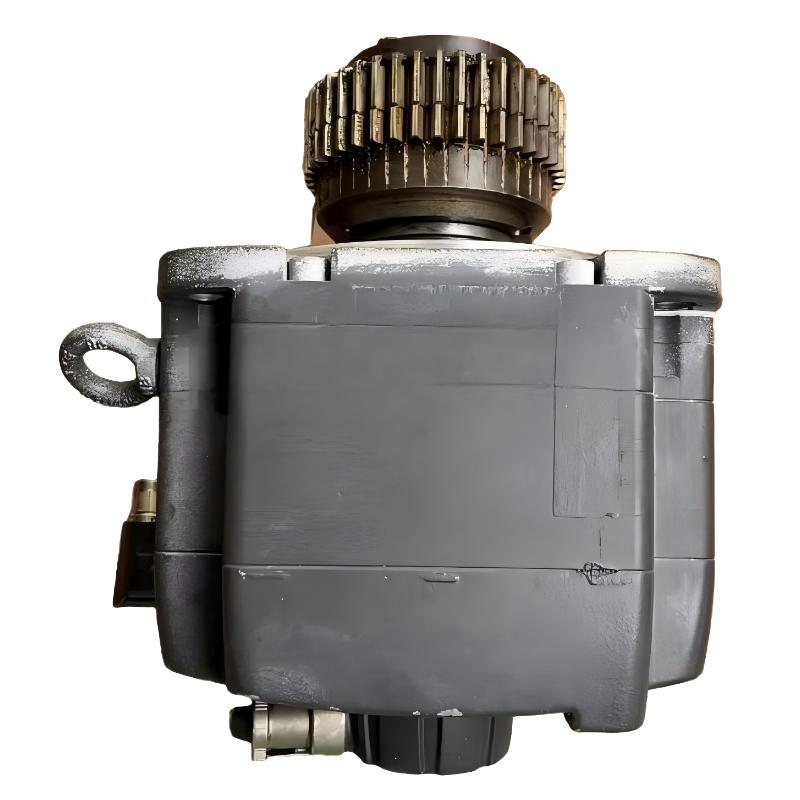
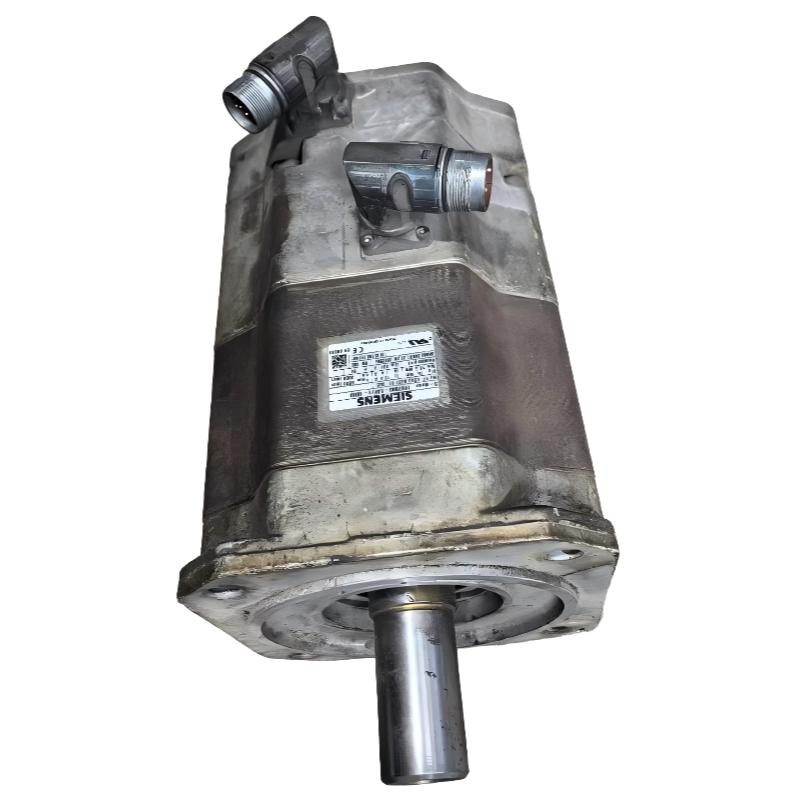
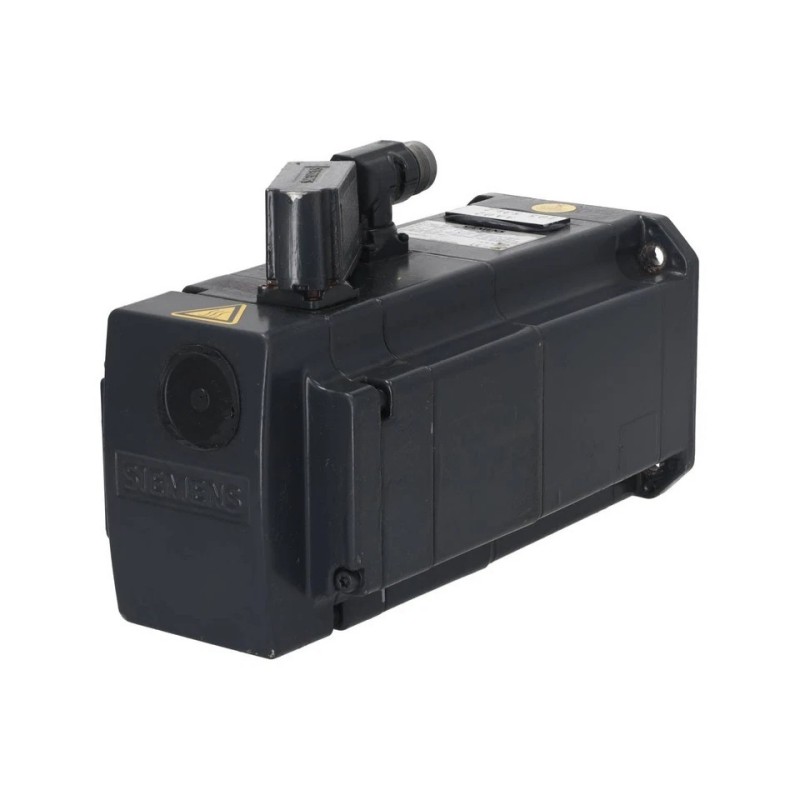
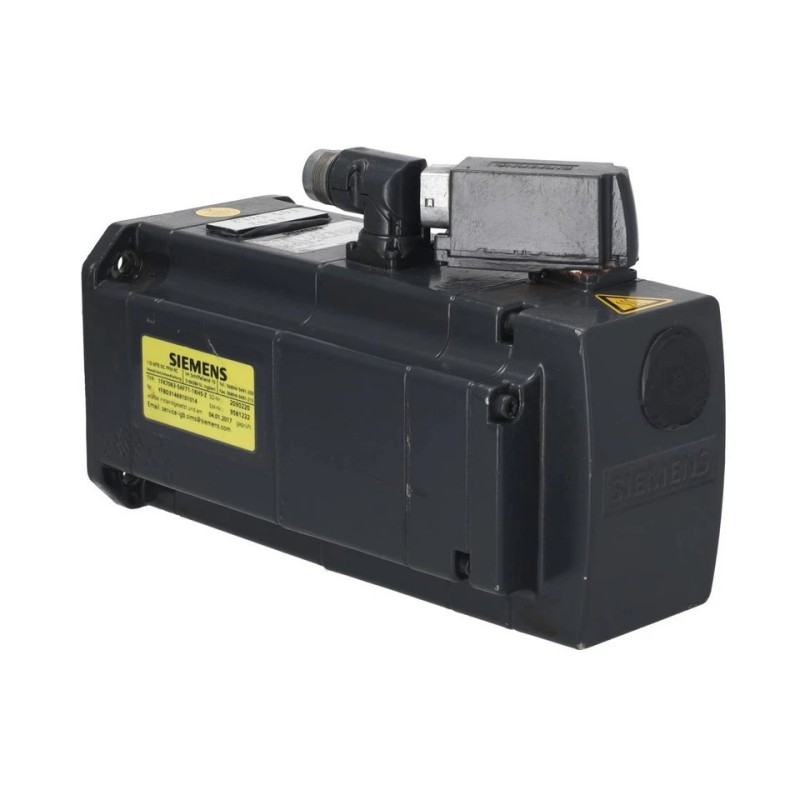
- 1FK7063-5AF71-1KH5
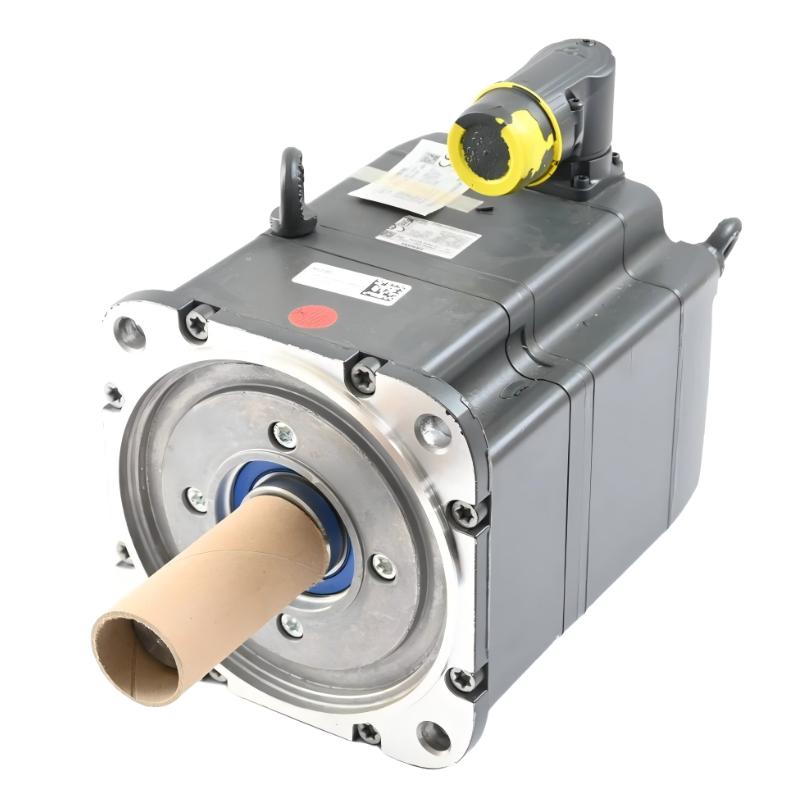
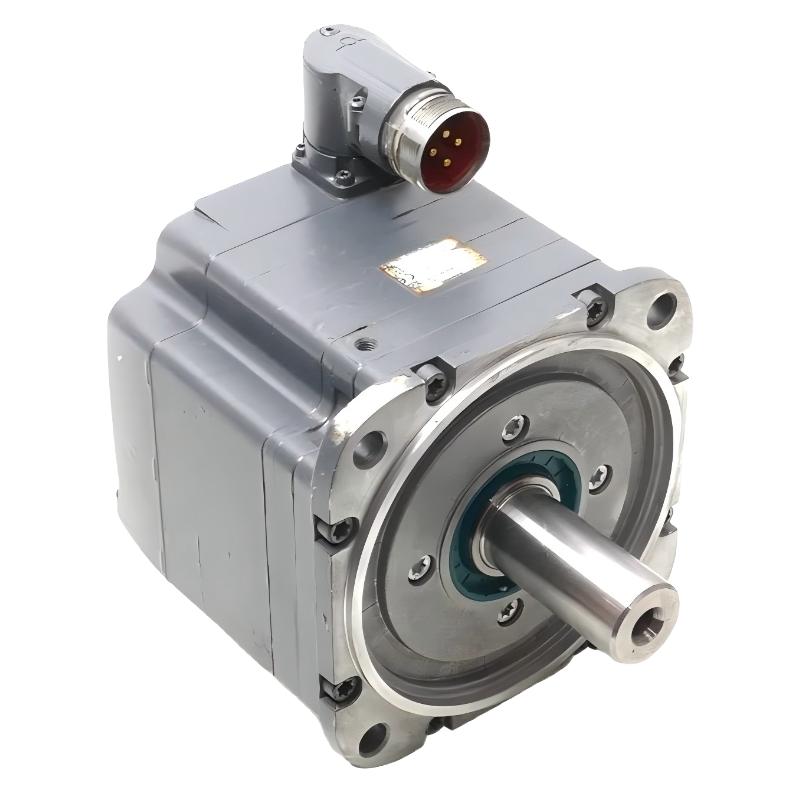
- Permanent-magnet Synchronous Compact Servo Motor
- Germany
- 7.3 Nm
- 12.7kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 6
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
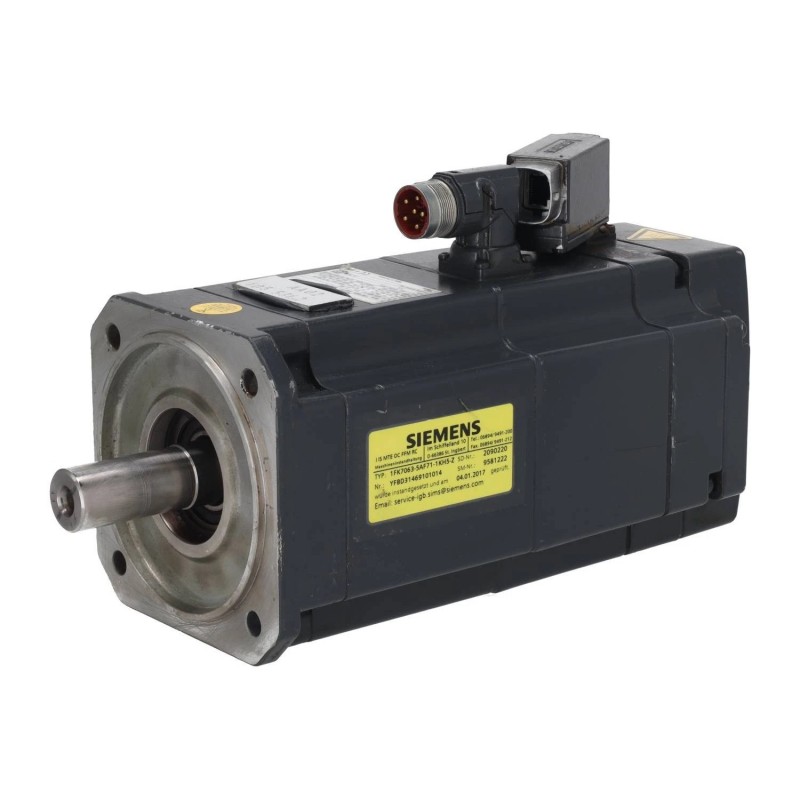
Siemens 1FK7063-5AF71-1KH5 Servo Motor: Technical Specifications, Product Introduction, Applications, Advantages, and Recommended Models
1. Product Overview
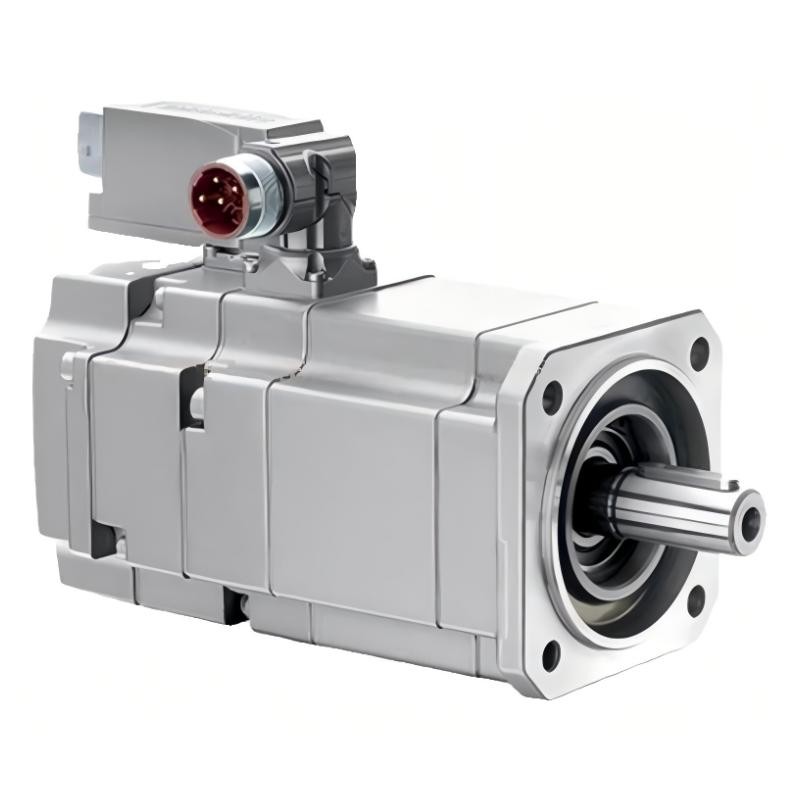
The 1FK7063-5AF71-1KH5 is a model designation associated with the SIMOTICS S-1FK7 family of industrial servo motors. This family is designed for industrial motion control applications that require controlled rotational movement, precise positioning, repeatable motion sequences, and reliable integration with automated machinery.
Servo motors are commonly used in systems where a machine must move to a defined position, maintain a controlled speed, accelerate quickly, or synchronize with other mechanical axes. Unlike a basic fixed-speed motor arrangement, a servo system can regulate movement through a compatible drive and, where applicable, encoder feedback.
The 1FK7 family is suitable for consideration in automated production equipment, packaging machinery, positioning systems, machine tools, and other industrial applications that depend on controlled movement.
The complete ordering code is important because motors within the same family can differ in their encoder interfaces, brake arrangements, shaft configurations, electrical ratings, and mechanical dimensions.
Technical identification note: The exact suffix-specific technical record for the 1FK7063-5AF71-1KH5 is not established in the information available here. The following description therefore distinguishes general 1FK7 family characteristics from specifications that must be confirmed for the exact variant. Unverified numerical values are not presented as guaranteed ratings.
3. Confirmed Product Parameters and Configuration
The following specifications identify the principal characteristics of the 1FK7063-5AF71-1KH5 configuration.
| Parameter | Specification |
|---|---|
| Model | 1FK7063-5AF71-1KH5 |
| Brand | Siemens |
| Product family | SIMOTICS |
| Product series | SIMOTICS S-1FK7 Compact |
| Motor type | Three-phase synchronous servo motor |
| Rated speed | 3,000 rpm |
| Rated torque | 7.3 Nm at the specified 100 K temperature rise |
| Static torque | 11.0 Nm at the specified 100 K temperature rise |
| Rated current | 5.6 A |
| Optimum operating power | 2.29 kW |
| Maximum permissible mechanical speed | 7,200 rpm |
| Maximum inverter-related speed | 6,600 rpm |
| Maximum torque | 35.0 Nm |
| Maximum current | 28.0 A |
| Number of poles | 8 |
| Cooling method | Natural cooling |
| Mounting arrangement | IM B5; also suitable for the specified IM V1 and IM V3 arrangements |
| Encoder | Basic absolute encoder, A-32 |
| Encoder resolution | 32 increments per revolution |
| Feedback interface | DRIVE-CLiQ |
| Shaft design | Plain shaft, tolerance class N |
| Holding brake | Integrated permanent-magnet holding brake |
| Holding brake torque | 13.0 Nm |
| Brake supply voltage | 24 V DC ±10% |
| Brake coil current | 0.8 A |
| Brake opening time | Approximately 100 ms |
| Brake closing time | Approximately 50 ms |
| Maximum braking work | 380 J |
| Protection rating | IP65 for the motor; IP67 at the drive-end flange |
| Connector orientation | Power and signal connectors rotatable through 270° |
| Shaft height | 63 mm |
| Overall dimensions (mm) | Exact length, width, and height require the dimensional drawing |
| Net weight (kg) | 12.70 kg |
| Insulation temperature-rise class | 100 K |
| Paint finish | Anthracite, RAL 7016 |
3.1 Rated Performance
The motor’s rated speed is 3,000 rpm, and its rated torque is 7.3 Nm under the specified 100 K temperature-rise conditions.
Its stated optimum operating power is 2.29 kW. These figures describe the reference motor configuration and should be used together when assessing the application’s operating point.
The 11.0 Nm static torque rating represents a different operating condition from the rated torque. It should not be interpreted as the continuous torque available at every speed.
The maximum torque of 35.0 Nm is a limiting value rather than a normal continuous operating rating. The permissible duration of high-torque operation depends on the motor’s thermal characteristics, the drive’s current limits, and the machine’s operating cycle.
3.2 Absolute Encoder and DRIVE-CLiQ Interface
The 1FK7063-5AF71-1KH5 uses a basic absolute encoder, designated A-32, with a DRIVE-CLiQ interface.
The encoder provides absolute position information within its specified operating range. This can be useful in automated systems that require controlled positioning and predictable machine initialization.
The 32-increment-per-revolution encoder specification is not equivalent to the higher-resolution 2048-increment configurations available elsewhere in the 1FK7 family.
The actual positioning performance of the complete machine also depends on the servo drive, control architecture, mechanical transmission, and feedback processing.
The encoder interface must be compatible with the selected drive. A motor with a different feedback interface should not be assumed to be a direct replacement.
3.3 Integrated Holding Brake
The integrated permanent-magnet holding brake has a stated holding torque of 13.0 Nm.
Its purpose is to hold the motor shaft when the brake is engaged. This can be particularly useful for stationary axes and selected vertical positioning applications.
The brake requires a 24 V DC supply within the specified tolerance. Its opening and closing times must be taken into account when developing the machine’s motion sequence.
A holding brake should not automatically be treated as a dynamic stopping brake. The application must be assessed for stopping energy, brake duty, and safety requirements.
3.4 Protection and Installation
The motor has an IP65 protection rating, with IP67 protection specified at the drive-end flange.
This configuration offers protection appropriate for many industrial environments, subject to the limitations of the specified rating and installation conditions.
The IP67 flange rating should not be interpreted as an IP67 rating for the complete motor assembly.
The IM B5 mounting arrangement and the specified IM V1 and IM V3 mounting alternatives provide options for different installation orientations.
The connector arrangement allows rotation through 270°, which can help with cable routing in compact machine layouts.
3.5 Dimensions and Weight
The shaft height is 63 mm, but this value alone does not establish the motor’s complete dimensions.
The overall length, flange diameter, mounting-hole arrangement, shaft extension, and connector clearance must be taken from the exact mechanical drawing.
The net motor weight is 12.70 kg. This value is useful for preliminary machine-layout and handling calculations, although the total installed assembly will be heavier once cables, couplings, mounting hardware, and any transmission components are included.
4. Product Introduction
The 1FK7063-5AF71-1KH5 is a compact industrial synchronous servo motor intended for controlled motion in automated machinery. Its combination of a 63 mm shaft height, 3,000 rpm rated speed, integrated holding brake, and absolute encoder makes it relevant to applications where controlled rotation and repeatable positioning are required.
The motor is part of the SIMOTICS S-1FK7 Compact family. Motors in this family are designed to work with compatible servo drives and industrial control systems, allowing the machine to regulate movement according to its programmed operating sequence.
Unlike a conventional motor that primarily operates at a commanded speed, a servo motor can be controlled through a motion profile that specifies position, speed, acceleration, and deceleration. This capability is useful for production machinery that repeatedly performs the same sequence or coordinates multiple moving components.
4.1 Compact Synchronous Motor Construction
The motor uses permanent-magnet synchronous technology. Its rotor contains permanent magnets, while the stator windings generate a rotating magnetic field under the control of the servo drive.
This arrangement supports controlled torque generation and responsive movement when the motor is correctly matched to its drive and load.
The compact frame can be useful in machines where space is limited or where several axes must be installed close together.
4.2 Absolute Position Feedback
The A-32 absolute encoder provides position information through a DRIVE-CLiQ interface.
Absolute feedback can simplify machine initialization and position management, depending on the control system and the encoder’s specified behavior.
The encoder’s 32-increment-per-revolution specification should be considered when assessing positioning requirements. Applications demanding particularly fine feedback resolution may require a different motor configuration or an additional assessment of the control architecture.
4.3 Integrated Brake for Holding Applications
The motor includes a permanent-magnet holding brake with a stated holding torque of 13.0 Nm.
This feature can be useful when the motor must hold a stationary position after movement has stopped.
For example, a machine axis may need to remain in place while another production operation takes place. A vertical mechanism may also require a brake to prevent unwanted movement when the drive is disabled.
The brake must be incorporated into the machine’s control sequence and safety design. Its holding torque alone does not establish that it is suitable for every suspended load or emergency stopping application.
4.4 Natural Cooling
Natural cooling eliminates the need for a separate forced-air cooling arrangement in applications where the motor can dissipate heat within its specified limits.
This can simplify installation and reduce auxiliary equipment.
However, the actual permissible load depends on ambient temperature, mounting conditions, enclosure design, and the operating duty cycle.
4.5 Industrial Mechanical Integration
The motor’s mounting arrangements and rotatable power and signal connectors provide flexibility for equipment design.
Correct mechanical integration remains essential. Shaft alignment, coupling selection, permissible radial and axial loads, and cable routing all affect operating reliability.
The exact dimensions must be checked before the motor is used as a replacement for an existing unit.
5. Main Product Advantages
5.1 Controlled and Repeatable Movement
The motor can be integrated into a servo system that regulates position, speed, and torque.
This makes it suitable for equipment that must repeatedly move components to defined positions, synchronize mechanical axes, or follow a programmed production sequence.
The achievable accuracy depends on the encoder, drive, controller, mechanical transmission, and machine structure rather than the motor alone.
5.2 Responsive Motion Control
A properly configured servo system can respond rapidly to changes in commanded movement.
This is valuable in applications that involve frequent acceleration, deceleration, or direction changes.
The actual dynamic performance depends on the motor’s inertia, load inertia, drive current capability, mechanical stiffness, and operating speed.
5.3 Integrated Holding Brake
The integrated brake provides a means of holding the shaft stationary when engaged.
It can reduce the need for a separately mounted holding mechanism in suitable applications.
The brake’s holding capacity and release timing must be included in the machine design, particularly where external forces or gravity can move the axis.
5.4 Absolute Encoder Interface
The absolute encoder provides position information through the DRIVE-CLiQ interface.
When used with a compatible drive, it can support position management and machine initialization.
The specific A-32 encoder has a different resolution from higher-resolution encoder variants, so the complete configuration should be checked against the required positioning performance.
5.5 Compact Installation
The 63 mm shaft-height format can help reduce the space required for a motor installation.
This can be useful in compact production machinery, multi-axis systems, and equipment with limited mounting space.
The overall motor length and connector clearance still need to be checked to establish whether the complete assembly fits the available space.
5.6 Industrial Protection
The IP65 motor protection rating and IP67 drive-end flange rating are relevant to many industrial environments.
These ratings help define the conditions in which the motor can be installed, but they do not make it suitable for every cleaning method, chemical exposure, or immersion condition.
The environmental requirements of the machine should be checked before installation.
5.7 Simplified Cooling Requirements
Natural cooling can reduce the need for auxiliary cooling equipment.
This may simplify wiring, installation, and maintenance.
The benefit is conditional on the motor operating within its thermal limits and having suitable heat dissipation in the installed environment.
5.8 Defined Engineering Characteristics
The motor’s rated torque, speed, current, maximum torque, and brake specifications provide a starting point for engineering calculations.
These parameters help determine whether the motor is appropriate for the intended application.
A complete selection must also consider the torque-speed curve, duty cycle, load inertia, drive compatibility, and mechanical constraints.
6. Product Applications
The following applications are representative uses for the 1FK7 family. Actual suitability of the 1FK7063-5AF71-1KH5 depends on the complete machine requirements and the encoder’s resolution.
6.1 CNC Machinery
Servo motors are used in CNC machines to control the movement of tables, tools, positioning mechanisms, and auxiliary axes.
The motor may drive a ballscrew, coupling, or other transmission that converts rotary motion into linear movement.
Typical functions include:
-
Machine-axis positioning.
-
Auxiliary rotary movement.
-
Tool positioning.
-
Automated fixture adjustment.
-
Coordinated movement between axes.
The required torque, speed, acceleration, and positioning performance must be calculated for the specific machine.
6.2 Packaging Equipment
Packaging machines often require repeated movement and synchronization between several mechanisms.
The motor may be used for indexing, feeding, positioning, or operating an auxiliary mechanism.
Potential applications include packaging-material feeding, product positioning, indexing mechanisms, and automated transfer between production stages.
The motor must be evaluated against the cycle time, load inertia, and required stopping accuracy.
6.3 Automated Assembly Machinery
Assembly equipment frequently positions components before insertion, fastening, inspection, or another production operation.
A servo motor can control the movement of a fixture, transfer mechanism, or positioning axis.
The motor’s suitability depends on the required travel, acceleration, payload, mechanical resistance, and repeatability.
For applications requiring fine positioning or force-sensitive assembly, the encoder resolution and control architecture deserve particular attention.
6.4 Pick-and-Place Systems
Pick-and-place systems transfer components between pickup and placement positions.
Servo motors can drive rotary arms, linear axes, or transfer mechanisms.
Important considerations include payload, movement time, cycle frequency, acceleration, and transmission ratio.
The motor must be sized for both the peak torque during acceleration and the continuous torque needed over the operating cycle.
6.5 Material Handling Systems
The motor may be considered for selected positioning and transfer functions in automated material handling equipment.
Examples include workpiece positioning, fixture movement, indexing systems, and automated transfer mechanisms.
For vertical axes, the holding brake, external load, mechanical transmission, and safety arrangements must be assessed together.
6.6 Printing and Converting Machinery
Printing and converting equipment often requires synchronized motion between rollers, material-feeding systems, and processing mechanisms.
A servo motor may be used for auxiliary positioning or controlled material movement.
The important factors include speed range, torque demand, synchronization, material properties, and the machine’s operating cycle.
6.7 General Industrial Automation
The motor may also be considered for positioning and auxiliary motion in general industrial machinery.
Its compact format and servo-control capabilities can be useful in equipment that needs controlled rotary movement.
The exact encoder resolution, drive interface, and brake configuration must match the application’s requirements.
7. Five Recommended Models from the Same Series or Related Configurations
The following models are useful candidates for comparison because they belong to the same general 1FK7 motor platform or offer related motor configurations.
They should not be considered interchangeable without checking the complete specifications.
7.1 Comparison Table
| No. | Model | Series | Rated speed | Rated torque | Rated power | Encoder | Brake | Dimensions (mm) | Weight (kg) |
|---|---|---|---|---|---|---|---|---|---|
| 1 | 1FK7063-5AF71-1KH5 | SIMOTICS S-1FK7 Compact | 3,000 rpm | 7.3 Nm rated; 11 Nm static | 2.29 kW | A-32 absolute, DRIVE-CLiQ | Yes | Exact drawing required | 12.70 |
| 2 | 1FK7063-5AF71-1KH0 | SIMOTICS S-1FK7 Compact | 3,000 rpm | 7.3 Nm rated; 11 Nm static | 2.29 kW | A-32 absolute, DRIVE-CLiQ | Yes | Exact drawing required | 12.802 |
| 3 | 1FK7063-5AF71-1FH0 | SIMOTICS S-1FK7 Compact | 3,000 rpm | 7.3 Nm rated; 11 Nm static | 2.29 kW | A-2048 absolute, DRIVE-CLiQ | Yes | Exact drawing required | 12.802 |
| 4 | 1FK7063-5AF71-1EB2 | SIMOTICS S-1FK7 Compact | 3,000 rpm | 7.3 Nm rated; 11 Nm static | 2.29 kW | A-2048 absolute, EnDat | Yes | Exact drawing required | Confirm exact variant |
| 5 | 1FK7063-5AF71-1AG0 | SIMOTICS S-1FK7 Compact | 3,000 rpm | 7.3 Nm rated; 11 Nm static | 2.29 kW | Incremental SIN/COS, 2048 increments/revolution | No | Exact drawing required | 11.503 |
The ratings in this table are reference values for the corresponding motor platform. Configuration-specific reductions, encoder differences, and mechanical interfaces must be checked before selecting a replacement.
7.2 Model 1: 1FK7063-5AF71-1KH5
This is the reference model for the comparison.
Its key characteristics include the A-32 absolute encoder, DRIVE-CLiQ interface, integrated holding brake, and specified IP65 motor protection.
It is worth considering when the application already uses this configuration and the intention is to maintain the existing motion-control architecture.
Before purchasing, confirm the exact mechanical drawing and the compatibility of the installed drive with the encoder interface.
7.3 Model 2: 1FK7063-5AF71-1KH0
This is a closely related configuration with an A-32 absolute encoder, DRIVE-CLiQ interface, and integrated holding brake.
Its nominal performance characteristics are similar to those of the KH5 model.
The protection configuration and any suffix-specific differences must be checked before substitution. The complete ordering code should match the original motor’s requirements.
7.4 Model 3: 1FK7063-5AF71-1FH0
This model uses an absolute encoder with a higher resolution of 2048 increments per revolution and a DRIVE-CLiQ interface.
It also includes an integrated holding brake.
It may be worth considering when the control system requires the corresponding higher-resolution feedback configuration.
However, it should not be treated as a direct replacement without checking drive compatibility, encoder settings, and the complete mechanical arrangement.
7.5 Model 4: 1FK7063-5AF71-1EB2
This configuration uses an absolute EnDat encoder and includes a holding brake.
Its shaft configuration and protection details differ from those of the KH5 model.
It is worth investigating when the machine requires the corresponding encoder and mechanical interface.
The EnDat feedback arrangement must be compatible with the installed drive.
7.6 Model 5: 1FK7063-5AF71-1AG0
This configuration uses an incremental SIN/COS encoder with 2048 increments per revolution and does not include a holding brake.
It may be suitable for equipment designed around incremental feedback.
It is not an equivalent substitute when the original application requires absolute multi-turn feedback or an integrated holding brake.
8. Five Additional Siemens Models or Product Families to Consider
These recommendations broaden the selection beyond the 1FK7063 motor platform. They are candidates for investigation rather than guaranteed direct replacements.
The exact numerical specifications of each family depend on the complete ordering code.
8.1 Comparison Table
| No. | Model or family | Product series | Motor type | Rated speed | Rated torque | Power | Dimensions (mm) | Weight (kg) |
|---|---|---|---|---|---|---|---|---|
| 1 | 1FK7063-5AF71-1KH5 | SIMOTICS S-1FK7 Compact | Synchronous servo motor | 3,000 rpm | 7.3 Nm rated | 2.29 kW | Exact drawing required | 12.70 |
| 2 | 1FK7080 series | SIMOTICS S-1FK7 | Synchronous servo motor | Configuration-dependent | Configuration-dependent | Configuration-dependent | Exact drawing required | Confirm complete model |
| 3 | 1FK7103 series | SIMOTICS S-1FK7 | Synchronous servo motor | Configuration-dependent | Configuration-dependent | Configuration-dependent | Exact drawing required | Confirm complete model |
| 4 | 1FT7 series | SIMOTICS S | Industrial synchronous servo motor | Configuration-dependent | Configuration-dependent | Configuration-dependent | Exact drawing required | Confirm complete model |
| 5 | 1FL6 series | SIMOTICS S | Industrial servo motor family | Configuration-dependent | Configuration-dependent | Configuration-dependent | Exact drawing required | Confirm complete model |
8.2 Model 1: 1FK7063-5AF71-1KH5
Recommended for: Maintaining the original motor configuration.
This is the first model to consider when replacing an existing unit, because the complete motor specification is the starting point for compatibility.
Matching the original configuration can reduce the need for mechanical changes or feedback-system modifications.
8.3 Model 2: 1FK7080 Series
Recommended for: Applications requiring a different motor size or performance range.
The 1FK7080 family is worth evaluating when the original motor’s torque or mechanical characteristics do not satisfy the application.
The selected model must be assessed for continuous torque, peak torque, rated speed, inertia, mounting dimensions, and compatible drive requirements.
8.4 Model 3: 1FK7103 Series
Recommended for: Evaluating larger-frame servo motor configurations.
This family may be worth investigating when the application requires a different torque range or mechanical format.
The correct selection depends on the motion profile, available drive capacity, and machine installation requirements.
8.5 Model 4: 1FT7 Series
Recommended for: Alternative industrial synchronous servo motor applications.
The 1FT7 family is worth considering when the application permits a different motor configuration.
The main selection factors include rated torque, speed range, cooling, encoder compatibility, mounting arrangement, and overall dimensions.
8.6 Model 5: 1FL6 Series
Recommended for: Evaluating alternative servo motor solutions for suitable automation equipment.
The 1FL6 family may be relevant when designing a new motion-control system or comparing alternative motor configurations.
Its suitability depends on the required motion performance, the available drive system, feedback requirements, and the mechanical installation.
9. Installation, Maintenance, and Selection Guidelines
9.1 Confirm Mechanical Dimensions
Before installing or replacing the motor, check the exact overall length, flange dimensions, shaft extension, mounting-hole locations, and connector clearances.
The 63 mm shaft height is only one part of the mechanical specification.
A correct dimensional drawing is necessary to avoid interference with the machine frame or connected transmission.
9.2 Confirm Drive Compatibility
The encoder uses a DRIVE-CLiQ interface.
The selected drive must support the relevant feedback configuration and the motor’s electrical characteristics.
A motor with a similar rated speed and power may still be incompatible if its feedback interface differs.
9.3 Check the Holding Brake
Confirm the required holding torque, supply voltage, release timing, and control sequence.
For vertical axes, consider the load under gravity and the consequences of losing motor torque.
The brake should be integrated into the machine’s safety design and should not be assumed to replace a complete safety system.
9.4 Monitor Thermal Performance
Natural cooling requires sufficient heat dissipation under the intended operating conditions.
Excessive heating can result from sustained overload, unsuitable duty cycles, mechanical resistance, or insufficient heat dissipation.
The motor should be selected according to the actual motion profile, not simply the peak torque requirement.
9.5 Inspect Electrical and Mechanical Connections
Power and feedback cables should be checked for damage, contamination, loose connections, and incorrect routing.
Mechanical alignment should also be verified to avoid unnecessary bearing and coupling loads.
Repeated encoder, overcurrent, or thermal faults should be investigated rather than repeatedly reset without diagnosis.
10. Final Product Summary
The 1FK7063-5AF71-1KH5 belongs to the SIMOTICS S-1FK7 Compact family of industrial synchronous servo motors.
Its principal characteristics include a 3,000 rpm rated speed, 7.3 Nm rated torque, 2.29 kW optimum operating power, a 63 mm shaft height, an A-32 absolute encoder with DRIVE-CLiQ, and an integrated permanent-magnet holding brake.
The stated net weight is 12.70 kg. The exact overall dimensions should be confirmed from the mechanical drawing for the complete model.
The motor is suitable for consideration in automated machinery, packaging equipment, positioning systems, and other applications requiring controlled motion. Actual suitability depends on the machine’s torque requirements, duty cycle, encoder resolution, drive compatibility, and mechanical arrangement.
The most relevant alternatives within the same motor platform are the 1FK7063-5AF71-1KH0, 1FK7063-5AF71-1FH0, 1FK7063-5AF71-1EB2, and 1FK7063-5AF71-1AG0. These configurations differ in encoder technology, feedback interface, brake arrangement, or mechanical characteristics.
For a replacement, prioritize matching the complete ordering code and mechanical interface. Rated power and speed alone are insufficient to establish compatibility. The encoder, holding brake, protection rating, mounting arrangement, overall dimensions, and net weight should all be checked before final selection.