ProductPRODUCT
Featured products
Contact Us
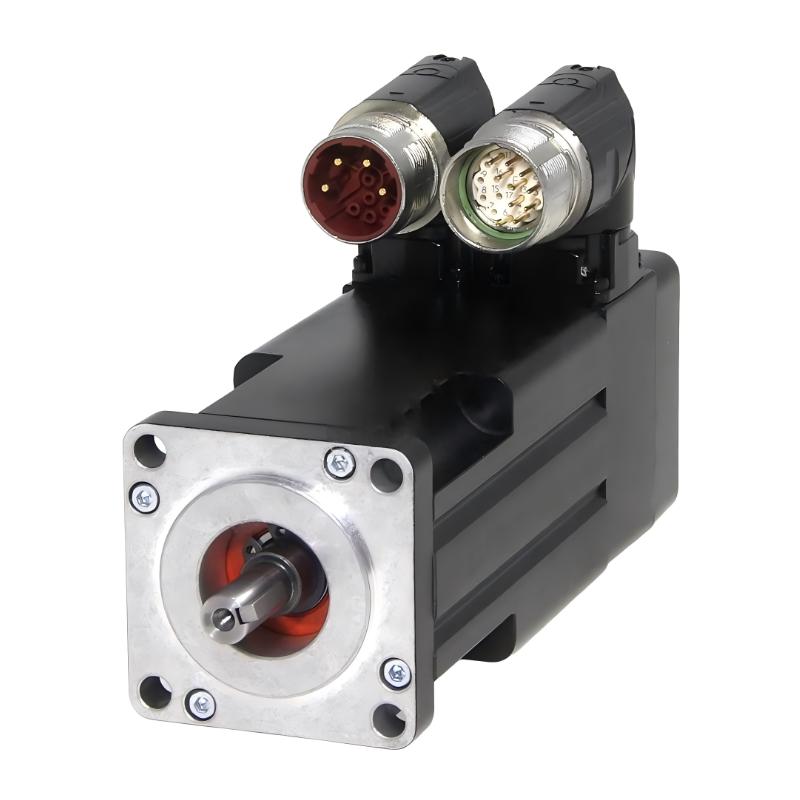
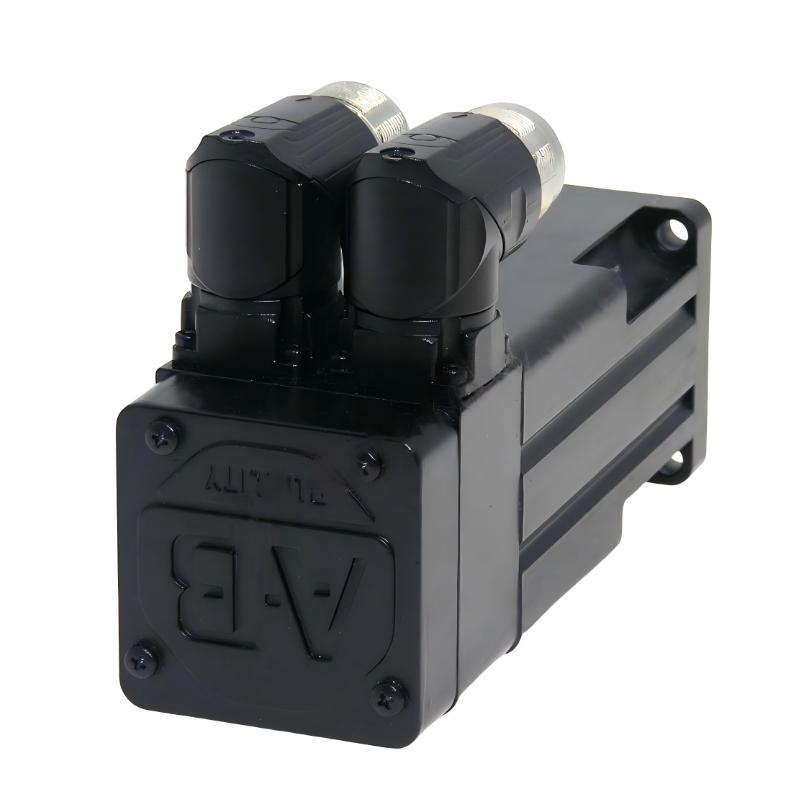
- Allen Bradley
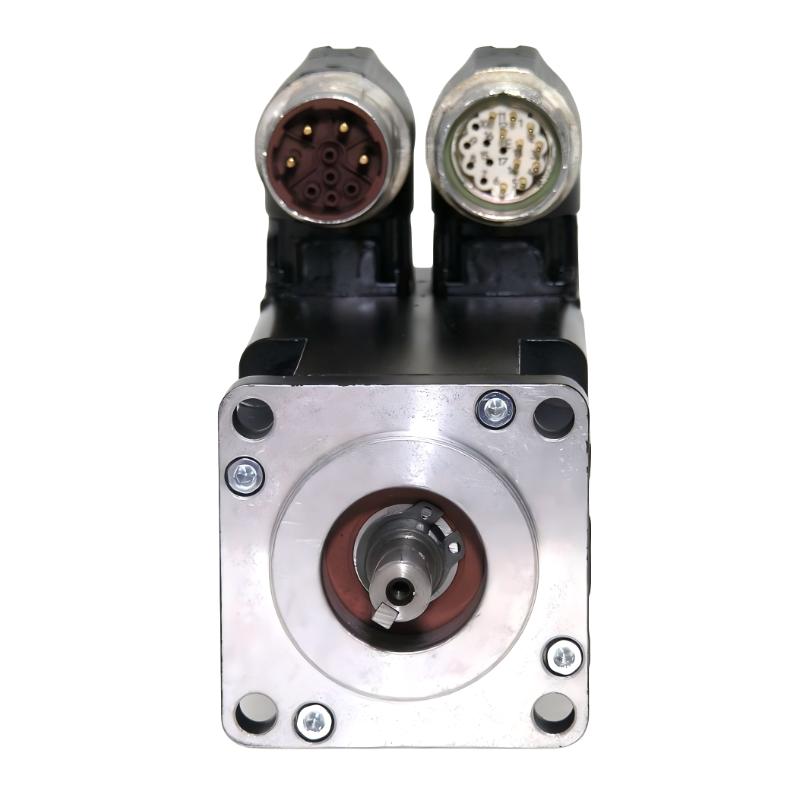
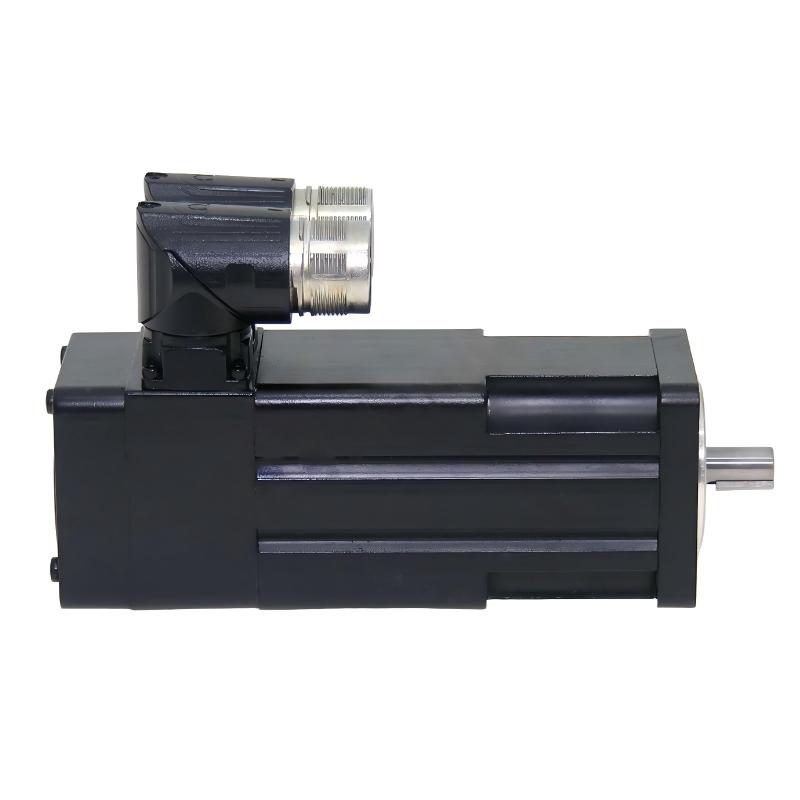
- MPL-B1530U-VJ72AA
- Rotary Servo Motor
- USA
- 63 mm
- 1.6 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 7
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
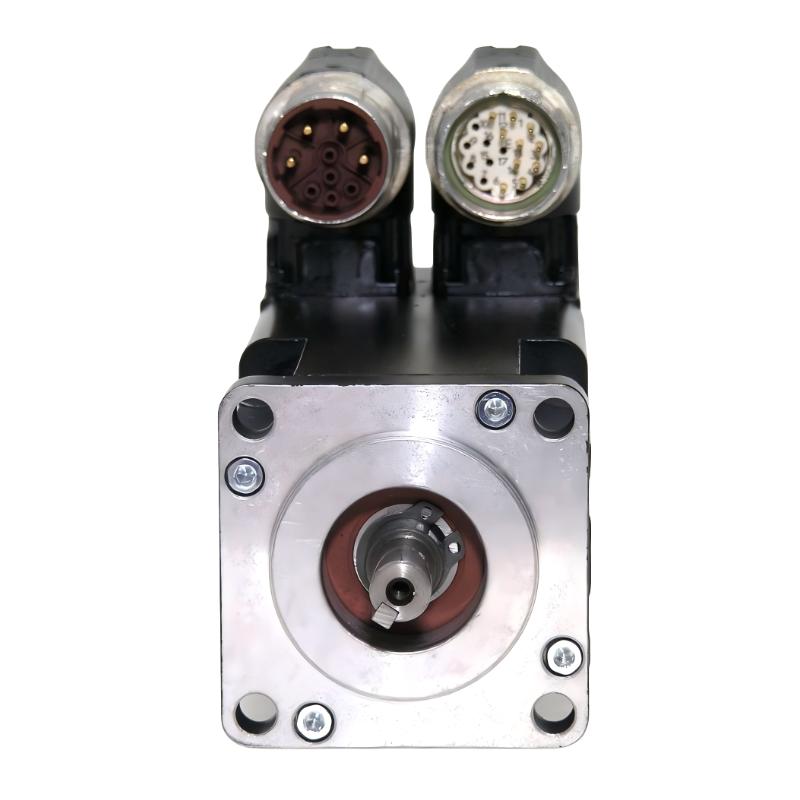
The Allen Bradley MPL-B1530U-VJ72AA is an MP-Series rotary servo motor used in closed-loop industrial motion systems. It works with a compatible Allen-Bradley servo drive and motion controller to produce controlled rotary movement for machine axes.
The motor is suited to applications where the axis must repeatedly follow programmed speed and position commands. In a typical installation, the controller determines the motion profile, the servo drive regulates motor output, and the motor converts that electrical output into mechanical rotation. Feedback from the motor is used by the control system to monitor actual movement and maintain the required response.
This type of servo motor can be used on packaging, indexing, material handling, assembly, and automated production equipment where repeatable rotary motion is required.
Technical Specifications
| Parameter | Specification |
|---|---|
| Product Model | MPL-B1530U-VJ72AA |
| Product Type | MP-Series Rotary Servo Motor |
| Product Family | MP-Series |
| Motor Series | MPL |
| Motor Type | Low-Inertia Rotary Servo Motor |
| Voltage Class | 460 V |
| Rated Speed | 7000 rpm |
| Rated Output Power | 0.39 kW |
| Continuous Stall Torque | 0.90 Nm |
| Peak Stall Torque | 2.82 Nm |
| Feedback Type | Incremental Encoder |
| Feedback Resolution | 2000 lines/revolution |
| Brake | 24 V DC Holding Brake |
| Frame Size | 63 mm |
| Magnet Stack Length | 76.2 mm |
| Weight | 1.6 kg |
Product Features
- MP-Series MPL low-inertia servo motor construction for responsive machine-axis control.
- Supports closed-loop rotary motion with encoder feedback.
- Suitable for positioning, indexing, speed control, and coordinated motion.
- High-speed operation supports repetitive machine cycles.
- Holding brake configuration supports applications requiring shaft retention.
- Keyed shaft configuration allows connection to compatible mechanical transmission components.
- Suitable for integration into Allen-Bradley servo motion architectures.
- Can be used as part of single-axis or coordinated multi-axis systems.
Working Principle
The MPL-B1530U-VJ72AA operates as the motor element of a closed-loop servo axis. The motion controller generates the required movement, while the servo drive converts the command into regulated electrical output for the motor.
1. Motion command
The controller establishes the required position, speed, acceleration, or indexing profile according to the machine sequence.
2. Drive control
The servo drive regulates the electrical current supplied to the motor according to the commanded torque and motion requirements.
3. Motor rotation
The motor converts the electrical input into electromagnetic torque, producing rotary movement at the output shaft.
4. Feedback measurement
The incremental encoder provides rotational feedback to the servo system. The control system can compare actual motor movement with the commanded position and speed.
5. Motion correction
Any difference between commanded and actual movement is processed by the servo control loop. The drive adjusts motor output to maintain the required axis response.
6. Load movement
Motor torque is transferred through the machine’s coupling or transmission to the final mechanism. Actual system performance depends on the complete servo loop, including the controller, drive, motor, feedback, and mechanical load.
Role in a Servo Motion Control Architecture
The MPL-B1530U-VJ72AA forms the motor layer of an Allen-Bradley servo control architecture. It receives controlled electrical output from the servo drive and returns feedback information through its encoder interface.
| Architecture Layer | Main Function | Relationship to Servo Motor |
|---|---|---|
| Motion Controller | Generates motion commands | Defines the required axis movement |
| Servo Drive | Controls motor current and torque | Supplies regulated output to the motor |
| Servo Motor | Converts electrical energy into rotation | Executes the commanded rotary motion |
| Encoder | Measures motor movement | Supplies position and speed feedback |
| Mechanical Transmission | Transfers motor torque | Connects the motor to the machine |
| Machine Load | Performs the production movement | Determines the mechanical demand |
Industrial Applications
| Application | Typical Use |
|---|---|
| Packaging Machinery | Product indexing, feeding, cutting, and synchronized mechanisms |
| Material Handling | Conveyor positioning and controlled transfer movement |
| Assembly Equipment | Repeatable positioning of tools and fixtures |
| Automated Production Lines | Coordinated movement between machine stations |
| Pick-and-Place Systems | Fast and repeatable rotary positioning |
| Printing Equipment | Synchronized rollers and material-handling mechanisms |
| Machine Tools | Servo-controlled positioning and auxiliary axes |
| General Factory Automation | Rotary axes requiring closed-loop motion control |
Installation and Maintenance
- Confirm motor and servo drive compatibility before connecting the motor to the motion system.
- Verify motor power and encoder feedback wiring against the applicable system wiring configuration.
- Inspect connectors for contamination, damaged contacts, loose locking hardware, or cable strain.
- Secure the motor properly to the machine mounting surface before commissioning.
- Align the motor shaft with the driven mechanism to minimize mechanical stress.
- Use an appropriate coupling or transmission component and avoid impact when installing it on the shaft.
- Check the holding-brake circuit when shaft retention is required by the application.
- Confirm the servo drive has the correct motor and feedback configuration before enabling the axis.
- During initial startup, use reduced speed and acceleration while verifying rotation direction and feedback response.
- Monitor drive alarms, following-error conditions, and abnormal motor behavior during operation.
- Inspect mechanical couplings and transmission components periodically for looseness, wear, or abnormal vibration.
- When troubleshooting or replacing the motor, inspect the complete axis, including feedback wiring, drive settings, coupling, transmission, and load.
Related Components
| Component | Function |
|---|---|
| Allen-Bradley Servo Drive | Regulates motor current, torque, and speed |
| Allen-Bradley Motion Controller | Generates and coordinates motion commands |
| Motor Power Cable | Transfers electrical power from the drive to the motor |
| Feedback Cable | Transfers encoder information to the servo system |
| Holding Brake Circuit | Controls the motor shaft holding function |
| Mechanical Coupling | Transfers motor torque to the machine |
| Gearbox or Transmission | Adapts motor rotation to the machine mechanism |
| Safety and I/O Interface | Handles enable, limit, and interlock functions |
Recommended Related Models
| Model | Product Type | Typical Relationship |
|---|---|---|
| Allen Bradley MPL-B1530U-EJ72AA | MP-Series Rotary Servo Motor | Related MPL servo motor configuration |
| Allen Bradley MPL-B1530U-HJ72AA | MP-Series Rotary Servo Motor | Related MPL motor for similar motion applications |
| Allen Bradley MPL-B1530U-HJ74AA | MP-Series Rotary Servo Motor | Related MPL motor configuration |
| Allen Bradley MPL-B230P-MJ72AA | MP-Series Rotary Servo Motor | Higher-capacity MP-Series servo motor option |
| Allen Bradley MPL-B310P-MJ72AA | MP-Series Rotary Servo Motor | Related MP-Series motor for industrial motion systems |
Key Advantages
- MP-Series MPL low-inertia servo motor architecture.
- Closed-loop operation with incremental encoder feedback.
- High-speed rotary motion capability.
- Suitable for positioning and indexing applications.
- Holding brake configuration for shaft retention requirements.
- Suitable for Allen-Bradley servo motion architectures.
- Supports repetitive and coordinated machine-axis operation.
Technical FAQs
What type of motion is the MPL-B1530U-VJ72AA intended for?
It is a rotary servo motor intended for machine axes that require controlled rotation, such as indexing, positioning, synchronized movement, and other closed-loop motion applications.
How does encoder feedback affect servo operation?
Encoder feedback gives the servo system information about actual motor movement. The drive can use this information to compare actual and commanded motion and make corrections during operation.
What can cause excessive following error on this servo axis?
Possible causes include incorrect servo tuning, excessive mechanical load, coupling problems, transmission issues, feedback faults, or incorrect drive configuration. Troubleshooting should cover both the electrical and mechanical portions of the axis.
What should be checked before commissioning a replacement motor?
Verify the motor and drive configuration, feedback wiring, power connections, mechanical mounting, shaft coupling, brake circuit, and commanded rotation direction before placing the axis into normal production operation.