ProductPRODUCT
Featured products
Contact Us
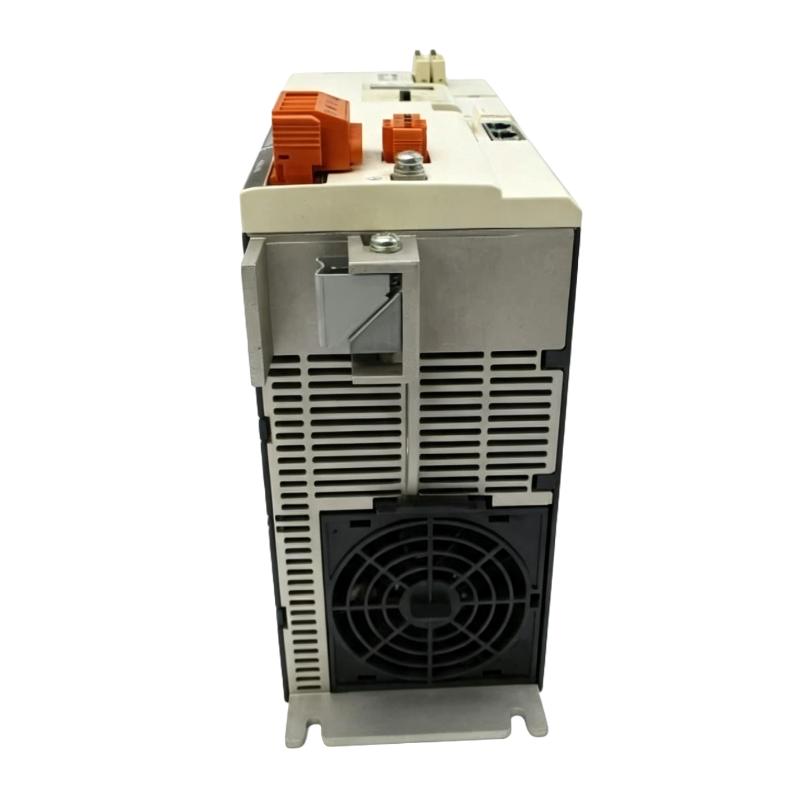
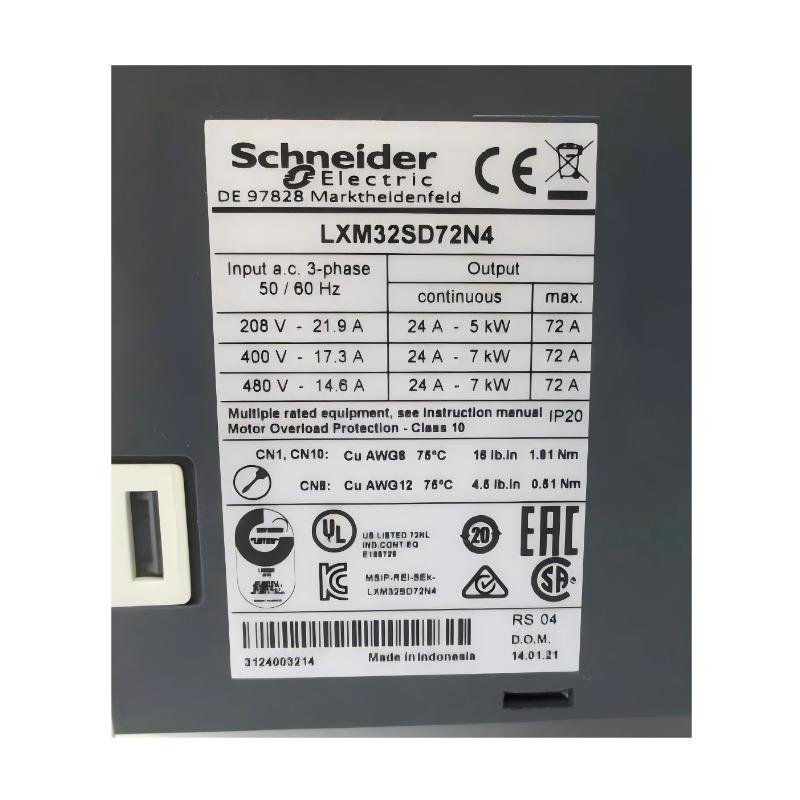
- Schneider
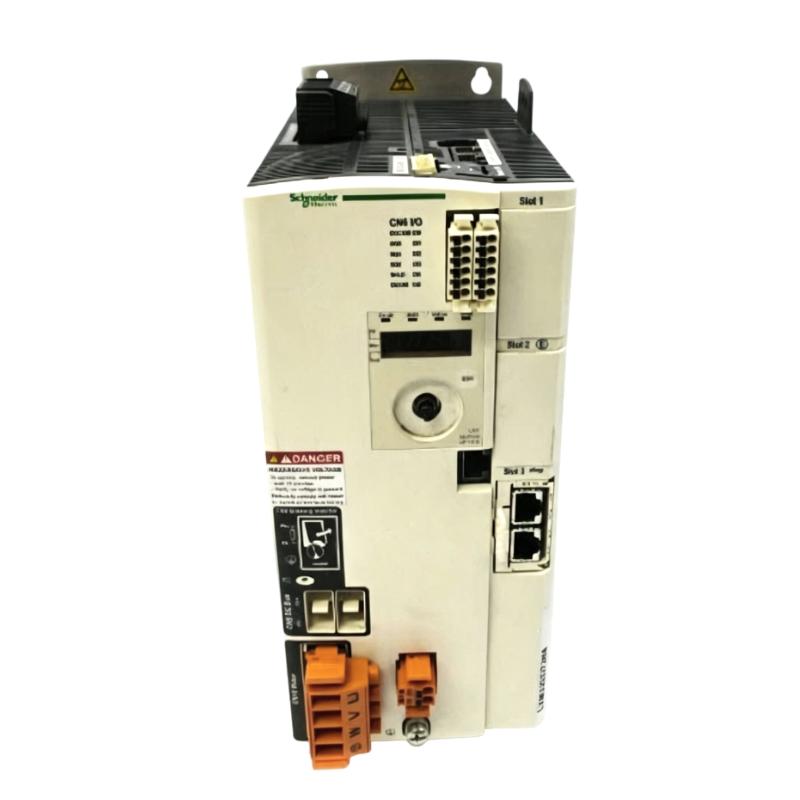
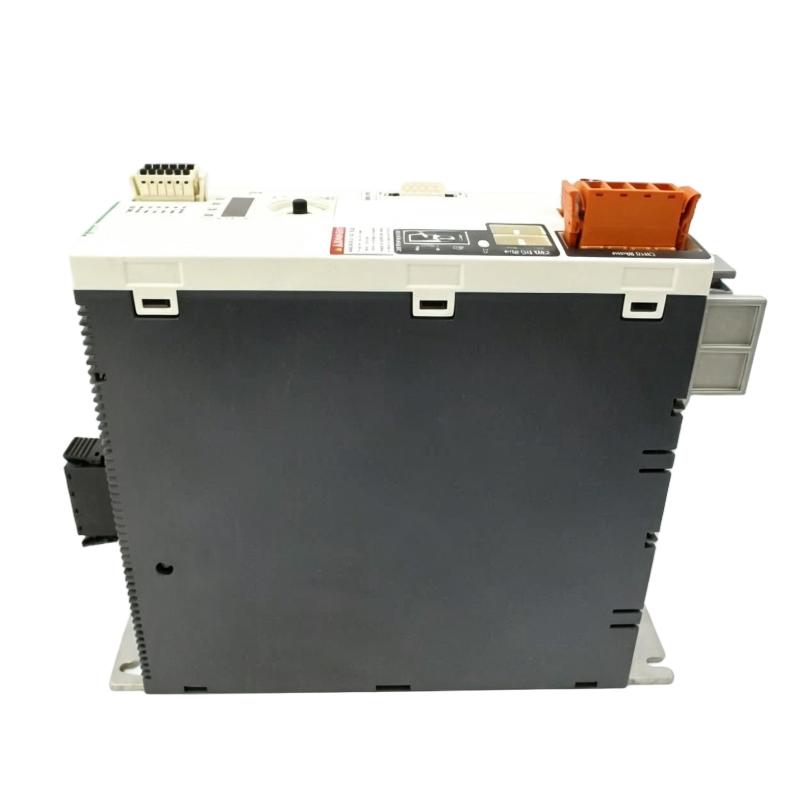
- LXM32SD72N4
- Motion Servo Drive
- France
- 270 × 108 × 237 mm
- 4.8 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 3
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
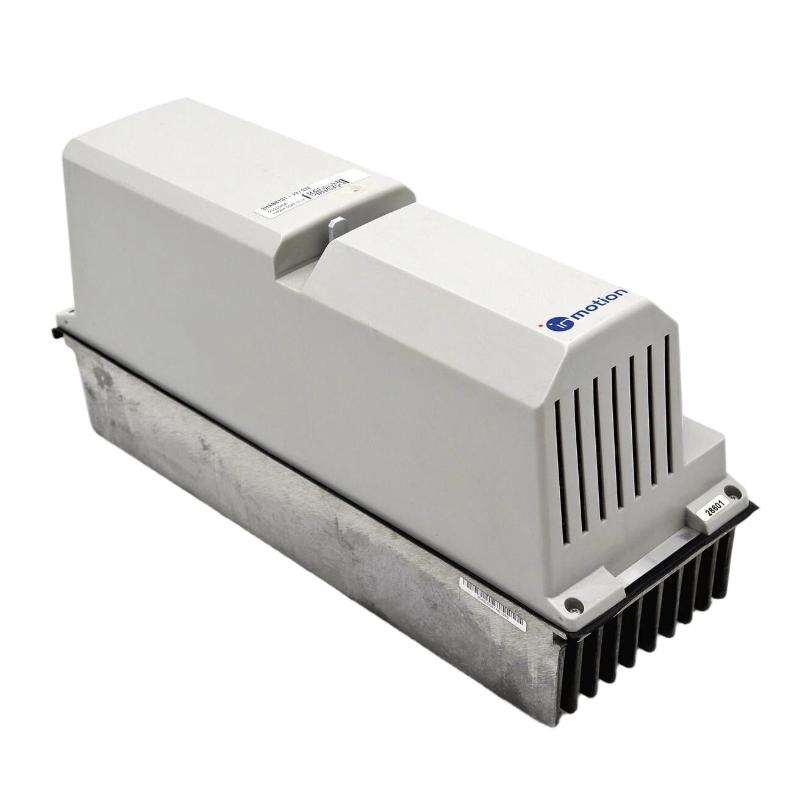
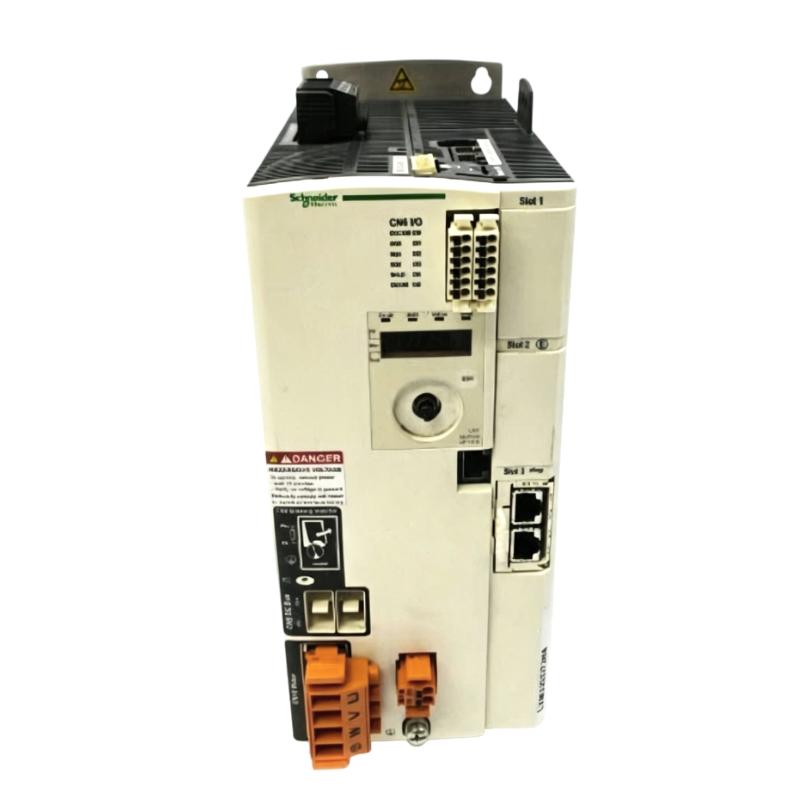
The Schneider LXM32SD72N4 Lexium 32 Motion Servo Drive is a servo drive for controlling compatible AC servo motors in machine automation and motion-control applications. It operates between the machine controller and servo motor, translating motion commands into controlled electrical output for the motor.
In applications such as packaging machinery, indexing systems, material handling equipment, and automated assembly machines, the drive manages motor speed, torque, and position according to commands received from the motion-control system. Feedback from the motor can be used to maintain the commanded operating condition during machine movement.
The Lexium 32 platform is suited to machines where repeatable positioning and coordinated axis movement are required. The servo drive can operate as one axis within a larger motion system, working alongside a controller, feedback device, motor, and other drives.
During commissioning, the drive configuration must correspond to the connected motor and machine axis. Incorrect motor parameters, feedback configuration, communication settings, or enable conditions can prevent the axis from operating correctly even when the drive itself is powered.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | LXM32SD72N4 |
| Product Family | Lexium 32 |
| Product Series | Lexium 32 Motion |
| Product Type | Servo Drive |
| Primary Function | AC servo motor control |
| System Role | Motion-control and motor-drive interface |
| Typical Application | Machine automation and multi-axis motion control |
| Dimensions | 270 × 108 × 237 mm |
| Weight | 4.8 kg |
Product Features
- Lexium 32 Motion servo drive for machine automation.
- Controls compatible AC servo motors for controlled machine-axis movement.
- Supports coordinated motion applications when integrated with a suitable motion controller.
- Provides the electrical interface between the control system and servo motor.
- Suitable for positioning, speed-control, and torque-control applications.
- Can be integrated into multi-axis machine architectures.
- Works with compatible motor feedback systems for closed-loop operation.
- Suitable for packaging, assembly, handling, and other automated machinery.
Working Principle
The LXM32SD72N4 receives motion commands from the machine controller and converts them into controlled electrical output for the connected servo motor.
Motion Controller → LXM32SD72N4 Servo Drive → Servo Motor → Machine Axis
During operation, the drive regulates the motor according to the commanded motion state. Motor feedback is returned to the drive where applicable, allowing the control loop to compare actual motor behavior with the commanded condition.
Command → Drive Control → Motor Output → Motor Movement → Feedback → Drive Regulation
This closed-loop relationship allows the servo axis to respond to changes in position, speed, and torque requirements during machine operation. The controller remains responsible for higher-level machine sequencing and coordinated motion, while the servo drive handles the motor-side control.
Role in a Lexium 32 Motion Control Architecture
The LXM32SD72N4 occupies the motor-control layer between the machine controller and the servo motor. Multiple drives can be incorporated into a machine where several axes must move according to a coordinated production sequence.
PLC / Motion Controller → Lexium 32 Servo Drive → Servo Motor → Mechanical Axis → Machine Process
| System Element | Function |
|---|---|
| PLC / Motion Controller | Generates machine sequence and motion commands |
| LXM32SD72N4 | Controls the connected servo motor |
| Servo Motor | Converts electrical energy into controlled mechanical motion |
| Motor Feedback | Returns position and motion information |
| Mechanical Transmission | Transfers motor movement to the machine mechanism |
| Machine Axis | Performs the required positioning or continuous movement |
| HMI / Engineering Tool | Provides operation, configuration, and diagnostic functions |
The division between controller and drive allows machine-level motion coordination to remain separate from the electrical regulation of each individual motor axis.
Industrial Applications
| Application | Typical Use |
|---|---|
| Packaging Machinery | Coordinated movement of conveyors, cutters, and feeders |
| Automated Assembly | Precise positioning of assembly mechanisms |
| Material Handling | Servo-controlled positioning and transfer |
| Labeling Machines | Synchronization of product and labeling axes |
| Printing Equipment | Controlled speed and position of machine rollers |
| Pick-and-Place Machines | Repetitive high-accuracy axis positioning |
| Indexing Systems | Rapid and repeatable machine-axis movement |
| Production Machinery | Coordinated multi-axis motion and machine sequencing |
Installation and Maintenance
- Confirm that the LXM32SD72N4 is suitable for the intended Lexium 32 motion architecture.
- Verify the connected servo motor and drive combination before applying power.
- Check the incoming power, protective devices, grounding, and motor wiring against the approved electrical design.
- Verify motor feedback connections and ensure the feedback device matches the configured axis.
- Confirm communication wiring between the motion controller and servo drive.
- Check the drive configuration, motor parameters, and axis settings before enabling the motor.
- Verify that machine travel limits and applicable enable or permissive conditions are correctly configured.
- Inspect motor and control cables for secure termination and mechanical protection.
- Perform initial commissioning with the machine in a controlled state and with the axis movement limited where appropriate.
- Check actual motor response against commanded speed, position, and direction during testing.
- Investigate drive faults together with motor, feedback, communication, mechanical, and controller diagnostics.
- After replacement, verify axis homing, positioning, motion sequence, feedback behavior, and machine interlocks before returning the equipment to production.
Compatible System Components
| Component | Function |
|---|---|
| Schneider Lexium 32 Motors | Provides the mechanical motion for the controlled axis |
| Motion Controller | Generates coordinated machine and motion commands |
| Motor Feedback Device | Supplies position and motion information |
| Lexium 32 Communication | Exchanges control and diagnostic information |
| Machine I/O System | Provides machine status, commands, and interlock signals |
| HMI / Operator Panel | Provides machine operation and status visualization |
| Mechanical Transmission | Transfers motor torque to the machine mechanism |
| Machine Safety Equipment | Provides applicable safety-related monitoring and control |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| Schneider Lexium 32 | Servo Drive Family | Machine motion control |
| Schneider LXM32AD30N4 | Lexium 32 Servo Drive | Servo-axis motor control |
| Schneider LXM32AD72N4 | Lexium 32 Servo Drive | Higher-capacity servo-axis applications |
| Schneider Lexium 32M | Servo Drive | Compact machine motion applications |
| Schneider Lexium 32 Motors | AC Servo Motor | Machine-axis motion |
| Schneider PacDrive M | Motion Controller | Coordinated multi-axis machine control |
| Schneider Lexium Motion Control | Motion Control Platform | Automated machine positioning and sequencing |
Key Advantages
- Provides dedicated motor-side control for Lexium 32 motion systems.
- Supports closed-loop servo operation with compatible feedback systems.
- Suitable for precise positioning and coordinated machine-axis movement.
- Separates individual motor regulation from higher-level machine sequencing.
- Can be integrated into multi-axis automation architectures.
- Useful for packaging, assembly, handling, and other servo-driven machinery.
Technical FAQs
How should the LXM32SD72N4 be matched to a servo motor?
The drive should be selected together with the motor rating, feedback arrangement, application requirements, and machine power architecture. The motor configuration stored in the drive must correspond to the actual motor connected to the axis.
What can cause a servo axis to remain enabled but fail to move?
Possible causes include an incorrect motion command, missing enable conditions, incorrect feedback configuration, communication problems, drive parameters, mechanical restrictions, or active machine interlocks. These conditions should be checked from the controller through to the motor and mechanical axis.
Why is feedback important in a Lexium 32 servo system?
Feedback allows the drive and motion-control system to determine the actual motor position or movement and regulate the axis accordingly. A feedback fault can therefore prevent normal closed-loop operation or cause the drive to report an axis-related fault.
What should be verified after replacing the LXM32SD72N4?
Verify the drive configuration, connected motor, feedback settings, communication parameters, axis assignment, and machine-specific settings. The axis should then be tested for homing, direction, positioning, and coordinated operation before full automatic production is resumed.