ProductPRODUCT
Featured products
Contact Us
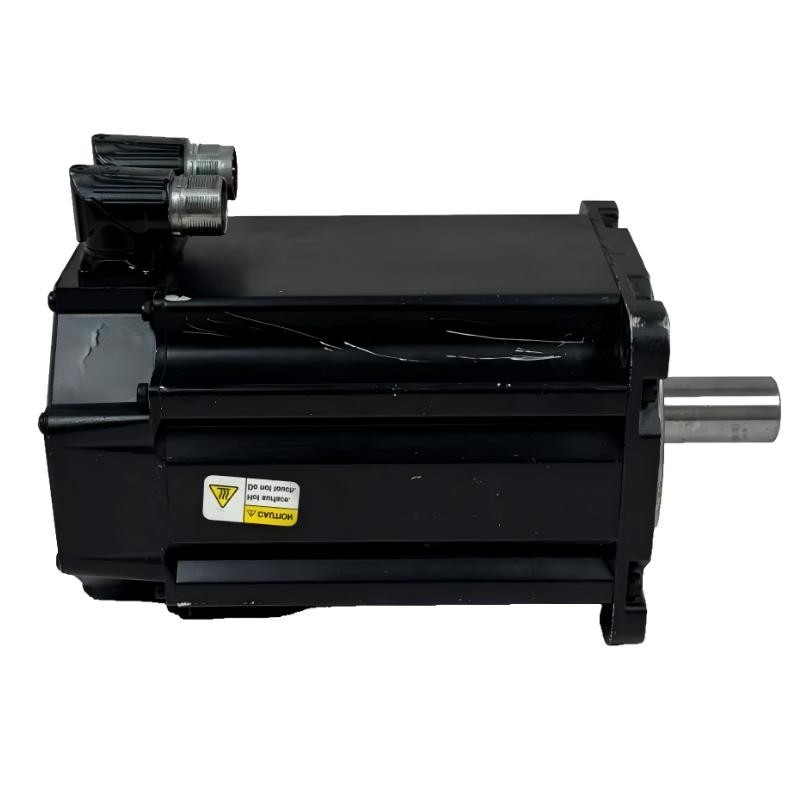
- Allen Bradley
- MPL-B960B-MJ72AA
- Low-Inertia Brushless Servo Motors Product
- USA
- 215 mm ×203.2 mm × 325 mm
- 42.7 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 10
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
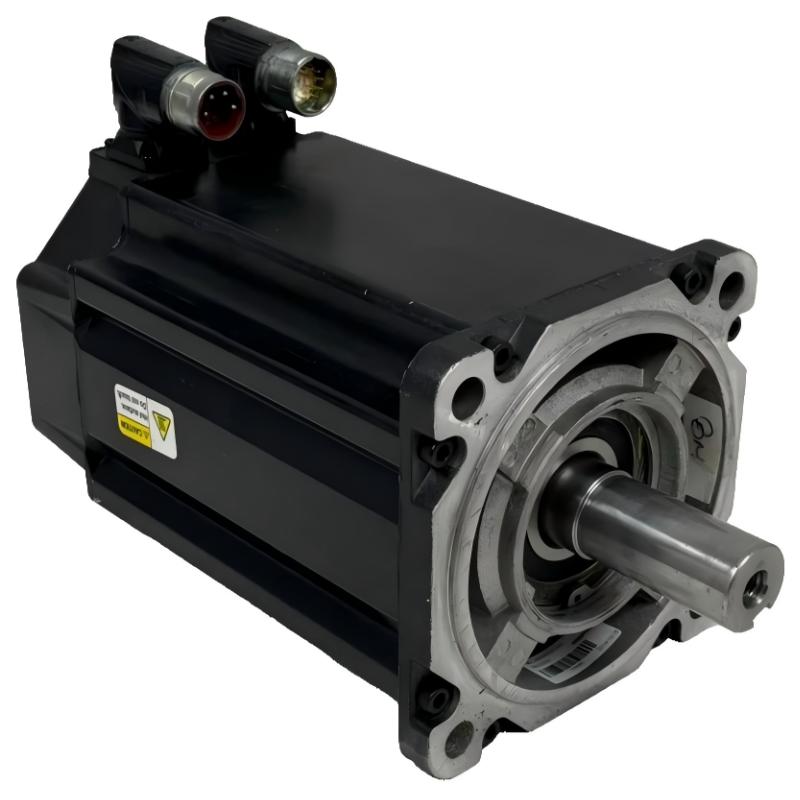
Allen-Bradley MPL-B960B-MJ72AA Servo Motor: Technical Specifications, Product Description, Applications, Advantages, and Related Models
1. Product Overview
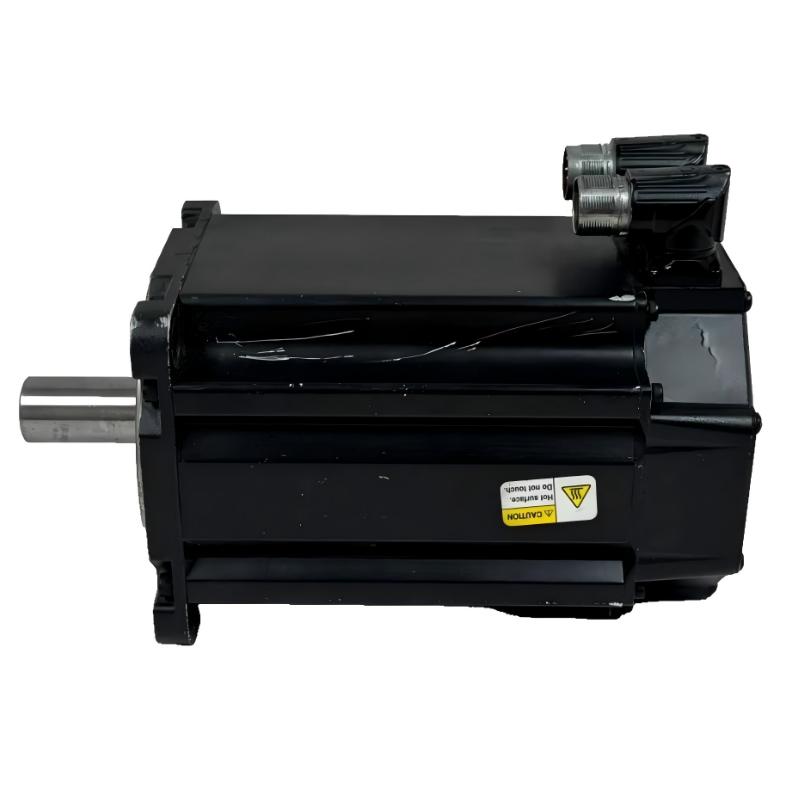
The Allen-Bradley MPL-B960B-MJ72AA is a low-inertia brushless AC rotary servo motor designed for industrial motion-control applications that require controlled movement, substantial torque, and repeatable positioning. It belongs to the MP-Series MPL family and is intended to operate with a compatible servo drive and motion controller.
This model uses a 460 V AC voltage-class configuration, multi-turn high-resolution absolute feedback, a keyed shaft extension, and a right-angle SpeedTEC DIN quick-connect connector that can be rotated through 180 degrees. It has no integrated holding brake.
A key characteristic of this motor is its 1,200 RPM nominal speed configuration, combined with approximately 130 N·m continuous stall torque, 231 N·m peak stall torque, and 12.7 kW rated output power. This makes it a candidate for applications that require a higher torque capability at a lower nominal speed than some 1,500 RPM or 2,000 RPM motor configurations.
The motor’s multi-turn absolute encoder supplies position information across multiple revolutions, which can be useful in automated machinery where position tracking is important. The exact restart and position-recovery behavior still depends on the encoder, drive, controller, and machine configuration.
The MPL-B960B-MJ72AA is suitable for evaluation in demanding automation equipment, including material-handling systems, rotary mechanisms, production machinery, and selected industrial positioning axes. Final selection should be based on the required motion profile, load inertia, available drive, mounting dimensions, and operating conditions.
2. Brand and Product Series
|
Item |
Description |
|---|---|
|
Model |
MPL-B960B-MJ72AA |
|
Brand |
Allen-Bradley |
|
Product family |
MP-Series |
|
Product series |
MPL low-inertia brushless servo motors |
|
Product type |
Industrial AC rotary servo motor |
|
Motor construction |
Brushless servo motor |
|
Voltage class |
460 V AC |
|
Nominal speed |
1,200 RPM |
|
Rated output power |
Approximately 12.7 kW |
|
Continuous stall torque |
Approximately 130 N·m |
|
Peak stall torque |
Approximately 231 N·m |
|
Feedback |
Multi-turn high-resolution absolute encoder |
|
Brake |
No integrated brake |
|
Shaft |
Keyed shaft extension |
|
Connector |
Right-angle SpeedTEC DIN quick-connect |
|
Connector orientation |
Rotatable through 180° |
|
Frame designation |
Size 9, nominal frame dimension 300 mm |
|
Magnet stack length |
152.4 mm |
|
Mounting arrangement |
IEC metric, Type FF free mounting holes |
|
Overall dimensions |
Confirm using the exact mechanical outline drawing |
|
Approximate motor weight |
76.0 kg |
The MPL designation identifies the low-inertia servo motor series. These motors are intended for use in closed-loop motion-control systems where the controller needs feedback to regulate speed and position.
The B960B motor configuration is distinguished by its speed and torque characteristics. The MJ72AA configuration identifies a multi-turn absolute feedback arrangement, keyed shaft, specified connector configuration, and no integrated brake.
For purchasing and replacement work, the complete catalog number should always be retained. A model with a similar base number may have a different nominal speed, feedback type, brake option, or mechanical configuration.
3. Detailed Technical Specifications
The following table summarizes the principal electrical, mechanical, and performance characteristics of the MPL-B960B-MJ72AA. Values are intended for product comparison and preliminary engineering assessment.
|
Parameter |
Specification |
|---|---|
|
Model |
MPL-B960B-MJ72AA |
|
Brand |
Allen-Bradley |
|
Series |
MP-Series MPL |
|
Motor type |
Low-inertia brushless AC rotary servo motor |
|
Voltage class |
460 V AC |
|
Nominal rated speed |
1,200 RPM |
|
Maximum speed |
1,200 RPM |
|
Rated output power |
12.7 kW |
|
Continuous stall torque |
130 N·m |
|
Peak stall torque |
231 N·m |
|
Rotor inertia |
Approximately 0.0273 kg·m² |
|
Feedback device |
Multi-turn high-resolution absolute encoder |
|
Feedback function |
Absolute rotor-position feedback over multiple revolutions |
|
Brake configuration |
No integrated brake |
|
Shaft type |
Keyed shaft extension |
|
Connector |
Right-angle SpeedTEC DIN quick-connect |
|
Connector adjustment |
Rotatable through 180° |
|
Frame designation |
Size 9 |
|
Nominal frame dimension |
300 mm (11.81 in.) |
|
Magnet stack length |
152.4 mm (6.0 in.) |
|
Mounting arrangement |
IEC metric, Type FF free mounting holes |
|
Overall dimensions |
Confirm from the complete mechanical outline drawing |
|
Approximate weight |
76.0 kg |
|
Cooling and installation |
Follow the motor-specific installation instructions |
|
Control method |
Closed-loop servo control using a compatible drive |
|
Typical operating role |
High-torque positioning, controlled rotary motion, and industrial automation |
Dimensions and weight: The 300 mm frame designation and 152.4 mm magnet stack length are useful mechanical references, but they are not the complete length, width, and height of the assembled motor. For mounting or replacement, use the exact outline drawing to confirm the motor envelope, mounting-hole pattern, shaft projection, and connector clearance. The approximate weight is 76.0 kg.
Torque clarification: Continuous stall torque is a specified motor characteristic, not a guarantee that the motor can deliver that torque continuously at every speed. Available torque under actual operating conditions depends on the speed-torque curve, drive limits, cooling, duty cycle, and environmental conditions.
4. Product Introduction
The MPL-B960B-MJ72AA is designed for servo applications where the motor must provide controlled rotary motion in response to commands from an automation controller. Rather than simply running at a fixed speed, the motor can be commanded to accelerate, decelerate, change speed, or reach a target position through a compatible servo drive.
During operation, the controller generates a motion command and the drive supplies controlled electrical power to the motor. The encoder reports position information, allowing the drive and controller to regulate movement through a feedback loop.
This closed-loop arrangement is useful in production equipment where movement must be repeated consistently. It can also support coordinated motion between several axes, provided the drive, controller, and application program are designed for synchronized operation.
The B960B configuration has a nominal speed of 1,200 RPM and a rated output power of 12.7 kW. Its torque ratings make it worth evaluating for equipment that needs substantial starting or holding torque at the motor shaft, as well as controlled motion during acceleration and deceleration.
The motor’s multi-turn absolute feedback is another important feature. Unlike single-turn feedback, which describes position within one revolution, multi-turn feedback can retain position information across multiple revolutions within the encoder’s specified range and operating conditions. This can be useful for rotary mechanisms and axes whose position is not confined to a single turn.
The model has no integrated brake. Applications that require the motor to hold a load when power is removed must account for this limitation in the machine design. A separate brake, counterbalance, mechanical lock, or other appropriate load-holding mechanism may be required, depending on the application.
5. Main Product Features
5.1 Low-inertia brushless design
The motor belongs to the MPL low-inertia family, which is designed for responsive servo operation. Low motor inertia can help the system react efficiently to changes in commanded speed and direction.
This characteristic can be valuable in industrial machinery that performs frequent positioning moves, short cycles, or repeated acceleration and deceleration. Actual machine performance depends on the combined inertia of the motor, gearbox, coupling, and driven load.
A low-inertia motor is not automatically the best choice for every high-torque application. The motor must still be sized for the load inertia, required acceleration, peak torque, continuous torque, and thermal operating limits.
5.2 Multi-turn high-resolution absolute encoder
The multi-turn absolute encoder provides detailed position feedback over multiple revolutions. This can help the control system determine the rotor’s position without relying solely on counting incremental movement from a reference point.
This feature is particularly useful when a rotary mechanism or machine axis must track position across several turns. However, the actual position-retention and restart behavior depends on the encoder specifications, drive configuration, controller, and system power-up procedure.
The encoder must be compatible with the intended servo drive. Replacing this model with a single-turn feedback motor may require changes to the control program, commissioning procedure, or position-recovery strategy.
5.3 High torque capability
The motor has approximately 130 N·m continuous stall torque and 231 N·m peak stall torque. These ratings make it a candidate for applications where the required motor torque is relatively high.
Peak torque is normally available only within specified limits and for a defined operating duration. It should not be treated as a continuous operating rating. For reliable selection, calculate the torque required during acceleration, steady operation, deceleration, and any short-duration overload conditions.
5.4 1,200 RPM speed configuration
The B960B configuration has a nominal rated speed of 1,200 RPM. It may be worth considering when the machine’s required speed and torque profile differs from that of a 1,500 RPM or 2,000 RPM motor.
The motor should not be selected based on speed alone. The application must also meet the torque, output power, inertia, cycle-time, and drive requirements.
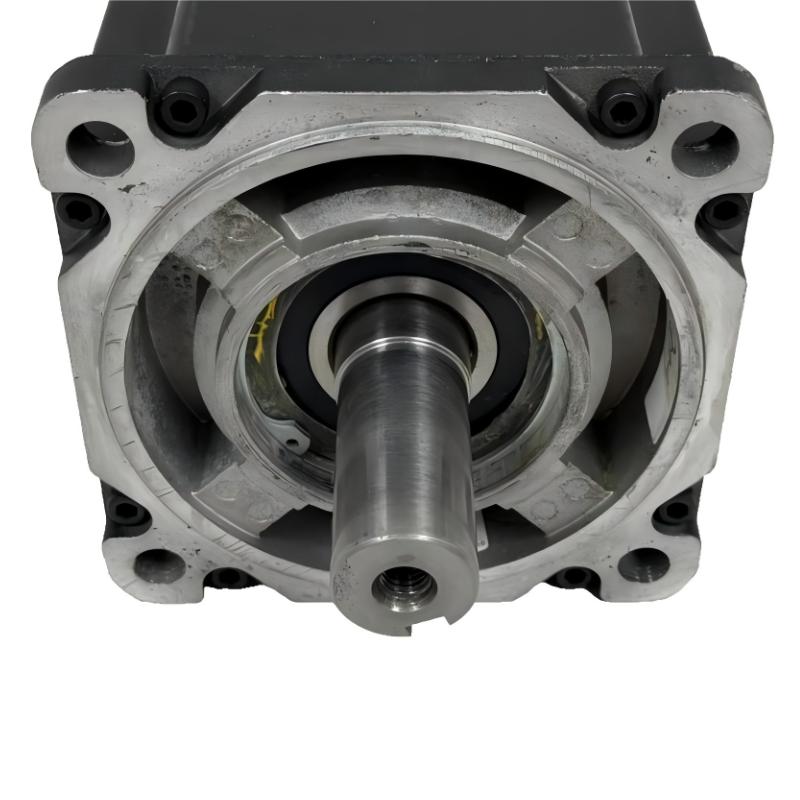
5.5 Keyed shaft extension
The keyed shaft allows the motor to connect to compatible mechanical transmission components such as couplings, pulleys, or gearboxes.
Correct shaft matching and alignment are essential. The shaft diameter, keyway, coupling type, allowable radial and axial loads, and transmission requirements should all be verified before installation. Improper alignment can cause vibration, bearing wear, and reduced motion accuracy.
5.6 Rotatable right-angle connector
The right-angle SpeedTEC DIN quick-connect connector can be rotated through 180 degrees. This gives the installer flexibility when routing cables around machine frames, guards, and adjacent equipment.
The connector position should be planned to maintain adequate cable clearance, prevent excessive bending, and allow convenient inspection and maintenance.
5.7 No integrated brake
The no-brake configuration is suitable for applications where a motor-mounted holding brake is not required or where the machine provides a separate holding arrangement.
If the motor drives a vertical axis, suspended load, or mechanism that could move under gravity, the absence of a brake must be addressed before installation. The control system alone should not be assumed to provide mechanical holding capability when the drive is disabled.
6. Product Applications

6.1 Material-handling equipment
The motor can be evaluated for transfer mechanisms, powered handling units, and rotary positioning equipment. These applications may require controlled movement under varying loads. Motor selection should consider the transmission ratio, load inertia, required acceleration, and duty cycle.
Where the load can move after power is removed, the machine must provide an appropriate holding solution.

6.2 Automated assembly systems
Assembly machinery often requires components to be transferred between stations at specific intervals. The motor can be considered for rotary indexers, positioning mechanisms, and controlled machine axes that need repeatable movement and feedback-based regulation.
The final design should account for positioning accuracy, mechanical backlash, cycle time, and the inertia of the assembly mechanism.

6.3 Packaging and converting machinery
Packaging systems can use servo motors for feed rollers, indexing stations, cutting mechanisms, and synchronized machine movements. A suitable servo system can control acceleration and stopping behavior to support consistent production cycles.
Confirm that the motor’s rated speed, torque curve, and thermal capacity match the machine’s required throughput.

6.4 Rotary tables and indexing mechanisms
Rotary tables may need to move through a specified angle, stop at a programmed position, and repeat the operation over many cycles. Multi-turn absolute feedback can be useful when the position information must extend beyond a single revolution.
The motor, gearbox, table inertia, and controller must be selected together to achieve the required accuracy and cycle time.

6.5 Machine tools and specialized production equipment
The motor may be considered for selected positioning axes, rotary mechanisms, and automated machine functions. Its suitability depends on the machine’s speed-torque requirements, mechanical stiffness, feedback architecture, and expected operating duty.
The complete drive and mechanical system should be evaluated before installation.
These are representative application areas, not a guarantee that the motor will suit every machine in the category. Final selection requires a review of the actual load, motion profile, mounting arrangement, operating environment, and drive compatibility.
7. Product Advantages
7.1 Strong torque capability for demanding axes
The continuous and peak stall torque ratings provide a useful starting point when assessing applications that need substantial torque at the motor shaft. This can be beneficial for machinery with significant acceleration demands or changing mechanical loads.
The torque ratings must be interpreted together with the operating speed and thermal limits. A motor’s peak torque should not be treated as a continuous operating value.
7.2 Multi-turn position feedback
Multi-turn absolute feedback is useful where the control system needs position information across multiple revolutions. This can simplify certain position-tracking requirements compared with systems that rely exclusively on incremental movement from a reference point.
The benefits depend on the encoder’s supported range and the drive and controller’s handling of absolute position.
7.3 Closed-loop control
When used with a compatible servo drive and controller, the motor can operate within a feedback loop that regulates movement against the commanded position or speed.
This is useful in automation systems where consistent movement and repeatable production cycles are important.
7.4 Industrial mechanical configuration
The frame and magnet-stack designations help engineers compare the motor against other MPL models during equipment design or replacement evaluation. The keyed shaft and defined connector configuration also provide clear starting points for mechanical and electrical integration.
7.5 Flexible connector orientation
The rotatable right-angle connector can help accommodate different cable-routing arrangements. This is useful where motor placement is constrained by a machine frame, guard, or adjacent component.
7.6 Potential for integration into existing motion-control systems
Where the drive, feedback interface, voltage class, and mechanical arrangement are compatible, the motor can be evaluated for existing servo-controlled machinery. A full compatibility check is still necessary, particularly when replacing a motor with a different speed or feedback configuration.
8. Model Number Explanation
The catalog number identifies the motor’s principal configuration. The table below provides a practical overview of the main code sections.
|
Code section |
General interpretation |
|---|---|
|
MPL |
MPL low-inertia brushless servo motor family |
|
B |
Voltage and motor configuration code |
|
960 |
Frame and magnet-stack size designation |
|
B |
1,200 RPM nominal speed configuration |
|
M |
Multi-turn high-resolution absolute feedback |
|
J |
Keyed shaft extension |
|
7 |
Right-angle SpeedTEC DIN connector, rotatable through 180° |
|
2 |
No integrated brake |
|
AA |
Additional catalog configuration designation |
The full model number, MPL-B960B-MJ72AA, should be used when ordering, servicing, or comparing alternatives. A change in the speed, feedback, or brake code can affect the motor’s suitability and may require changes to the drive configuration or machine-control program.
9. Five Related Models in the MPL Series
The following models provide useful comparisons within the MPL family. They differ in speed, torque, feedback, brake configuration, or mechanical dimensions. They should be treated as candidates for engineering evaluation rather than automatic replacements.
|
Model |
Voltage class |
Nominal speed |
Continuous / peak stall torque |
Rated output power |
Feedback |
Brake |
Frame / stack length |
Approx. weight |
|---|---|---|---|---|---|---|---|---|
|
MPL-B960B-MJ74AA |
460 V AC |
1,200 RPM |
130 / 231 N·m |
12.7 kW |
Multi-turn absolute |
24 V DC |
300 / 152.4 mm |
Approx. 76.0 kg |
|
MPL-B960B-SJ72AA |
460 V AC |
1,200 RPM |
130 / 231 N·m |
12.7 kW |
Single-turn absolute |
No brake |
300 / 152.4 mm |
Approx. 76.0 kg |
|
MPL-B960C-MJ72AA |
460 V AC |
1,500 RPM |
124.3 / 226 N·m |
14.8 kW |
Multi-turn absolute |
No brake |
300 / 152.4 mm |
Approx. 76.0 kg |
|
MPL-B960D-MJ72AA |
460 V AC |
2,000 RPM |
124.3 / 226 N·m |
15.0 kW |
Multi-turn absolute |
No brake |
300 / 152.4 mm |
Approx. 76.7 kg |
|
MPL-B980B-MJ72AA |
460 V AC |
1,000 RPM |
162.7 / 278 N·m |
15.2 kW |
Multi-turn absolute |
No brake |
300 / 203.2 mm |
Approx. 94.5 kg |
Frame and stack values are nominal dimensions in millimetres, not the complete external motor dimensions. Weight values marked approximate should be confirmed for the exact catalog variant. Check the motor’s mechanical drawing before using any model as a replacement.
Related-model selection notes
MPL-B960B-MJ74AA
This model retains the same general speed, torque, and multi-turn feedback configuration while adding a 24 V DC holding brake. It is worth evaluating if the application needs a motor-mounted brake for holding a stationary load.
MPL-B960B-SJ72AA
This model uses single-turn absolute feedback instead of multi-turn feedback. It may be appropriate when the machine’s position requirements fit the single-turn configuration and the selected drive supports it.
MPL-B960C-MJ72AA
The B960C is a 1,500 RPM configuration with a different rated power and torque profile. It can be considered when the required machine speed is higher than the B960B’s nominal speed but the application still needs substantial torque.
MPL-B960D-MJ72AA
The B960D is a 2,000 RPM configuration. It may be worth comparing where a higher nominal speed is required, although the actual load and speed-torque curve must be assessed.
MPL-B980B-MJ72AA
This model has a 1,000 RPM nominal speed configuration and higher continuous and peak stall torque ratings. It may be relevant for applications that favor higher torque at a lower speed, provided the larger stack length, weight, and mechanical envelope suit the machine.
10. Five Other Allen-Bradley Servo Motor Models to Compare
The models below offer additional choices within the MPL family. They have different speed, torque, and physical configurations, so their suitability depends on the specific application rather than model popularity alone.
|
Model |
Voltage class |
Nominal speed |
Continuous / peak stall torque |
Rated output power |
Frame / stack length |
Approx. weight |
|---|---|---|---|---|---|---|
|
MPL-B860D-MJ72AA |
460 V AC |
2,000 RPM |
83 / 152.5 N·m |
12.5 kW |
265 / 152.4 mm |
67.5 kg |
|
MPL-B880D-MJ72AA |
460 V AC |
2,000 RPM |
110 / 147 N·m |
12.6 kW |
265 / 203.2 mm |
Approx. 86.7 kg |
|
MPL-B960C-MJ72AA |
460 V AC |
1,500 RPM |
124.3 / 226 N·m |
14.8 kW |
300 / 152.4 mm |
Approx. 76.0 kg |
|
MPL-B960D-MJ72AA |
460 V AC |
2,000 RPM |
124.3 / 226 N·m |
15.0 kW |
300 / 152.4 mm |
Approx. 76.7 kg |
|
MPL-B980C-MJ72AA |
460 V AC |
1,500 RPM |
158.2 / 271 N·m |
16.8 kW |
300 / 203.2 mm |
Approx. 94.5 kg |
The frame and stack dimensions are nominal designations. Complete external dimensions, shaft details, and mounting-hole locations must be checked against the mechanical drawing. Weight figures may vary by configuration and should be confirmed before installation or shipment.
Additional model comparison
MPL-B860D-MJ72AA
The B860D has a lower continuous stall torque rating than the B960B and a shorter magnet stack designation. It may be worth considering when the application’s torque requirement is lower and installation space is more restricted.
MPL-B880D-MJ72AA
The B880D is a 2,000 RPM configuration with a different torque and speed profile. It may be suitable for a machine requiring higher nominal speed than the B960B, provided its continuous and peak torque capability meets the application needs.
MPL-B960C-MJ72AA
The B960C offers a 1,500 RPM configuration with a rated output power of approximately 14.8 kW. It is a useful comparison when the machine’s required speed falls between the B960B and B960D configurations.
MPL-B960D-MJ72AA
The B960D provides a 2,000 RPM nominal speed configuration with approximately 124.3 N·m continuous stall torque and 226 N·m peak stall torque. It may be considered for higher-speed axes that need substantial torque, subject to drive and load calculations.
MPL-B980C-MJ72AA
The B980C offers higher continuous and peak stall torque ratings than the B960B. Its stack length and total motor dimensions must be checked carefully when evaluating it for an existing machine.
11. Installation and System Integration
11.1 Servo drive compatibility
The selected servo drive must support the motor’s voltage class, current requirements, feedback interface, and motor configuration. Confirm that the drive can correctly identify and operate the multi-turn absolute encoder.
A similar model number does not guarantee drive compatibility. Before replacing an existing motor, check the drive’s supported motor list, feedback connection, power requirements, and configuration parameters.
11.2 Mechanical mounting and alignment
The 300 mm frame designation and 152.4 mm magnet stack length are not enough to determine whether the motor will fit a machine. Confirm the full motor length, flange dimensions, mounting-hole positions, shaft projection, keyway, and connector clearance.
The mounting structure should be rigid enough for the expected load and acceleration. Correct alignment between the motor shaft and the driven component helps limit vibration and unnecessary bearing loads.
11.3 Load and inertia calculations
Motor selection should be based on the total load, including any gearbox, coupling, rotary table, belt, pulley, or other driven components. The engineer should assess continuous torque, peak torque, acceleration, deceleration, cycle duration, and thermal loading.
The rotor inertia of approximately 0.0273 kg·m² is one input to the calculation, but the inertia of the external load and the transmission ratio must also be considered.
11.4 Brake and load-holding requirements
The MPL-B960B-MJ72AA has no integrated brake. If the motor operates a vertical axis or a load that could move when the drive is disabled, determine whether a separate brake or other mechanical holding method is required.
Do not treat the servo drive’s ability to command zero speed as a substitute for mechanical load holding under power-loss conditions. Safety requirements should be addressed in the complete machine design.
11.5 Cable routing and electrical installation
The right-angle connector can be rotated through 180 degrees, which helps with installation flexibility. Route power and feedback cables so they are protected from sharp edges, moving machinery, excessive bending, and unnecessary strain.
Use the specified grounding, shielding, and cable-separation practices for the drive system. Poor electrical installation can lead to feedback errors, intermittent faults, or unreliable operation.
11.6 Commissioning
Before normal production, verify mounting, shaft alignment, cable connections, grounding, feedback operation, and drive settings. Start with controlled motion and confirm direction, position response, acceleration, deceleration, and travel limits.
For equipment with heavy or gravity-loaded mechanisms, verify how the machine responds to drive faults and loss of power. The absence of an integrated brake must be included in the commissioning and risk-assessment process.
12. Maintenance Recommendations
A planned maintenance routine helps identify developing mechanical or electrical problems before they interrupt production.
Recommended inspection items include:
-
Check motor mounting bolts and mechanical connections for looseness.
-
Inspect the shaft coupling and driven mechanism for alignment and abnormal vibration.
-
Examine power and feedback cables for damage, loose connections, or strain.
-
Investigate unusual motor noise, excessive temperature, or repeated drive faults.
-
Keep the installation environment within the specified operating limits.
-
Review drive fault history and confirm that feedback and motor identification remain correct after maintenance.
-
Inspect any separate holding brake or load-support system used by the machine according to its own maintenance requirements.
Maintenance intervals should reflect the actual duty cycle, operating environment, contamination level, and equipment requirements. Avoid disassembling or modifying the motor without the appropriate service procedure.
13. Frequently Asked Questions
What is the nominal speed of the MPL-B960B-MJ72AA?
Its nominal rated speed is 1,200 RPM. The actual operating point depends on the motor’s speed-torque characteristics, the drive, the mechanical load, and the required duty cycle.
What are the motor’s torque ratings?
The motor has approximately 130 N·m continuous stall torque and 231 N·m peak stall torque. These figures should be assessed alongside the speed-torque curve and thermal limits.
Does this model include a holding brake?
No. The MJ72AA configuration is a no-brake version. If the machine requires the motor to hold a load when power is removed, a separate load-holding arrangement may be needed.
What is the approximate motor weight?
The approximate motor weight is 76.0 kg. Confirm the exact catalog variant and mechanical documentation before lifting, mounting, or shipping.
What are the dimensions?
The nominal frame dimension is 300 mm and the magnet stack length is 152.4 mm. These are not the complete external dimensions. The mechanical outline drawing is required to confirm total length, mounting dimensions, shaft projection, and connector clearance.
Can the B960B be replaced with the B960C or B960D?
Not without checking the application. The B960C and B960D have different nominal speed configurations and rated output power. Confirm the required speed, torque, feedback, drive compatibility, mounting dimensions, and load inertia before selecting a replacement.
Is multi-turn feedback useful for all applications?
Not necessarily. It is useful when position information across multiple revolutions is required. For applications that only need single-turn position information, a single-turn feedback configuration may be sufficient, provided it is supported by the drive and controller.
14. Final Product Summary
The Allen-Bradley MPL-B960B-MJ72AA is a low-inertia brushless AC rotary servo motor in the MP-Series MPL family. It features a 460 V AC voltage-class configuration, 1,200 RPM nominal speed, 12.7 kW rated output power, approximately 130 N·m continuous stall torque, approximately 231 N·m peak stall torque, multi-turn absolute feedback, a keyed shaft extension, and a rotatable right-angle connector.
Its principal strengths are its torque capability, multi-turn position feedback, and suitability for integration into closed-loop industrial motion-control systems. It may be worth evaluating for material handling, rotary positioning, assembly machinery, packaging equipment, and other applications where its speed, torque, and mechanical configuration match the load requirements.
The no-brake configuration is an important limitation to consider when the motor is used on a vertical axis or any mechanism that must remain stationary when the drive is disabled. In those cases, the complete machine must provide an appropriate holding solution.
For related alternatives, the B960B-MJ74AA adds a holding brake, the B960B-SJ72AA uses single-turn feedback, and the B960C or B960D provide different nominal speed configurations. The B980B offers a higher torque configuration but has a different stack length and weight.
Before ordering or installing a motor, verify the complete catalog number, drive and encoder compatibility, torque and speed requirements, mechanical dimensions, actual weight, and load-holding needs. These checks are essential to selecting a motor that fits the machine and performs reliably in its intended application.