ProductPRODUCT
Featured products
Contact Us
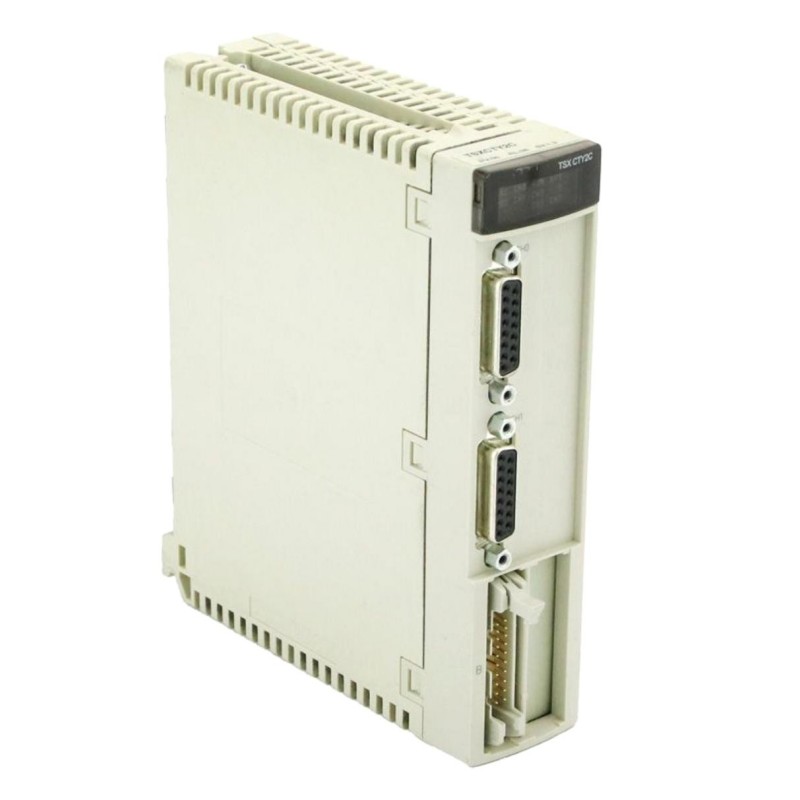
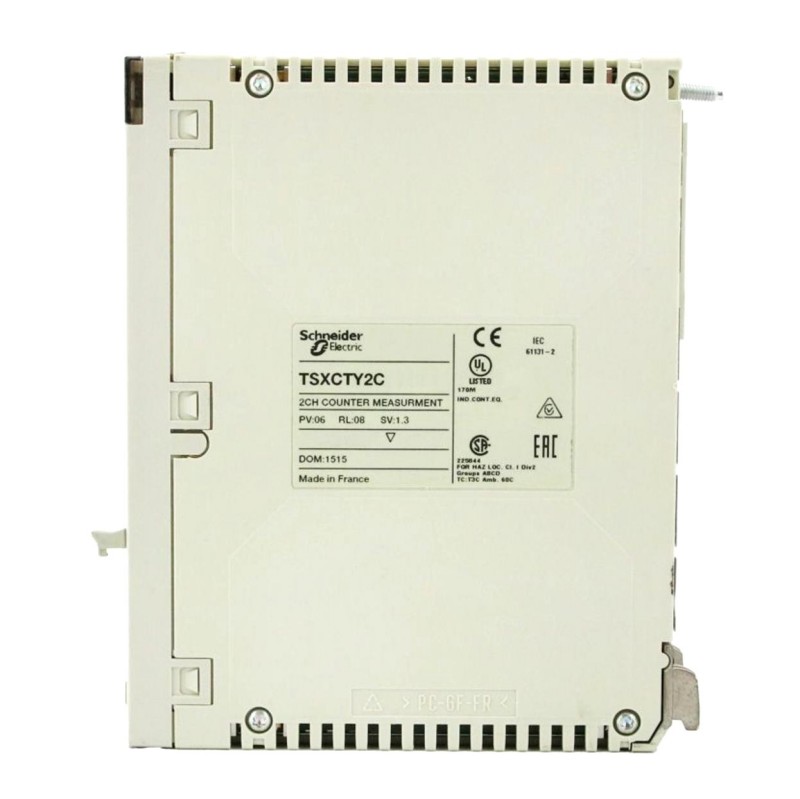
- Schneider
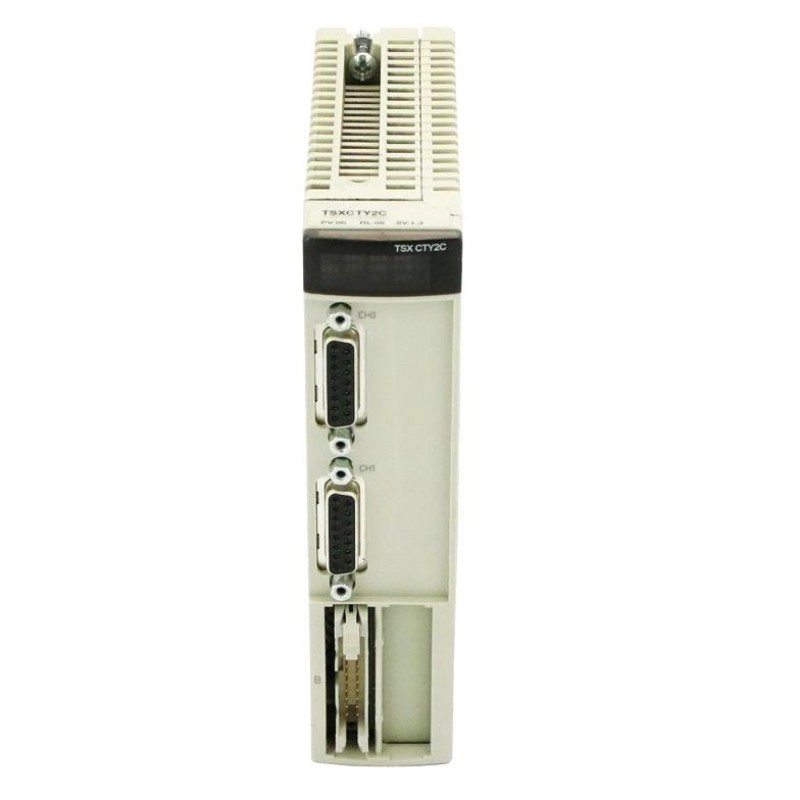
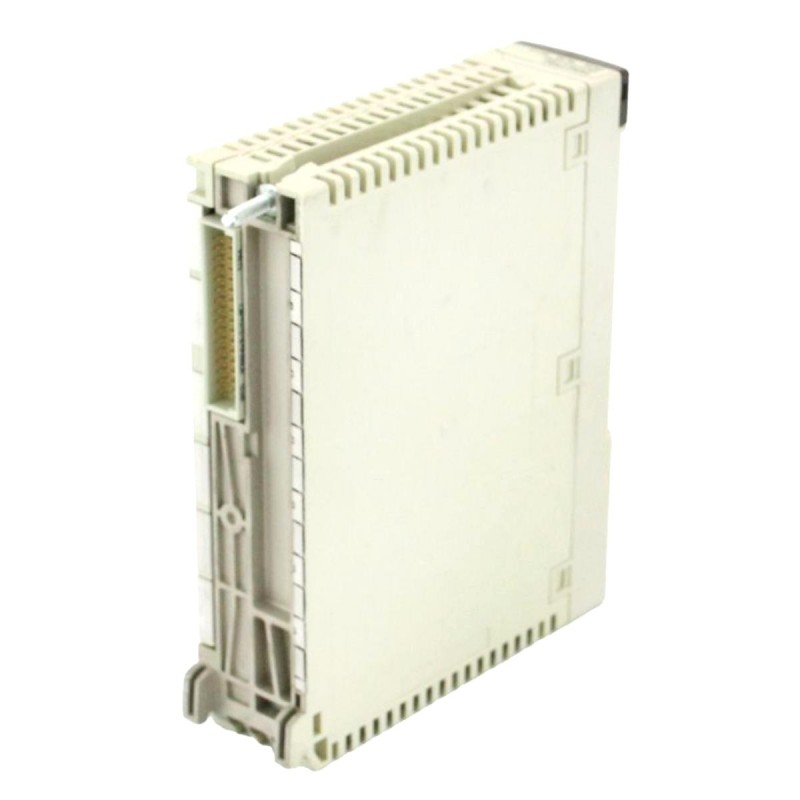
- TSXCTY2C
- Measurement and Counter Module
- France
- 55 ×180 × 260 mm
- 0.34 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
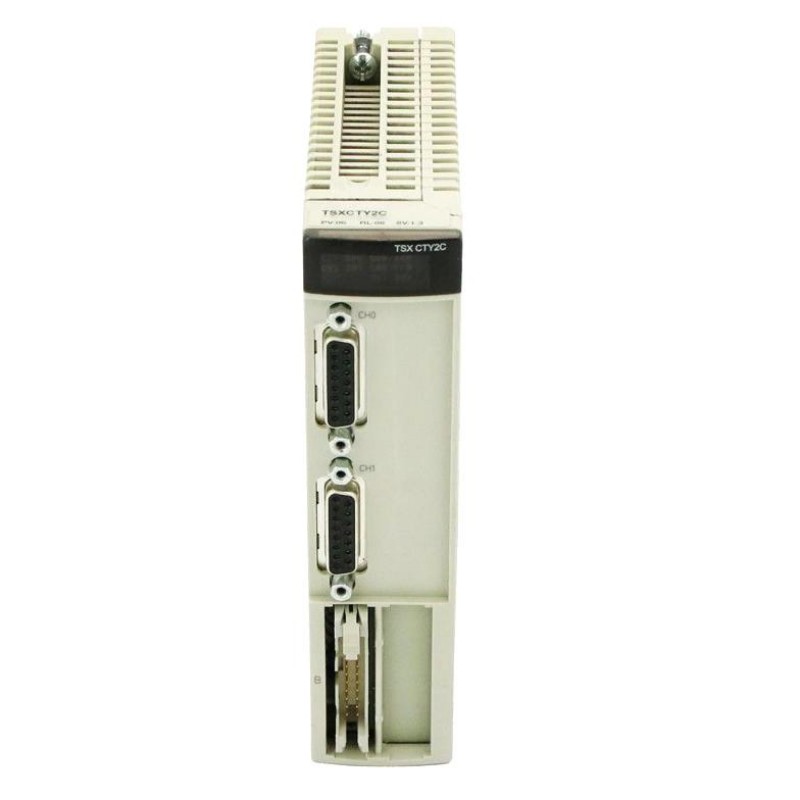
Product Overview
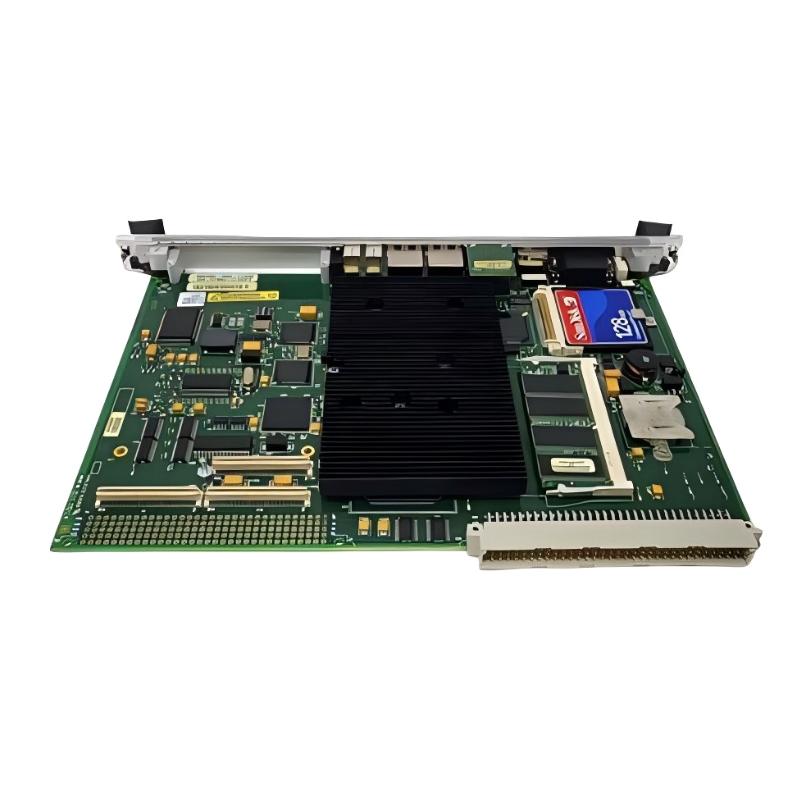
The Schneider Electric TSXCTY2C Modicon Premium Measurement and Counter Module is a high-speed counting and measurement module for industrial automation systems built around the Modicon Premium PLC platform. It is used in applications that require accurate pulse acquisition, encoder feedback processing, production counting, speed monitoring, and position-related measurement.
In automated machinery, standard PLC scan-based logic may not be suitable for processing high-frequency pulses from a rapidly rotating encoder or moving production line. The TSXCTY2C handles counting and measurement through dedicated hardware functions, allowing the PLC application to use the resulting data for machine sequencing and process control.
Typical applications include packaging equipment, conveyor systems, material-length measurement, automated cutting machinery, and production lines that rely on encoder feedback. The module supports two counting channels and can work with compatible incremental encoders, absolute encoders, and proximity sensors, subject to the selected interface and configuration.
Its auxiliary inputs and outputs provide additional control options for synchronizing measurement with machine events. Correct encoder selection, channel configuration, and signal wiring are essential to achieving accurate results.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | TSXCTY2C |
| Product Family | Modicon Premium |
| Product Type | Measurement and Counter Module |
| Number of Channels | 2 |
| Maximum Counting Frequency | Up to 1 MHz, depending on operating mode |
| Incremental Encoder Frequency, x1 | Up to 500 kHz |
| Incremental Encoder Frequency, x4 | Up to 250 kHz |
| Module Cycle Time | 1 ms |
| Encoder Compatibility | Supported incremental encoders and absolute encoder interfaces |
| Incremental Encoder Interfaces | 5 V DC RS-422 and 10–30 V DC Totem Pole |
| Absolute Encoder Interface | SSI |
| Proximity Sensor Compatibility | Supported 2-wire and 3-wire PNP/NPN sensors |
| Auxiliary Input Functions | Preset, enable, and read |
| Auxiliary Input Voltage | 24 V DC |
| Encoder Input Voltage | 5 V DC for the applicable RS-422 interface |
| Auxiliary Output Voltage | 24 V DC nominal |
| Nominal Auxiliary Output Current | 0.5 A |
| Electrical Connections | Two 15-pin SUB-D connectors and one HE-10 20-pin connector |
| Power Consumption from 5 V DC Supply | 850 mA |
| Current Consumption from 24 V DC Supply | 15 mA |
| Local Diagnostics | RUN, I/O fault, ERR, and channel status indicators |
| Dimensions | 55 ×180 × 260 mm |
| Weight | 0.34 kg |
Product Features
- Two counting channels: Processes pulse signals from compatible encoders and sensors for measurement and counting applications.
- High-speed signal acquisition: Handles high-frequency pulses that may exceed the practical processing capability of ordinary cyclic PLC logic.
- Incremental encoder processing: Acquires encoder signals for movement tracking, speed monitoring, and position calculations.
- Absolute position acquisition: Supports compatible SSI absolute encoder applications.
- Configurable auxiliary inputs: Preset, enable, and read functions can be incorporated into the measurement sequence.
- Reflex output capability: Configured output functions can respond to defined measurement conditions, depending on the selected operating mode.
- Multiple sensor options: Supports compatible proximity sensors for applications involving event detection and pulse counting.
- Diagnostic indicators: Status LEDs provide useful information when checking module operation, channel conditions, and I/O faults.
- PLC application integration: Makes measurement values available for control logic, machine sequencing, and production monitoring.
The usable counting frequency depends on the selected input interface and counting mode. Encoder specifications and application requirements must be evaluated together rather than relying solely on the module’s highest stated frequency.
Working Principle
The TSXCTY2C receives electrical signals from an encoder or compatible sensor and processes the signals through its configured counting or measurement channel. The resulting count or measurement information is then used by the Modicon Premium PLC program to determine machine actions.
Encoder or Sensor → TSXCTY2C → Counter and Measurement Processing → PLC Control Logic
For example, in a material-feed system, an incremental encoder generates pulses as a roller advances the material. The module processes the pulses, while the PLC application converts the count into a material position using the configured resolution and mechanical scaling. When the measured position reaches a programmed target, the control sequence can initiate the next operation, such as stopping the feed or starting a cutting cycle.
For speed monitoring, the PLC application can use changes in encoder counts over time to calculate movement speed. In applications using an absolute encoder, the selected interface and configuration determine how position data is acquired and interpreted.
The auxiliary inputs can synchronize counting operations with machine events. A preset input, for example, can establish a reference count when a known position is reached. The enable input can control when counting is active, while the read function can be used according to the configured operating mode.
The module’s measurement functions do not replace the main PLC program. The CPU remains responsible for coordinating interlocks, sequencing actuators, processing operating conditions, and managing the wider automation process.
Role in the Modicon Premium Control System
The TSXCTY2C occupies a measurement and counting role within a Modicon Premium PLC architecture. It processes encoder or sensor signals locally and makes the resulting information available to the controller.
| System Component | Function |
|---|---|
| Modicon Premium CPU | Executes application logic and coordinates machine operations |
| TSXCTY2C Module | Acquires and processes high-speed counting and measurement signals |
| Incremental Encoder | Generates pulses corresponding to rotation or movement |
| SSI Absolute Encoder | Supplies absolute position information through a serial interface |
| Proximity Sensor | Detects targets or machine events and supplies electrical signals |
| Auxiliary Input Circuit | Provides preset, enable, or read signals according to the configuration |
| Auxiliary Output Circuit | Executes configured output functions within electrical operating limits |
| Machine Actuators | Perform actions commanded by the PLC control sequence |
The overall system depends on matching the encoder interface to the module configuration and ensuring that the PLC program interprets the acquired values correctly. Mechanical scaling, signal quality, counting mode, and target calculations all affect the final control result.
Industrial Applications
| Application | Typical Function |
|---|---|
| Packaging Machinery | Tracks material feed and encoder movement during packaging cycles |
| Conveyor Systems | Counts products and monitors conveyor movement |
| Automated Cutting | Measures material advancement before a cutting operation |
| Material-Length Measurement | Converts encoder counts into length values |
| Production Equipment | Counts cycles, parts, or machine events |
| Speed Monitoring | Uses encoder signals to calculate rotational or linear speed |
| Position Monitoring | Compares measured movement against a programmed target |
| Automated Assembly | Tracks component movement and synchronizes operations with machine position |
Installation and Maintenance
- Confirm rack and system compatibility. Check that the module matches the installed Modicon Premium rack and controller configuration.
- Isolate the equipment before installation. Switch off the relevant power supplies before inserting the module or changing field connections.
- Identify the encoder interface. Confirm whether the application uses an incremental encoder, SSI absolute encoder, or supported proximity sensor.
- Verify electrical signal levels. Match the field device output type and voltage to the selected input interface.
- Check connector assignments. Use the appropriate channel connector and wiring arrangement for the selected sensor or encoder.
- Configure the counting channel. Set the required operating mode, counting direction, and measurement parameters in the PLC application.
- Check input frequency limits. Confirm that the encoder pulse rate is within the permitted range for the selected counting mode.
- Set up auxiliary functions. Configure preset, enable, read, and applicable output behavior to match the machine sequence.
- Verify measurement scaling. Compare the displayed or calculated measurement with a known physical movement to confirm the encoder resolution and mechanical conversion factor.
- Test under controlled conditions. Confirm counting direction, position response, and output behavior before returning the machine to normal production.
- Check diagnostic indicators. Use the module status LEDs to help identify operating, I/O, or channel-related issues.
- Inspect field wiring periodically. Check connector security, shielding, cable condition, and routing near high-interference equipment.
If counts are missing or inconsistent, inspect the encoder supply, signal wiring, interface selection, and input frequency before changing the application logic. If the count is correct but the machine stops at the wrong position, examine the scaling factor, target calculation, and mechanical transmission ratio.
Related Components
| Component | Function |
|---|---|
| Modicon Premium CPU | Executes the PLC program and processes measurement data |
| Modicon Premium Rack | Provides the mounting and backplane connection for the module |
| Incremental Encoder | Supplies movement-related pulse signals |
| SSI Absolute Encoder | Provides absolute position information |
| PNP/NPN Proximity Sensor | Detects parts and machine events |
| Encoder Connection Cable | Carries encoder signals to the module |
| Shielded Signal Cable | Reduces susceptibility to electrical interference when correctly installed |
| Auxiliary Input Wiring | Connects preset, enable, and read signals |
| Auxiliary Output Circuit | Interfaces configured output functions with compatible external circuits |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| TSXCTY2C | Modicon Premium Measurement and Counter Module | Two-channel high-speed counting and measurement |
| TSXCTY2A | Modicon Premium Counter Module | Counting applications using supported sensor configurations |
| TSXCTY4A | Modicon Premium Counter Module | Applications requiring additional counting channels |
| TSXCAY41 | Modicon Premium Motion Control Module | Motion-control applications requiring coordinated axis control |
| TSXAEY414 | Modicon Premium Analog Input Module | Acquisition of analog process signals |
| ABE7CPA11 | Telefast Encoder Interface Sub-Base | Connection arrangement for compatible parallel-output absolute encoders |
| Modicon Premium CPU Family | Programmable Logic Controllers | Processing measurement values and coordinating machine logic |
Key Advantages
- Two dedicated channels for high-speed counting and measurement.
- Support for multiple compatible encoder and sensor interfaces.
- High-frequency pulse processing for movement and position applications.
- Configurable auxiliary inputs for synchronizing counting operations.
- Measurement data available to the PLC application for control and monitoring.
- Diagnostic indicators that assist with installation checks and fault isolation.
- Integration into a Modicon Premium automation architecture.
Technical FAQs
How do you choose between incremental and absolute encoders for the TSXCTY2C?
An incremental encoder is suitable when the application can track movement by counting pulses from a known reference position. An absolute encoder is preferable when the control system needs a coded position value from the encoder itself. For the TSXCTY2C, confirm that the encoder’s electrical interface and output format match a supported configuration. Also consider required resolution, operating speed, reference-position strategy, and the consequences of losing the count during a power interruption.
How is the TSXCTY2C configured for high-speed position measurement?
Position measurement requires the correct channel mode, encoder interface, counting direction, and resolution settings. The PLC program must then convert the acquired count into engineering units using the encoder resolution and the mechanical transmission ratio. Before commissioning, verify the maximum signal frequency for the selected counting mode and test the measured position against a known movement. Incorrect scaling or an unsuitable counting mode can produce position errors even when the module is acquiring pulses correctly.
Can the TSXCTY2C perform length measurement on a conveyor or material-feed machine?
Yes, when a compatible encoder is mechanically coupled to the conveyor or feed mechanism and the application converts the count into a length value. The conversion depends on encoder resolution, roller circumference, gearing, and any other mechanical ratio between the encoder and the moving material. The PLC application can compare the calculated length with a target and trigger a sequence change when the target is reached. Mechanical slip and incorrect scaling can reduce measurement accuracy.
What causes counting errors or incorrect position values on a TSXCTY2C module?
Common causes include incorrect encoder wiring, an incompatible electrical output, excessive input frequency, incorrect counting configuration, electrical interference, and an inaccurate engineering-unit conversion. Check the signal type and connector assignment first, then verify that the selected counting mode matches the encoder and that the pulse rate remains within the applicable limit. If counting is stable but the displayed position is wrong, review the encoder resolution, mechanical ratio, reference preset, and PLC calculation.