

ProductPRODUCT
Featured products
Contact Us
- Schneider
- LXM23DU30M3X
- Motion Servo Drive
- France
- 114 × 225 × 195 mm
- 3.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
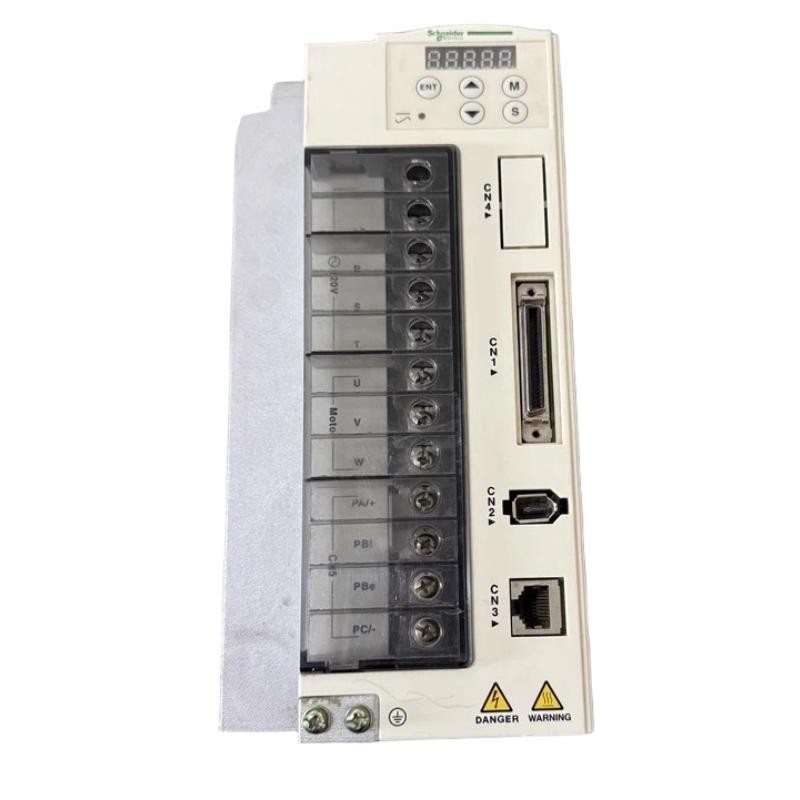
Product Overview
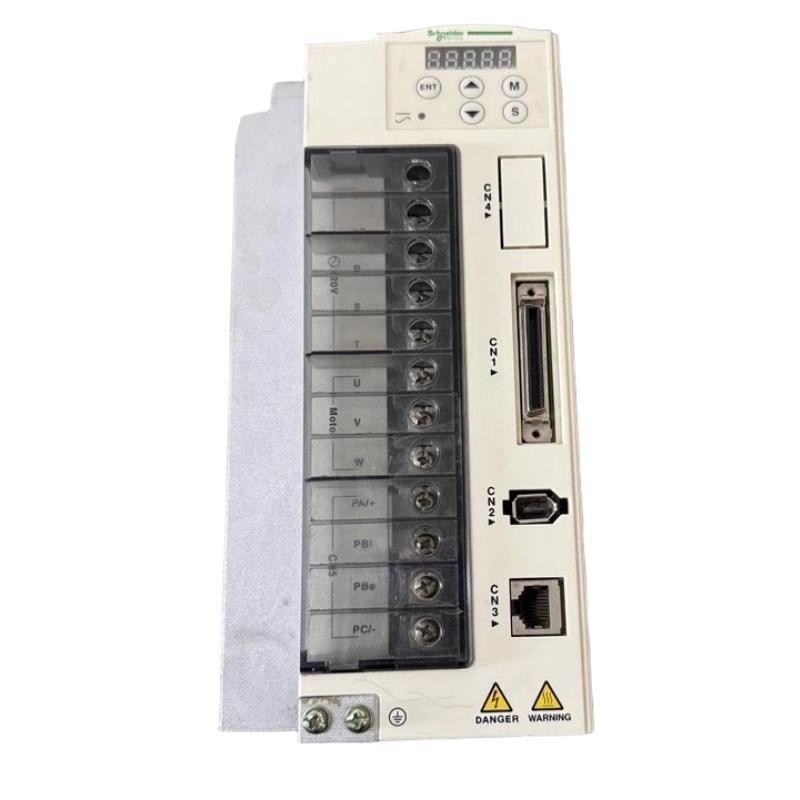
The Schneider Electric LXM23DU30M3X is a 3 kW AC servo drive in the Lexium 23 family. It controls compatible servo motors in industrial machinery that requires repeatable positioning, regulated speed, and controlled acceleration and deceleration. The drive processes motion commands and regulates motor output using feedback from the connected servo motor.
With a 3 kW nominal power rating, this model is suited to servo axes with substantial power requirements. Potential applications include automated packaging lines, assembly equipment, indexing systems, material-handling machinery, and dedicated production machines. The appropriate motor and drive combination depends on the required torque, load inertia, operating speed, acceleration profile, and duty cycle.
Consider a machine that transfers a heavy fixture between several processing stations. The axis must accelerate the fixture, reach the target position, and stop without disrupting the next operation. The LXM23DU30M3X regulates the servo motor throughout this movement, while the machine controller coordinates the positioning sequence with sensors, actuators, and other production equipment.
The LXM23DU30M3X belongs to the I/O-oriented configuration of the Lexium 23 family. It supports pulse-based positioning commands from compatible controllers, together with programmable digital inputs and outputs for machine coordination. Position, speed, and torque control functions allow it to serve different types of motion applications when the drive and controller are configured accordingly.
Its control interface is an important consideration during system integration. The LXM23DU30M3X should not be confused with an LXM23A variant equipped with CANopen communication. A controller that generates compatible pulse commands may be appropriate for this model, provided that the electrical interface, signal timing, and command logic match the drive’s requirements.
A 3 kW rating does not automatically make the drive suitable for every heavy-duty axis. The motor’s rated current, peak torque, mechanical transmission, load inertia, and stopping frequency must also be considered. A machine that performs rapid indexing may have different electrical and braking requirements from a mechanism that rotates continuously at a controlled speed.
For commissioning engineers, the drive should be evaluated as part of the complete motion system. Motor feedback, command scaling, wiring, grounding, and mechanical alignment all affect the final result. Careful configuration helps establish repeatable movement and makes subsequent fault diagnosis more straightforward.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | LXM23DU30M3X |
| Product Type | Motion Servo Drive |
| Product Family | Lexium 23 |
| Nominal Power | 3 kW |
| Rated Supply Voltage | 220 V AC, three-phase |
| Supply Voltage Range | 170–255 V AC, three-phase |
| Supply Frequency | 50/60 Hz |
| Network Frequency Limits | 47.5–63 Hz |
| Command Interface | Pulse control and programmable I/O |
| Programmable Digital Inputs | 8 |
| Digital Input Voltage | 12–24 V DC |
| Digital Outputs | 5 |
| Analog Inputs | 2 voltage inputs |
| Analog Input Range | -10 to +10 V |
| Feedback Type | Compatible servo motor encoder |
| Control Functions | Position, speed, and torque control |
| Cooling Method | Natural convection |
| EMC Filter | Not integrated |
| Protection Rating | IP20; upper-part protection depends on the specified protective cover |
| Operating Temperature | 0–55°C |
| Relative Humidity | 5–85%, non-condensing |
| Mounting Position | Vertical, within the specified installation tolerance |
| Dimensions | 114 × 225 × 195 mm |
| Weight | 3.2 kg |
Product Features
- 3 kW nominal power: Supports servo applications with substantial motor power requirements.
- Pulse-based positioning: Accepts supported movement commands from compatible controllers.
- Multiple control functions: Supports position, speed, and torque control according to the selected configuration.
- Programmable digital inputs: Provides inputs for configured operating commands and machine signals.
- Digital outputs: Supports external status and control signaling.
- Analog voltage inputs: Accommodates supported analog-reference functions.
- Encoder feedback: Allows the drive to regulate motor movement using feedback signals.
- Configured motion sequences: Supports predefined movement sequences for suitable repetitive applications.
- Natural-convection cooling: Requires appropriate cabinet ventilation and installation clearances.
- External braking provisions: Allows an appropriate braking arrangement where regenerative-energy demand requires one.
Working Principle
The LXM23DU30M3X receives movement commands from a compatible controller or executes a configured motion sequence. It regulates the electrical power delivered to the servo motor and uses encoder feedback to control the motor’s response.
PLC or Motion Controller → Pulse Commands → LXM23DU30M3X → Servo Motor → Mechanical Axis
In position-control mode, pulse commands represent the requested movement. The drive interprets the incoming signals according to its configured command scaling and electronic gearing, then regulates the motor through acceleration, travel, and deceleration. The resulting mechanical movement depends on the motor feedback arrangement and the transmission connecting the motor to the load.
For example, a transfer mechanism may need to move a loaded platform between workstations. The controller issues the movement command, and the drive regulates the motor as the platform accelerates and approaches its target. The machine sequence then coordinates the completed movement with the next operation. The motion profile must account for the platform’s inertia so that stopping remains within the machine’s mechanical and electrical limits.
Speed control is appropriate when an axis must follow a specified rotational-speed reference rather than repeatedly move between fixed positions. This may suit feed rollers, rotating mechanisms, and other equipment that operates at a commanded speed. The reference source and operating parameters must match the chosen control arrangement.
Torque control is relevant when the process requires regulation of motor torque as the principal control objective. The command source and torque limits must be configured for the connected motor and load. Torque control may help manage variable resistance in suitable applications, but it does not replace mechanical protection against jamming or excessive force.
The programmable digital inputs and outputs connect the drive to the machine’s control sequence. Depending on their assignments, they can support applicable enable, reset, limit, and status functions. Their behavior depends on the drive configuration and the controller program.
During deceleration, the motor may return energy to the drive. High-inertia loads, rapid stopping, and frequent motion cycles can increase regenerative-energy demand. Where the application exceeds the permitted energy-handling capability, an appropriately selected external braking resistor may be necessary.
If the axis overshoots, vibrates, or produces following errors, check the pulse commands, encoder feedback, motor configuration, mechanical transmission, and load inertia. For a high-power servo axis, the braking arrangement and deceleration profile also deserve attention when faults occur during stopping.
Role in a Lexium 23 Motion Control System
The LXM23DU30M3X serves as the servo power and control stage between the machine controller and the driven mechanism. It processes movement commands, regulates motor output, and uses encoder feedback to control the motor’s response.
PLC or Motion Controller → Servo Drive → Servo Motor → Mechanical Transmission → Machine Axis
| System Component | Function |
|---|---|
| Schneider Electric LXM23DU30M3X | Regulates servo motor power and executes configured motion control |
| Compatible Servo Motor | Converts electrical power into controlled mechanical movement |
| Motor Encoder | Supplies position and speed feedback |
| PLC or Motion Controller | Generates movement commands and coordinates machine sequences |
| Pulse Command Wiring | Transfers supported positioning signals to the drive |
| Digital I/O | Carries configured control and status signals |
| Analog Command Source | Supplies voltage references for supported control functions |
| Servo Motor Power Cable | Carries drive output power to the motor |
| Encoder Feedback Cable | Transfers motor feedback signals to the drive |
| External Braking Resistor | Dissipates regenerative energy where required |
| Mechanical Transmission | Transfers motor movement to the driven mechanism |
Industrial Applications
| Application | Typical Use |
|---|---|
| Packaging Machinery | Controlling feed mechanisms, indexing axes, and repetitive positioning cycles |
| Automated Assembly | Moving components into defined positions for insertion, fastening, or pressing |
| Indexing Systems | Transferring fixtures between processing stations |
| Material Handling | Operating compatible servo-driven transfer mechanisms |
| Printing Equipment | Regulating suitable feed and positioning axes |
| Labeling Machinery | Coordinating material movement with product positioning |
| Automated Inspection | Moving workpieces into repeatable measurement positions |
| Machine Tools | Controlling compatible auxiliary positioning axes |
| Winding Equipment | Regulating suitable axes where torque and regenerative demands match the system |
| Special-Purpose Machinery | Executing dedicated movement sequences for customized production equipment |
The LXM23DU30M3X is appropriate when the motor, three-phase supply, command interface, and motion profile match the machine’s operating requirements.
Installation and Maintenance
- Verify the supply circuit: Confirm that the incoming three-phase supply falls within the specified 170–255 V AC range and that the installation meets the drive’s electrical requirements.
- Match the motor to the drive: Check the motor’s rated current, voltage, power, encoder type, and supported drive-motor combination before connecting the equipment.
- Prepare the control cabinet: Provide adequate ventilation for natural-convection cooling and maintain the specified environmental conditions.
- Follow mounting requirements: Install the drive in the prescribed vertical orientation and maintain the required installation clearances.
- Check grounding and circuit protection: Verify protective grounding, supply-side protection, and electrical isolation before energizing the system.
- Inspect motor power connections: Confirm correct wiring, secure terminals, appropriate cable ratings, and grounding continuity.
- Verify encoder feedback: Inspect the encoder cable and connector for compatibility and secure installation. Keep feedback wiring appropriately separated from electrical noise sources.
- Configure pulse commands: Set the required pulse scaling and electronic gearing, then verify movement direction and signal timing against the controller output.
- Assign digital I/O functions: Configure the required inputs and outputs for the machine’s enable, reset, limit, and status requirements.
- Adjust the motion profile: Set acceleration, deceleration, speed limits, and positioning parameters according to the load inertia and operating cycle.
- Commission under controlled conditions: Test the axis at reduced speed and verify direction, feedback response, stopping behavior, and positioning before normal production.
- Maintain configuration records: Document motor details, parameter settings, alarms, wiring changes, and maintenance findings for future troubleshooting.
When the drive develops repeated overvoltage or positioning faults, investigate the motion profile, encoder feedback, load inertia, mechanical transmission, and braking arrangement. Identifying the underlying cause is more effective than changing multiple parameters without a clear diagnosis.
Related Components
| Component | Function |
|---|---|
| Schneider Electric LXM23DU30M3X | Controls a compatible servo motor using configured motion commands |
| Compatible Lexium Servo Motor | Produces the mechanical movement required by the application |
| Motor Encoder | Supplies position and speed feedback |
| PLC or Motion Controller | Generates commands and coordinates machine operations |
| Pulse Command Cable | Transfers supported positioning signals |
| Servo Motor Power Cable | Connects the drive output to the motor |
| Encoder Feedback Cable | Transfers motor feedback signals to the drive |
| Digital I/O Wiring | Carries configured control and status signals |
| External Braking Resistor | Dissipates regenerative energy when required |
| Circuit Protection Devices | Protect the drive supply circuit according to the installation design |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| Schneider LXM23DU10M3X | Lexium 23 Motion Servo Drive, 1 kW | Servo axes requiring 1 kW nominal output |
| Schneider LXM23DU15M3X | Lexium 23 Motion Servo Drive, 1.5 kW | Positioning and motion applications with higher power demands |
| Schneider LXM23DU20M3X | Lexium 23 Motion Servo Drive, 2 kW | Servo axes requiring 2 kW nominal output |
| Schneider LXM23DU30M3X | Lexium 23 Motion Servo Drive, 3 kW | Higher-power positioning and motion applications |
| Schneider LXM23DU45M3X | Lexium 23 Motion Servo Drive, 4.5 kW | Applications requiring a higher nominal power rating |
Key Advantages
- Supports servo applications requiring 3 kW nominal output.
- Accepts pulse-based positioning commands from compatible controllers.
- Supports position, speed, and torque control functions.
- Provides programmable digital inputs and outputs.
- Supports analog voltage references for applicable control arrangements.
- Uses encoder feedback for closed-loop motor regulation.
- Supports three-phase AC supply within the specified voltage range.
- Accommodates external braking provisions where regenerative-energy demand requires dissipation.
Technical FAQs
What should be considered when selecting a motor for the LXM23DU30M3X?
The motor’s rated current, voltage, encoder type, and compatibility with the drive must be checked. The application also needs sufficient torque and acceleration capability for its load inertia and operating cycle. Nominal power alone is not enough to establish a suitable motor-drive combination.
Can the LXM23DU30M3X be controlled directly by a PLC?
A compatible PLC can provide the pulse commands and digital signals required by the drive. The controller’s output circuitry, pulse timing, direction logic, and command scaling must match the drive configuration. The PLC program must also coordinate movement completion with the machine sequence.
What is the practical difference between the LXM23DU30M3X and the LXM23AU30M3X?
The LXM23DU30M3X uses the I/O-oriented configuration with pulse-based positioning capability, whereas the LXM23A variant uses a CANopen interface. The appropriate choice depends on the communication architecture and the command interface available in the machine controller.
Why is braking-system selection important for a 3 kW servo axis?
A moving load can return energy to the drive during deceleration. High inertia and frequent stopping may increase regenerative-energy demand, potentially causing overvoltage faults if the energy cannot be handled adequately. The motion profile and any required external braking resistor must be selected according to the drive specifications and actual operating cycle.