ProductPRODUCT
Featured products
Contact Us
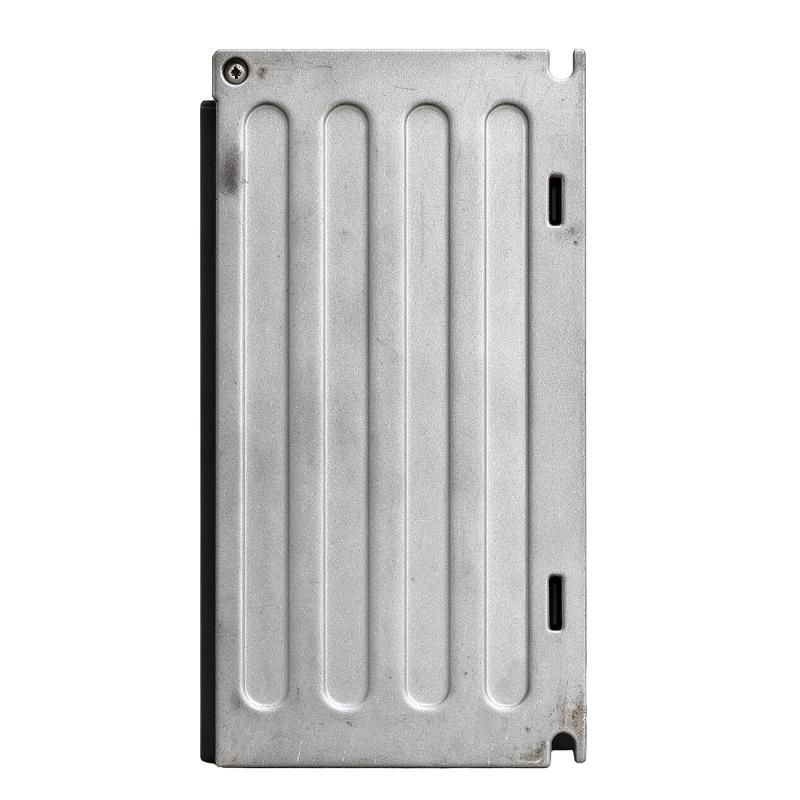
- Schneider
- LXM23AU10M3X
- Motion Servo Drive
- France
- 85 × 162 × 180 mm
- 2.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
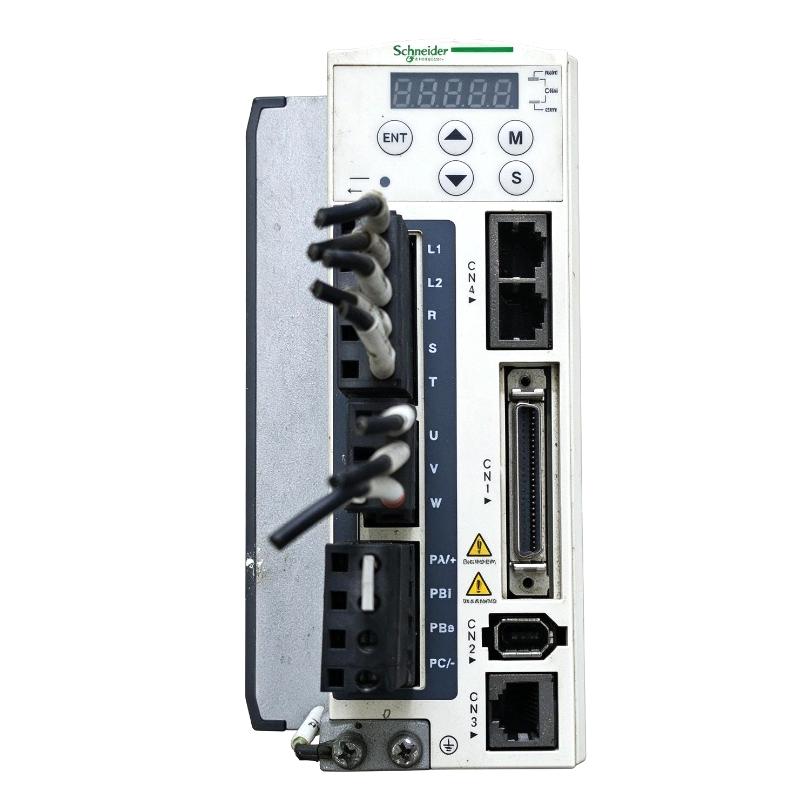
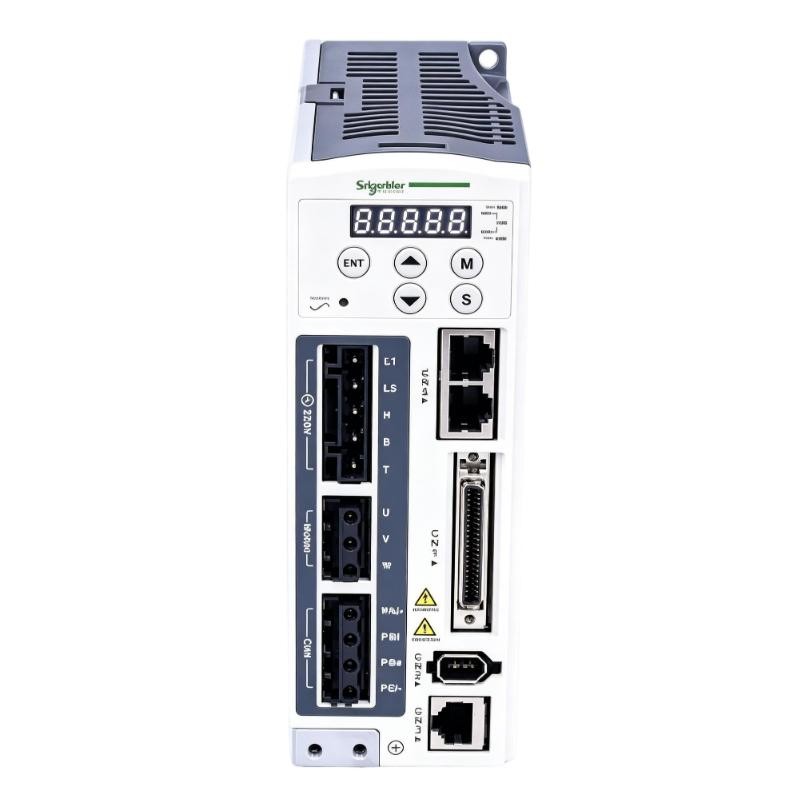
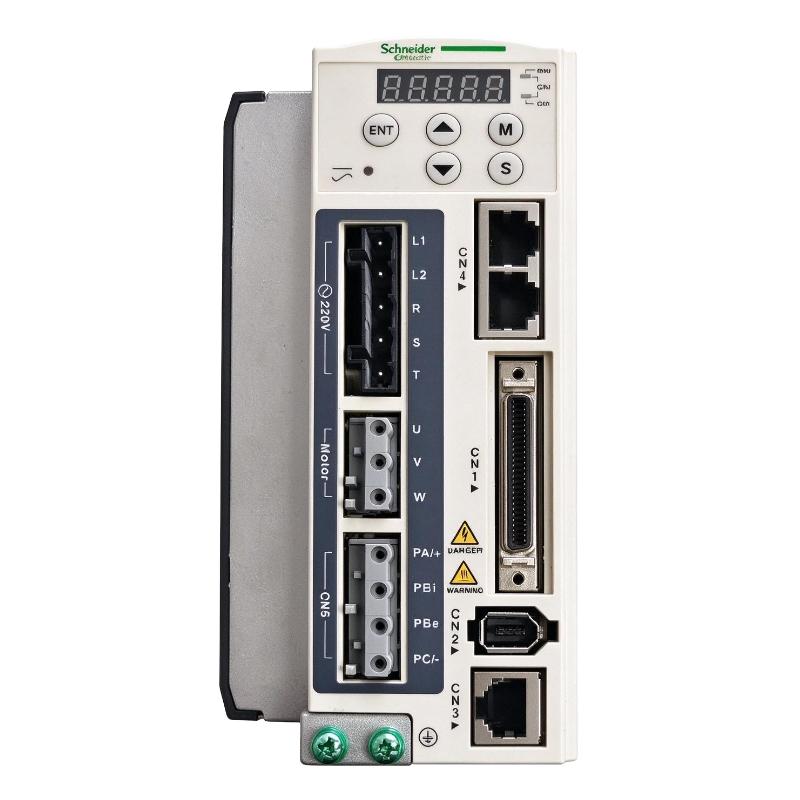
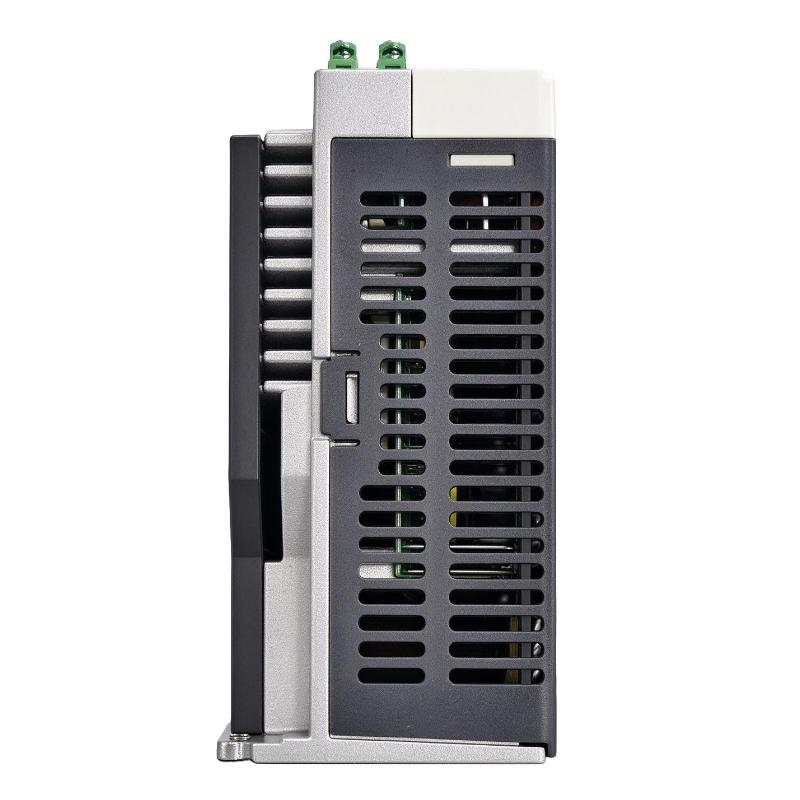
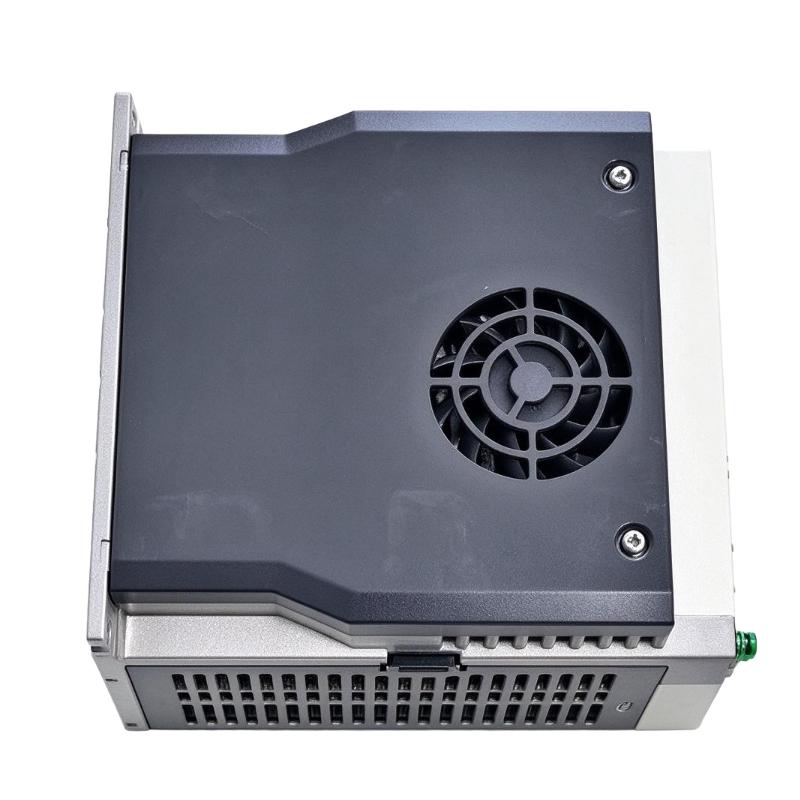
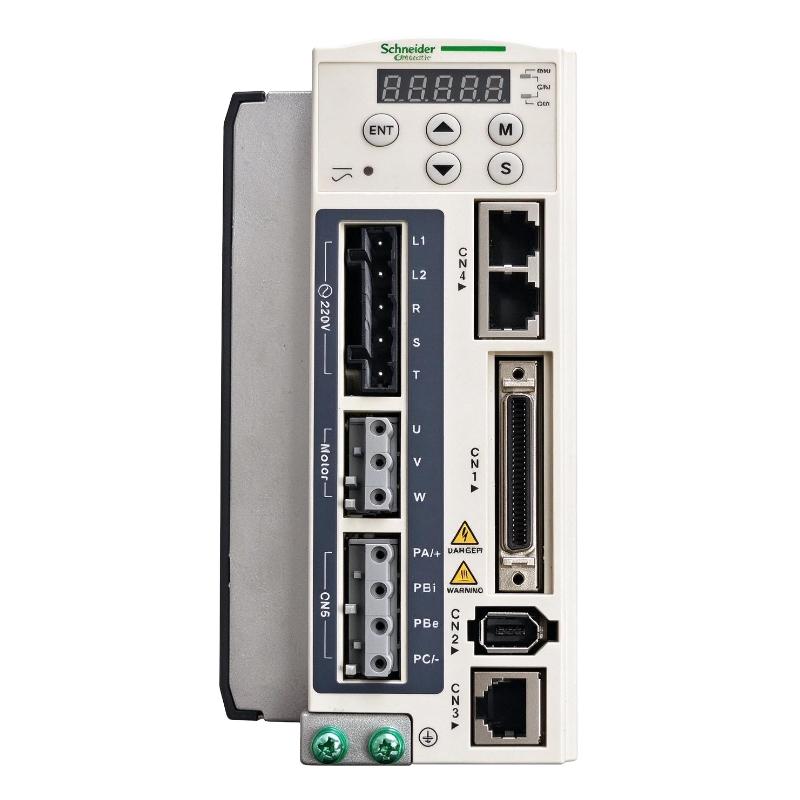
The Schneider LXM23AU10M3X Lexium 23 Motion Servo Drive is a 1 kW AC servo drive in the Lexium 23 Plus series. It operates from a single-phase 200–255 V AC supply or a compatible three-phase supply within its specified voltage range. The drive regulates a connected servo motor and supports position, speed and torque control for industrial machine axes.
This model is suited to applications requiring repeatable positioning, controlled acceleration and coordinated movement between machine mechanisms. Packaging equipment, automated assembly systems, material-handling machinery and dedicated production machines are typical applications where servo control helps maintain consistent motion throughout a production cycle.
The LXM23AU10M3X supports CANopen communication and programmable pulse-based positioning configurations. It also provides programmable digital inputs and outputs, analog command inputs and an encoder feedback interface. These features allow the drive to operate within different machine-control architectures, depending on the controller and selected operating mode.
When integrating this drive into an existing machine, engineers should verify the motor’s rated current and power, encoder compatibility, supply arrangement and communication configuration. The 1 kW rating alone does not establish compatibility with every servo motor in the same product family.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model / Part Number | LXM23AU10M3X |
| Product Family | Lexium 23 Plus |
| Product Type | Motion Servo Drive |
| Device Category | AC Servo Drive |
| Rated Motor Power | 1 kW |
| Rated Supply Voltage | 220 V AC nominal |
| Input Voltage Range | 200–255 V AC single-phase; 170–255 V AC three-phase |
| Supply Frequency | 50/60 Hz |
| Continuous Output Current | 7.3 A |
| Control Modes | Position, speed and torque |
| Communication Protocol | CANopen |
| Digital Inputs | 8 programmable inputs |
| Digital Outputs | 5 outputs |
| Analog Inputs | 2 voltage inputs |
| Analog Input Range | -10 to +10 V |
| Encoder Feedback | Servo motor encoder feedback |
| Pulse Control | Supported |
| Braking Resistor Connection | Supported |
| Mounting Orientation | Vertical |
| Protection Rating | IP20 |
| Dimensions | 85 × 162 × 180 mm |
| Weight | 2.2 kg |
Product Features
- 1 kW servo control: Supports motion axes requiring regulated motor speed, torque and position.
- Flexible supply configuration: Accepts the specified single-phase or three-phase AC supply arrangements.
- CANopen communication: Connects the drive to compatible networked motion-control systems.
- Multiple control modes: Supports position, speed and torque operation according to the application configuration.
- Programmable digital inputs: Provides eight inputs for supported control commands and machine signals.
- Digital output signals: Supplies five outputs for configured status and control functions.
- Analog command inputs: Accepts voltage references within the specified input range.
- Encoder feedback: Uses motor feedback to regulate motion in a closed-loop servo system.
- Braking resistor connection: Supports applications requiring dissipation of regenerated energy during deceleration.
- Compact cabinet installation: Fits industrial control panels with the specified mounting orientation and ventilation clearances.
Working Principle
The LXM23AU10M3X converts incoming AC power into regulated electrical output for a compatible servo motor. It processes the selected motion command, monitors motor encoder feedback and adjusts the motor current to achieve the requested movement.
In position-control mode, the drive follows a configured position command supplied through a supported pulse interface or motion-control arrangement. In speed-control mode, it regulates the motor toward the commanded rotational speed. Torque-control operation regulates the motor’s torque-producing current according to the selected command and operating limits.
The encoder feedback allows the drive to evaluate the motor’s actual response rather than relying solely on the requested command. This feedback is important when the machine must move through repeatable distances or maintain a controlled speed under changing mechanical loads.
Consider a packaging machine that uses a servo motor to advance a film or product feed mechanism. The machine controller requests a defined movement, and the LXM23AU10M3X regulates the motor to follow that command. The controller can then coordinate the feed axis with sealing, cutting or labeling operations to maintain the required production sequence.
During deceleration, the motor may return energy to the drive. If the application produces sufficient regenerated energy, a correctly selected braking resistor may be required. Its resistance, power rating and installation must follow the drive’s electrical requirements.
The final motion response depends on the connected motor, encoder feedback, drive parameters, mechanical transmission and control architecture. Incorrect configuration can result in positioning errors, unstable movement or drive faults.
Role in a Lexium 23 Servo Control System
The LXM23AU10M3X acts as the motor power and regulation stage between the machine controller and the servo motor. It receives motion commands, processes encoder feedback and adjusts motor output to execute the required axis movement.
Motion Controller / PLC → LXM23AU10M3X Servo Drive → Servo Motor → Mechanical Transmission → Machine Axis
| System Component | Function | Relationship to the Drive |
|---|---|---|
| LXM23AU10M3X Servo Drive | Regulates electrical power supplied to the motor | Executes the selected servo-control mode |
| Motion Controller / PLC | Generates machine sequences and motion commands | Coordinates the drive with other machine operations |
| Compatible Servo Motor | Converts electrical energy into mechanical movement | Executes the commanded axis motion |
| Motor Encoder | Supplies position and speed feedback | Provides feedback for closed-loop regulation |
| CANopen Network | Exchanges control and status data | Connects the drive to a compatible network master |
| Pulse Command Interface | Transfers configured positioning commands | Supports pulse-based control arrangements |
| Analog Command Source | Supplies voltage references | Can provide supported analog speed or torque-related commands |
| Motor Power Cable | Carries electrical power to the motor | Connects the drive output to the motor |
| Encoder Cable | Transfers feedback signals | Connects the motor feedback interface to the drive |
| Braking Resistor | Dissipates regenerated energy when required | Supports applications with demanding deceleration |
| Circuit Protection | Protects the incoming power circuit | Provides electrical protection according to the installation design |
| Operator HMI | Displays machine status and alarms | Presents information through the wider control system |
Industrial Applications
| Application | Typical Equipment | Role of the LXM23AU10M3X |
|---|---|---|
| Packaging Machinery | Film feeds, indexing mechanisms and sealing stations | Controls repeatable movement during production cycles |
| Automated Assembly | Positioning tables and assembly mechanisms | Regulates programmed positioning and speed |
| Material Handling | Transfer systems and sorting mechanisms | Controls movement in coordinated machine sequences |
| Labeling Equipment | Label feed and placement axes | Supports accurate, repeatable servo movement |
| Printing and Converting | Feed rollers and auxiliary positioning mechanisms | Regulates motion according to configured commands |
| Inspection Equipment | Automated positioning stages | Moves inspection components through programmed positions |
| OEM Machinery | Dedicated production machines | Provides servo control for appropriately sized motor axes |
| General Industrial Automation | Servo-driven mechanisms | Supports position, speed or torque control as required |
Installation and Maintenance
- Verify the drive reference: Confirm that LXM23AU10M3X matches the required 1 kW rating, supply configuration and communication requirements.
- Check motor compatibility: Compare the motor’s rated power, voltage, current and encoder specifications with the drive’s requirements.
- Isolate the electrical supply: Follow the equipment’s lockout procedure and allow the specified DC-bus discharge time before handling power connections.
- Prepare the cabinet: Mount the drive vertically and provide the required ventilation clearances for heat dissipation.
- Confirm the supply circuit: Check the incoming voltage, supply phase arrangement, grounding and protective devices.
- Connect the motor: Use a compatible power cable and verify the motor connections and protective earth.
- Inspect the encoder wiring: Confirm the feedback cable, connector pinout and encoder compatibility before enabling the drive.
- Configure the command interface: Select the intended CANopen, pulse-based or other supported control arrangement and configure the corresponding parameters.
- Set the motor parameters: Enter the correct motor data and review applicable speed, torque, acceleration and deceleration limits.
- Check braking requirements: Determine whether the application requires an external braking resistor and verify its electrical ratings before installation.
- Perform a controlled commissioning test: Check rotation direction, feedback response, communication and motion behavior at reduced operating demand before production use.
- Record maintenance findings: Document the drive reference, motor configuration, parameter settings, active alarms and commissioning results.
Compatible System Components
| Component | Function | Compatibility Consideration |
|---|---|---|
| Compatible Lexium Servo Motor | Provides controlled rotary motion | Match rated power, voltage, current and encoder feedback |
| Motor Encoder | Supplies position and speed feedback | Verify the encoder interface and cable arrangement |
| Motion Controller / PLC | Generates axis commands | Confirm support for the selected control method |
| CANopen Master | Coordinates networked automation devices | Verify the network configuration and communication requirements |
| Motor Power Cable | Connects the drive to the motor | Match connector type and electrical ratings |
| Encoder Cable | Transfers motor feedback signals | Confirm pin assignments and feedback compatibility |
| Braking Resistor | Dissipates regenerated energy | Select according to the drive’s permitted resistance and power specifications |
| Circuit Breaker / Protective Device | Protects the incoming supply | Follow the applicable electrical protection requirements |
| Control Cabinet | Houses the drive and associated equipment | Provide suitable ventilation and environmental protection |
| Operator HMI | Displays operating states and alarms | Integrate through the controller or supervisory system |
Recommended Related Models
| Model / Product | Product Type | Relationship | Selection Consideration |
|---|---|---|---|
| Schneider LXM23AU04M3X | Lexium 23 Motion Servo Drive | Related drive with a 400 W rating | Check whether its power and current ratings suit the motor and load |
| Schneider LXM23AU07M3X | Lexium 23 Motion Servo Drive | Related drive with a lower power rating | Verify motor sizing and supply requirements |
| Schneider LXM23AU10M3X | Lexium 23 Motion Servo Drive | Requested 1 kW drive | Match the complete model reference and control configuration |
| Schneider LXM23AU15M3X | Lexium 23 Motion Servo Drive | Related drive with a higher power rating | Check the required output current and motor ratings |
| Schneider LXM28AU10M3X | Lexium 28 Motion Servo Drive | Related 1 kW servo drive in the Lexium 28 family | Review motor compatibility, wiring, communication and commissioning requirements |
Key Advantages
- Supports 1 kW servo motor applications.
- Offers position, speed and torque control.
- Provides CANopen communication for compatible automation networks.
- Includes programmable digital and analog command interfaces.
- Supports encoder feedback and external braking-resistor integration.
Technical FAQs
How should the LXM23AU10M3X be matched to a servo motor?
Check the motor’s rated power, voltage, current and encoder interface against the drive specifications. The machine’s load inertia, required acceleration and duty cycle should also be considered when sizing the complete motion axis.
Can the drive use a three-phase power supply?
Yes. The specified input range supports single-phase 200–255 V AC and three-phase 170–255 V AC operation. The actual supply arrangement must comply with the drive’s wiring instructions and the installation’s electrical requirements.
What is the purpose of the drive’s analog inputs?
The two voltage analog inputs accept references within the specified -10 to +10 V range. Their use depends on the selected operating mode, terminal configuration and drive parameters.
What should be checked if the motor stops with a drive fault during deceleration?
Review the active fault indication, deceleration settings, mechanical load and regenerated-energy conditions. If the application requires an external braking resistor, verify its wiring and electrical ratings against the drive specifications before returning the machine to operation.