ProductPRODUCT
Featured products
Contact Us
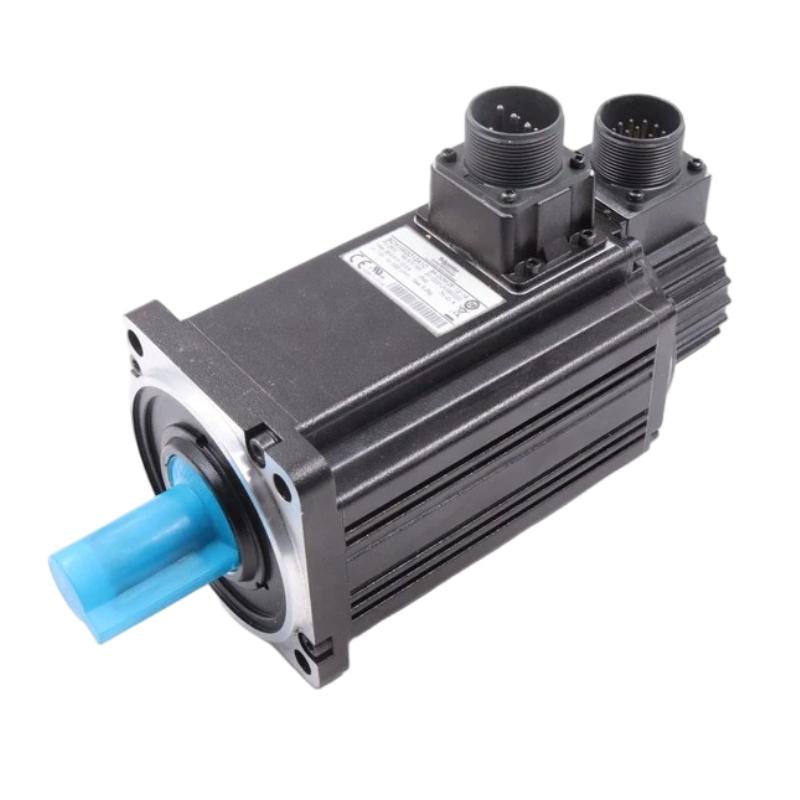
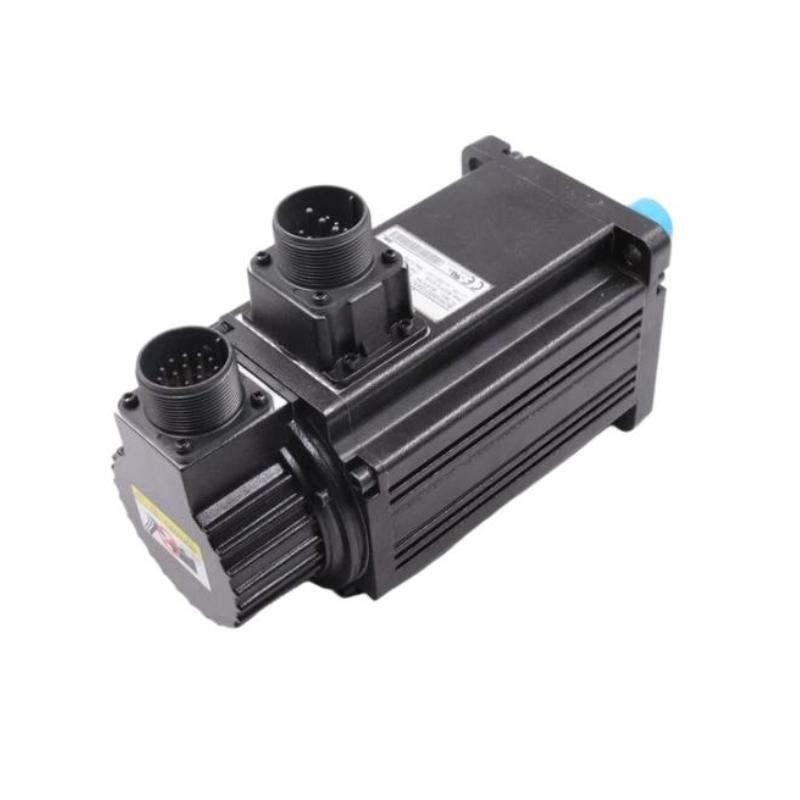
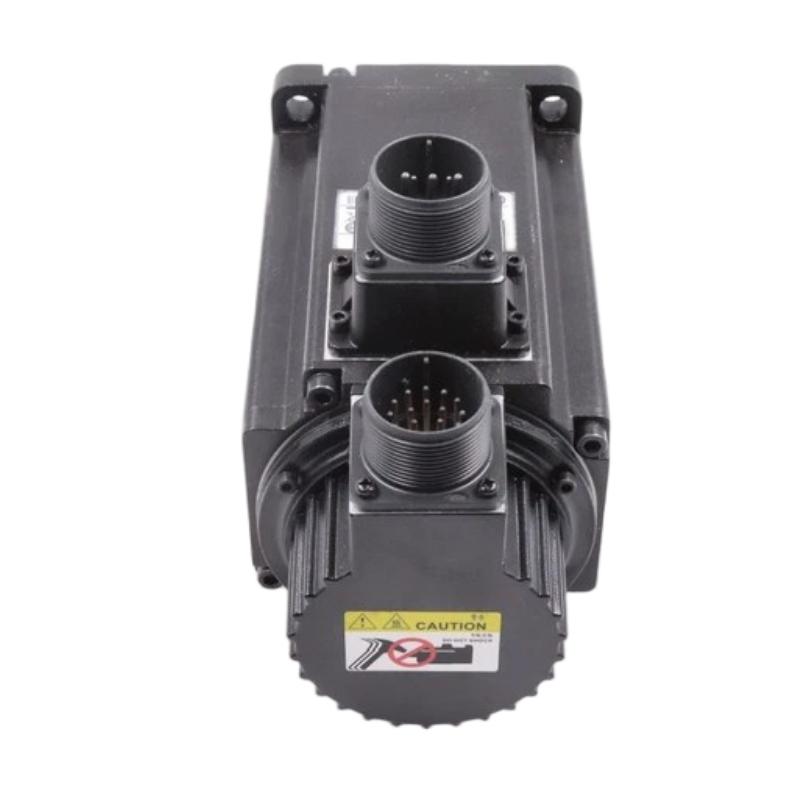
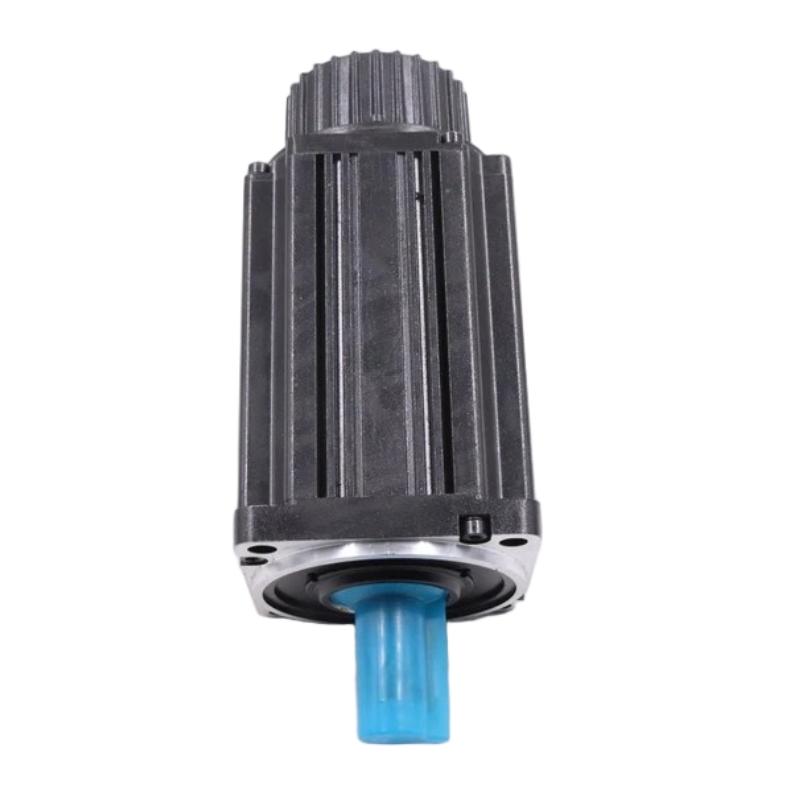
- Schneider
- BCH1002O12A1C
- Servo Motor
- France
- 199 mm
- 6.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 37
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
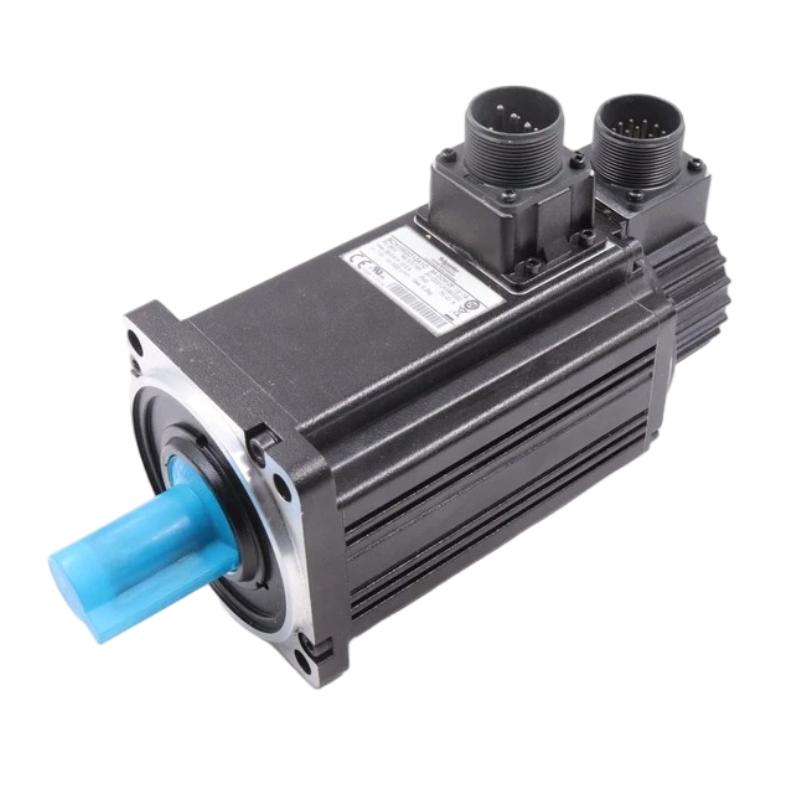
The Schneider Electric BCH1002O12A1C Servo Motor is an industrial servo motor designed for automated motion-control applications that require controlled rotation, repeatable movement, and coordinated machine operation. As part of the Schneider Electric BCH servo motor family, the motor can be integrated into a compatible servo system consisting of a servo drive, motion controller, feedback system, and mechanical load.
Servo motors are widely used in modern industrial automation because they provide closed-loop motion control rather than simple uncontrolled motor rotation. In a typical system, the controller generates a motion command, the servo drive regulates electrical power supplied to the motor, and feedback information allows the control system to compare commanded movement with actual motor behavior.
The BCH1002O12A1C has a supplied length of 199 mm and a weight of 6.2 kg. These physical parameters are important for machine design, mounting-space calculations, equipment handling, spare-parts management, and replacement planning.
The exact electrical and performance characteristics of the motor should be confirmed against the applicable Schneider Electric documentation and motor nameplate. Parameters such as rated power, rated torque, rated speed, maximum speed, encoder type, brake configuration, shaft dimensions, mounting dimensions, and connector configuration should not be inferred solely from the model number.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | BCH1002O12A1C |
| Product Type | Servo Motor |
| Product Family | BCH Servo Motor Series |
| Application | Industrial Motion Control |
| Control Architecture | Closed-Loop Servo System |
| Feedback | Compatible Servo Feedback System |
| Length | 199 mm |
| Weight | 6.2 kg |
| Installation | Machine-Mounted |
| Typical Applications | Industrial Automation, Positioning, Packaging, Handling, Assembly, Motion Control |
Specification note: Exact electrical ratings and detailed mechanical characteristics should be verified against the documentation for the specific BCH1002O12A1C motor. The dimensions and weight above are the values supplied for this product.
What Is the Schneider BCH1002O12A1C?
The Schneider BCH1002O12A1C is a servo motor intended for use in automated machinery where controlled and repeatable motor movement is required.
A servo motor does not normally operate as an independent device. It forms part of a coordinated motion-control system. The controller determines the required movement, the servo drive controls the motor, and feedback information is used to maintain the desired operating condition.
A simplified system can be represented as:
Motion Controller → Servo Drive → BCH1002O12A1C Servo Motor → Mechanical Load
The feedback path completes the closed-loop system:
Servo Motor → Feedback System → Servo Drive / Controller
This architecture allows the automation system to continuously monitor motor behavior and make control adjustments during operation.
Servo Motor Working Principle
The BCH1002O12A1C operates within a closed-loop servo-control architecture.
The motion controller first generates a command based on the programmed machine sequence. Depending on the application, this command may define a desired position, velocity, acceleration, or coordinated movement.
The servo drive receives the command and determines the electrical output required to drive the motor.
As the motor rotates, the associated feedback system provides information about actual motor movement. The servo drive compares the commanded condition with the feedback information and adjusts motor operation as required.
The general process is:
- The controller generates a motion command.
- The servo drive receives the command.
- The drive supplies controlled electrical power to the motor.
- The motor generates mechanical rotation.
- Feedback information represents actual motor movement.
- The drive compares actual and commanded conditions.
- Control output is continuously adjusted.
- The mechanical system follows the programmed motion profile.
This closed-loop process enables servo systems to provide controlled and repeatable machine movement.
Role in Industrial Automation
The BCH1002O12A1C can serve as the motor element of a complete industrial motion-control system.
In an automated machine, the motor converts electrical energy into mechanical movement. The servo drive manages the electrical control process, while the controller determines the required motion.
A complete system may include:
- PLC or motion controller
- Servo drive
- BCH1002O12A1C servo motor
- Feedback system
- Motor power cable
- Feedback cable
- Mechanical coupling
- Gearbox
- Linear actuator
- Machine mechanism
- HMI
- Safety controller
- Industrial communication network
Correct compatibility between these components is essential for reliable operation.
Industrial Applications
Packaging Machinery
Servo motors are widely used in packaging equipment where machine sections must move in a coordinated sequence. Typical applications include indexing, feeding, cutting, sealing, and positioning mechanisms.
Material Handling
Automated handling systems can use servo motors for controlled conveyor movement, positioning, transfer mechanisms, and automated loading systems.
Assembly Equipment
Servo systems can provide controlled motion for assembly machines where components or tools must be positioned repeatedly.
Machine Tools
Servo motors can be used in machine-tool systems where controlled movement and coordinated axes are required.
Robotics
Robotic mechanisms commonly use servo motors to generate controlled rotary movement.
Printing and Converting
Servo motion systems can coordinate rollers, feeders, cutting mechanisms, and other machine elements.
Textile Machinery
Controlled motor movement can be used for material feeding, synchronization, positioning, and other automated textile processes.
General Factory Automation
The motor can be incorporated into automated equipment where controlled rotary motion is required.
Servo System Architecture
A typical automation system using the BCH1002O12A1C can include several interconnected layers.
| Component | Typical Function |
|---|---|
| PLC / Motion Controller | Generates machine motion commands |
| Servo Drive | Controls motor power and closed-loop operation |
| BCH1002O12A1C | Produces mechanical rotary movement |
| Feedback System | Provides motor movement information |
| Mechanical Transmission | Transfers motor output to the machine |
| HMI | Operator control and machine monitoring |
| Safety System | Provides machine safety functions |
| Industrial Network | Transfers control and status information |
The exact system architecture depends on the machine design and selected Schneider Electric automation equipment.
Installation Guidelines
Correct installation is important for servo motor reliability and motion performance.
Before installing the BCH1002O12A1C, technicians should verify:
- Full motor model number
- Motor nameplate
- Servo drive compatibility
- Feedback configuration
- Mounting arrangement
- Shaft and coupling requirements
- Cable compatibility
- Connector configuration
- Mechanical load
- Environmental conditions
The supplied motor length is 199 mm, and the supplied weight is 6.2 kg. These values should be included in mechanical layout and handling calculations.
The complete mechanical envelope may be larger than the motor body length because of shaft projection, connectors, mounting components, and cable-clearance requirements.
Mechanical Installation
The servo motor should be mounted securely to a suitable machine structure.
Alignment
Correct shaft alignment is important. Excessive misalignment can place additional loads on bearings and mechanical couplings.
Coupling
The coupling should be appropriate for the machine application and installed according to the applicable mechanical requirements.
Load
The connected load must remain within the motor’s applicable mechanical and performance limits.
Vibration
Excessive vibration may affect bearings, feedback devices, connectors, and machine components.
Mounting Clearance
Adequate clearance should be maintained around the motor for cable routing, ventilation, inspection, and maintenance.
Exact flange dimensions, mounting-hole spacing, shaft dimensions, and other mechanical parameters should be verified from the applicable product documentation.
Servo Drive Integration
The BCH1002O12A1C should be integrated with a compatible servo drive.
The servo drive provides controlled electrical power and processes the motor feedback signal.
Before commissioning, engineers should verify:
- Motor-drive compatibility
- Motor identification
- Feedback compatibility
- Power cable compatibility
- Feedback cable compatibility
- Control interface
- Communication configuration
- Motor rotation direction
- Motion parameters
- Safety circuit status
An incorrect motor-drive combination can cause drive faults, abnormal motor operation, overheating, or feedback errors.
Commissioning Procedure
A controlled commissioning procedure can reduce startup problems.
1. Verify Motor Identification
Confirm that the installed motor is the correct BCH1002O12A1C.
2. Inspect Mechanical Installation
Check mounting hardware, shaft alignment, coupling installation, and mechanical clearance.
3. Inspect Cables
Check motor power and feedback cables for damage, loose connections, excessive bending, or incorrect routing.
4. Configure the Servo Drive
Enter or select the applicable motor configuration according to the drive and system documentation.
5. Verify Feedback
Confirm that the servo drive receives valid feedback information.
6. Test at Low Speed
Initial movement should be performed under controlled conditions.
7. Verify Rotation Direction
Confirm that motor rotation corresponds to the machine’s intended direction.
8. Test Acceleration and Deceleration
Gradually test the programmed motion profile while monitoring the machine.
9. Verify Positioning
Check that commanded and actual movement remain within the application’s required operating range.
10. Monitor the System
Observe motor temperature, drive status, vibration, noise, and alarm information during commissioning.
Troubleshooting the BCH1002O12A1C
Servo motor faults should be diagnosed as part of the complete servo system.
Motor Does Not Rotate
Possible causes include:
- Servo drive not enabled
- Active safety circuit
- Incorrect motor configuration
- Missing motor power
- Feedback fault
- Cable or connector problem
- Incorrect motion command
- Mechanical obstruction
Drive diagnostics should be checked before assuming that the motor itself has failed.
Servo Drive Faults During Acceleration
Possible causes can include:
- Excessive acceleration demand
- Excessive mechanical load
- Incorrect motor parameters
- Feedback problems
- Cable problems
- Incorrect servo tuning
- Mechanical resistance
Testing with a controlled motion profile can help determine whether the issue is electrical, mechanical, or configuration-related.
Positioning Accuracy Problems
Possible causes include:
- Incorrect tuning
- Mechanical backlash
- Coupling problems
- Mechanical slippage
- Excessive load
- Feedback abnormalities
- Incorrect motion parameters
Both the servo system and mechanical transmission should be inspected.
Excessive Motor Temperature
Possible causes include:
- Excessive mechanical load
- High operating duty
- Poor heat dissipation
- Mechanical friction
- Incorrect drive configuration
- Excessive acceleration or deceleration
Temperature should always be evaluated against the applicable motor specifications.
Abnormal Noise or Vibration
Inspect:
- Motor mounting
- Shaft alignment
- Coupling
- Mechanical load
- Bearings
- Transmission components
- Servo tuning
Mechanical causes should be eliminated before making unnecessary control-parameter changes.
Preventive Maintenance
Regular inspection can help maintain stable servo performance.
Check Motor Connections
Inspect power and feedback connectors for looseness, contamination, damage, or excessive mechanical stress.
Inspect Mechanical Couplings
Check coupling alignment and mounting condition periodically.
Monitor Vibration
Changes in vibration can indicate mechanical wear, misalignment, imbalance, or bearing-related problems.
Monitor Temperature
Unexpected temperature increases may indicate excessive loading, mechanical resistance, or cooling problems.
Review Servo Diagnostics
Drive alarms and historical fault information can provide useful clues when investigating developing problems.
Maintain a Clean Environment
Dust, oil, moisture, and other contaminants should be controlled according to the environmental requirements of the equipment.
Replacement Considerations
When replacing the Schneider BCH1002O12A1C Servo Motor, technicians should verify the complete model designation before installation.
Important information includes:
- Full motor model
- Nameplate data
- Motor family
- Feedback configuration
- Brake configuration, where applicable
- Shaft arrangement
- Mounting configuration
- Connector arrangement
- Compatible servo drive
- Machine load requirements
The supplied 199 mm length and 6.2 kg weight are useful for mechanical planning but are not sufficient to establish electrical or functional compatibility.
A motor with similar physical dimensions may have different electrical, feedback, or mechanical characteristics.
Physical Dimensions and Handling
The supplied physical specifications for the BCH1002O12A1C are:
Length: 199 mm
Weight: 6.2 kg
These values are useful for:
- Machine layout
- Mounting-space planning
- Spare-parts management
- Transportation planning
- Installation handling
- Replacement preparation
- Equipment inventory
When designing a mounting arrangement, engineers should account for the complete motor envelope rather than using body length alone. Shaft projection, connectors, cables, mounting hardware, and required service clearance can affect the actual installation space.
Engineering Best Practices
Match Motor and Servo Drive
The servo drive should be selected and configured for the exact motor and feedback arrangement.
Protect Feedback Connections
Feedback signals are critical to closed-loop control. Secure connectors and suitable cable routing can help prevent intermittent feedback faults.
Maintain Mechanical Alignment
Correct alignment reduces unnecessary bearing and coupling loads.
Evaluate the Complete Motion Profile
Motor selection and configuration should consider acceleration, deceleration, load inertia, operating cycle, and required machine movement.
Record Commissioning Parameters
Motor identification, drive configuration, motion parameters, and commissioning results should be documented for future maintenance.
Perform Controlled Startup
Initial commissioning should be conducted at controlled machine conditions before the equipment is placed into full production operation.
Compatible Automation Components
Depending on the machine architecture, the BCH1002O12A1C may be integrated into a Schneider Electric automation system containing:
- Compatible Schneider Electric servo drives
- Modicon PLC systems
- Motion controllers
- Industrial HMIs
- Industrial communication systems
- Machine safety equipment
- Servo feedback interfaces
- Motor power cables
- Feedback cables
- Mechanical couplings
- Gearboxes
- Linear motion mechanisms
Exact compatibility should be confirmed for the specific motor, drive, feedback system, and machine configuration.
Recommended Related Schneider Product Categories
| Product Category | General Function |
|---|---|
| Schneider BCH Servo Motors | Industrial servo motion |
| Schneider Servo Drives | Closed-loop motor control |
| Schneider Motion Controllers | Coordinated motion commands |
| Schneider Modicon PLCs | Machine and process control |
| Schneider HMIs | Operator interface |
| Schneider Safety Controllers | Machine safety functions |
These categories represent related automation equipment rather than direct replacement recommendations for the BCH1002O12A1C.
Key Advantages
- Designed for industrial servo motion applications
- Suitable for closed-loop automation architectures
- Supports controlled and repeatable rotary movement
- Can be integrated with compatible Schneider servo drives
- Supplied length of 199 mm
- Supplied weight of 6.2 kg
- Suitable for automated positioning applications
- Applicable to packaging, assembly, handling, and manufacturing equipment
- Supports coordinated machine motion
- Suitable for integration into Schneider Electric automation environments
Technical FAQs
What is the Schneider BCH1002O12A1C?
The Schneider BCH1002O12A1C is a Schneider Electric servo motor designed for use in industrial motion-control systems.
What is the length of the BCH1002O12A1C?
The supplied length is 199 mm.
How much does the BCH1002O12A1C weigh?
The supplied weight is 6.2 kg.
What is the BCH1002O12A1C used for?
It is intended for industrial automation applications requiring controlled rotary motion, positioning, speed regulation, and coordinated machine movement.
Does the BCH1002O12A1C require a servo drive?
A servo motor is normally operated together with a compatible servo drive that controls motor power and processes feedback information.
What should be checked before replacing the motor?
The complete model number, feedback configuration, brake configuration where applicable, shaft arrangement, mounting configuration, connectors, motor cables, and servo-drive compatibility should be checked.
Are the 199 mm length and 6.2 kg weight enough to identify a replacement?
No. These physical values are useful for mechanical planning, but they do not establish electrical, feedback, or motion-system compatibility.
What can cause a servo motor to overheat?
Possible causes include excessive mechanical load, high duty cycle, inadequate heat dissipation, mechanical friction, incorrect configuration, or unsuitable operating conditions.
What can cause positioning errors?
Positioning errors can be related to servo tuning, feedback problems, mechanical backlash, coupling issues, excessive load, incorrect motion parameters, or other mechanical and control-system problems.
Conclusion
The Schneider Electric BCH1002O12A1C Servo Motor is an industrial servo motor designed to operate as part of a closed-loop motion-control system. When correctly integrated with a compatible servo drive, feedback system, controller, and mechanical load, it can provide controlled and repeatable rotary movement for automated machinery.
The supplied physical specifications are 199 mm in length and 6.2 kg in weight. These values are useful for machine layout, installation planning, transportation, inventory management, and replacement preparation.
For reliable operation, the BCH1002O12A1C should be evaluated as part of the complete servo architecture. Correct motor-drive matching, proper mechanical alignment, secure feedback connections, appropriate commissioning, and preventive maintenance all contribute to stable motion performance.
When purchasing or replacing the BCH1002O12A1C, the complete model designation and applicable technical documentation should be checked carefully. Exact electrical ratings, feedback characteristics, shaft dimensions, mounting details, brake configuration, and performance parameters should be verified for the specific motor before final installation.