ProductPRODUCT
Featured products
Contact Us
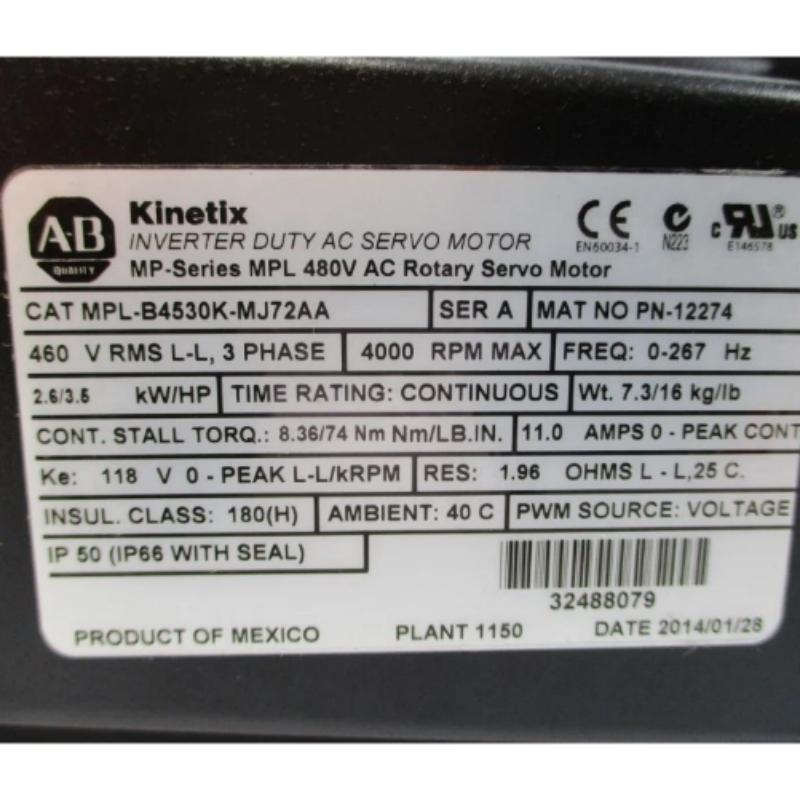
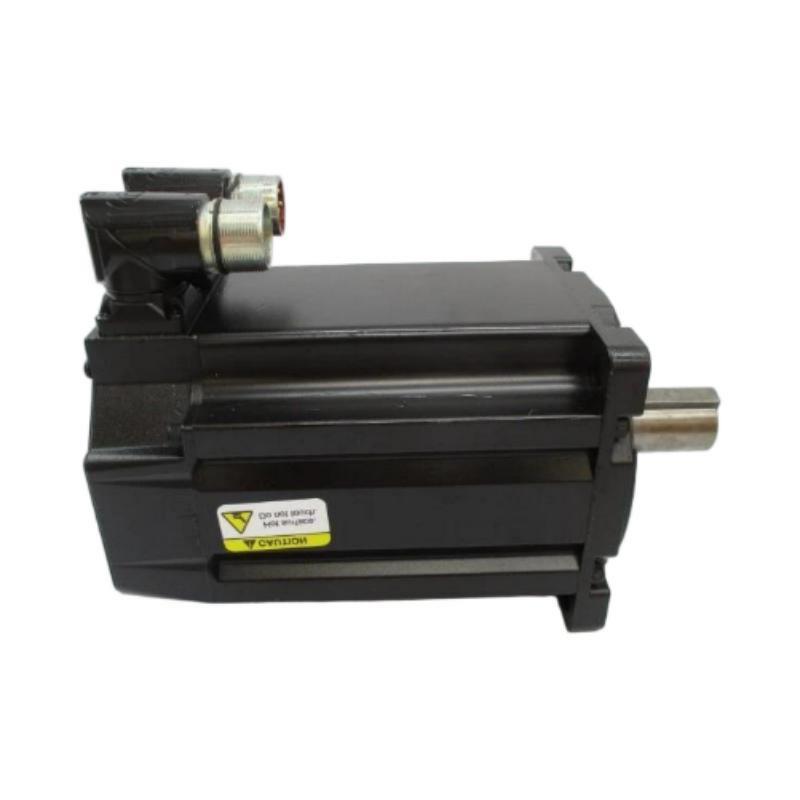
- Allen Bradley
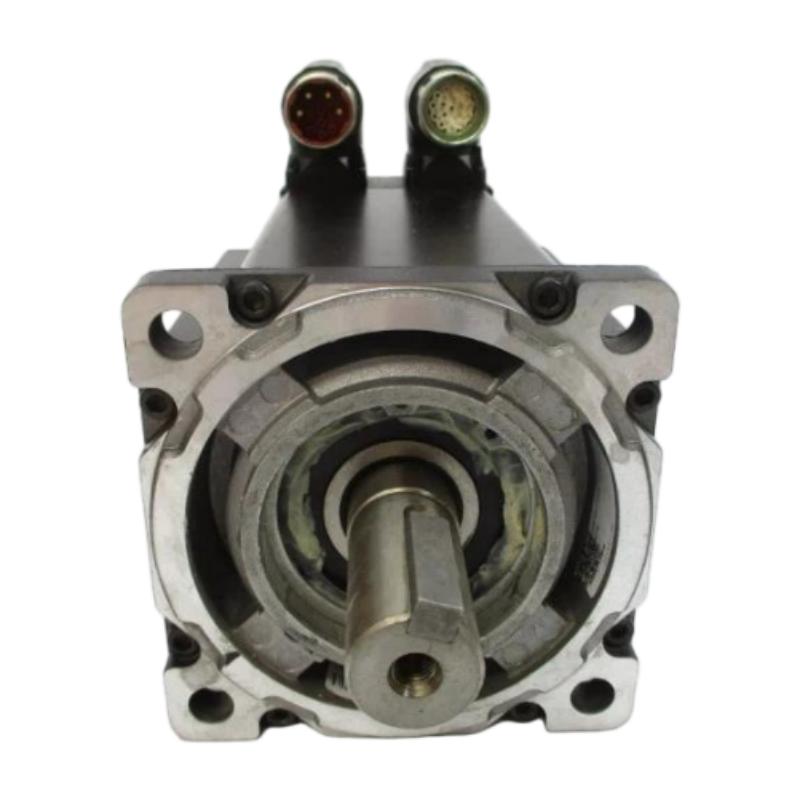
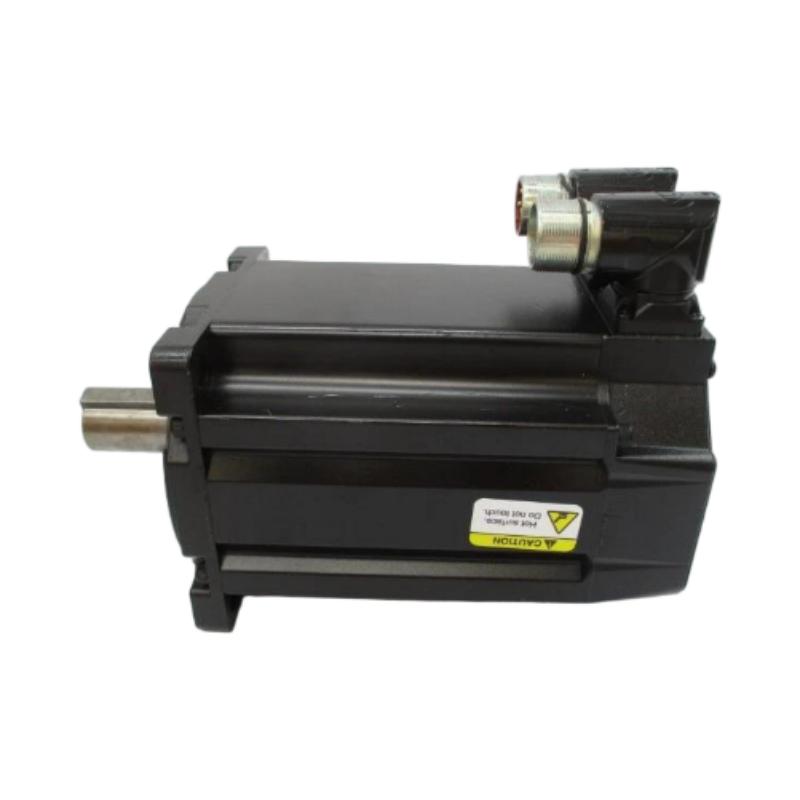
- MPL-B4530K-MJ72AA
- Servo Motor
- USA
- 130 mm
- 7.3 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 3
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
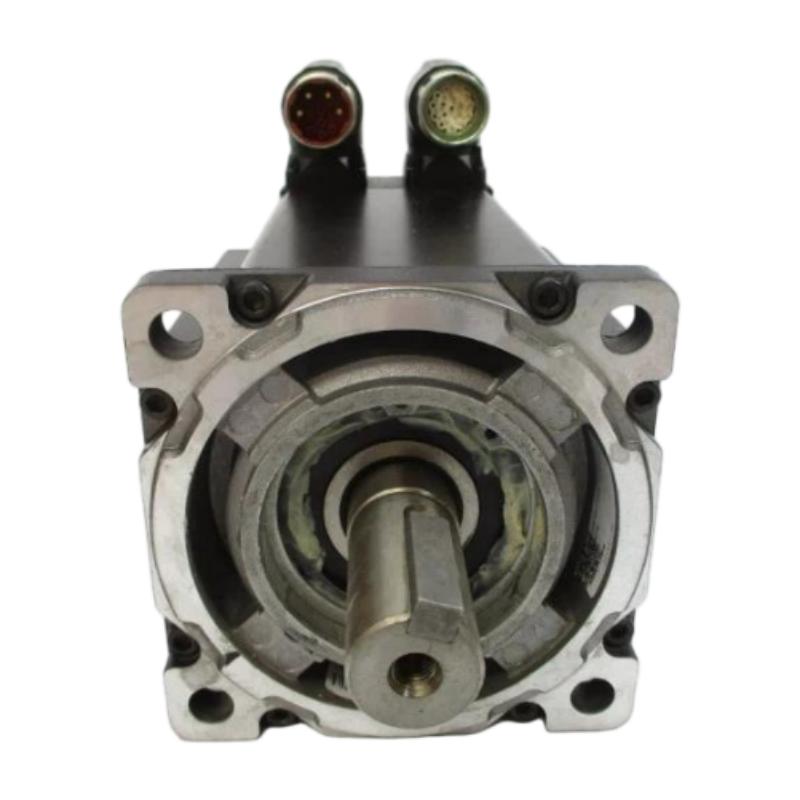
The Allen Bradley MPL-B4530K-MJ72AA Servo Motor is an industrial motion-control component identified within the Allen-Bradley MP-Series servo motor family. Servo motors are designed for applications requiring controlled rotation, repeatable positioning, coordinated movement, and accurate response to commands from a compatible motion controller or servo drive.
In modern industrial automation, servo motors play an important role in converting electrical energy into controlled mechanical motion. They are commonly used in packaging machinery, material handling equipment, automated assembly systems, machine tools, and other applications where conventional motor operation may not provide the required positioning accuracy or dynamic response.
The MPL-B4530K-MJ72AA is specified with a 130 mm frame size and a weight of 7.3 kg. These physical characteristics are useful when planning machine layouts, evaluating mounting arrangements, preparing replacement equipment, and managing industrial spare-parts inventories.
A servo motor normally operates as part of a complete motion-control system. The servo drive supplies controlled electrical power, while feedback and command signals allow the system to regulate motor movement according to the application requirements. The exact drive pairing, feedback configuration, rated power, torque, speed, shaft design, and connector arrangement for the MPL-B4530K-MJ72AA should be verified against the complete product identification and applicable technical documentation before installation.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Allen-Bradley |
| Brand Owner | Rockwell Automation |
| Model | MPL-B4530K-MJ72AA |
| Product Type | AC Servo Motor |
| Product Family | MP-Series Servo Motors |
| Frame Size | 130 mm |
| Weight | 7.3 kg |
| Primary Function | Controlled rotary motion for industrial automation |
| Control Method | Servo drive-based motion control |
| Feedback System | Verify the exact motor configuration |
| Rated Power | Confirm from the applicable motor specification |
| Rated Torque | Confirm from the applicable motor specification |
| Rated Speed | Confirm from the applicable motor specification |
| Shaft and Mounting Details | Verify against the exact model |
| Electrical Connections | Confirm connector and wiring specifications |
| Typical Applications | Automated machinery, positioning systems, and motion-control equipment |
The table distinguishes the supplied physical specifications from electrical and performance data that require confirmation. Servo motors with similar model designations can have different winding characteristics, feedback options, connectors, or mechanical configurations, so the complete catalog identification should be checked before selecting a drive or replacement.
What Is the Allen Bradley MPL-B4530K-MJ72AA Servo Motor?
A servo motor is an electrically controlled motor used when a machine needs to regulate movement rather than simply run at a fixed operating condition. Depending on the system design, the motor can be commanded to move to a target position, maintain a specified speed, or produce controlled torque.
The MPL-B4530K-MJ72AA is identified as a servo motor within the Allen-Bradley MP-Series family. Its role in an automation installation is to convert commands from a compatible servo drive into mechanical movement.
A typical servo-control arrangement contains several interconnected elements:
- A PLC or motion controller generates motion commands.
- A compatible servo drive regulates the motor’s electrical power.
- The servo motor produces rotary movement.
- A feedback device, when provided by the motor configuration, supplies information used by the control system.
- Mechanical transmission components transfer motor movement to the machine load.
The complete system must be configured as a matched combination. A motor should not be selected solely by frame size or physical appearance because electrical characteristics and feedback compatibility are equally important.
Servo Motor Working Principle
1. Motion Command Generation
The process begins when the controller issues a motion command. Depending on the application, the command may specify a target position, velocity, acceleration profile, or torque requirement.
For example, a packaging machine may require a feed mechanism to advance a precise distance before the next operation begins. The controller determines the movement sequence and sends the appropriate command to the motion-control system.
2. Drive-Based Power Regulation
The servo drive receives the command and regulates the electrical power supplied to the motor. It adjusts motor operation according to the configured control mode and the requirements of the connected application.
The drive must be suitable for the exact motor’s voltage, current, feedback, and performance characteristics. Using an incompatible drive can prevent correct operation or damage equipment.
3. Electromagnetic Torque Production
Electrical current in the motor windings creates electromagnetic forces that produce rotational torque. The motor’s mechanical output then drives the connected load through a direct coupling, gearbox, belt, screw mechanism, or other transmission arrangement.
The appropriate mechanical interface depends on the machine design and the motor’s actual shaft and mounting specifications.
4. Feedback and Motion Regulation
Where the motor configuration includes a compatible feedback device, the servo system can use feedback information to evaluate motor position or speed. The drive compares the commanded behavior with the measured response and adjusts its output to reduce the control error.
This closed-loop approach helps the machine achieve repeatable movement and respond to changing load conditions within the limits of the configured system.
5. Coordinated Machine Operation
When integrated with a suitable controller, servo motors can participate in coordinated motion sequences involving several axes or mechanisms. The controller manages the required sequence, while each drive and motor executes its assigned movement.
The achievable accuracy, speed, and dynamic performance depend on the complete system, including the motor, drive, feedback device, mechanical transmission, tuning, and load.
Role in Industrial Motion-Control Systems
The Allen-Bradley MPL-B4530K-MJ72AA can serve as the mechanical output element in a compatible servo-control arrangement. Its function is different from that of a PLC, which executes logic, or a servo drive, which regulates motor power.
| System Component | Main Responsibility |
|---|---|
| PLC or Motion Controller | Generates machine logic and motion commands |
| Servo Drive | Controls the electrical power delivered to the motor |
| Servo Motor | Converts electrical energy into mechanical movement |
| Feedback Device | Supplies motion information when included in the motor configuration |
| Mechanical Coupling | Transfers torque to the driven mechanism |
| Gearbox or Transmission | Adjusts speed and torque when required |
| HMI Panel | Provides operator commands, status, and alarms |
| Industrial Network | Exchanges commands and status data when supported |
| Machine Load | Performs the required production or handling operation |
The exact components and communication architecture depend on the installed automation platform. Confirm the motor’s complete identification and drive compatibility before preparing a replacement package.
Industrial Applications
Packaging and Filling Machinery
Servo motors can control product feeding, indexing, cutting, sealing, and positioning mechanisms. Repeatable movement helps coordinate machine operations and maintain consistent production cycles.
Automated Assembly Equipment
Assembly systems may use servo-driven mechanisms to position components, move tooling, and coordinate workstations. The required motion profile depends on the mechanical design and production process.
Material Handling
Servo systems can support controlled movement in transfer mechanisms, positioning tables, automated handling equipment, and other machinery requiring repeatable positioning.
Machine Tools
In suitable machine-tool architectures, servo motors provide controlled movement for feed axes and other mechanisms. The required performance depends on the application, mechanical transmission, controller, and drive configuration.
Printing and Converting Machinery
Printing, labeling, and converting equipment can use servo control to coordinate rollers, feed mechanisms, cutting assemblies, and other moving components.
Automated Production Lines
Servo motors can support synchronized movement between machine stations. A controller coordinates the motion sequence, while the drive and motor provide the mechanical response required by the process.
These examples describe common servo-motor applications. Actual suitability of the MPL-B4530K-MJ72AA depends on its verified electrical and mechanical specifications and the requirements of the target machine.
Installation and Mechanical Integration
Correct installation is essential for dependable motor operation, accurate motion control, and long service life.
Confirm the Motor Identification
Before installation, inspect the motor nameplate and confirm the complete model number MPL-B4530K-MJ72AA. Check for any revision, configuration, or nameplate information relevant to replacement.
Do not assume that motors with similar MP-Series designations share the same winding, feedback, or connection characteristics.
Check Mounting Compatibility
The supplied frame size is 130 mm. Confirm the mounting dimensions, pilot diameter, bolt pattern, shaft dimensions, and available installation clearance using the applicable motor drawing.
The frame-size designation alone is not sufficient to determine every mechanical mounting measurement.
Evaluate the Driven Load
Before coupling the motor to a machine, evaluate the load inertia, required torque, operating speed, acceleration, deceleration, and duty cycle. The motor and drive must be capable of handling the required motion profile.
Excessive load inertia or unsuitable mechanical transmission can affect response, stability, and positioning performance.
Align the Coupling
Misalignment between the motor shaft and driven equipment can create vibration, bearing loads, noise, and premature wear. Follow the mechanical equipment manufacturer’s alignment tolerances and coupling requirements.
Avoid applying impact loads to the motor shaft during installation. Use suitable tools and handling procedures to protect the shaft, bearings, and mounting surfaces.
Protect Cables and Connectors
Route motor power and feedback cables according to the drive and motor installation requirements. Prevent cables from being crushed, sharply bent, exposed to abrasion, or routed in a manner that compromises electrical noise control.
Confirm connector type, pin assignment, cable compatibility, grounding, and shielding requirements before energizing the system.
Servo Drive and Controller Compatibility
A servo motor must be paired with a drive that supports its electrical and feedback characteristics. The model designation alone should not be used to select a specific drive or controller.
Before integration, verify:
- Motor rated voltage and current
- Rated and peak torque
- Rated and maximum speed
- Feedback-device type and compatibility
- Motor power connector and feedback connector
- Drive firmware and parameter requirements
- Controller and motion-network compatibility
- Motor thermal protection requirements
- Required cable assemblies and accessories
Allen-Bradley motion systems may include compatible servo drives, PLCs, motion controllers, engineering software, operator interfaces, and industrial communication equipment. The exact products required for the MPL-B4530K-MJ72AA must be determined from the verified motor specification and the installed system architecture.
Commissioning and Initial Testing
Commissioning should be performed by qualified personnel using the procedures applicable to the motor, drive, and machine.
Pre-Power Inspection
Confirm the motor mounting, coupling alignment, cable connections, grounding, protective devices, and machine operating clearances. Ensure that the driven mechanism can move safely within its permitted travel range.
Verify Drive Configuration
Enter the correct motor parameters and select the appropriate feedback configuration according to the drive’s supported setup procedure. Do not copy parameters from a similar motor unless the manufacturer documentation confirms that the settings are applicable.
Conduct a Controlled Initial Test
Where the machine design permits, conduct an initial movement test under controlled conditions. Observe motor direction, abnormal vibration, unexpected movement, noise, and drive alarms.
Keep personnel clear of moving machinery and verify that guarding and machine safety functions are in place before testing.
Confirm Motion Performance
After the initial test, verify that the motor follows the commanded direction and motion profile. Check acceleration, deceleration, stopping behavior, and position response against the machine’s acceptance criteria.
Record the Final Configuration
Document the motor model, drive model, parameter settings, wiring arrangement, commissioning results, and any observed limitations. Accurate records simplify future maintenance and replacement.
Troubleshooting the MPL-B4530K-MJ72AA Servo Motor
Motor faults should be investigated as part of the complete motion-control system. A drive alarm or movement problem does not automatically mean that the motor itself has failed.
Motor Does Not Rotate
Possible causes include:
- Missing or incorrect drive power
- Drive disabled or not ready
- Active drive fault
- Incorrect command configuration
- Incompatible motor parameters
- Disconnected power or feedback cable
- Mechanical obstruction
- Incorrect controller configuration
Check the drive’s status and fault information first. Verify the command path, power connections, motor configuration, and mechanical freedom of movement according to the approved maintenance procedure.
Motor Rotates in the Wrong Direction
Unexpected rotation can result from command configuration, direction settings, axis mapping, or an incorrect machine-control setup.
Review the controller and drive configuration before changing wiring or parameters. Perform direction tests only under controlled conditions and in accordance with the machine’s commissioning procedure.
Positioning Is Inaccurate
Positioning errors may be associated with feedback problems, incorrect motion scaling, unsuitable tuning, mechanical backlash, coupling slippage, load variation, or incorrect motor configuration.
Compare commanded and measured movement where diagnostic information is available. Inspect the mechanical transmission and verify the feedback configuration before replacing the motor.
Vibration or Unusual Noise
Possible causes include shaft misalignment, mechanical looseness, excessive load inertia, bearing wear, resonance, unsuitable tuning, or damage to the driven mechanism.
Inspect the installation and load system before adjusting servo gains. Changes to tuning parameters should be based on the drive manufacturer’s procedure and the machine’s mechanical characteristics.
Motor or Drive Overheating
Overheating may be caused by excessive load, frequent acceleration, insufficient cooling, incorrect motor parameters, high ambient temperature, or a mechanical problem.
Review the operating duty cycle and load requirements. Confirm that the motor and drive are configured for the actual application and that the cooling arrangement meets the installation requirements.
Intermittent Drive Faults
Intermittent faults may result from loose connectors, damaged cables, electrical interference, unstable power, feedback interruptions, or mechanical overloads.
Record the fault codes and operating conditions before clearing alarms. Inspect connectors and cable routes, then follow the relevant diagnostic procedure to identify the cause.
Maintenance Recommendations
Regular inspection helps maintain reliable operation and identify developing problems before they interrupt production.
Inspect the motor exterior: Check for contamination, physical damage, loose mounting hardware, and signs of overheating.
Check mechanical alignment: Inspect the coupling, shaft connection, mounting bolts, and driven equipment for wear or looseness.
Examine cables and connectors: Look for damaged insulation, loose connections, abrasion, and contamination.
Review drive diagnostics: Monitor recurring alarms and operating trends where the connected drive supports these functions.
Check the operating load: Investigate changes in cycle time, acceleration, noise, vibration, or load conditions that may indicate a developing mechanical issue.
Maintain a clean environment: Follow the applicable environmental and cooling requirements for the motor and the surrounding machinery.
Document maintenance activity: Record inspections, fault codes, replaced components, parameter changes, and commissioning results.
Maintenance should follow the manufacturer’s requirements and the actual operating conditions. Avoid disassembling the motor or replacing internal components without the appropriate technical procedure and equipment.
Compatible System Components
A complete servo-control installation may contain the following component categories. Specific model compatibility must be verified for the MPL-B4530K-MJ72AA.
| Component Category | Function |
|---|---|
| Compatible Allen-Bradley Servo Drive | Regulates motor power and motion |
| PLC or Motion Controller | Generates control commands |
| Motor Power Cable | Transfers electrical power from the drive |
| Feedback Cable | Carries feedback signals when required |
| Motion Network Components | Support communication where the selected architecture requires them |
| HMI or Operator Interface | Displays status and provides operator interaction |
| Mechanical Coupling | Connects the motor to the load |
| Gearbox or Transmission | Matches motor output to the application |
| Protective Devices | Provide protection as specified by the system design |
| Engineering Software | Supports configuration, diagnostics, and commissioning |
This list identifies functional component types rather than guaranteed compatible part numbers. The exact motor, drive, cable, controller, and feedback combination must be confirmed before procurement or installation.
Replacement and Procurement Considerations
When sourcing a replacement for the Allen Bradley MPL-B4530K-MJ72AA Servo Motor, verify both the model designation and the mechanical and electrical configuration.
Important checks include:
- Complete motor model number
- Nameplate and revision information
- Frame size and mounting dimensions
- Shaft and coupling configuration
- Rated voltage, current, torque, and speed
- Feedback-device specification
- Power and feedback connector arrangement
- Compatible servo drive
- Cable and accessory requirements
- Product condition and applicable testing records
The supplied 130 mm frame size and 7.3 kg weight are useful for initial mechanical planning, shipping, handling, and spare-parts management. However, neither measurement establishes electrical compatibility.
For an installed machine, compare the replacement with the original motor and confirm the drive configuration before returning the equipment to service. If the exact motor variant is unavailable, an alternative should be selected only after its electrical, feedback, mechanical, and control-system compatibility has been established.
Key Advantages of Servo Motor Technology
Controlled Mechanical Movement
Servo systems support controlled position, speed, and torque behavior when paired with a suitable drive and controller.
Repeatable Positioning
Feedback-based control, where supported by the configured motor system, helps machines execute repeatable movement sequences.
Integration with Automated Machinery
Servo motors can operate as part of a broader control architecture containing PLCs, motion controllers, drives, and operator interfaces.
Flexible Motion Profiles
The motion controller and servo drive can be configured for application-specific acceleration, deceleration, speed, and positioning requirements within system limits.
Compact Physical Specifications
The supplied 130 mm frame size and 7.3 kg weight provide useful reference information for equipment layout, handling, and replacement planning.
Technical FAQs
What is the Allen Bradley MPL-B4530K-MJ72AA?
It is identified as an Allen-Bradley MP-Series servo motor intended for controlled rotary motion in compatible industrial automation systems.
What is the frame size of this servo motor?
The supplied frame size is 130 mm. Detailed mounting dimensions should be confirmed using the applicable motor drawing.
How much does the MPL-B4530K-MJ72AA weigh?
The supplied weight is 7.3 kg.
Does the motor require a servo drive?
A servo motor generally operates with a compatible servo drive that regulates the electrical power and executes the required motion-control functions. The appropriate drive must be selected using the exact motor specifications.
What applications can use a servo motor?
Common applications include packaging, automated assembly, material handling, machine tools, printing equipment, and other machinery requiring controlled movement. Suitability depends on the motor’s verified performance ratings and the application’s load requirements.
What can cause inaccurate positioning?
Possible causes include feedback problems, incorrect configuration, unsuitable tuning, mechanical backlash, coupling slippage, load changes, and faults in the drive or controller.
Can another MP-Series motor replace the MPL-B4530K-MJ72AA?
Not automatically. A substitute must match the required electrical characteristics, feedback configuration, mounting dimensions, shaft arrangement, drive compatibility, and application performance.
What should be checked before installing a replacement?
Confirm the full model number, nameplate information, mounting and shaft dimensions, electrical ratings, feedback interface, cable requirements, and compatible drive. After installation, perform the required commissioning and functional tests.
Conclusion
The Allen Bradley MPL-B4530K-MJ72AA Servo Motor is an industrial motion-control component identified within the MP-Series family. In a properly configured system, a servo motor converts electrical power into controlled rotary movement, allowing automated equipment to perform positioning, synchronization, and repeatable motion sequences.
With a supplied 130 mm frame size and a weight of 7.3 kg, the MPL-B4530K-MJ72AA provides useful physical reference data for equipment design, replacement planning, and spare-parts inventory. Successful integration depends on matching the motor with a compatible drive, controller, feedback arrangement, mechanical transmission, and application load.
Before procurement or commissioning, verify the complete model designation and the applicable electrical and mechanical specifications. Careful compatibility checks, correct installation, controlled testing, and systematic maintenance help support reliable motion control and reduce avoidable equipment downtime.