ProductPRODUCT
Featured products
Contact Us
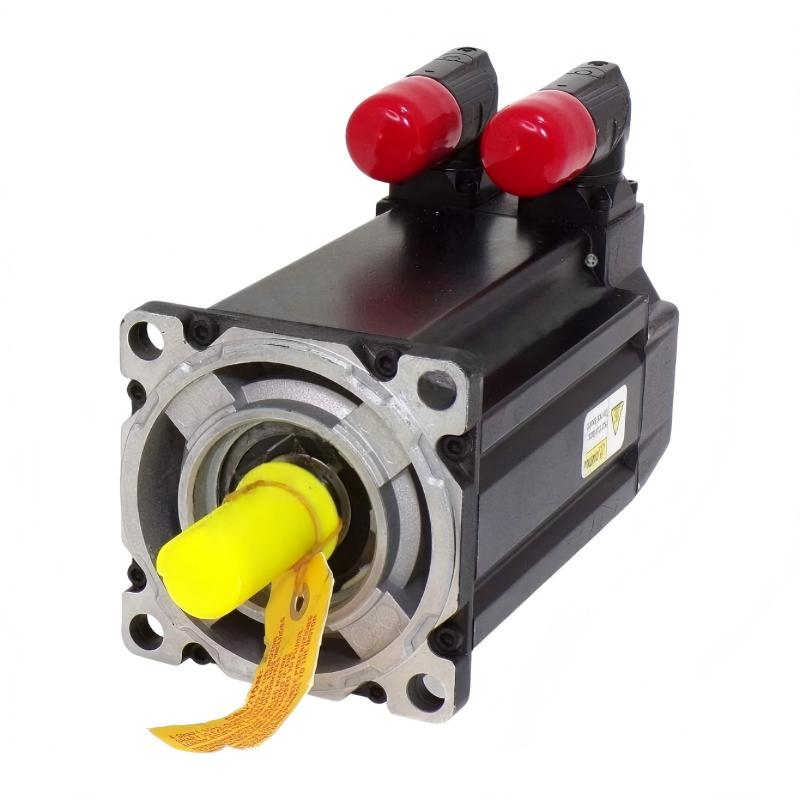
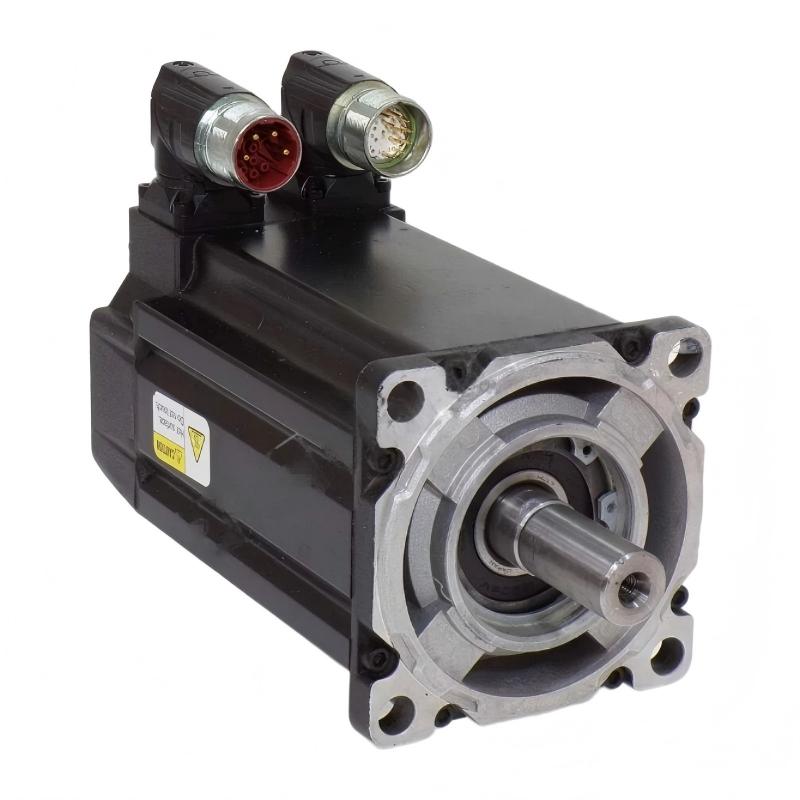
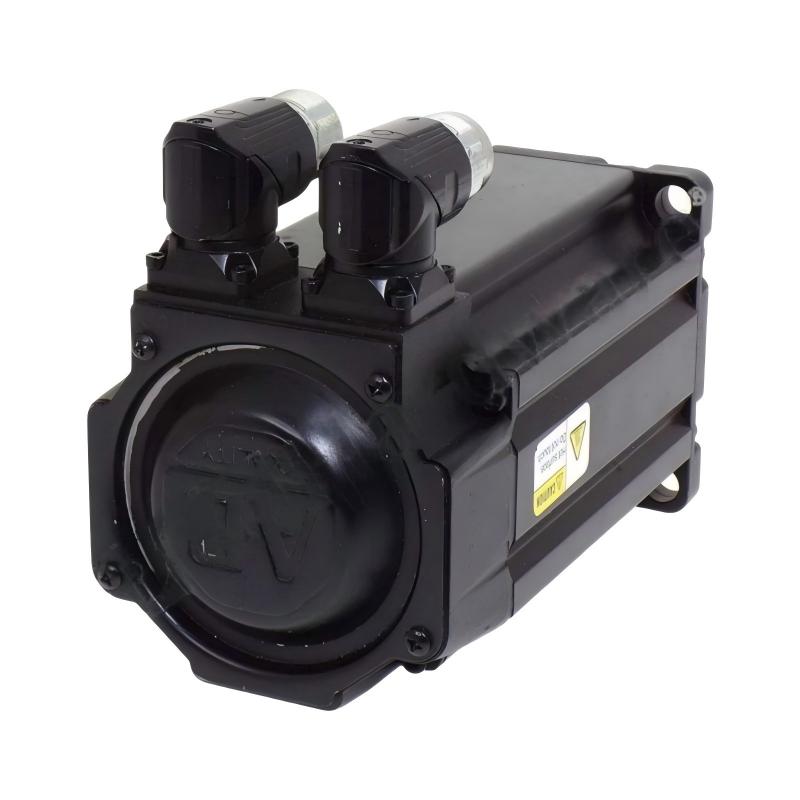
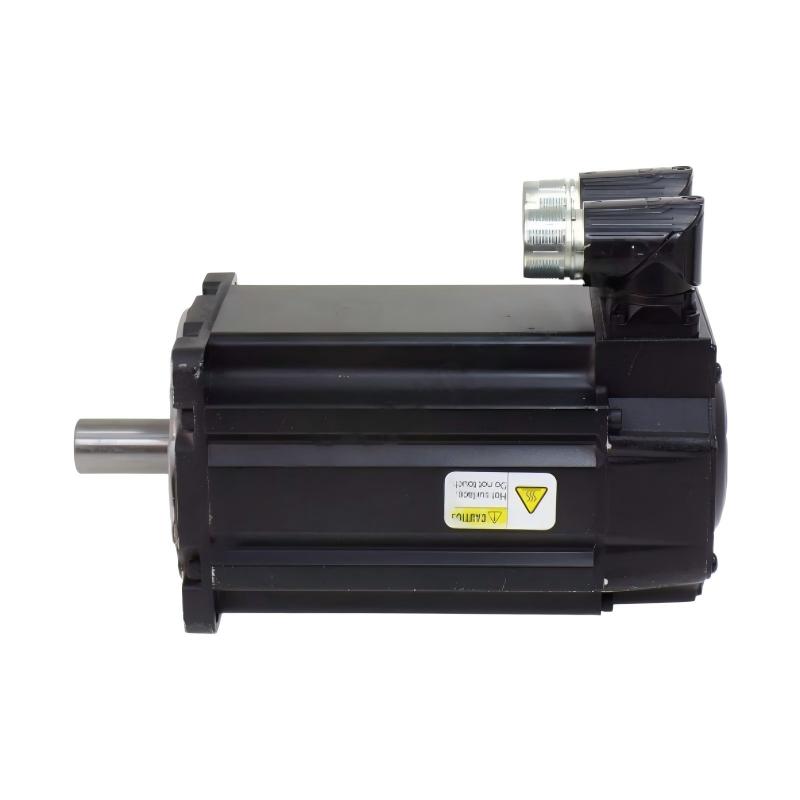
- Allen Bradley
- MPL-B430P-SK72AA
- Servo Motor
- USA
- 115 mm
- 5.5 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 3
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
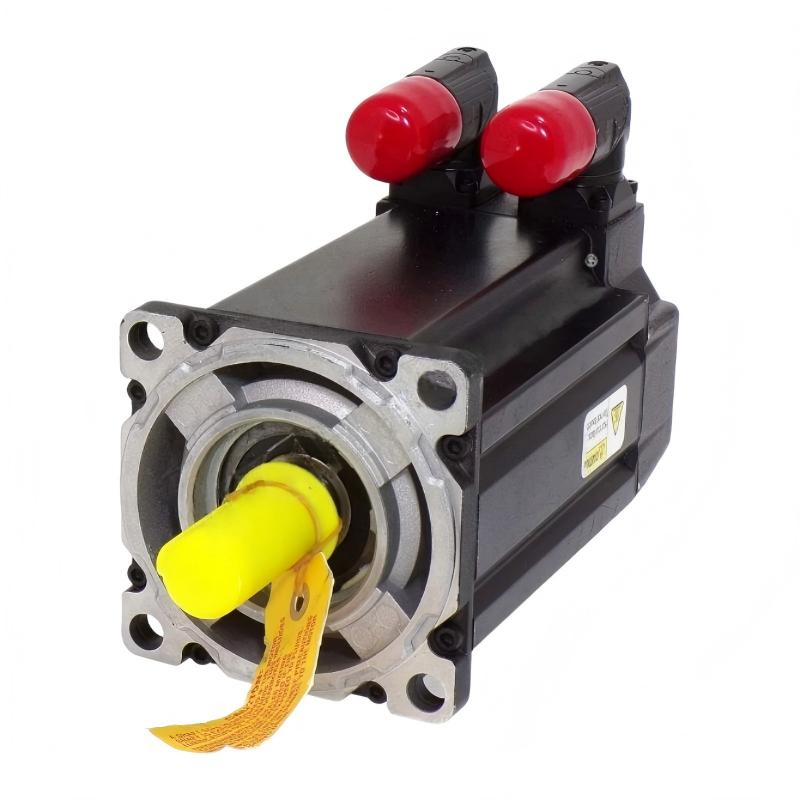
The Allen Bradley MPL-B430P-SK72AA Servo Motor is an industrial motion-control component designed for applications that require accurate rotary movement, controlled acceleration, and coordinated operation with a compatible servo drive. As part of the Allen-Bradley Kinetix motion-control ecosystem, MPL-series servo motors are associated with applications involving automated machinery, positioning systems, material handling, and precision manufacturing.
Servo motors are used when a machine must control not only motor rotation but also movement according to defined speed, position, or torque requirements. In a typical servo system, the motor operates with a compatible servo drive and feedback device. The drive regulates motor current and voltage based on motion commands and feedback information, while a PLC or motion controller coordinates the overall machine sequence.
The MPL-B430P-SK72AA is identified by its supplied product description as an Allen-Bradley servo motor. The provided frame size is 115 mm, and the stated weight is 5.5 kg. These physical specifications are useful for preliminary equipment planning, handling, and replacement identification. The exact mounting dimensions, shaft configuration, rated output, feedback arrangement, and electrical requirements should be confirmed against the complete catalog number and motor nameplate before installation.
For industrial users, selecting the correct servo motor is essential to achieving stable motion performance, reducing mechanical stress, and maintaining repeatable production quality. The motor must be matched to the application load, servo drive, feedback system, and mechanical transmission.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Allen-Bradley |
| Product Model | MPL-B430P-SK72AA |
| Product Type | AC Servo Motor |
| Product Series | MPL Servo Motor Series |
| Application Category | Industrial Motion Control |
| Frame Size | 115 mm |
| Weight | 5.5 kg |
| Motion Function | Controlled rotary motion in a compatible servo system |
| Drive Compatibility | Must be verified against the exact motor catalog number |
| Feedback System | Confirm from the motor’s applicable technical documentation |
| Mounting Configuration | Verify shaft, flange, and mounting dimensions before installation |
| Typical Applications | Automated machinery, positioning equipment, material handling, and manufacturing systems |
The table contains the product information supplied for this model. Rated power, continuous and peak torque, rated speed, operating voltage, shaft dimensions, brake availability, feedback type, and connector configuration should be verified using the exact motor documentation rather than estimated from the model designation.
What Is the Allen Bradley MPL-B430P-SK72AA Servo Motor?
A servo motor is designed to operate as part of a controlled motion system. Unlike a conventional motor that may run primarily at a commanded speed, a servo motor is commonly used in applications where the control system must coordinate movement with a defined position, speed profile, or torque requirement.
The MPL-B430P-SK72AA is described as an industrial servo motor intended for integration into a compatible motion-control arrangement. The motor converts electrical energy into mechanical rotation, allowing machinery to perform tasks such as positioning, indexing, feeding, transferring, and synchronized movement.
A typical servo system contains several functional elements:
- Motion controller or PLC: Generates commands and coordinates the machine sequence.
- Servo drive: Regulates motor operation according to the commanded motion and available feedback.
- Servo motor: Converts electrical power into mechanical movement.
- Feedback device: Supplies position or speed information when required by the motor and drive design.
- Mechanical transmission: Transfers motor rotation to the machine load through a coupling, gearbox, belt, or other mechanism.
The actual architecture depends on the selected drive, controller, motor configuration, and application requirements.
Function and Working Principle
1. Conversion of Electrical Energy into Motion
The servo drive supplies controlled electrical power to the motor. The motor converts this electrical input into rotary movement, producing the torque required to move the connected load.
The motor’s performance depends on the electrical characteristics of the drive, the motor winding configuration, the mechanical load, and the commanded operating profile.
2. Motion Command Processing
A PLC or motion controller defines the required movement according to the machine program. Commands may specify a target position, movement distance, speed, acceleration, or coordinated sequence.
The servo drive interprets the commands according to the supported control interface and applies the appropriate motor-control response.
3. Feedback-Based Control
Where the motor and drive use a supported feedback arrangement, position or speed information is returned to the drive. The control system uses this information to regulate movement and reduce the difference between commanded and actual motion.
Feedback performance depends on the installed motor configuration and the compatible drive. The exact feedback device and interface for the MPL-B430P-SK72AA should be confirmed from the product documentation.
4. Acceleration and Deceleration
Servo applications frequently require controlled changes in speed. The motion controller and drive can apply programmed acceleration and deceleration profiles within the limits of the motor, drive, and mechanical system.
Appropriate motion profiles help reduce sudden mechanical loads and improve positioning consistency. Excessively aggressive settings can increase vibration, current demand, mechanical stress, and following errors.
5. Coordinated Machine Operation
In multi-axis machinery, servo motors may operate together to coordinate several movements. A compatible motion controller synchronizes the axes according to the machine sequence.
This capability is useful for packaging equipment, automated assembly, material transfer, and other systems where movement timing affects product quality or throughput.
Role in Industrial Automation Systems
The Allen Bradley MPL-B430P-SK72AA can be considered a motion-producing element within an industrial automation system, subject to confirmation of the exact motor identity and compatibility.
Its role is different from that of a PLC, servo drive, or digital input module. The controller processes logic and motion commands, the drive manages the motor’s electrical operation, and the motor supplies the mechanical movement.
| System Component | Typical Function |
|---|---|
| PLC or Motion Controller | Executes machine logic and coordinates movement |
| Compatible Servo Drive | Controls the motor using the supported control and feedback interfaces |
| MPL-B430P-SK72AA Servo Motor | Produces controlled rotary motion |
| Feedback Device | Provides motion feedback where required |
| Coupling or Gearbox | Transfers torque to the driven mechanism |
| Mechanical Load | Performs the required machine operation |
| HMI Panel | Provides operator commands and machine-status information |
| Industrial Network | Supports communication between compatible automation devices |
Successful integration requires more than matching the motor’s frame size. The motor and drive must be compatible electrically and functionally, and the mechanical arrangement must satisfy the application’s torque, speed, and positioning requirements.
Industrial Applications
Automated Manufacturing
Servo motors are widely used in manufacturing systems that require repeatable movement and coordinated machine sequences. Depending on the verified ratings and application design, a compatible servo motor may support indexing, positioning, feeding, or transfer operations.
Packaging Machinery
Packaging equipment often requires accurate coordination between product movement and machine actions. Servo-driven mechanisms may control feeding, indexing, cutting, sealing, or product transfer where programmable motion is beneficial.
Material Handling
Automated material-handling systems can use servo motors to control the movement of positioning mechanisms, transfer units, and other machine axes. Correct motor sizing is essential when loads change frequently or when rapid acceleration is required.
Assembly Equipment
Servo systems can support repeatable positioning in automated assembly processes. The motion controller can coordinate multiple axes to place components or move tooling through a defined sequence.
Machine Tools and Special-Purpose Machinery
Special-purpose machinery may use servo motors to control feed mechanisms, rotary positioning units, and other axes that require programmable motion. Suitability depends on the motor’s verified torque, speed, environmental, and feedback specifications.
Robotics and Automated Workstations
Servo motors are common in controlled-motion architectures, including selected robotic and automated workstation applications. The exact motor model must be evaluated against the axis load, duty cycle, required accuracy, and mechanical configuration before being selected.
These are general applications of industrial servo technology, not confirmation that every listed application is suitable for this particular model.
Installation and Mechanical Integration
Proper installation helps protect the motor and the connected machine from unnecessary stress.
Confirm the Motor Identity
Before installation, verify the complete model designation MPL-B430P-SK72AA on the nameplate. Check the catalog number, revision or suffix information where applicable, connector arrangement, and any existing installation records.
Do not substitute a similar MPL-series motor solely because it has a comparable frame size or appearance.
Check Mounting Dimensions
The supplied frame size is 115 mm. Confirm the actual flange dimensions, mounting-hole pattern, shaft diameter, shaft length, and available clearance from the applicable dimensional drawing.
A matching frame-size description does not guarantee that the motor will fit an existing machine without mechanical changes.
Inspect the Mechanical Load
Before coupling the motor to the machine, check the load inertia, required torque, operating speed, acceleration profile, and duty cycle. Confirm that the mechanical transmission is suitable for the expected operating conditions.
Misalignment, excessive radial or axial loading, or an unsuitable coupling can shorten bearing life and cause vibration.
Align the Motor and Driven Equipment
Align the motor shaft with the connected mechanical transmission according to the installation requirements. Avoid forcing the shaft into position or using the motor to compensate for misalignment.
Check the coupling, mounting bolts, and driven mechanism before operation. Where a gearbox or belt transmission is used, verify its condition and lubrication requirements as applicable.
Protect Cables and Connectors
Use the specified motor power and feedback cables for the verified motor and drive combination. Route cables to avoid sharp edges, excessive bending, crushing, and interference from high-power switching conductors.
Secure cable runs to reduce movement and connector strain during machine operation.
Servo Drive Configuration and Commissioning
The motor should be commissioned only with a compatible drive and a verified system configuration.
Verify Drive Compatibility
Confirm that the selected servo drive supports the complete motor catalog number, required electrical ratings, feedback arrangement, and any installed accessories.
The exact drive model should be selected from the manufacturer’s compatibility information. Do not assume that all Kinetix drives support every MPL-series motor.
Enter the Correct Motor Data
Where the drive requires motor selection or parameter entry, use the documented values for the exact motor. These may include rated electrical data, torque and speed limits, feedback configuration, and other motor-specific parameters.
Incorrect motor data can cause poor motion performance, drive faults, excessive current, or unsafe machine behavior.
Inspect the Motion System
Before enabling the motor, check the mounting hardware, coupling, load travel, cable connections, grounding, and protective devices. Ensure that the machine can move through its intended range without mechanical obstruction.
Remove personnel and loose objects from hazardous movement areas before testing.
Test Movement at a Controlled Speed
Follow the approved commissioning procedure and begin with conservative movement settings where permitted. Confirm the direction of rotation, feedback behavior, stopping response, and basic movement accuracy.
Unexpected movement, excessive noise, vibration, or repeated drive faults should be investigated before normal production begins.
Validate the Complete Machine Sequence
After initial testing, verify the motor’s behavior under representative load conditions. Check acceleration and deceleration, position repeatability where applicable, and coordination with other machine axes.
Record the final configuration and relevant commissioning observations so future maintenance work can be performed consistently.
Troubleshooting the MPL-B430P-SK72AA Servo Motor
Motor-related problems may originate from the motor itself, the servo drive, feedback wiring, mechanical transmission, or motion-control configuration. Troubleshooting should examine the complete system.
Motor Does Not Rotate
Potential causes include missing or incorrect power connections, an inhibited drive, an active fault, an uncompleted enable sequence, incorrect configuration, or a mechanical obstruction.
Check the drive status and diagnostic messages first. Then verify the control commands, power connections, motor compatibility, and mechanical load according to the approved maintenance procedure.
Unexpected Movement or Incorrect Direction
Unexpected movement may result from an incorrect motion command, configuration mismatch, wiring issue, or incorrect mechanical assumptions.
Review the motion program, axis configuration, motor identification, and direction settings. Keep personnel clear of the machine during tests, and use the approved procedure for disabling or isolating the system before making changes.
Positioning Errors or Following Faults
In a feedback-controlled servo system, following errors can occur when actual motion does not track the commanded trajectory within the permitted limits.
Possible contributing factors include excessive load, aggressive acceleration, mechanical binding, incorrect tuning, feedback problems, or a mismatch between the motor and drive configuration.
Inspect the mechanics first, review the drive diagnostics, and verify that the motion profile is appropriate for the application. Adjust tuning only after confirming the correct motor data and mechanical condition.
Excessive Noise or Vibration
Unusual noise or vibration can indicate mechanical misalignment, loose mounting hardware, bearing wear, coupling problems, excessive load inertia, or unsuitable motion settings.
Stop the machine if the noise suggests a mechanical fault or creates a safety concern. Inspect the motor mounting, shaft coupling, and driven equipment before returning the system to service.
Motor or Drive Overheating
Overheating may be associated with excessive load, insufficient cooling, unsuitable duty cycle, repeated high-current operation, mechanical friction, or incorrect drive configuration.
Compare the actual operating conditions with the verified motor and drive ratings. Check for mechanical resistance and ensure that the installation meets the required environmental and cooling conditions.
Feedback or Configuration Fault
If the drive reports a feedback-related or motor-identification fault, inspect the relevant connectors and cables, verify the exact motor catalog number, and confirm that the selected drive configuration matches the installed hardware.
Do not replace a motor based solely on a feedback alarm. The fault may originate from the cable, connector, drive, configuration, or feedback interface.
Maintenance Recommendations
A preventive maintenance program can help identify mechanical and electrical issues before they interrupt production.
Inspect mounting hardware: Check for loosened fasteners, signs of movement, and changes in alignment.
Monitor vibration and noise: Record unusual changes during normal operation and investigate them before they become severe.
Inspect cables and connectors: Look for abrasion, crushing, damaged insulation, loose connections, and excessive strain.
Check the driven mechanism: Inspect couplings, gearboxes, belts, and other transmission components according to their maintenance requirements.
Review drive diagnostics: Record recurring faults, overload events, and motion-performance changes where diagnostic data is available.
Maintain a clean operating environment: Keep the motor within its specified environmental limits and protect connectors and cables from contamination or damage.
Preserve configuration records: Document motor replacement details, drive parameters, mechanical adjustments, and commissioning results.
Maintenance intervals should be based on operating hours, duty cycle, environmental conditions, equipment criticality, and the applicable manufacturer’s recommendations.
Compatible System Components
The MPL-B430P-SK72AA should be integrated with components selected for its exact electrical and mechanical requirements. Potential component categories include:
| Component Category | Function |
|---|---|
| Compatible Allen-Bradley Servo Drive | Supplies controlled electrical power to the motor |
| PLC or Motion Controller | Coordinates axis movement and machine sequencing |
| Approved Motor Power Cable | Connects the motor to the compatible drive |
| Compatible Feedback Cable | Transfers feedback information when required by the motor configuration |
| Mechanical Coupling | Connects the motor shaft to the driven equipment |
| Gearbox or Transmission | Adapts torque and speed to the application |
| HMI or Operator Interface | Provides machine commands and status information |
| Protective and Isolation Equipment | Supports safe electrical maintenance and system operation |
Specific drive, cable, connector, and accessory part numbers must be confirmed using the exact motor catalog number. A component should not be treated as compatible simply because it belongs to the same manufacturer’s product family.
Replacement and Procurement Considerations
When purchasing or replacing the Allen Bradley MPL-B430P-SK72AA, confirm that the supplied motor matches the machine’s original requirements.
Important checks include:
- Complete motor catalog number
- Frame size and mounting dimensions
- Shaft configuration and mechanical interface
- Rated torque, speed, and power
- Electrical ratings
- Feedback type and connector arrangement
- Brake or other accessory configuration, if applicable
- Compatible servo drive
- Cable and connector requirements
- Environmental and duty-cycle requirements
The supplied frame size is 115 mm, and the stated weight is 5.5 kg. These values can support preliminary space planning, handling arrangements, and shipping calculations, but they do not establish electrical or mechanical interchangeability.
If the motor is replacing an existing unit, compare the complete nameplate information and dimensional drawing before ordering. After installation, verify the drive configuration and complete the required motion tests before returning the machine to production.
Key Advantages of Servo Motor Technology
Controlled Motion
A properly configured servo system can control movement according to the application’s speed, position, and torque requirements.
Repeatable Machine Operation
Feedback-based control, where supported by the system, helps the drive regulate motion and maintain consistent machine behavior.
Flexible Motion Programming
A compatible controller can coordinate movement profiles and sequences to suit different machine operations.
Integration with Industrial Automation
Servo motors can operate as part of a broader architecture containing motion controllers, drives, operator interfaces, and other automation equipment.
Support for Preventive Maintenance
Drive diagnostics and recorded motion behavior can help maintenance teams investigate performance changes and recurring faults.
These benefits depend on correct motor selection, compatible control hardware, appropriate configuration, and a mechanically sound installation.
Technical FAQs
What is the Allen Bradley MPL-B430P-SK72AA?
It is identified by the supplied description as an Allen-Bradley industrial servo motor intended for controlled rotary motion in a compatible servo system.
What is the frame size of the MPL-B430P-SK72AA?
The supplied frame size is 115 mm. Confirm the actual mounting and shaft dimensions from the relevant dimensional drawing before installation.
How much does the MPL-B430P-SK72AA weigh?
The supplied weight is 5.5 kg.
Can this motor operate without a servo drive?
A servo motor requires a suitable motor-control power system designed for its electrical characteristics. For the intended servo application, use a compatible servo drive and the required feedback and control interfaces.
Which servo drive is compatible with this motor?
The exact compatible drive should be confirmed from the complete motor catalog number and the manufacturer’s compatibility information. Do not select a drive based solely on the MPL-series designation.
What can cause a servo motor to lose positioning accuracy?
Possible causes include feedback problems, mechanical looseness, shaft misalignment, excessive load, unsuitable motion settings, or incorrect motor and drive configuration. Diagnose the complete system before replacing components.
What should be checked before replacing the motor?
Verify the full catalog number, mounting dimensions, shaft configuration, electrical ratings, feedback arrangement, cable requirements, and drive compatibility. Confirm the machine’s motion parameters after replacement.
Is the MPL-B430P-SK72AA suitable for every industrial machine?
No. Suitability depends on required torque, speed, acceleration, load inertia, duty cycle, environmental conditions, and the compatibility of the servo drive and mechanical system.
Conclusion
The Allen Bradley MPL-B430P-SK72AA Servo Motor is identified as an industrial motion-control motor for applications requiring controlled rotary movement and integration with a compatible servo system. As part of an appropriately configured automation architecture, a servo motor can support repeatable positioning, coordinated machinery, and controlled acceleration and deceleration.
The supplied specifications list a 115 mm frame size and a weight of 5.5 kg. Before purchasing, installing, or replacing the motor, confirm its complete catalog identity, electrical ratings, mechanical dimensions, feedback configuration, and compatible drive requirements.
Correct motor selection, careful mechanical alignment, verified electrical connections, and systematic commissioning are essential for reliable operation. By matching the motor to the application and maintaining accurate configuration records, industrial users can support stable motion performance and reduce avoidable equipment downtime.