ProductPRODUCT
Featured products
Contact Us
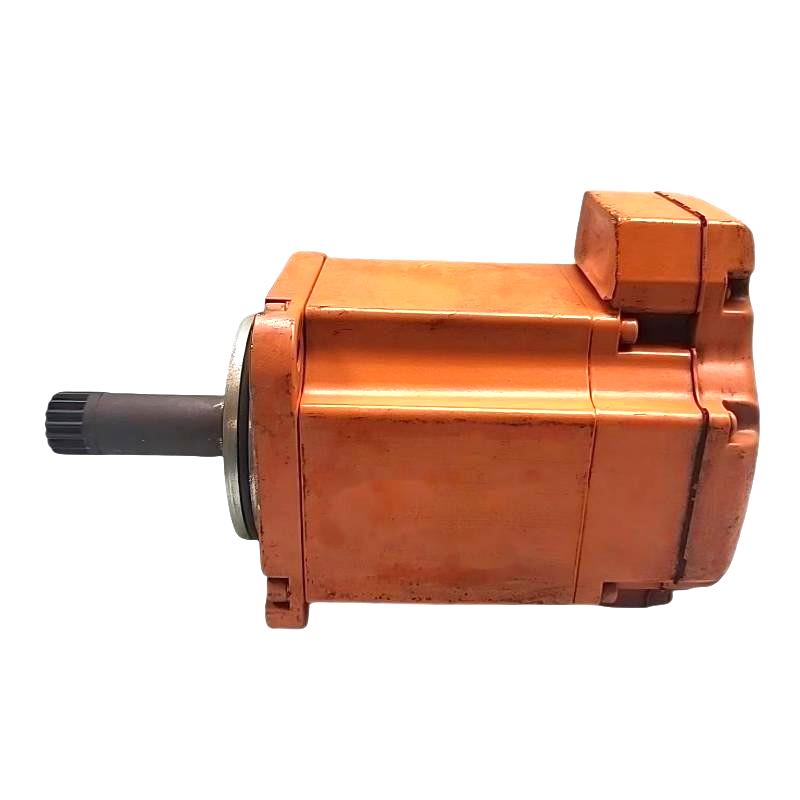
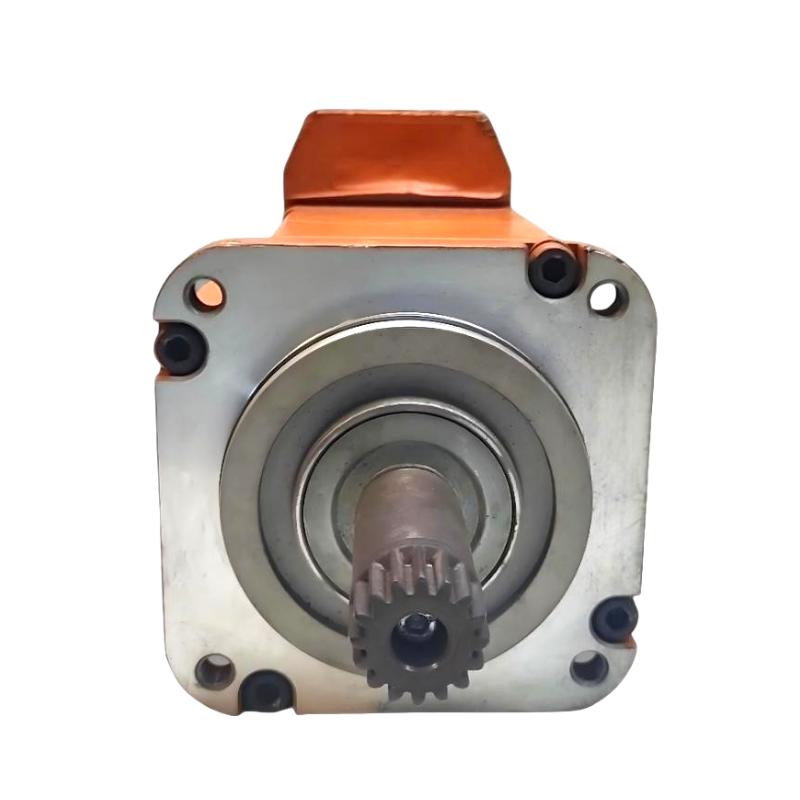
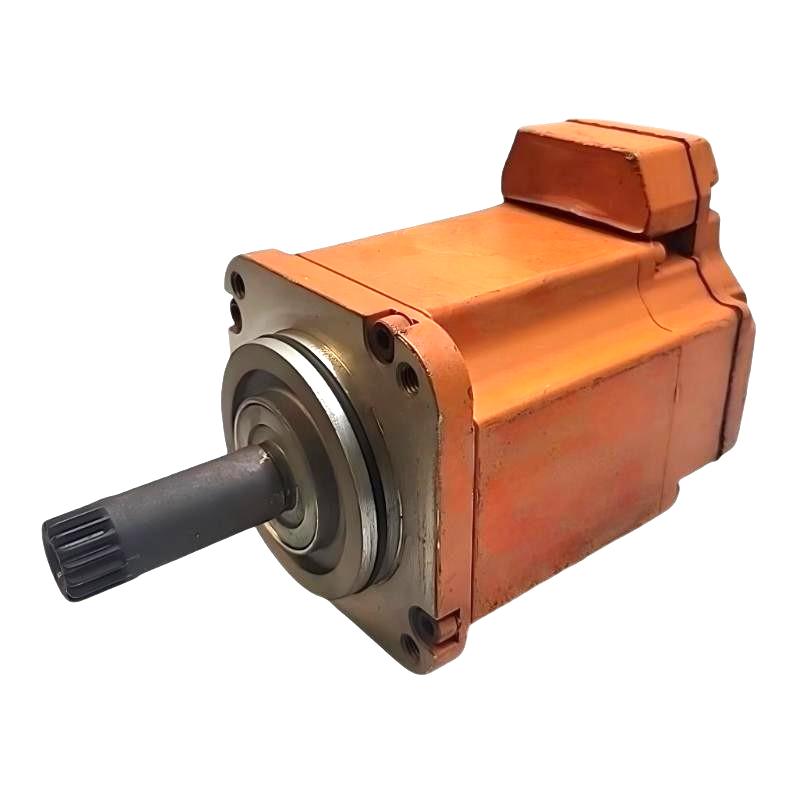
- ABB
- 3HAC17484-8/00
- Rotational AC Motor M8
- Sweden (SE)
- 480 × 80 × 250 mm
- 8.88 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 3
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
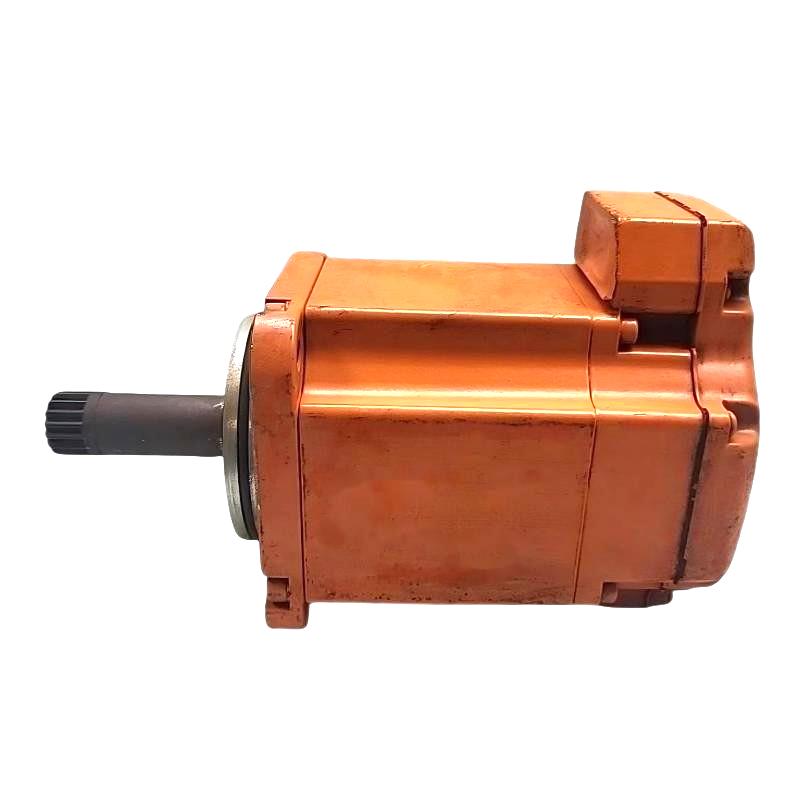
The ABB 3HAC17484-8/00 Rotational AC Motor M8 is a robotic motion motor used to generate controlled rotary movement within an ABB industrial robot system. The motor forms part of the axis-drive chain and works with the robot controller, drive electronics, feedback arrangement, and mechanical transmission.
In a robot application, the M8 motor can be associated with a specific mechanical axis where precise and repeatable rotation is required. The controller determines the required motion while the drive regulates the electrical power delivered to the motor, allowing the motor to generate the torque needed by the connected axis mechanism.
The motor is suited to repetitive industrial operations involving acceleration, deceleration, positioning, and coordinated multi-axis movement. Typical robot duties include material handling, assembly, welding, machine tending, and other automated production processes.
For maintenance, motor condition should be assessed together with the drive, feedback circuit, gearbox, coupling, and mechanical load. A motor fault and an axis fault can produce similar symptoms, so the complete motion chain should be considered during troubleshooting.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | 3HAC17484-8/00 |
| Product Family | ABB Robotics |
| Product Type | Rotational AC Motor |
| Motor Designation | M8 |
| Primary Function | Rotary motion generation |
| System Role | Robot axis drive motor |
| Typical Application | Industrial robotic and automation motion systems |
| Dimensions | 480 × 80 × 250 mm |
| Weight | 8.88 kg |
Product Features
- Rotational AC motor identified as M8 for ABB robotic motion applications.
- Converts electrical drive power into rotary mechanical torque.
- Suitable for controlled movement of a robot axis.
- Works with the associated robot drive and control system.
- Supports repeated positioning and coordinated robotic motion.
- Can operate as part of a multi-axis robot motion architecture.
- Suitable for industrial robotic production environments.
- Requires matching with the applicable robot-axis configuration and associated drive system.
Working Principle
The 3HAC17484-8/00 receives controlled electrical power from the associated robot drive. The drive adjusts the motor supply according to the movement command generated by the robot control system.
Electrical energy is converted into electromagnetic torque inside the motor, producing rotary shaft movement. The resulting torque is transferred through the mechanical transmission to the corresponding robot axis.
Robot Controller → Robot Drive → 3HAC17484-8/00 M8 Motor → Gearbox / Transmission → Robot Axis
During controlled movement, the robot system uses feedback information where applicable to compare the commanded axis position or movement with the actual machine response. The drive can then regulate motor operation to follow the required motion profile.
Motor performance depends on the complete axis assembly. Electrical connections, drive configuration, feedback signals, mechanical loading, gearbox condition, and coupling alignment can all influence the observed robot-axis behavior.
Role in an ABB Robot Motion Control Architecture
The 3HAC17484-8/00 occupies the motor stage of the ABB robot motion chain. It converts regulated electrical power from the drive into the mechanical torque required to move the assigned robot mechanism.
Robot Controller → Drive System → M8 AC Motor → Mechanical Transmission → Robot Axis
| System Element | Function |
|---|---|
| Robot Controller | Coordinates programmed robot movements |
| Robot Drive System | Regulates electrical power delivered to the motor |
| 3HAC17484-8/00 M8 Motor | Generates rotary torque for the robot axis |
| Feedback System | Provides relevant axis-motion information |
| Gearbox / Transmission | Transfers motor torque to the robot mechanism |
| Robot Axis Mechanism | Converts motor torque into physical movement |
| Robot Tool / End Effector | Performs the programmed production operation |
The motor therefore operates as one element of an integrated axis rather than as an independent motion controller.
Industrial Applications
| Application | Typical Use |
|---|---|
| Industrial Robot Arms | Rotary movement of a controlled robot axis |
| Material Handling | Repeated positioning of robot mechanisms |
| Welding Automation | Coordinated axis movement during welding |
| Assembly Automation | Controlled positioning during component assembly |
| Machine Tending | Robot movement for loading and unloading |
| Palletizing | Repetitive multi-axis positioning |
| Robotic Production Cells | Coordinated automated movement |
| Manufacturing Automation | Rotary motion for automated production equipment |
Installation and Maintenance
- Verify the complete 3HAC17484-8/00 part number and M8 motor designation before installation.
- Confirm that the motor matches the intended ABB robot model and axis configuration.
- Isolate electrical power and secure the robot against unintended movement before maintenance.
- Inspect the motor housing, mounting points, shaft interface, and accessible connectors for damage.
- Check the motor-to-transmission coupling for looseness, wear, or mechanical misalignment.
- Verify motor power connections and terminal interfaces before energizing the system.
- Inspect the feedback connection and cable routing where feedback equipment is part of the axis.
- Check the surrounding area for conditions that could restrict motor cooling or expose the motor to contamination.
- Verify that the mechanical load and transmission can move freely according to the applicable robot maintenance procedure.
- During commissioning, perform controlled axis movement and monitor motor and drive behavior.
- Investigate abnormal noise, vibration, temperature, or positioning errors by checking the motor, drive, feedback, and mechanical transmission together.
- After replacement, complete the applicable axis calibration, motion verification, and robot-system functional tests before returning the equipment to production.
Compatible System Components
| Component | Function |
|---|---|
| ABB Robot Controller | Coordinates programmed robot movement |
| ABB Robot Drive Unit | Controls electrical power supplied to the motor |
| Motor Feedback System | Provides axis-motion information where applicable |
| Robot Gearbox | Transfers motor torque to the robot axis |
| Mechanical Coupling | Connects the motor to the transmission system |
| Robot Axis Assembly | Produces the corresponding physical movement |
| Motor Power Cable | Carries electrical power to the motor |
| Robot Maintenance Equipment | Supports inspection and servicing of the axis |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| ABB 3HAC17484-8/00 | Rotational AC Motor | Robot-axis rotary motion |
| ABB M8 Motor | Robot AC Motor | Controlled robotic axis movement |
| ABB S4C+ Motion System | Robot Control System | Industrial robot motion control |
| ABB S4Cplus M2000 | Robot Controller Platform | Coordinated robot-axis control |
| ABB InMotion Drive Units | Robot Drive Unit | Motor power and motion regulation |
| ABB DSQC Robot Drive Modules | Robot Drive Module | Controlled axis motor operation |
| ABB Robot Gearbox Assemblies | Mechanical Transmission | Torque transmission to robot axes |
| ABB Robot Feedback Components | Feedback System | Axis motion feedback |
Key Advantages
- Provides rotary torque for a compatible ABB robot axis.
- Supports controlled and repeatable robotic movement.
- Works within an integrated controller, drive, feedback, and mechanical transmission chain.
- Suitable for repetitive industrial robot motion.
- Supports coordinated movement in multi-axis robotic applications.
- Can be maintained as part of a complete ABB robot axis assembly.
Technical FAQs
How can the correct replacement for the 3HAC17484-8/00 be identified?
The complete part number should be matched against the installed motor and robot-axis configuration. The associated drive, feedback arrangement, mounting interface, and mechanical transmission should also be checked before replacement.
What should be investigated if the M8 motor runs but the robot axis does not move correctly?
Check the drive configuration, feedback signals, gearbox, coupling, mechanical load, and axis mechanics. A motor that rotates does not necessarily indicate that the complete transmission and positioning system is functioning correctly.
What can cause abnormal vibration or noise from the motor?
Possible causes include mechanical coupling problems, transmission wear, excessive load, mounting issues, bearing-related problems, or drive behavior. The motor should be inspected together with the connected axis components.
What needs to be verified after replacing the M8 motor?
Verify the motor and drive connections, feedback path, mechanical installation, and controlled axis movement. The applicable robot calibration and functional verification procedure should be completed before production operation resumes.