

ProductPRODUCT
Featured products
Contact Us
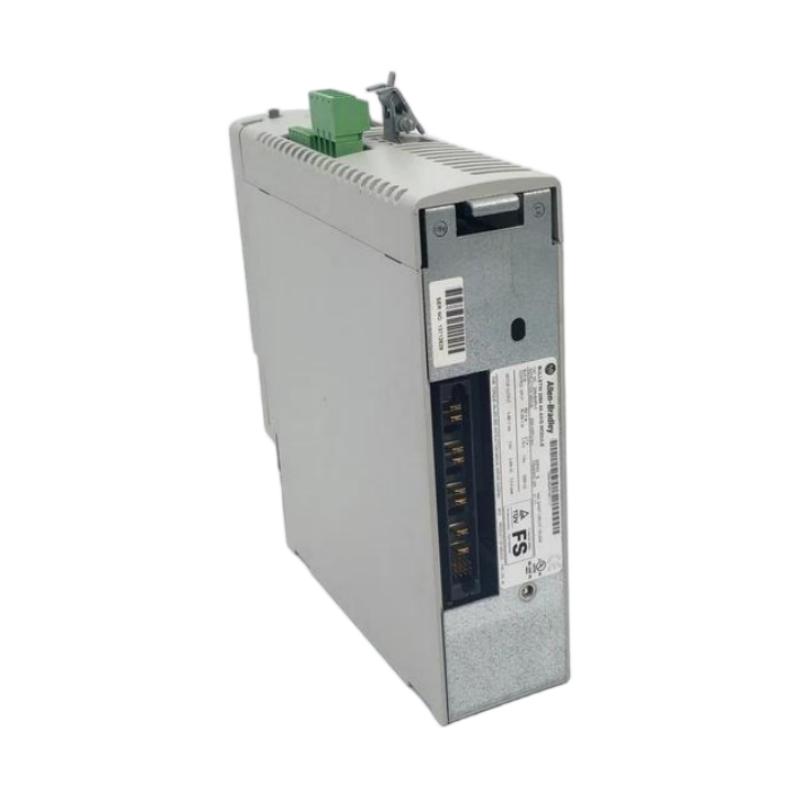
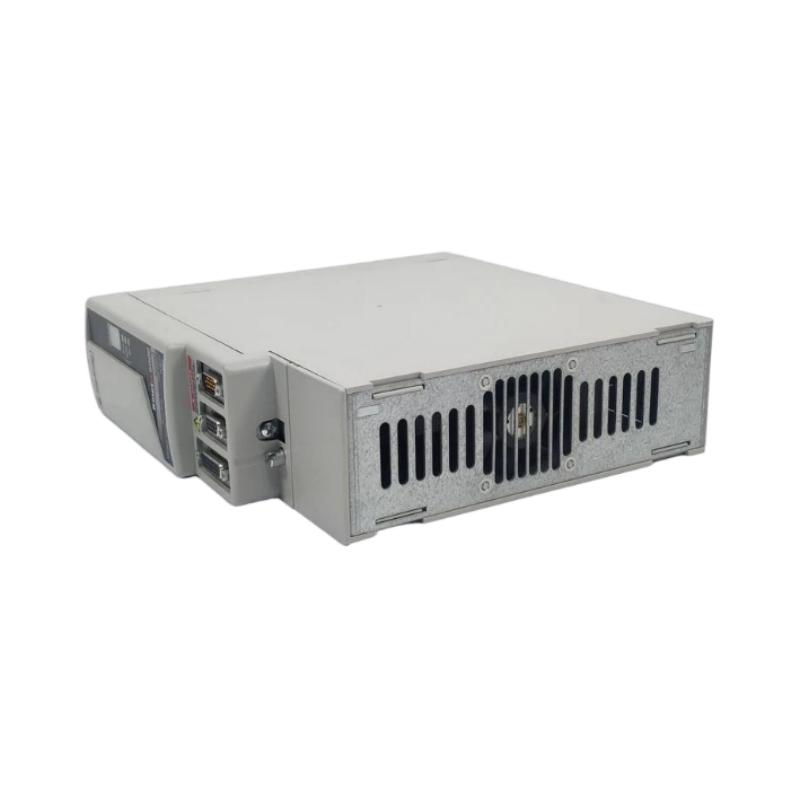
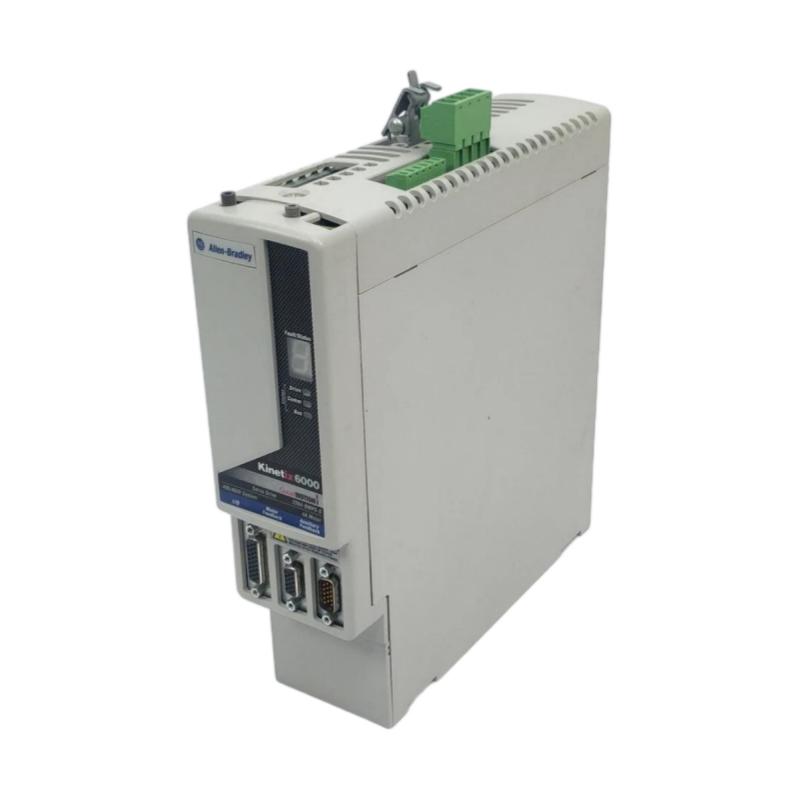
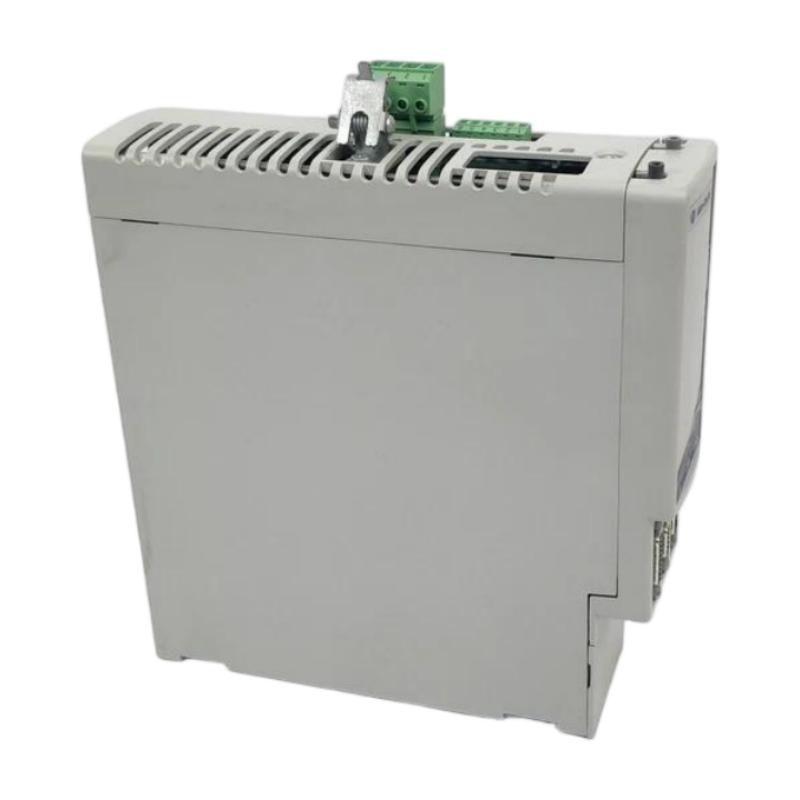
- Allen Bradley
- 2094-BMP5
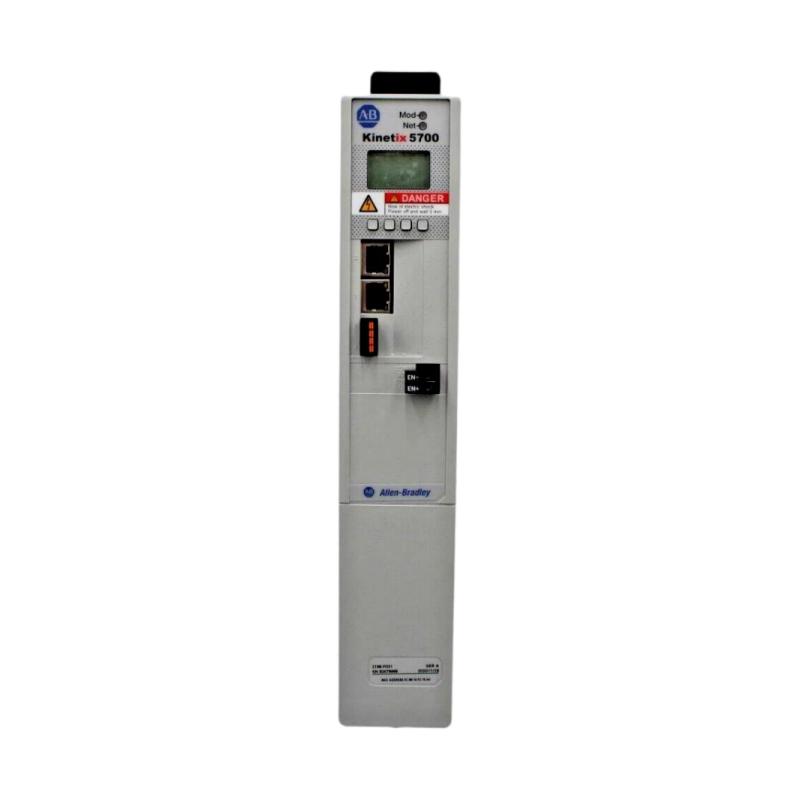
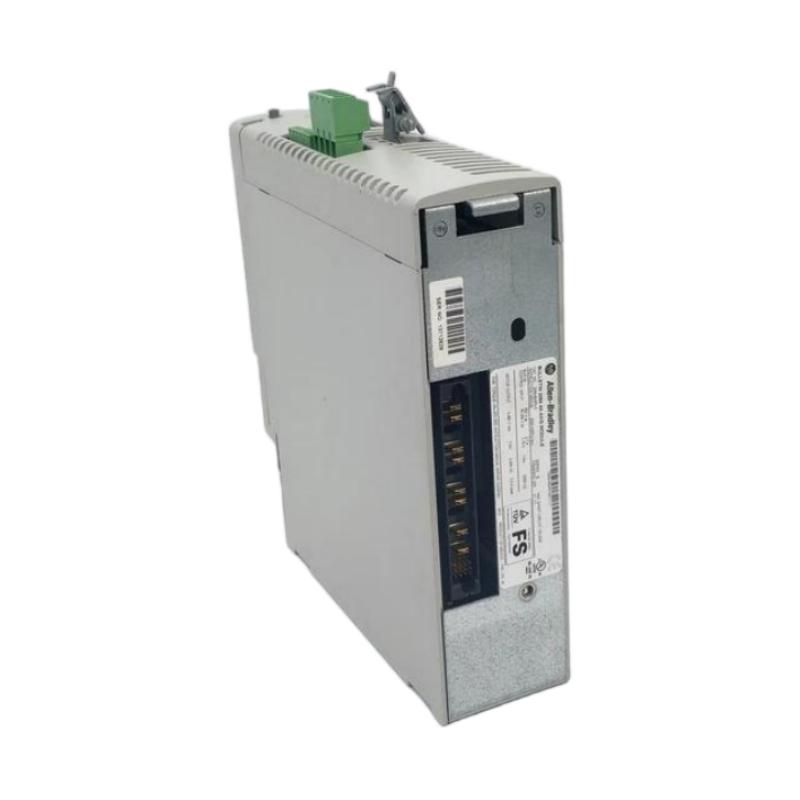
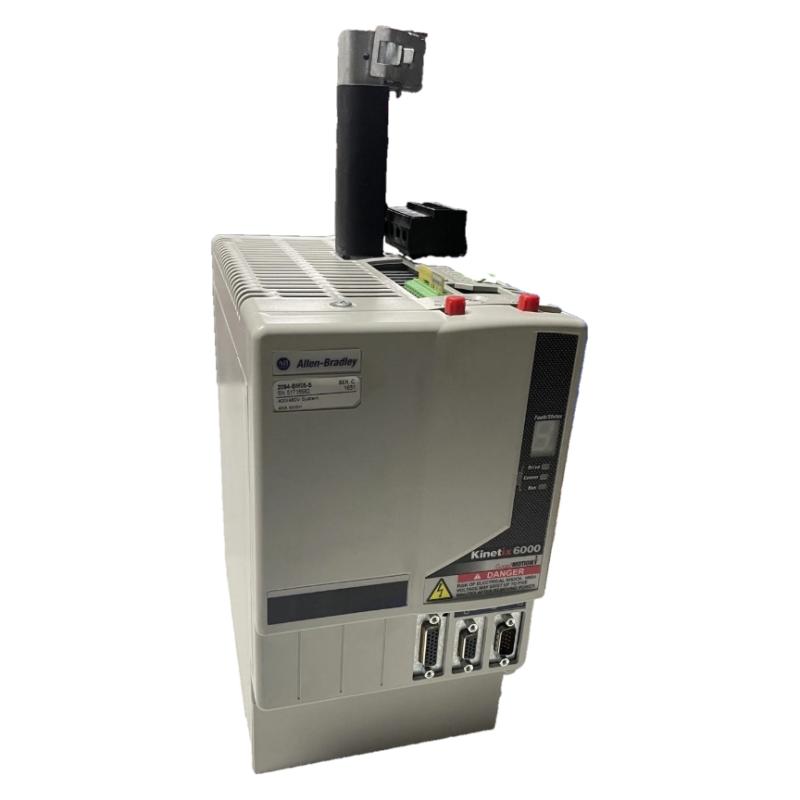
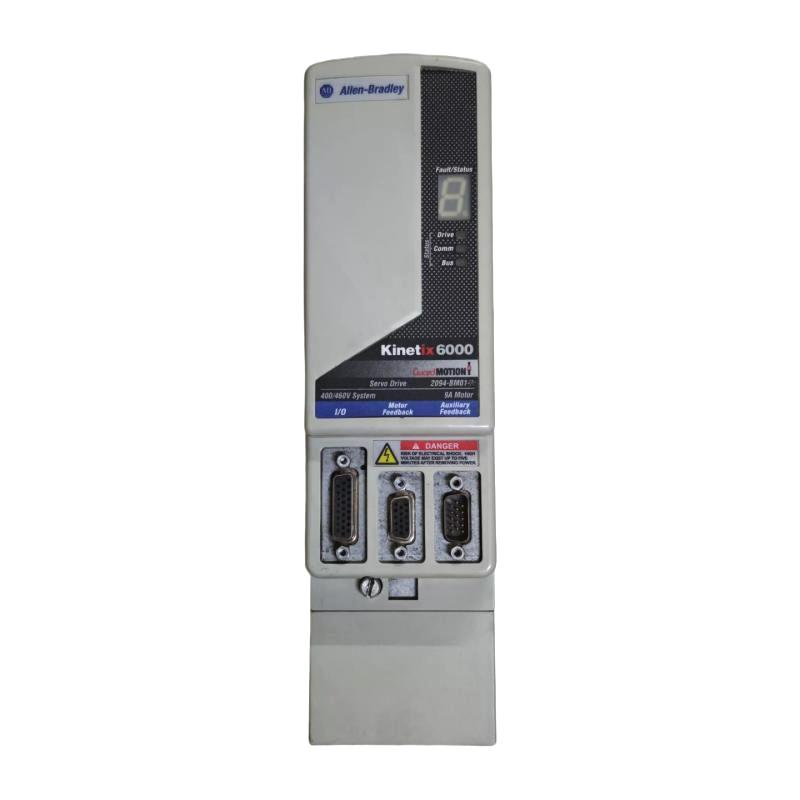
- Kinetix 6000 Axis Module
- USA
- 287 x 70 x 249 mm
- 2.44 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
The Allen-Bradley 2094-BMP5 Kinetix 6000 Axis Module is a servo axis module designed for use in Rockwell Automation’s Kinetix 6000 multi-axis motion control system. Manufactured by Allen-Bradley, this module provides the inverter function required to control an individual servo axis in industrial machinery.
Unlike a standalone AC drive, the 2094-BMP5 is designed to operate as part of a modular servo drive architecture. It is installed on a compatible Kinetix 6000 power rail and works with the system’s integrated axis module (IAM), power supply, feedback connections, and other motion-control components.
The 2094-BMP5 belongs to the 400/460 V-class axis module family and has a 4 A inverter current rating. Its published electrical specifications include a continuous output current of approximately 2.8 A RMS and a nominal continuous output power of approximately 1.7 kW. These ratings make it suitable for compatible servo motors used in industrial positioning, coordinated motion, and automated production equipment.
The module receives DC bus power from the Kinetix 6000 system and uses its inverter circuitry to provide controlled electrical output to the connected servo motor. Motion commands and feedback information are coordinated through the wider motion-control system.
The exact catalog number is important when selecting a replacement. The 2094-BMP5 and 2094-BMP5-S are related models, but the suffix identifies a configuration difference associated with the Safe Torque-Off feature. They should not be treated as automatically interchangeable.
Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Allen-Bradley |
| Manufacturer | Rockwell Automation |
| Model | 2094-BMP5 |
| Product Series | Kinetix 6000 |
| Product Type | Axis Module / Servo Drive Axis Module |
| Module Function | Single-axis servo inverter |
| Voltage Class | 400/460 V |
| Inverter Current Rating | 4 A |
| Continuous Output Current | Approximately 2.8 A RMS |
| Continuous Output Current (0-Peak) | Approximately 4.2 A |
| Nominal DC Bus Input | Approximately 650 V DC |
| PWM Frequency | 8 kHz |
| Nominal Continuous Output Power | Approximately 1.7 kW |
| Internal Shunt Continuous Power | 50 W |
| Internal Shunt Peak Power | 5,600 W |
| Internal Shunt Resistance | 115 Ω |
| Efficiency | Approximately 97% |
| System Compatibility | Kinetix 6000 multi-axis servo system |
| Dimensions Provided | 287 × 70 × 249 mm |
| Weight Provided | 2.44 kg |
Specifications are based on published Kinetix 6000 documentation and may vary with module series and operating conditions. Confirm the nameplate, hardware revision, and applicable manual before installation.
Function and Working Principle
The 2094-BMP5 operates as the inverter section of a Kinetix 6000 servo axis. Its primary function is to convert DC bus power into controlled electrical output for a connected servo motor.
The module works with the motion controller and the other components of the servo system to achieve coordinated motor operation.
1. Servo Motor Power Conversion
The Kinetix 6000 system distributes DC bus power through its power rail. The 2094-BMP5 uses its inverter circuitry to switch this power and generate the electrical output required by the servo motor.
By controlling the inverter output, the system can regulate motor torque and speed according to the motion commands received from the controller.
2. Single-Axis Motion Control
Each axis module is responsible for an individual servo axis. In a multi-axis machine, several axis modules can operate together under a coordinated motion-control program.
For example, a packaging machine may use separate servo axes for product feeding, sealing, cutting, and transfer. The controller coordinates their movement so that each operation occurs at the correct position and time.
The 2094-BMP5 provides the power-conversion function for its assigned axis, while the motion controller manages the overall motion sequence.
3. Motor Feedback and Position Regulation
Servo systems rely on feedback from the motor to determine actual operating conditions. Depending on the motor and feedback configuration, the controller can compare commanded movement with measured motor position or speed.
This feedback-based control helps the system correct deviations and maintain the required motion profile.
The motor, feedback cable, connector, axis module, and controller must all be compatible. Incorrect feedback wiring or configuration can prevent the system from operating correctly.
4. Internal Shunt Function
The 2094-BMP5 includes an internal shunt circuit. A shunt circuit helps manage excess DC bus energy that can occur when a servo motor decelerates or operates regeneratively.
During deceleration, a motor may return energy to the DC bus. If the bus voltage rises beyond the permitted operating level, the shunt circuit can help dissipate excess energy through its braking resistor.
The published internal shunt specifications include 50 W continuous power and 5,600 W peak power. Actual braking capability depends on operating conditions, duty cycle, and system configuration.
5. Multi-Axis System Coordination
The axis module operates as part of a coordinated motion system. The controller can command multiple axes to move independently or according to synchronized motion profiles.
This architecture is useful for machines requiring accurate positioning, repeatable movement, and coordinated mechanical operations.
Role in Industrial Motion Control Systems
The 2094-BMP5 is designed for modular servo systems in which multiple axes share a common power architecture.
Integration with the Kinetix 6000 Power Rail
The module mounts on a compatible Kinetix 6000 power rail. The rail provides the physical mounting arrangement and electrical connections needed to distribute DC bus power and other system connections.
Correct rail selection is essential. The power rail must support the required number of modules and be compatible with the installed system configuration.
Integration with the Integrated Axis Module
The integrated axis module provides the main power-conversion and system power functions for the Kinetix 6000 installation. The 2094-BMP5 receives the DC bus power required for its inverter operation through the system architecture.
The IAM and axis modules must be selected according to the system voltage class, power requirements, and installation design.
Integration with Motion Controllers
A compatible motion controller generates the commands used to coordinate servo movement. The controller manages position, speed, acceleration, and other motion parameters according to the application program.
The axis module provides the electrical power interface for the motor, while the controller manages motion behavior.
Servo Motor Integration
The 2094-BMP5 must be paired with a compatible servo motor. Motor voltage, current, feedback type, cable configuration, and performance requirements must be verified before installation.
A mismatch between the motor and drive configuration can cause commissioning problems, faults, or unsuitable operating performance.
Industrial Applications
The Kinetix 6000 platform is designed for industrial applications requiring coordinated servo motion. The 2094-BMP5 can be used in systems where its electrical ratings and axis-control capabilities match the motor and machine requirements.
1. Packaging Machinery
Packaging equipment frequently uses servo motors for product feeding, sealing, cutting, and indexing. Accurate movement helps maintain consistent product spacing and production timing.
A Kinetix 6000 system can coordinate several axes to perform these operations as part of one machine sequence.
2. Material Handling Systems
Automated material-handling equipment may require servo-controlled positioning, lifting, transfer, or indexing. Servo control allows machine movements to follow defined motion profiles.
The 2094-BMP5 can provide the inverter function for a compatible axis in such a system.
3. Automated Assembly Lines
Assembly machinery often requires precise positioning of components, tools, and workpieces. Servo systems can coordinate multiple movements to support repeatable production operations.
The axis module can be incorporated into a multi-axis arrangement controlled by a compatible motion controller.
4. Printing and Converting Equipment
Printing and converting machinery may use synchronized servo axes to control rollers, feeding mechanisms, cutting systems, and material positioning.
Coordinated motion helps maintain process timing and registration accuracy.
5. Industrial Robotics and Special Machinery
Some special-purpose machines use several servo axes for coordinated movement. The Kinetix 6000 system can provide the power and control architecture for compatible applications.
The final selection depends on motor requirements, axis count, motion performance, and the system’s electrical configuration.
Installation and System Integration
Correct installation is essential for reliable servo operation and electrical safety.
1. Verify System Voltage and Compatibility
The 2094-BMP5 belongs to the 400/460 V-class axis module family. Confirm that the installed Kinetix 6000 system uses the correct voltage class and compatible power architecture.
Check the IAM, power rail, motor, feedback components, and other installed modules before replacing an existing axis module.
2. Install on the Correct Power Rail
The module is designed to mount on a compatible Kinetix 6000 power rail. Confirm the rail type, available slot, module orientation, and mounting arrangement.
The dimensions supplied for this listing are 287 × 70 × 249 mm. Use the manufacturer’s dimensional drawings to verify actual mounting and clearance requirements.
3. Connect the Servo Motor
Connect the motor power and feedback cables according to the applicable installation documentation. Verify connector type, cable routing, grounding, shielding, and bend radius.
Incorrect motor or feedback connections can result in drive faults or unexpected motion.
4. Configure Motion Parameters
After installation, configure the servo axis through the compatible motion-control environment. Required settings may include motor selection, feedback configuration, axis scaling, travel limits, motion profiles, and fault responses.
Use the correct motor and axis data rather than copying parameters from a different drive or motor configuration.
5. Check Shunt and Regenerative Requirements
The module has an internal shunt circuit, but the complete system’s regenerative-energy requirements must still be evaluated.
Applications involving frequent deceleration, high inertia, or multiple regenerative axes may require additional system-level braking analysis. Confirm that the internal shunt capacity and any external shunt arrangements are appropriate for the actual duty cycle.
6. Commission the Axis
Before operating the machine, verify the electrical connections, motor feedback, axis direction, travel limits, and emergency-stop behavior.
Test the axis at low speed before proceeding to normal operating conditions. Confirm that the motion controller reports the correct feedback and that the motor responds to commands as expected.
Compatible System Components
The 2094-BMP5 is designed to work with other components in the Kinetix 6000 architecture.
| Component | Function | Compatibility Considerations |
|---|---|---|
| Kinetix 6000 Integrated Axis Module | Provides the main power-conversion and system power functions | Match voltage class and system power requirements |
| Kinetix 6000 Power Rail | Provides mounting and electrical distribution | Select a compatible rail with sufficient axis slots |
| Kinetix 6000 Motion Controller | Coordinates servo-axis commands | Verify supported controller and motion architecture |
| Compatible Servo Motor | Converts electrical power into mechanical motion | Check motor voltage, current, feedback, and performance |
| Motor Power Cable | Carries power to the servo motor | Match motor connector and current requirements |
| Feedback Cable | Transfers motor feedback signals | Confirm feedback type and connector compatibility |
| Shunt Module | Provides additional regenerative-energy handling where required | Evaluate system braking requirements |
| Slot-Filler Module | Covers unused power-rail positions | Use the appropriate Kinetix 6000 accessory |
| Control Cabinet | Houses and protects the servo system | Provide suitable cooling, grounding, and clearances |
Component compatibility should be confirmed using the exact catalog numbers and hardware revisions. Not every component listed above is included with the 2094-BMP5.
Alternative Models and Replacement Considerations
The 2094-BMP5 belongs to the Kinetix 6000 400/460 V axis module family. Related models have different current ratings and may not be suitable as direct replacements.
| Model | Description | Important Difference |
|---|---|---|
| 2094-BMP5 | Kinetix 6000, 400/460 V-class, 4 A axis module | Original model covered in this article |
| 2094-BM01 | Kinetix 6000, 400/460 V-class, 9 A axis module | Higher inverter current rating |
| 2094-BM02 | Kinetix 6000, 400/460 V-class, 15 A axis module | Higher current capacity |
| 2094-BM03 | Kinetix 6000, 400/460 V-class, 30 A axis module | Designed for larger servo-axis requirements |
| 2094-BM05 | Kinetix 6000, 400/460 V-class, 49 A axis module | Higher-capacity axis module |
The 2094-BMP5-S is a related version with Safe Torque-Off functionality. The suffix is significant and should be checked against the machine’s safety architecture. Do not substitute the -S version or a non-S version without verifying the required safety functions and system design.
When selecting a replacement, compare:
- Complete catalog number and suffix.
- Voltage class and DC bus compatibility.
- Continuous and peak current requirements.
- Servo motor model and feedback configuration.
- Power rail compatibility.
- IAM and system power capacity.
- Shunt and regenerative-energy requirements.
- Safety functions and machine safety design.
- Firmware and controller compatibility.
- Physical dimensions and installation clearances.
A higher-current module is not automatically a suitable replacement. The entire servo system must be evaluated before making a substitution.
Key Advantages
Modular Multi-Axis Architecture
The Kinetix 6000 system allows multiple axis modules to operate within a shared power architecture. This supports coordinated motion in machines with several servo motors.
Dedicated Servo-Axis Control
The 2094-BMP5 provides the inverter function for an individual servo axis, allowing the system to control motor movement according to programmed motion commands.
400/460 V-Class Operation
Its voltage class supports compatible industrial servo systems designed around the Kinetix 6000 400/460 V architecture.
Integrated Shunt Circuit
The internal shunt circuit helps manage regenerative energy within its specified power limits.
Industrial Motion Control Integration
The module can work with compatible motion controllers, servo motors, feedback cables, and power-rail components to support automated production equipment.
Established Installed Base
Kinetix 6000 equipment remains relevant in existing industrial installations. Accurate identification of the original module can help maintenance teams source spare parts and plan system upgrades.
Technical FAQs
1. What is the Allen-Bradley 2094-BMP5?
It is a Kinetix 6000 axis module designed to control one servo axis in a compatible multi-axis motion-control system.
2. What voltage class does the 2094-BMP5 support?
It belongs to the 400/460 V-class axis module family. The module receives DC bus power through the Kinetix 6000 system architecture.
3. What is its inverter current rating?
The 2094-BMP5 has a 4 A inverter current rating. Its published continuous output current is approximately 2.8 A RMS.
4. What is the nominal continuous output power?
The published nominal continuous output power is approximately 1.7 kW. Actual operating capability depends on the motor and system conditions.
5. Is the 2094-BMP5 a complete servo drive?
No. It is an axis module intended for use with a Kinetix 6000 power rail and compatible system power components. It does not function as a standalone complete servo system.
6. Does the module include a shunt circuit?
Yes. The published specifications identify an internal shunt with 50 W continuous power and 5,600 W peak power. Application-specific regenerative-energy requirements should still be evaluated.
7. What is the difference between 2094-BMP5 and 2094-BMP5-S?
The suffix identifies a safety configuration difference. The -S version includes the Safe Torque-Off feature, while the standard 2094-BMP5 should not be assumed to provide that same function.
8. Can the 2094-BMP5 replace a 2094-BM01?
Not automatically. The 2094-BM01 has a higher inverter current rating. Replacement requires checking motor requirements, system configuration, power rail, and control parameters.
9. What should be checked before purchasing a replacement?
Verify the full catalog number, series, hardware revision, physical condition, terminal and connector condition, and compatibility with the installed Kinetix 6000 system. For critical applications, request appropriate functional testing.
10. What is the supplied weight of the 2094-BMP5?
The supplied listing weight is 2.44 kg. This is consistent with the published module weight for the 2094-BMP5. Confirm the actual shipping weight separately if packaging and accessories are included.
Procurement and Maintenance Recommendations
When sourcing the Allen-Bradley 2094-BMP5, begin by confirming the complete catalog number on the installed module. Pay particular attention to the difference between 2094-BMP5 and 2094-BMP5-S because the safety configuration affects replacement decisions.
For used or refurbished equipment, request clear photographs of the nameplate, connectors, mounting surfaces, and overall condition. Check for signs of physical damage, contamination, overheating, or damaged electrical contacts. Where possible, request functional test information and confirm the seller’s warranty and return conditions.
Before installing a replacement, verify compatibility with the existing power rail, IAM, servo motor, feedback cable, and motion controller. Back up the relevant axis configuration and document the original system settings.
During maintenance, inspect connectors, cables, grounding, cabinet ventilation, and the surrounding power components. Follow the manufacturer’s procedures for isolation and discharge before handling the servo drive system.
For long-term maintenance planning, consider the availability of compatible spare modules and the potential requirements of a future motion-system upgrade. A replacement from a newer servo-drive family may require changes to wiring, controller configuration, software, and commissioning procedures.
Conclusion
The Allen-Bradley 2094-BMP5 Kinetix 6000 Axis Module is a 400/460 V-class servo axis module with a 4 A inverter current rating. It provides the inverter function for a single servo axis and operates as part of a Kinetix 6000 multi-axis motion-control system.
With an approximately 2.8 A RMS continuous output current, an internal shunt circuit, and integration with the Kinetix 6000 power-rail architecture, the module is designed for compatible industrial motion-control applications.
For maintenance and replacement projects, accurate catalog-number verification is essential. Engineers and buyers should confirm the voltage class, current rating, safety configuration, motor compatibility, and system architecture before selecting or installing a replacement.