

ProductPRODUCT
Featured products
Contact Us
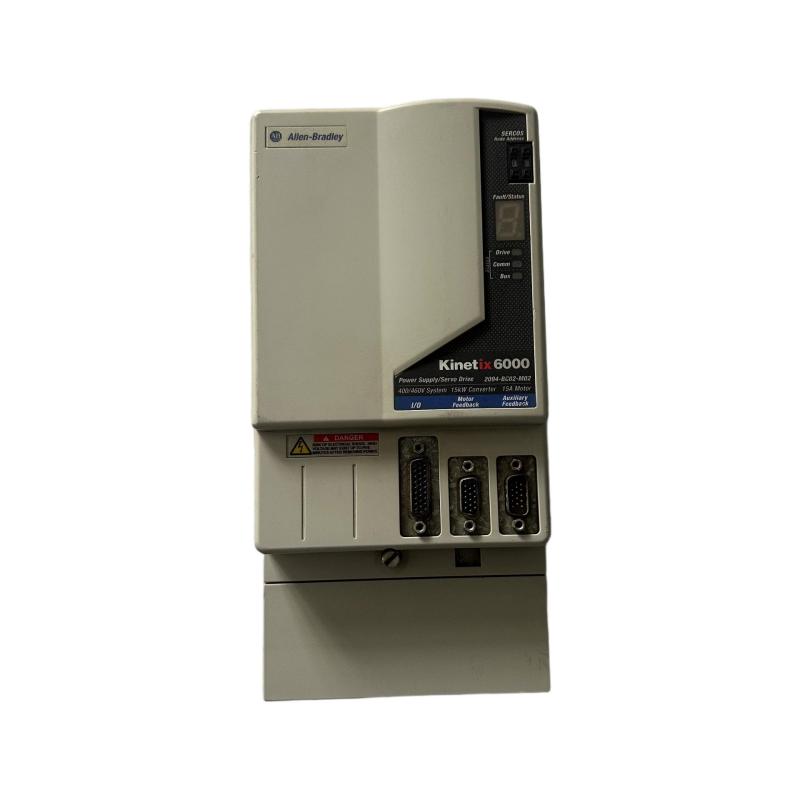
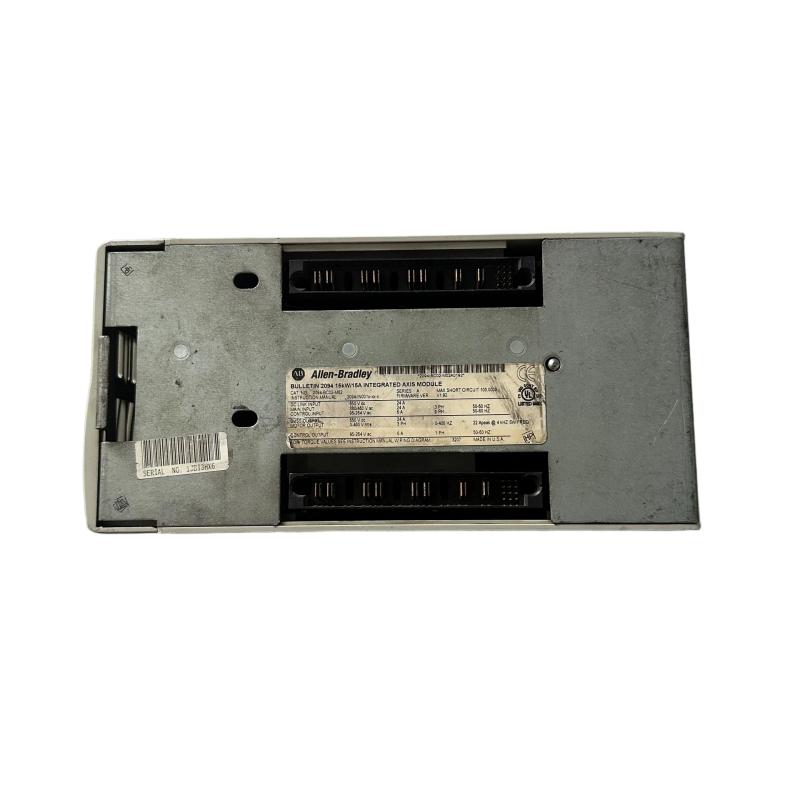
- Allen Bradley
- 2094-BC02-M02
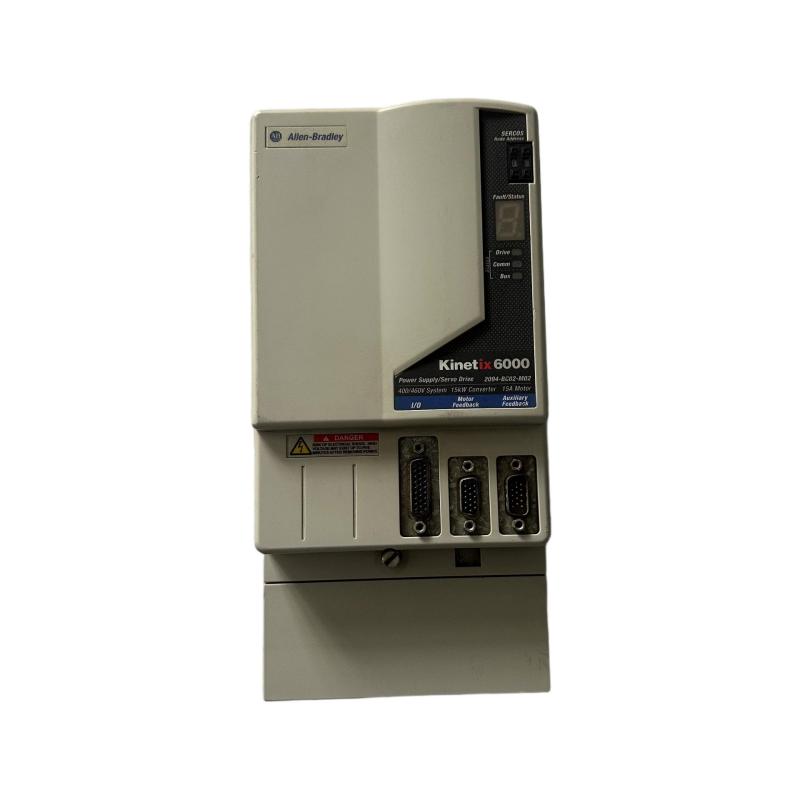
- Kinetix 6000 Integrated Axis Module
- USA
- 287 x 125 x 249 mm
- 5.08 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
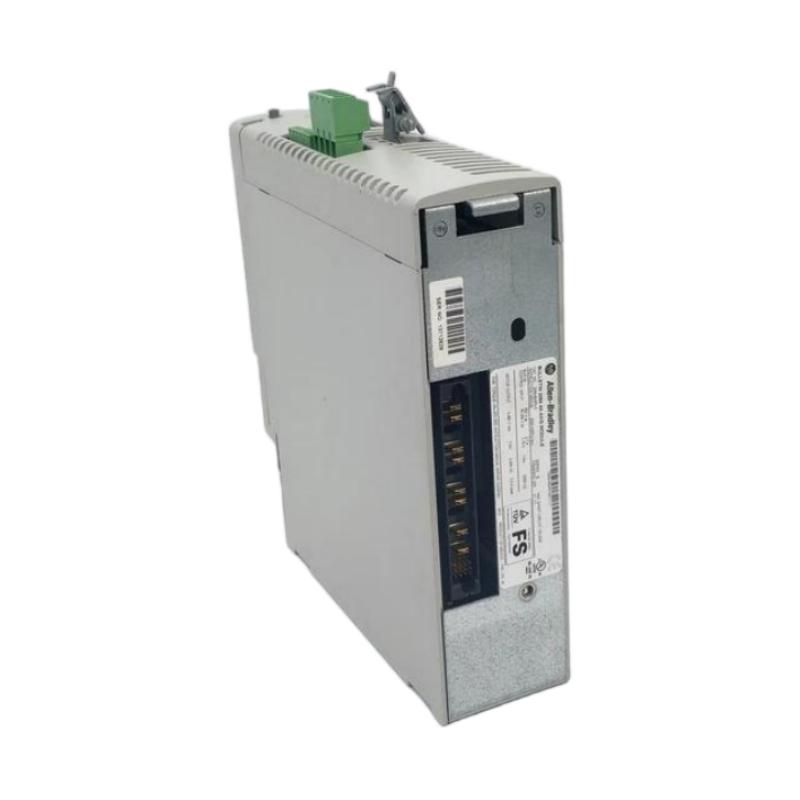
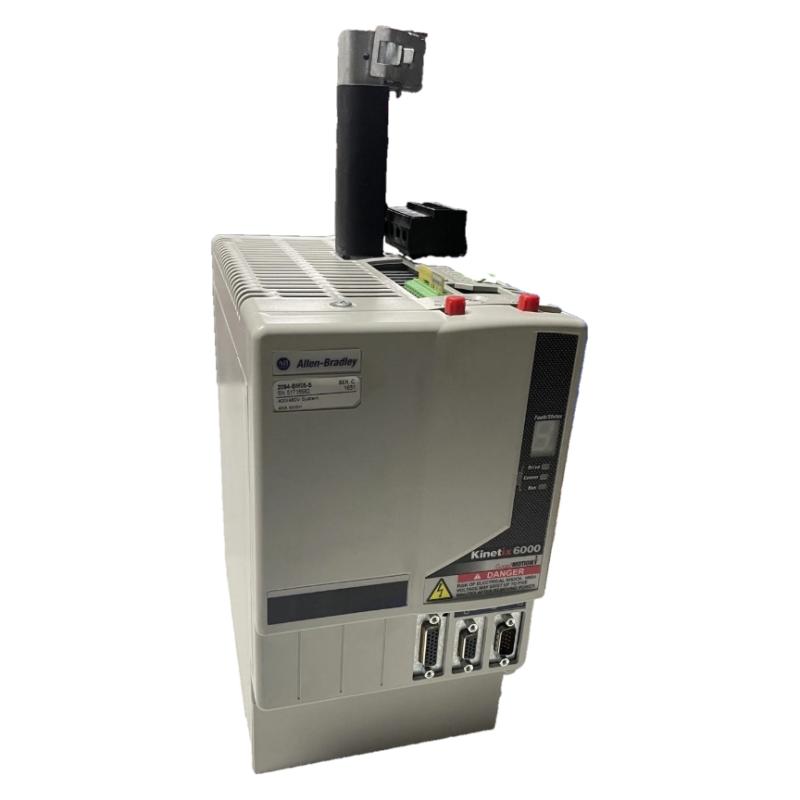
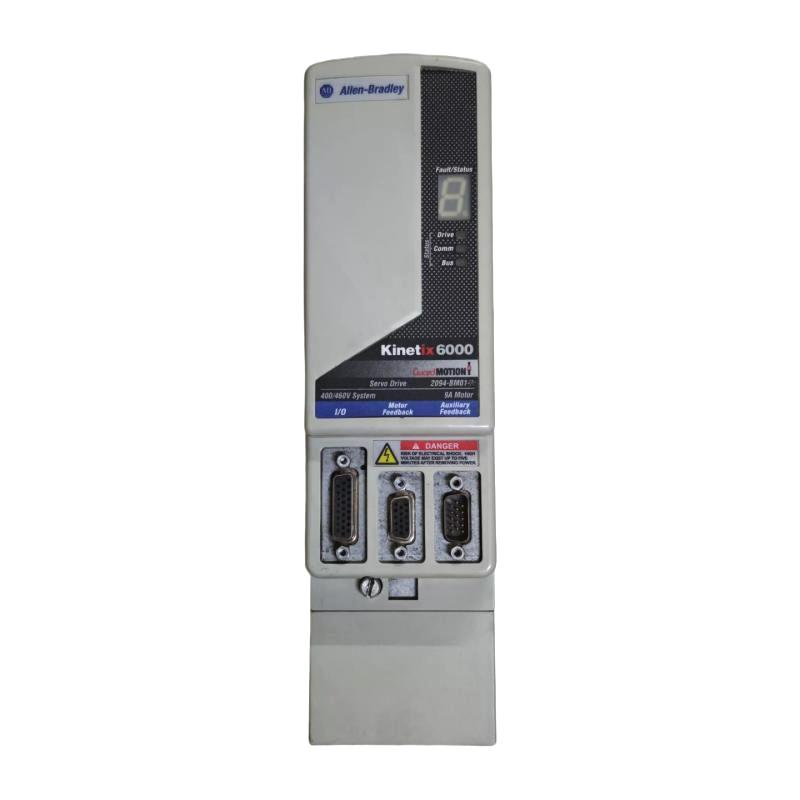
The Allen-Bradley 2094-BC02-M02 Kinetix 6000 Integrated Axis Module (IAM) is a servo drive power module designed for multi-axis motion control systems. Manufactured by Rockwell Automation, it combines the converter and inverter sections required to supply and control servo drive components within a Kinetix 6000 architecture.
In industrial automation, servo systems are used when machinery requires accurate speed, torque, and position control. Applications such as packaging equipment, material-handling machinery, automated assembly lines, and production equipment often require several servo axes to operate in a coordinated manner. The Kinetix 6000 platform provides a modular architecture for these applications.
The 2094-BC02-M02 is a 400/460 V-class Integrated Axis Module. Its configuration is associated with a 15 kW converter rating and a 15 A inverter rating. The converter section supplies the common DC bus, while the inverter section provides controlled power for the associated servo axis.
As an Integrated Axis Module, it serves as a central power component in a multi-axis Kinetix 6000 installation. It works with compatible axis modules, power rails, servo motors, feedback devices, and motion controllers to create a coordinated motion-control system.
The catalog number is important when identifying this module. Versions with additional suffixes may have different safety or control configurations. For example, the 2094-BC02-M02-S is a separately identified Safe Torque-Off version. Buyers should not assume that all variants provide identical safety functions.
The 2094-BC02-M02 is primarily relevant to maintenance, replacement, and continued operation of existing Kinetix 6000 installations. Its suitability must be evaluated against the electrical ratings and hardware configuration of the complete servo system.
Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Allen-Bradley |
| Manufacturer | Rockwell Automation |
| Model | 2094-BC02-M02 |
| Product Series | Kinetix 6000 |
| Product Type | Integrated Axis Module (IAM) |
| Bulletin | 2094 |
| Voltage Class | 400/460 V |
| Input Supply | Three-phase AC |
| Nominal Voltage Class | 360/480 V AC |
| Converter Power Rating | 15 kW |
| Inverter Current Rating | 15 A class |
| System Architecture | Multi-axis servo drive |
| Main Function | Power conversion and servo-axis power control |
| Mounting Architecture | Compatible 2094 power rail system |
| Dimensions Provided | 287 × 125 × 249 mm |
| Weight Provided | 5.08 kg |
| Typical Application | Industrial multi-axis motion control |
Note: Confirm the exact series and hardware revision on the product nameplate. Specifications and available functions can vary between catalog-number variants and revisions.
Function and Working Principle
The 2094-BC02-M02 operates as the central power module in a Kinetix 6000 multi-axis servo drive system. Its main function is to convert incoming AC power into the DC bus power required by the connected servo axis modules.
1. AC Power Conversion
The module receives three-phase AC power within its specified voltage class. Its converter section processes the incoming electrical supply and provides DC bus power for the servo drive system.
The DC bus provides a common power source for compatible axis modules installed on the same power rail. This architecture allows several servo axes to share a coordinated power system.
Correct supply voltage, phase configuration, protective devices, and grounding are essential for reliable operation.
2. DC Bus Distribution
After conversion, DC power is distributed through the compatible Kinetix 6000 power rail architecture.
The common DC bus supplies the connected axis modules, which independently control their associated servo motors. This arrangement reduces the need for separate complete power-conversion assemblies for every axis.
The number and type of connected modules must follow the system’s electrical ratings and installation requirements.
3. Servo Axis Power Control
The inverter section provides controlled electrical power for the associated servo axis. Servo drive control electronics regulate motor operation according to commands received from the motion-control system.
Depending on the connected motor and feedback configuration, the system can regulate torque, speed, and position.
The 15 A inverter rating is an important selection parameter. The connected axis and motor must remain within the permitted current and power limits.
4. Coordinated Motion Control
The Kinetix 6000 system is designed for applications in which multiple servo axes operate together.
A motion controller coordinates commands for individual axes, while the IAM supplies the required power to the system. This architecture supports synchronized motion in machines that perform feeding, positioning, cutting, packaging, or assembly operations.
The IAM provides the power infrastructure; it does not independently replace the motion controller or the axis-control modules.
5. Regenerative Energy Management
During deceleration, a servo motor can return energy to the drive system. This is known as regenerative energy.
The Kinetix 6000 architecture includes provisions for managing energy within the DC bus and the overall drive system. The system designer must evaluate the regenerative energy produced by the application and determine whether additional shunt or energy-management hardware is required.
The correct arrangement depends on the number of axes, motor inertia, stopping frequency, and operating cycle.
Role in Industrial Control Systems
The 2094-BC02-M02 is an important power component in a multi-axis servo control architecture. It works alongside motion controllers, axis modules, servo motors, feedback devices, and machine-level automation equipment.
Motion Controller Integration
A motion controller generates motion commands and coordinates the operation of connected servo axes.
The controller determines the required movement profile, including position, speed, and acceleration. The Kinetix 6000 drive system executes these commands through its servo control architecture.
This coordination is essential in machines where several motors must move together with accurate timing.
PLC and Machine Control Integration
A PLC can coordinate the overall machine sequence, including sensors, actuators, safety interlocks, and production operations.
In a typical installation, the PLC manages machine-level logic while the motion controller handles detailed servo motion. The IAM supplies power to the connected servo drive components.
This division of responsibilities helps organize complex industrial automation systems.
Servo Motor Coordination
The IAM supplies the power infrastructure for compatible axis modules. These modules control individual servo motors according to the motion commands they receive.
Servo motors may be used for conveyor positioning, rotary indexing, synchronized feeding, robotic movement, and other applications requiring controlled motion.
Feedback and Position Monitoring
Servo systems commonly use feedback devices such as encoders or other compatible position sensors.
Feedback information allows the motion-control system to compare commanded movement with actual motor performance. The controller can then adjust the drive command to maintain the required motion profile.
The exact feedback interface depends on the connected servo motor and axis-module configuration.
Industrial Applications
The Allen-Bradley 2094-BC02-M02 is designed for industrial applications requiring multi-axis servo control and a common power architecture.
1. Packaging Machinery
Packaging equipment often uses several servo motors to coordinate product feeding, film movement, cutting, sealing, and indexing.
A Kinetix 6000 system can provide the power architecture required for these synchronized movements. The IAM supplies power to the connected axis modules, while the motion controller coordinates the operating sequence.
2. Automated Assembly Lines
Automated assembly equipment may require multiple motors to position workpieces, operate indexing tables, and control mechanical assemblies.
Servo systems provide controlled movement that can help maintain repeatable production cycles.
The 2094-BC02-M02 can serve as the central power module in a compatible Kinetix 6000 installation.
3. Material-Handling Equipment
Material-handling systems may use servo motors for lifting, positioning, feeding, and transfer operations.
Coordinated servo control can support accurate movement and synchronization between different machine sections.
System designers must verify the required torque, speed, inertia, and regenerative-energy characteristics before selecting the drive hardware.
4. Printing and Converting Machinery
Printing and converting machines frequently require synchronized motor operation to maintain material tension, feeding speed, and registration accuracy.
A multi-axis servo architecture can coordinate several motors to support consistent machine performance.
The IAM provides the shared power infrastructure for the compatible axis modules in the drive system.
5. Industrial Automation Equipment
The module may also be used in specialized manufacturing machinery, automated positioning systems, and other equipment built around the Kinetix 6000 platform.
Its suitability depends on the connected servo axes, motor ratings, power requirements, and control-system configuration.
Installation and System Integration
Correct installation is essential for electrical safety, reliable operation, and long-term system performance.
1. Verify the Electrical Supply
Before installation, confirm that the incoming supply matches the module’s 400/460 V-class requirements.
Check the following:
- Three-phase supply voltage.
- Supply frequency.
- Input current requirements.
- Protective-device ratings.
- Grounding and bonding arrangements.
- System short-circuit current rating.
The power supply must be compatible with the complete Kinetix 6000 system, not just the IAM.
2. Install on the Compatible Power Rail
The 2094-BC02-M02 is designed for the Kinetix 6000 modular power rail architecture.
Confirm that the power rail is the correct type and voltage class. Check the permitted module arrangement and ensure that the connected axis modules are compatible with the IAM.
Mechanical mounting must follow the manufacturer’s installation instructions.
3. Connect the DC Bus System
The IAM supplies the DC bus for compatible axis modules. Ensure that the power rail connections and associated electrical interfaces are correctly installed.
Incorrect installation can cause electrical faults, unstable operation, or damage to connected components.
4. Configure the Servo System
After installation, configure the motion-control system according to the connected motors, axis modules, and application requirements.
Verify motor parameters, feedback configuration, axis assignments, motion profiles, and fault-handling procedures.
The motion controller and servo drive components must use compatible hardware and firmware configurations.
5. Evaluate Regenerative Energy
Applications involving frequent deceleration or high-inertia loads may return significant energy to the DC bus.
Evaluate the regenerative energy generated by all connected axes. Determine whether the existing shunt or energy-management arrangement is adequate.
Do not assume that an existing installation can support additional servo axes without reviewing the total power and regenerative-energy requirements.
6. Commission and Test
Before returning the machine to operation, inspect the power connections, grounding, module mounting, and system wiring.
Perform commissioning checks for:
- Correct supply voltage.
- DC bus operation.
- Axis-module communication.
- Servo motor direction.
- Feedback signal operation.
- Motion profiles.
- Emergency stop and safety functions.
- Fault detection and recovery.
Document the final system configuration and parameter settings for future maintenance.
Compatible System Components
The 2094-BC02-M02 operates as part of a Kinetix 6000 servo drive system. The following components are commonly associated with this architecture.
| Component | Example Model | Function |
|---|---|---|
| Integrated Axis Module | 2094-BC02-M02 | Converts AC power and supplies the common DC bus |
| Axis Module | 2094-BM02 | Controls an individual servo axis |
| Power Rail | 2094-PRS series | Provides the modular mounting and electrical connection structure |
| Shunt Module | 2094-BSP2 | Supports management of regenerative energy |
| Line Interface Module | 2094-BL series | Provides line-interface functions in compatible system configurations |
| Servo Motor | MP-series compatible motors | Converts electrical power into controlled mechanical motion |
| Feedback Device | Compatible motor encoder | Provides motor position and speed feedback |
| Motion Controller | Compatible Rockwell Automation controller | Coordinates multi-axis motion |
| PLC | ControlLogix or compatible controller | Executes machine-level control logic |
Compatibility depends on voltage class, hardware revision, system design, and the applicable Rockwell Automation documentation. The listed components are examples and are not necessarily included with the IAM.
Alternative Models and Replacement Considerations
When replacing a 2094-BC02-M02, the replacement must match the electrical and functional requirements of the original Kinetix 6000 installation.
| Model or Product Family | Description | Replacement Considerations |
|---|---|---|
| 2094-BC01-M01 | Kinetix 6000 IAM | Different converter and inverter ratings |
| 2094-BC02-M02-S | Kinetix 6000 IAM with Safe Torque-Off configuration | Safety configuration differs; verify exact application requirements |
| 2094-BC04-M03 | Higher-rated Kinetix 6000 IAM | Different power and current ratings |
| 2094-BC07-M05 | Higher-capacity Kinetix 6000 IAM | Requires complete system-level compatibility review |
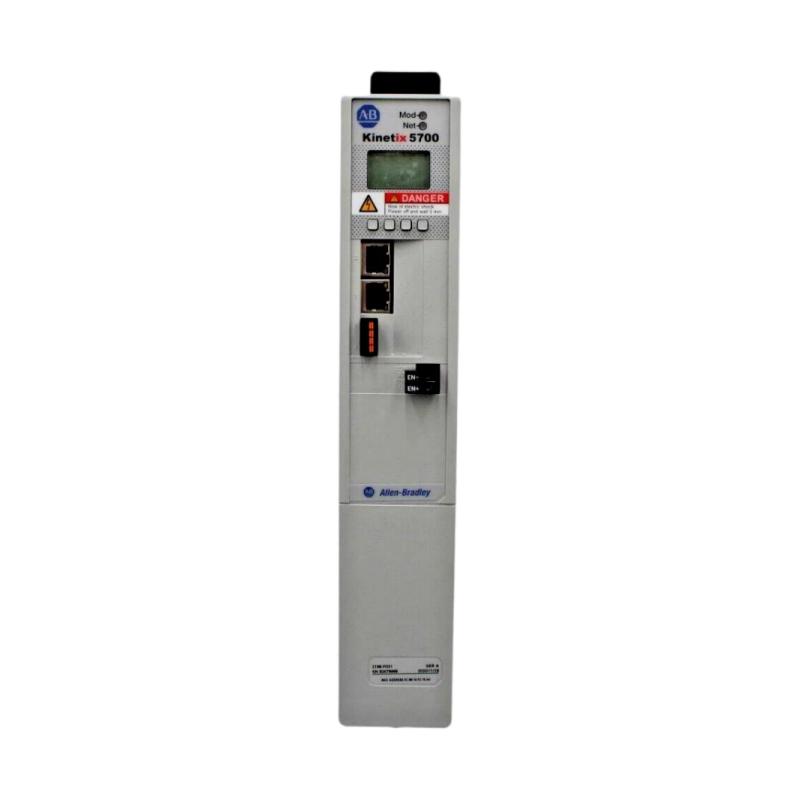
| Kinetix 5700 | Newer Rockwell Automation servo drive family | May require architectural changes, new components, and recommissioning |
The newer Kinetix 5700 family should not be treated as a direct plug-in replacement. A migration may involve changes to power distribution, motor connections, feedback interfaces, network architecture, and motion-control software.
Before selecting an alternative, verify the complete catalog number, voltage class, converter rating, inverter rating, safety requirements, power rail arrangement, and connected axis modules.
Key Advantages
Integrated Power Architecture
The IAM combines converter and inverter functions within one module, providing a central power component for a compatible multi-axis servo system.
Multi-Axis System Support
The common DC bus architecture allows compatible axis modules to operate within one coordinated Kinetix 6000 installation.
Industrial Motion Control
The module supports servo applications requiring controlled motor movement, speed regulation, and coordinated machine operation.
Modular System Design
The Kinetix 6000 platform uses a modular architecture that allows system designers to configure installations according to the required number of servo axes.
Established Installed Base
The Kinetix 6000 family has been used in industrial motion-control systems. Accurate identification of existing hardware is therefore important for maintenance and spare-parts procurement.
Service and Replacement Applications
The 2094-BC02-M02 remains relevant to facilities maintaining existing Kinetix 6000 equipment. A correctly matched replacement can help restore an established servo system without immediately redesigning the entire machine.
Technical FAQs
1. What is the Allen-Bradley 2094-BC02-M02?
It is a Kinetix 6000 Integrated Axis Module designed to provide AC-to-DC power conversion and inverter power for a servo axis within a multi-axis motion-control system.
2. What voltage class does the module support?
The 2094-BC02-M02 belongs to the 400/460 V class. The actual supply requirements must be confirmed against the module nameplate and the complete system documentation.
3. What is its converter power rating?
The documented converter rating is 15 kW.
4. What is its inverter current rating?
The module is identified with a 15 A inverter rating. The connected servo motor and axis requirements must remain within the applicable system limits.
5. What is the difference between an IAM and an AM?
An Integrated Axis Module combines the converter and inverter sections and supplies the common DC bus. An Axis Module receives DC bus power and controls an individual servo axis.
6. Can the 2094-BC02-M02 work with multiple servo axes?
Yes. It is designed for the Kinetix 6000 multi-axis architecture and can supply compatible axis modules through the power rail. The number and type of modules must follow system power and configuration limits.
7. Does the 2094-BC02-M02 include Safe Torque-Off?
Do not assume that it does. The separately identified 2094-BC02-M02-S version is documented with Safe Torque-Off. Always verify the complete catalog number and the actual safety architecture.
8. Is the 2094-BC02-M02 discontinued?
The Kinetix 6000 family has entered the discontinued-product lifecycle. Buyers should confirm current availability and replacement guidance directly against the exact catalog number and installed hardware revision.
9. What should be checked before purchasing a replacement?
Verify the complete catalog number, series, voltage class, converter rating, inverter current, hardware revision, safety configuration, physical condition, and compatibility with the existing power rail and axis modules.
10. Can a Kinetix 5700 module directly replace this IAM?
Not automatically. Kinetix 5700 belongs to a different servo drive architecture. A migration requires engineering evaluation of power distribution, motor and feedback interfaces, communications, control software, and system safety.
Procurement and Maintenance Recommendations
When purchasing the Allen-Bradley 2094-BC02-M02, begin by checking the complete catalog number and the label on the existing module. Pay particular attention to suffixes and hardware revisions, because similar catalog numbers may represent different safety and control configurations.
For used or refurbished units, request clear photographs of the nameplate, front panel, terminals, and mounting interfaces. Confirm whether the module has been tested and whether any repair history is available.
During maintenance, inspect the power rail connections, grounding, electrical terminals, and cabinet ventilation. Check for visible contamination, overheating, or damage to the module housing. Follow the manufacturer’s procedures for electrical isolation and DC bus discharge before servicing the equipment.
Keep a record of the system configuration, connected axis modules, motion-controller settings, and commissioning parameters. This information can reduce troubleshooting time and help maintenance teams identify compatible replacement components.
Because the Kinetix 6000 platform is a legacy system, spare-parts planning is important. Facilities should assess the availability of critical IAMs, axis modules, power rails, and associated components. For long-term modernization, evaluate whether the existing architecture should be maintained or migrated to a newer servo platform.
Conclusion
The Allen-Bradley 2094-BC02-M02 Kinetix 6000 Integrated Axis Module is a central power component for industrial multi-axis servo systems. With a 400/460 V-class configuration, a 15 kW converter rating, and a 15 A inverter rating, it supports the power requirements of compatible Kinetix 6000 motion-control installations.
Its integrated converter and inverter architecture provides a common DC bus for connected servo axis modules. For maintenance and replacement projects, engineers should verify the complete catalog number, hardware revision, voltage class, safety configuration, and compatibility with the existing power rail.
Accurate product identification and proper system-level evaluation are essential for maintaining reliable operation of legacy Kinetix 6000 servo equipment.