ProductPRODUCT
Featured products
Contact Us
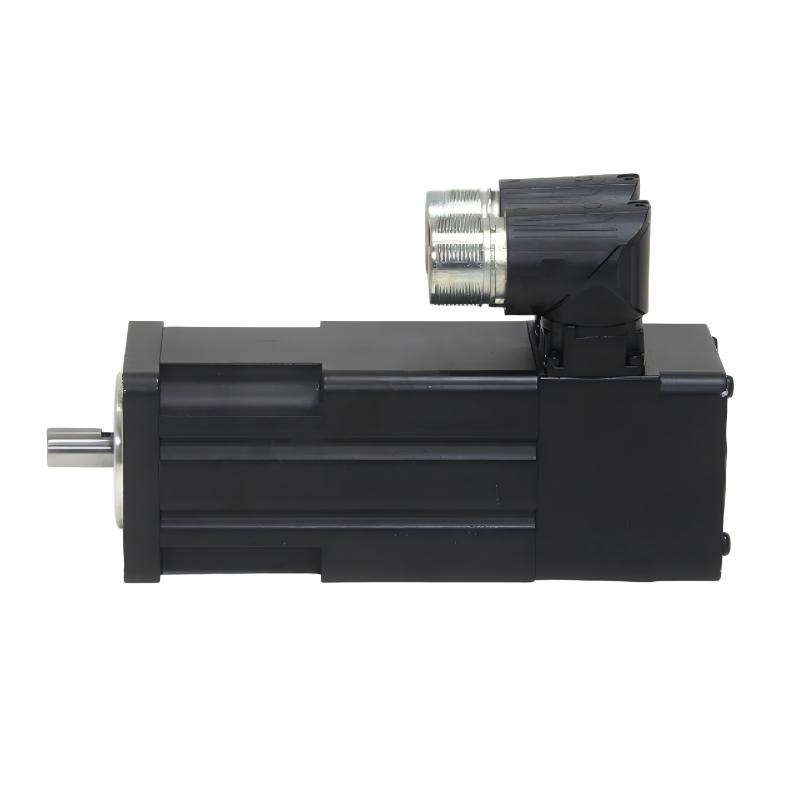
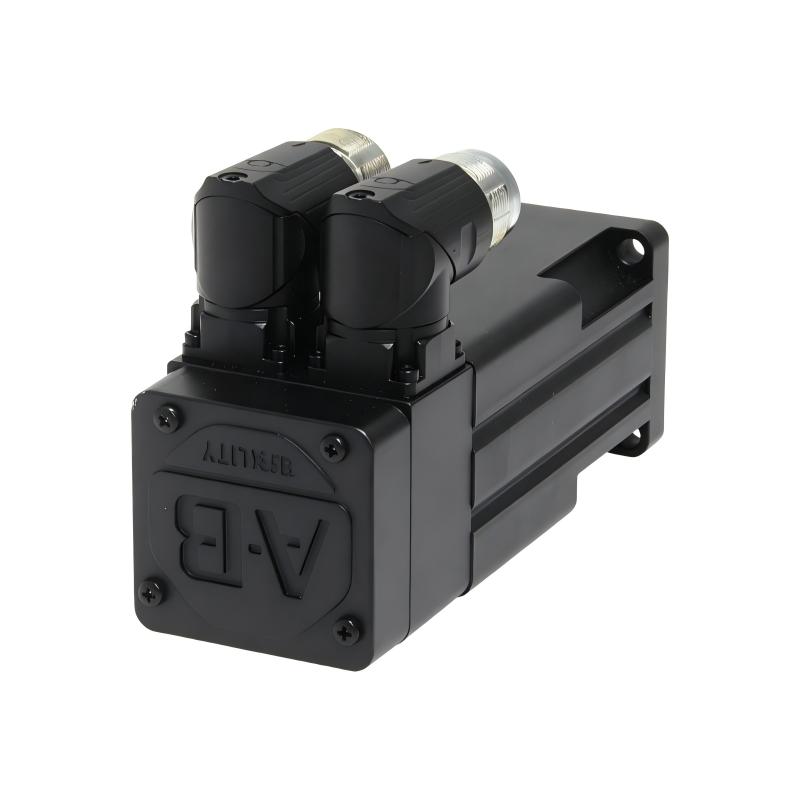
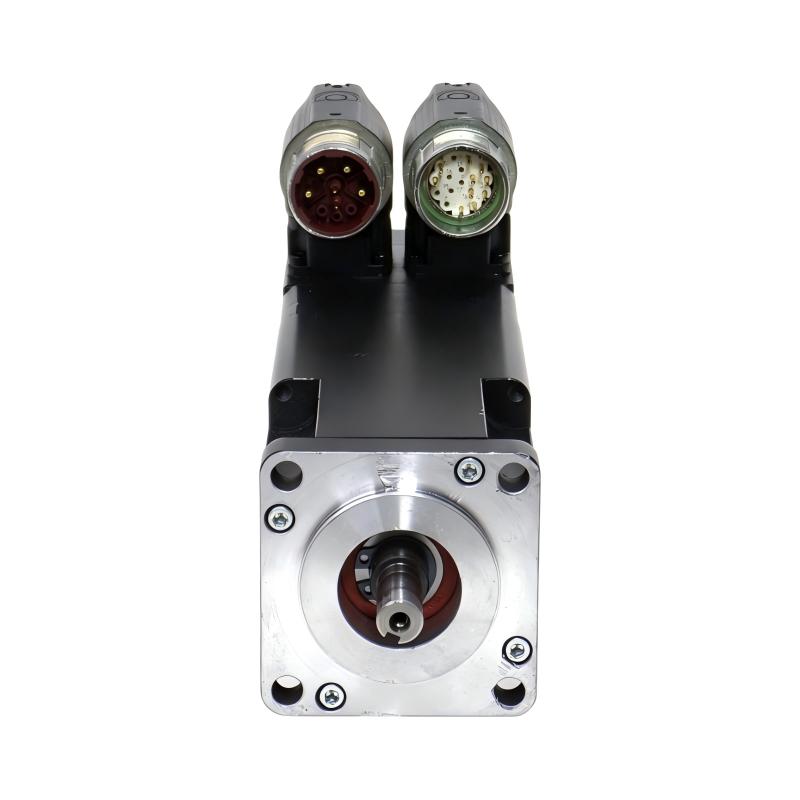
- Allen Bradley
- MPL-A1530F-V-X207
- MP Electric Cylinder Replacement Motor
- USA
- 40 mm frame class
- 10kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 17
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
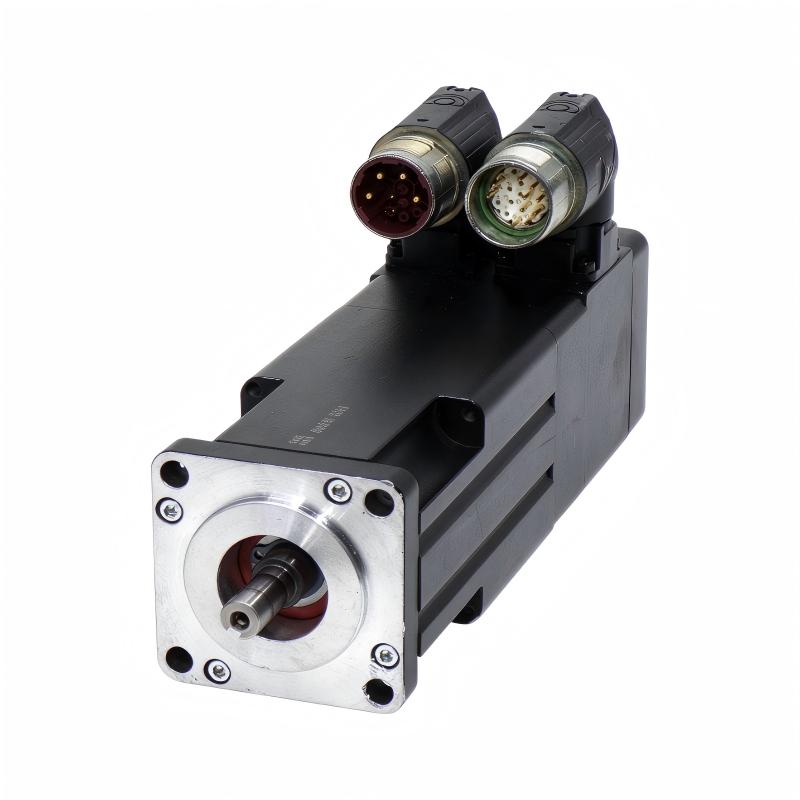
MPL-A1530F-V-X207 Low-Inertia Servo Motor – Detailed Product Overview, Specifications, Applications and Related Models
1. Product Overview
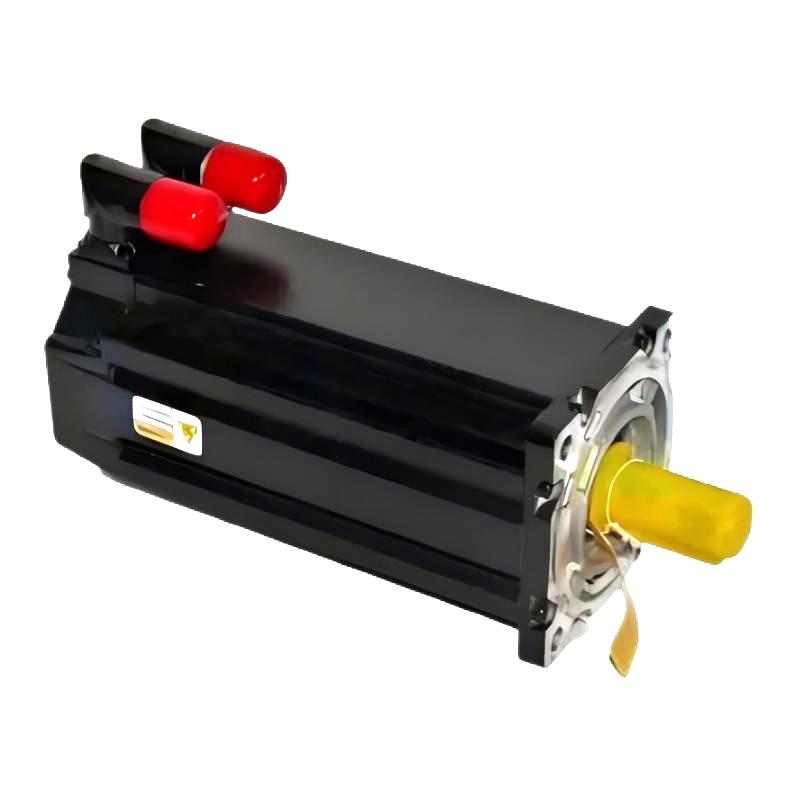
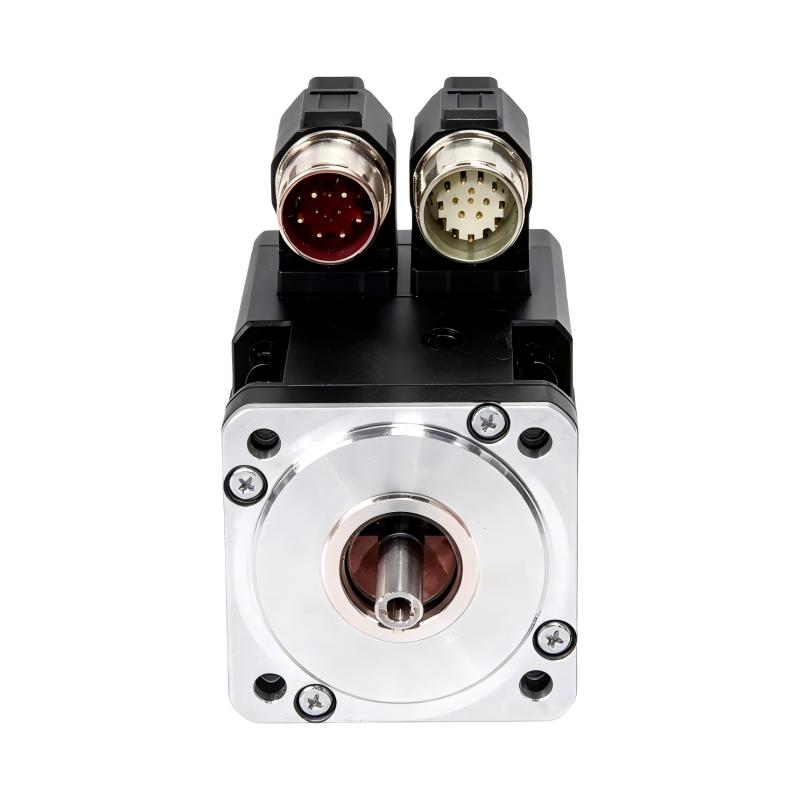
The MPL-A1530F-V-X207 is a low-inertia servo motor used as a replacement motor for MP-Series electric-cylinder systems. It belongs to the MPL family of brushless servo motors and is specifically associated with electric-cylinder configurations that use a 40 mm frame size and a 5.0 mm/rev mechanical pitch.
This model is the non-brake version of the X207/X208 motor pair. The corresponding brake-equipped version is MPL-A1530F-V-X208, which uses a 24 V DC holding brake.
The MPL-A1530F-V-X207 is intended for applications where a compact, responsive servo motor is required to drive a precision mechanical actuator. Its low rotor inertia allows the motor to respond quickly to changes in commanded speed and position, making it suitable for positioning applications where acceleration, deceleration and repeatability are important.
The motor is also closely associated with MP-Series electric-cylinder systems. In this type of application, the rotary motion of the servo motor is converted into controlled linear movement through the actuator’s internal mechanical transmission.
2. Brand and Product Series
| Item | Details |
|---|---|
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Servo Motors |
| Product Type | Low-Inertia Brushless Servo Motor |
| Model / Catalog Number | MPL-A1530F-V-X207 |
| Application Type | Electric-cylinder replacement motor |
| Voltage Class | 200 V class |
| Frame Size | 40 mm |
| Mechanical Pitch | 5.0 mm/rev |
| Brake | None |
| Motor Construction | Brushless servo motor |
| Intended System | MP-Series electric-cylinder applications |
| Typical Control | Servo drive / motion controller |
| Mounting | Machine or actuator-mounted |
| Feedback | Servo feedback system, configuration-dependent |
| Dimensions | 40 mm frame class; complete envelope is configuration-dependent |
| Weight | Not reliably specified as a universal standalone value; configuration-dependent |
The MPL-A1530F-V-X207 should therefore be viewed less as a general-purpose standalone induction motor and more as a precision motion component designed for integration into a servo-controlled mechanical system.
3. Main Technical Parameters
| Parameter | MPL-A1530F-V-X207 Specification |
|---|---|
| Model | MPL-A1530F-V-X207 |
| Product Series | MPL Low-Inertia Servo Motors |
| Motor Type | Brushless low-inertia servo motor |
| Voltage Class | 200 V |
| Frame Size | 40 mm |
| Pitch | 5.0 mm/rev |
| Pitch in Inches | 0.197 in./rev |
| Brake | None |
| Brake Voltage | Not applicable |
| Intended Use | MP-Series electric-cylinder replacement |
| Motion Type | Servo-controlled rotary motion converted to linear motion |
| Feedback | Servo feedback, system-dependent |
| Installation | Actuator / machine mounted |
| Dimensions | 40 mm frame class; full dimensions depend on motor/actuator configuration |
| Weight (kg) | Configuration-dependent; exact standalone shipping weight should be confirmed before mechanical design or logistics planning |
| Control Method | Closed-loop servo control |
| Application Category | Precision positioning and linear motion |
| Motor Family | MPL |
| Associated Actuator Family | MPAR-series electric cylinders |
4. Understanding the MPL-A1530F-V-X207 Model Number
The catalog number contains useful information about the motor configuration.
| Model Section | Meaning |
|---|---|
| MPL | MPL low-inertia servo motor family |
| A | 200 V-class motor family |
| 1530 | Motor size / performance designation |
| F | Motor construction/configuration designation |
| V | Voltage / winding configuration designation |
| X207 | Electric-cylinder replacement motor configuration |
The final X207 designation is particularly important because this is not simply a generic MPL motor configuration. It identifies a replacement-motor configuration associated with a particular MP-Series electric-cylinder arrangement.
For the X207 configuration, the important mechanical characteristic is the 5.0 mm/rev pitch and the 40 mm frame size.
5. Mechanical Characteristics
The MPL-A1530F-V-X207 uses a 40 mm frame size, placing it above the 32 mm-frame configurations in the same replacement-motor group.
Its 5.0 mm/rev pitch configuration is intended for a balance between linear travel and mechanical force transmission.
In an electric-cylinder system, pitch is an important parameter because it determines how much linear travel is produced for each revolution of the motor’s mechanical transmission.
For example, a 5.0 mm/rev pitch means that one revolution of the associated mechanical screw or transmission corresponds to approximately 5.0 mm of linear movement, assuming the actuator’s mechanical arrangement directly follows that pitch.
This makes the X207 configuration different from the X205/X206 configuration, which uses a 10.0 mm/rev pitch.
6. Brake Configuration
The MPL-A1530F-V-X207 does not include a motor brake.
This distinction is important when selecting a replacement motor.
The closely related MPL-A1530F-V-X208 is the brake-equipped version and incorporates a 24 V DC brake.
| Model | Frame Size | Pitch | Brake |
|---|---|---|---|
| MPL-A1530F-V-X205 | 32 mm | 10.0 mm/rev | None |
| MPL-A1530F-V-X206 | 32 mm | 10.0 mm/rev | 24 V DC |
| MPL-A1530F-V-X207 | 40 mm | 5.0 mm/rev | None |
| MPL-A1530F-V-X208 | 40 mm | 5.0 mm/rev | 24 V DC |
The brake should not be treated as a minor option. A brake-equipped and non-brake motor can have different mechanical and control requirements, particularly when the actuator must hold a vertical load after servo power is removed.
7. Product Introduction
The MPL-A1530F-V-X207 is designed around the requirements of precision servo motion.
Unlike a conventional motor intended primarily to provide continuous rotation, a servo motor is used as part of a closed-loop motion system. The controller continuously commands the required position, velocity or torque, while feedback allows the system to monitor actual motor movement.
The low-inertia design is particularly useful when the application requires frequent changes in speed or direction.
A machine may need to accelerate quickly, move a precise distance, decelerate smoothly and immediately begin another movement. Lower motor inertia helps reduce the amount of energy that must be controlled during these transitions.
The motor is therefore well suited to equipment where dynamic response is more important than simply maintaining a constant rotational speed.
8. Low-Inertia Design
One of the main characteristics of the MPL family is its low-inertia servo construction.
Low motor inertia can provide several practical benefits.
When the commanded speed changes, the servo drive does not need to overcome as much rotational inertia from the motor rotor. This can improve acceleration and deceleration response.
For positioning applications, this can make it easier for the control system to follow a rapidly changing motion profile.
Typical motion sequences can include:
- Rapid acceleration.
- Controlled deceleration.
- Short-distance positioning.
- Repeated forward and reverse movement.
- High-frequency positioning cycles.
- Synchronization with other machine axes.
- Precise linear actuator movement.
The actual achievable performance still depends on the servo drive, mechanical load, feedback system, actuator configuration and tuning.
9. Electric-Cylinder Application
The MPL-A1530F-V-X207 is particularly relevant to MP-Series electric-cylinder replacement applications.
An electric cylinder converts the motor’s rotary motion into linear mechanical motion.
A simplified motion chain is:
Servo controller → Servo drive → MPL motor → Mechanical transmission → Linear actuator → Machine load
The servo controller determines the required movement.
The servo drive supplies controlled electrical power to the motor.
The MPL motor produces controlled rotary motion.
The actuator’s mechanical transmission converts this rotation into linear movement.
The machine then uses that linear movement for positioning, pushing, pulling, clamping or other automated operations.
10. Typical Applications
Packaging Machinery
The motor can be used in packaging machinery where an actuator must repeatedly move to predefined positions.
Typical movements include product positioning, pushing, indexing, forming and feeding.
Servo control is useful because the machine can change acceleration, velocity and position according to the production cycle.
Material Handling
Electric-cylinder systems can be used for controlled linear movement in material-handling equipment.
Examples include:
- Product transfer.
- Stop mechanisms.
- Linear positioning.
- Lift or push mechanisms.
- Automated alignment.
- Workpiece handling.
The low-inertia motor configuration is useful where the actuator needs to repeatedly start and stop.
Assembly Equipment
Automated assembly equipment often requires accurate linear positioning.
The motor can be used with an electric-cylinder arrangement to move tooling or components to specific positions.
Potential applications include:
- Component insertion.
- Part positioning.
- Pressing operations.
- Fixture movement.
- Automated assembly stations.
- Workpiece alignment.
Machine Tools
Servo-driven linear actuators can be used for auxiliary positioning functions in machine tools.
The key benefit is controlled motion rather than simply continuous motor rotation.
Depending on the machine architecture, servo-driven linear movement may be used for tool positioning, workpiece positioning or auxiliary mechanisms.
Robotics and Automation
Industrial automation systems frequently require coordinated movement between multiple axes.
An electric-cylinder system driven by a servo motor can form one axis of a larger machine.
The motion controller can coordinate this axis with other servo motors, conveyors, rotary tables or robotic mechanisms.
11. Main Advantages
11.1 Low-Inertia Response
The low-inertia motor design is suitable for applications involving frequent acceleration and deceleration.
This can be particularly valuable in high-cycle machinery.
11.2 Precision Motion Control
Because the motor operates within a servo system, position, speed and torque can be controlled through the servo drive and motion controller.
This makes it suitable for applications requiring repeatable movement.
11.3 Compact 40 mm Frame
The 40 mm frame configuration provides a relatively compact motor package while supporting a different mechanical configuration from the smaller 32 mm-frame models.
11.4 5.0 mm/rev Pitch
The 5.0 mm/rev configuration provides a relatively fine mechanical pitch.
Compared with a 10.0 mm/rev configuration, a 5.0 mm/rev pitch provides less linear travel per revolution but can be advantageous where controlled linear positioning and mechanical resolution are important.
11.5 No Brake Configuration
The X207 configuration does not include a brake.
This can be useful in horizontal applications where a holding brake is not required and where a simpler motor configuration is preferred.
If a holding brake is required, the X208 version should be considered instead.
11.6 Suitable for Replacement Applications
The model was specifically used as a replacement motor configuration for compatible MP-Series electric-cylinder arrangements.
This makes the exact catalog number important when replacing an existing motor.
A visually similar MPL motor should not automatically be considered interchangeable.
12. Five Closely Related Models
The following models are closely related to MPL-A1530F-V-X207 and are useful when comparing replacement configurations.
| Model | Voltage Class | Frame Size | Pitch | Brake | Main Difference | Dimensions | Weight (kg) |
|---|---|---|---|---|---|---|---|
| MPL-A1520F-V-X203 | 200 V | 32 mm | 3.0 mm/rev | None | Smaller frame / finer pitch | 32 mm frame class; full envelope configuration-dependent | Configuration-dependent |
| MPL-A1530F-V-X205 | 200 V | 32 mm | 10.0 mm/rev | None | Smaller frame / higher pitch | 32 mm frame class; full envelope configuration-dependent | Configuration-dependent |
| MPL-A1530F-V-X206 | 200 V | 32 mm | 10.0 mm/rev | 24 V DC | Brake-equipped alternative | 32 mm frame class; full envelope configuration-dependent | Configuration-dependent |
| MPL-A1530F-V-X208 | 200 V | 40 mm | 5.0 mm/rev | 24 V DC | Directly related brake version | 40 mm frame class; full envelope configuration-dependent | Configuration-dependent |
| MPL-A220F-V-X209 | 200 V | 40 mm | 12.7 mm/rev | None | Same frame class, different motor/pitch configuration | 40 mm frame class; full envelope configuration-dependent | Configuration-dependent |
Among these, MPL-A1530F-V-X208 is the closest functional comparison because it uses the same basic X207 configuration family but adds a 24 V DC brake.
13. Same-Series Model Comparison
| Model | Voltage | Frame | Pitch | Brake | Typical Use |
|---|---|---|---|---|---|
| MPL-A1520F-V-X203 | 200 V | 32 mm | 3.0 mm/rev | No | Fine-pitch actuator |
| MPL-A1520F-V-X204 | 200 V | 32 mm | 3.0 mm/rev | 24 V | Fine-pitch actuator with holding brake |
| MPL-A1530F-V-X205 | 200 V | 32 mm | 10.0 mm/rev | No | Higher linear travel per revolution |
| MPL-A1530F-V-X206 | 200 V | 32 mm | 10.0 mm/rev | 24 V | Higher-pitch actuator with brake |
| MPL-A1530F-V-X207 | 200 V | 40 mm | 5.0 mm/rev | No | 40 mm-frame precision actuator |
| MPL-A1530F-V-X208 | 200 V | 40 mm | 5.0 mm/rev | 24 V | 40 mm-frame actuator with brake |
| MPL-A220F-V-X209 | 200 V | 40 mm | 12.7 mm/rev | No | Higher-pitch linear movement |
| MPL-A220F-V-X210 | 200 V | 40 mm | 12.7 mm/rev | 24 V | Higher-pitch movement with brake |
| MPL-A330F-M-X211 | 200 V | 63 mm | 10.0 mm/rev | No | Larger actuator configuration |
| MPL-A330F-M-X212 | 200 V | 63 mm | 10.0 mm/rev | 24 V | Larger actuator configuration with brake |
This comparison shows why the complete catalog number matters. Two motors may both belong to the MPL family while having substantially different mechanical characteristics.
14. Five Representative Models From the Same Brand
The following are representative models from the same brand that are commonly relevant when building or maintaining servo-motion systems.
| Model | Product Family | Product Type | Voltage / System Class | Main Application | Dimensions | Weight (kg) |
|---|---|---|---|---|---|---|
| MPL-A1530U-VJ72AA | MP-Series | Rotary servo motor | 200/240 V class | General servo motion | Motor frame/envelope configuration-dependent | Configuration-dependent |
| MPL-A220F-V-X210 | MP-Series | Electric-cylinder replacement motor | 200 V | Linear actuator | 40 mm frame class | Configuration-dependent |
| MPL-A330F-M-X212 | MP-Series | Electric-cylinder replacement motor | 200 V | Larger linear actuator | 63 mm frame class | Configuration-dependent |
| MPL-B1530F-V-X220 | MP-Series | Electric-cylinder replacement motor | 400 V | Higher-voltage actuator systems | 40 mm frame class | Configuration-dependent |
| MPL-B220F-V-X222 | MP-Series | Electric-cylinder replacement motor | 400 V | Linear actuator with brake | 40 mm frame class | Configuration-dependent |
These models cover several different motion-system requirements, including standard rotary servo applications, 200 V-class electric-cylinder systems and 400 V-class actuator configurations.
15. Pitch Selection and Motion Characteristics
The pitch value is one of the most important specifications when selecting an electric-cylinder motor configuration.
For the MPL-A1530F-V-X207, the pitch is:
5.0 mm/rev
This means that the associated mechanical transmission is designed around approximately 5.0 mm of linear movement for each revolution.
For comparison:
| Model | Pitch | General Motion Characteristic |
|---|---|---|
| MPL-A1520F-V-X203 | 3.0 mm/rev | Finer movement per revolution |
| MPL-A1530F-V-X205 | 10.0 mm/rev | Greater linear travel per revolution |
| MPL-A1530F-V-X207 | 5.0 mm/rev | Intermediate pitch |
| MPL-A220F-V-X209 | 12.7 mm/rev | Higher linear travel per revolution |
| MPL-A330F-M-X211 | 10.0 mm/rev | Larger-frame actuator configuration |
| MPL-A420F-M-X213 | 20.0 mm/rev | High linear travel per revolution |
A smaller pitch generally provides more mechanical movement per motor revolution control point, while a larger pitch produces greater linear travel per revolution.
However, pitch should not be selected by itself. Load, required force, maximum speed, actuator stroke, duty cycle and servo-drive compatibility all need to be considered.
16. X207 Versus X208
The most direct comparison is between the X207 and X208 models.
| Feature | MPL-A1530F-V-X207 | MPL-A1530F-V-X208 |
|---|---|---|
| Voltage Class | 200 V | 200 V |
| Frame Size | 40 mm | 40 mm |
| Pitch | 5.0 mm/rev | 5.0 mm/rev |
| Brake | None | 24 V DC |
| Basic Mechanical Configuration | X207 | X208 |
| Suitable for MPAR 40 mm / 5 mm pitch configuration | Yes | Yes |
| Holding Brake | No | Yes |
| Typical Reason for Selection | Horizontal / non-braking application | Applications requiring holding brake |
If the original system uses X207, replacing it with X208 should not be considered a simple drop-in substitution without checking the electrical and mechanical requirements of the complete system.
The opposite is also true: replacing a brake-equipped motor with a non-brake version can remove an important holding function.
17. Dimensions and Weight
For industrial replacement motors, dimensions and weight can sometimes be listed differently depending on whether the specification refers to the motor itself, the replacement assembly, packaging or the complete electric-cylinder assembly.
For this reason, the reliable engineering-level information for this model is the 40 mm frame classification rather than an assumed complete three-axis envelope.
| Mechanical Parameter | Specification |
|---|---|
| Frame Size | 40 mm |
| Frame Class | 40 mm |
| Motor Configuration | MPL-A1530F-V-X207 |
| Pitch | 5.0 mm/rev |
| Brake | None |
| Overall Motor Length | Configuration-dependent |
| Shaft / Mounting Geometry | Configuration-dependent |
| Complete Actuator Dimensions | Dependent on electric-cylinder assembly |
| Shipping Dimensions | Dependent on packaging |
| Net Weight | Not reliably specified as a universal standalone figure |
| Weight (kg) | Configuration-dependent |
For replacement planning, the safest approach is to match the catalog number and existing actuator configuration rather than attempting to substitute based only on outside dimensions.
18. Servo Drive Compatibility
The MPL-A1530F-V-X207 is intended to operate as part of a compatible servo system rather than directly from a conventional AC motor starter.
The servo drive must be suitable for the motor’s voltage class, feedback arrangement and electrical characteristics.
A complete motion system normally includes:
- Motion controller.
- Servo drive.
- Servo motor.
- Feedback system.
- Mechanical actuator.
- Machine load.
- Appropriate motor and feedback cabling.
- Safety circuit.
The servo drive is responsible for regulating motor current and controlling the motor according to commands from the motion controller.
19. Replacement Considerations
When replacing an existing MPL-A1530F-V-X207, the following items should be checked.
Catalog Number
The complete catalog number should be compared.
Do not assume that another MPL-A1530 motor is automatically interchangeable.
Frame Size
The X207 uses the 40 mm frame configuration.
Pitch
The actuator must use the appropriate 5.0 mm/rev configuration.
Brake
The X207 is a non-brake motor.
If the machine requires a holding brake, the motor configuration must be evaluated accordingly.
Voltage Class
The X207 belongs to the 200 V class.
A 400 V-class motor from the MPL-B family should not be treated as a direct electrical replacement.
Mechanical Interface
The motor mounting, shaft/interface and actuator arrangement should match the existing system.
Feedback
The servo drive and feedback system must be compatible with the replacement motor.
20. Where This Model Fits in an Automation System
The MPL-A1530F-V-X207 can be considered the motor portion of a precision linear-motion system.
A typical arrangement is:
PLC / Motion Controller
↓
Servo Network / Motion Command
↓
Servo Drive
↓
MPL-A1530F-V-X207
↓
MP-Series Electric Cylinder
↓
Linear Mechanical Movement
↓
Machine Tool / Fixture / Product
This architecture provides controlled linear movement without requiring a pneumatic cylinder.
Compared with basic pneumatic motion, servo-driven electric-cylinder systems can provide programmable position, velocity and acceleration.
That makes them particularly useful when the machine needs multiple motion profiles rather than simple extend/retract movement.
21. Advantages Compared With Simple On/Off Actuation
A conventional actuator may only have two practical states: extended or retracted.
A servo-driven electric cylinder can provide multiple programmable positions.
For example, a machine may require:
- Move to position A.
- Slow down before position B.
- Stop at position B.
- Apply controlled force.
- Retract at a different speed.
- Return to the home position.
- Repeat the sequence.
The servo system can coordinate these movements with other machine axes.
This is one of the main reasons a low-inertia servo motor such as the MPL-A1530F-V-X207 is valuable in automated machinery.
22. Maintenance Considerations
Because the motor is part of a servo-driven actuator system, maintenance should consider the entire motion chain rather than the motor alone.
Important inspection areas include:
- Motor mounting.
- Mechanical coupling.
- Actuator mounting.
- Cable condition.
- Feedback wiring.
- Servo-drive alarms.
- Mechanical backlash.
- Abnormal vibration.
- Unusual noise.
- Excessive motor temperature.
- Repeated positioning errors.
- Lubrication of the mechanical actuator where applicable.
- Mechanical load changes.
If the motor begins producing positioning errors, replacing the motor immediately may not solve the problem.
Feedback cables, mechanical wear, actuator transmission components, servo tuning and load changes can also contribute to motion problems.
23. Product Selection Summary
| Selection Item | MPL-A1530F-V-X207 |
|---|---|
| Brand | Allen-Bradley |
| Series | MPL |
| Product Family | MP-Series |
| Product Type | Low-Inertia Servo Motor |
| Main Role | Electric-cylinder replacement motor |
| Voltage Class | 200 V |
| Frame Size | 40 mm |
| Pitch | 5.0 mm/rev |
| Brake | None |
| Motion Type | Servo-controlled linear motion through actuator |
| Main Application | Precision electric-cylinder motion |
| Feedback | System-dependent |
| Dimensions | 40 mm frame class; complete dimensions configuration-dependent |
| Weight (kg) | Configuration-dependent |
| Closest Brake Version | MPL-A1530F-V-X208 |
| Closely Related Smaller-Frame Version | MPL-A1530F-V-X205 / X206 |
| Higher-Pitch Related Version | MPL-A220F-V-X209 / X210 |
24. Recommended Related Models at a Glance
| Model | Frame | Pitch | Brake | Voltage | Relationship |
|---|---|---|---|---|---|
| MPL-A1520F-V-X203 | 32 mm | 3.0 mm/rev | No | 200 V | Smaller-frame, finer-pitch alternative |
| MPL-A1530F-V-X205 | 32 mm | 10.0 mm/rev | No | 200 V | Smaller-frame, higher-pitch alternative |
| MPL-A1530F-V-X206 | 32 mm | 10.0 mm/rev | 24 V | 200 V | Brake-equipped 32 mm configuration |
| MPL-A1530F-V-X208 | 40 mm | 5.0 mm/rev | 24 V | 200 V | Closest brake-equipped counterpart |
| MPL-A220F-V-X209 | 40 mm | 12.7 mm/rev | No | 200 V | Same frame class, higher pitch |
25. Final Product Summary
The MPL-A1530F-V-X207 is a 200 V-class MPL low-inertia servo motor with a 40 mm frame configuration, 5.0 mm/rev pitch and no holding brake.
Its primary role is as a replacement motor for compatible MP-Series electric-cylinder configurations.
The combination of a low-inertia servo motor and a 5.0 mm/rev actuator configuration makes it suitable for controlled linear motion where repeatable positioning, dynamic response and programmable movement are required.
The most important characteristics to remember are:
- 40 mm frame size
- 5.0 mm/rev pitch
- 200 V class
- No brake
- Low-inertia servo construction
- MP-Series electric-cylinder application
- Servo-controlled positioning
- Replacement-motor configuration
For applications requiring the same basic 40 mm / 5.0 mm-rev configuration but with a holding brake, MPL-A1530F-V-X208 is the closely related configuration to evaluate.
For applications using a smaller 32 mm frame, the MPL-A1530F-V-X205 and MPL-A1530F-V-X206 configurations are relevant comparisons.
For applications requiring a larger linear travel per revolution, the MPL-A220F-V-X209 and MPL-A220F-V-X210 configurations provide a different pitch arrangement.
The most important point when replacing this motor is to match the complete catalog number, voltage class, frame size, pitch, brake configuration, actuator compatibility and servo-drive requirements rather than selecting a motor based only on physical appearance.