ProductPRODUCT
Featured products
Contact Us
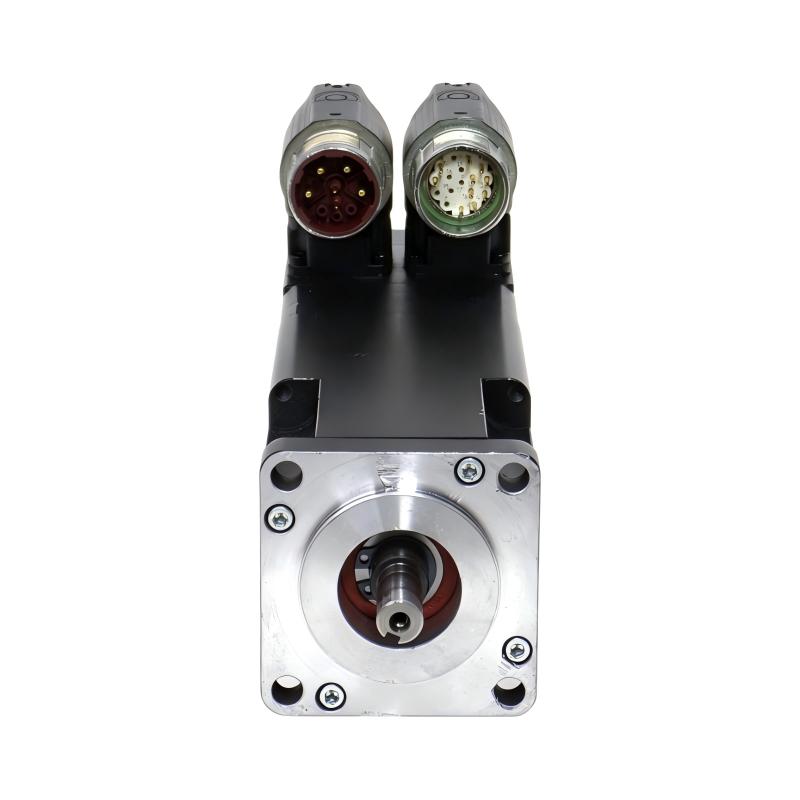
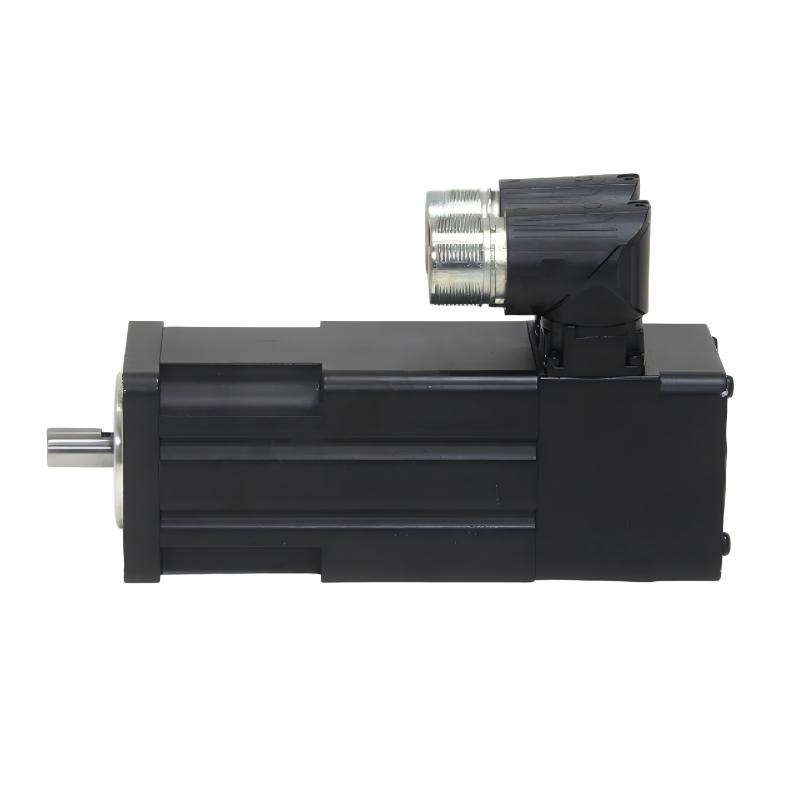
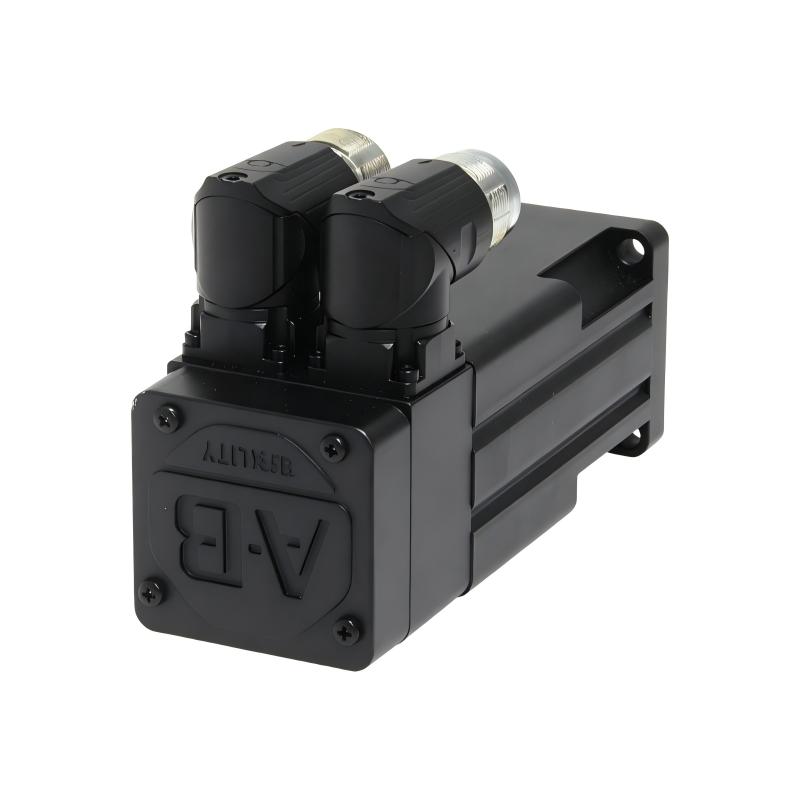
- Allen Bradley
- MPL-A1530F-V-X206
- MP Electric Cylinder Replacement Motor
- USA
- 203 × 25 × 35 mm
- 80kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 17
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
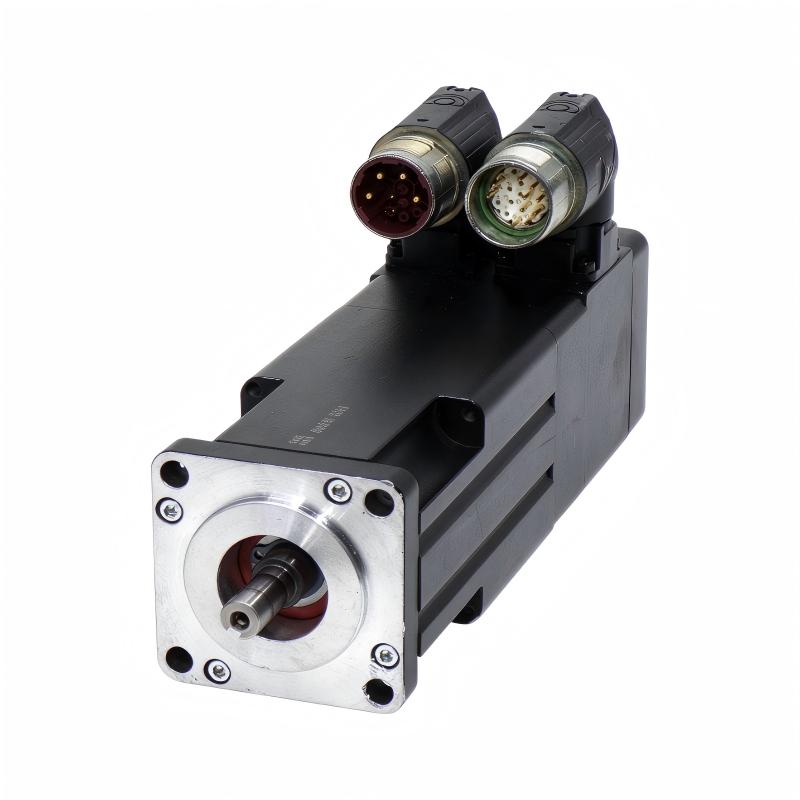
MPL-A1530F-V-X206 — Detailed Product Information, Specifications, Applications and Related Models
1. Product Overview
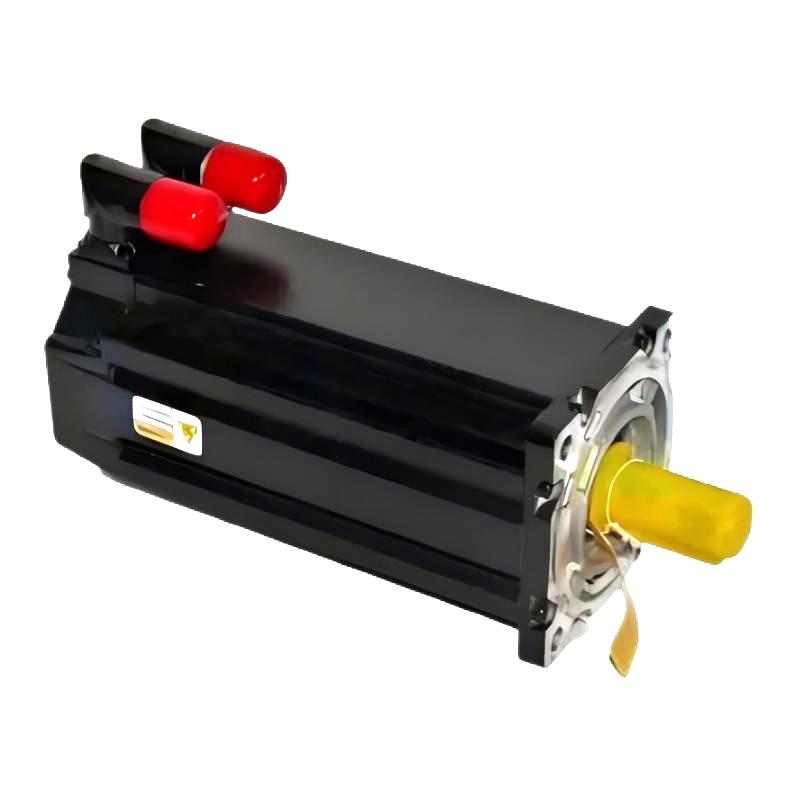
The MPL-A1530F-V-X206 is a low-inertia brushless servo motor belonging to the MPL Series of servo motors.
It is a motor configuration designed for motion-control applications where accurate speed, position, acceleration, and deceleration control are required. The motor is also used as a replacement motor for compatible electric-cylinder assemblies.
The MPL-A1530F-V-X206 configuration is a 230 V class, 3000 RPM servo motor with a Frame Size 6 mechanical configuration and an 80 stack-length designation. It incorporates a 24 V brake and is associated with the corresponding electric-cylinder configuration used for linear-motion applications.
This model is particularly relevant to applications where a rotary servo motor is used to provide controlled mechanical motion through an electric cylinder, actuator, gearbox, belt mechanism, screw mechanism, or other motion-transmission arrangement.
The motor is designed around the requirements of industrial motion control rather than simple constant-speed motor operation.
2. Brand and Product Series
| Item | Specification |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Servo Motors |
| Product Type | Brushless AC Servo Motor |
| Motor Type | Permanent-Magnet Brushless Servo Motor |
| Motor Class | Low-Inertia Servo Motor |
| Voltage Class | 230 V class |
| Rated / Maximum Speed Class | 3000 RPM |
| Frame Size | Size 6 |
| Stack Length | 80 |
| Stack Length, Metric | Approx. 203.2 mm |
| Brake | 24 V DC brake |
| Primary Function | Precision motion control |
| Typical Drive System | Servo drive / motion controller |
| Typical Application | Electric cylinders, linear actuators, positioning systems |
| Mounting | Machine-mounted servo motor |
| Feedback | Servo feedback system |
| Rotor Characteristic | Low inertia |
| Main Advantage | Fast dynamic response and precise motion control |
3. Important Model Identification
The catalog number MPL-A1530F-V-X206 is a highly specific motor configuration.
The model should not be interpreted simply as a generic 230 V servo motor.
The catalog number identifies a particular combination of:
- MPL servo-motor family
- 230 V class
- Frame size
- Motor stack length
- Mechanical configuration
- Feedback arrangement
- Brake configuration
- Electric-cylinder compatibility
The X206 designation is especially important because it distinguishes this motor from closely related X203, X204, X205, X207 and X208 configurations.
For replacement purposes, the complete catalog number should therefore be matched rather than selecting another MPL motor solely according to voltage or speed.
4. Main Technical Specifications
| Parameter | Specification |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Product Family | MP-Series |
| Product Series | MPL Low-Inertia Servo Motor |
| Motor Type | Brushless Servo Motor |
| Voltage Class | 230 V |
| Rated Speed Class | 3000 RPM |
| Frame Size | 6 |
| Frame Dimension Reference | Approx. 215 mm |
| Stack Length | 80 |
| Stack Length | Approx. 203.2 mm |
| Brake | 24 V DC brake |
| Inertia | Low-inertia design |
| Motor Application | Servo motion control |
| Control Type | Closed-loop servo control |
| Typical Motion | Rotary / linear motion through compatible mechanism |
| Electric-Cylinder Compatibility | Compatible MPAR-series electric-cylinder arrangement |
| Typical Drive | Compatible servo drive |
| Feedback | Integrated servo feedback system |
| Mounting | Industrial machine mounting |
| Housing | Industrial servo-motor construction |
| Cooling | Motor-surface / application-dependent cooling |
| Approx. Motor Length | Configuration-dependent |
| Approx. Motor Width | Frame-dependent |
| Approx. Motor Height | Frame-dependent |
| Weight (kg) | Configuration-dependent; exact shipping weight should be confirmed from the motor assembly specification |
5. Electrical Characteristics
The MPL-A1530F-V-X206 is a 230 V-class servo motor intended to operate as part of a matched servo system.
Unlike an ordinary induction motor, the servo motor is normally controlled through a servo drive that regulates current, torque, speed, and position.
The motor’s feedback system allows the controller to determine rotor position and motor operating conditions.
This makes the motor suitable for applications where the machine must move to a defined position repeatedly and accurately.
| Electrical Characteristic | Description |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Voltage Class | 230 V |
| Motor Type | Brushless permanent-magnet servo |
| Speed Class | 3000 RPM |
| Brake Voltage | 24 V |
| Brake | Integrated 24 V brake |
| Control | Closed-loop servo control |
| Feedback | Servo feedback |
| Drive Requirement | Compatible servo amplifier/drive |
| Motor Connection | Dedicated servo motor connection |
| Application | Precision motion |
| Operating Mode | Speed, torque and position control |
6. Mechanical Specifications
The motor belongs to a Frame Size 6 configuration.
The frame-size reference is approximately 215 mm, while the stack-length designation is 80, corresponding to approximately 203.2 mm.
These dimensions describe the motor’s mechanical classification and are not equivalent to the complete installed envelope.
The actual machine installation envelope can be larger because of the motor shaft, connector, brake components, cable bend radius, mounting flange, and clearance requirements.
| Mechanical Parameter | Specification |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Frame Size | 6 |
| Frame Reference | Approx. 215 mm |
| Stack Length | 80 |
| Stack Length in mm | Approx. 203.2 mm |
| Shaft | Servo-motor shaft |
| Mounting | Flange / machine mounting |
| Brake | Integrated 24 V brake |
| Connector Space | Required |
| Cable Bend Space | Required |
| Overall Length | Configuration-dependent |
| Overall Diameter | Frame-dependent |
| Mounting Dimensions | Frame-dependent |
| Weight (kg) | Configuration-dependent |
| Installation Orientation | Application-dependent |
Because this particular catalog number is a replacement-motor configuration associated with an electric-cylinder system, the exact finished weight and complete external dimensions should not be inferred from the model number alone.
For purchasing or replacement documentation, it is better to distinguish the motor’s frame and stack dimensions from its final shipping weight.
7. Product Introduction
Servo motors are designed for applications in which a motor must do more than simply rotate continuously.
A conventional motor may be used to drive a pump, fan, conveyor, or other machine at a relatively stable speed.
A servo motor is different.
It is intended to work together with a servo drive and feedback system so that the machine can control:
- Position
- Speed
- Torque
- Acceleration
- Deceleration
- Direction
- Motion profile
The MPL-A1530F-V-X206 belongs to this type of motion-control system.
Its low-inertia rotor design is particularly useful for applications requiring rapid changes in speed and direction.
8. Low-Inertia Servo Motor Design
One of the main characteristics of the MPL family is its low-inertia design.
Rotor inertia directly affects how quickly a servo system can accelerate or decelerate.
A lower-inertia motor can respond rapidly when the controller changes the commanded speed or position.
This characteristic is particularly useful for:
- High-speed positioning
- Repetitive motion
- Rapid indexing
- Short motion cycles
- Start-stop applications
- Electronic synchronization
- Linear positioning
The exact achievable machine performance depends on the motor, drive, mechanical load, transmission ratio, inertia ratio, control parameters, and application mechanics.
9. Integrated 24 V Brake
The MPL-A1530F-V-X206 configuration includes a 24 V brake.
The brake is mechanically associated with the motor and can be used to help hold the motor/load when the motor is not actively producing torque.
This is especially useful in applications where gravity or external mechanical forces could cause unwanted movement when the servo motor is disabled.
Typical examples include:
- Vertical axes
- Electric cylinders
- Lifting mechanisms
- Vertical positioning systems
- Mechanical actuators
The brake should not automatically be regarded as a replacement for a complete safety-braking system.
The application must determine whether additional mechanical or safety-related holding provisions are required.
10. Application with Electric Cylinders
One of the most important applications for this particular configuration is an electric-cylinder system.
An electric cylinder converts rotary motor motion into controlled linear motion.
A typical arrangement can be represented as:
Servo Motor → Mechanical Transmission → Screw Mechanism → Linear Actuator → Machine Load
The servo motor provides controlled rotation.
The mechanical transmission converts this rotation into linear displacement.
The servo controller can then command the cylinder to move to a specified position.
This makes the MPL-A1530F-V-X206 particularly useful in precision linear-motion applications.
11. Typical Applications
11.1 Electric Cylinders
This is one of the most relevant applications.
The motor can be integrated with a compatible electric cylinder to provide:
- Linear positioning
- Controlled extension
- Controlled retraction
- Force-related motion
- Repetitive positioning
- Automated machine movement
11.2 Linear Actuators
The motor can be used with screw-driven or other mechanical linear actuators.
Typical applications include:
- Machine positioning
- Workpiece positioning
- Automated adjustment
- Tool positioning
- Material handling
11.3 Packaging Machinery
Packaging machinery frequently requires rapid and accurate motion.
Servo motors are commonly used for:
- Product positioning
- Cutting
- Sealing
- Indexing
- Label positioning
- Film handling
- Pick-and-place mechanisms
The low-inertia characteristics are particularly useful for repeated acceleration and deceleration.
11.4 Material Handling
Servo motors can control:
- Linear slides
- Transfer systems
- Pick-and-place mechanisms
- Positioning axes
- Automated handling equipment
The motor’s feedback system allows controlled positioning rather than relying solely on fixed-speed operation.
11.5 Assembly Equipment
Automated assembly machines often need accurate and repeatable motion.
The motor can be used for:
- Part insertion
- Clamping
- Positioning
- Pressing
- Feeding
- Tool movement
11.6 Robotic and Automation Equipment
Servo motors are frequently used as motion axes in automated machinery.
Possible applications include:
- Rotary axes
- Linear axes
- Grippers
- Positioning mechanisms
- Automated tooling
11.7 Machine Tools
Precision motion is essential in machine tools.
Servo motors can provide controlled motion for:
- Positioning tables
- Feed axes
- Tool mechanisms
- Automated adjustments
- Auxiliary axes
12. Application Summary
| Application | Motion Requirement | Suitability |
|---|---|---|
| Electric Cylinder | Controlled linear movement | Very suitable |
| Linear Actuator | Position control | Suitable |
| Packaging Machine | Fast repetitive motion | Suitable |
| Assembly Machine | Accurate positioning | Suitable |
| Material Handling | Controlled transfer | Suitable |
| Pick-and-Place | Rapid acceleration/deceleration | Suitable |
| Machine Tool | Precision axis movement | Suitable |
| Automated Door/Actuator | Controlled linear movement | Suitable |
| Pressing Mechanism | Controlled motion | Suitable |
| Industrial Automation | Servo positioning | Suitable |
13. Product Advantages
13.1 Low-Inertia Rotor
The low-inertia design is one of the major characteristics of this motor.
It helps the servo system respond quickly to changes in the commanded motion.
This can be valuable when the machine repeatedly accelerates, decelerates, starts, stops, or reverses direction.
13.2 3000 RPM Speed Class
The 3000 RPM speed class provides a useful combination of motor speed and mechanical response for many industrial servo applications.
It can be paired with an appropriate mechanical transmission to obtain the required linear or rotary machine speed.
13.3 24 V Holding Brake
The integrated 24 V brake adds mechanical holding capability.
This is particularly useful for vertical or gravity-loaded axes.
13.4 Suitable for Linear Motion
The motor’s compatibility with electric-cylinder applications is an important practical advantage.
Instead of using the motor only as a rotary drive, the motor can be integrated into a controlled linear actuator system.
13.5 Precision Motion
The closed-loop servo arrangement allows the controller to monitor motor position and regulate the commanded motion.
This provides significantly more control than a basic fixed-speed motor.
13.6 Fast Dynamic Response
Low rotor inertia allows the motor to change speed quickly when the servo controller changes its command.
This is useful for machines with short cycle times.
13.7 Repeatability
A servo system can repeatedly move to programmed positions.
This is valuable for automated production equipment where consistent positioning is required.
14. Five Same-Series or Closely Related Models
The following five models are especially relevant because they are closely related MPL replacement-motor configurations.
They are useful for comparing brake options, frame configurations, pitch requirements, and compatible electric-cylinder arrangements.
| Model | Voltage Class | Frame Size | Pitch / Motion Class | Brake | Speed Class | Typical Use | Dimensions | Weight (kg) |
|---|---|---|---|---|---|---|---|---|
| MPL-A1530F-V-X205 | 200/230 V class | 32 | 10.0 mm/rev | No brake | 3000 RPM class | Electric-cylinder motor | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X206 | 200/230 V class | 32 | 10.0 mm/rev | 24 V brake | 3000 RPM class | Electric-cylinder motor | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X207 | 200/230 V class | 40 | 5.0 mm/rev | No brake | 3000 RPM class | Electric-cylinder motor | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X208 | 200/230 V class | 40 | 5.0 mm/rev | 24 V brake | 3000 RPM class | Electric-cylinder motor | Frame-dependent | Configuration-dependent |
| MPL-A1520F-V-X204 | 200/230 V class | 32 | 3.0 mm/rev | 24 V brake | Servo application | Electric-cylinder motor | Frame-dependent | Configuration-dependent |
The X205 and X206 configurations are particularly close to each other.
The main distinction is the brake configuration: X205 is the non-brake version, while X206 incorporates a 24 V brake.
Likewise, X207 and X208 form another related pair, with X208 incorporating the 24 V brake.
15. Same-Series Model Comparison
| Parameter | MPL-A1530F-V-X205 | MPL-A1530F-V-X206 | MPL-A1530F-V-X207 | MPL-A1530F-V-X208 | MPL-A1520F-V-X204 |
|---|---|---|---|---|---|
| Series | MPL | MPL | MPL | MPL | MPL |
| Motor Type | Low-inertia servo | Low-inertia servo | Low-inertia servo | Low-inertia servo | Low-inertia servo |
| Voltage Class | 200/230 V | 200/230 V | 200/230 V | 200/230 V | 200/230 V |
| Frame Class | 32 | 32 | 40 | 40 | 32 |
| Pitch | 10.0 mm/rev | 10.0 mm/rev | 5.0 mm/rev | 5.0 mm/rev | 3.0 mm/rev |
| Brake | No | 24 V | No | 24 V | 24 V |
| Typical Application | Electric cylinder | Electric cylinder | Electric cylinder | Electric cylinder | Electric cylinder |
| Dimensions | Frame-dependent | Frame-dependent | Frame-dependent | Frame-dependent | Frame-dependent |
| Weight (kg) | Configuration-dependent | Configuration-dependent | Configuration-dependent | Configuration-dependent | Configuration-dependent |
16. Five Additional Models from the Same Brand
The following products are representative servo and motion-control products from the same brand portfolio.
They are not direct replacements for MPL-A1530F-V-X206. They are included as broader alternatives for applications requiring servo motors, motion control, or related automation functions.
| Model | Product Family | Product Type | Voltage Class | Typical Application | Main Characteristic | Dimensions | Weight (kg) |
|---|---|---|---|---|---|---|---|
| MPL-A1520F-V-X203 | MPL | Servo Motor | 230 V class | Electric cylinder | 3.0 mm/rev, no brake | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X208 | MPL | Servo Motor | 230 V class | Electric cylinder | 5.0 mm/rev, 24 V brake | Frame-dependent | Configuration-dependent |
| MPL-A220F-V-X210 | MPL | Servo Motor | 230 V class | Electric cylinder | 12.7 mm/rev, 24 V brake | Frame-dependent | Configuration-dependent |
| MPL-A330F-M-X212 | MPL | Servo Motor | 230 V class | Electric cylinder | 10.0 mm/rev, 24 V brake | Frame-dependent | Configuration-dependent |
| MPL-A420F-M-X214 | MPL | Servo Motor | 230 V class | Electric cylinder | 20.0 mm/rev, 24 V brake | Frame-dependent | Configuration-dependent |
These models cover different mechanical sizes and pitch characteristics.
They should not be selected solely on the basis of similar model numbers. The compatible electric-cylinder model, mechanical pitch, frame size, motor speed, brake arrangement, load, and required force/speed must all be considered.
17. Comparison of the Related MPL Motors
| Model | Frame | Pitch | Brake | Typical Electric-Cylinder Class | Main Motion Characteristic | Dimensions | Weight (kg) |
|---|---|---|---|---|---|---|---|
| MPL-A1520F-V-X203 | 32 | 3.0 mm/rev | No | MPAR-A1xxxB-x2x | Fine linear movement | Frame-dependent | Configuration-dependent |
| MPL-A1520F-V-X204 | 32 | 3.0 mm/rev | 24 V | MPAR-A1xxxB-x4x | Fine linear movement + holding | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X205 | 32 | 10.0 mm/rev | No | MPAR-A1xxxE-x2x | Faster linear movement | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X206 | 32 | 10.0 mm/rev | 24 V | MPAR-A1xxxE-x4x | Faster linear movement + holding | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X207 | 40 | 5.0 mm/rev | No | MPAR-A2xxxC-x2x | Medium-speed linear movement | Frame-dependent | Configuration-dependent |
| MPL-A1530F-V-X208 | 40 | 5.0 mm/rev | 24 V | MPAR-A2xxxC-x4x | Medium-speed movement + holding | Frame-dependent | Configuration-dependent |
| MPL-A220F-V-X209 | 40 | 12.7 mm/rev | No | MPAR-A2xxxF-x2x | Higher linear travel per revolution | Frame-dependent | Configuration-dependent |
| MPL-A220F-V-X210 | 40 | 12.7 mm/rev | 24 V | MPAR-A2xxxF-x4x | Higher travel + holding | Frame-dependent | Configuration-dependent |
18. Understanding the Pitch Specification
For the electric-cylinder configurations associated with these motors, the pitch is an important mechanical parameter.
Pitch represents the approximate amount of linear movement produced for one revolution of the associated screw mechanism.
For example:
| Pitch | General Motion Characteristic |
|---|---|
| 3.0 mm/rev | Lower travel per revolution, suitable for finer linear movement |
| 5.0 mm/rev | Moderate travel per revolution |
| 10.0 mm/rev | Higher travel per revolution |
| 12.7 mm/rev | Higher linear travel per revolution |
The MPL-A1530F-V-X206 is associated with the 10.0 mm/rev configuration.
This is important because changing the pitch changes the relationship between motor rotation and actuator linear movement.
A motor that looks similar electrically may therefore not be a suitable replacement if it is intended for a different pitch or electric-cylinder configuration.
19. Why the 24 V Brake Matters
The brake is an important difference between X205 and X206.
| Model | Brake |
|---|---|
| MPL-A1530F-V-X205 | No brake |
| MPL-A1530F-V-X206 | 24 V brake |
The brake is particularly useful where the load needs to remain stationary when servo torque is removed.
This is common in vertical applications.
For example, an electric cylinder may support a mechanical load above the machine base.
If servo torque disappears, gravity may cause the axis to move.
The motor brake provides a mechanical holding function when correctly controlled as part of the machine system.
The brake’s exact safety function should always be evaluated separately from the servo motor’s normal torque-producing capability.
20. Electric-Cylinder Application
The motor is especially relevant to an electric-cylinder arrangement.
A typical system can contain:
- Servo motor
- Servo drive
- Feedback system
- Mechanical screw
- Linear cylinder
- Machine load
- Motion controller
The controller sends the desired position or motion command.
The servo drive supplies controlled current to the motor.
The motor rotates the mechanical transmission.
The screw mechanism converts rotary motion into linear movement.
The feedback system reports motor position to the controller.
The controller can then continuously adjust the motor command to achieve the desired motion.
This closed-loop operation is one of the main reasons servo motors are used in precision automation.
21. Advantages for Linear Motion
The MPL-A1530F-V-X206 offers several characteristics that are useful for linear-motion applications.
Precise Positioning
The feedback-based servo system allows the machine to command a defined position.
Controlled Acceleration
The motor can accelerate according to a programmed motion profile.
Controlled Deceleration
The motor can decelerate before reaching the target position.
Rapid Repetition
Low inertia is helpful for repeated motion cycles.
Holding Capability
The integrated 24 V brake can provide mechanical holding when appropriately controlled.
Compact Motion System
An electric-cylinder arrangement can provide controlled linear movement without requiring a conventional pneumatic cylinder.
22. Typical Industries
| Industry | Example Application |
|---|---|
| Manufacturing | Automated positioning |
| Packaging | Cutting and indexing |
| Automotive | Assembly and pressing |
| Electronics | Precision positioning |
| Material Handling | Transfer mechanisms |
| Machine Building | Linear axes |
| Robotics | Controlled motion axes |
| Food Machinery | Automated mechanisms |
| Pharmaceutical Machinery | Precision positioning |
| General Automation | Servo-controlled movement |
23. Product Selection Considerations
When replacing MPL-A1530F-V-X206, the complete system should be considered rather than the motor alone.
Important factors include:
- Motor voltage class
- Servo-drive compatibility
- Motor feedback compatibility
- Rated speed
- Continuous torque
- Peak torque
- Motor inertia
- Load inertia
- Mechanical pitch
- Required linear speed
- Required linear force
- Brake requirement
- Mounting dimensions
- Shaft dimensions
- Connector configuration
- Cable requirements
- Environmental conditions
- Motor thermal requirements
A motor with the same nominal voltage but a different frame, stack length, feedback system, brake, or mechanical configuration may not be a direct replacement.
24. Mechanical Replacement Considerations
For a replacement project, the following mechanical dimensions should be checked:
| Mechanical Item | Required Check |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Frame | Size 6 |
| Frame Reference | Approx. 215 mm |
| Stack Length | 80 |
| Stack Length | Approx. 203.2 mm |
| Shaft Diameter | Verify against original motor |
| Shaft Length | Verify against original motor |
| Mounting Bolt Pattern | Verify |
| Flange Dimensions | Verify |
| Connector Location | Verify |
| Brake Connection | 24 V |
| Cable Clearance | Verify |
| Overall Motor Length | Verify |
| Overall Motor Diameter | Verify |
| Weight (kg) | Verify from actual motor/package |
| Load Alignment | Must be checked |
25. Servo System Compatibility
A servo motor should normally be selected as part of a complete motor-drive combination.
The drive must be compatible with:
- Motor voltage
- Motor feedback
- Motor current
- Motor power
- Motor brake
- Motor thermal characteristics
- Motor inertia
- Feedback resolution
- Required motion profile
The MPL-A1530F-V-X206 should therefore not be treated as a generic three-phase motor that can simply be connected to any 230 V motor drive.
Its feedback and servo-control characteristics are essential parts of the product.
26. Product Advantages Summary
| Advantage | Description |
|---|---|
| Low Inertia | Supports rapid dynamic response |
| 3000 RPM Class | Suitable for high-speed servo motion |
| 230 V Class | Suitable for corresponding industrial servo systems |
| 24 V Brake | Provides mechanical holding capability |
| Precision Feedback | Supports closed-loop positioning |
| Electric-Cylinder Compatibility | Suitable for controlled linear motion |
| High Repeatability | Useful for repetitive machine cycles |
| Fast Acceleration | Suitable for dynamic applications |
| Controlled Deceleration | Supports accurate stopping |
| Industrial Construction | Designed for machine automation environments |
27. Quick Reference Table
| Parameter | Value |
|---|---|
| Model | MPL-A1530F-V-X206 |
| Brand | Allen-Bradley |
| Product Family | MP-Series |
| Product Series | MPL |
| Product Type | Low-Inertia Brushless Servo Motor |
| Voltage Class | 230 V |
| Speed Class | 3000 RPM |
| Frame Size | 6 |
| Frame Reference | Approx. 215 mm |
| Stack Length | 80 |
| Stack Length | Approx. 203.2 mm |
| Brake | 24 V DC |
| Motor Application | Servo motion control |
| Main Application | Electric cylinders / linear actuators |
| Feedback | Servo feedback |
| Motor Control | Closed-loop |
| Dimensions | Frame-dependent; frame reference approx. 215 mm, stack length approx. 203.2 mm |
| Weight (kg) | Configuration-dependent; verify from actual assembly |
| Mounting | Industrial machine mounting |
| Typical Industries | Automation, packaging, assembly, material handling |
| Main Advantage | Low inertia and precision motion |
28. Final Product Summary
The MPL-A1530F-V-X206 is a low-inertia brushless servo motor in the MPL series, designed for precision industrial motion applications.
Its key characteristics include a 230 V class, 3000 RPM speed class, Frame Size 6, 80 stack-length designation, and an integrated 24 V brake.
The motor is particularly associated with electric-cylinder applications and controlled linear-motion systems. It can convert the rotary motion of the servo motor into precise linear movement through a compatible screw-driven actuator.
The motor’s low-inertia construction is useful for applications requiring rapid acceleration and deceleration, repeated positioning, frequent starts and stops, and accurate motion profiles.
The integrated 24 V brake is another important feature, especially for applications in which the mechanical load needs to remain stationary when the servo is not actively producing torque.
The closest related models include MPL-A1530F-V-X205, MPL-A1530F-V-X207, MPL-A1530F-V-X208, MPL-A1520F-V-X204, and MPL-A220F-V-X210. These models differ in areas such as brake configuration, frame size, pitch, and associated electric-cylinder configuration.
For the requested model, the most useful mechanical reference information is Frame Size 6, approximately 215 mm frame reference, and 80 stack length, corresponding to approximately 203.2 mm. The exact complete motor envelope and Weight (kg) should be confirmed from the physical motor configuration because the catalog number identifies a specific replacement-motor arrangement and the final mechanical assembly can include configuration-dependent features.
When replacing this motor, it is important to match not only the voltage and speed but also the feedback system, brake, frame size, stack length, mounting dimensions, shaft arrangement, compatible servo drive, mechanical pitch, and electric-cylinder configuration.
Overall, the MPL-A1530F-V-X206 is best understood as a precision motion-control motor for applications where controlled positioning, rapid response, repeatability, and mechanically held motion are more important than simple constant-speed rotation.