ProductPRODUCT
Featured products
Contact Us
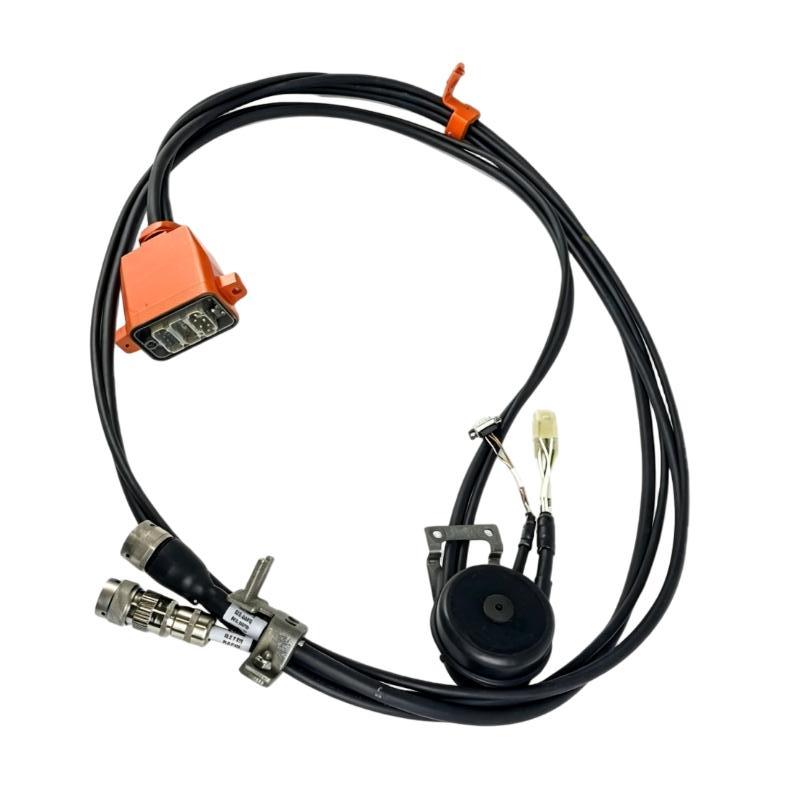
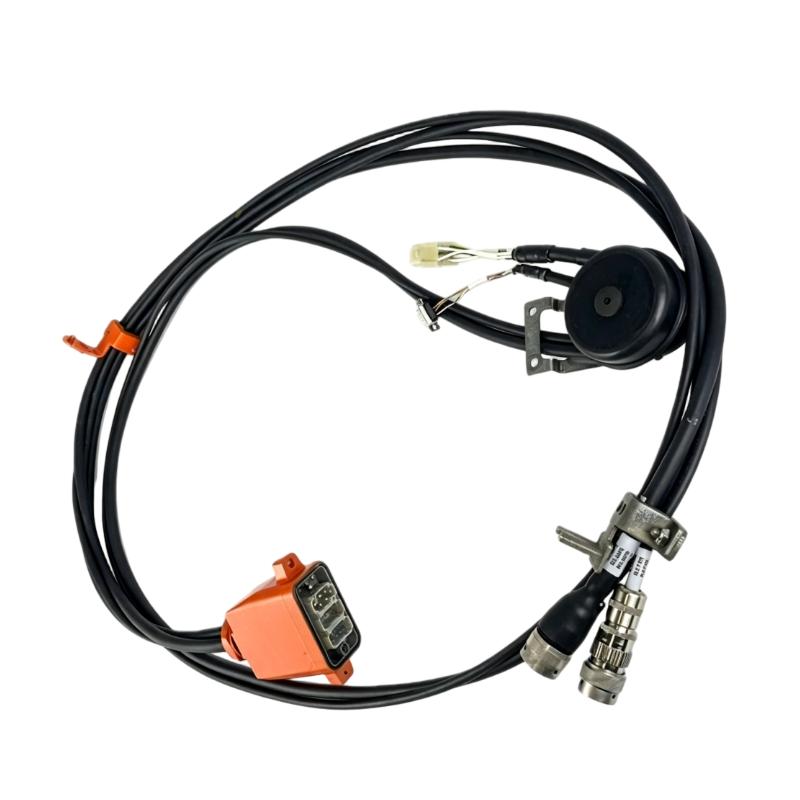
- ABB
- 3HAC14140-1
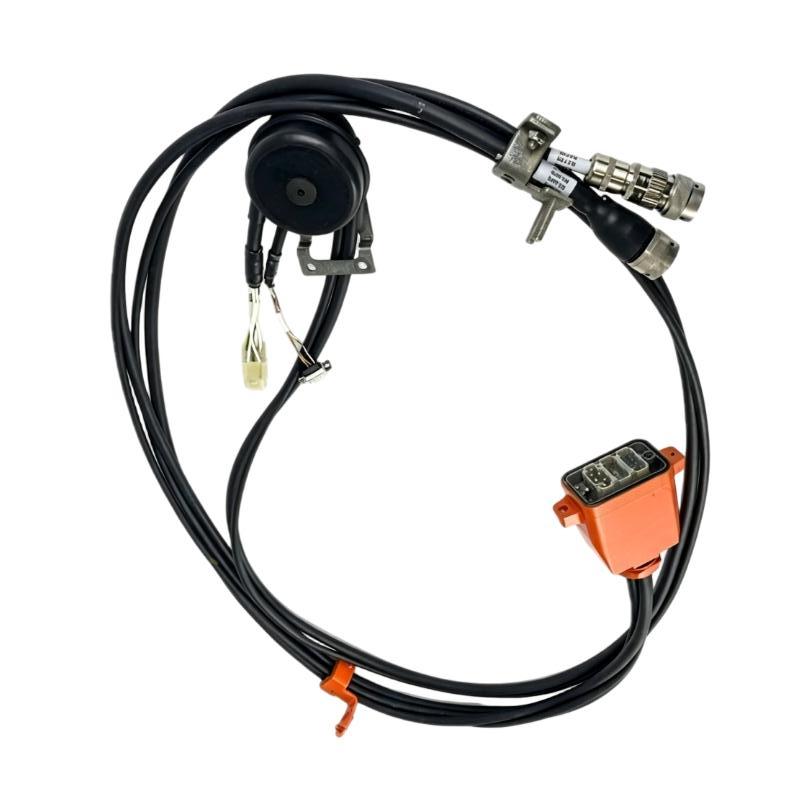
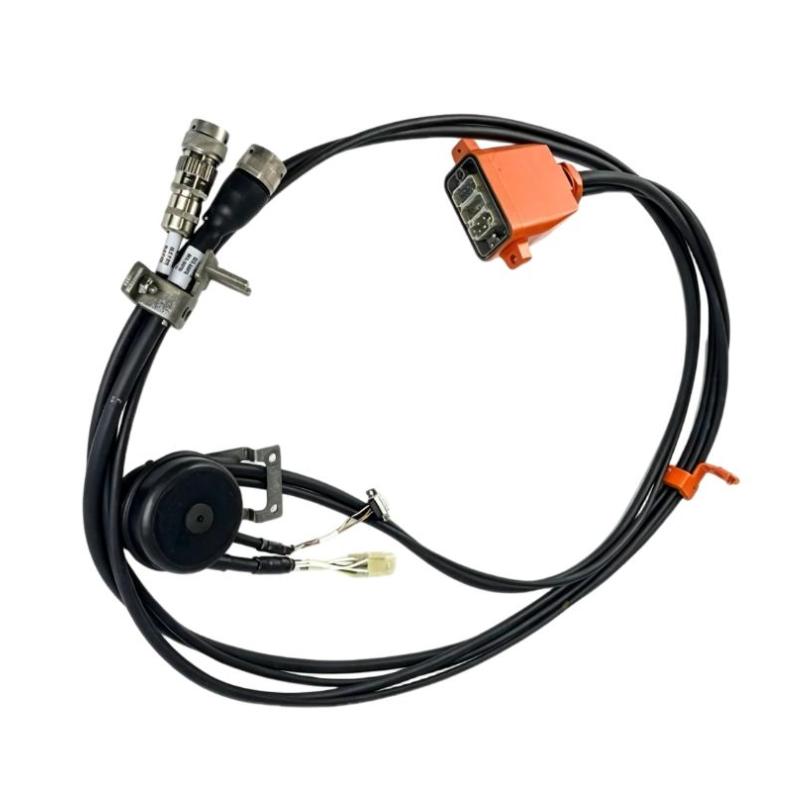
- Axis Manipulator Harness
- Sweden (SE)
- Optional
- 3 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
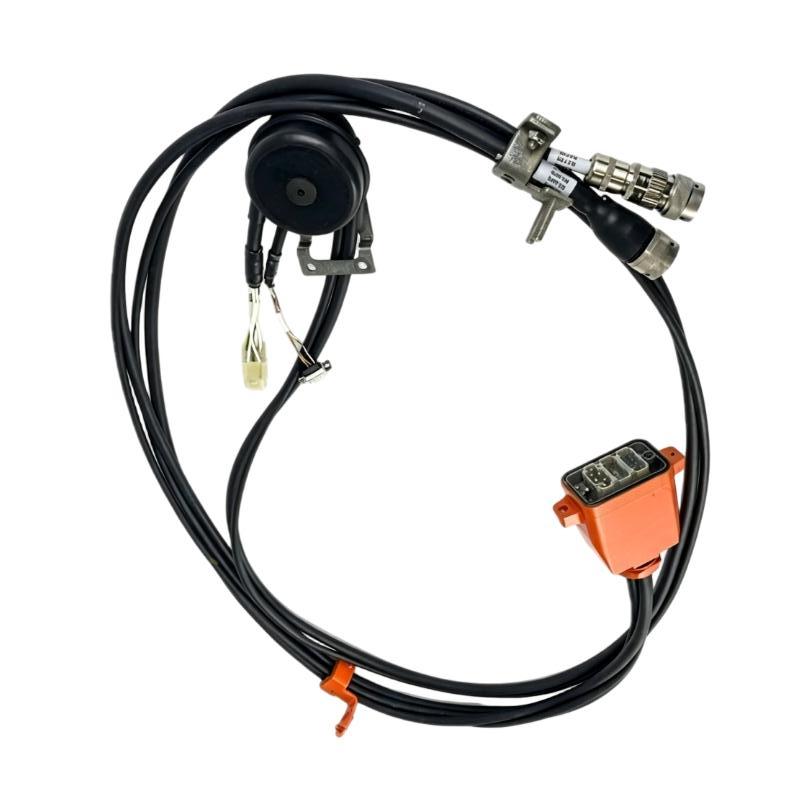
The ABB 3HAC14140-1 IRB 6600 Axis Manipulator Harness (Axes 5 6) is a robot cable harness associated with the ABB IRB 6600 manipulator and the wiring required around robot axes 5 and 6. It routes electrical connections between the robot’s stationary and moving sections while accommodating the repeated movement of the manipulator during normal operation.
Cable harnesses in this area of an industrial robot are exposed to continuous bending, twisting, vibration, and mechanical movement. Correct routing and secure attachment are therefore important for maintaining signal and power continuity during robot operation.
The harness is relevant to robot maintenance and refurbishment work where axis-related cabling has become worn, damaged, or requires replacement as part of a planned service procedure.
Technical Specifications
| Parameter | Details |
|---|---|
| Model | 3HAC14140-1 |
| Brand | ABB |
| Product Type | IRB 6600 Axis Manipulator Harness |
| Applicable Robot | IRB 6600 |
| Axis Coverage | Axes 5 and 6 |
| Cable Length | Optional |
| Shipping Weight | 3 kg |
Product Features
- IRB 6600 Compatibility: Intended for the cable arrangement associated with the ABB IRB 6600 robot family.
- Axes 5 and 6 Harness: Covers wiring associated with the specified robot-axis section.
- Flexible Cable Routing: Accommodates cable movement generated by robot articulation.
- Robot Motion Support: Suitable for cabling exposed to repeated mechanical movement.
- Maintenance Replacement: Can be used when existing axis harnesses require service or replacement.
- Organized Wiring: Keeps electrical connections routed along the robot structure.
- Industrial Robot Application: Intended for demanding automated production environments.
- Service-Oriented Component: Useful during robot refurbishment and corrective maintenance.
Working Principle
The 3HAC14140-1 harness functions as an electrical connection path within the moving structure of the IRB 6600 robot.
Signals and electrical power required by components around axes 5 and 6 travel through the harness between the relevant robot components and the controller-side wiring system. As the robot moves, the harness follows the mechanical movement of the arm while maintaining the required electrical connections.
Because axes 5 and 6 can generate repeated rotational and bending movement, the harness must remain correctly routed and secured. Improper routing can increase mechanical stress and accelerate cable wear.
Robot Controller / Electrical Interface → Robot Harness → Axis 5 / Axis 6 Connections → Motors, Feedback Devices and Related Robot Components
Role in an ABB IRB 6600 Robot Control Architecture
| System Element | Function |
|---|---|
| Robot Controller | Executes robot programs and coordinates motion |
| Axis Manipulator Harness | Routes electrical connections through the moving robot structure |
| 3HAC14140-1 Harness | Provides wiring associated with axes 5 and 6 |
| Axis Motors | Generate mechanical movement at the robot joints |
| Motor Feedback Devices | Provide position and motion feedback |
| Robot Manipulator | Converts drive commands into mechanical movement |
| Drive System | Controls the robot axis motors |
| Teach Pendant | Provides programming and manual operation |
| Robot Software | Manages programmed motion and process functions |
| End Effector | Performs the production operation |
| Safety System | Controls permitted robot operation |
| External I/O | Interfaces the robot with surrounding production equipment |
Industrial Applications
| Application | Typical Use |
|---|---|
| Robot Maintenance | Replacement of worn axis harnesses |
| Robot Refurbishment | Restoration of electrical connections in older manipulators |
| Welding Automation | Maintains wiring continuity on robots performing repetitive welding motions |
| Material Handling | Supports moving robot-axis electrical connections |
| Machine Tending | Maintains cable routing during repeated robot cycles |
| Assembly Automation | Supports axis wiring in high-cycle applications |
| Palletizing | Used in robot maintenance for repetitive axis movement |
| Packaging Automation | Maintains electrical connections in continuously moving manipulators |
| Production Lines | Supports replacement of damaged robot harnesses |
| Robot Service Operations | Used during corrective and preventive maintenance |
Installation and Maintenance
- Verify the Part Number: Confirm that 3HAC14140-1 matches the required IRB 6600 harness configuration.
- Confirm Axis Application: Check that the harness is intended for the relevant axes 5 and 6 installation.
- Isolate Robot Power: Follow the applicable robot lockout and safety procedure before cable replacement.
- Inspect Existing Routing: Record the original cable path and attachment points before removing the old harness.
- Check Connectors: Inspect mating connectors for contamination, bent contacts, or mechanical damage.
- Maintain Correct Routing: Route the replacement harness along the intended robot path without unnecessary bends or twists.
- Secure the Harness: Use the specified attachment points and ensure that the cable cannot interfere with moving robot parts.
- Check Mechanical Clearance: Move the relevant axes through their permitted range under controlled conditions and verify adequate cable clearance.
- Inspect for Pinching: Confirm that the harness is not trapped between covers, brackets, joints, or other moving components.
- Check Electrical Continuity: Perform appropriate continuity and insulation checks before returning the robot to production.
- Monitor During Operation: Watch for abnormal cable movement, rubbing, excessive tension, or intermittent electrical faults.
- Record the Service Work: Document harness replacement, routing checks, connector inspections, and functional testing.
Related Components
| Component | Function |
|---|---|
| ABB IRB 6600 Manipulator | Provides the robot’s mechanical axes |
| Robot Controller | Controls robot motion and programs |
| Axis 5 Motor | Drives the corresponding robot axis |
| Axis 6 Motor | Drives the corresponding robot axis |
| Motor Feedback Device | Provides position feedback |
| Teach Pendant | Provides robot programming and manual control |
| Robot Drive Unit | Controls robot-axis motors |
| Robot Cable Harness | Routes electrical connections through the manipulator |
| End Effector | Performs the production task |
| Robot Base Cabling | Connects the manipulator with controller-side equipment |
| Safety Circuit | Controls safe robot operation |
| External I/O Interface | Connects the robot with production equipment |
Recommended Related Models
| Model | Product Type / Application |
|---|---|
| ABB 3HAC14140-1 | IRB 6600 Axis Manipulator Harness (Axes 5 6) |
| ABB IRB 6600 | Industrial Robot Manipulator |
| ABB IRB 6600 Axis Cable Assemblies | Robot Axis Wiring |
| ABB IRB 6600 Motor Components | Robot Axis Drive Components |
| ABB IRB 6600 Feedback Components | Robot Position Feedback |
| ABB IRB 6600 Teach Pendant Components | Robot Programming and Manual Control |
| ABB Robot Controller Components | Robot Control and Motion Management |
Key Advantages
- Provides dedicated wiring for IRB 6600 axes 5 and 6.
- Supports electrical connections through the moving robot structure.
- Suitable for robot maintenance and refurbishment.
- Accommodates repeated manipulator movement.
- Helps restore proper axis-related electrical connectivity.
- Supports continued operation of industrial robot systems.
Technical FAQs
What is the ABB 3HAC14140-1 harness used for?
It is an axis manipulator harness associated with the ABB IRB 6600 and is used for electrical connections related to axes 5 and 6.
Why is cable routing important on IRB 6600 axes 5 and 6?
These axes generate repeated mechanical movement. Incorrect routing can cause excessive bending, twisting, rubbing, or tension, which may shorten cable service life or cause intermittent electrical faults.
What should be checked before replacing the harness?
Verify the part number and robot configuration, isolate the robot safely, record the original cable routing, inspect connector locations, and check the attachment points before removing the existing harness.
How can harness problems affect robot operation?
Cable damage can lead to intermittent signals, loss of feedback, electrical faults, or communication problems with connected robot components. Mechanical inspection and electrical testing can help identify harness-related problems.