

ProductPRODUCT
Featured products
Contact Us
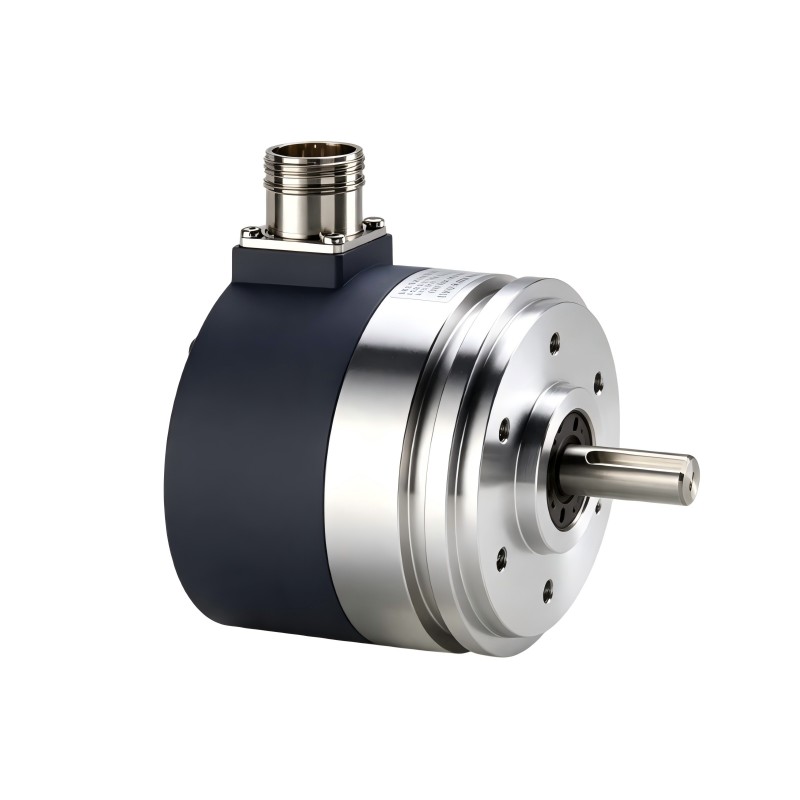
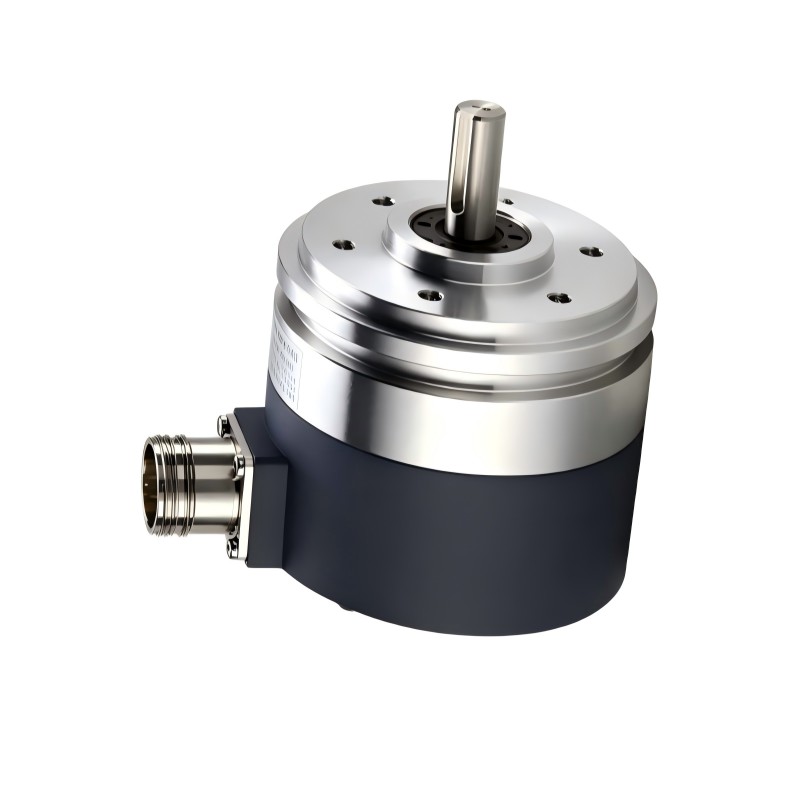
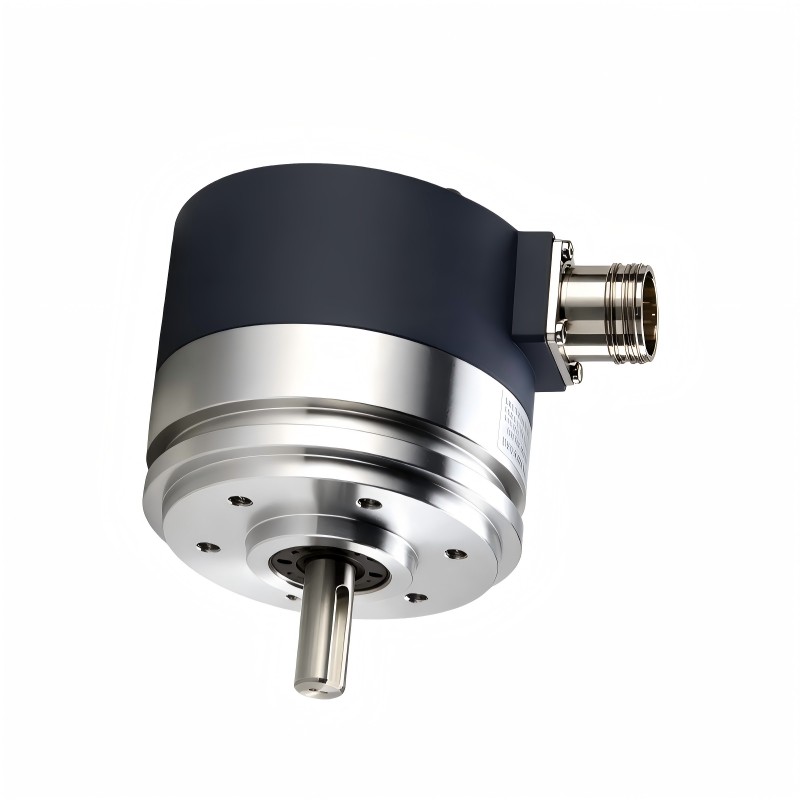
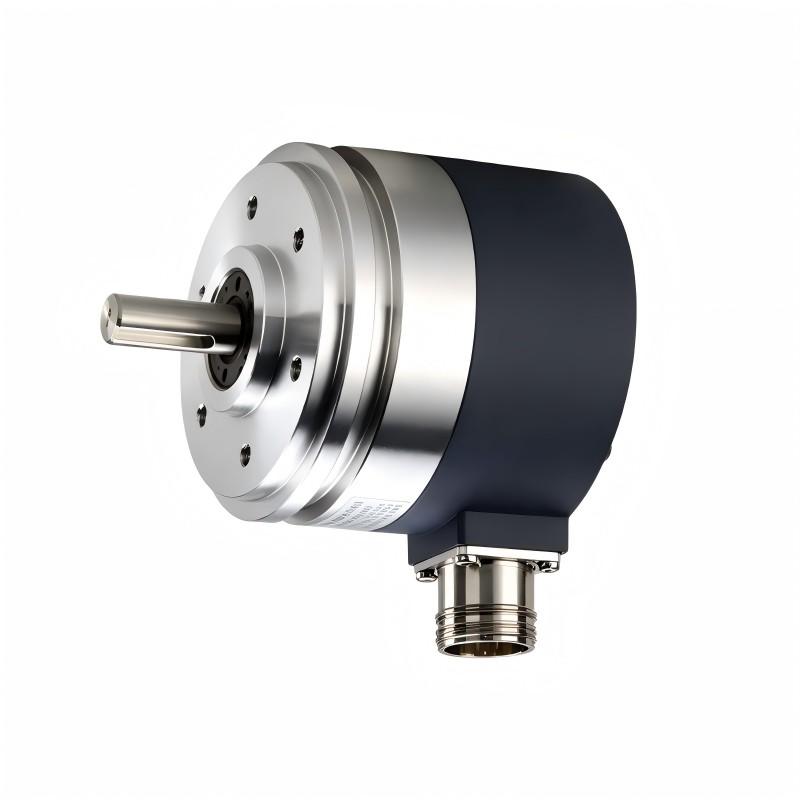
- Schneider
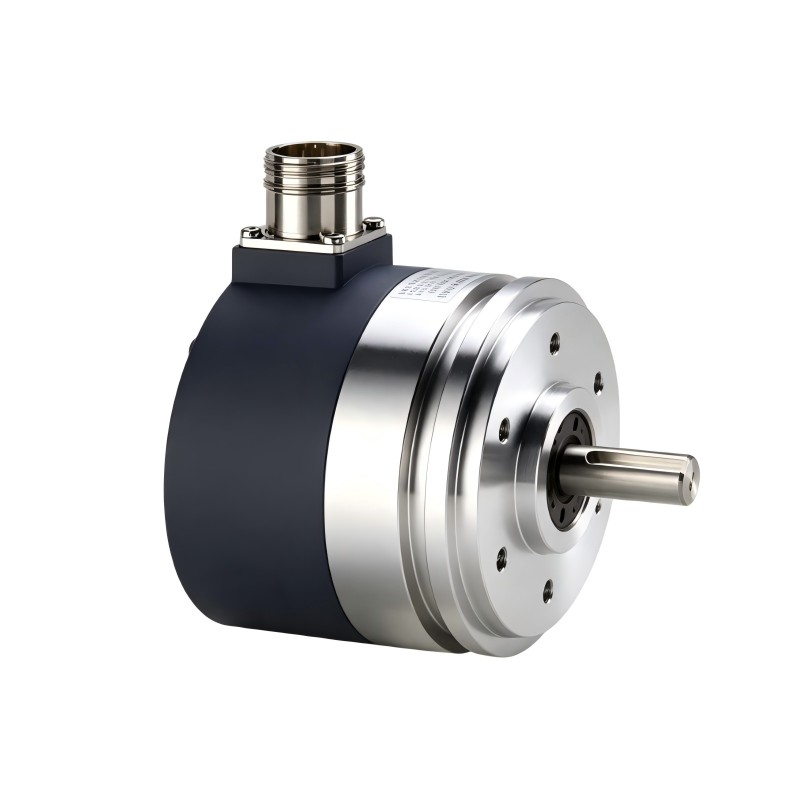
- XCC-3912PS84SGN
- XCC Multi-turn Absolute Encoder
- France
- 90 mm
- 1.84 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
1. Product Overview
The Schneider XCC-3912PS84SGN XCC Multi-Turn Absolute Encoder is an industrial automation feedback component designed for applications requiring rotational position information. Multi-turn absolute encoders are used in motion-control systems to identify shaft position across multiple revolutions, allowing compatible controllers to obtain position information without relying solely on incremental pulse counting.
In industrial machinery, accurate position feedback is important for controlling movement, coordinating mechanical assemblies, monitoring equipment status, and supporting repeatable operating sequences. A multi-turn absolute encoder can provide position data that represents both the angular position within a revolution and the number of revolutions within its supported measurement range.
The Schneider XCC-3912PS84SGN has a specified diameter of 90 mm and a listed weight of 1.84 kg. These physical characteristics are relevant when evaluating cabinet or machine space, mechanical mounting, equipment handling, and replacement requirements.
Before installation or replacement, the encoder’s exact electrical interface, output format, resolution, supported multi-turn range, supply requirements, and mounting configuration should be verified against the product label and applicable technical documentation. These details are essential for ensuring compatibility with the intended controller or motion-control system.
2. Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Schneider Electric |
| Model | XCC-3912PS84SGN |
| Product Series | XCC |
| Product Type | Multi-Turn Absolute Encoder |
| Diameter | 90 mm |
| Weight | 1.84 kg |
| Primary Function | Absolute rotational position feedback across multiple turns |
| Typical Application | Industrial automation and motion-control systems |
| Measurement Type | Multi-turn absolute position |
| Output Interface | Verify from the exact model documentation |
| Resolution | Confirm the supported resolution before configuration |
| Multi-Turn Range | Verify the specified measurement range |
| Supply Voltage | Confirm before electrical connection |
| Connection Type | Verify the connector and wiring arrangement |
| Mounting Configuration | Confirm from the mechanical drawing |
| System Compatibility | Verify against the controller, drive, and feedback interface |
The diameter and weight above are the supplied product specifications. Electrical characteristics, resolution, output format, and supported operating limits should be confirmed before commissioning.
3. Function and Working Principle
A multi-turn absolute encoder converts shaft rotation into position information. Unlike a conventional incremental encoder, which typically tracks movement by counting pulses from a reference point, an absolute encoder associates its output with a defined position value.
A multi-turn absolute encoder extends this concept by accounting for movement across multiple revolutions. Depending on its design, it may distinguish both the angular position within one revolution and the number of completed turns.
3.1 Absolute Position Measurement
An absolute encoder provides a position value associated with a particular shaft position. A compatible controller interprets this value to determine the measured position within the encoder’s supported range.
The availability of a position value can simplify certain startup and recovery procedures because the system may not need to reconstruct position solely by counting movement after power-up. However, the actual startup behavior depends on the encoder’s design, configuration, and communication interface.
3.2 Multi-Turn Position Tracking
A multi-turn encoder records position across more than one revolution. This capability is useful in equipment where a shaft can rotate through many turns while the controller must retain information about its broader position.
The supported number of turns and the method used to retain multi-turn information depend on the specific encoder design. These details should be verified for the XCC-3912PS84SGN before it is used in a position-critical application.
3.3 Position Feedback for Control Systems
The encoder’s position data can be processed by a compatible PLC, motion controller, or drive. The control system can use this information to monitor movement, compare actual and target positions, and execute programmed machine sequences.
The encoder provides feedback information; the receiving control equipment performs the required interpretation and control calculations.
3.4 Startup and Reference Behavior
One advantage of absolute position measurement is that the system may be able to read the encoder’s position directly instead of establishing position exclusively through incremental pulse counting. Nevertheless, the system may still require initialization, reference validation, or a machine-specific homing procedure.
For the XCC-3912PS84SGN, the exact startup sequence, position-retention behavior, and communication requirements must be established from its technical documentation.
4. Role in Industrial Automation Systems
Multi-turn absolute encoders support applications where equipment needs reliable position information across multiple shaft revolutions. Their role is determined by the mechanical arrangement, encoder interface, and control architecture.
4.1 Position Control
In automated machinery, a controller may need to determine the position of a rotating mechanism before allowing the next operation to begin. Absolute position feedback can help the control system compare the measured position with a programmed target.
4.2 Motion Coordination
Machines often contain multiple moving components that must operate in a coordinated sequence. Encoder feedback can help the controller monitor the position of a shaft or mechanism and coordinate its movement with other equipment.
4.3 Startup and Recovery
Where the encoder and receiving system support direct absolute-position reading, the controller may be able to recover position information without reconstructing the entire movement history. This can be beneficial after a controlled restart, although the actual recovery process depends on the application and hardware configuration.
4.4 Machine Monitoring
Position data can help a control system monitor whether a mechanism has reached a required position or whether movement is progressing as expected. Combined with appropriate control logic, this information can support fault detection and operational monitoring.
4.5 Equipment Modernization
When upgrading existing machinery, an absolute encoder may be considered where position tracking across multiple revolutions is required. The replacement or upgrade must be checked for mechanical fit, electrical compatibility, communication support, and software configuration.
5. Industrial Applications
The Schneider XCC-3912PS84SGN may be evaluated for applications that require multi-turn absolute position feedback, subject to confirmation of its detailed specifications and compatibility with the target system.
5.1 Industrial Machinery
Automated industrial machines use position feedback to monitor shafts, rotary mechanisms, and other moving assemblies. A compatible absolute encoder can provide position information for sequencing and movement supervision.
5.2 Material Handling Equipment
Material handling systems may include lifting mechanisms, rotary transfer units, and other equipment that moves through multiple revolutions. Multi-turn position feedback can help a suitable controller monitor movement across a broader operating range.
5.3 Packaging and Production Lines
Packaging equipment may require coordinated movement between feed mechanisms, rollers, indexing systems, and other components. Absolute position information can support controlled sequencing when the encoder interface is compatible with the machine’s control architecture.
5.4 Rotary Machinery
Rotary tables, indexing mechanisms, and similar systems may need to determine both the angular position and the broader rotational position of a shaft. A suitable multi-turn encoder can provide information for these functions.
5.5 Automated Assembly Systems
Assembly machines may use rotary mechanisms to position workpieces, tools, or fixtures. Absolute feedback can help the controller verify movement and coordinate successive operating steps.
5.6 Industrial Motion Monitoring
Equipment that requires multi-turn position tracking may benefit from an encoder capable of reporting absolute position. The suitability of this particular model depends on its supported range, output interface, mechanical design, and environmental specifications.
These examples describe general application areas for appropriately specified multi-turn absolute encoders. They do not establish compatibility with every machine or control system listed.
6. Installation and System Integration
Correct installation is essential for dependable encoder feedback. The following checklist provides general guidance; the manufacturer’s model-specific installation instructions and electrical requirements take precedence.
Step 1: Verify the Product Identity
Confirm that the label identifies the encoder as Schneider XCC-3912PS84SGN. Compare the model number with the equipment documentation, existing component, and bill of materials.
Do not select a replacement based only on the XCC series designation or the external appearance of the housing.
Step 2: Isolate the Equipment
Place the machine in a safe condition and isolate the relevant power sources according to the site’s lockout/tagout procedure. Confirm that it is safe to work on the equipment before disconnecting wiring or handling the encoder.
Step 3: Inspect the Encoder and Mounting Area
Check the housing, connector, cable entry, mounting surfaces, and mechanical interface for visible damage or contamination. Confirm that the installation location provides sufficient space and that the mounting arrangement matches the equipment design.
Step 4: Confirm Mechanical Compatibility
Review the encoder’s mechanical drawing to verify mounting dimensions, shaft or coupling requirements, alignment tolerances, and permitted mechanical loads. Incorrect alignment or excessive loading may affect measurement accuracy or cause premature mechanical wear.
Step 5: Verify Electrical and Communication Requirements
Confirm the required supply voltage, output format, communication interface, connector type, and wiring arrangement. Ensure that the receiving PLC, drive, or motion controller supports the encoder’s actual output.
Do not infer connector pinouts, voltage levels, or communication protocols from the model number alone.
Step 6: Install the Encoder
Mount the encoder according to the approved procedure. Ensure that the mechanical connection is secure and that any coupling is correctly aligned. Route cables to avoid excessive bending, tension, abrasion, or contact with moving components.
Step 7: Configure the Receiving System
Configure the controller or drive according to the verified encoder specifications. Relevant settings may include the feedback interface, position format, resolution, scaling, and operating range, depending on the system architecture.
Step 8: Restore Power and Validate Position Data
After installation and inspection, restore power in accordance with the commissioning procedure. Confirm that the receiving system recognizes the encoder and obtains valid position data.
Move the mechanism through a controlled test and compare the displayed position with the actual mechanical movement. Verify behavior across multiple revolutions where appropriate and permitted by the equipment design.
Step 9: Complete Functional Testing
Check position accuracy, repeatability, startup behavior, and relevant diagnostic information. Confirm that the complete machine responds correctly to the feedback before returning it to normal operation.
7. Common Problems and Troubleshooting
Problems involving absolute encoder feedback can originate in the encoder, power supply, communication wiring, mechanical installation, or receiving control system.
| Symptom | Possible Causes | Recommended Checks |
|---|---|---|
| Encoder is not detected | Missing supply, incorrect wiring, unsupported interface, or damaged connector | Verify supply requirements, connections, and controller compatibility |
| Position value is unavailable | Communication fault, configuration error, or encoder malfunction | Review system diagnostics and confirm the configured feedback interface |
| Position reading is incorrect | Incorrect scaling, incompatible data interpretation, mechanical slippage, or configuration error | Verify encoder parameters, mechanical coupling, and controller settings |
| Position changes unexpectedly | Electrical interference, unstable connection, mechanical movement, or feedback-processing issue | Inspect the signal path, mounting, and diagnostic records |
| Multi-turn information appears incorrect | Unsupported configuration, incorrect interpretation, or model-specific operating limitation | Verify the documented multi-turn range and position-retention behavior |
| Encoder loses communication intermittently | Loose connector, damaged cable, interference, or unstable supply | Inspect the wiring and verify signal quality and power stability |
| Fault remains after replacement | The cause may be outside the encoder | Check the controller, cable, supply, mounting, and configuration |
7.1 Check the Power Supply
Confirm that the encoder receives the specified supply voltage and that the connection remains stable during operation. Inspect the connector and cable for loose contacts, damaged insulation, or other visible defects.
7.2 Verify Communication Compatibility
Absolute encoders may use different output formats and communication interfaces. Confirm that the receiving equipment supports the exact interface and data format provided by the encoder.
A physically compatible connector does not necessarily indicate electrical or communication compatibility.
7.3 Review Position Scaling and Configuration
Incorrect parameter settings can result in position values that do not correspond to actual movement. Check the encoder’s supported resolution, measurement range, position format, and the receiving controller’s interpretation of the data.
7.4 Inspect Mechanical Installation
Check mounting security, alignment, and the integrity of the shaft or coupling arrangement. Mechanical slippage or unwanted movement between the encoder and the measured shaft may cause discrepancies between the reported position and actual machine position.
7.5 Investigate Interference and Wiring Problems
Inspect the signal cable routing, shielding, grounding, and connector condition according to the system design. Electrical interference or intermittent connections may disrupt position data or communication.
7.6 Confirm Multi-Turn Behavior
If the reported turn count is incorrect after a restart or power interruption, verify the encoder’s documented position-retention method and operating conditions. Do not assume that every absolute encoder uses the same mechanism or retains multi-turn information under every circumstance.
7.7 Decide Whether Replacement Is Necessary
If power, wiring, communication, mechanical installation, and configuration have been checked but the problem persists, further testing or replacement may be necessary. Use a confirmed compatible component and document any hardware or configuration changes.
8. Preventive Maintenance and Reliability
Preventive maintenance can help preserve reliable encoder feedback and reduce unexpected equipment interruptions.
- Inspect mounting hardware: Check for looseness, damage, or signs of vibration.
- Check the mechanical coupling: Confirm that alignment and mechanical engagement remain within the specified limits.
- Examine connectors and cables: Look for abrasion, crushing, contamination, or loose connections.
- Monitor diagnostic information: Investigate recurring communication or position errors instead of repeatedly resetting faults.
- Verify position consistency: During scheduled maintenance, compare reported position with an appropriate machine reference where the maintenance procedure permits.
- Maintain configuration records: Keep the model number, controller settings, and approved wiring documentation available.
- Review environmental conditions: Ensure that temperature, vibration, dust, moisture, and other site conditions meet the encoder’s specified limits.
- Use approved replacement parts: Verify the exact model and system compatibility before replacement.
- Follow safe maintenance procedures: Isolate the equipment and observe the approved handling and installation instructions.
The appropriate maintenance interval depends on the operating environment, machine duty cycle, and the criticality of the application.
9. Compatible System Components
The XCC-3912PS84SGN should be evaluated as part of the complete automation system. The following table lists component categories that may require verification during integration. It does not confirm compatibility with any specific component model.
| Component Category | Integration Considerations |
|---|---|
| PLC or industrial controller | Confirm support for the encoder’s output interface and position data |
| Motion controller | Verify feedback compatibility, data interpretation, and configuration requirements |
| Servo or motor drive | Confirm that the drive supports the encoder interface or an approved intermediary |
| Communication interface | Check the supported protocol, data format, and connection requirements |
| Power supply | Verify rated voltage and current requirements |
| Signal cable and connector | Confirm connector type, wiring arrangement, and cable specifications |
| Mechanical coupling or adapter | Check mounting dimensions, shaft compatibility, alignment, and mechanical loads |
| Engineering software | Verify that the required hardware and feedback configuration are supported |
Compatibility should be established from the complete system configuration and the applicable technical documentation.
10. Replacement and Alternative Encoder Selection
When replacing the Schneider XCC-3912PS84SGN, engineers should assess the encoder’s functional, electrical, and mechanical requirements rather than relying on its appearance or housing dimensions alone.
| Selection Factor | What to Verify |
|---|---|
| Exact model | Confirm XCC-3912PS84SGN and any relevant product revision |
| Encoder type | Confirm multi-turn absolute operation |
| Diameter | Compare with the supplied 90 mm specification and the mounting drawing |
| Weight | Account for the listed 1.84 kg when evaluating handling and mechanical support |
| Resolution | Confirm the required single-turn and multi-turn position resolution |
| Measurement range | Verify the supported number of turns and absolute-position range |
| Output interface | Confirm the communication method and data format |
| Supply requirements | Verify the rated voltage and current |
| Mechanical interface | Check mounting dimensions, shaft or coupling arrangement, and alignment requirements |
| Environmental specifications | Confirm suitability for the intended operating conditions |
| Controller compatibility | Verify support for the encoder’s output and position data |
| Commissioning requirements | Determine whether configuration, reference validation, or functional testing is necessary |
A replacement should be considered equivalent only after its specifications have been checked against the original encoder and the requirements of the installed system.
11. Key Benefits of Correct Encoder Selection
A correctly specified multi-turn absolute encoder can support reliable position monitoring and improve the integration of feedback into an industrial control system.
Multi-turn position information: The encoder category is intended to provide position information across multiple revolutions, subject to the model’s documented measurement range.
Absolute position feedback: Absolute position data can help compatible control systems identify shaft position without relying exclusively on incremental pulse counting.
Support for automated motion: Position information can assist machine sequencing and motion coordination when processed by a suitable controller.
Maintenance and diagnostics: Consistent feedback can help technicians investigate position-related faults and assess machine behavior.
Mechanical planning: The supplied 90 mm diameter and 1.84 kg weight help engineers assess installation space and handling requirements.
System integration: Verifying the electrical interface, output format, and mounting configuration before installation reduces the risk of compatibility problems.
Actual performance depends on the model’s confirmed specifications, installation quality, and the capabilities of the receiving control system.
12. Technical FAQs
Q1: What is the Schneider XCC-3912PS84SGN?
The Schneider XCC-3912PS84SGN is identified in the supplied product information as an XCC multi-turn absolute encoder. Its detailed electrical and mechanical characteristics should be confirmed before use.
Q2: What is the diameter of the XCC-3912PS84SGN?
The supplied diameter is 90 mm. Check the complete mechanical drawing before selecting mounting hardware or planning a replacement.
Q3: How much does the XCC-3912PS84SGN weigh?
The supplied product weight is 1.84 kg.
Q4: What is a multi-turn absolute encoder used for?
A multi-turn absolute encoder provides position information across multiple shaft revolutions. A compatible controller can use the information to monitor position and coordinate machine movement.
Q5: What is the difference between an incremental encoder and a multi-turn absolute encoder?
An incremental encoder generally reports movement through pulses that a controller counts relative to a reference. A multi-turn absolute encoder provides position information that includes the angular position within a revolution and, within its supported range, the number of revolutions.
Q6: Does an absolute encoder always retain its position after a power interruption?
Not necessarily under every operating condition. Position-retention behavior depends on the encoder’s design and documented operating requirements. Confirm the specifications for the exact model and the behavior of the complete control system.
Q7: Can the XCC-3912PS84SGN connect directly to any PLC?
No. Direct connection depends on the encoder’s output interface, data format, supply requirements, and the PLC’s supported input or communication interface.
Q8: Why might an absolute encoder report the wrong position?
Possible causes include incorrect configuration, incompatible data interpretation, communication errors, mechanical slippage, or an issue with the encoder or receiving equipment. Troubleshooting should cover both the electrical signal path and the mechanical installation.
Q9: Can another 90 mm encoder replace the XCC-3912PS84SGN?
Not automatically. A replacement must also match the required encoder type, measurement range, output interface, resolution, mechanical arrangement, and controller compatibility.
Q10: What should be checked before installing a replacement encoder?
Verify the complete model number, mounting dimensions, electrical ratings, output interface, position range, connection requirements, and the receiving system’s configuration. Perform controlled functional testing before returning the equipment to normal operation.
13. Conclusion
The Schneider XCC-3912PS84SGN XCC Multi-Turn Absolute Encoder is an industrial feedback component identified for applications requiring absolute rotational position information across multiple turns. Its supplied diameter of 90 mm and weight of 1.84 kg provide useful information for initial identification, equipment planning, and replacement assessment.
For dependable operation, engineers should confirm the encoder’s resolution, supported multi-turn range, output interface, electrical requirements, and mechanical mounting configuration before installation. Correct integration with the receiving controller or drive, careful commissioning, and regular maintenance can help maintain reliable position feedback in industrial automation systems.