

ProductPRODUCT
Featured products
Contact Us
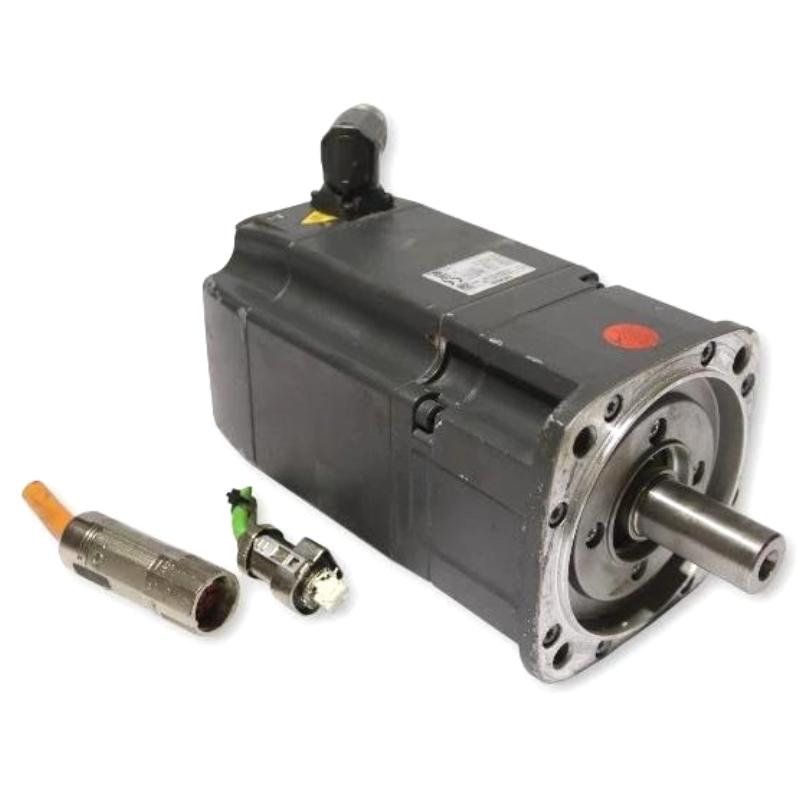
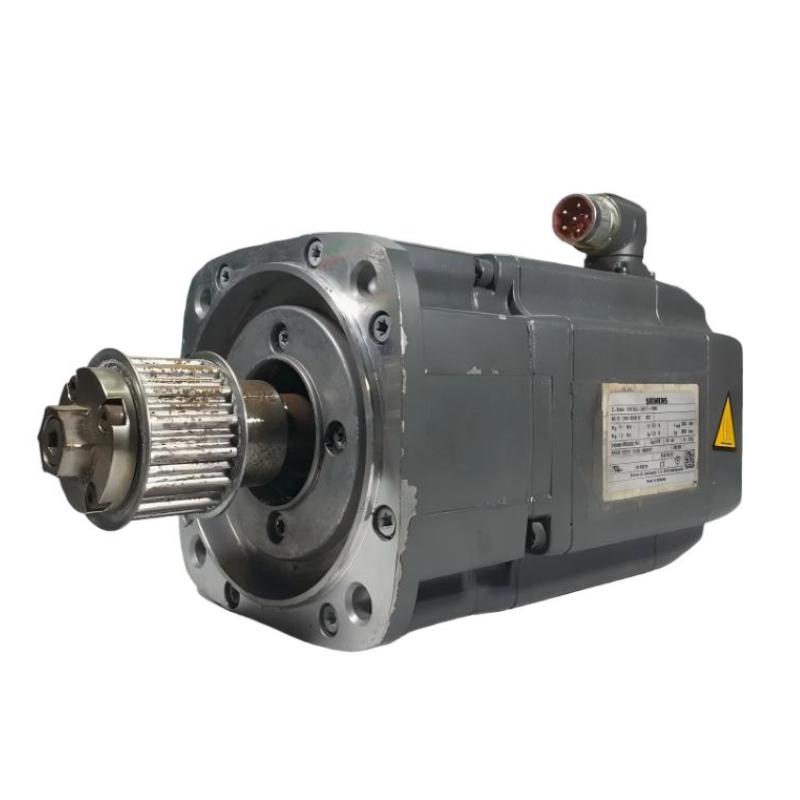
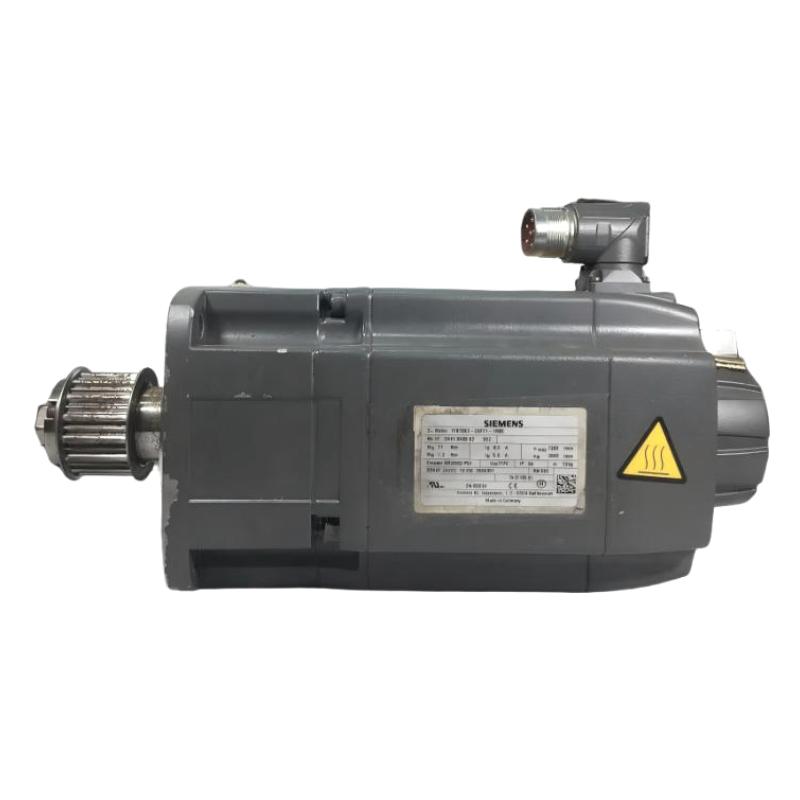
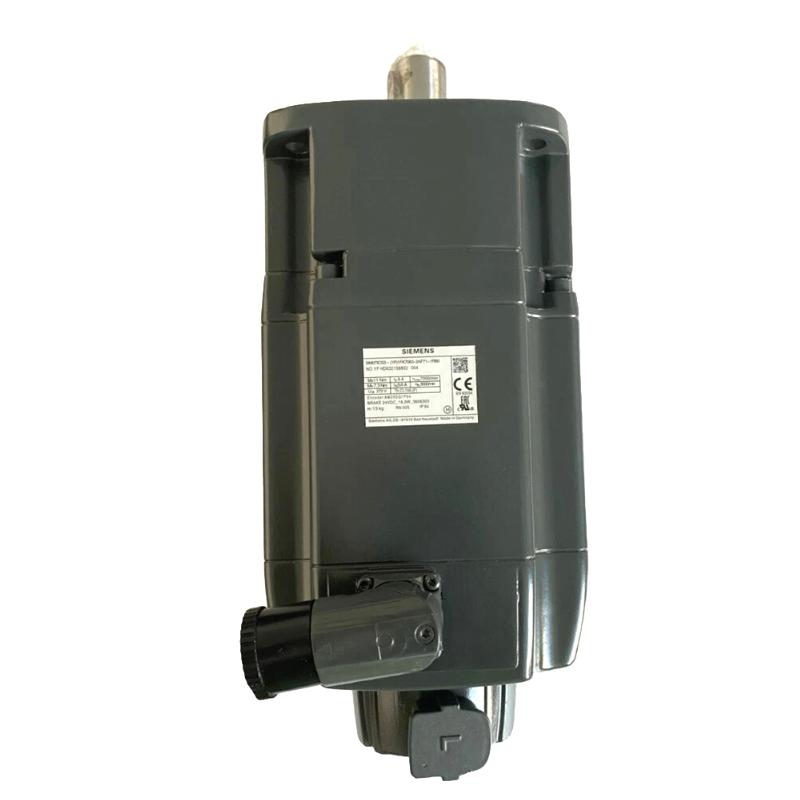
- Siemens
- 1FK7063-2AF71-1RB0
- Synchronous Motor
- Germany
- 63 mm
- 11.400 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
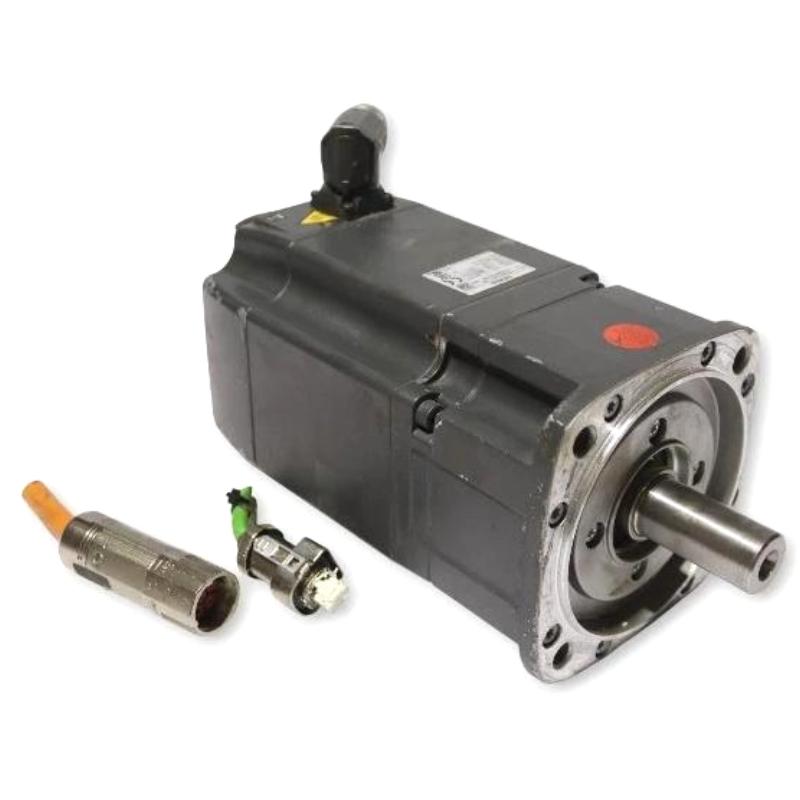
Product Overview
The Siemens 1FK7063-2AF71-1RB0 SIMOTICS S Synchronous Motor is a permanent-magnet synchronous motor from the SIMOTICS S-1FK7 compact motor family. It is intended for industrial servo applications that require controlled rotation, repeatable positioning, and coordinated movement. This configuration combines natural cooling, an absolute encoder with DRIVE-CLiQ communication, a feather-key shaft, and an integrated holding brake.
In a servo-motion system, the motor converts electrical energy into mechanical torque while a compatible drive regulates its response to motion commands. Encoder feedback allows the drive to monitor rotor position and control movement according to the requirements of the machine. This arrangement supports applications that need controlled acceleration, regulated speed, and repeatable positioning rather than simple continuous rotation.
The 1FK7063-2AF71-1RB0 has a rated power of 2.3 kW and a rated speed of 3,000 rpm. Its rated torque is 7.3 Nm, while its static torque at the specified 100 K temperature-rise condition is 11 Nm. These ratings help engineers evaluate the motor against the required torque-speed profile, but the final selection must also consider load inertia, acceleration, operating frequency, and the dynamic capabilities of the connected drive.
A key feature of this model is its AM20DQI absolute encoder, which provides 20-bit single-turn position information and 12-bit multiturn information through the DRIVE-CLiQ interface. This feedback arrangement allows compatible Siemens drive systems to obtain rotor-position information for motion regulation and commissioning. The encoder configuration is particularly relevant when replacing an existing motor because the drive must support the specified feedback interface.
The integrated holding brake helps keep the shaft stationary when the application requires mechanical holding and the brake is correctly engaged. This function is distinct from the motor’s torque production during movement. Brake control, release timing, and load suitability must follow the applicable motor and drive requirements. The holding brake should not automatically be treated as a dynamic stopping device or as a complete machine safety function.
The feather-key shaft provides a mechanical interface for compatible couplings and transmission components. The key helps transfer torque between the motor shaft and the connected mechanical assembly. The coupling and mating components must be selected to suit the shaft interface, torque demand, alignment requirements, and operating speed. Incorrect assembly or excessive radial and axial loading can affect bearing life and motion accuracy.
Natural cooling dissipates motor heat through the housing and surrounding environment. The installation must therefore allow for the thermal conditions associated with the intended duty cycle. Ambient temperature, mounting orientation, surrounding airflow, and repeated high-torque movements can influence the permissible continuous load.
The motor uses an IM B5 flange mounting arrangement, with IM V1 and IM V3 mounting positions supported as specified for this motor series. Its IP64 protection rating defines protection against dust ingress and water splashing under the specified conditions. The suitability of the complete installation also depends on connector condition, cable routing, and the environmental requirements of the machine.
The 1FK7063-2AF71-1RB0 is intended for integration with compatible Siemens SINAMICS servo-drive systems. Drive selection requires consideration of the motor’s electrical ratings, encoder interface, brake control, speed range, and dynamic load requirements. Correct configuration allows the motor and drive to operate as a coordinated motion-control unit.
Typical applications include automated assembly machinery, packaging equipment, production-line mechanisms, and material-handling systems that require controlled rotary movement. Its suitability for a particular machine depends on the actual motion profile, mechanical transmission, feedback requirements, and operating conditions.
The Siemens 1FK7063-2AF71-1RB0 combines permanent-magnet synchronous motor technology with absolute position feedback, a feather-key shaft, and an integrated holding brake. When matched with a compatible drive and correctly installed mechanical components, it can support controlled and repeatable motion in industrial automation systems.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Siemens |
| Model | 1FK7063-2AF71-1RB0 |
| Product Family | SIMOTICS S-1FK7 |
| Product Type | Permanent-Magnet Synchronous Motor |
| Motor Series | 1FK7-CT Compact Synchronous Motor |
| Rated Power | 2.3 kW |
| DC-Link Voltage | 600 V DC |
| Rated Speed | 3,000 rpm |
| Rated Torque at 100 K | 7.3 Nm |
| Static Torque at 100 K | 11 Nm |
| Rated Current at 100 K | 5.6 A |
| Static Current at 100 K | 8.0 A |
| Maximum Mechanical Speed | 7,200 rpm |
| Maximum Torque | 35 Nm |
| Cooling Method | Natural cooling |
| Mounting Design | IM B5 (IM V1, IM V3) |
| Flange Size | 1 |
| Encoder Type | Absolute encoder, single-turn and multiturn |
| Encoder Model | AM20DQI |
| Single-Turn Resolution | 20-bit |
| Multiturn Resolution | 12-bit |
| Encoder Interface | DRIVE-CLiQ |
| Shaft Type | Feather-key shaft, tolerance N |
| Holding Brake | Integrated |
| Temperature Monitoring | Pt1000 temperature sensor |
| Degree of Protection | IP64 |
| Electrical Connections | Rotatable power connector and signal connections |
| Recommended Drive Family | Compatible Siemens SINAMICS servo drive systems |
| Shaft Height | 63 mm |
| Weight | 11.400 kg |
Product Features
- Permanent-magnet synchronous design: Generates controlled torque for industrial servo applications.
- 2.3 kW rated power: Supports motion tasks within the motor’s specified electrical and thermal operating limits.
- 3,000 rpm rated speed: Suits servo axes requiring regulated rotational speed and controlled acceleration.
- AM20DQI absolute encoder: Supplies 20-bit single-turn and 12-bit multiturn position information.
- DRIVE-CLiQ interface: Connects the encoder to compatible Siemens drive systems for feedback and commissioning.
- Integrated holding brake: Helps maintain shaft position when the brake is correctly controlled and the load is within its permitted operating conditions.
- Feather-key shaft: Provides a keyed mechanical interface for compatible torque-transmission components.
- Natural cooling: Dissipates heat without requiring a separate forced-air cooling unit mounted to the motor.
- Flange mounting: Supports integration into compatible machine structures and servo-axis assemblies.
- IP64 protection: Provides defined protection against dust ingress and water splashing under the specified conditions.
- Pt1000 temperature monitoring: Supplies motor temperature information for compatible monitoring and protection functions.
Working Principle
The Siemens 1FK7063-2AF71-1RB0 operates as the electromechanical actuator in a closed-loop servo system. A compatible servo drive supplies controlled current to the motor windings, generating a rotating magnetic field that interacts with the permanent magnets in the rotor. This interaction produces torque and drives the shaft.
Motion Command → SINAMICS Servo Drive → Motor Rotation → DRIVE-CLiQ Feedback → Control Correction
The motion controller generates a position, speed, or torque command according to the machine sequence. The servo drive processes the command and regulates the electrical current supplied to the motor. By adjusting current, the drive controls the motor’s torque and influences acceleration, deceleration, and operating speed.
As the rotor moves, the AM20DQI encoder supplies absolute position information through DRIVE-CLiQ. Its single-turn data identifies angular position within one revolution, while the multiturn data represents position across multiple revolutions within the encoder’s specified range. The compatible drive uses this information as part of its motion-control process.
Absolute feedback helps the drive determine rotor position without relying solely on accumulated incremental pulses. However, startup behavior and machine-position management still depend on the drive configuration, encoder initialization, and application requirements. The machine designer must verify the required reference and recovery behavior during commissioning.
The integrated holding brake performs a separate function from the motor’s electromagnetic torque production. During normal movement, the brake must be released according to the specified control sequence. When the application requires the shaft to remain stationary, the brake can hold the shaft within its rated conditions. The brake-control arrangement must follow the prescribed electrical and mechanical requirements.
Brake selection and use must account for the actual load, transmission ratio, external forces, and the consequences of unintended movement. Applications involving suspended loads or safety-related stopping requirements may need additional engineered measures. The integrated brake should not be assumed to provide every required safety function.
The feather-key shaft transfers torque through a compatible keyed coupling or transmission component. Proper mating dimensions, key engagement, alignment, and fastening are necessary to prevent unwanted movement at the mechanical interface. Poor alignment or excessive shaft loading can introduce vibration and place additional stress on the bearings.
The Pt1000 temperature sensor supplies temperature information to compatible monitoring electronics. Correct wiring and parameterization allow the drive system to monitor thermal conditions during operation. This is particularly relevant when the motor experiences sustained loading or frequent acceleration cycles.
Natural cooling removes heat through the motor housing and surrounding environment. The available thermal margin depends on ambient temperature, mounting conditions, and the operating duty. If the application involves prolonged high torque or frequent changes in speed, the motor’s thermal limits must be considered during system design.
During normal operation, the controller defines the movement, the drive regulates current, the encoder reports rotor position, and the holding brake provides stationary holding when appropriately engaged. These functions work together to support controlled movement within an industrial automation system.
Role in the Industrial Control Architecture
The 1FK7063-2AF71-1RB0 forms the actuator stage of a servo-motion axis. It receives controlled electrical power from a compatible servo drive and returns absolute encoder information through DRIVE-CLiQ. Its integrated holding brake is controlled as part of the complete axis arrangement.
Motion Controller → SINAMICS Servo Drive → 1FK7063-2AF71-1RB0 → Mechanical Load
| System Component | Function |
|---|---|
| Siemens 1FK7063-2AF71-1RB0 | Converts electrical power into controlled mechanical rotation |
| SINAMICS Servo Drive | Regulates motor current, torque, speed, and position |
| SIMATIC Motion Controller or PLC | Generates axis commands and coordinates machine sequences |
| AM20DQI Absolute Encoder | Supplies single-turn and multiturn rotor-position information |
| DRIVE-CLiQ Connection | Transfers encoder data to compatible drive electronics |
| Holding-Brake Circuit | Controls release and engagement of the integrated brake |
| Pt1000 Temperature Sensor | Provides motor temperature information for compatible monitoring functions |
| Motor Power Cable | Supplies electrical power from the drive to the motor |
| Mechanical Coupling | Transfers torque from the keyed shaft to the connected mechanism |
| Gearbox or Transmission | Adapts speed and torque to the load where required |
| Engineering Software | Supports motor identification, drive configuration, commissioning, and diagnostics |
The controller defines the movement, while the drive regulates motor operation using encoder feedback. The brake circuit and mechanical transmission must also be configured according to the requirements of the individual axis.
Industrial Applications
| Application | Typical Use |
|---|---|
| Automated Assembly Machines | Positioning tooling, fixtures, and rotary mechanisms |
| Packaging Equipment | Driving indexing mechanisms and synchronized feed systems |
| Material-Handling Machinery | Controlling rotary axes in automated handling equipment |
| Production-Line Automation | Executing repeatable movement within coordinated machine sequences |
| Printing Machinery | Driving controlled feed and positioning mechanisms |
| Industrial Converting Equipment | Regulating rollers and other rotary machine elements |
| Automated Inspection Systems | Positioning fixtures and inspection assemblies |
| Manufacturing Equipment | Providing controlled rotation for process mechanisms |
| Servo Positioning Systems | Using absolute encoder feedback for repeatable axis movement |
| Load-Holding Servo Axes | Supporting applications where an appropriately engineered holding-brake function is required |
Installation and Maintenance
- Confirm drive compatibility: Check the motor’s rated power, current, speed, encoder interface, and brake requirements against the selected servo drive.
- Inspect the motor before installation: Check the connectors, shaft, keyway, mounting flange, and enclosure for visible damage that could affect operation.
- Prepare the mounting structure: Ensure that the machine flange and supporting structure are suitable for the specified mounting arrangement and expected operating loads.
- Align the mechanical coupling: Use a coupling compatible with the feather-key shaft and follow the specified alignment tolerances to avoid excessive bearing forces.
- Connect the motor power cable: Use the appropriate power connection and follow the required grounding, shielding, and electrical installation practices.
- Connect the DRIVE-CLiQ interface: Use compatible signal cabling and confirm that the encoder is recognized by the drive during commissioning.
- Wire the holding brake correctly: Follow the specified brake supply and control requirements, and verify the release sequence before enabling normal motion.
- Configure the drive parameters: Check the motor data, encoder identification, control mode, speed limits, and brake settings in the engineering environment.
- Verify absolute position feedback: Confirm that the reported rotor position is plausible and that the machine’s reference-management procedure behaves as intended.
- Test the brake function: Verify release and engagement under the approved commissioning procedure, taking the actual load and mechanical arrangement into account.
- Monitor temperature and vibration: Investigate abnormal heating, noise, or vibration that may indicate overload, coupling misalignment, bearing problems, or incorrect tuning.
- Maintain configuration records: Retain the motor identification, drive parameters, encoder settings, brake configuration, and maintenance history for future troubleshooting.
If the axis exhibits positioning errors, inspect the DRIVE-CLiQ connection, encoder configuration, mechanical coupling, and drive parameters. If the brake does not operate as expected, check its wiring, control settings, and mechanical loading before returning the machine to service.
Related Components
| Component | Function |
|---|---|
| Siemens 1FK7063-2AF71-1RB0 SIMOTICS S Synchronous Motor | Provides controlled rotary motion with absolute feedback and an integrated holding brake |
| Siemens SINAMICS Servo Drive | Regulates motor current, torque, speed, and position |
| SIMATIC Motion Controller | Coordinates axis movement and machine sequences |
| DRIVE-CLiQ Cable | Transfers encoder information to compatible drive electronics |
| Motor Power Cable | Supplies electrical power to the motor |
| Holding-Brake Connection | Provides the electrical interface required to control the brake |
| Pt1000 Sensor Connection | Transfers motor temperature information to compatible monitoring electronics |
| Keyed Mechanical Coupling | Transfers torque from the feather-key shaft to the driven mechanism |
| Gearbox | Adapts motor speed and torque to the application |
| Engineering Software | Supports drive setup, commissioning, tuning, and diagnostics |
| Industrial Control Cabinet | Houses the servo drive, controller, and associated electrical equipment |
Recommended Related Models
| Model | Product Type | Typical Application |
|---|---|---|
| Siemens 1FK7063-2AF71-1RB0 | SIMOTICS S Synchronous Motor | Absolute encoder, feather-key shaft, natural cooling, and integrated holding brake |
| Siemens 1FK7063-2AF71-1RH0 | SIMOTICS S Synchronous Motor | Related configuration with absolute DRIVE-CLiQ feedback and a smooth shaft |
| Siemens 1FK7063-2AF71-1RG0 | SIMOTICS S Synchronous Motor | Related configuration with absolute DRIVE-CLiQ feedback and a smooth shaft without an integrated holding brake |
| Siemens 1FK7063-2AF71-1CH1 | SIMOTICS S Synchronous Motor | Related configuration with absolute DRIVE-CLiQ feedback, a smooth shaft, and an integrated holding brake |
Key Advantages
- Provides controlled rotary movement for compatible servo-drive systems.
- Uses absolute single-turn and multiturn feedback through DRIVE-CLiQ.
- Integrates a holding brake for applications requiring stationary shaft holding.
- Supports keyed mechanical torque transmission through a feather-key shaft.
- Includes Pt1000 temperature monitoring for compatible drive systems.
- Combines motion feedback and brake functionality in one servo-motor assembly.
Technical FAQs
What is the difference between the AM20DQI encoder and an incremental encoder?
The AM20DQI provides absolute single-turn and multiturn position information through DRIVE-CLiQ. An incremental encoder instead generates signals representing relative movement and generally requires a reference procedure when the system needs to establish a known position. The appropriate choice depends on the drive architecture and machine-position requirements.
What should be checked when coupling this motor to an existing gearbox?
Confirm that the gearbox input interface accommodates the feather-key shaft and that the coupling or adapter matches the mechanical arrangement. Check torque capacity, alignment, permitted shaft loading, and the operating speed before commissioning.
How should the integrated holding brake be handled during startup and shutdown?
The brake must be released and engaged according to the specified electrical and mechanical procedure. The control sequence should account for motor torque and the load conditions so that the brake is not inadvertently used as a routine dynamic stopping device unless its ratings explicitly permit that duty.
Which factors can cause the motor to overheat despite operating within its rated speed?
High sustained torque, frequent acceleration cycles, elevated ambient temperature, restricted heat dissipation, and unsuitable drive settings can all affect thermal loading. The Pt1000 sensor connection and monitoring parameters should also be checked if the reported temperature appears inconsistent with actual operating conditions.