

ProductPRODUCT
Featured products
Contact Us
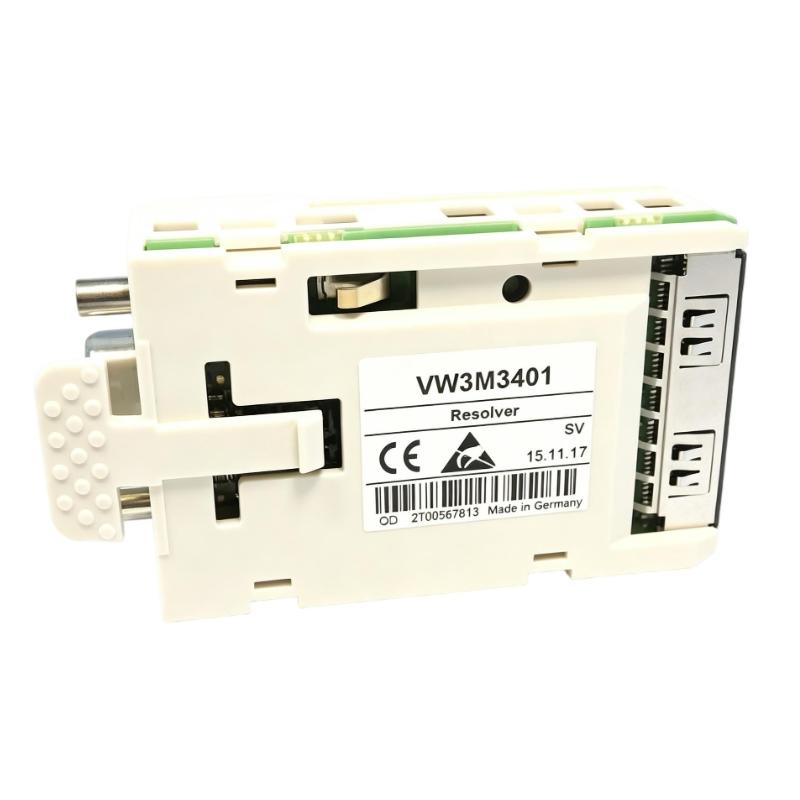
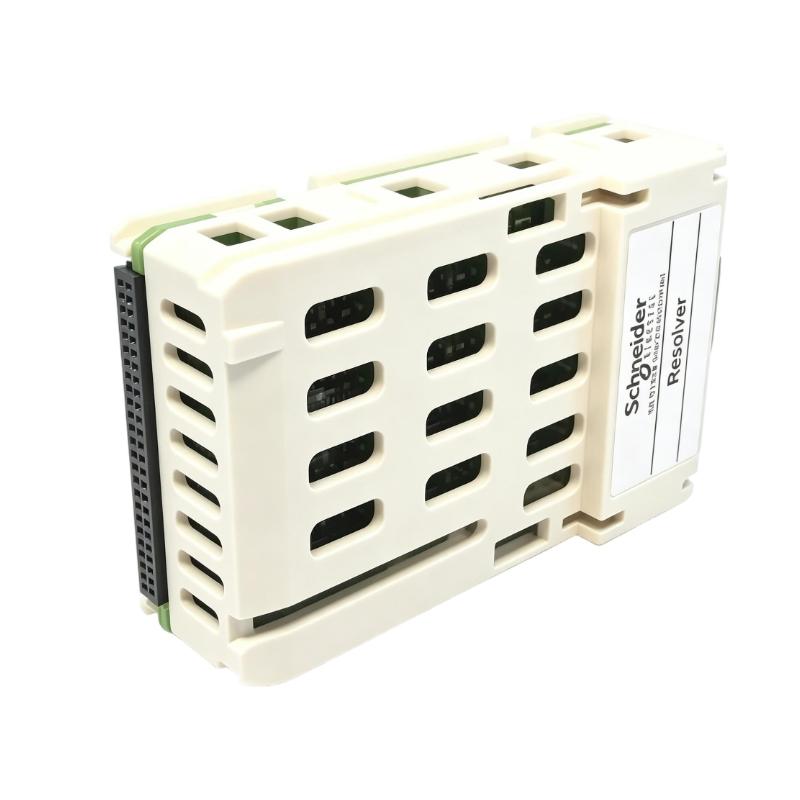
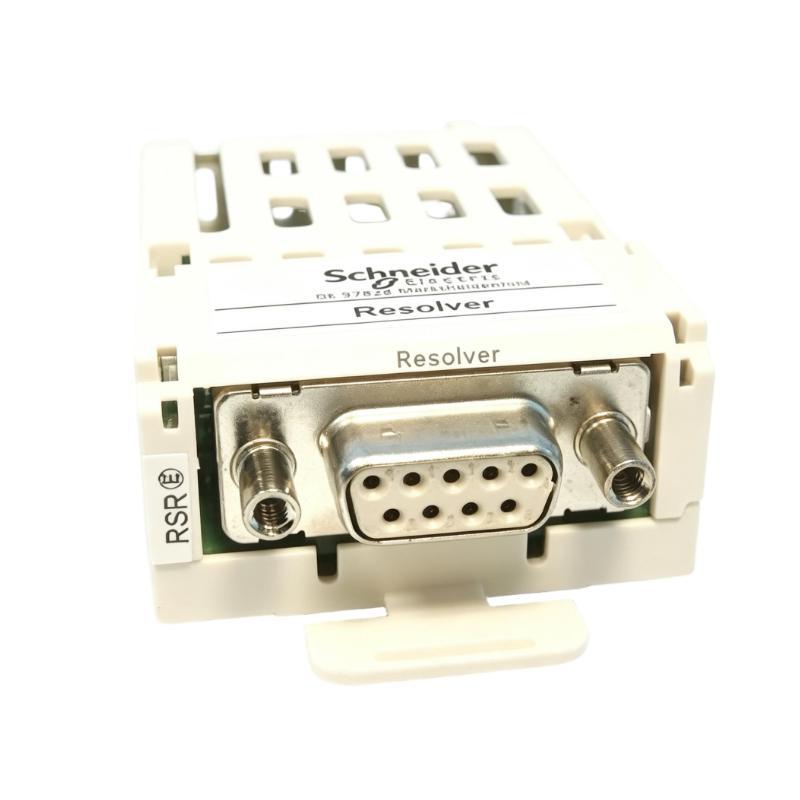
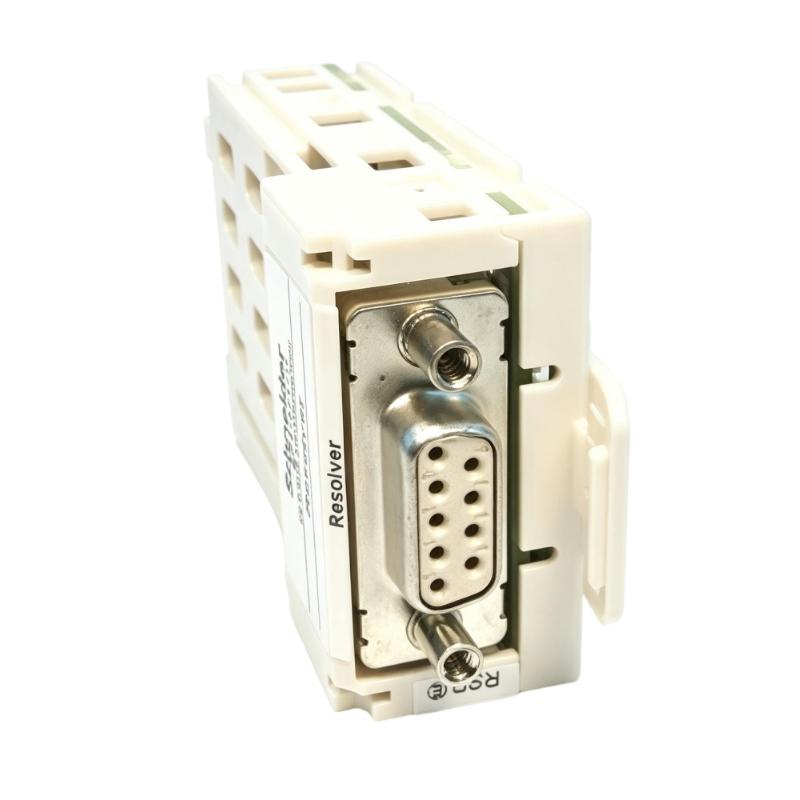
- Schneider
- VW3M3401
- Encoder Interface Module
- France
- 89 x 41 x 61 mm
- 0.057 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage

Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.

Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.

24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.

Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
1. Product Overview
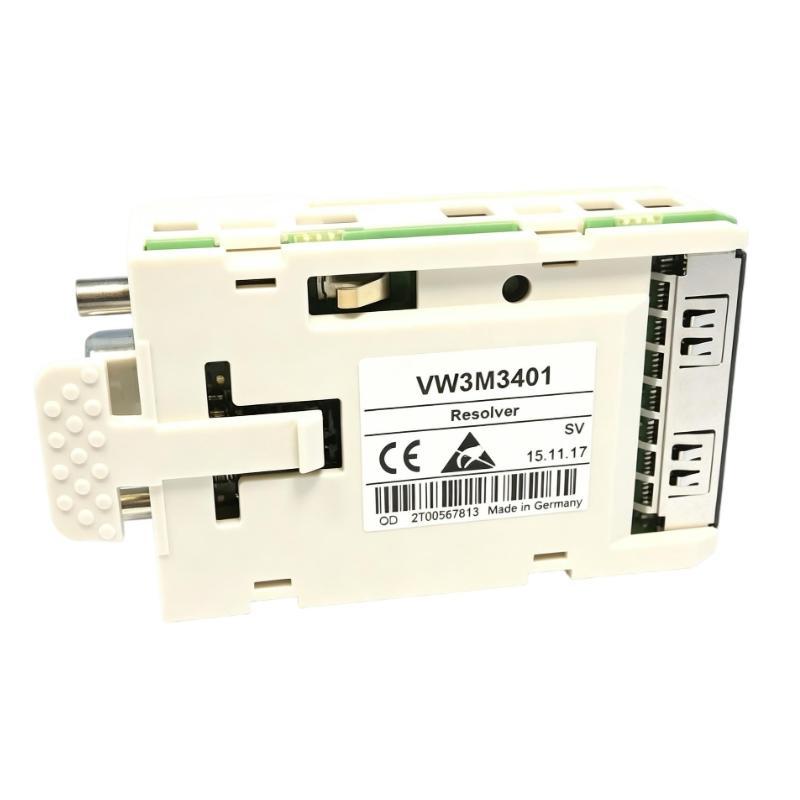
The Schneider VW3M3401 Encoder Interface Module is an industrial automation component identified for encoder interface applications. Encoder interfaces are important in motion-control systems because they provide a connection between feedback devices and compatible control equipment, allowing position, speed, or movement-related information to be used by the automation system when supported by the installed hardware.
In industrial machinery, encoder feedback can help controllers and drives monitor motion and coordinate equipment operation. The correct interface module must match the encoder type, electrical interface, supported equipment, and system configuration. Choosing an incompatible module may prevent feedback signals from being interpreted correctly or stop the system from operating as intended.
The Schneider VW3M3401 has supplied dimensions of 89 × 41 × 61 mm and a listed weight of 0.057 kg. These specifications provide useful reference information for product identification, spare-parts management, and preliminary installation planning.
The exact encoder types supported by the VW3M3401, its signal characteristics, connector arrangement, electrical requirements, and compatible drive or controller models should be confirmed from the product label and applicable Schneider Electric technical documentation. These details should not be inferred from the model designation alone.
For maintenance engineers, system integrators, and industrial spare-parts buyers, verifying the complete part number is essential before installing or replacing an encoder interface module.
2. Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Schneider Electric |
| Model | VW3M3401 |
| Product Type | Encoder Interface Module |
| Dimensions | 89 × 41 × 61 mm |
| Weight | 0.057 kg |
| Application | Encoder feedback integration in compatible automation systems |
| Encoder Compatibility | Confirm the supported encoder types from product documentation |
| Signal Interface | Verify the supported signal format and electrical characteristics |
| Connector Configuration | Confirm the required connector arrangement |
| Compatible Equipment | Verify supported drives, controllers, and feedback devices |
| Configuration Requirements | Check the applicable hardware and software instructions |
| Installation Requirements | Follow the product-specific installation procedure |
The dimensions and weight above are the supplied product specifications. Encoder signal types, supply requirements, pin assignments, supported feedback standards, and compatible equipment models should be verified before installation or commissioning.
3. Function and Working Principle
An encoder interface module provides a connection between a compatible encoder and the equipment that uses its feedback information. Depending on the design, the interface may support the transmission or interpretation of position-related, speed-related, or other motion feedback signals.
The exact function of the Schneider VW3M3401 depends on its documented specifications and the automation equipment for which it is intended. Its designation as an encoder interface module does not, by itself, establish the encoder technologies or signal formats it supports.
3.1 Encoder Feedback
An encoder is a feedback device that generates signals associated with movement or position. Depending on its type, an encoder may provide incremental pulses, absolute position information, or another supported feedback format.
The connected controller or drive uses this information according to the system’s control architecture. Accurate feedback can help the equipment monitor movement and coordinate motion-related tasks.
3.2 Signal Interface
The encoder interface establishes the required electrical and signal connection between the feedback device and compatible automation equipment. Signal characteristics must match the receiving interface requirements.
An encoder may physically connect to a system yet remain incompatible if its signal format, voltage levels, or interface standard is unsupported.
3.3 Integration with Motion Control
In suitable motion-control systems, encoder feedback can be used for monitoring movement, assessing speed, and supporting position-related control functions. The specific role of the VW3M3401 depends on the compatible drive or controller and the overall system configuration.
3.4 Importance of Correct Feedback Configuration
Reliable encoder operation requires the correct interface, wiring, signal settings, and device configuration. Incorrect settings or incompatible feedback hardware can lead to missing feedback, inaccurate readings, diagnostic alarms, or unexpected machine behavior.
The applicable product documentation should therefore be checked before commissioning.
4. Role in Industrial Automation Systems
Encoder interface modules can be important components in automation systems that rely on motion feedback. They help connect designated feedback devices to compatible control equipment.
4.1 Motion Monitoring
Encoder feedback can provide information about movement and position. Where supported by the system, this information allows controllers or drives to monitor motion-related operating conditions.
4.2 Drive and Controller Integration
Industrial drives and controllers may use feedback interfaces to receive information from encoders. The interface module must be compatible with the receiving equipment and the specific encoder technology.
The VW3M3401 should be selected only after verifying its intended hardware configuration.
4.3 Position and Speed Feedback
Depending on the encoder and control architecture, feedback information may support position monitoring, speed measurement, or motion coordination. The actual functions available depend on the supported hardware and software.
4.4 Machine Coordination
Automated machines often coordinate several moving components. Appropriate feedback interfaces can help integrate encoder information into the control system, supporting the intended machine sequence and motion behavior.
4.5 Maintenance and System Reliability
Encoder interface faults may affect the availability or accuracy of a motion-control system. Correct module identification, proper installation, and systematic troubleshooting help maintenance personnel isolate problems and reduce avoidable downtime.
5. Industrial Applications
The Schneider VW3M3401 may be considered for industrial installations where the exact module is specified and its documented capabilities match the encoder and control-system requirements.
5.1 Servo and Motion-Control Systems
Servo applications may use encoder feedback to monitor motor movement and support precise control. A suitable interface is required to connect the feedback device to the compatible drive or controller.
The VW3M3401 should be used in such an application only when the required compatibility is confirmed.
5.2 Automated Manufacturing Equipment
Manufacturing machines often include moving axes, positioning mechanisms, and coordinated drive systems. Encoder feedback can help control equipment movement and monitor operating conditions.
5.3 Packaging Machinery
Packaging systems may use motion feedback to coordinate feeding, cutting, indexing, and product-handling mechanisms. Suitable encoder interfaces can support the integration of feedback devices into the machine’s control architecture.
5.4 Material Handling Equipment
Conveyors, positioning units, and automated transfer systems may use encoders to monitor movement or speed. Correct interface selection helps ensure that the feedback device can communicate with the intended control equipment.
5.5 Robotics and Positioning Equipment
Some robotic and positioning applications rely on feedback devices to monitor movement. The required interface depends on the encoder technology, controller architecture, and supported signal format.
5.6 Industrial Equipment Maintenance
When an existing encoder interface module requires replacement, the complete part number and supported feedback configuration should be checked. A replacement must match the original function and the requirements of the connected equipment.
These examples describe potential environments for suitable encoder interface hardware. They do not establish universal compatibility between the VW3M3401 and every application listed.
6. Installation and System Integration
Correct installation is essential for reliable encoder feedback and safe machine operation. The following steps provide a general checklist; the model-specific instructions and requirements of the connected equipment take precedence.
Step 1: Verify the Model Number
Confirm that the module label or packaging identifies the product as Schneider VW3M3401. Compare the part number with the equipment documentation, original module, and spare-parts list.
Do not replace the module with a similar-looking product without confirming its function and compatibility.
Step 2: Confirm Encoder Compatibility
Identify the encoder that will be connected to the module. Verify the encoder type, supported signal format, electrical characteristics, and connector arrangement against the applicable documentation.
Step 3: Isolate the Equipment
Before installation or removal, place the machine in a safe state and isolate the relevant power sources according to the site’s approved procedures. Verify that the equipment is safe to handle.
Follow applicable lockout/tagout requirements. Motion-control equipment may require additional precautions to prevent unexpected movement.
Step 4: Inspect the Module and Connectors
Check the module housing, connectors, contacts, and mounting interface for visible damage or contamination. Confirm that the module is suitable for installation and that the connection points are in good condition.
Step 5: Check the Wiring Requirements
Review the approved wiring diagram and confirm the correct signal connections, cable requirements, shielding provisions, and grounding arrangements where applicable.
Never infer pin assignments, voltage levels, or signal polarity from the model number alone.
Step 6: Install the Module
Install the module according to the specified mounting and connection procedure. Ensure that it is correctly positioned and securely fitted.
Avoid excessive force when engaging connectors or mounting components.
Step 7: Configure the Feedback System
Where configuration is required, use the supported engineering software and follow the applicable equipment instructions. Confirm that the encoder settings and feedback configuration match the installed hardware.
Record existing settings before making changes to an operating system.
Step 8: Restore Power and Verify Feedback
Restore power according to the approved commissioning procedure. Check module indicators, drive diagnostics, controller status, and available feedback data.
Verify that the feedback signal is recognized and behaves as expected before returning the machine to normal operation.
7. Common Problems and Troubleshooting
Encoder interface problems may result from incorrect wiring, incompatible feedback devices, configuration errors, damaged connectors, or faults elsewhere in the control system.
| Symptom | Possible Causes | Recommended Checks |
|---|---|---|
| Encoder is not detected | Incorrect installation, incompatible encoder, or connection fault | Verify the model, connector arrangement, and supported encoder type |
| No feedback data is available | Wiring fault, missing supply where required, or unsupported signal interface | Check the approved wiring diagram and electrical requirements |
| Feedback readings are unstable | Loose connections, damaged cable, electrical interference, or configuration problems | Inspect wiring, shielding, routing, and feedback settings |
| Drive or controller reports a feedback fault | Incompatible encoder, incorrect settings, or hardware fault | Review diagnostic codes and verify the complete feedback configuration |
| Position or speed readings appear incorrect | Incorrect configuration, signal mismatch, or encoder-related problem | Confirm encoder settings and compare feedback behavior with system requirements |
| Fault occurs after module replacement | Incorrect replacement model, wiring differences, or configuration mismatch | Compare the original and replacement modules and verify all connections |
| Fault remains after replacement | Problem may originate in the encoder, cable, drive, or controller | Check the entire feedback path and associated equipment |
7.1 Check the Physical Connections
Inspect accessible connectors and cables for looseness, damage, or contamination. Ensure that the module and encoder connections are correctly seated according to the approved procedure.
Perform inspections with the equipment safely isolated where required.
7.2 Verify Encoder Compatibility
Confirm that the connected encoder is supported by the interface and receiving equipment. Check the documented signal format and electrical characteristics rather than assuming that all encoders are interchangeable.
7.3 Review Feedback Configuration
Incorrect encoder parameters can cause missing or inaccurate feedback. Review the relevant settings in the engineering software and compare them with the encoder and drive documentation.
Avoid changing parameters without recording the original configuration.
7.4 Inspect Cabling and Electrical Interference
Damaged cables, loose connectors, improper routing, or electrical interference may affect feedback signals. Check the installation against the specified requirements for cable type, shielding, grounding, and separation from other wiring.
7.5 Determine Whether Replacement Is Necessary
If the encoder, cable, wiring, and configuration have been checked but the fault persists, further testing may be needed to determine whether the interface module is defective. Replace the module only with a verified compatible part, then repeat the required commissioning checks.
8. Preventive Maintenance and Reliability
Preventive maintenance helps identify feedback problems before they cause production interruptions or unexpected machine behavior.
- Inspect connectors and cables: Check for loose fittings, damaged insulation, and visible connector defects.
- Monitor diagnostic information: Record recurring feedback alarms and investigate their causes.
- Maintain configuration records: Keep accurate encoder settings, module lists, wiring diagrams, and controller backups.
- Protect feedback wiring: Follow the specified cable-routing, shielding, and grounding requirements.
- Check mechanical conditions: Ensure that cable routing does not expose connections to excessive vibration, tension, or movement.
- Use approved replacement parts: Confirm the exact module model and encoder compatibility before installation.
- Document maintenance work: Record replacement dates, configuration changes, and troubleshooting findings.
- Follow safe working procedures: Apply the approved isolation and commissioning procedures for motion-control equipment.
The appropriate maintenance interval depends on the operating environment, equipment criticality, vibration, cable movement, and site maintenance policy.
9. Compatible System Components
The compatible equipment for the VW3M3401 should be established from its technical documentation and the requirements of the intended installation.
| Component Category | Integration Considerations |
|---|---|
| Encoder or feedback device | Confirm supported encoder types, signal format, and electrical characteristics |
| Servo drive or motor-control equipment | Verify the supported feedback interface and hardware configuration |
| Controller or motion controller | Check compatibility with the intended feedback architecture |
| Encoder cable | Confirm cable specifications, connector types, and required shielding |
| Power supply | Verify applicable supply requirements for the module and feedback device |
| Engineering software | Confirm support for the installed hardware and configuration parameters |
| Control cabinet assembly | Check mounting requirements, available space, and cable routing |
This table identifies component categories that may need to be checked during integration. It does not confirm compatibility with any specific encoder, drive, or controller model.
10. Replacement and Alternative Selection
When selecting a replacement for the Schneider VW3M3401, verify the encoder interface and supported system configuration rather than relying on physical dimensions alone.
| Selection Factor | What to Verify |
|---|---|
| Exact model | Confirm Schneider VW3M3401 |
| Dimensions | 89 × 41 × 61 mm |
| Weight | 0.057 kg |
| Functional role | Confirm the module’s documented encoder interface function |
| Encoder compatibility | Verify the supported encoder type and signal format |
| Electrical characteristics | Confirm the required signal and supply specifications |
| Connector configuration | Match the required interface and contact arrangement |
| Hardware compatibility | Verify support for the connected drive or controller |
| Software requirements | Confirm applicable configuration and diagnostic support |
| Product condition | Inspect the module and connectors before installation |
10.1 Selecting a Direct Replacement
The original model number is the preferred starting point when sourcing a replacement. Confirm that the replacement has the same documented function and is supported by the existing equipment.
10.2 Evaluating Alternative Modules
An alternative module must meet the required encoder interface, electrical characteristics, connector configuration, and hardware compatibility requirements. Similar dimensions or a general encoder-interface description do not establish functional equivalence.
If the original module is unavailable, verify the proposed alternative against the equipment documentation or with a qualified technical specialist.
10.3 Commissioning After Replacement
After replacing the module, inspect all connections, restore the required configuration, and verify that the encoder feedback is recognized correctly. Review diagnostic information and complete the required functional tests before returning the machine to normal operation.
11. Key Benefits of Correct Encoder Interface Selection
Selecting a suitable encoder interface module can support reliable feedback integration in compatible automation systems.
Reliable feedback integration: A correctly matched interface provides the connection required between a supported encoder and the intended control equipment.
Improved system compatibility: Verifying the encoder type and signal characteristics helps prevent feedback mismatch and configuration problems.
Efficient product identification: The VW3M3401 model number, supplied dimensions, and weight support inventory management and spare-parts planning.
Simplified troubleshooting: Accurate module identification and configuration records help engineers isolate faults within the feedback system.
Maintainable motion-control architecture: Using approved components helps preserve the intended hardware arrangement during repairs and upgrades.
Reduced avoidable downtime: Correct selection, installation, and commissioning can help prevent faults caused by incompatible interfaces or incorrect settings.
These benefits depend on verifying the module’s actual technical characteristics and using it according to the requirements of the connected equipment.
12. Technical FAQs
Q1: What is the Schneider VW3M3401?
The Schneider VW3M3401 is identified in the supplied product information as an encoder interface module. Its exact feedback function and compatible equipment should be confirmed from the module label and applicable technical documentation.
Q2: What are the dimensions of the VW3M3401?
The supplied dimensions are 89 × 41 × 61 mm.
Q3: How much does the VW3M3401 weigh?
The supplied product weight is 0.057 kg.
Q4: What does an encoder interface module do?
An encoder interface module connects a compatible feedback device to supported control equipment. Depending on the system, encoder feedback may provide information about movement, position, or speed.
Q5: Which encoders are compatible with the VW3M3401?
The supported encoder types and signal formats should be confirmed from the technical documentation for the exact model. Compatibility should not be inferred from the module’s name alone.
Q6: Can the VW3M3401 be used with any Schneider Electric drive?
No. Compatibility depends on the drive model, supported feedback interface, electrical requirements, and system configuration.
Q7: Why might the controller fail to receive encoder feedback?
Possible causes include incorrect wiring, an incompatible encoder, a damaged cable, configuration errors, or a problem with the module or connected equipment. Review diagnostic information and check the complete feedback path.
Q8: Does replacing the encoder interface require configuration changes?
Configuration requirements depend on the connected equipment and the installed feedback architecture. Verify the required settings and commissioning procedures before replacing the module.
Q9: Can another encoder interface module be used as an alternative?
Only if its encoder compatibility, electrical characteristics, connector configuration, and system support are confirmed. Similar product descriptions or dimensions are not sufficient.
Q10: What should be done if feedback faults continue after replacement?
Inspect the encoder, cable, connectors, module installation, controller settings, and drive diagnostics. The original problem may originate outside the interface module itself.
13. Conclusion
The Schneider VW3M3401 Encoder Interface Module is an industrial automation component identified for encoder feedback applications, with supplied dimensions of 89 × 41 × 61 mm and a listed weight of 0.057 kg. These specifications provide a starting point for product identification, equipment planning, and spare-parts management.
Reliable operation depends on confirming the module’s precise feedback function, supported encoder types, electrical characteristics, and compatibility with the existing automation system. Correct installation, appropriate configuration, diagnostic review, and preventive maintenance can help reduce feedback-related interruptions.
For replacement planning and system integration, verify the complete model number and all relevant technical requirements before installation. Selecting the correct encoder interface module helps preserve the intended motion-control configuration and supports dependable industrial automation operation.