ProductPRODUCT
Featured products
Contact Us
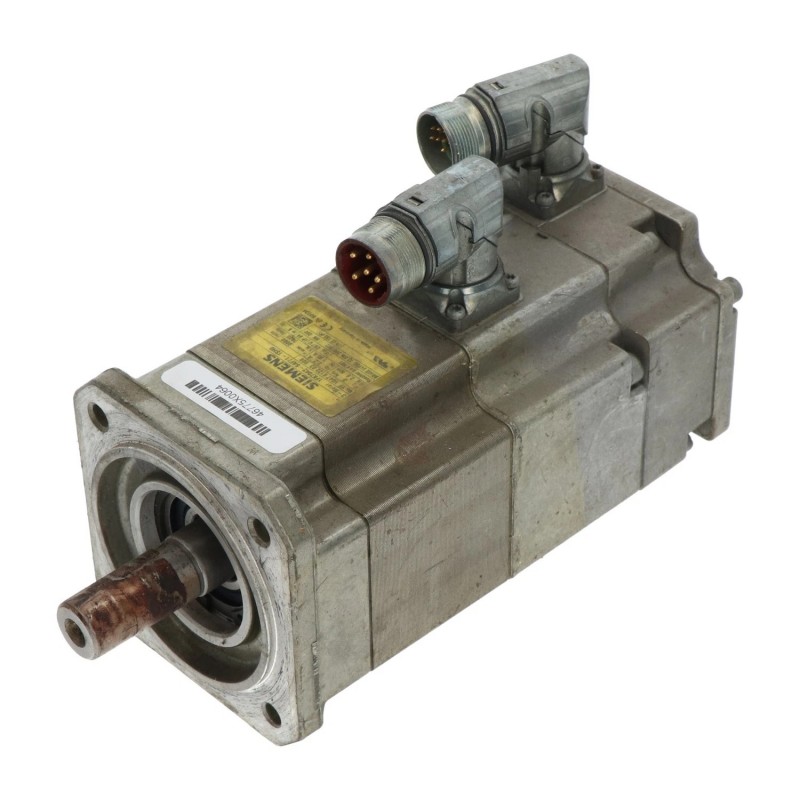
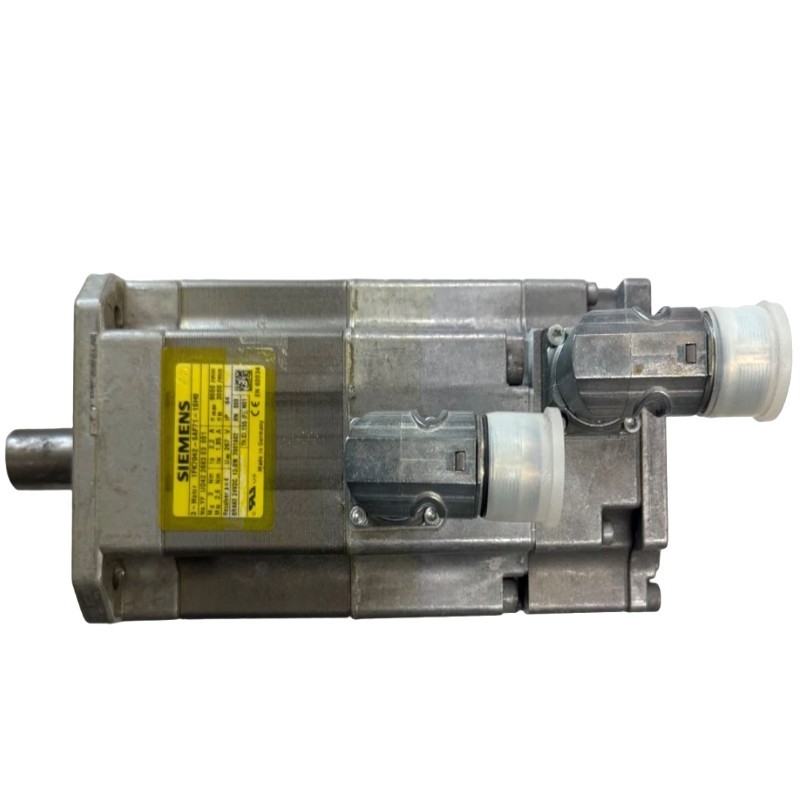
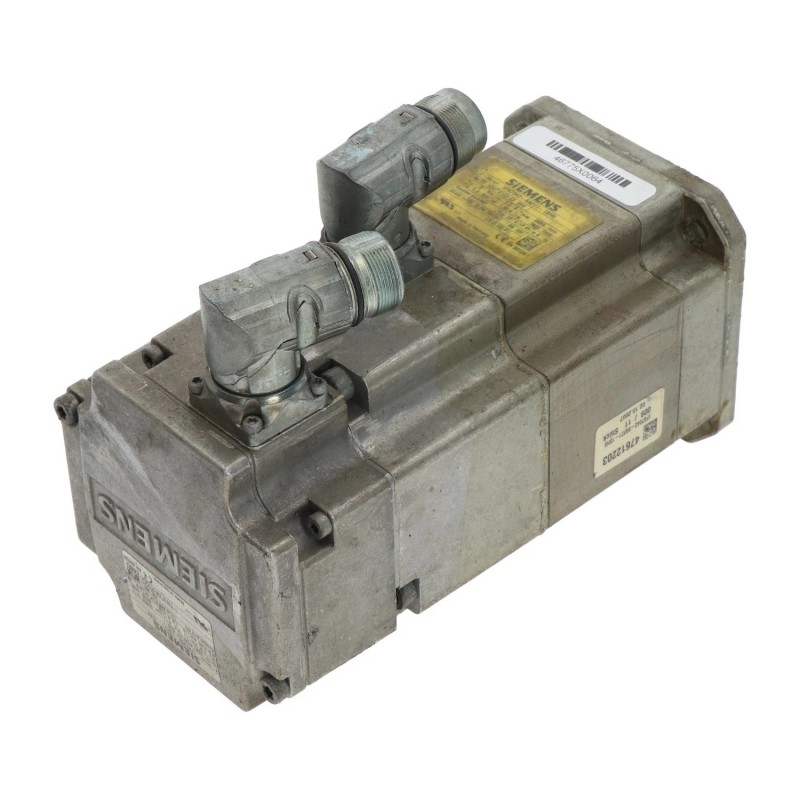
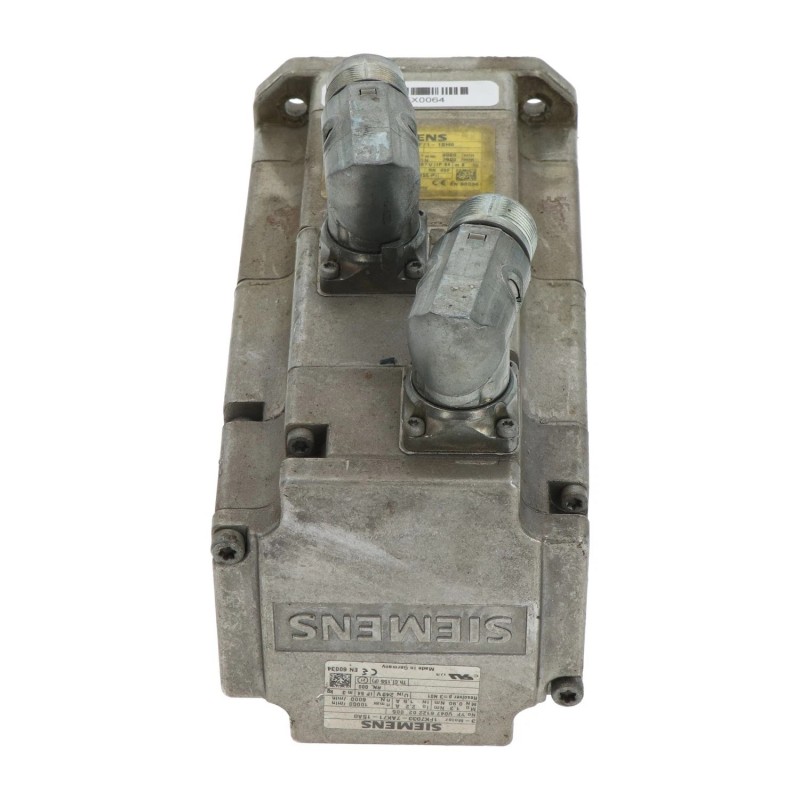
- Siemens
- 1FK7042-5AF71-1SH0
- Synchronous Servo Motor
- Germany
- 48 mm
- 5.502 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 6
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
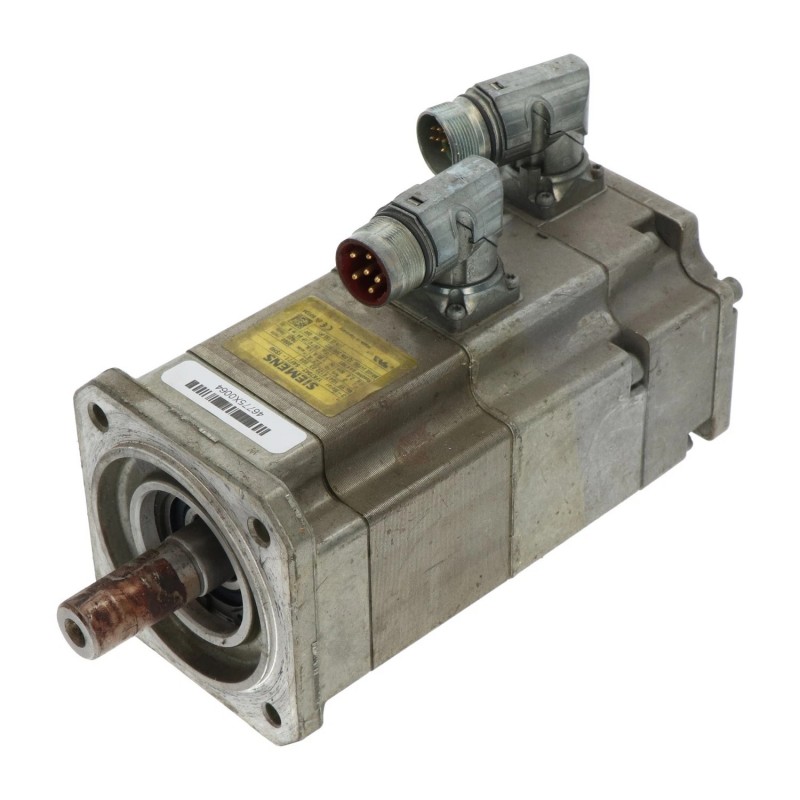
The Siemens 1FK7042-5AF71-1SH0 is a SIMOTICS S-1FK7 compact synchronous servo motor for industrial motion-control applications requiring controlled speed, torque and positioning. It uses permanent-magnet synchronous motor technology and a multi-pole resolver with four pole pairs for rotor-position feedback. The motor has a plain shaft and an integrated permanent-magnet holding brake, making it suitable for servo axes where the mechanical design requires both controlled movement and a means of holding the load when the drive is not actively producing torque.
With a rated power of 0.82 kW, a rated speed of 3,000 rpm and a rated torque of 3.0 Nm, the motor can serve compact machine axes, feed mechanisms and automated positioning equipment. Its naturally cooled construction supports installations where a separate motor fan is not required, while rotatable power and signal connectors help accommodate cable-routing constraints during machine assembly.
The resolver feedback, brake connection and electrical ratings must match the selected servo drive. In particular, the drive configuration must support the resolver interface and the holding-brake control requirements. Correct motor identification and parameter configuration are essential when replacing an existing servo motor or integrating the unit into a new axis.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Siemens |
| Order Number | 1FK7042-5AF71-1SH0 |
| Product Family | SIMOTICS S-1FK7 |
| Product Type | Synchronous Servo Motor |
| Motor Design | Compact permanent-magnet synchronous motor |
| Rated Power | 0.82 kW |
| Rated Speed | 3,000 rpm |
| Rated Torque at 100 K Temperature Rise | 3.0 Nm |
| Static Torque at 100 K Temperature Rise | 3.0 Nm |
| Maximum Mechanical Speed | 9,000 rpm |
| Maximum Inverter Speed | 6,500 rpm |
| Maximum Torque | 10.5 Nm |
| Rated Current | Approximately 1.95 A |
| Cooling Method | Natural cooling |
| Mounting Arrangement | IM B5 (IM V1, IM V3) |
| Feedback System | Multi-pole resolver, 4 pole pairs |
| Shaft Type | Plain shaft, tolerance N |
| Holding Brake | Integrated permanent-magnet holding brake |
| Holding Torque | 4.0 Nm |
| Brake Supply Voltage | 24 V DC ±10% |
| Brake Coil Current | 0.5 A |
| Degree of Protection | IP64 |
| Temperature Monitoring | KTY84 temperature sensor in stator winding |
| Electrical Connections | Rotatable power and signal connectors |
| Shaft Height | 48 mm |
| Weight | 5.502 kg |
Product Features
- Permanent-magnet synchronous motor: Supports controlled torque and speed in servo-driven machinery.
- Integrated holding brake: Provides a means of holding the shaft when the brake is correctly engaged and the application is within its rated requirements.
- Multi-pole resolver feedback: Supplies rotor-position information to a compatible servo drive.
- Compact motor construction: Suits machine axes where space and mechanical integration are important.
- Naturally cooled operation: Uses natural cooling rather than an integrated forced-ventilation system.
- Plain shaft design: Supports compatible coupling and transmission arrangements.
- Rotatable connectors: Allow the power and signal connector orientation to be adjusted for installation needs.
- Winding-temperature monitoring: Uses a KTY84 sensor to provide temperature information for compatible monitoring and protection functions.
- IP64 protection: Helps protect the motor against dust ingress and water splashing under the specified conditions.
- Servo-system integration: Supports closed-loop motion control when paired with a drive configured for its electrical and feedback characteristics.
Working Principle
The 1FK7042-5AF71-1SH0 operates through interaction between the stator’s rotating magnetic field and the rotor’s permanent magnets. A compatible servo drive supplies controlled three-phase current to the motor windings, regulating torque and speed according to commands from the motion controller.
The multi-pole resolver provides rotor-position feedback. The drive uses this information for motor commutation and closed-loop motion regulation, helping the axis follow programmed speed or position commands. Because this model uses resolver feedback, the selected drive and feedback configuration must support the corresponding resolver signals.
The integrated permanent-magnet holding brake serves a different function from the motor’s electromagnetic torque production. When properly controlled, it holds the shaft stationary after the axis has stopped. Brake operation must follow the applicable drive and motor instructions; the brake should not be treated as a routine dynamic stopping device unless the application and specifications explicitly permit it.
The KTY84 temperature sensor monitors the stator winding temperature. Compatible monitoring functions can use this signal to identify excessive thermal loading. Correct drive parameters, brake control, feedback wiring and thermal monitoring help maintain appropriate operating conditions.
Role in a SINAMICS Servo Control Architecture
The 1FK7042-5AF71-1SH0 acts as the rotary actuator in a closed-loop servo axis. The controller generates motion commands, the servo drive regulates motor current, and resolver feedback supports motion control. The integrated brake provides a separate holding function when required by the machine sequence.
| System Component | Function | Relationship to the Motor |
|---|---|---|
| SINAMICS Servo Drive | Regulates motor current, torque and speed | Supplies motor power and processes resolver feedback |
| Motion Controller or PLC | Executes motion commands and machine sequences | Commands the servo drive |
| 1FK7042-5AF71-1SH0 | Converts electrical energy into rotary motion | Drives the connected mechanism |
| Resolver Feedback Cable | Carries rotor-position signals | Connects the resolver to a compatible drive interface |
| Motor Power Cable | Supplies three-phase power | Connects the drive output to the motor |
| Holding-Brake Control Circuit | Controls brake engagement and release | Operates the integrated holding brake according to the system design |
| Mechanical Coupling | Transfers torque to the driven mechanism | Connects the plain shaft to the machine transmission |
| Gearbox, Where Required | Changes speed and output torque | Adapts motor motion to the mechanical load |
| KTY84 Temperature Monitoring Circuit | Monitors stator winding temperature | Supplies temperature information to compatible monitoring equipment |
| HMI Panel | Displays operating status and alarms | Presents information processed by the controller |
Industrial Applications
| Application | Motion Requirement | Role of the Motor |
|---|---|---|
| Machine Tool Feed Axes | Controlled feed movement and repeatable positioning | Drives a compatible feed mechanism under servo control |
| Packaging Machinery | Synchronized motion and repeatable product positioning | Supplies rotary motion for machine sequences |
| Automated Assembly | Controlled movement between programmed positions | Drives positioning mechanisms in assembly stations |
| Pick-and-Place Equipment | Repeatable acceleration, deceleration and positioning | Provides rotary actuation for a suitable machine axis |
| Indexing Systems | Repeated movement followed by a stationary holding period | Combines servo motion with an integrated holding brake |
| Material Handling Machinery | Controlled movement of machine components | Drives mechanisms requiring regulated speed or position |
| Automated Inspection Equipment | Repeatable fixture or component positioning | Supports controlled movement during inspection cycles |
| Compact Production Machines | Servo motion within restricted machine layouts | Provides a compact motor solution with resolver feedback and brake functionality |
Installation and Maintenance
- Verify the complete motor order number: Confirm that 1FK7042-5AF71-1SH0 matches the required resolver, plain-shaft and holding-brake configuration.
- Check servo-drive compatibility: Ensure that the selected drive supports the motor’s electrical ratings and multi-pole resolver feedback.
- Isolate electrical power: Follow the applicable lockout and electrical safety procedures before installation, wiring or maintenance.
- Inspect the mounting interface: Check the flange, fasteners and mounting surface for damage, contamination or alignment problems.
- Confirm shaft coupling compatibility: Select a coupling suitable for the plain shaft and the mechanical load’s torque and alignment requirements.
- Verify motor power wiring: Check phase connections, connector assignments and cable condition against the applicable wiring information.
- Connect the resolver correctly: Confirm that the feedback cable and drive interface match the resolver configuration.
- Check the holding-brake circuit: Verify brake supply, control wiring and release sequence before allowing the axis to move.
- Configure motor parameters: Enter the correct motor data and feedback settings in the drive configuration.
- Set motion and torque limits: Configure speed, current, torque and acceleration limits for the connected mechanism and application.
- Test the axis under controlled conditions: Check rotation direction, feedback behavior, brake release and engagement, and drive diagnostics before normal operation.
- Monitor operating conditions: Investigate abnormal noise, vibration, temperature changes or brake-related alarms and document maintenance findings.
Related Components
| Component | Function | Relationship to the Motor |
|---|---|---|
| Siemens SINAMICS Servo Drive | Supplies controlled motor power | Must support the motor’s ratings and resolver feedback |
| Siemens SIMOTION Motion Controller | Executes coordinated motion tasks | Can command a compatible servo axis |
| SIMATIC S7-1500T CPU | Provides technology and motion-control functions | Can coordinate suitable drive applications |
| Motor Power Cable | Transfers electrical power from the drive | Connects the servo drive to the motor |
| Resolver Feedback Cable | Carries rotor-position signals | Supports closed-loop servo operation |
| Holding-Brake Control Circuit | Controls brake engagement and release | Operates the motor’s integrated holding brake |
| Mechanical Shaft Coupling | Transfers motor torque to the machine | Connects the plain shaft to the driven mechanism |
| Precision Gearbox | Adapts speed and torque | Used where the application requires a transmission ratio |
| Machine HMI | Displays operating values and alarms | Supports operator supervision |
| Electrical Protection Devices | Provide circuit protection and isolation | Form part of the overall servo-axis electrical design |
Recommended Related Models
| Model | Product Type | Relationship | Selection Consideration |
|---|---|---|---|
| Siemens 1FK7042-5AF71-1SH0 | SIMOTICS S-1FK7 Synchronous Servo Motor | Main product | Multi-pole resolver, plain shaft and integrated holding brake |
| Siemens 1FK7042-5AF71-1SG0 | SIMOTICS S-1FK7 Synchronous Servo Motor | Related resolver-feedback version | Has a similar motor configuration but without the integrated holding brake |
| Siemens 1FK7042-5AF71-1SA0 | SIMOTICS S-1FK7 Synchronous Servo Motor | Related resolver-feedback version | Uses a shaft with fitted key and no holding brake; verify mechanical interface requirements |
| Siemens 1FK7042-5AF71-1SB0 | SIMOTICS S-1FK7 Synchronous Servo Motor | Related resolver-feedback version | Uses a shaft with fitted key and an integrated holding brake |
| Siemens 1FK7042-5AF71-1FH0 | SIMOTICS S-1FK7 Synchronous Servo Motor | Related encoder-feedback version | Uses an absolute encoder with DRIVE-CLiQ; not a direct feedback-interface substitute |
| Siemens 1FK7042-5AF71-1SH2 | SIMOTICS S-1FK7 Synchronous Servo Motor | Related order-code variant | Verify the complete configuration and electrical interfaces before substitution |
Key Advantages
- Combines servo motion control with an integrated holding brake.
- Uses multi-pole resolver feedback for compatible closed-loop drive systems.
- Supports compact positioning and feed applications.
- Includes winding-temperature monitoring through a KTY84 sensor.
- Offers naturally cooled operation and rotatable power and signal connectors.
Technical FAQs
What is the main difference between the 1FK7042-5AF71-1SH0 and 1FK7042-5AF71-1SG0?
Both are SIMOTICS S-1FK7 compact synchronous servo motors with resolver feedback and a plain shaft. The 1SH0 version includes an integrated permanent-magnet holding brake, whereas the 1SG0 version does not. This difference matters when the machine must hold its axis after motion stops.
Does the integrated holding brake control the motor’s normal running speed?
No. The servo drive controls running speed and torque through motor current. The holding brake is intended to hold the shaft stationary when engaged and should be operated according to the motor and drive instructions, not used as a routine substitute for servo braking.
Which feedback interface is required for this motor?
The motor uses a multi-pole resolver with four pole pairs. The selected servo drive must support the corresponding resolver interface and configuration. A DRIVE-CLiQ encoder interface should not be assumed to be compatible with this resolver version.
What should be checked if the motor moves correctly but the brake does not hold the axis?
Check the brake supply and control wiring, the brake release and engagement sequence, and the mechanical load applied to the axis. Also verify that the holding torque is appropriate for the application and that the brake is not being used beyond its specified operating limits.