ProductPRODUCT
Featured products
Contact Us
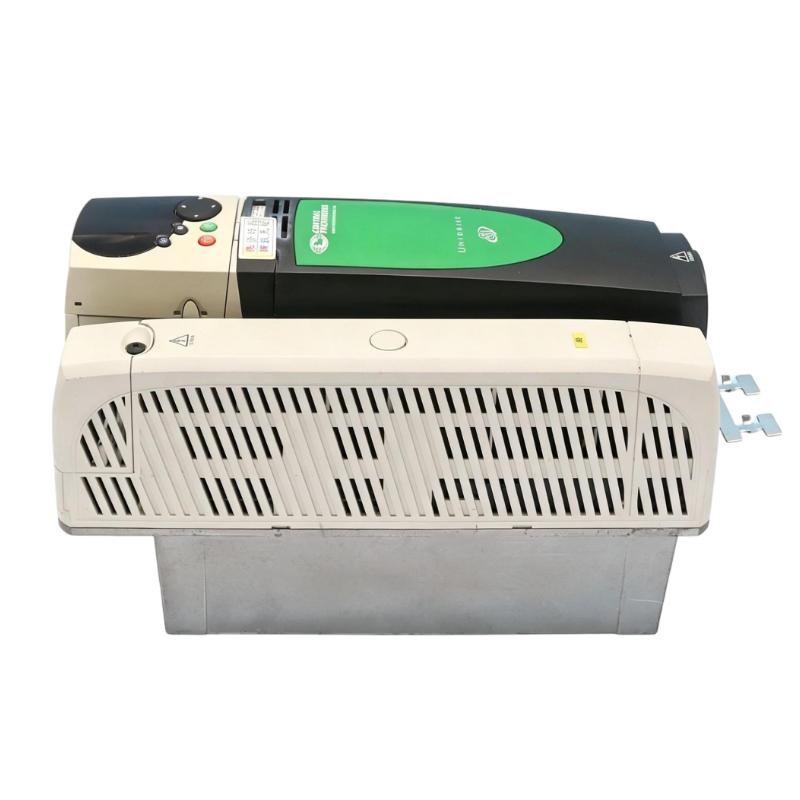
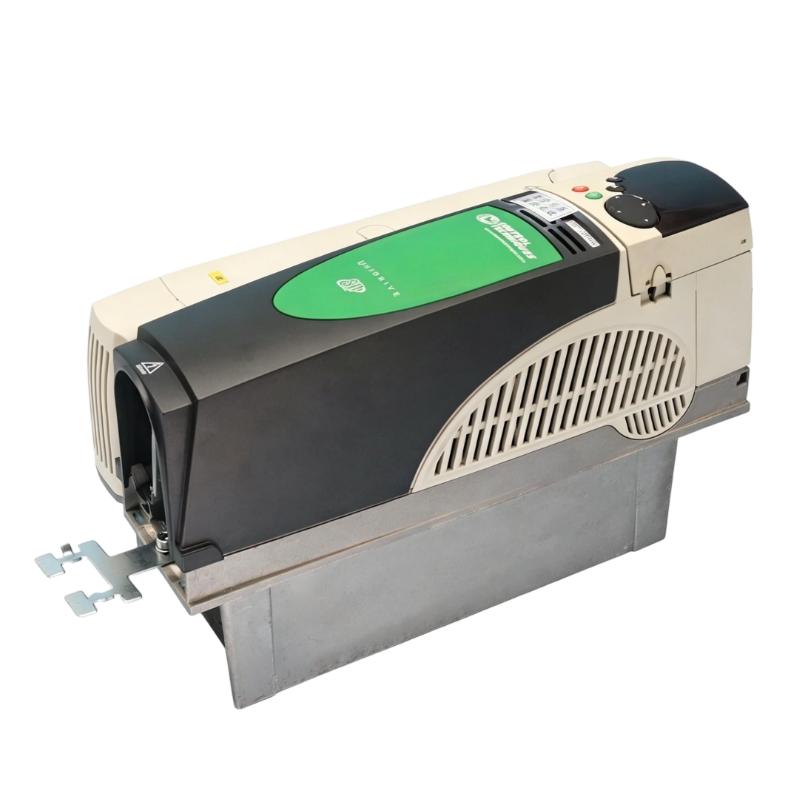
- Emerson
- SP2402
- AC Drive
- USA
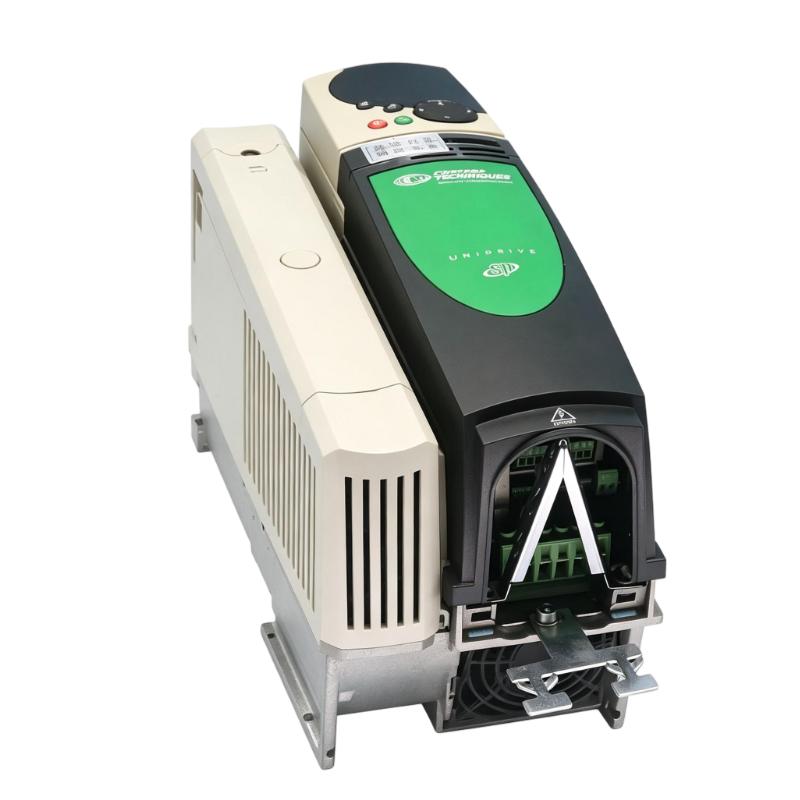
- 368 × 155 × 219 mm
- 2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 7
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
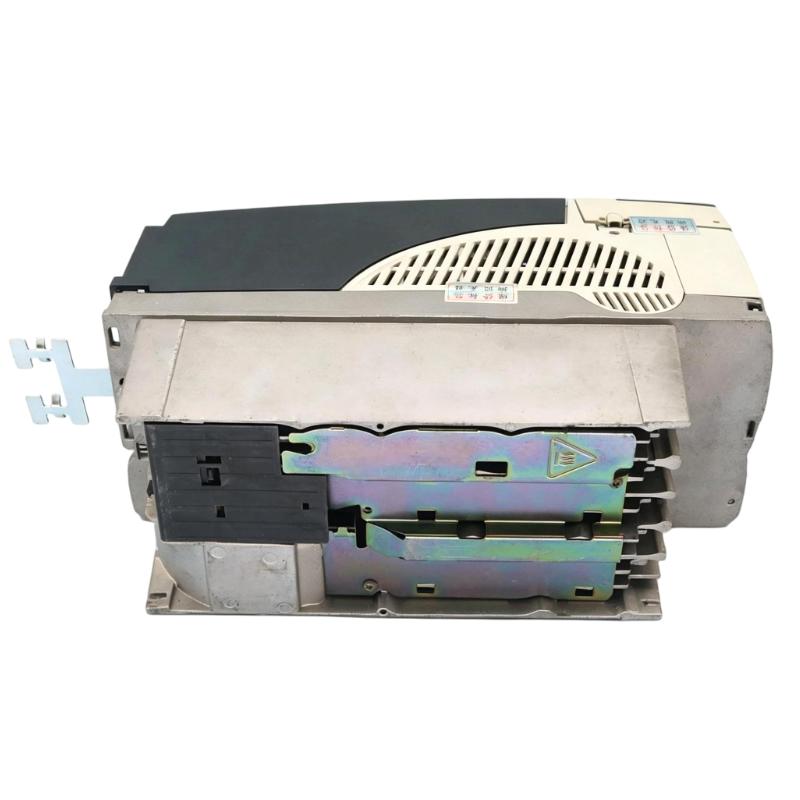
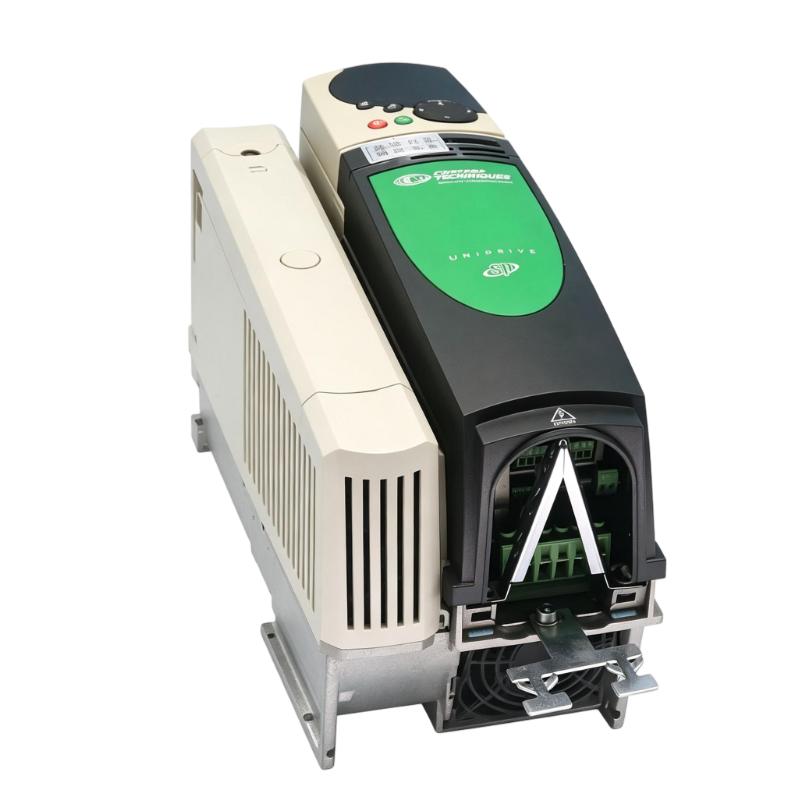
The Emerson SP2402 Unidrive SP Series AC Drive is a universal variable-speed drive for industrial motor systems requiring adjustable speed, torque control and configurable motor response. Its Size 2 platform serves applications that need greater output current than the SP1400 series, including machinery with heavier operating loads or more demanding acceleration and deceleration cycles.
For the 380–480 V three-phase model, the SP2402 has a continuous output-current rating of 16.5 A in Heavy Duty operation and 21 A in Normal Duty operation. It can be configured for supported induction motor and servo applications, with the operating mode selected according to the motor, control requirements and load characteristics.
In an automated production system, the SP2402 regulates motor output based on programmed motor data and incoming commands. Its control interfaces support integration with machine controllers, while optional modules can extend communications or feedback functions. This makes configuration, fault monitoring and appropriate duty selection central to commissioning the drive for a specific machine.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Emerson / Control Techniques |
| Model | SP2402 |
| Product Series | Unidrive SP |
| Product Type | Universal AC and Servo Drive |
| Frame Size | Size 2 |
| Input Supply | Three-phase AC |
| Input Voltage | 380–480 V AC |
| Input Frequency | 48–65 Hz |
| Heavy Duty Continuous Output Current | 16.5 A |
| Normal Duty Continuous Output Current | 21 A |
| Typical Motor Power at 400 V, Heavy Duty | 7.5 kW |
| Typical Motor Power at 400 V, Normal Duty | 11 kW |
| Typical Motor Power at 460 V, Heavy Duty | 10 hp |
| Typical Motor Power at 460 V, Normal Duty | 15 hp |
| Motor Control | Configurable control modes for supported motor applications |
| Analog Inputs | 3 |
| Analog Outputs | 2 |
| Digital Inputs | 6 |
| Digital Outputs | 3 |
| Onboard Communication | Modbus RTU |
| Feedback Support | Via compatible feedback options, depending on configuration |
| Enclosure Protection | IP20; other enclosure arrangements depend on installation configuration |
| Dimensions | 368 × 155 × 219 mm |
| Weight | 2 kg |
Product Features
- Higher output-current capacity: Provides 16.5 A Heavy Duty and 21 A Normal Duty continuous output-current ratings for appropriately matched motor applications.
- Universal motor-control platform: Supports different control modes for compatible induction motor and servo applications.
- Configurable speed and torque response: Allows motor behavior to be adjusted to the machine’s operating requirements.
- Integrated control interfaces: Provides digital and analog I/O for supported references, commands and monitoring signals.
- Serial communication: Supports Modbus RTU for data exchange with compatible automation equipment.
- Feedback expansion: Compatible feedback options can support applications requiring additional motor feedback.
- Programmable ramp settings: Acceleration and deceleration parameters can be adapted to the load and process cycle.
- Diagnostic information: Drive status and fault indications assist commissioning and troubleshooting.
- Industrial automation integration: Can be coordinated with PLC logic, machine interlocks and supervisory monitoring through supported interfaces.
Working Principle
The SP2402 converts incoming three-phase AC power into a controlled output for the connected motor. Its power electronics regulate motor operation according to the selected control mode, configured motor data and active speed or torque reference. The chosen mode determines how the drive responds to load changes and operating commands.
The drive’s continuous output-current ratings are 16.5 A for Heavy Duty and 21 A for Normal Duty. These values apply to different duty conditions, so the selected rating must suit the motor current and load profile. Frequent overloads, high starting demand or prolonged operation at elevated current require particular attention during drive selection.
During operation, the drive processes reference signals and control commands to regulate the motor. Acceleration and deceleration settings determine how quickly the motor changes speed. For high-inertia equipment or applications involving frequent stopping, the braking method and regenerated energy must also be considered as part of the system design.
When a fault occurs, the drive reports a corresponding diagnostic condition. Troubleshooting should start by recording the fault and identifying the operating conditions at the time. Supply voltage, motor wiring, control signals, mechanical load and parameter configuration can then be checked systematically.
Role in an Industrial Motor Control Architecture
The SP2402 operates between the incoming power supply and the motor, while exchanging commands and status information with the machine’s control system. It performs the configured motor-control function and enables the wider automation system to coordinate motion, monitor operating conditions and respond to drive faults.
| System Component | Function | Relationship to the Drive |
|---|---|---|
| Three-Phase AC Supply | Supplies input power | Feeds the drive through appropriately rated isolation and protective devices |
| AC Induction Motor | Converts electrical power into mechanical motion | Receives the drive’s controlled output |
| Compatible Servo Motor | Provides controlled motion in supported applications | Requires a suitable control mode and compatible configuration |
| PLC or Machine Controller | Coordinates machine sequencing | Sends supported run commands, references and enable signals |
| Operator Interface | Provides setpoints and operating commands | Exchanges commands or status through the configured control system |
| Analog Reference Source | Supplies a variable speed or process reference | Connects to a configured compatible analog input |
| Modbus RTU Master | Exchanges supported drive data | Communicates through the drive’s serial interface |
| Feedback Device | Supplies speed or position information where required | Requires a compatible feedback interface and supported control mode |
| Braking Arrangement | Manages regenerated energy during applicable stopping cycles | Must be selected according to the load and drive configuration |
Industrial Applications
| Application | Operating Requirement | Role of the SP2402 |
|---|---|---|
| Industrial Conveyor Systems | Coordinate speed with material flow and production timing | Regulates motor speed through configured references and operating limits |
| Pumping and Fluid Handling | Adjust motor operation to process demand | Supports variable-speed control when the motor and pump are appropriately matched |
| Fans and Blowers | Adjust airflow by changing motor speed | Applies the requested speed reference to the connected motor |
| Material Processing Machinery | Maintain motor response under changing process loads | Executes configured motor-control parameters and limits |
| Packaging Equipment | Coordinate motor operation with production cycles | Applies programmed speed, acceleration and deceleration settings |
| Winding Machinery | Manage motor speed or torque according to line conditions | Supports suitable configured control strategies |
| General Industrial Machinery | Integrate motor operation with automation logic | Processes commands and returns supported status and diagnostic information |
Installation and Maintenance
- Verify the model designation: Confirm that the installed unit is an SP2402 and that its electrical ratings suit the intended motor and application.
- Check the incoming supply: Verify the three-phase voltage and frequency against the drive’s rating information before connecting power.
- Inspect the unit and terminals: Check accessible terminals, connectors and the enclosure for damage, contamination or signs of overheating.
- Provide adequate ventilation: Follow the required mounting clearances and cooling instructions to manage heat within the control panel.
- Verify protective grounding: Ensure protective-earth connections comply with the electrical design and applicable installation requirements.
- Match the duty rating: Compare motor rated current and overload requirements with the 16.5 A Heavy Duty and 21 A Normal Duty ratings.
- Inspect motor wiring: Verify conductor sizing, terminal tightness, insulation and cable routing before energizing the drive.
- Review control connections: Check run commands, stop signals, reference inputs and machine interlocks against the electrical drawings.
- Configure motor parameters: Enter the required motor data and confirm that the selected control mode suits the motor and load.
- Assess stopping requirements: Review acceleration and deceleration settings, and evaluate the braking arrangement for high-inertia or frequent-stop applications.
- Test control and communications: Verify reference tracking, command response, Modbus RTU communication and any installed feedback options before production use.
- Document commissioning results: Record the duty selection, motor data, parameter settings, installed option modules, fault history and functional test results.
Compatible System Components
| Component | Function | Compatibility Consideration |
|---|---|---|
| Compatible AC Induction Motor | Produces mechanical output | Verify voltage, rated current and control requirements against the drive |
| Supported Servo Motor | Provides controlled motion in suitable applications | Confirm the required control configuration and motor compatibility |
| PLC or Machine Controller | Coordinates machine logic | Confirm supported command signals and interface arrangements |
| Analog Reference Source | Supplies a speed or process reference | Match signal type and scaling to the configured input |
| Feedback Device | Provides speed or position information | Requires a compatible feedback option and supported device |
| Modbus RTU Master | Exchanges supported drive information | Configure serial parameters and supported data mapping |
| Communication Option Module | Adds a supported network interface | Verify the exact module and protocol compatibility |
| Braking Components | Support applicable deceleration requirements | Select according to the load and drive configuration |
| Upstream Protective Device | Protects the input supply circuit | Select according to the electrical installation design |
Recommended Related Models
| Model | Product Type | Relationship | Selection Consideration |
|---|---|---|---|
| Emerson SP1406 | Unidrive SP AC Drive | Smaller-frame model with lower current capacity | Compare its 9.5 A Heavy Duty and 11 A Normal Duty ratings with the application |
| Emerson SP2401 | Unidrive SP AC Drive | Lower-current model in the same frame group | Compare its 13 A Heavy Duty and 15.3 A Normal Duty ratings with motor demand |
| Emerson SP2403 | Unidrive SP AC Drive | Higher-current model in the same frame group | Evaluate if the SP2402’s applicable rating is insufficient |
| Emerson SP3401 | Unidrive SP AC Drive | Related model from a larger frame group | Check current requirements, installation conditions and enclosure design before selection |
Key Advantages
- Provides 16.5 A Heavy Duty and 21 A Normal Duty continuous output-current ratings.
- Supports configurable motor control for compatible induction and servo applications.
- Offers adjustable speed and torque response for different machine requirements.
- Includes integrated control I/O and Modbus RTU communication.
- Supports compatible feedback and communication expansion.
- Supplies diagnostic information for commissioning and fault investigation.
Technical FAQs
What should be reviewed when the SP2402 cannot maintain speed as the mechanical load increases?
Check the active current or torque limits, selected control mode, motor parameters and load profile. Confirm that the motor and drive are correctly sized for the required operating point, then review any active fault or limiting status before adjusting control parameters.
How can the SP2402 be commissioned for an application that needs precise low-speed operation?
Select a control mode suitable for the motor and required performance, enter accurate motor nameplate data, and configure any required feedback interface. Test operation at low speed under controlled conditions and adjust parameters only after confirming that wiring and feedback signals are correct.
What can cause repeated overvoltage trips when the SP2402 stops a high-inertia load?
During deceleration, the motor can return energy to the drive’s DC bus. If the stopping ramp or braking arrangement cannot handle that energy, an overvoltage trip may occur. Review deceleration time, stopping frequency and the required braking configuration for the actual load.
What should be checked when the SP2402 responds to local commands but not to a PLC command?
Verify the active command source, enable conditions, digital input assignments and any communication-control selection. If Modbus RTU is being used, also check the serial settings, command mapping and communication status to identify whether the issue lies in the control logic or the drive configuration.