ProductPRODUCT
Featured products
Contact Us
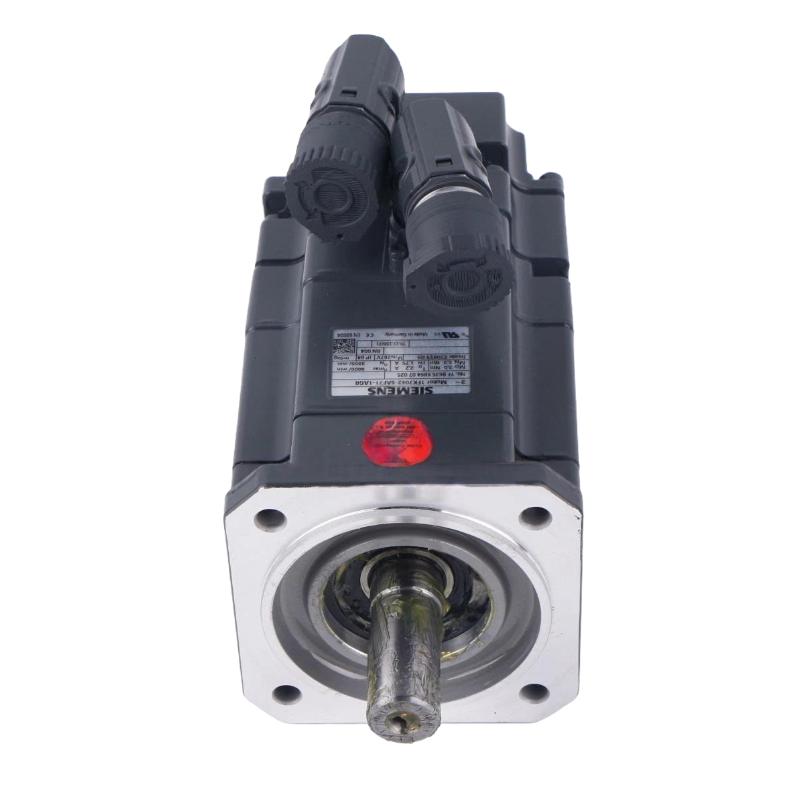
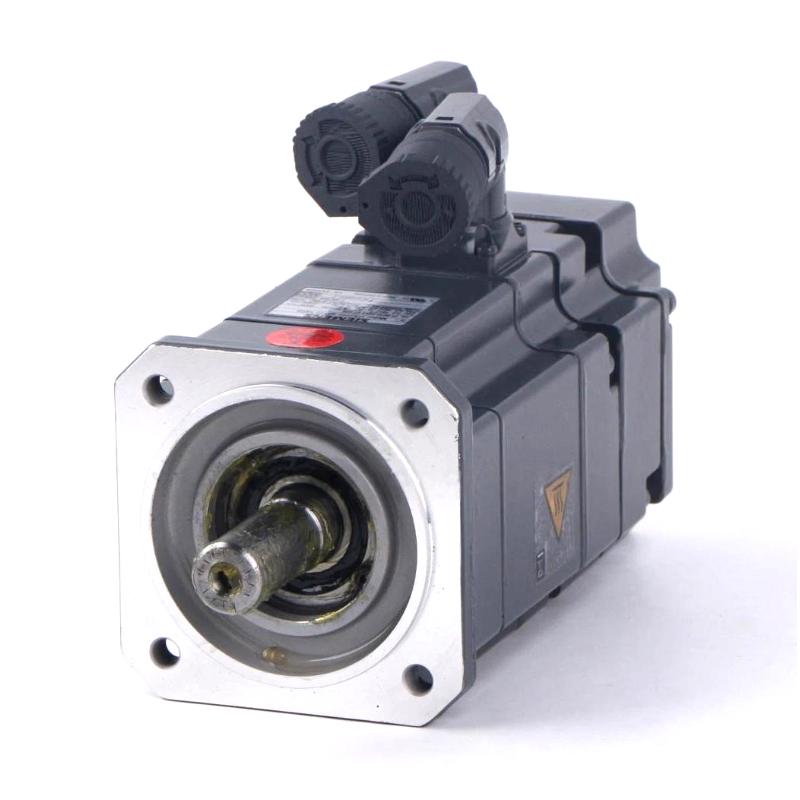
- Siemens
- 1FK7042-5AF71-1AG0
- Synchronous Servo Motor
- Germany
- 48 mm
- 4.903 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 6
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
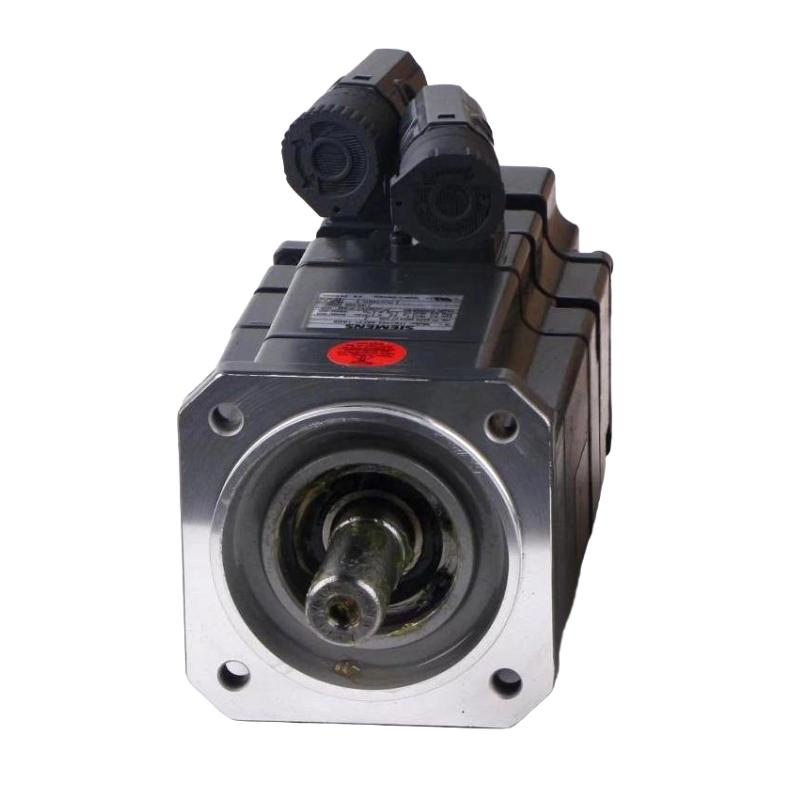
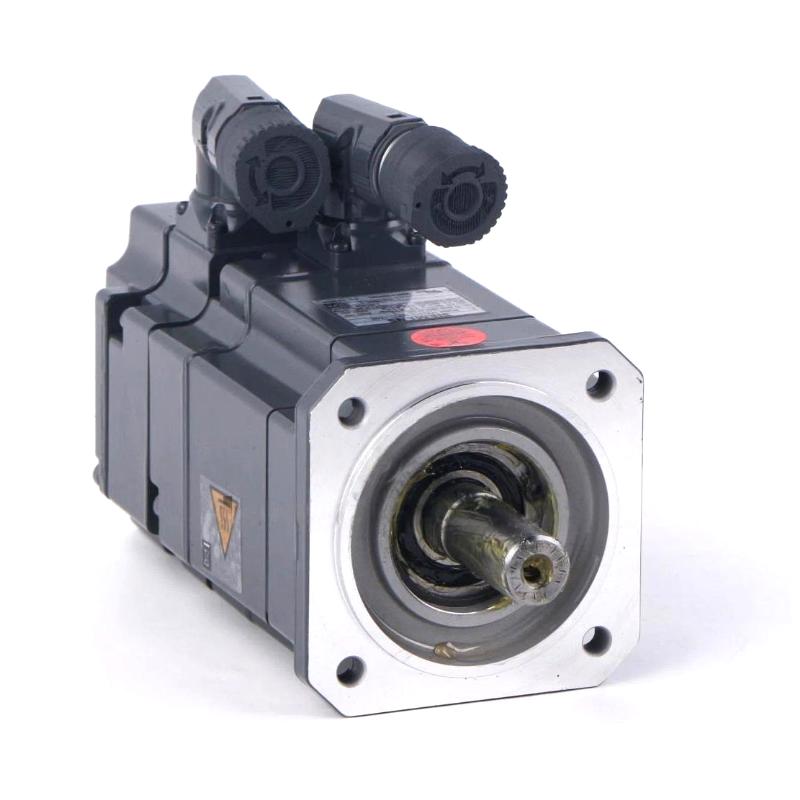
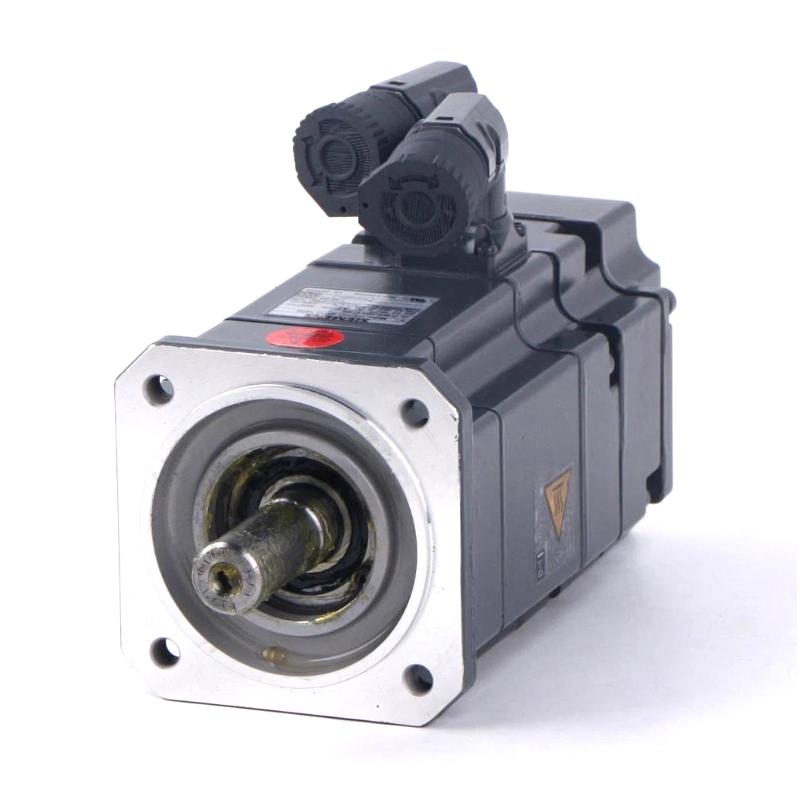
The Siemens 1FK7042-5AF71-1AG0 SIMOTICS S Synchronous Servo Motor is a compact permanent-magnet synchronous servo motor in the SIMOTICS S-1FK7 family. It has a rated power of 0.82 kW, a rated speed of 3,000 rpm and a rated torque of 3 Nm at a 100 K temperature rise. Its natural-cooling configuration and IM B5 mounting arrangement suit machine axes that require controlled rotary motion without a separate motor-cooling circuit.
This version uses an incremental encoder with 2,048 pulses per revolution and has a plain shaft without an integrated holding brake. The encoder supplies incremental feedback to a compatible servo drive for speed regulation and position control. Because the feedback is incremental, applications requiring a known machine reference after startup may need a homing or referencing procedure.
The motor’s power and signal connectors can be rotated through 270°, offering some flexibility when routing cables within a machine. Its IP64 protection rating should be considered when determining the installation environment and the protection required for the complete motor-and-cable assembly.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Siemens |
| Model / Order Number | 1FK7042-5AF71-1AG0 |
| Product Family | SIMOTICS S-1FK7 |
| Product Type | Synchronous Servo Motor |
| Motor Design | Compact permanent-magnet synchronous motor |
| Rated Power | 0.82 kW |
| Rated Speed | 3,000 rpm |
| Rated Torque (100 K) | 3 Nm |
| Static Torque (100 K) | 3.0 Nm |
| Cooling Method | Natural cooling |
| Mounting Design | IM B5 (IM V1, IM V3) |
| Shaft Design | Plain shaft |
| Shaft Tolerance | N |
| Encoder Type | Incremental encoder |
| Encoder Signal | Sin/cos, 1 Vpp |
| Encoder Resolution | 2,048 pulses per revolution |
| Holding Brake | Without integrated holding brake |
| Degree of Protection | IP64 |
| Connector Arrangement | Power and signal connectors rotatable by 270° |
| Shaft Height | 48 mm |
| Weight | 4.903 kg |
Product Features
- Permanent-magnet synchronous motor: Supports controlled torque and speed when operated with a compatible servo drive.
- Incremental encoder feedback: Supplies rotor-motion information for closed-loop speed and position regulation.
- 2,048-pulse resolution: Provides incremental feedback for motion-control tasks requiring repeatable movement.
- Plain shaft: Supports compatible couplings and transmission arrangements that match the shaft interface.
- Natural cooling: Uses the specified motor cooling arrangement without requiring a separate motor-cooling circuit.
- No integrated holding brake: Suits applications where a motor-mounted brake is unnecessary or load holding is handled separately.
- Rotatable connectors: Allows the power and signal connector orientation to be adjusted through 270° for installation flexibility.
- IP64 protection: Provides protection against dust ingress and water splashes under the specified enclosure test conditions.
Working Principle
The 1FK7042-5AF71-1AG0 converts electrical energy into mechanical rotation through the interaction between the stator’s magnetic field and the rotor’s permanent magnets. A compatible servo drive regulates current in the stator windings to generate the torque required by the machine.
As the shaft rotates, the incremental sin/cos encoder produces feedback signals. The drive processes these signals to determine changes in rotor position and rotational speed, then adjusts motor current according to the motion command. This closed-loop process supports speed regulation and controlled positioning within the capabilities of the drive and the overall control system.
An incremental encoder does not independently retain an absolute machine position after power loss. Where the machine requires a known reference position, the control system may need to perform a homing procedure using the configured reference method.
This motor version has no integrated holding brake. If the driven mechanism must remain stationary when the motor is de-energized, the machine design must provide an appropriate external load-holding arrangement where required.
Role in a SIMOTICS S Servo Control Architecture
The 1FK7042-5AF71-1AG0 serves as the rotary actuator in a closed-loop servo system. The controller issues motion commands, the servo drive regulates motor current, and the incremental encoder returns feedback used to control the axis response.
| System Component | Function | Relationship to the Motor |
|---|---|---|
| SIMOTICS S-1FK7 Motor | Converts electrical energy into rotary motion | Executes the commanded movement |
| Compatible Siemens Servo Drive | Regulates motor current, speed and torque | Powers the motor and evaluates encoder feedback |
| Incremental Encoder | Generates sin/cos feedback signals | Supplies position-change and speed information |
| Encoder Signal Cable | Carries feedback signals to the drive | Connects the encoder to compatible feedback inputs |
| Motor Power Cable | Supplies electrical power | Connects the motor to the drive output |
| Motion Controller / PLC | Executes motion sequences and machine logic | Sends axis commands to the drive |
| Mechanical Coupling | Transfers torque to the driven mechanism | Connects the plain motor shaft to the machine transmission |
| External Holding Mechanism, Where Required | Helps prevent unwanted movement when the motor is not producing torque | Addresses load-holding requirements not covered by an integrated motor brake |
Industrial Applications
| Application | Motion-Control Task | Role of the Motor |
|---|---|---|
| Automated Production Machinery | Controlling rotary axes and machine mechanisms | Supplies servo torque with incremental feedback |
| Packaging Equipment | Regulating movement during product handling | Supports speed control and repeatable motion |
| Assembly Automation | Moving mechanisms through programmed sequences | Provides controlled rotary actuation |
| Machine-Building Applications | Operating servo-driven mechanisms | Supports appropriately sized motion axes |
| Material Handling Equipment | Driving transfer or positioning mechanisms | Provides closed-loop motion when its ratings suit the application |
| Special-Purpose Machinery | Executing programmed rotary movements | Combines incremental feedback with a plain-shaft connection |
Installation and Maintenance
- Verify the motor reference: Confirm that 1FK7042-5AF71-1AG0 matches the required power, encoder, shaft and brake configuration.
- Check mechanical mounting: Ensure that the machine interface matches the specified IM B5 mounting arrangement or an approved IM V1 or IM V3 position.
- Confirm drive compatibility: Select a compatible servo drive and verify that it supports the motor’s electrical ratings and incremental encoder signals.
- Isolate the equipment: Follow the applicable electrical lockout procedure and secure the driven mechanism before installation or maintenance.
- Inspect power connections: Check the motor power connector and cable for damage, contamination or loose connections.
- Verify encoder wiring: Confirm that the sin/cos 1 Vpp feedback signals are connected to compatible drive inputs using the correct cable arrangement.
- Configure encoder parameters: Set the encoder type and resolution correctly in the drive and motion-control configuration.
- Establish the reference position: Configure a suitable homing or referencing procedure if the application requires a known machine position after startup.
- Inspect the shaft and coupling: Check the plain shaft and mating coupling for damage, misalignment or excessive mechanical play.
- Check the operating environment: Ensure that installation conditions comply with the motor’s specified protection and operating requirements.
- Perform a controlled commissioning test: Verify rotation direction, encoder response, speed regulation and positioning behavior before normal operation.
- Record maintenance findings: Document the motor reference, drive parameters, encoder configuration and any abnormal noise, vibration or temperature observations.
Compatible System Components
| Component | Function | Compatibility Consideration |
|---|---|---|
| Compatible Siemens Servo Drive | Supplies regulated power and performs motor control | Must support the motor’s electrical ratings and incremental encoder signals |
| Motor Power Cable | Carries power from the drive to the motor | Match the cable and connector specification to the motor |
| Encoder Signal Cable | Transfers incremental feedback signals | Confirm compatibility with the sin/cos 1 Vpp encoder interface |
| Motion Controller / PLC | Generates motion commands and sequences | Configure for the selected drive and feedback arrangement |
| Mechanical Coupling | Transfers torque to the machine mechanism | Match the coupling to the plain shaft and mechanical load |
| External Holding Brake or Locking Mechanism, Where Required | Provides load holding when the application requires it | Select according to load characteristics and machine safety requirements |
| Machine Reference Sensor, Where Required | Establishes a known reference position | Select according to the homing strategy and controller configuration |
Recommended Related Models
| Model | Product Type | Relationship | Selection Consideration |
|---|---|---|---|
| Siemens 1FK7042-5AF71-1AA0 | SIMOTICS S Synchronous Servo Motor | Related 1FK7 Compact motor with a keyed shaft and incremental encoder configuration | Compare shaft design and the complete encoder specification |
| Siemens 1FK7042-5AF71-1FA0 | SIMOTICS S Synchronous Servo Motor | Related motor configuration with an absolute encoder and no integrated holding brake | Consider when absolute encoder feedback is required |
| Siemens 1FK7042-5AF71-1AH0 | SIMOTICS S Synchronous Servo Motor | Related motor configuration with incremental feedback and an integrated holding brake | Compare shaft design, brake requirement and protection rating |
| Siemens SINAMICS S120 | Servo Drive System | Drive family used in compatible Siemens servo architectures | Verify electrical sizing and support for the motor’s incremental encoder interface |
Key Advantages
- Provides 0.82 kW of rated power for appropriately sized servo applications.
- Supports closed-loop speed and position regulation through incremental encoder feedback.
- Uses natural cooling and a plain-shaft configuration.
- Allows connector orientation adjustment through 270°.
- Supports IM B5, IM V1 and IM V3 mounting arrangements.
- Suits applications where an integrated holding brake is not required.
Technical FAQs
What encoder is used in the Siemens 1FK7042-5AF71-1AG0?
The motor uses an incremental sin/cos encoder with a 1 Vpp signal and a resolution of 2,048 pulses per revolution. The connected drive must support this feedback interface and be configured correctly.
Does the 1FK7042-5AF71-1AG0 include a holding brake?
No. This model is specified without an integrated holding brake. If the machine must hold a load while the motor is stationary or de-energized, a separate holding arrangement may be required.
Is a homing procedure necessary when using this motor?
A homing or referencing procedure is generally needed when the machine requires a known absolute axis position after startup. The exact method depends on the controller, machine reference arrangement and application.
What should be checked if the drive cannot read the encoder correctly?
Check the encoder cable and connectors, compatibility of the sin/cos 1 Vpp signals, encoder configuration and resolution settings. Verify the motor reference and drive parameters before replacing components.