ProductPRODUCT
Featured products
Contact Us
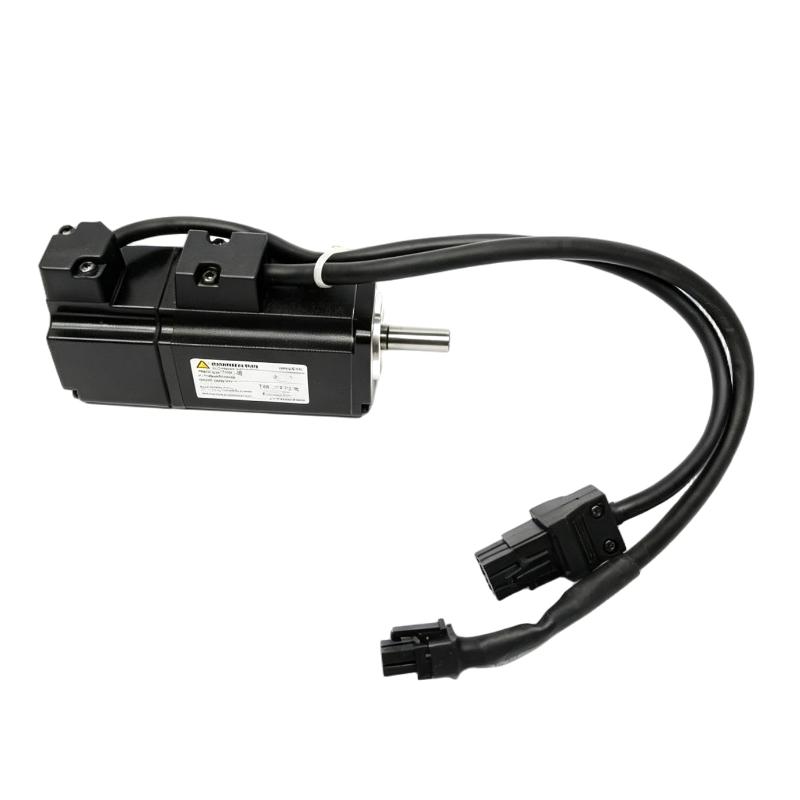
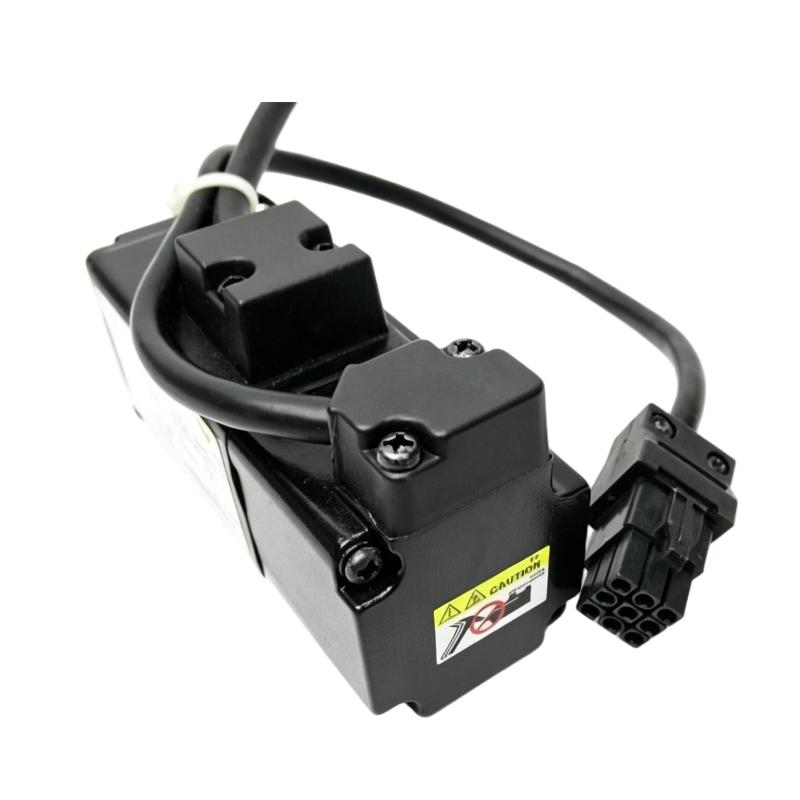
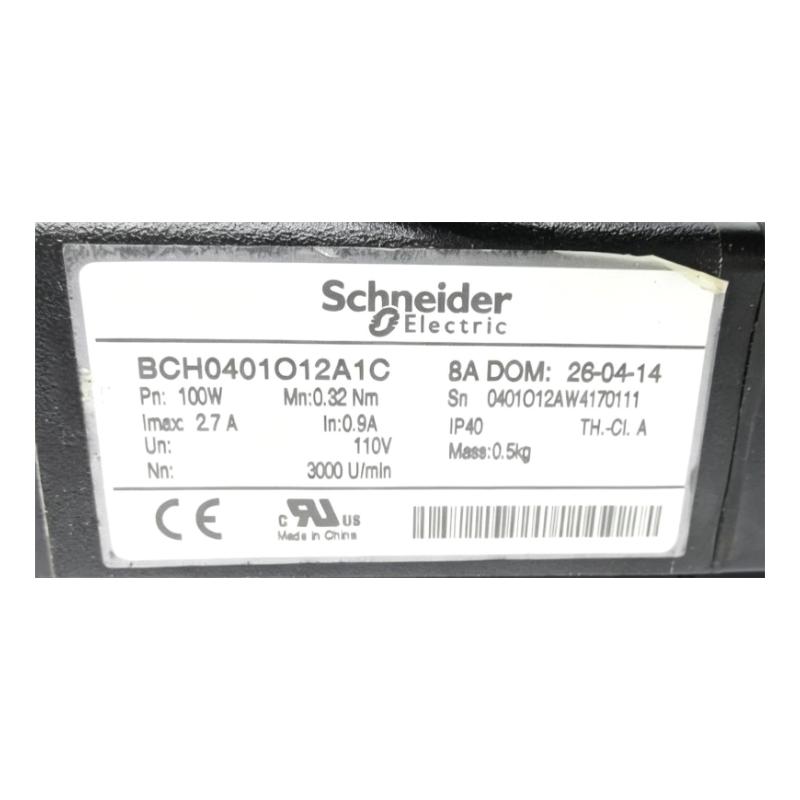
- Schneider
- BCH0401O12A1C
- Servo Motor
- France
- 100.6 mm
- 0.5 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 6
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
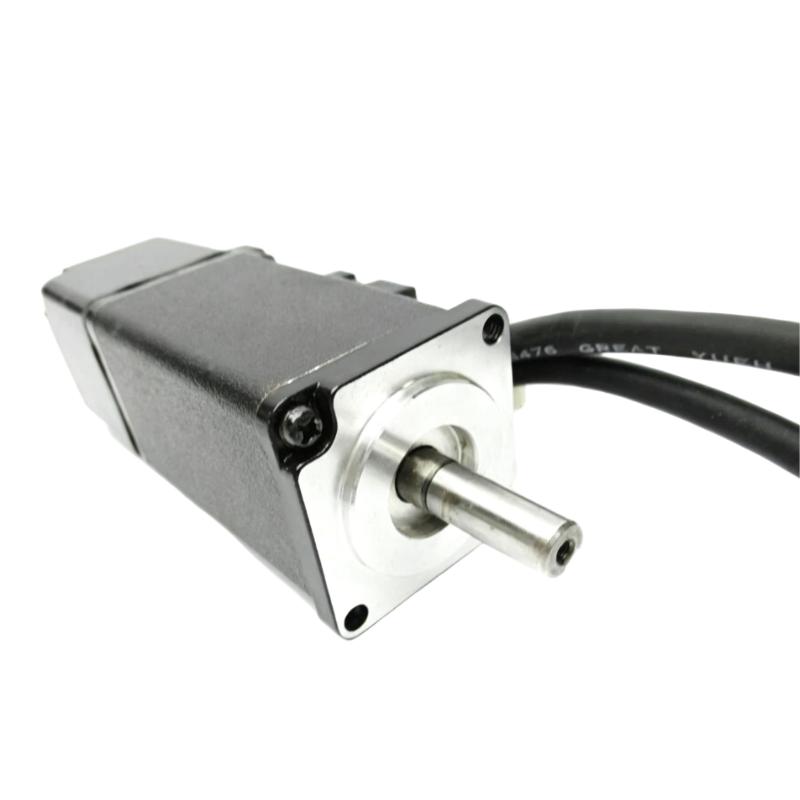
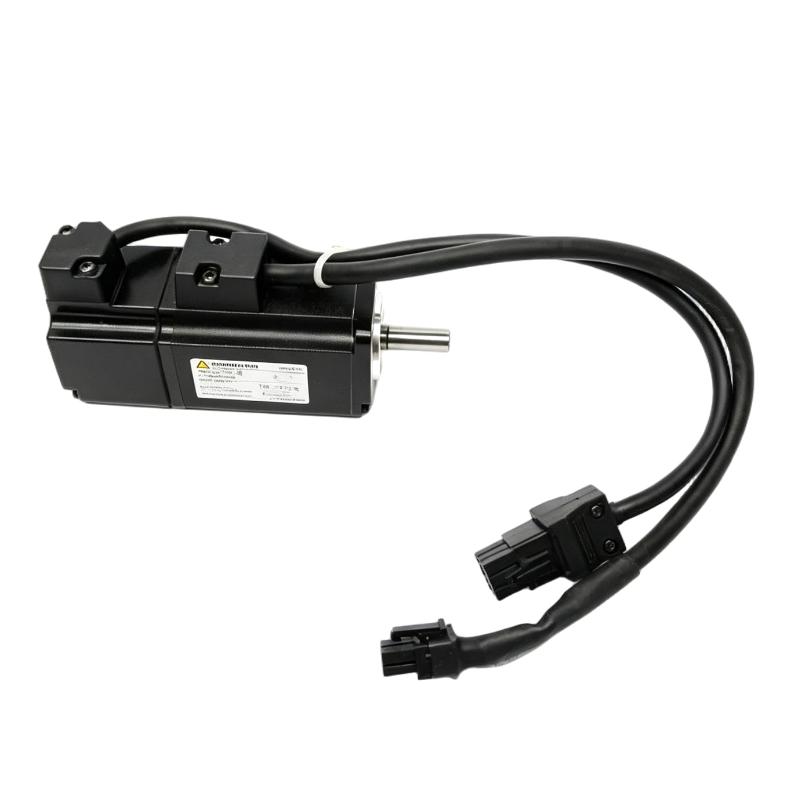
The Schneider Electric BCH0401O12A1C is a compact servo motor from the BCH series, compatible with the Lexium 23 Plus servo drive family. With a rated output power of 100 W, a nominal speed of 3000 rpm, and a 40 mm mounting flange, it suits compact motion-control systems where installation space and precise shaft positioning are important.
In applications such as small indexing tables, electronic assembly equipment, label applicators, and lightweight positioning mechanisms, the motor converts servo-drive output into controlled rotary movement. Its 20-bit incremental encoder supplies position feedback to the drive, allowing the control system to regulate motor speed and position. The keyed shaft provides a mechanical interface for coupling the motor to compatible pulleys, gears, or other transmission components.
The BCH0401O12A1C has no holding brake and uses an IP40 protection configuration. It is therefore best assessed for installations where the motor can be mounted in a suitably protected machine enclosure and where the application does not require an integrated brake to hold a vertical or gravity-loaded axis after power is removed.
Technical Specifications
| Parameter | Specification |
|---|---|
| Brand | Schneider Electric |
| Model | BCH0401O12A1C |
| Product Type | Servo Motor |
| Product Series | BCH |
| Compatible Product Range | Lexium 23 Plus |
| Rated Output Power | 0.1 kW (100 W) |
| Rated Supply Voltage | 220 V |
| Supply Phase | Single phase supply configuration |
| Nominal Speed | 3000 rpm |
| Maximum Mechanical Speed | 5000 rpm |
| Nominal Torque | 0.32 N·m |
| Peak Stall Torque | 0.96 N·m |
| Continuous Stall Current | 0.9 A |
| Maximum Current | 2.7 A RMS |
| Feedback Type | 20-bit incremental encoder |
| Shaft Type | Keyed shaft |
| Shaft Diameter | 8 mm |
| Shaft Length | 20 mm |
| Motor Flange Size | 40 mm |
| Holding Brake | Without holding brake |
| Protection Rating | IP40 |
| Electrical Connection | Flying leads |
| Cooling Method | Natural convection |
| Length | 100.6 mm |
| Weight | 0.5 kg |
Product Features
Compact 40 mm flange: The small mounting interface suits machinery with limited installation space, including compact positioning units and lightweight automation mechanisms.
20-bit incremental encoder: The encoder provides feedback for servo control. The drive uses this feedback to regulate motor movement and track commanded position during operation.
Keyed shaft connection: The shaft includes a keyway for mechanical coupling to compatible transmission components. Correct shaft alignment and coupling selection help limit vibration and unnecessary bearing loads.
No integrated holding brake: The motor is intended for applications that do not require an integrated brake to hold the shaft stationary when power is removed. Vertical axes and gravity-loaded mechanisms require a separate assessment of their holding and safety requirements.
Natural-convection cooling: The motor dissipates heat without a dedicated forced-air cooling system. Mounting conditions, ambient temperature, and operating duty still affect thermal performance.
Lexium 23 Plus compatibility: The motor belongs to the BCH servo-motor family used with compatible Lexium 23 Plus drives. Motor and drive selection must account for rated power, current, torque, speed, feedback, and supply conditions.
Working Principle
The BCH0401O12A1C receives electrical power from a compatible servo drive. The drive controls the current supplied to the motor windings, producing a rotating magnetic field that turns the rotor and connected shaft.
During a positioning task, a motion controller sends a movement command to the servo drive. The motor’s 20-bit incremental encoder returns position feedback, allowing the drive to compare actual movement with the commanded motion and adjust motor output. This feedback-based operation supports repeatable positioning and controlled speed changes.
For example, in a small indexing mechanism, the motor can rotate a fixture to a specified position before a sensor check or assembly operation takes place. The servo drive coordinates acceleration, travel, and deceleration, while the encoder helps track the motor’s movement.
The keyed shaft transfers torque to the connected mechanism through a compatible coupling or transmission. Because this model has no integrated holding brake, applications that must maintain position during a power interruption need a separate mechanical or braking solution appropriate to the load.
Role in a Lexium 23 Plus Motion Control Architecture
The BCH0401O12A1C serves as the electromechanical actuator in a servo axis. The servo drive regulates motor current and speed, while the encoder supplies feedback used to control the movement commanded by the machine controller.
| System Component | Function | Relationship to BCH0401O12A1C |
|---|---|---|
| Motion Controller or PLC | Generates motion commands and machine sequences | Defines the required movement, position, and operating sequence |
| Lexium 23 Plus Servo Drive | Controls motor current, speed, and movement | Supplies controlled electrical power and processes encoder feedback |
| BCH0401O12A1C Servo Motor | Converts electrical energy into rotary motion | Drives the connected mechanical axis |
| Incremental Encoder | Measures motor movement | Returns feedback used by the servo-control loop |
| Mechanical Coupling | Transfers motor torque to the load | Connects the keyed shaft to the transmission mechanism |
| Gearbox or Belt Drive | Adapts speed and torque to the application | Transfers motor rotation to the machine’s driven component |
| Limit or Home Sensors | Identify travel limits or a reference position | Provide additional machine-position signals where required |
| HMI or Operator Panel | Provides operator commands and status | Displays axis status through the controller or servo system |
Industrial Applications
| Application | Motion Requirement | Use of BCH0401O12A1C |
|---|---|---|
| Electronic Assembly Equipment | Short, repeatable movements between work positions | Drives compact mechanisms used for component positioning |
| Labeling Machinery | Coordinated rotation and positioning | Operates small feed or positioning mechanisms |
| Compact Indexing Tables | Repeated angular movement between stations | Provides rotary motion for lightweight indexing assemblies |
| Small Packaging Machines | Controlled movement of guides, feeders, or adjustment mechanisms | Supports servo-controlled movement coordinated with the packaging sequence |
| Laboratory and Inspection Equipment | Repeatable positioning of small fixtures or mechanisms | Drives an axis where encoder feedback is required |
| Lightweight Pick-and-Place Mechanisms | Controlled movement over a limited travel range | Supplies rotary motion to a suitably sized mechanical transmission |
| Small Automated Production Units | Positioning synchronized with sensors and machine logic | Operates as a servo axis within a PLC-based control system |
Installation and Maintenance
- Verify the complete model reference: Confirm that the motor is BCH0401O12A1C and that its shaft, encoder, brake configuration, and mounting interface match the application requirements.
- Match the servo drive: Check drive compatibility, rated power, current, voltage, encoder interface, and motor parameters before connecting the motor.
- Check the supply arrangement: Confirm that the servo drive receives the correct supply and is configured for the selected motor. Do not connect the motor directly to the mains supply.
- Inspect the mounting flange: Verify the 40 mm flange interface, mounting-hole alignment, and mechanical clearances before securing the motor.
- Align the shaft coupling: Match the keyed shaft to a compatible coupling or transmission. Avoid forcing the coupling onto the shaft or applying excessive axial force during assembly.
- Check the driven load: Confirm that the required torque, acceleration, speed, and inertia are within the capabilities of the motor and servo drive.
- Protect the motor environment: IP40 protection does not provide protection against water ingress. Use an appropriate enclosure and installation arrangement where dust, moisture, or contamination may be present.
- Route encoder and power cables correctly: Follow the drive installation requirements for cable routing, grounding, shielding, and separation between motor power wiring and feedback signals.
- Configure encoder feedback: Set the correct motor and feedback parameters in the servo drive. Verify that feedback direction and commanded rotation agree during initial testing.
- Test motion at low speed: Check the direction of rotation, acceleration, deceleration, positioning response, and mechanical clearance before operating at the intended speed.
- Assess holding requirements: Since this motor has no integrated holding brake, evaluate the need for a separate holding mechanism where the load could move when the drive is disabled or power is lost.
- Perform periodic inspections: Check mounting fasteners, shaft coupling, cables, connector terminations, vibration, and operating temperature. Investigate abnormal noise or changes in positioning accuracy before returning the equipment to normal operation.
Related Components
| Component | Function | Selection Considerations |
|---|---|---|
| Lexium 23 Plus Servo Drive | Controls motor current and movement | Rated power, current, supply arrangement, and encoder compatibility |
| Motion Controller or PLC | Generates positioning commands and machine sequences | Required motion functions, I/O, and communication interface |
| Servo Power Cable | Connects the motor to the drive | Current capacity, cable length, connector or flying-lead arrangement |
| Encoder Feedback Cable | Carries feedback signals to the drive | Encoder interface, shielding, routing, and electrical compatibility |
| Keyed Shaft Coupling | Transfers torque to the driven mechanism | Shaft diameter, key dimensions, alignment, and allowable torque |
| Gearbox | Adapts speed and torque | Gear ratio, backlash, rated torque, and positioning requirements |
| Home or Limit Sensors | Detect reference positions and travel limits | Sensor type, switching logic, and controller compatibility |
| Mechanical Holding Brake | Holds a load when the motor is not actively driving it | Required holding torque, release method, and application safety requirements |
Recommended Related Models
| Model | Product Description | Application Context |
|---|---|---|
| BCH0401O12A1C | Lexium 23 Plus BCH Servo Motor, 100 W | Compact servo axis requiring a keyed shaft and no integrated holding brake |
| BCH0401O22A1C | Lexium 23 Plus BCH Servo Motor variant | Consider only after verifying the exact shaft and protection configuration against the application |
| BCH0601O12A1C | Lexium 23 Plus BCH Servo Motor, 200 W class | A higher-power option with a larger mounting flange for applications requiring greater motor capacity |
| BCH0602O12A1C | Lexium 23 Plus BCH Servo Motor, 400 W class | For applications requiring a higher power class and a larger motor frame |
| BCH0401O12F1C | Lexium 23 Plus BCH Servo Motor variant with holding brake | A configuration to evaluate where a holding brake is required; verify the full model specification before selection |
Related motor references can differ in power, shaft configuration, feedback, protection, and brake arrangement. Confirm the complete model code and the matching servo-drive requirements before substituting one motor for another.
Key Advantages
- Compact installation: The 40 mm flange and 100.6 mm length suit space-constrained servo mechanisms.
- Encoder feedback: Supports closed-loop motion control and repeatable positioning.
- Keyed shaft: Provides a mechanical connection for compatible couplings and transmission components.
- Lexium 23 Plus integration: Fits servo architectures built around compatible BCH motors and Lexium 23 Plus drives.
- Low motor mass: The 0.5 kg weight can be beneficial in compact mechanisms with limited moving or mounting mass.
Technical FAQs
What does the 20-bit incremental encoder do on the BCH0401O12A1C?
It supplies motor-position feedback to the servo drive. The drive uses this feedback to regulate movement against the commanded motion. The encoder is part of the motor’s feedback arrangement, so the drive configuration and feedback wiring must be compatible.
Does the BCH0401O12A1C have a holding brake?
No. This model is specified without an integrated holding brake. If the application includes a vertical axis or a load that could move when power is removed, a separate holding solution may be necessary.
What should be checked when pairing this motor with a Lexium 23 Plus drive?
Verify the drive’s motor compatibility, rated power, current, supply arrangement, encoder interface, and supported motor parameters. The controller and drive must also be configured for the intended movement and feedback direction.
Can the BCH0401O12A1C be installed in a wet or dusty environment?
The motor’s IP40 protection configuration does not provide protection against water ingress. For installations exposed to moisture, conductive dust, or other contaminants, the machine enclosure and mounting arrangement must provide the necessary environmental protection.