ProductPRODUCT
Featured products
Contact Us
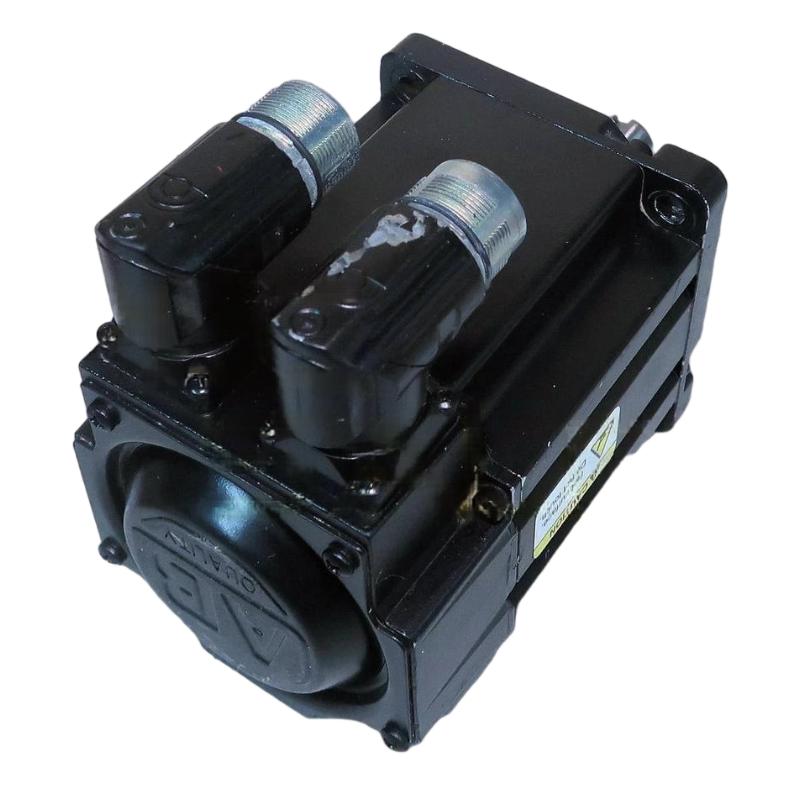
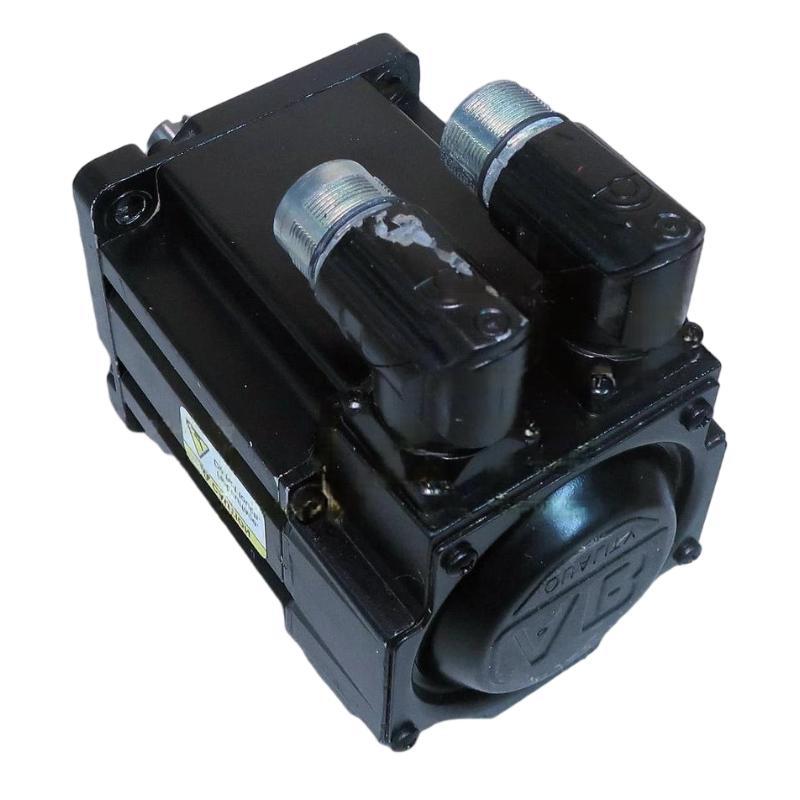
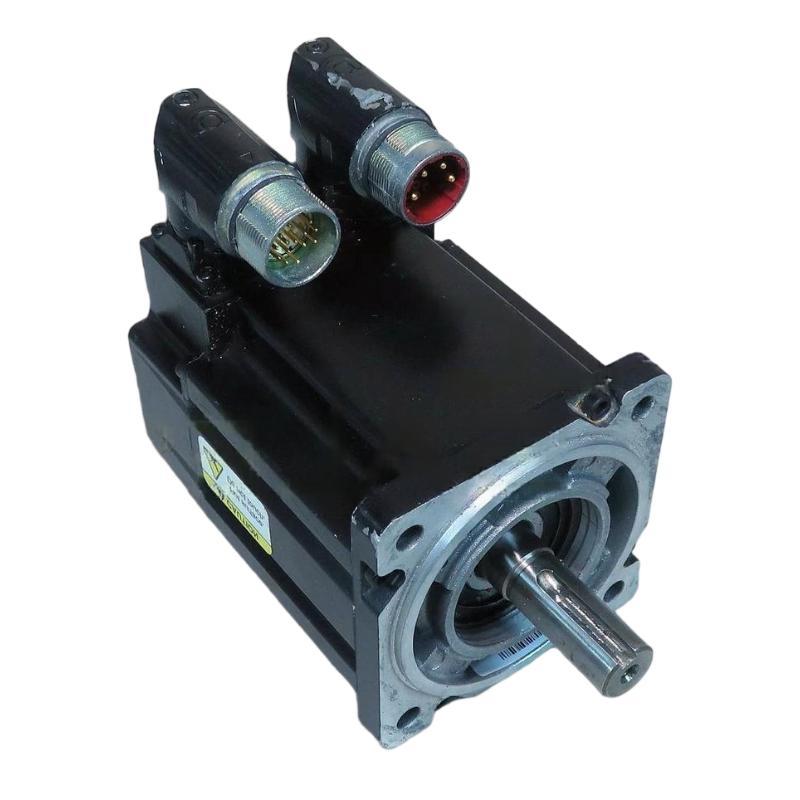
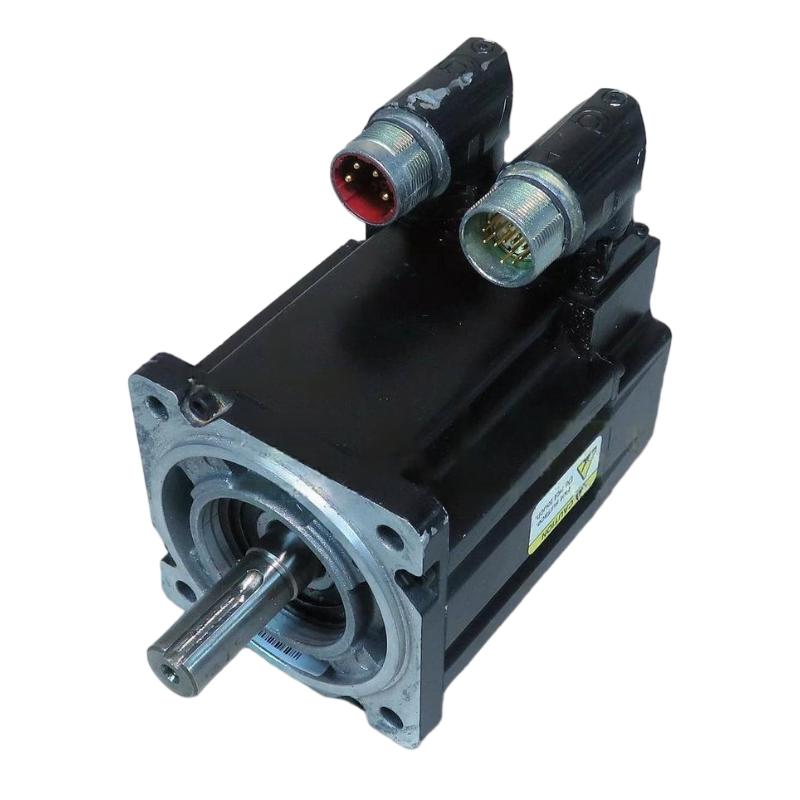
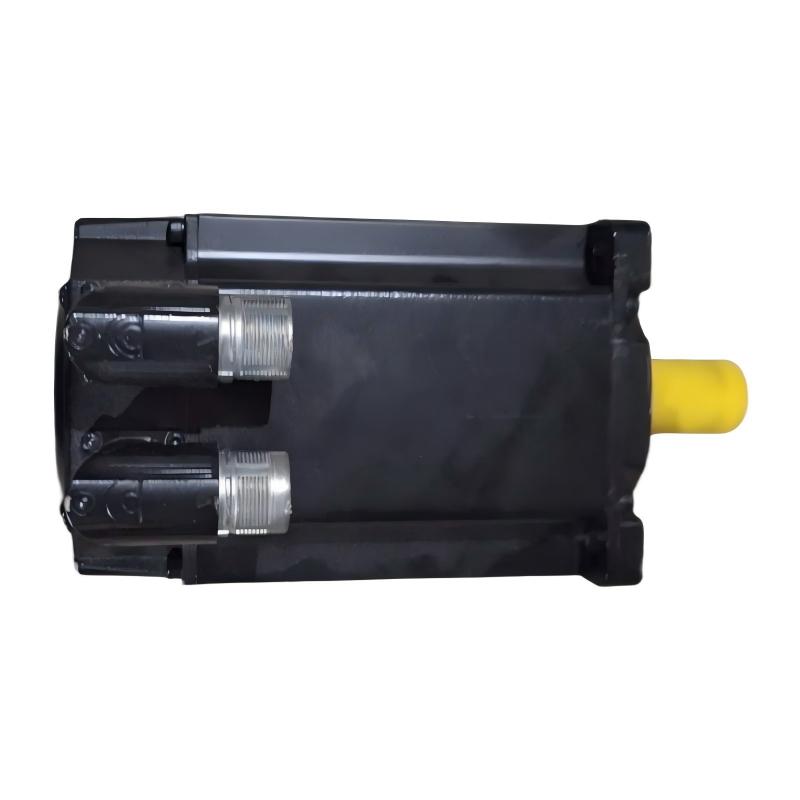
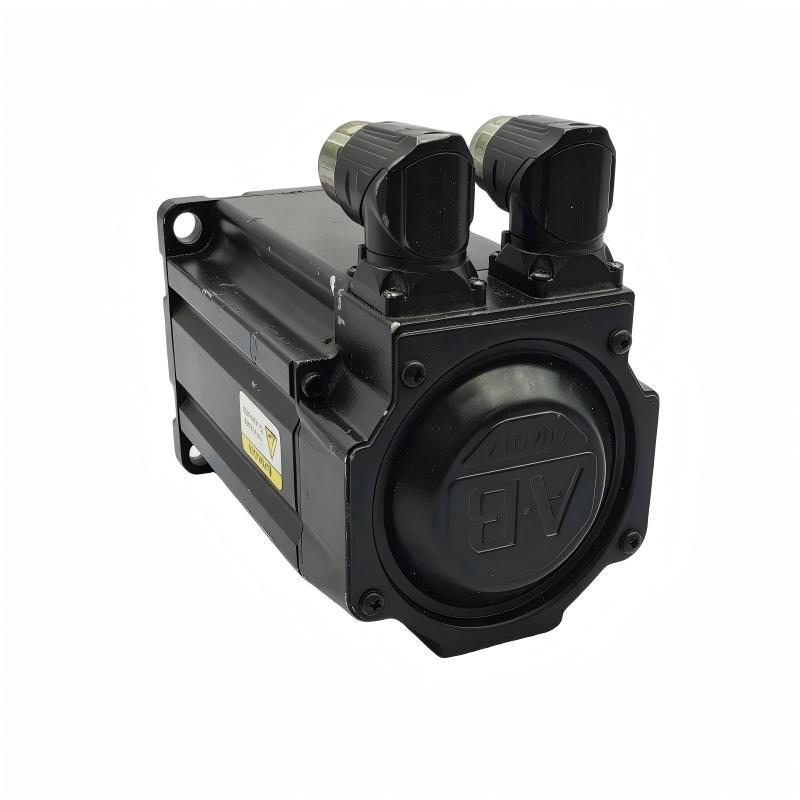
- Allen Bradley
- MPL-B310P-HJ74AA
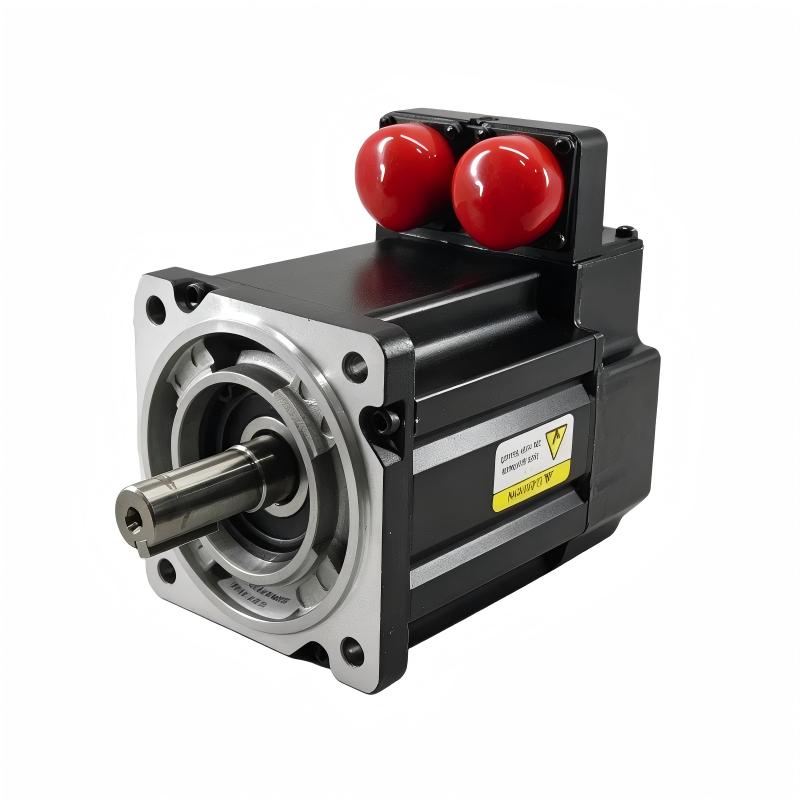
- Servo Motor
- USA
- 100 mm
- 2.7 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
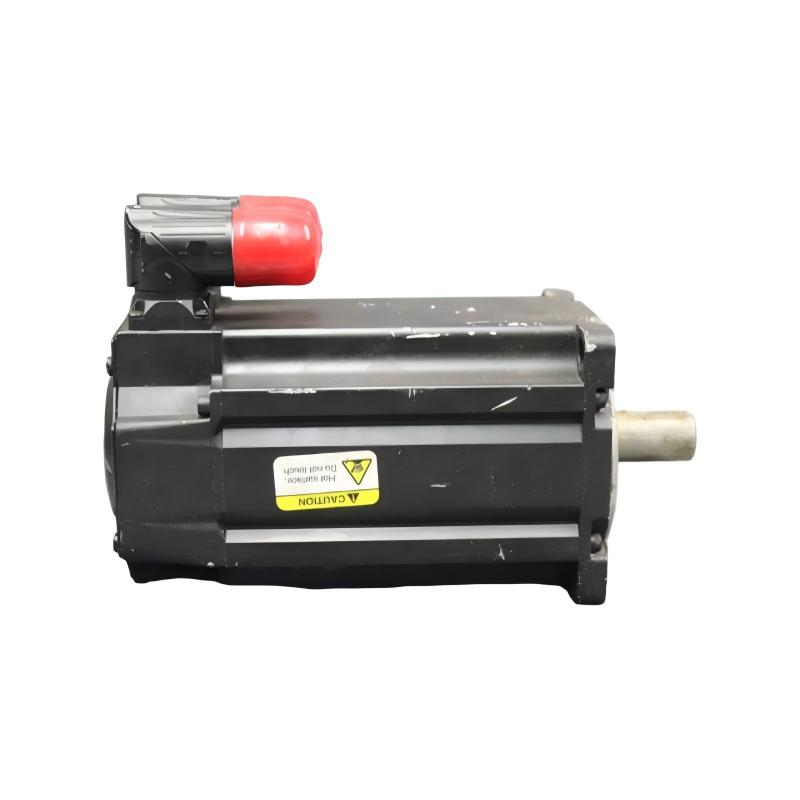
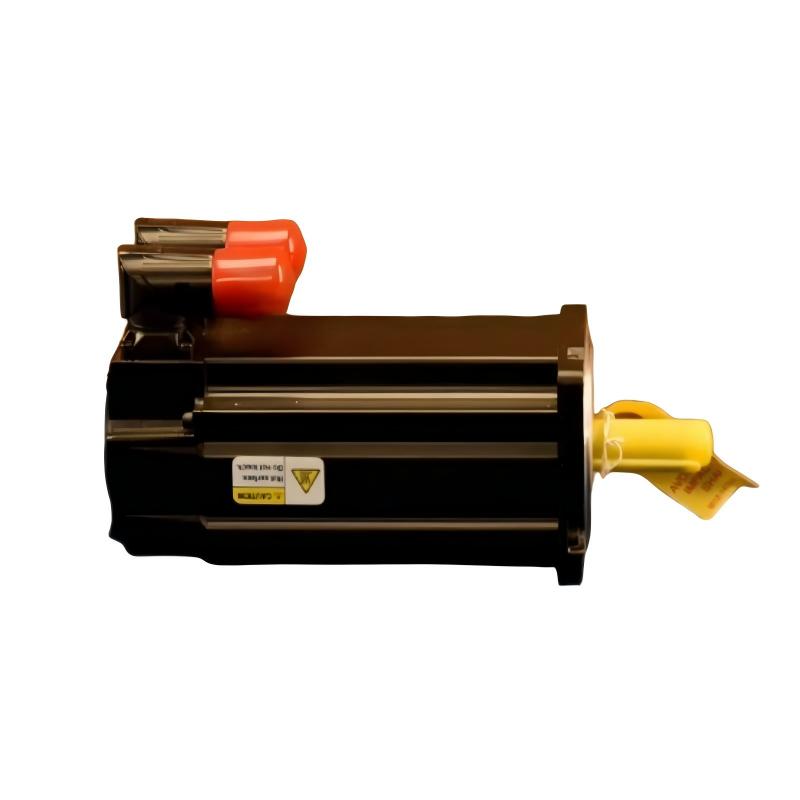
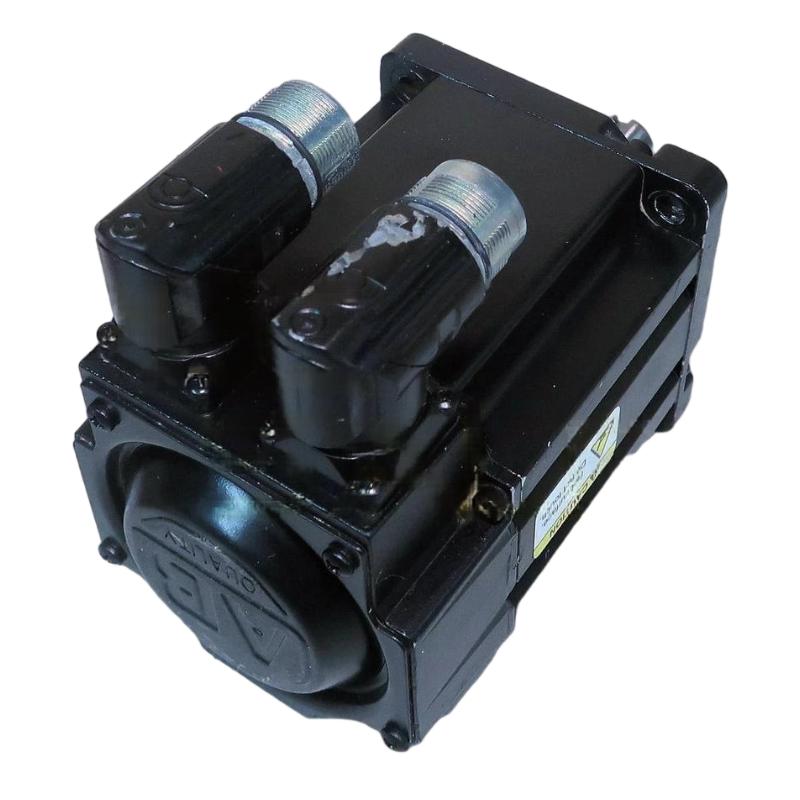
The Allen Bradley MPL-B310P-HJ74AA Servo Motor is an industrial motion-control component designed for applications requiring controlled rotation, accurate positioning, and coordinated mechanical movement. Servo motors are widely used in automated production equipment where speed, torque, and position must be managed according to commands from a compatible servo drive and motion controller.
As part of the Allen-Bradley Kinetix motion-control product ecosystem, the MPL servo motor family is associated with industrial applications such as packaging machinery, automated assembly systems, material handling equipment, and precision manufacturing. A properly configured servo system combines the motor, drive, feedback device, controller, and mechanical transmission to deliver repeatable motion and responsive operation.
The MPL-B310P-HJ74AA is identified by the supplied product description as a servo motor. Its specified frame size is 100 mm, and its listed weight is 2.7 kg. These physical details are useful for preliminary machine-layout planning, equipment inventory, and replacement logistics.
Servo motor performance depends on the complete ordering code, motor electrical characteristics, feedback configuration, compatible drive, and application requirements. Before installation or replacement, verify the full model number and its specifications against the motor nameplate and the applicable equipment documentation. Voltage, continuous and peak torque, rated speed, shaft dimensions, feedback type, connector arrangement, and brake configuration should not be inferred from the model name alone.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Allen-Bradley |
| Product Model | MPL-B310P-HJ74AA |
| Product Type | Servo Motor |
| Product Family | MPL Servo Motor Series |
| Application Category | Industrial Motion Control |
| Frame Size | 100 mm |
| Weight | 2.7 kg |
| Primary Function | Controlled rotary motion for automated machinery |
| Motion Characteristics | Speed, torque, and position control when used in a compatible servo system |
| Drive Requirement | Compatible servo drive, selected according to verified motor specifications |
| Controller Integration | Compatible motion controller or automation controller |
| Feedback Interface | Verify the exact feedback device and drive compatibility |
| Mounting | Confirm flange, shaft, and mechanical interface dimensions |
| Typical Applications | Packaging, assembly, positioning, material handling, and industrial automation |
The table reflects the supplied model designation, frame size, and weight. Additional electrical and mechanical specifications should be confirmed for the exact motor variant before engineering, procurement, or commissioning.
What Is the Allen Bradley MPL-B310P-HJ74AA Servo Motor?
A servo motor is an electromechanical device used to produce controlled movement in a machine. Unlike a motor operated only through a simple ON/OFF command, a servo motor normally works as part of a feedback-based motion-control system. The controller issues a motion command, the servo drive regulates electrical power to the motor, and feedback information helps the system evaluate actual movement.
This arrangement allows automated machinery to perform tasks such as moving a component to a defined position, maintaining a commanded speed, or coordinating movement with other machine axes.
The MPL-B310P-HJ74AA is intended to serve as the motor element within a suitable motion-control installation. Its performance in a particular machine depends on the complete system configuration, including the servo drive, controller, mechanical load, transmission, cabling, and feedback interface.
A typical servo system follows this sequence:
Motion Controller → Servo Drive → Servo Motor → Mechanical Load
Feedback information returns through the supported feedback path, allowing the drive and controller to regulate motion according to the configured control strategy.
Function and Working Principle
1. Motion Command Processing
The motion controller generates commands based on the machine program, operator input, production sequence, or coordinated-axis requirements. Depending on the application, a command may specify a target position, travel speed, acceleration, deceleration, or torque-related operating condition.
The controller must be configured for the installed motor and drive combination so that motion commands are interpreted correctly.
2. Servo Drive Power Regulation
The servo drive receives the motion command and regulates the electrical power supplied to the motor. It adjusts motor operation according to the control requirements and supported feedback information.
Drive selection is critical because the drive must match the motor’s rated voltage, current, feedback interface, and other electrical requirements. A motor should not be connected to a drive based solely on brand or product-family similarity.
3. Electromechanical Conversion
The motor converts electrical energy into rotational mechanical movement. The resulting torque rotates the motor shaft, which can be connected to a gearbox, coupling, belt, screw mechanism, rotary table, or other machine transmission.
The mechanical system converts motor rotation into the movement required by the application. Load inertia, friction, acceleration requirements, and transmission efficiency all affect the final performance.
4. Feedback-Based Regulation
A compatible servo system uses feedback to compare actual motion with the commanded movement. The drive or controller can then adjust its output to reduce the difference between the requested and measured behavior.
The exact feedback technology and interface for the MPL-B310P-HJ74AA must be verified from its specific hardware documentation. Feedback compatibility is essential when selecting a replacement drive or commissioning a new motion axis.
5. Coordinated Machine Movement
In multi-axis applications, the controller can coordinate the motor with other axes to achieve synchronized movement. Examples include packaging operations, pick-and-place machinery, indexing systems, and automated assembly equipment.
Successful coordination requires suitable controller capabilities, drive configuration, motion profiles, mechanical design, and correct axis tuning.
Role in Industrial Motion-Control Systems
The Allen Bradley MPL-B310P-HJ74AA can be considered the mechanical motion-producing element in an appropriately configured servo system. The motor alone does not provide the entire motion-control function; it operates together with drive electronics, control software, feedback, and mechanical components.
| System Element | Primary Function |
|---|---|
| Motion Controller | Generates position, speed, and coordinated-motion commands |
| Servo Drive | Regulates motor power and executes supported control functions |
| MPL-B310P-HJ74AA Servo Motor | Converts electrical energy into mechanical rotation |
| Feedback Device | Supplies motion-related feedback when required by the system |
| Power and Feedback Cables | Connect the motor to compatible drive interfaces |
| Mechanical Coupling | Transfers motor torque to the driven mechanism |
| Gearbox or Transmission | Adapts speed and torque to the machine load where required |
| HMI or Operator Interface | Allows operators to enter commands and monitor machine status |
| Engineering Software | Supports axis configuration, diagnostics, and commissioning |
Each element must be correctly selected and configured. An incorrectly matched drive, unsuitable feedback interface, or poorly sized mechanical transmission can prevent the motor from achieving the required motion performance.
Industrial Applications
Packaging Machinery
Servo motors are used in packaging equipment where accurate movement and repeatable timing are important. Applications may include indexing, product positioning, feed mechanisms, and coordinated movement between machine stations.
The motor’s suitability depends on the required acceleration, load inertia, operating cycle, and verified torque-speed characteristics.
Automated Assembly
Assembly equipment often requires components to move between defined positions. A servo system can provide controlled motion for positioning stages, transfer mechanisms, insertion operations, and automated handling devices.
Repeatability depends on the complete mechanical and control system rather than the motor alone.
Material Handling
Automated material handling systems use servo motors for controlled movement of transfer mechanisms, positioning platforms, and other driven components. Proper sizing helps maintain the required motion profile under changing load conditions.
Pick-and-Place Equipment
Pick-and-place machinery frequently requires rapid movement between programmed coordinates. Servo systems can coordinate the movement of multiple axes while maintaining the required speed and positioning behavior.
Printing and Converting Equipment
Certain printing, cutting, winding, and converting machines use servo motors to coordinate web movement, rotary mechanisms, and feed systems. Applications with continuous material movement require careful consideration of synchronization, tension, and dynamic response.
General Industrial Automation
Servo motors can also be integrated into automated inspection equipment, indexing tables, production fixtures, and other machinery requiring controlled rotary motion. The exact application should be evaluated against the motor’s verified ratings and mechanical interface.
Installation and Mechanical Integration
Correct installation helps protect the motor and maintain stable operation throughout the machine’s service life.
Verify the Motor Identity
Before installation, confirm the complete model designation MPL-B310P-HJ74AA on the motor nameplate. Check the ordering code, revision or suffix information where applicable, and any existing equipment records.
Do not assume that motors with similar MPL model numbers have identical electrical, feedback, shaft, or mounting characteristics.
Check the Mechanical Interface
Confirm the mounting flange, shaft dimensions, shaft-end configuration, allowable mounting orientation, and coupling requirements against the actual motor specification.
The supplied 100 mm frame size is useful for preliminary identification, but it does not replace the complete dimensional drawing. Check the machine interface before installing a replacement.
Evaluate the Driven Load
Calculate or confirm the required torque, speed, acceleration, and reflected inertia. The motor must be suitable for both continuous operation and the peak demands of the machine cycle.
Pay particular attention to rapid acceleration, frequent direction changes, vertical loads, and high-inertia mechanisms. These conditions can affect motor heating, drive sizing, and motion stability.
Install the Coupling or Transmission
Align the motor shaft with the driven mechanism according to the applicable mechanical requirements. Incorrect alignment, excessive radial or axial loading, or an unsuitable coupling can cause vibration, premature bearing wear, and mechanical failure.
Where a gearbox or belt transmission is used, verify its ratio, allowable load, backlash, and operating limits.
Connect the Cables
Use the correct power and feedback cables for the specific motor and drive combination. Verify connector type, pin assignment, cable routing, shielding, grounding, and separation from noise-generating power conductors according to the applicable installation requirements.
Never infer connector assignments from a similar motor variant.
Servo Drive Configuration and Commissioning
A servo motor must be commissioned as part of a compatible motion-control system.
Confirm Drive Compatibility
Before energizing the system, verify that the selected drive supports the motor’s electrical ratings and feedback configuration. Confirm the required power supply, motor-current range, feedback interface, cable arrangement, and applicable drive firmware or configuration requirements.
Enter Motor Parameters
Configure the axis using the correct motor identification and supported parameter set. Depending on the system, relevant settings may include motor data, feedback configuration, travel limits, speed limits, acceleration and deceleration, and applicable protection settings.
Incorrect motor parameters can cause poor motion response, nuisance faults, or unsafe mechanical behavior.
Check Motion Direction
Perform initial movement tests under controlled conditions. Confirm that the motor rotates in the intended direction and that the commanded and measured motion correspond correctly.
If direction is incorrect, review the controller configuration and approved drive setup procedure rather than changing wiring or parameters arbitrarily.
Tune the Motion Axis
Axis tuning helps balance response, stability, settling time, and mechanical behavior. The appropriate tuning method depends on the drive, controller, load, and machine requirements.
Start with conservative motion limits and verify the machine’s response before increasing speed or acceleration. Watch for vibration, excessive noise, overshoot, or unexpected movement.
Verify the Complete Machine Sequence
After basic motion checks, test the motor under representative operating conditions. Confirm repeatability, load handling, stopping behavior, and coordination with other axes where applicable.
Record the final configuration and any relevant commissioning measurements for future maintenance.
Troubleshooting the MPL-B310P-HJ74AA Servo Motor
Servo-system faults can originate in the motor, drive, feedback device, power supply, cabling, controller, or mechanical load. A systematic diagnosis helps identify the actual cause without replacing components unnecessarily.
Motor Does Not Rotate
Possible causes include:
- Servo drive not enabled
- Missing or incorrect drive power
- Active drive fault
- Incorrect motor or feedback configuration
- Missing motion command
- Open or damaged cable
- Mechanical obstruction
- Controller interlock preventing movement
Begin by reviewing drive status and fault information. Confirm that the system is enabled, the command is valid, and the machine is permitted to move. Inspect the cables and mechanical load according to approved safety procedures.
Servo Faults During Acceleration
Faults during acceleration may indicate excessive load inertia, unsuitable acceleration settings, current limitations, incorrect motor parameters, power-supply issues, or a mechanical restriction.
Compare the motion profile with the verified motor and drive ratings. Reduce the commanded acceleration during controlled testing if appropriate, then investigate whether the fault is related to electrical loading, mechanical resistance, or configuration.
Positioning Is Inaccurate
Positioning problems may be associated with feedback issues, incorrect axis scaling, mechanical backlash, coupling slippage, poor tuning, or load changes.
Check the feedback status and axis configuration. Inspect the mechanical transmission and confirm that commanded movement corresponds to the expected physical displacement.
Excessive Vibration or Noise
Unusual vibration may result from mechanical misalignment, loose mounting hardware, unsuitable tuning, resonance, damaged bearings, or a load that exceeds the application’s design assumptions.
Inspect the motor mounting and coupling, then review the motion profile and tuning parameters. Do not continue operation if vibration is severe or if mechanical damage is suspected.
Motor Overheating
Possible causes include excessive continuous torque demand, repeated high-acceleration cycles, inadequate cooling, high ambient temperature, mechanical binding, or incorrect motor sizing.
Review operating conditions and compare the actual duty cycle with the motor’s verified ratings. Check that the motor is mounted correctly and that the driven mechanism moves freely.
Feedback or Drive Communication Fault
A feedback-related fault may result from incompatible hardware, a damaged cable, a loose connector, incorrect configuration, or a fault in the feedback device or drive interface.
Check the exact motor and drive combination, connector condition, cable integrity, and diagnostic messages. Use the appropriate wiring diagram and service procedures for the installed hardware.
Maintenance Recommendations
Routine inspection helps identify developing mechanical and electrical problems before they cause production interruptions.
Inspect the motor exterior: Look for contamination, corrosion, physical damage, loose mounting hardware, and signs of overheating.
Check mechanical alignment: Inspect couplings, mounting surfaces, transmission components, and the driven load for looseness or abnormal wear.
Inspect cables and connectors: Look for damaged insulation, strained cables, loose connectors, and signs of moisture or contamination.
Monitor operating trends: Review drive faults, temperature indications where available, vibration, cycle performance, and changes in positioning accuracy.
Maintain correct loading: Avoid operation beyond the motor and drive’s verified ratings. Reassess sizing if the machine load or production cycle changes significantly.
Document configuration changes: Record replacement details, drive parameters, tuning adjustments, and commissioning results.
Maintenance should follow the applicable manufacturer instructions and the plant’s isolation and lockout procedures. Do not open or service energized equipment unless the task is specifically authorized and performed using the required protective measures.
Compatible System Components
The MPL-B310P-HJ74AA should be integrated with components that are confirmed compatible with its exact specifications. The following are general categories of equipment commonly found in industrial servo systems.
| Component Category | Purpose |
|---|---|
| Compatible Allen-Bradley Servo Drive | Supplies controlled electrical power to the motor |
| Motion Controller | Generates and coordinates motion commands |
| Feedback Cable | Transfers supported feedback signals |
| Motor Power Cable | Connects the motor to the drive output |
| Industrial Ethernet or Motion Network | Exchanges control and status data when supported |
| Mechanical Coupling | Connects the motor shaft to the driven equipment |
| Gearbox | Adapts speed and torque where required |
| Circuit Protection | Provides appropriately engineered electrical protection |
| HMI | Displays operating status, alarms, and machine commands |
| Engineering Software | Supports configuration, diagnostics, and axis tuning |
Specific drive models, cable part numbers, and controller combinations should be chosen only after confirming the complete motor ordering code and the system’s hardware requirements.
Replacement and Procurement Considerations
When sourcing a replacement for the Allen Bradley MPL-B310P-HJ74AA, verify the full model number rather than relying only on the MPL family designation or frame size.
Important checks include:
- Complete motor catalog number
- Frame size and mounting dimensions
- Rated voltage and current
- Continuous and peak torque requirements
- Rated speed and allowable operating range
- Feedback device and connector configuration
- Shaft dimensions and mechanical interface
- Brake configuration, if applicable
- Compatible servo drive and cable assembly
- Product condition and available testing records
The listed 100 mm frame size and 2.7 kg weight are useful for preliminary handling and installation planning. They are not sufficient by themselves to establish electrical or mechanical interchangeability.
For a replacement installation, compare the original motor nameplate, mechanical drawing, drive configuration, and machine requirements before purchasing or commissioning the unit.
Key Advantages
Controlled Rotary Motion
When used with a compatible drive and controller, a servo motor supports regulated rotation for machinery requiring controlled speed, torque, and position.
Integration Into Automated Machinery
Servo systems can be incorporated into production equipment where repeatable motion and coordinated machine sequences are required.
Flexible Motion Profiles
Suitable drive and controller configurations can support application-specific acceleration, deceleration, positioning, and synchronization requirements.
Compact Physical Characteristics
The supplied 100 mm frame-size designation and 2.7 kg weight support preliminary machine-layout and inventory planning.
Support for System-Level Diagnostics
When paired with compatible drive and controller hardware, the servo system can provide diagnostic information useful for commissioning and maintenance.
Technical FAQs
What is the Allen Bradley MPL-B310P-HJ74AA?
The MPL-B310P-HJ74AA is identified as an Allen-Bradley servo motor intended for use in a compatible industrial motion-control system.
What is its frame size?
The supplied frame size is 100 mm.
How much does the MPL-B310P-HJ74AA weigh?
The listed weight is 2.7 kg.
Can the motor operate without a servo drive?
A servo motor intended for a servo-control application must be paired with suitable drive electronics and the required control arrangement. It should not be connected directly to a power supply without confirming the motor’s design and manufacturer requirements.
Which servo drive is compatible with this motor?
The exact drive must be selected using the motor’s verified electrical ratings, feedback interface, connector arrangement, and the intended motion-control architecture. Compatibility should not be assumed from the brand or product family alone.
What causes poor positioning accuracy?
Possible causes include feedback problems, incorrect axis scaling, poor tuning, mechanical backlash, coupling slippage, or changing load conditions.
What should be checked before replacing the motor?
Verify the full catalog number, mounting and shaft dimensions, electrical ratings, feedback configuration, cable requirements, and compatibility with the existing drive and controller.
Is the motor suitable for every industrial motion application?
No. Suitability depends on the required torque, speed, acceleration, duty cycle, load inertia, environment, and control-system configuration. Engineering calculations and verified product specifications are necessary before selection.
Conclusion
The Allen Bradley MPL-B310P-HJ74AA Servo Motor is an industrial motion-control component intended to produce controlled rotary movement as part of a compatible servo system. When correctly matched with a servo drive, motion controller, feedback interface, and mechanical transmission, a servo motor can support positioning, speed regulation, coordinated motion, and repeatable machine operation.
With a supplied 100 mm frame size and a listed weight of 2.7 kg, the MPL-B310P-HJ74AA provides useful physical reference information for equipment planning and replacement logistics. Successful integration depends on verifying its exact electrical and mechanical specifications, selecting compatible drive hardware, configuring the axis correctly, and commissioning the complete machine under controlled conditions.
For maintenance and procurement, confirm the full MPL-B310P-HJ74AA catalog number and all relevant motor characteristics before installation. Correct identification, careful mechanical integration, appropriate parameter configuration, and systematic troubleshooting help maintain reliable motion control and reduce avoidable downtime in industrial automation systems.