ProductPRODUCT
Featured products
Contact Us
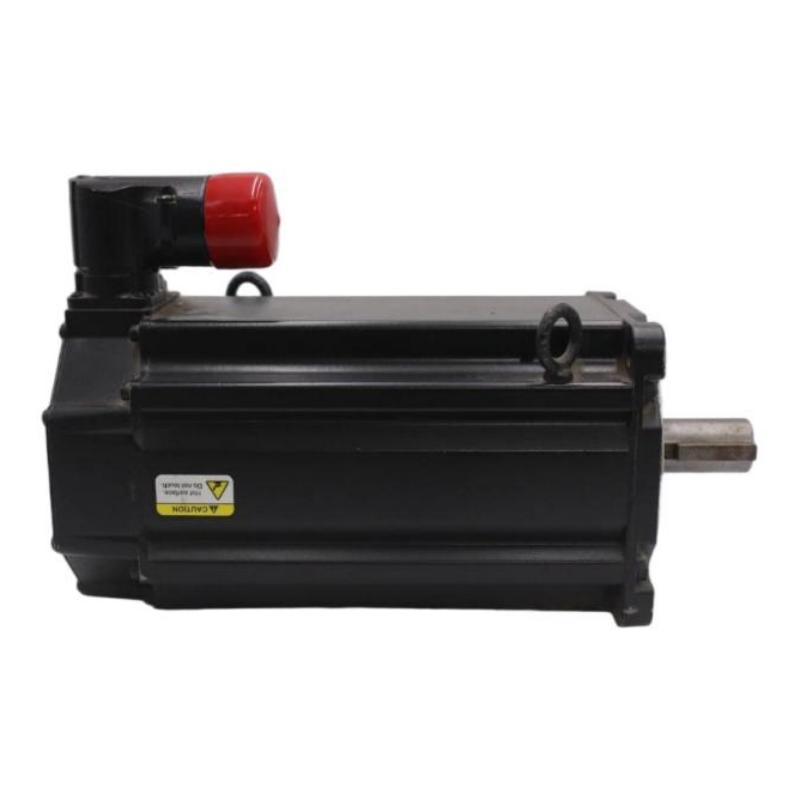
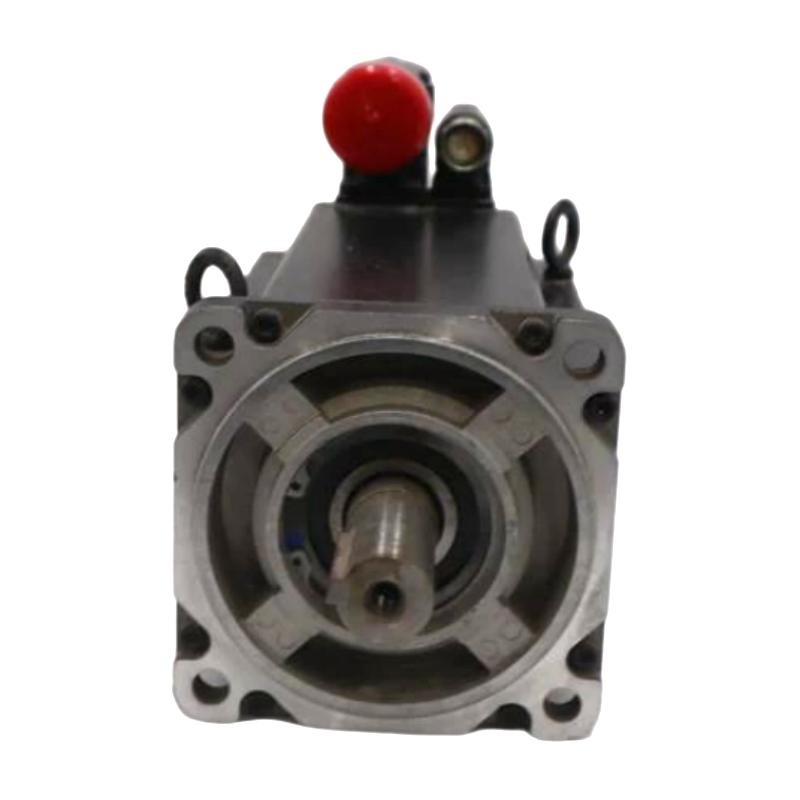
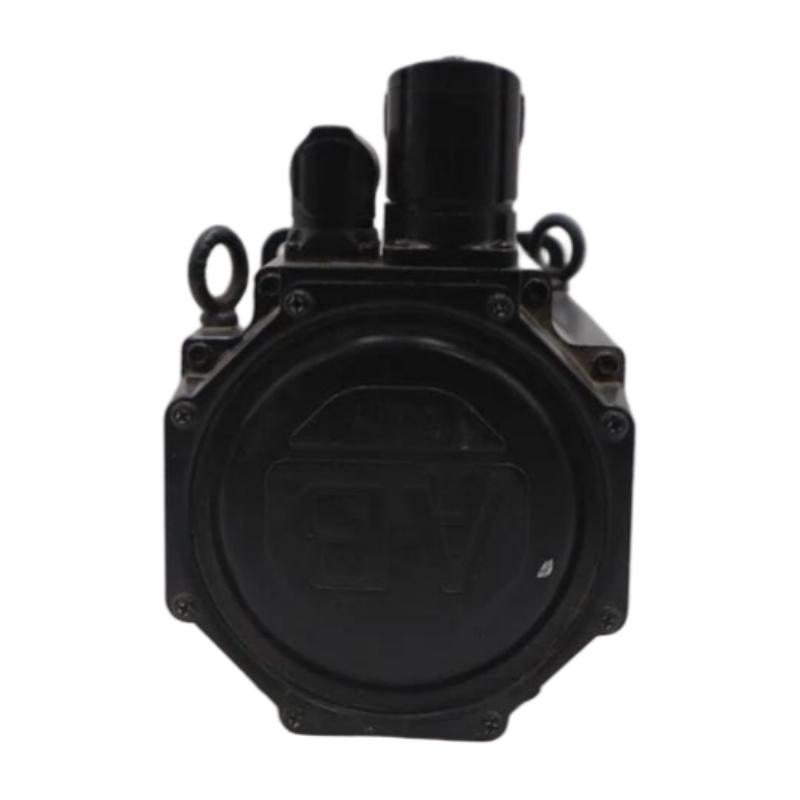
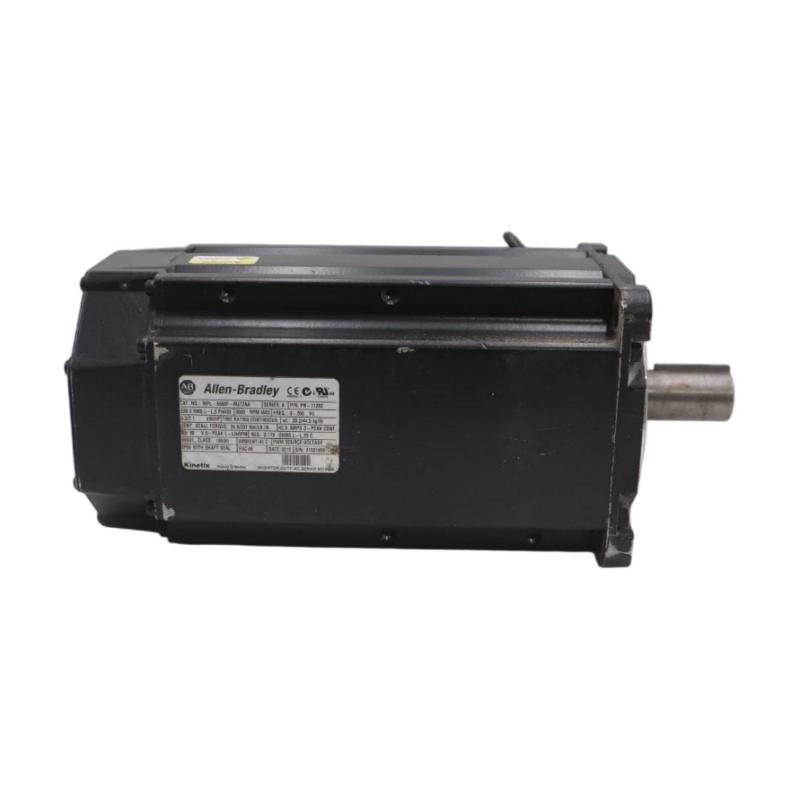
- Allen Bradley
- MPL-A560F-MJ72AA
- Servo Motor
- USA
- 165 mm
- 20.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 34
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
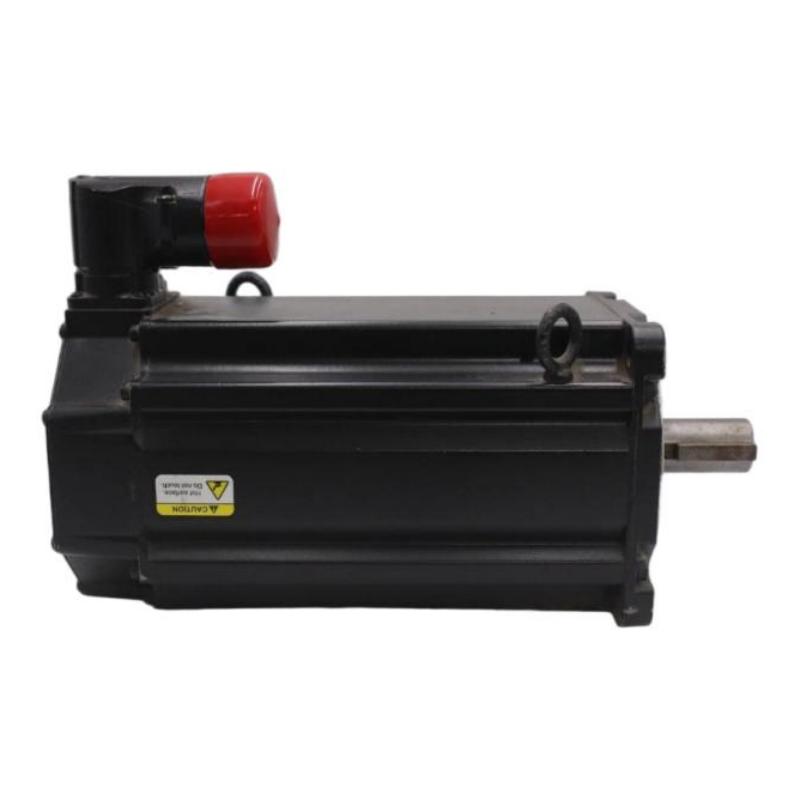
The Allen Bradley MPL-A560F-MJ72AA Servo Motor is an industrial servo motor designed for integration into automated motion-control systems. As part of the Allen Bradley MPL servo motor family, the MPL-A560F-MJ72AA is intended for machine applications where controlled movement, repeatable positioning, coordinated axis operation, and reliable dynamic performance are important.
The motor has a 165 mm frame size and a listed weight of 20.2 kg, providing a substantial mechanical platform for industrial machinery and automated production equipment. Its physical characteristics make correct machine-frame design, mounting, shaft alignment, cable routing, and handling important considerations during installation.
In a typical automation system, the servo motor works together with a compatible servo drive and motion controller. The controller generates the desired movement command, the servo drive regulates electrical power delivered to the motor, and the feedback system allows actual motor movement to be monitored as part of the closed-loop control process.
The MPL-A560F-MJ72AA can therefore be considered for applications involving machine positioning, coordinated motion, indexing, material handling, packaging, assembly, converting, and other industrial processes requiring controlled motor movement.
For engineering and replacement purposes, the complete MPL-A560F-MJ72AA catalog number should always be verified. Motor frame size alone is not sufficient to establish electrical or mechanical interchangeability.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Allen Bradley |
| Model | MPL-A560F-MJ72AA |
| Product Type | AC Servo Motor |
| Product Family | Allen Bradley MPL Servo Motor |
| Frame Size | 165 mm |
| Weight | 20.2 kg |
| Application | Industrial Motion Control |
| Control Architecture | Servo Drive and Motion Controller |
| Feedback | Compatible feedback system required |
| Installation | Machine-mounted |
| Typical Applications | Industrial Automation, Packaging, Assembly, Material Handling, Machine Motion |
The exact electrical and mechanical specifications of an individual servo motor should be verified against its nameplate and applicable documentation before installation. Parameters such as rated torque, peak torque, rated speed, winding characteristics, feedback technology, shaft dimensions, mounting pattern, connector configuration, brake configuration, and environmental ratings should not be assumed solely from the model family or frame size.
Understanding the MPL-A560F-MJ72AA
The MPL-A560F-MJ72AA is intended to operate as part of a closed-loop servo system rather than as an independent general-purpose motor.
A conventional motor may primarily be controlled for continuous rotation, while a servo motor is typically integrated into a control architecture in which the machine needs more precise control over movement.
The basic system can be represented as:
Motion Controller → Servo Drive → MPL-A560F-MJ72AA → Mechanical Load
Feedback from the motor returns to the control system, allowing actual motion to be compared with the commanded movement.
This architecture enables the machine to coordinate motor movement with other machine functions. Depending on the overall automation configuration, the servo system may be used for positioning, speed regulation, synchronized movement, indexing, or other controlled motion functions.
The 165 mm frame size and 20.2 kg weight should be considered when designing the mechanical support structure and planning installation procedures.
Servo Motor Operating Principle
The MPL-A560F-MJ72AA converts electrical energy supplied by a compatible servo drive into controlled mechanical rotation.
The servo drive receives commands from the motion controller and regulates the electrical output applied to the motor. Feedback information is used by the control system to monitor motor behavior.
During operation, the system can continuously evaluate the relationship between commanded and actual motion.
A typical servo control process involves:
- The controller generates a motion command.
- The servo drive receives the command.
- The drive regulates motor current and voltage according to the control requirements.
- The motor produces mechanical rotation.
- Feedback provides information about actual motor movement.
- The control system evaluates the motion response.
- Corrections are made when necessary.
This closed-loop process is fundamental to automated positioning and coordinated machine motion.
Role in Industrial Motion Control
The MPL-A560F-MJ72AA can serve as the actuator for a machine axis.
A complete industrial servo system normally contains several interconnected elements:
- Motion controller
- Servo drive
- Servo motor
- Feedback system
- Motor power cable
- Feedback cable
- Mechanical coupling
- Gearbox or transmission where applicable
- Machine load
- Safety system
The servo motor is only one part of this architecture. Reliable operation depends on correct compatibility between all components.
For example, in an automated packaging machine, a servo axis may be responsible for positioning a product or material before another machine operation occurs. The controller determines the required movement while the drive controls the motor to execute the motion.
The feedback system provides information that allows the motion controller or drive to maintain the required movement profile.
Industrial Applications
Packaging Equipment
Servo motors are widely used in packaging machinery where machine axes must repeatedly accelerate, decelerate, stop, and reposition.
The MPL-A560F-MJ72AA can be considered for applications such as:
- Product positioning
- Indexing
- Feeding
- Cutting
- Sealing
- Material synchronization
The exact suitability depends on the mechanical load and servo-system configuration.
Material Handling
Automated material-handling equipment can use servo motors for controlled movement of conveyors, transfer mechanisms, positioning systems, and machine axes.
Assembly Systems
Automated assembly equipment often requires repeatable positioning. Servo-based motion control can coordinate mechanical movement with sensors, tooling, and production sequences.
Machine Tools
Machine tools may use servo motors for controlled axis movement. Proper sizing requires analysis of machine inertia, load, acceleration, mechanical transmission, and required positioning performance.
Printing and Converting Machinery
Printing and converting systems frequently require synchronized movement between multiple mechanical sections. Servo control can help coordinate rollers, feeders, cutters, and other moving elements.
General Industrial Automation
The motor can also form part of automated production equipment where controlled rotational motion is required.
Mechanical Integration
Mechanical integration is an important consideration for a motor with a 165 mm frame size and 20.2 kg weight.
Before installing the MPL-A560F-MJ72AA, engineers should verify the complete mechanical interface.
Important considerations include:
- Motor mounting arrangement
- Available installation space
- Shaft alignment
- Coupling compatibility
- Mechanical load
- Radial load
- Axial load
- Machine-frame rigidity
- Cable clearance
- Cooling conditions
- Service accessibility
The machine structure must be able to support the motor securely during normal operation.
Dynamic forces can also occur when the motor accelerates, decelerates, reverses direction, or experiences changes in mechanical load. Therefore, mechanical support should not be designed solely around the static motor weight.
Servo Drive Compatibility
The MPL-A560F-MJ72AA should be connected to a compatible Allen Bradley servo drive.
Drive selection should be based on the complete motor and machine requirements rather than simply matching the frame size.
Before commissioning, verify:
- Complete motor catalog number
- Drive compatibility
- Feedback compatibility
- Motor power connections
- Feedback connections
- Grounding
- Control-network configuration
- Motor configuration parameters
- Mechanical load
- Motion profile
Incorrect motor configuration can result in drive faults, unexpected motion, or poor positioning performance.
Feedback and Closed-Loop Operation
Servo systems rely on feedback to monitor motor behavior.
The control system generates a commanded position, speed, or motion profile. The actual motor response is then monitored through the compatible feedback system.
The difference between commanded and actual motion can be evaluated by the servo control system.
This closed-loop architecture helps the machine respond to changing conditions such as:
- Variable mechanical load
- Acceleration
- Deceleration
- Position changes
- Speed changes
- Machine synchronization requirements
The exact feedback technology and electrical characteristics for the MPL-A560F-MJ72AA should be verified for the specific motor configuration rather than inferred from the general MPL product family.
Installation Guidelines
Verify the Product Identification
Before installation, confirm that the motor nameplate identifies:
Allen Bradley MPL-A560F-MJ72AA
The complete catalog number should be recorded for maintenance and replacement purposes.
Inspect the Motor
Inspect the motor housing, mounting surfaces, shaft, connectors, and cables.
Look for:
- Mechanical damage
- Cracks
- Connector damage
- Cable damage
- Contamination
- Signs of impact
- Abnormal shaft condition
Prepare the Machine Mount
The mounting structure should be rigid and correctly aligned.
A poor mounting surface can increase vibration and mechanical stress.
Install the Motor Securely
The motor should be installed using the appropriate mounting hardware and machine-specific procedures.
Because the listed weight is 20.2 kg, suitable handling and lifting procedures should be used during installation.
Connect Motor Power
Connect the motor power wiring according to the compatible servo drive and motor configuration.
Connect Feedback
The feedback connection should be checked carefully. A loose or incorrect feedback connection can prevent normal servo operation.
Verify Grounding
Protective grounding should be correctly established according to the machine’s electrical design.
Check Shaft Alignment
The motor shaft and driven mechanism should be aligned correctly.
Misalignment can result in increased bearing loads, vibration, coupling wear, and reduced mechanical life.
Commissioning Procedure
A controlled commissioning sequence can reduce the risk of unexpected machine movement.
Step 1: Confirm Installation
Verify motor mounting, shaft coupling, cable connections, grounding, and mechanical clearances.
Step 2: Verify Drive Configuration
Confirm that the servo drive is configured for the correct motor.
Step 3: Check Feedback
Confirm that the drive recognizes the motor feedback correctly.
Step 4: Check Machine Safety
Verify that machine safety functions and emergency stopping arrangements are operational before enabling motion.
Step 5: Perform a Low-Speed Test
Where appropriate, perform an initial controlled movement at reduced speed.
Step 6: Verify Rotation Direction
Confirm that motor movement corresponds to the intended machine direction.
Step 7: Test Positioning
Check the commanded and actual positions.
Step 8: Introduce Normal Load
Gradually test the motor under normal machine operating conditions.
During commissioning, engineers can monitor:
- Position error
- Following error
- Drive status
- Motor current
- Speed
- Temperature
- Vibration
- Abnormal noise
- Fault messages
Troubleshooting the MPL-A560F-MJ72AA
Troubleshooting should begin with the complete servo system rather than immediately assuming that the motor is defective.
Motor Does Not Move
Possible causes include:
- Servo drive disabled
- Incorrect motor configuration
- Feedback fault
- Power connection problem
- Drive fault
- Mechanical obstruction
- Incorrect motion command
Check the drive status and fault information before replacing the motor.
Motor Moves Unexpectedly
Unexpected movement can result from incorrect control parameters, axis configuration, command signals, feedback configuration, or machine-control logic.
The machine should be placed in a safe state before investigating unexpected motion.
Positioning Accuracy Is Poor
Potential causes include:
- Mechanical backlash
- Coupling problems
- Mechanical misalignment
- Incorrect tuning
- Excessive load
- Feedback problems
- Incorrect motion-profile settings
The mechanical and electrical portions of the system should both be examined.
Excessive Vibration
Possible causes include:
- Loose mounting
- Mechanical misalignment
- Coupling problems
- Incorrect tuning
- Mechanical resonance
- Excessive load
- Bearing-related problems
A mechanical inspection should be performed before determining that the motor itself has failed.
Motor Overheats
Possible causes include:
- Excessive load
- High duty cycle
- Insufficient cooling
- Mechanical friction
- Incorrect drive configuration
- Installation conditions outside the intended operating range
The motor’s actual operating conditions should be compared with the requirements of the specific application.
Intermittent Servo Faults
Intermittent faults may result from:
- Loose connectors
- Damaged feedback cable
- Damaged power cable
- Electrical interference
- Mechanical vibration
- Drive problems
- Feedback communication problems
Cable routing and connector integrity should be checked carefully.
Preventive Maintenance
Preventive maintenance should address both the motor and the complete motion-control system.
Mechanical Inspection
Inspect the:
- Motor mounting
- Shaft coupling
- Mechanical transmission
- Machine frame
- Fasteners
- Mechanical alignment
Electrical Inspection
Check:
- Motor cables
- Feedback cables
- Connectors
- Grounding
- Cable routing
- Signs of insulation damage
Operating Monitoring
Monitor changes in:
- Motor temperature
- Vibration
- Noise
- Position error
- Current demand
- Servo fault frequency
A gradual change in operating behavior may indicate developing mechanical or electrical problems.
Servo System Optimization
Good servo performance depends on more than the motor itself.
The machine should be evaluated as an integrated system.
Important optimization factors include:
Mechanical Rigidity
A rigid mechanical structure can help reduce unwanted vibration and positioning errors.
Load Matching
The motor and drive should be appropriately matched to the mechanical load.
Motion Profile
Acceleration and deceleration should be configured according to the mechanical characteristics of the machine.
Servo Tuning
Servo-loop tuning should be performed carefully to achieve an appropriate balance between response and stability.
Cable Management
Power and feedback cables should be routed appropriately to reduce mechanical stress and electrical interference.
Preventive Maintenance
Regular inspection can help maintain stable motion performance over the machine’s operating life.
Replacement and Compatibility Considerations
When replacing an existing motor with the MPL-A560F-MJ72AA, the complete catalog number should be checked.
The following should be verified:
- Full motor model
- Frame size
- Weight
- Motor mounting
- Shaft configuration
- Feedback arrangement
- Servo drive compatibility
- Cable compatibility
- Mechanical load
- Machine controller configuration
The 165 mm frame size provides an important mechanical reference, while the 20.2 kg weight should be considered for mounting and handling.
A motor with a similar appearance should not automatically be treated as a replacement. Even motors belonging to the same family can have different electrical, feedback, mechanical, or application characteristics.
Compatible Motion-Control Architecture
The MPL-A560F-MJ72AA can form part of an Allen Bradley-based motion-control system incorporating compatible:
- Servo drives
- Motion controllers
- PLC systems
- Industrial communication networks
- Feedback interfaces
- Motor power cables
- Feedback cables
- Mechanical transmissions
- Couplings
- Safety systems
- Human-machine interfaces
In multi-axis machines, several servo motors can operate together under coordinated control.
The controller can assign different motion profiles to individual axes while maintaining synchronization between mechanical operations.
Physical Dimensions and Weight
The most important physical values provided for the Allen Bradley MPL-A560F-MJ72AA are:
| Physical Parameter | Value |
|---|---|
| Frame Size | 165 mm |
| Weight | 20.2 kg |
These values are useful for machine layout, installation planning, replacement logistics, mechanical support, and handling procedures.
Frame size should not be treated as a substitute for a complete mechanical drawing. Before fabrication or replacement, engineers should verify the exact mounting-hole pattern, shaft dimensions, overall motor envelope, connector locations, and required service clearances.
Key Product Characteristics
The MPL-A560F-MJ72AA provides several characteristics relevant to industrial motion applications:
- Allen Bradley MPL servo motor design
- 165 mm frame size
- 20.2 kg listed weight
- Designed for closed-loop motion-control applications
- Suitable for integration with compatible servo drives
- Appropriate for automated machine axes
- Suitable for coordinated industrial motion
- Applicable to packaging and material-handling systems
- Suitable for assembly and production machinery
- Supports integration into multi-axis automation architectures
Technical FAQs
What is the Allen Bradley MPL-A560F-MJ72AA?
The Allen Bradley MPL-A560F-MJ72AA is an industrial AC servo motor designed for use in compatible closed-loop motion-control systems.
What is the frame size?
The specified frame size is 165 mm.
What is the weight of the MPL-A560F-MJ72AA?
The specified weight is 20.2 kg.
What is the purpose of this servo motor?
The motor converts controlled electrical energy from a compatible servo drive into mechanical motion for an automated machine axis.
What systems can use the MPL-A560F-MJ72AA?
It can be integrated into compatible industrial automation systems such as packaging machines, assembly equipment, material-handling systems, machine tools, converting machinery, and other controlled-motion applications.
Does frame size determine compatibility?
No. Frame size is only one mechanical reference. Complete electrical, feedback, mounting, shaft, connector, drive, and machine-load requirements must also be checked.
What should be checked when replacing the motor?
Verify the complete catalog number, servo-drive compatibility, feedback arrangement, mounting configuration, shaft interface, cable configuration, machine load, and control-system parameters.
What can cause servo motor vibration?
Vibration can be associated with mechanical misalignment, loose mounting, coupling problems, mechanical resonance, excessive load, incorrect servo tuning, or other machine-level issues.
Why is feedback important?
Feedback allows the servo system to compare commanded movement with actual motor behavior. This is essential for closed-loop position and motion control.
How should a 20.2 kg servo motor be handled during installation?
Appropriate mechanical handling and lifting procedures should be used. The machine mounting structure should also be designed to safely support the motor and the dynamic forces associated with operation.
Conclusion
The Allen Bradley MPL-A560F-MJ72AA Servo Motor is an industrial motion-control component intended for integration into compatible servo drive and automation architectures. Its specified 165 mm frame size and 20.2 kg weight make mechanical installation, structural support, shaft alignment, and handling important aspects of system design.
In a complete motion-control application, the MPL-A560F-MJ72AA works together with a servo drive, motion controller, feedback system, mechanical transmission, and machine safety architecture. Proper compatibility between these components is essential for reliable positioning, coordinated motion, and stable machine operation.
For new installations and replacement projects, the complete MPL-A560F-MJ72AA catalog number should be verified before procurement and commissioning. Engineers should also confirm the exact electrical, feedback, mechanical, and environmental characteristics applicable to the specific motor configuration rather than relying only on the shared MPL family characteristics.
With appropriate system matching, installation, commissioning, and preventive maintenance, the MPL-A560F-MJ72AA can serve as a key actuator within industrial automated motion systems requiring controlled and repeatable machine movement.