ProductPRODUCT
Featured products
Contact Us
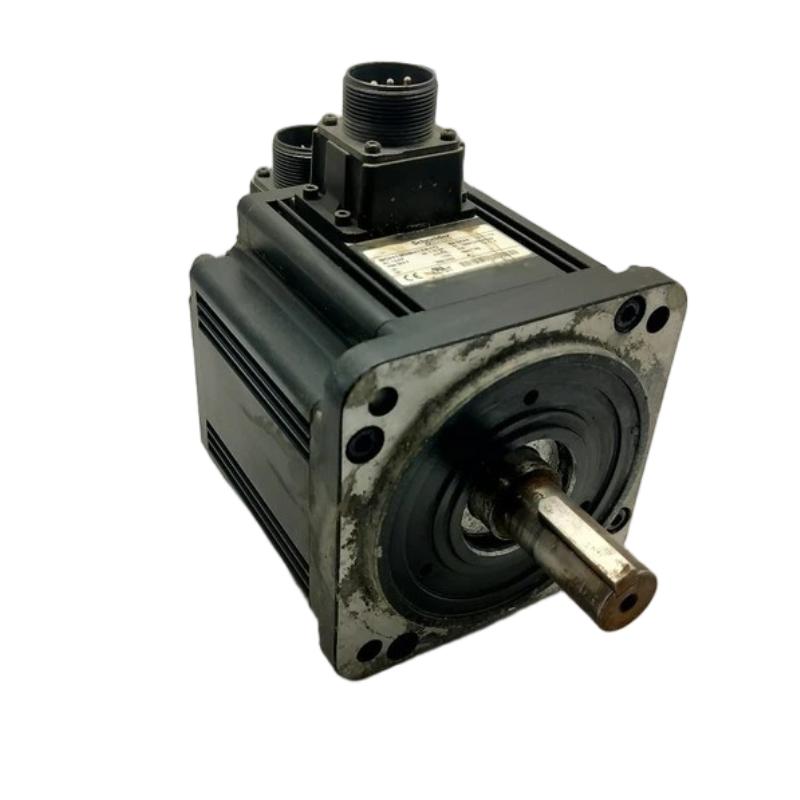
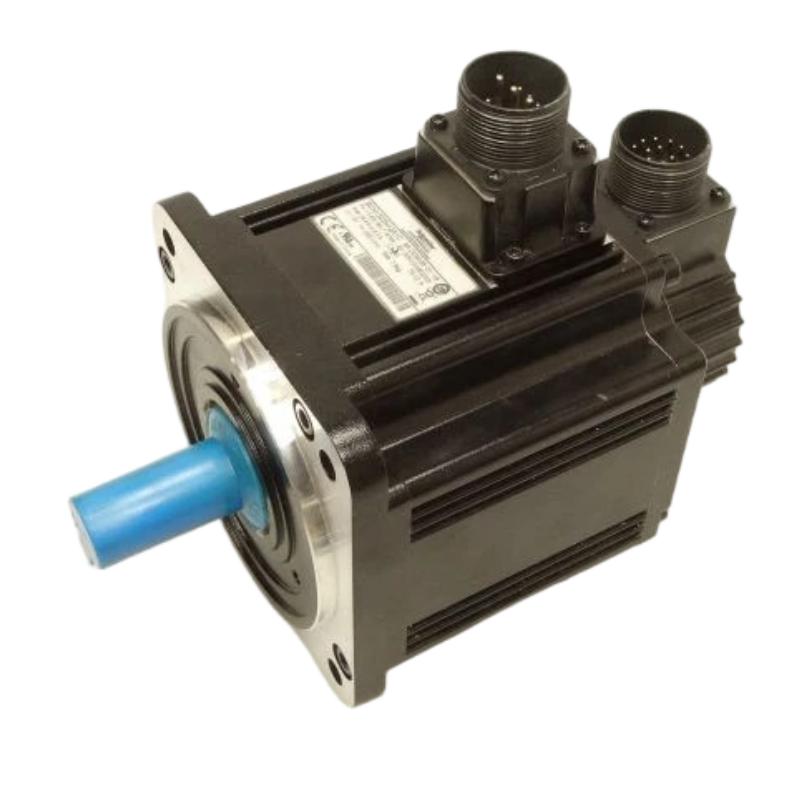
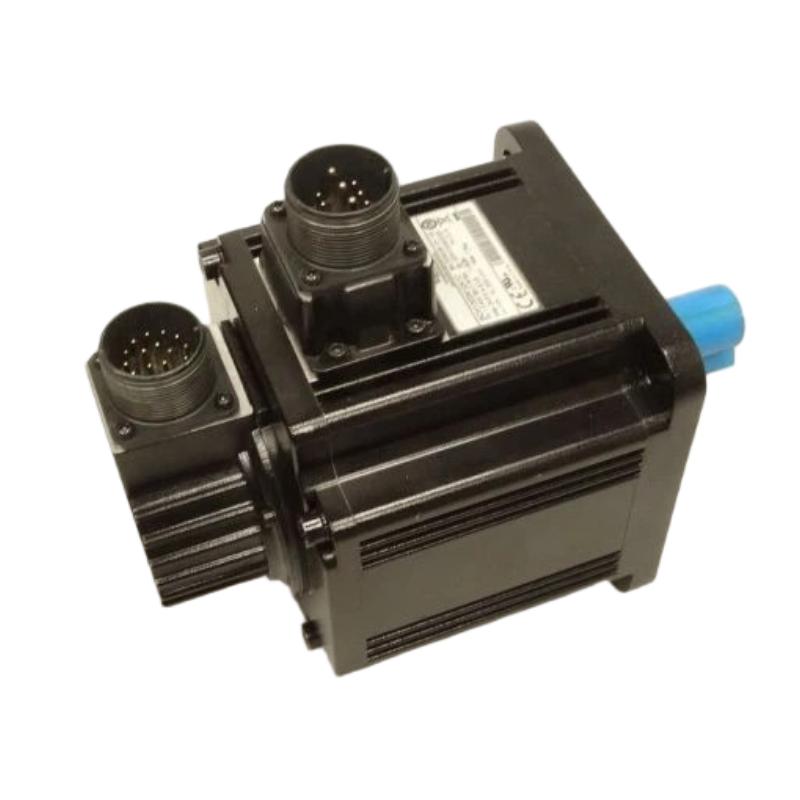
- Schneider
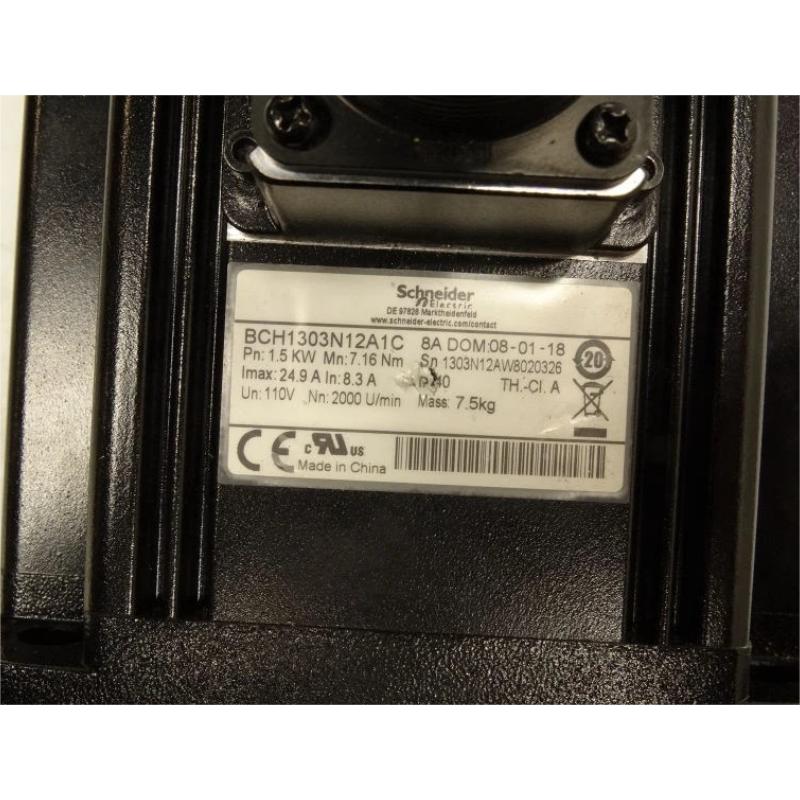
- BCH1303N12A1C
- Servo Motor
- France
- 167.5 mm
- 7.5 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 7
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
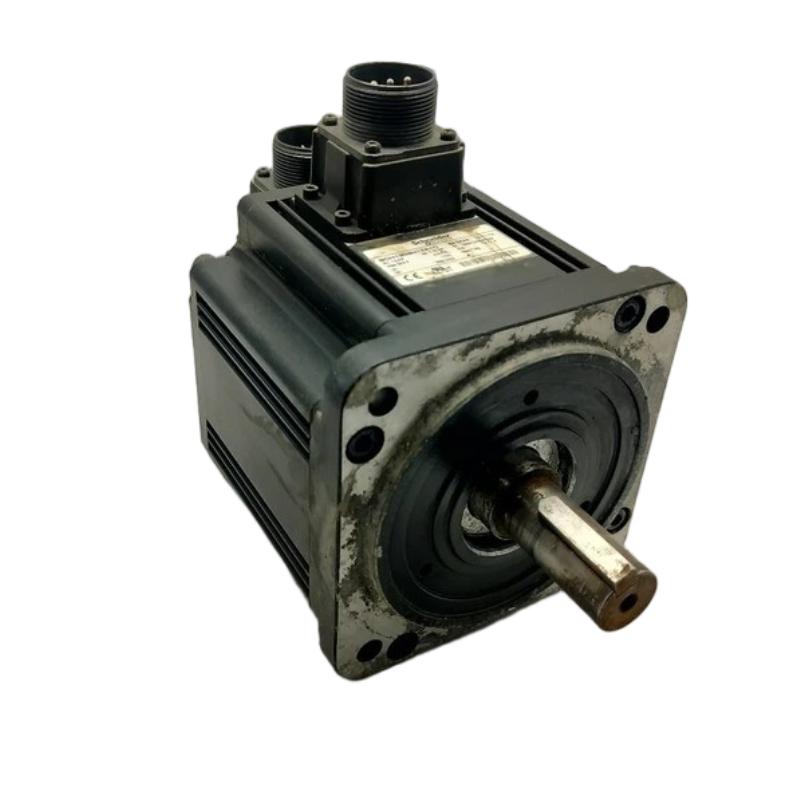
The Schneider BCH1303N12A1C Servo Motor is an industrial AC servo motor designed for precision motion-control applications where accurate positioning, controlled speed, repeatable movement, and coordinated machine operation are required. As part of Schneider Electric’s servo motor product family, the BCH1303N12A1C can be integrated with a compatible Schneider servo drive and motion-control system to create a closed-loop motor-control architecture.
Servo motors are widely used in industrial automation because they provide substantially more control information than conventional open-loop motors. A servo system continuously monitors motor feedback and compares actual motor behavior with the commanded position, speed, or motion profile. The controller can then adjust the drive output to reduce motion error and maintain the required operating condition.
The BCH1303N12A1C is particularly suitable for automated machinery requiring controlled rotary motion. Depending on the complete machine configuration, servo motor systems can be used for positioning, indexing, synchronized movement, acceleration and deceleration control, and repetitive production operations.
The supplied physical specifications for this model are a length of 167.5 mm and a weight of 7.5 kg. These parameters are useful when planning machine installation, mechanical integration, replacement, transportation, and spare-parts storage.
Exact electrical and performance characteristics such as rated power, rated voltage, rated torque, maximum speed, encoder configuration, shaft dimensions, mounting pattern, brake configuration, and connector arrangement should be verified against the applicable Schneider Electric documentation and the specific motor nameplate before installation.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | BCH1303N12A1C |
| Product Type | AC Servo Motor |
| Product Family | Schneider Electric BCH Servo Motor |
| Motor Technology | Industrial Servo Motor |
| Control Method | Closed-Loop Servo Control |
| Application | Precision Industrial Motion Control |
| Motor Length | 167.5 mm |
| Weight | 7.5 kg |
| Installation | Machine-Mounted Servo Application |
| Typical System | Servo Motor + Servo Drive + Motion Controller |
| Typical Applications | Positioning, Indexing, Automation Machinery, Material Handling, Packaging and Motion Systems |
The physical dimensions and weight listed above are based on the supplied product information. Other mechanical and electrical specifications should be confirmed for the exact BCH1303N12A1C configuration before engineering or replacement work.
What Is the Schneider BCH1303N12A1C?
The Schneider BCH1303N12A1C is a servo motor intended to provide controlled rotary motion in industrial automation equipment.
Unlike a conventional motor that may operate primarily according to an applied voltage and frequency, a servo motor normally operates as part of a complete feedback-controlled motion system.
A typical servo system can be represented as:
Motion Controller → Servo Drive → BCH1303N12A1C Servo Motor → Mechanical Load → Feedback → Servo Drive
The controller generates a motion command. The servo drive processes this command and supplies the appropriate electrical output to the motor. Feedback from the motor is used by the control system to determine actual motor position or speed.
This closed-loop architecture allows the machine to continuously compare commanded and actual motion.
The BCH1303N12A1C therefore should not be considered as an isolated motor component. Its correct operation depends on compatibility with the associated servo drive, feedback system, controller, mechanical load, wiring, and machine configuration.
Servo Motor Working Principle
The BCH1303N12A1C operates as part of a closed-loop motion-control system.
The general operating sequence is:
1. Motion Command
A PLC, motion controller, CNC controller, or other automation controller generates a command based on the machine sequence.
The command may represent a target position, speed, direction, acceleration, or coordinated movement.
2. Servo Drive Processing
The servo drive receives the command and determines the electrical output required by the motor.
The drive manages motor operation according to the configured motion parameters and feedback information.
3. Motor Rotation
The BCH1303N12A1C converts electrical energy into controlled mechanical rotation.
The motor shaft drives the connected mechanical mechanism, which may include a gearbox, belt, screw mechanism, coupling, pulley, or other machine component.
4. Feedback
The motor feedback system provides information about actual motor movement.
The servo drive uses this information to compare actual operation with the commanded motion.
5. Error Correction
If the actual movement differs from the commanded movement, the control system can modify motor operation to reduce the error.
This feedback process is one of the fundamental advantages of servo technology.
Role in Industrial Automation
Servo motors are important in applications where conventional motor control cannot provide the required positioning accuracy or dynamic response.
The BCH1303N12A1C can form part of a machine motion system responsible for:
- Precision positioning
- Rotary movement
- Indexing
- Repetitive motion
- Speed regulation
- Acceleration and deceleration
- Electronic synchronization
- Coordinated multi-axis movement
- Automated production sequences
A typical industrial control architecture may include a Schneider PLC or motion controller, servo drive, BCH servo motor, HMI, sensors, and machine-level mechanical components.
The controller determines what the machine should do, while the servo drive and motor execute the required motion.
Industrial Applications
Packaging Machinery
Servo motors are widely used in packaging equipment requiring controlled movement of conveyors, cutters, feeders, sealing mechanisms, and positioning systems.
The closed-loop architecture allows machine movement to be synchronized with the production sequence.
Material Handling
Automated material-handling equipment can use servo motors for controlled positioning of mechanical assemblies.
Typical applications include transfer mechanisms, indexing systems, lifting mechanisms, and automated handling equipment.
Conveyor Systems
Servo control can be used when conveyor speed and positioning must be coordinated with other machine functions.
The motor can participate in synchronized movement rather than simply operating continuously at a fixed speed.
Assembly Machinery
Automated assembly systems often require repeatable positioning of components and tools.
Servo motors can provide controlled motion for positioning mechanisms, rotary tables, and automated assembly stations.
Printing and Converting Equipment
Printing and converting machinery can require coordinated movement between multiple rotating or linear mechanisms.
Servo systems provide the feedback-based control necessary for synchronization.
Textile Machinery
Textile equipment frequently contains multiple moving mechanisms that must operate at controlled speeds and synchronized positions.
Servo motors can be incorporated into these systems to provide accurate motion control.
Robotics and Automated Machinery
Servo motors are fundamental components in many automated machines and robotic mechanisms.
The BCH1303N12A1C can be considered for machine architectures where precise rotary movement is required, provided that the complete motor and drive configuration is correctly matched.
Servo Motion-Control Architecture
A typical Schneider industrial servo system can be organized into several functional layers.
| System Component | Primary Function |
|---|---|
| PLC / Motion Controller | Generates machine and motion commands |
| Servo Drive | Controls motor electrical output |
| BCH1303N12A1C | Converts electrical energy into mechanical motion |
| Feedback System | Reports motor operating information |
| Mechanical Transmission | Transfers motor torque to the machine |
| Sensors | Detect machine conditions and positions |
| HMI | Provides operator control and monitoring |
| Industrial Network | Transfers commands and diagnostic information |
The exact architecture depends on the machine design.
For multi-axis applications, several servo axes may operate together under the control of a central motion controller. Synchronization between axes can be important for applications such as electronic gearing, coordinated positioning, and automated production sequences.
Mechanical Installation
Correct mechanical installation is essential for reliable servo motor operation.
Before installing the BCH1303N12A1C, engineers and technicians should verify the mechanical interface between the motor and machine.
Important considerations include:
- Motor mounting arrangement
- Shaft compatibility
- Coupling selection
- Mechanical alignment
- Load inertia
- Radial loading
- Axial loading
- Mounting rigidity
- Cable routing
- Motor orientation
- Available installation space
The supplied motor length is 167.5 mm, while the supplied weight is 7.5 kg.
The machine structure should be capable of safely supporting the motor and the mechanical forces generated during operation.
A rigid mounting arrangement helps reduce vibration and unwanted mechanical movement.
Servo Drive Integration
The BCH1303N12A1C should be connected to a compatible servo drive selected according to the complete motor configuration.
Before commissioning, technicians should verify:
- Motor model
- Servo drive compatibility
- Motor feedback compatibility
- Power wiring
- Feedback wiring
- Motor cable configuration
- Grounding
- Connector arrangement
- Brake configuration, if applicable
- Controller configuration
- Drive parameter settings
The motor and drive should be treated as a matched control system rather than independent components.
Using an incorrect drive configuration can cause poor performance, drive alarms, abnormal current, excessive vibration, or failure to complete the intended motion.
Electrical and Feedback Connections
Servo systems normally contain several important connection groups.
Motor Power
The motor power connection transfers electrical energy from the servo drive to the motor.
Correct wiring and connector engagement are essential for reliable operation.
Feedback Connection
The feedback circuit allows the servo drive to monitor motor operation.
A damaged or incorrectly connected feedback cable can result in position errors, drive alarms, unstable operation, or failure during startup.
Protective Grounding
Proper protective grounding is essential for personnel safety and electrical system reliability.
Grounding should follow the applicable Schneider Electric installation requirements and local electrical regulations.
Cable Routing
Motor power cables and sensitive feedback cables should be routed appropriately.
Separating feedback wiring from high-power switching conductors can help reduce electromagnetic interference.
Commissioning Procedure
A controlled commissioning process helps reduce the risk of mechanical or electrical problems.
Step 1: Verify the Motor
Confirm the complete BCH1303N12A1C model designation and inspect the motor for shipping or installation damage.
Check the supplied physical information:
- Length: 167.5 mm
- Weight: 7.5 kg
Step 2: Inspect Mechanical Installation
Verify that the motor is firmly mounted and properly aligned with the driven mechanism.
The coupling should be correctly installed without excessive mechanical stress.
Step 3: Check Wiring
Inspect all motor, feedback, grounding, and control connections.
Loose connectors can create intermittent faults and unstable operation.
Step 4: Confirm Servo Drive Configuration
Enter or select the correct motor information in the compatible servo drive.
The exact parameter procedure depends on the drive and control architecture.
Step 5: Perform Initial Testing
Initial testing should normally be performed at low speed or under controlled machine conditions.
Observe:
- Direction of rotation
- Motor noise
- Vibration
- Current behavior
- Position response
- Drive status
- Feedback operation
Step 6: Test Machine Motion
After basic motor operation has been verified, gradually test the required machine motion.
Acceleration, deceleration, positioning, and synchronization should be checked against the machine requirements.
Troubleshooting the BCH1303N12A1C
Servo motor troubleshooting should always consider the complete motion-control system.
Motor Does Not Rotate
Possible causes include:
- No drive output
- Incorrect drive configuration
- Missing enable command
- Feedback fault
- Incorrect motor wiring
- Controller command problem
- Drive protection state
- Mechanical obstruction
The servo drive diagnostic information should be checked before replacing the motor.
Servo Alarm During Startup
A startup alarm may be associated with:
- Feedback connection
- Incorrect motor configuration
- Wiring problems
- Drive parameter mismatch
- Mechanical problems
- Protective functions
The exact alarm code should be identified before attempting corrective action.
Excessive Vibration
Possible causes include:
- Mechanical misalignment
- Incorrect tuning
- Excessive load inertia
- Coupling problems
- Mechanical looseness
- Damaged bearings
- Incorrect motion parameters
Mechanical and control-system checks should be performed together.
Positioning Error
Positioning problems may result from:
- Incorrect controller parameters
- Feedback problems
- Mechanical backlash
- Excessive load
- Incorrect servo tuning
- Mechanical coupling problems
- Motion-profile configuration
The error should be analyzed from the controller through the drive and motor to the mechanical load.
Motor Overheating
Potential causes include:
- Excessive load
- Poor ventilation
- Continuous operation outside the intended operating conditions
- Mechanical resistance
- Incorrect drive configuration
- Excessive acceleration demands
The motor temperature and operating conditions should be evaluated before continued operation.
Preventive Maintenance
Servo motors generally require less routine mechanical maintenance than many conventional motor systems, but regular inspection remains important.
Inspect Mechanical Mounting
Check that mounting hardware remains secure and that no abnormal mechanical movement is present.
Inspect Couplings
Couplings should be inspected for wear, misalignment, looseness, and mechanical damage.
Check Cables
Motor and feedback cables should be inspected for:
- Cuts
- Abrasion
- Loose connectors
- Excessive bending
- Heat damage
- Moisture exposure
Monitor Motor Behavior
Unexpected changes in noise, vibration, temperature, or positioning performance can indicate developing problems.
Monitor Drive Diagnostics
Servo drive alarms and diagnostic information should be recorded and investigated rather than repeatedly reset without identifying the underlying cause.
Replacement Considerations
When replacing a Schneider BCH1303N12A1C Servo Motor, the complete model number should be checked carefully.
Do not select a replacement solely according to physical appearance.
Important verification points include:
- Complete motor model
- Motor family
- Electrical compatibility
- Servo drive compatibility
- Feedback configuration
- Mechanical mounting
- Shaft configuration
- Connector arrangement
- Brake configuration, if applicable
- Machine load requirements
- Control-system parameters
The supplied physical characteristics are:
Length: 167.5 mm
Weight: 7.5 kg
A motor with a similar appearance or similar physical dimensions may still have different electrical or feedback characteristics.
Physical Dimensions and Weight
The physical information supplied for the Schneider BCH1303N12A1C is summarized below.
| Physical Parameter | Value |
|---|---|
| Length | 167.5 mm |
| Weight | 7.5 kg |
These values can be useful for:
- Machine layout
- Replacement planning
- Cabinet and machine-space calculations
- Shipping preparation
- Spare-parts inventory
- Maintenance planning
- Equipment handling
Other dimensional information, such as shaft dimensions, flange dimensions, mounting-hole patterns, and connector positions, should be confirmed from the applicable mechanical documentation before fabrication or installation.
Engineering Best Practices
For reliable BCH1303N12A1C operation, several engineering practices should be followed.
Match the Complete Servo System
The motor should be matched with the appropriate servo drive, feedback system, and controller.
Minimize Mechanical Misalignment
Correct alignment reduces mechanical stress, vibration, and unnecessary bearing loading.
Protect Feedback Wiring
Feedback cables are important to closed-loop control and should be protected against mechanical damage and excessive electrical interference.
Configure the Drive Correctly
Incorrect motor parameters can negatively affect servo performance and may produce drive alarms.
Test Before Full-Speed Operation
Initial testing should be performed under controlled conditions before the machine is returned to full production.
Monitor Long-Term Performance
Changes in vibration, temperature, positioning accuracy, and drive alarms can provide useful indications of developing problems.
Compatible Automation Components
Depending on the machine architecture, the BCH1303N12A1C may be integrated with a wider Schneider Electric automation system containing:
- Schneider Electric servo drives
- Motion controllers
- Modicon PLCs
- Harmony HMI systems
- Industrial Ethernet networks
- Machine sensors
- Safety controllers
- Servo feedback systems
- Motor cables
- Industrial switching equipment
- Mechanical transmission systems
The exact compatible components should always be confirmed against the motor’s specific electrical and feedback configuration.
Recommended Related Schneider Servo Product Categories
| Product Category | Typical Role |
|---|---|
| Schneider BCH Servo Motors | Compact industrial servo motion |
| Schneider Lexium Servo Drives | Servo motor control |
| Schneider Lexium Motion Controllers | Coordinated motion control |
| Modicon PLCs | Machine sequencing and automation |
| Harmony HMIs | Operator interface and diagnostics |
| Schneider Industrial Networks | Controller and device communication |
| Servo Feedback Components | Closed-loop position and speed feedback |
These categories represent system-level components rather than direct replacement parts for the BCH1303N12A1C.
Key Advantages
Closed-Loop Motion Control
The servo architecture provides feedback-based control for precise and repeatable machine movement.
Industrial Automation Integration
The motor can be incorporated into PLC, motion-controller, servo-drive, and HMI-based automation systems.
Suitable for Precision Applications
Servo technology is appropriate for applications requiring controlled position, speed, acceleration, and coordinated movement.
Compact Mechanical Design
With a supplied length of 167.5 mm, the motor can be considered when machine installation space is an important engineering factor.
Robust Industrial Construction
The supplied weight of 7.5 kg reflects a substantial industrial motor assembly suitable for integration into automated machinery.
Flexible Machine Applications
Servo motor technology can be applied to packaging, material handling, assembly, indexing, conveying, and other automated motion systems.
Technical FAQs
What is the Schneider BCH1303N12A1C?
The Schneider BCH1303N12A1C is an industrial AC servo motor designed for integration into closed-loop motion-control systems.
What is the length of the BCH1303N12A1C?
The supplied motor length is 167.5 mm.
How much does the BCH1303N12A1C weigh?
The supplied weight is 7.5 kg.
What is the main purpose of a servo motor?
A servo motor provides controlled mechanical motion and is normally used with a servo drive and feedback system for accurate positioning, speed regulation, and coordinated machine movement.
Can the BCH1303N12A1C operate without a servo drive?
A servo motor is normally used as part of a compatible servo-control system. The appropriate drive and feedback configuration should be verified before installation.
What can cause a servo motor to produce abnormal vibration?
Potential causes include mechanical misalignment, coupling problems, excessive load, incorrect servo tuning, mechanical looseness, or motor-related issues.
What should be checked before replacing the BCH1303N12A1C?
The complete model number, servo-drive compatibility, feedback configuration, mechanical mounting, shaft arrangement, connectors, brake configuration if applicable, and machine requirements should be checked.
Are all BCH servo motors interchangeable?
No. Servo motors with similar physical characteristics may have different electrical, feedback, mechanical, or performance configurations. Exact model compatibility should be verified before replacement.
What applications can use the BCH1303N12A1C?
Potential applications include automated positioning equipment, packaging machinery, assembly systems, material handling, indexing equipment, conveyors, and other industrial motion-control systems where the complete servo configuration is suitable.
Conclusion
The Schneider BCH1303N12A1C Servo Motor is an industrial servo motor intended for closed-loop motion-control applications requiring accurate and repeatable mechanical movement. When combined with a compatible servo drive, feedback system, and motion controller, it can form an important part of a modern industrial automation architecture.
The supplied physical specifications are a length of 167.5 mm and a weight of 7.5 kg. These values are useful for machine integration, installation planning, replacement logistics, and spare-parts management.
For reliable operation, the BCH1303N12A1C should be selected and installed as part of a complete servo system. Mechanical alignment, correct wiring, feedback integrity, drive configuration, commissioning, and preventive maintenance all contribute to stable servo performance.
Before purchasing or replacing the motor, engineers should verify the complete BCH1303N12A1C model designation and confirm all required electrical, mechanical, feedback, and performance characteristics against the applicable equipment documentation.