ProductPRODUCT
Featured products
Contact Us
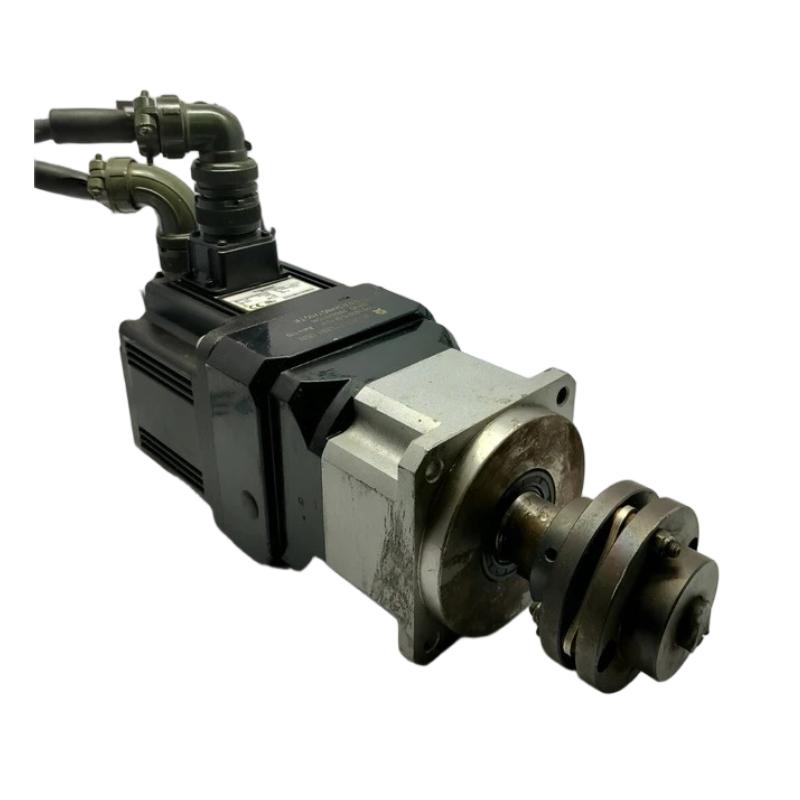
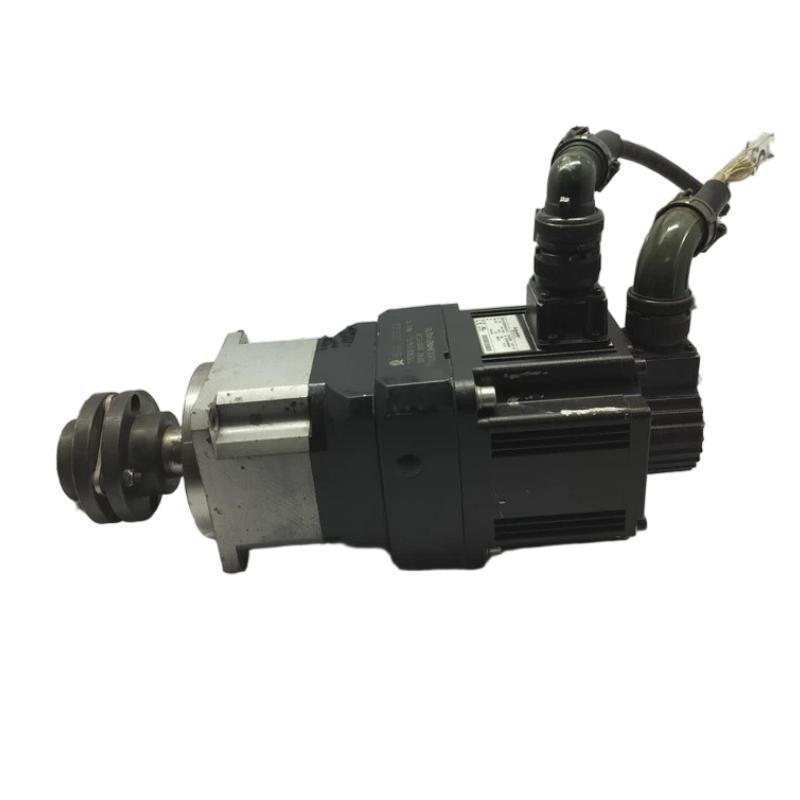
- Schneider
- BCH1302N32A1C
- Servo Motor
- France
- 147.5 mm
- 7 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
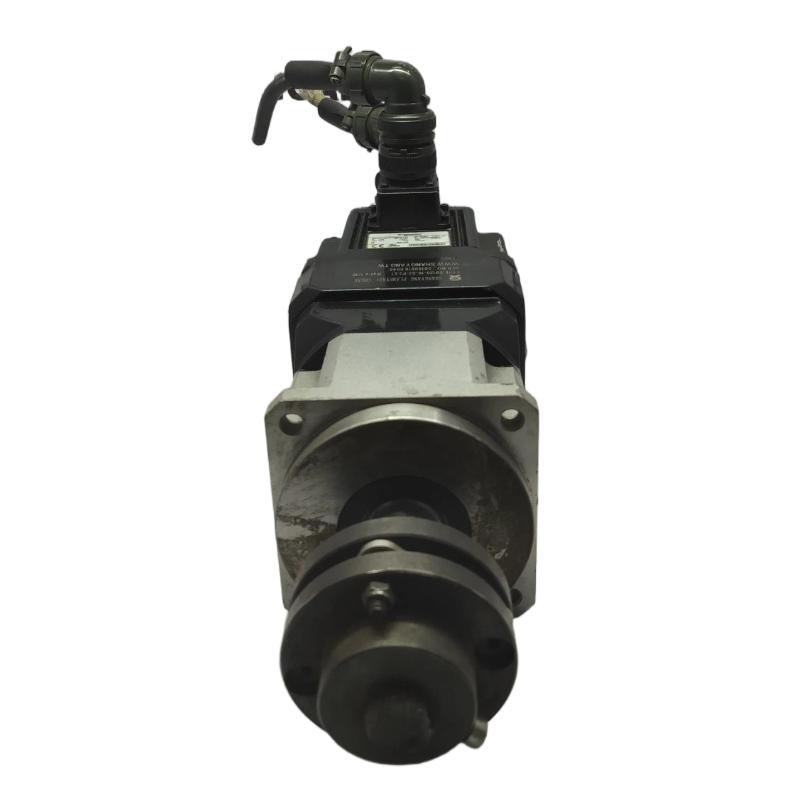
Product Overview
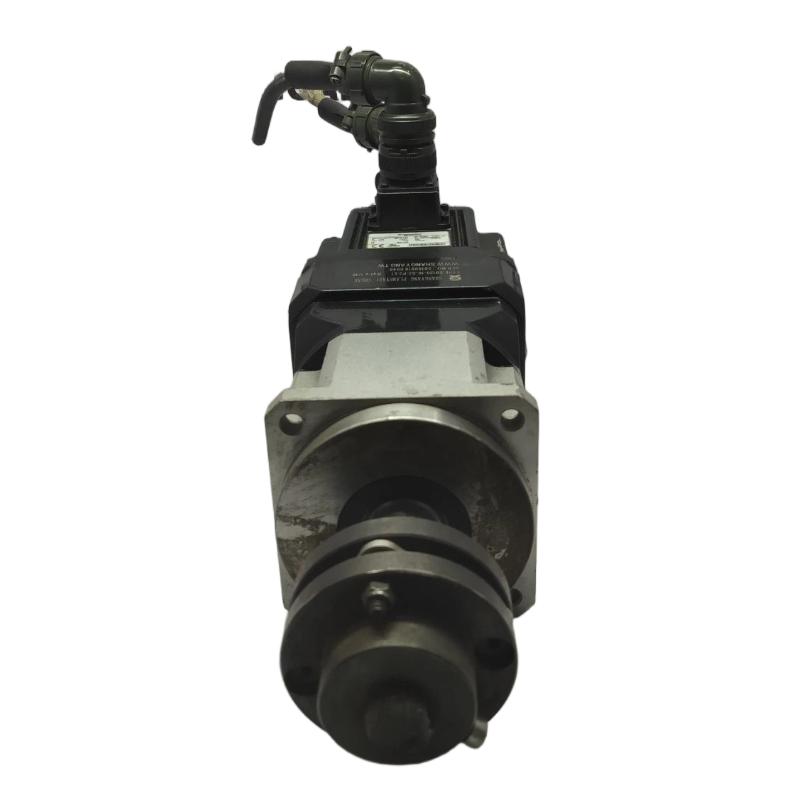
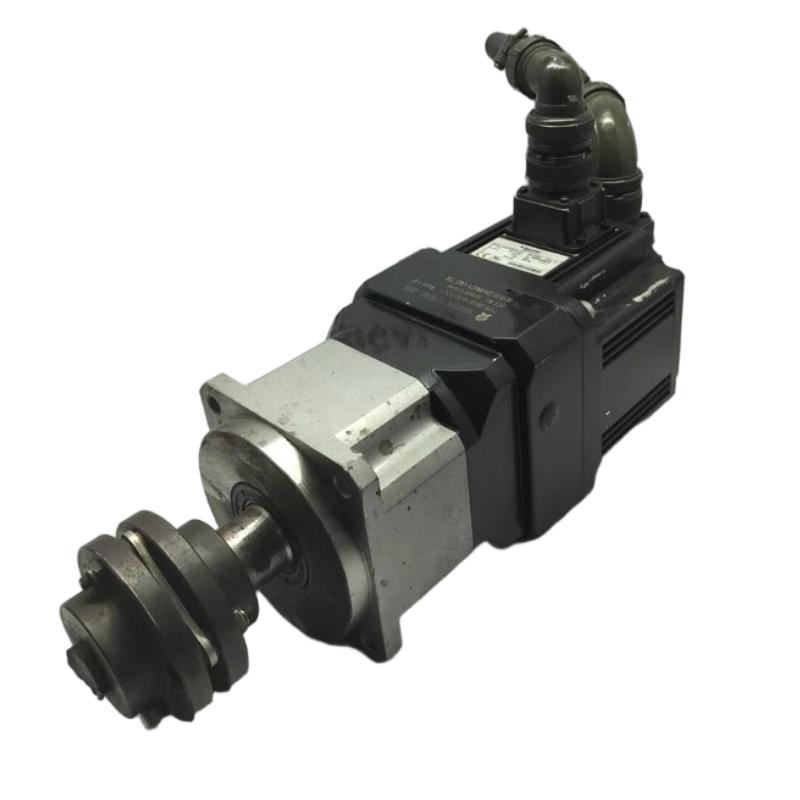
The Schneider Electric BCH1302N32A1C Servo Motor is an industrial servo motor designed for automated machinery requiring controlled rotary motion, repeatable positioning, and coordinated movement. As part of the Schneider Electric BCH servo motor family, the motor can be integrated with a compatible servo drive, motion controller, feedback system, and mechanical transmission to create a complete closed-loop motion-control system.
In industrial automation, servo motors are commonly used where machine movement must be accurately controlled rather than simply operated at a fixed speed. The controller establishes the required motion, the servo drive regulates the motor, and the feedback system provides information about actual motor behavior. This enables the control system to continuously adjust operation according to the programmed motion profile.
The BCH1302N32A1C has a supplied length of 147.5 mm and a weight of 7 kg. These physical parameters are useful for machine layout, mounting-space calculations, handling, transportation, spare-parts inventory, and replacement planning.
Exact electrical and performance specifications should be confirmed against the applicable Schneider Electric documentation and motor nameplate. Parameters such as rated power, rated torque, rated speed, maximum speed, feedback type, brake configuration, shaft dimensions, mounting arrangement, and connector specifications should not be assumed solely from the model number.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Schneider Electric |
| Model | BCH1302N32A1C |
| Product Type | Servo Motor |
| Product Family | BCH Servo Motor Series |
| Application | Industrial Motion Control |
| Control Architecture | Closed-Loop Servo System |
| Feedback | Compatible Servo Feedback System |
| Length | 147.5 mm |
| Weight | 7 kg |
| Installation | Machine-Mounted |
| Typical Applications | Industrial Automation, Positioning, Packaging, Assembly, Material Handling, Machine Tools |
Specification note: The length and weight above are the values supplied for the BCH1302N32A1C. Exact electrical, mechanical, feedback, and performance characteristics should be verified from the documentation applicable to the specific motor.
What Is the Schneider BCH1302N32A1C?
The Schneider BCH1302N32A1C is a servo motor designed to provide controlled mechanical rotation within an industrial motion-control system.
A servo motor normally operates as part of a larger automation architecture. The controller generates a movement command, the servo drive controls the electrical power supplied to the motor, and feedback information allows the system to monitor actual motor movement.
A simplified architecture can be represented as:
Motion Controller → Servo Drive → BCH1302N32A1C Servo Motor → Mechanical Load
The feedback path can be represented as:
Servo Motor → Feedback System → Servo Drive / Controller
This closed-loop arrangement enables controlled movement and allows the system to continuously respond to changes between commanded and actual motor conditions.
Servo Motor Working Principle
The BCH1302N32A1C operates as part of a closed-loop servo-control architecture.
The motion controller generates a command based on the machine program. Depending on the application, the command can define position, velocity, acceleration, or coordinated movement.
The servo drive processes this command and supplies controlled electrical power to the motor.
During operation, feedback information is returned to the servo drive. The drive compares the actual motor condition with the commanded condition and adjusts motor operation as necessary.
The general process is:
- The controller generates a motion command.
- The servo drive receives the command.
- Controlled electrical power is supplied to the motor.
- The motor produces mechanical rotation.
- Feedback information reports actual motor movement.
- The servo drive compares actual and commanded conditions.
- Control output is adjusted.
- The machine follows the programmed motion profile.
This continuous feedback process is fundamental to servo-based industrial motion control.
Role in Industrial Automation
The BCH1302N32A1C can serve as the motor element within a complete industrial automation system.
A typical servo-controlled machine may include:
- PLC or motion controller
- Servo drive
- BCH1302N32A1C servo motor
- Feedback system
- Motor power cable
- Feedback cable
- Mechanical coupling
- Gearbox
- Linear transmission
- Machine mechanism
- HMI
- Safety controller
- Industrial communication network
The motor converts electrical energy into mechanical movement, while the controller and servo drive determine how that movement is performed.
Correct matching of the motor, drive, feedback system, controller, and mechanical load is essential for reliable operation.
Industrial Applications
Packaging Machinery
Servo motors are commonly used in packaging equipment for indexing, feeding, cutting, sealing, and synchronized machine movement.
Material Handling
Servo-controlled systems can provide controlled movement for conveyors, transfer mechanisms, positioning systems, and automated handling equipment.
Assembly Automation
Servo motors can be used for repeatable positioning of tools, fixtures, components, feeders, and automated mechanisms.
Machine Tools
Servo systems are widely used in machine tools where controlled axis movement and coordinated positioning are required.
Robotics
Robotic mechanisms commonly rely on servo motors for controlled rotary movement.
Printing and Converting
Servo systems can coordinate rollers, material feeding, cutting, and positioning mechanisms.
Textile Machinery
Controlled servo movement can support material feeding, synchronization, positioning, and other automated textile operations.
General Industrial Automation
The BCH1302N32A1C can be considered for automated machinery requiring controlled rotary motion and repeatable machine movement.
Servo Motion-Control Architecture
A typical BCH1302N32A1C application can contain several functional layers.
| Component | Typical Function |
|---|---|
| PLC / Motion Controller | Generates motion commands |
| Servo Drive | Controls motor power and closed-loop operation |
| BCH1302N32A1C | Produces controlled rotary movement |
| Feedback System | Provides actual motor movement information |
| Mechanical Transmission | Transfers motor output to the machine |
| HMI | Operator control and monitoring |
| Safety System | Provides machine safety functions |
| Industrial Network | Transfers commands and status information |
The exact system architecture depends on the machine design and selected automation equipment.
Installation Guidelines
Proper installation is important for stable servo operation.
Before installing the BCH1302N32A1C, verify:
- Complete motor model
- Nameplate information
- Servo drive compatibility
- Feedback configuration
- Motor mounting arrangement
- Shaft and coupling requirements
- Power cable compatibility
- Feedback cable compatibility
- Connector arrangement
- Mechanical load
- Environmental conditions
- Available maintenance clearance
The supplied motor length is 147.5 mm, and the supplied weight is 7 kg.
These values should be included in machine layout and installation-handling calculations.
The actual installation envelope may be larger than the stated length because of shaft projection, connectors, cables, mounting hardware, and required service space.
Mechanical Installation
The BCH1302N32A1C should be securely mounted to an appropriate machine structure.
Alignment
The motor shaft should be correctly aligned with the driven mechanism. Misalignment can increase bearing loads and mechanical stress.
Coupling
The selected coupling should be suitable for the actual machine configuration and installed correctly.
Mechanical Load
The connected load should remain within the applicable motor and machine limitations.
Vibration
Excessive vibration may affect bearings, feedback components, connectors, couplings, and the mechanical transmission.
Clearance
Sufficient space should be maintained for cable routing, inspection, maintenance, and heat dissipation.
Exact shaft, flange, mounting-hole, and connector dimensions should be confirmed from the applicable technical documentation.
Servo Drive Integration
The BCH1302N32A1C should be paired with a compatible servo drive.
The servo drive controls electrical power supplied to the motor and processes the feedback required for closed-loop operation.
Before commissioning, verify:
- Motor-drive compatibility
- Motor identification
- Feedback compatibility
- Motor power connection
- Feedback connection
- Control interface
- Communication configuration
- Rotation direction
- Motion parameters
- Safety circuit status
Incorrect configuration can cause drive faults, unstable operation, excessive temperature, or feedback errors.
Commissioning Procedure
A controlled commissioning procedure helps reduce startup problems.
Step 1: Confirm Motor Identification
Verify that the installed motor is the correct BCH1302N32A1C model.
Step 2: Inspect Mechanical Installation
Check mounting hardware, shaft alignment, coupling condition, and mechanical clearance.
Step 3: Inspect Electrical Connections
Check motor power and feedback cables for damage, loose connections, excessive bending, and incorrect routing.
Step 4: Configure the Servo Drive
Configure the servo drive according to the applicable motor and feedback information.
Step 5: Verify Feedback
Confirm that valid feedback information is received by the servo drive.
Step 6: Perform Controlled Movement
Begin testing under controlled operating conditions.
Step 7: Verify Rotation Direction
Confirm that the motor rotates in the intended machine direction.
Step 8: Test Motion Parameters
Gradually test acceleration, deceleration, speed, and positioning functions.
Step 9: Monitor Diagnostics
Observe servo drive status, alarms, motor temperature, vibration, and abnormal noise.
Step 10: Verify Machine Operation
Confirm that the motor performs correctly under the intended machine operating conditions.
Troubleshooting the BCH1302N32A1C
Servo problems should be investigated across the complete motion-control system.
Motor Does Not Rotate
Possible causes include:
- Servo drive not enabled
- Active safety circuit
- Incorrect motor configuration
- Missing motor power
- Feedback fault
- Cable problem
- Loose connector
- Incorrect motion command
- Mechanical obstruction
Check the servo drive diagnostics before assuming that the motor itself has failed.
Servo Fault During Acceleration
Potential causes include:
- Excessive acceleration demand
- Excessive mechanical load
- Incorrect motor parameters
- Feedback problems
- Cable problems
- Servo tuning issues
- Mechanical resistance
A controlled low-speed test can help determine whether the issue is related to configuration, electrical connections, or mechanical loading.
Positioning Error
Potential causes include:
- Incorrect servo tuning
- Mechanical backlash
- Coupling problems
- Mechanical slippage
- Excessive load
- Feedback abnormalities
- Incorrect motion parameters
Both the electronic servo system and mechanical transmission should be checked.
Motor Overheating
Possible causes include:
- Excessive mechanical load
- High operating duty
- Poor heat dissipation
- Mechanical friction
- Incorrect configuration
- Unsuitable operating conditions
Actual operating conditions should be evaluated against the applicable motor specifications.
Excessive Noise or Vibration
Inspect:
- Motor mounting
- Shaft alignment
- Coupling
- Mechanical transmission
- Load condition
- Bearings
- Servo tuning
Mechanical problems should be corrected before making unnecessary control adjustments.
Preventive Maintenance
Regular maintenance can help maintain stable servo performance.
Inspect Motor Connections
Check power and feedback connectors for looseness, contamination, damage, and excessive cable strain.
Check Mechanical Couplings
Inspect coupling alignment and mounting condition during scheduled maintenance.
Monitor Temperature
Unexpected temperature increases can indicate excessive load, mechanical resistance, or insufficient heat dissipation.
Monitor Vibration
Changes in vibration can indicate mechanical wear, imbalance, misalignment, or bearing problems.
Review Servo Diagnostics
Drive alarms and diagnostic history can help identify developing problems.
Maintain a Suitable Environment
The motor and associated equipment should be operated under environmental conditions appropriate for the installation.
Replacement Considerations
When replacing a Schneider BCH1302N32A1C Servo Motor, the complete model designation should be verified.
Important identification information includes:
- Full motor model
- Nameplate data
- Motor family
- Feedback configuration
- Brake configuration, if applicable
- Shaft arrangement
- Mounting configuration
- Connector arrangement
- Compatible servo drive
- Machine load requirements
The supplied 147.5 mm length and 7 kg weight are useful for mechanical planning but cannot by themselves establish full compatibility.
A motor with similar physical dimensions may have different electrical, feedback, mechanical-interface, or performance characteristics.
Physical Dimensions and Weight
The supplied physical specifications for the BCH1302N32A1C are:
Length: 147.5 mm
Weight: 7 kg
These values are useful for:
- Machine layout
- Mounting-space planning
- Installation handling
- Transportation
- Spare-parts inventory
- Replacement planning
- Equipment design
The stated length should not automatically be treated as the complete installation envelope. Engineers should also consider shaft projection, connectors, cables, mounting hardware, and service access.
Engineering Best Practices
Verify Motor-Drive Compatibility
The servo drive should be matched to the exact BCH1302N32A1C motor and its applicable feedback configuration.
Protect Feedback Wiring
Feedback signals are essential to closed-loop operation. Appropriate cable routing and secure connections help reduce intermittent feedback faults.
Maintain Mechanical Alignment
Correct alignment helps reduce bearing loads, coupling stress, vibration, and positioning errors.
Consider the Complete Motion Profile
Acceleration, deceleration, load inertia, duty cycle, mechanical transmission, and machine dynamics should all be considered during system design.
Document the Configuration
Record the motor model, drive configuration, motion parameters, commissioning results, and maintenance history.
Use Controlled Startup
Initial commissioning should be performed under controlled conditions before full production operation.
Compatible Automation Components
Depending on the machine architecture, the BCH1302N32A1C may be integrated with:
- Compatible Schneider Electric servo drives
- Modicon PLC systems
- Motion controllers
- Industrial HMIs
- Industrial communication networks
- Machine safety systems
- Motor feedback interfaces
- Servo motor power cables
- Feedback cables
- Mechanical couplings
- Gearboxes
- Linear motion mechanisms
Exact compatibility should be confirmed for the complete motor, drive, controller, feedback, and mechanical configuration.
Recommended Related Schneider Product Categories
| Product Category | General Function |
|---|---|
| Schneider BCH Servo Motors | Industrial servo motion |
| Schneider Servo Drives | Closed-loop motor control |
| Schneider Motion Controllers | Coordinated machine movement |
| Schneider Modicon PLCs | Machine and process control |
| Schneider HMIs | Operator interface and monitoring |
| Schneider Safety Controllers | Machine safety functions |
These are related product categories and should not be interpreted as direct replacement recommendations for the BCH1302N32A1C.
Key Advantages
- Designed for industrial servo motion applications
- Suitable for closed-loop motion-control systems
- Supports controlled and repeatable rotary movement
- Can be integrated with compatible Schneider servo drives
- Supplied length of 147.5 mm
- Supplied weight of 7 kg
- Suitable for automated positioning applications
- Applicable to packaging, assembly, handling, and manufacturing machinery
- Supports coordinated machine movement
- Suitable for industrial automation environments
Technical FAQs
What is the Schneider BCH1302N32A1C?
The Schneider BCH1302N32A1C is a Schneider Electric servo motor designed for industrial motion-control applications.
What is the length of the BCH1302N32A1C?
The supplied length is 147.5 mm.
How much does the BCH1302N32A1C weigh?
The supplied weight is 7 kg.
What is the BCH1302N32A1C used for?
It is intended for industrial automation systems requiring controlled rotary movement, positioning, speed regulation, and coordinated machine operation.
Does the BCH1302N32A1C require a servo drive?
A servo motor normally operates with a compatible servo drive that controls motor power and processes closed-loop feedback.
What should be checked before replacing the motor?
The complete model number, feedback configuration, brake configuration where applicable, shaft arrangement, mounting configuration, connector arrangement, cables, and servo-drive compatibility should be verified.
Are the 147.5 mm length and 7 kg weight enough to select a replacement?
No. Physical dimensions and weight are useful for mechanical planning but do not establish electrical, feedback, mechanical-interface, or performance compatibility.
What can cause positioning errors?
Possible causes include incorrect tuning, feedback problems, mechanical backlash, coupling issues, excessive load, mechanical slippage, or incorrect motion parameters.
What can cause the servo motor to overheat?
Possible causes include excessive mechanical load, high duty cycle, mechanical friction, insufficient heat dissipation, incorrect configuration, or operating conditions outside the applicable specifications.
Conclusion
The Schneider Electric BCH1302N32A1C Servo Motor is an industrial motion-control component designed to operate within a compatible closed-loop servo architecture. When correctly integrated with a servo drive, feedback system, motion controller, and mechanical load, it can provide controlled and repeatable rotary movement for automated machinery.
The supplied physical specifications are 147.5 mm in length and 7 kg in weight. These values are useful for machine layout, mounting-space planning, handling, transportation, spare-parts management, and replacement preparation.
Reliable operation depends on the complete servo system rather than the motor alone. Correct motor-drive matching, proper mechanical alignment, secure feedback connections, controlled commissioning, appropriate operating conditions, and preventive maintenance all contribute to stable machine performance.
When sourcing or replacing the BCH1302N32A1C, the complete model designation should be checked carefully. Exact electrical ratings, feedback characteristics, shaft dimensions, mounting details, brake configuration, and other performance parameters should be confirmed against the applicable documentation for the specific motor before installation.