ProductPRODUCT
Featured products
Contact Us
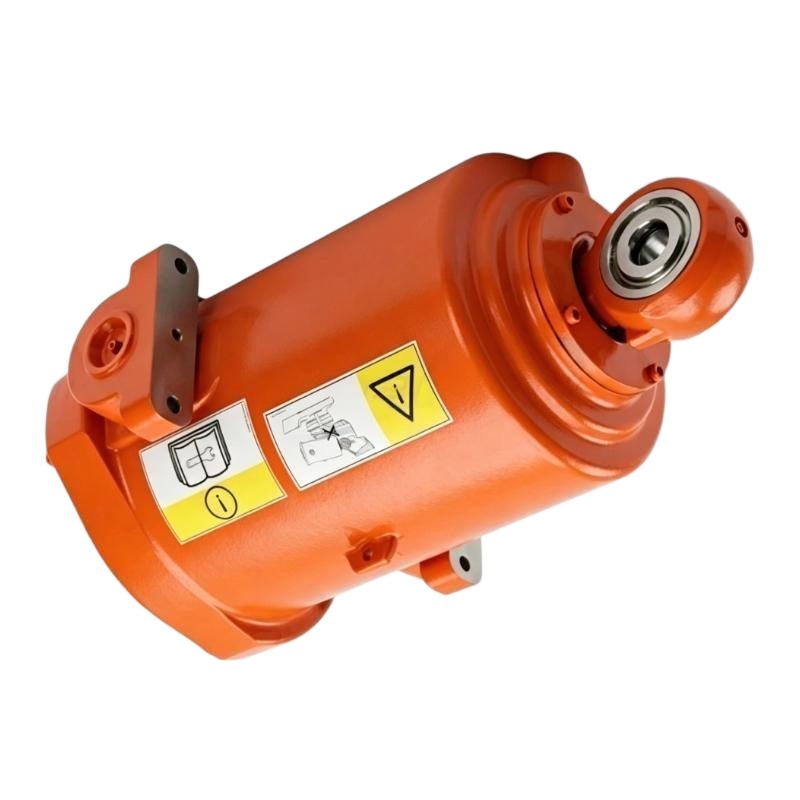
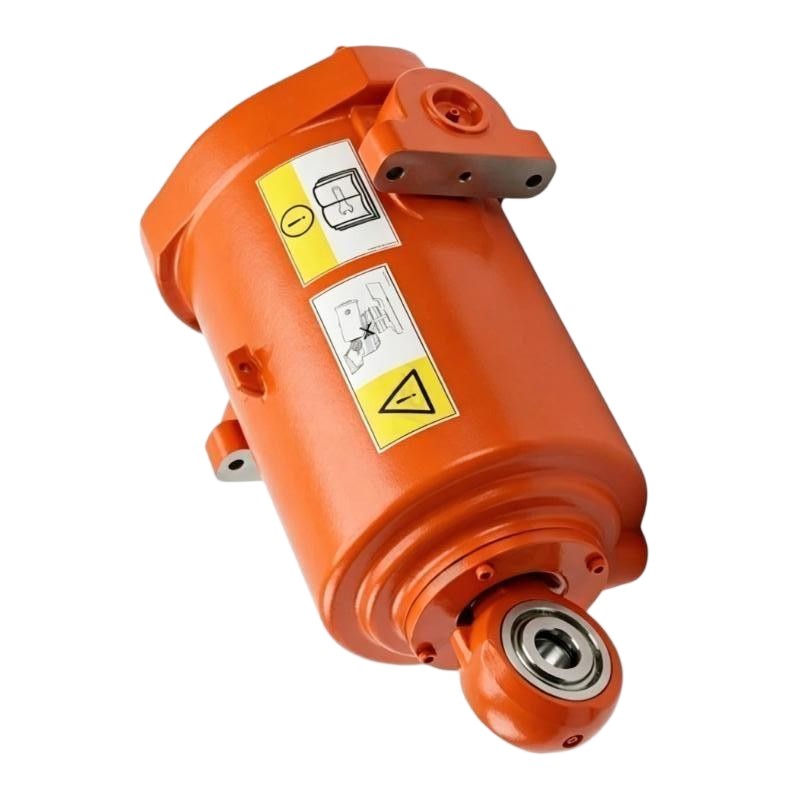
- ABB
- 3HAC14678-1
- Balancing Device F
- Sweden (SE)
- 680 × 250 × 500 mm
- 15 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 3
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
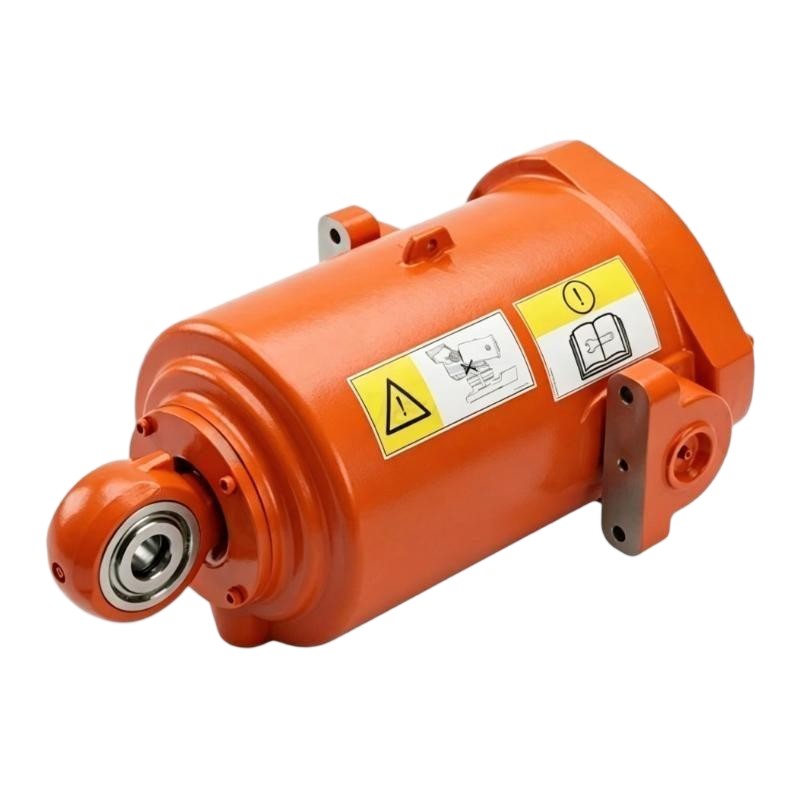
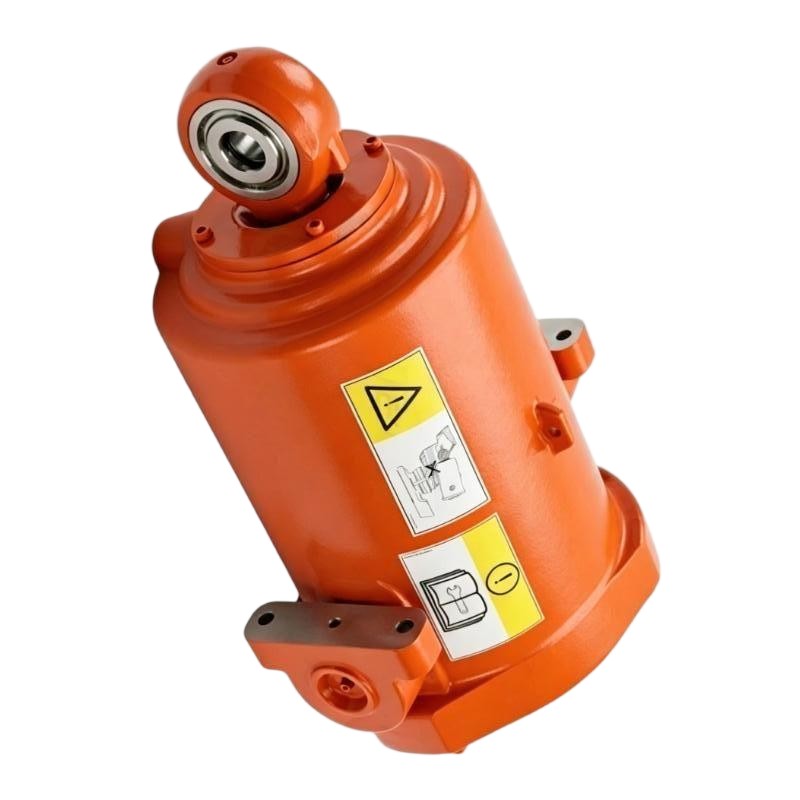
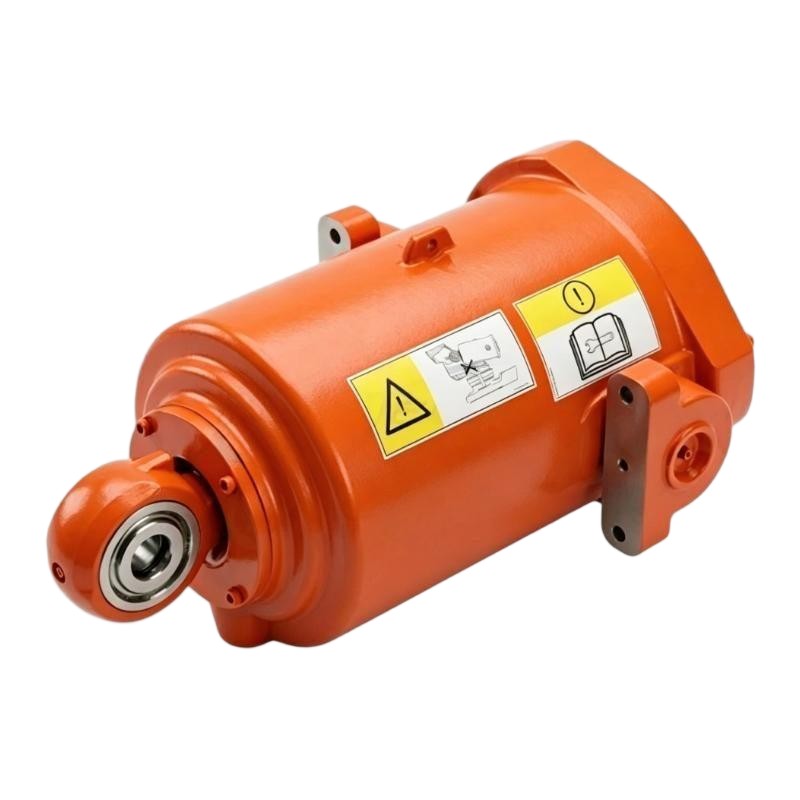
The ABB 3HAC14678-1 IRB 6600 Balancing Device F is a mechanical balancing component used in the articulated structure of compatible ABB IRB 6600 industrial robots. It supports the robot arm by counteracting part of the mechanical load associated with the arm configuration.
Large industrial robot arms are subjected to changing gravitational forces as their axes move through different positions. A balancing device helps manage these forces so that the robot’s drive system does not have to handle the entire static load of the supported mechanism.
The balancing device works as part of the mechanical axis assembly rather than as an electronic control component. Its condition can therefore directly affect mechanical loading, axis behavior, and the overall response of the manipulator during movement.
For maintenance, the device should be inspected together with its mounting points, mechanical connections, associated axis components, and robot structure. Wear, leakage where applicable, looseness, or mechanical damage can change the load characteristics of the robot and should be investigated before continued operation.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | 3HAC14678-1 |
| Product Family | ABB IRB 6600 |
| Product Type | Balancing Device |
| Designation | F |
| Primary Function | Mechanical load balancing for robot arm |
| System Role | Robot manipulator mechanical support component |
| Typical Application | ABB IRB 6600 industrial robot systems |
| Dimensions | 680 × 250 × 500 mm |
| Weight | 15 kg |
Product Features
- Balancing device identified as F for compatible ABB IRB 6600 robot systems.
- Supports mechanical load balancing within the robot arm assembly.
- Helps counteract gravitational loading on the manipulator structure.
- Reduces the mechanical burden placed on associated axis-drive components.
- Works as part of the robot’s mechanical support and axis structure.
- Suitable for articulated robot applications with changing arm positions.
- Requires correct mechanical mounting and alignment.
- Intended for maintenance or replacement within compatible IRB 6600 assemblies.
Working Principle
The 3HAC14678-1 works by providing a balancing force within the robot’s mechanical structure. As the manipulator changes position, the balancing device counteracts part of the gravitational load acting on the associated arm mechanism.
Robot Arm Load → 3HAC14678-1 Balancing Device → Mechanical Load Compensation → Axis Drive / Robot Structure
By compensating for part of the arm load, the balancing device helps maintain a more manageable mechanical load across the robot’s operating range. The robot controller and drive system still control the axis movement, while the balancing device acts passively within the mechanical system.
The balance characteristics are affected by mounting position, mechanical linkage, component condition, and the position of the robot arm. A damaged or improperly installed balancing device can therefore change the force distribution within the manipulator and influence axis movement.
Role in an ABB IRB 6600 Mechanical Control Architecture
The 3HAC14678-1 occupies the mechanical load-balancing layer of the IRB 6600 robot. It works between the manipulator structure and the axis-drive system by compensating part of the static mechanical load.
Robot Controller → Drive System → Axis Mechanism → Manipulator Structure
** ↑**
** 3HAC14678-1 Balancing Device F**
| System Element | Function |
|---|---|
| Robot Controller | Coordinates programmed robot movement |
| Robot Drive System | Controls motor torque and axis movement |
| Axis Mechanism | Transfers motor torque into mechanical movement |
| 3HAC14678-1 | Provides mechanical load-balancing assistance |
| Robot Arm Structure | Carries and positions the manipulator components |
| Mechanical Joints | Allow articulated robot movement |
| End Effector | Performs the programmed manufacturing operation |
The balancing device does not execute motion commands. Its contribution is mechanical: it helps the axis system manage the changing load imposed by the robot arm.
Industrial Applications
| Application | Typical Use |
|---|---|
| ABB IRB 6600 Robots | Mechanical arm-load balancing |
| Material Handling | Support for repetitive heavy-load robot movement |
| Welding Automation | Load compensation during articulated movement |
| Machine Tending | Mechanical support during arm positioning |
| Palletizing Systems | Balancing of changing arm loads |
| Assembly Automation | Support for repeated robot-axis movement |
| Robotic Production Cells | Mechanical load management |
| Robot Refurbishment | Replacement of worn balancing components |
Installation and Maintenance
- Verify the complete 3HAC14678-1 part number and IRB 6600 application before installation.
- Confirm that the balancing device matches the intended manipulator configuration and mounting arrangement.
- Secure the robot and follow the applicable ABB service procedure before removing a load-bearing mechanical component.
- Inspect mounting brackets, attachment points, and mechanical linkages before installing the replacement.
- Check the balancing device for visible deformation, corrosion, leakage, or other signs of mechanical damage.
- Use suitable lifting and support equipment when handling the assembly during maintenance.
- Install the device in the correct orientation and mounting position.
- Verify that all mechanical fasteners and connection points are properly secured.
- Check that the balancing mechanism moves through its intended range without mechanical interference.
- Perform controlled robot-axis movement after installation and observe for abnormal load behavior.
- Investigate unusual noise, vibration, increased motor loading, or unexpected axis behavior by checking the balancing device and related mechanics together.
- After replacement, complete the applicable ABB robot functional checks and verify normal axis operation before returning the robot to production.
Compatible System Components
| Component | Function |
|---|---|
| ABB IRB 6600 Manipulator | Provides the articulated robot structure |
| Robot Axis Assembly | Produces controlled mechanical movement |
| Robot Drive Unit | Controls the associated axis motor |
| Axis Motor | Generates torque for robot movement |
| Mechanical Linkage | Transfers balancing forces within the arm |
| Mounting Brackets | Secure the balancing device to the manipulator |
| Robot Controller | Coordinates programmed robot motion |
| Robot Maintenance Equipment | Supports servicing of mechanical robot components |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| ABB 3HAC14678-1 | IRB 6600 Balancing Device | Robot arm load balancing |
| ABB IRB 6600 Series | Industrial Robot | Heavy-duty articulated automation |
| ABB IRB 6600 Mechanical Assemblies | Robot Mechanical Component | Manipulator maintenance |
| ABB Robot Axis Assemblies | Robot Mechanical Assembly | Controlled axis movement |
| ABB Robot Drive Units | Robot Drive Module | Axis motor control |
| ABB Robot Axis Motors | Rotational AC Motor | Robot-axis torque generation |
| ABB Robot Gearbox Assemblies | Mechanical Transmission | Torque transfer within robot axes |
| ABB Robot Maintenance Components | Service Components | Robot overhaul and repair |
Key Advantages
- Supports mechanical load balancing in compatible IRB 6600 robot assemblies.
- Helps counteract gravitational loading within the articulated arm.
- Reduces the static mechanical burden on associated axis components.
- Supports more consistent mechanical behavior across different arm positions.
- Functions as a passive mechanical component within the robot structure.
- Suitable for maintenance and refurbishment of compatible IRB 6600 manipulators.
Technical FAQs
What is the purpose of a balancing device on the IRB 6600?
It counteracts part of the gravitational load acting on the robot arm. This helps the mechanical axis system manage the arm load without relying entirely on motor torque to support the structure.
What symptoms can indicate a problem with the balancing device?
Unexpected changes in axis loading, unusual mechanical noise, abnormal movement, increased drive effort, or visible mechanical damage can justify an inspection. The related linkage and mounting points should also be checked.
Can the robot operate if the balancing device is damaged?
Operation should not be assumed to be safe or normal if a load-balancing component is damaged. The robot should be secured and inspected according to the applicable ABB maintenance procedure before further operation.
What should be verified after replacing the 3HAC14678-1?
Check the mounting arrangement, mechanical connections, movement range, and axis behavior under controlled conditions. The applicable robot functional and maintenance checks should be completed before returning the manipulator to production.