ProductPRODUCT
Featured products
Contact Us
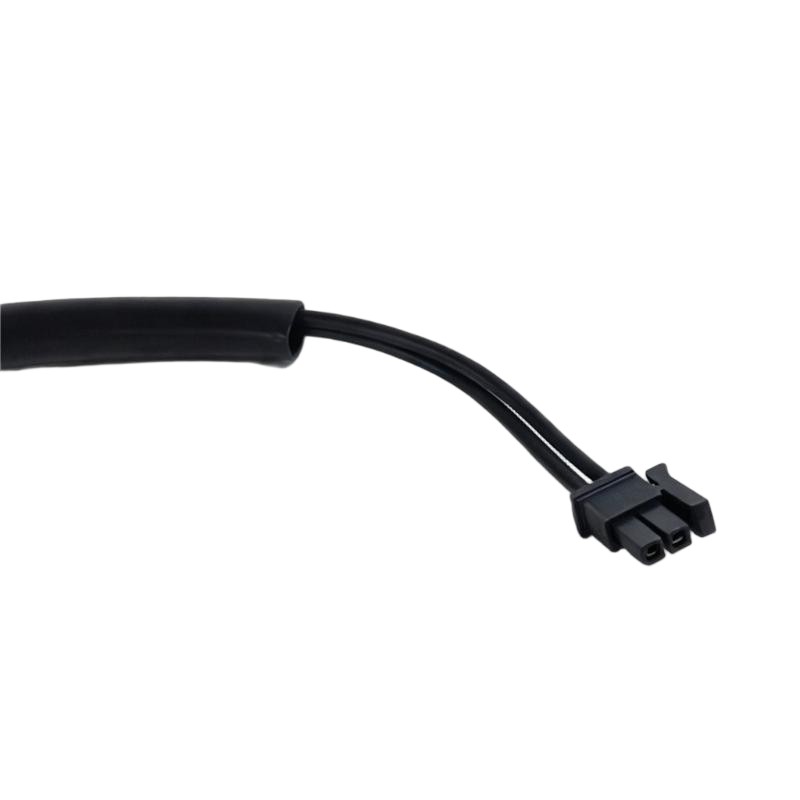
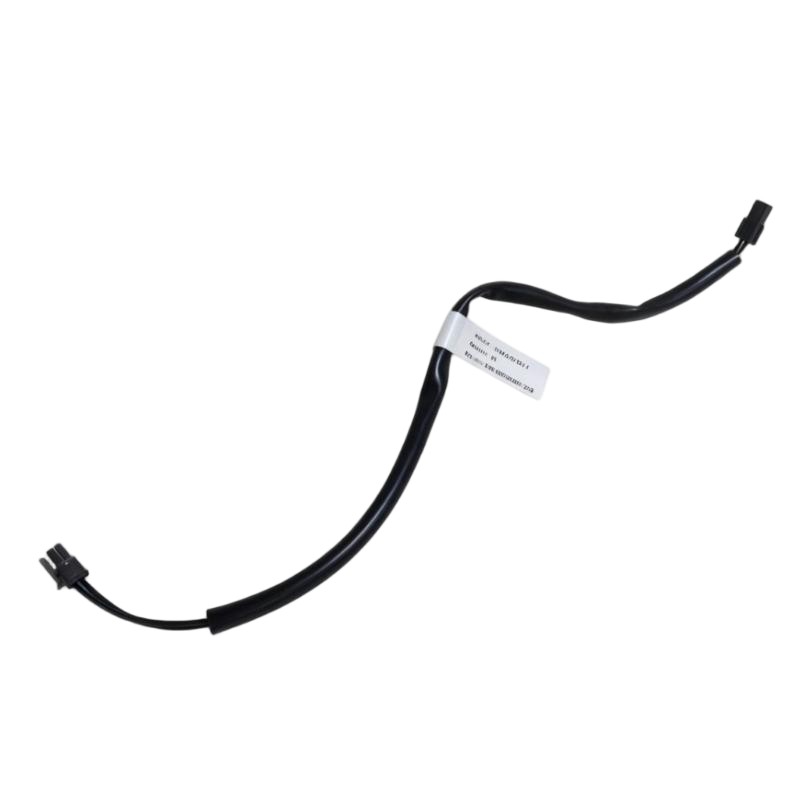
- ABB
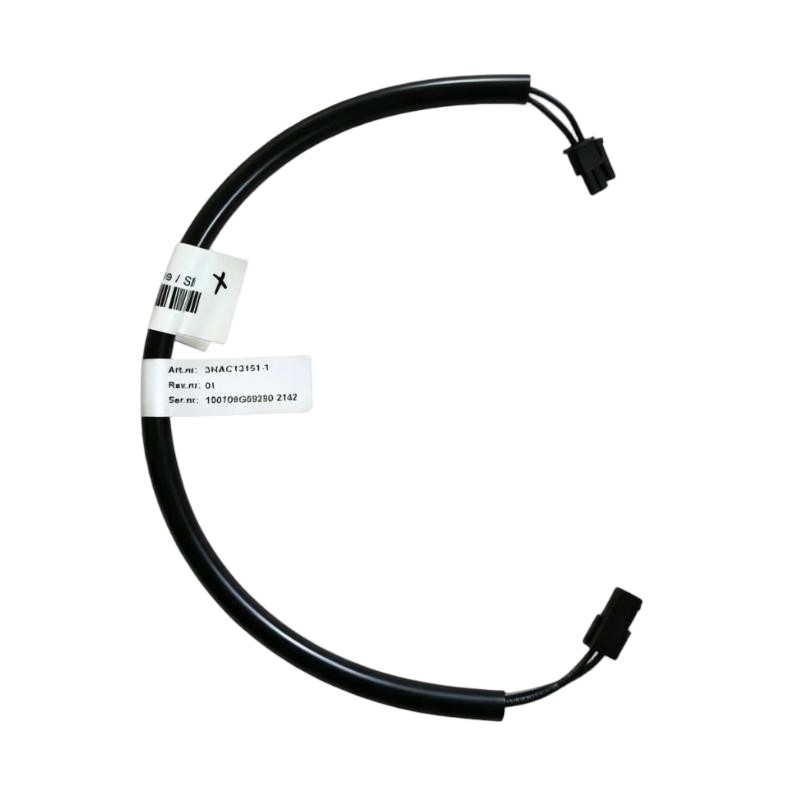
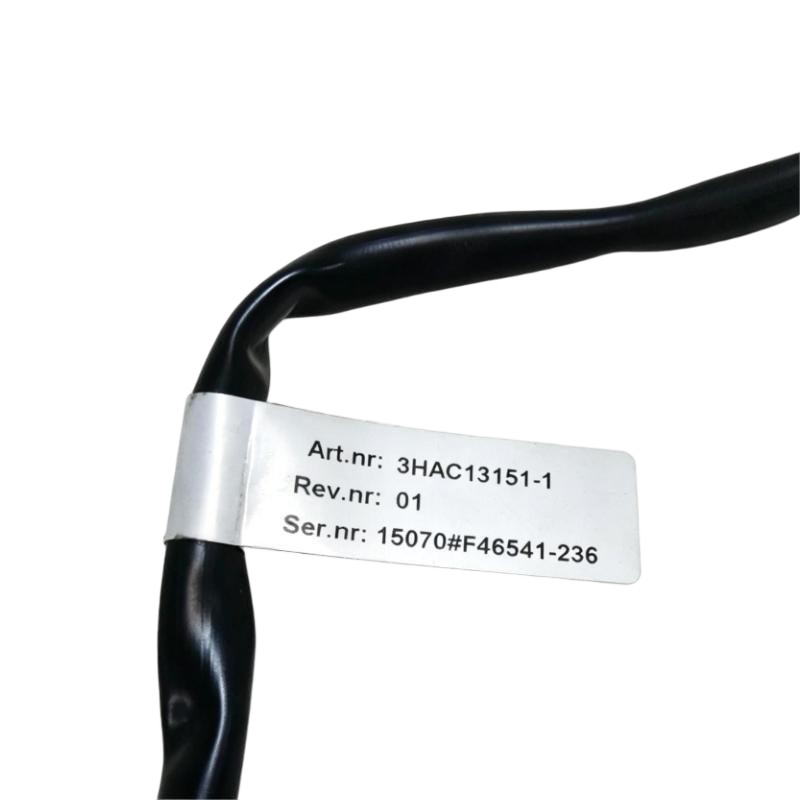
- 3HAC13151-1
- IRB Battery/SMB Cable
- Sweden (SE)
- Optional
- 3 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
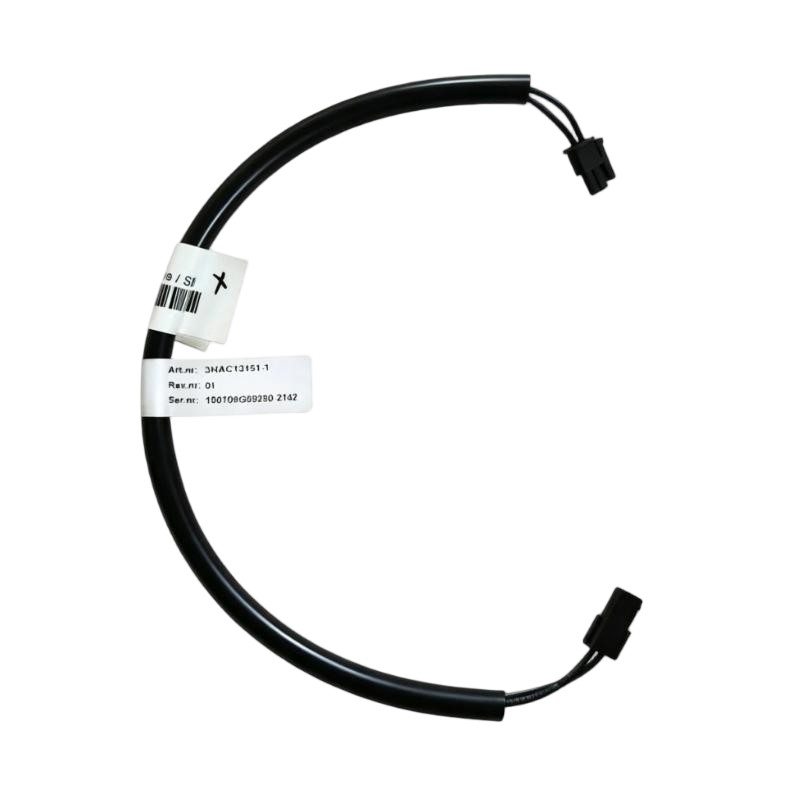
The ABB 3HAC13151-1 IRB Battery/SMB Cable is a dedicated cable assembly used within compatible ABB industrial robot systems to connect the robot battery circuit with the SMB (Serial Measurement Board) interface.
The cable forms part of the robot’s internal electrical infrastructure rather than the primary motor-power path. Its connection supports the electrical relationship between the battery arrangement and the SMB-related circuitry used within the robot manipulator.
In ABB robot systems, the battery and SMB assembly are associated with maintaining and handling relevant robot-axis measurement and position information. A correctly connected cable is therefore necessary for the associated circuit to operate as intended.
During maintenance, the cable should be inspected together with its connectors, battery connection, SMB assembly, and cable routing. A loose connector, damaged conductor, or incorrectly routed cable can produce electrical or axis-related faults even when the associated electronic components are functioning normally.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | 3HAC13151-1 |
| Product Family | ABB Robotics |
| Product Type | IRB Battery/SMB Cable |
| Primary Function | Battery-to-SMB electrical interconnection |
| System Role | Robot internal wiring and signal connection |
| Typical Application | ABB IRB industrial robot systems |
| Cable Length | Optional |
| Shipping Weight | 3 kg |
Product Features
- IRB Battery/SMB cable for compatible ABB robot systems.
- Provides an electrical connection between the battery arrangement and SMB circuitry.
- Forms part of the robot’s internal wiring system.
- Supports the electrical interface associated with robot position-related circuitry.
- Suitable for maintenance and replacement of compatible ABB robot cable assemblies.
- Designed for integration within the manipulator’s internal cable routing.
- Requires correct connector identification and routing during replacement.
- Cable length configuration can vary according to the applicable robot installation.
Working Principle
The 3HAC13151-1 provides the electrical path between the robot battery circuit and the SMB assembly. The cable carries the required electrical connection between these two points while the associated SMB circuitry handles its intended robot measurement and position-related functions.
IRB Battery Assembly → 3HAC13151-1 Battery/SMB Cable → SMB Assembly → Robot Controller / Axis System
The cable itself does not perform position measurement, battery management, or robot motion control. Its role is to maintain electrical continuity between the connected components.
Because the cable is installed inside a robot manipulator, connector condition and mechanical routing are important. Repeated robot movement, improper restraint, excessive bending, or connector stress can contribute to intermittent electrical faults.
Role in an ABB IRB Robot Control Architecture
The 3HAC13151-1 belongs to the internal electrical connection layer of the ABB IRB robot. It links the battery-related circuit with the SMB assembly that participates in the robot’s measurement and position-data infrastructure.
IRB Battery → 3HAC13151-1 Cable → SMB Assembly → Robot Axis Measurement / Control System
| System Element | Function |
|---|---|
| IRB Battery Assembly | Supplies the required battery-side electrical path |
| 3HAC13151-1 | Connects the battery circuit with the SMB assembly |
| SMB Assembly | Handles associated serial measurement functions |
| Robot Controller | Coordinates robot operation and motion control |
| Axis Measurement System | Provides relevant axis position information |
| Robot Manipulator | Provides the mechanical structure for robot movement |
The cable should be viewed as part of the complete battery/SMB connection rather than as an independent electronic module.
Industrial Applications
| Application | Typical Use |
|---|---|
| ABB IRB Robots | Battery-to-SMB internal connection |
| Robot Axis Systems | Support for associated measurement circuitry |
| Welding Robots | Internal electrical connection within manipulator |
| Assembly Robots | Maintenance of battery/SMB wiring |
| Material Handling Robots | Replacement of compatible internal cable assemblies |
| Machine Tending Robots | Internal manipulator wiring maintenance |
| Robotic Production Cells | Service replacement of robot wiring |
| Robot Overhaul Projects | Renewal of aging battery/SMB cable connections |
Installation and Maintenance
- Verify the complete 3HAC13151-1 part number and intended ABB IRB robot application before installation.
- Confirm that the replacement cable matches the installed battery and SMB configuration.
- Isolate robot power and follow the applicable maintenance procedure before accessing internal wiring.
- Record the original cable routing and connector positions before disconnecting the existing cable.
- Inspect the battery-side and SMB-side connectors for damage, contamination, or loose contacts.
- Route the replacement cable along the approved internal manipulator path.
- Avoid excessive bending, twisting, tension, crushing, or contact with moving mechanical parts.
- Secure the cable at the designated restraint points to prevent movement during robot operation.
- Verify that each connector is fully seated and connected to the correct interface before energizing the robot.
- Check the associated battery and SMB circuit for connection or continuity problems where required.
- Perform controlled robot-system diagnostics and axis movement after installation.
- After replacement, verify the relevant battery/SMB functions and complete the applicable robot calibration or functional verification before returning the robot to production.
Compatible System Components
| Component | Function |
|---|---|
| ABB IRB Battery Assembly | Provides the battery-side electrical connection |
| ABB SMB Assembly | Provides serial measurement functions |
| Robot Controller | Coordinates robot operation and motion |
| Axis Measurement System | Supplies relevant position information |
| Robot Manipulator | Houses the internal electrical components |
| Battery Connector | Provides battery-side cable connection |
| SMB Connector | Provides connection to the measurement board |
| Internal Robot Wiring | Provides related electrical paths within the arm |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| ABB 3HAC13151-1 | IRB Battery/SMB Cable | Battery-to-SMB interconnection |
| ABB IRB Battery Cable Assemblies | Robot Cable Assembly | Internal battery circuit connection |
| ABB SMB Cable Assemblies | Robot Signal Cable | SMB-related electrical connection |
| ABB Serial Measurement Board | SMB Assembly | Robot axis measurement interface |
| ABB IRB Manipulator Wiring Harnesses | Robot Wiring Harness | Internal manipulator electrical wiring |
| ABB S4C+ Robot Controller | Robot Controller | Industrial robot control |
| ABB S4Cplus M2000 | Robot Controller Platform | Robot motion and system control |
| ABB Robot Internal Cable Assemblies | Internal Cable Assembly | Replacement and maintenance wiring |
Key Advantages
- Provides the dedicated electrical connection between the IRB battery circuit and SMB assembly.
- Supports organized internal wiring within the robot manipulator.
- Helps maintain electrical continuity for the associated battery/measurement circuit.
- Suitable for maintenance and replacement of compatible ABB robot wiring.
- Can simplify troubleshooting of battery/SMB connection-related faults.
- Integrates into the internal electrical architecture of compatible ABB IRB robots.
Technical FAQs
What is the relationship between the battery and SMB connections in this cable?
The 3HAC13151-1 connects the battery-side circuit with the SMB assembly. It provides the electrical path between these components but does not itself perform the measurement or control functions handled by the associated electronics.
What symptoms can indicate a problem with the Battery/SMB cable?
Intermittent battery-related indications, SMB communication or measurement faults, connector errors, or faults associated with particular manipulator positions can justify inspection of the cable and its connectors.
How should the optional cable length be selected?
The required configuration should be matched to the specific ABB IRB manipulator and original cable routing. The replacement should have the correct connector arrangement and sufficient routing length rather than being selected only by nominal cable reach.
Is robot calibration required after replacing the 3HAC13151-1?
Cable replacement does not inherently alter the mechanical geometry of the robot, but the applicable ABB maintenance procedure should be followed. After installation, the battery/SMB circuit, controller diagnostics, and relevant axis functions should be verified before the robot returns to production.