ProductPRODUCT
Featured products
Contact Us
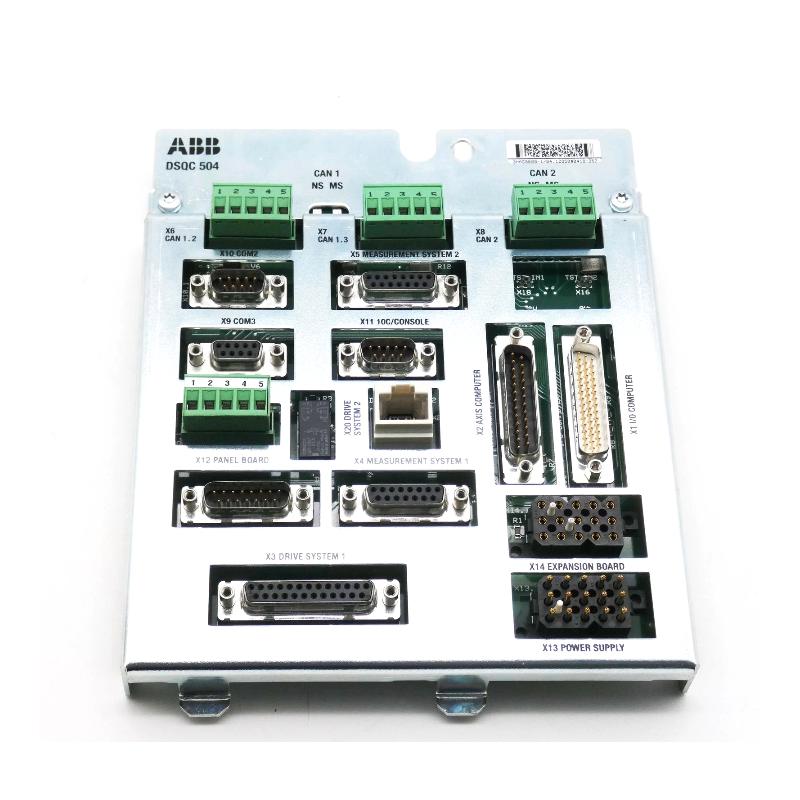
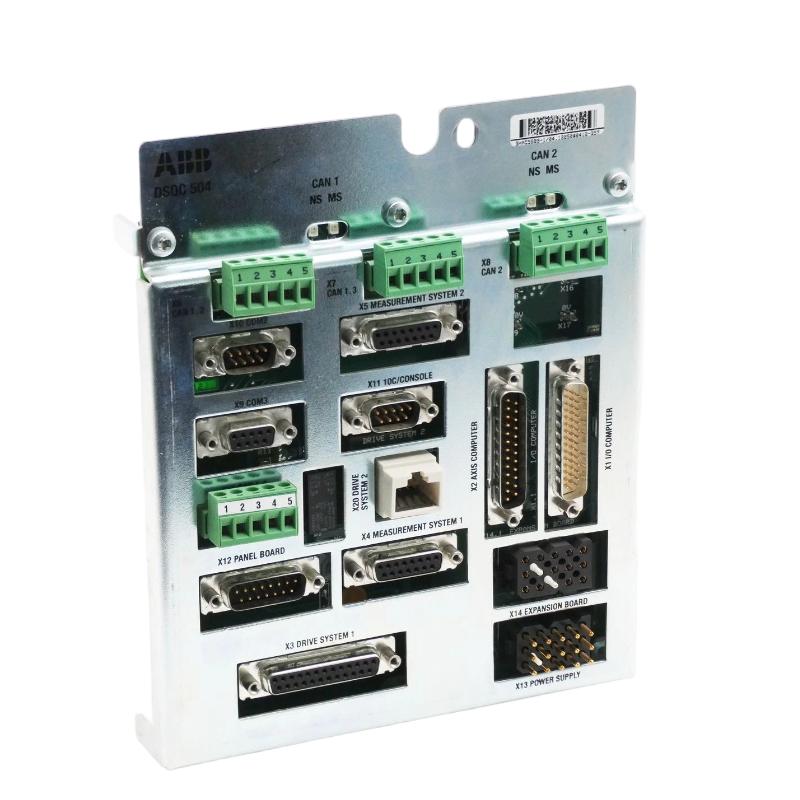
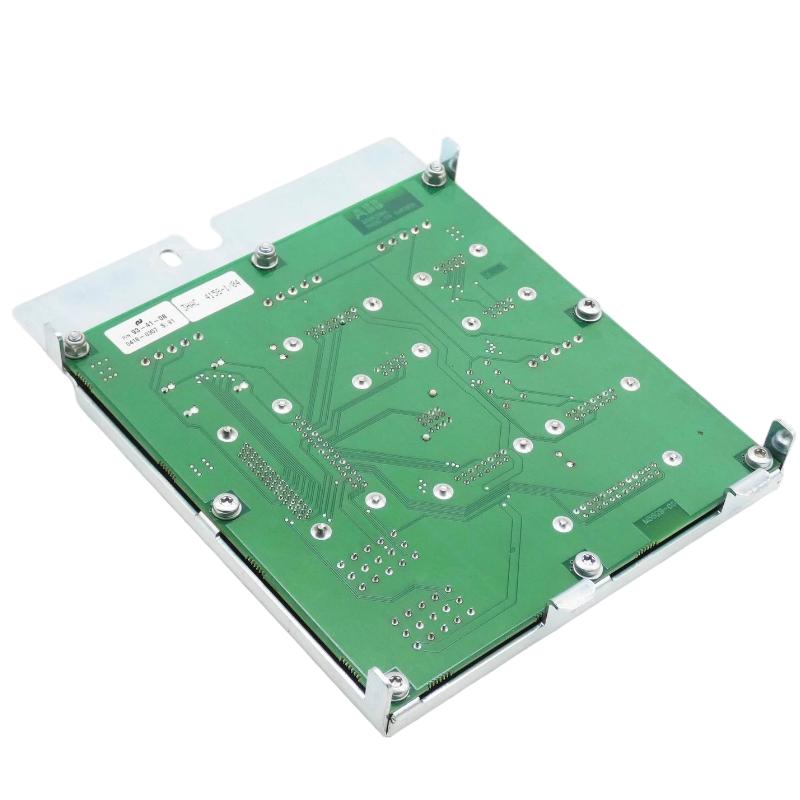
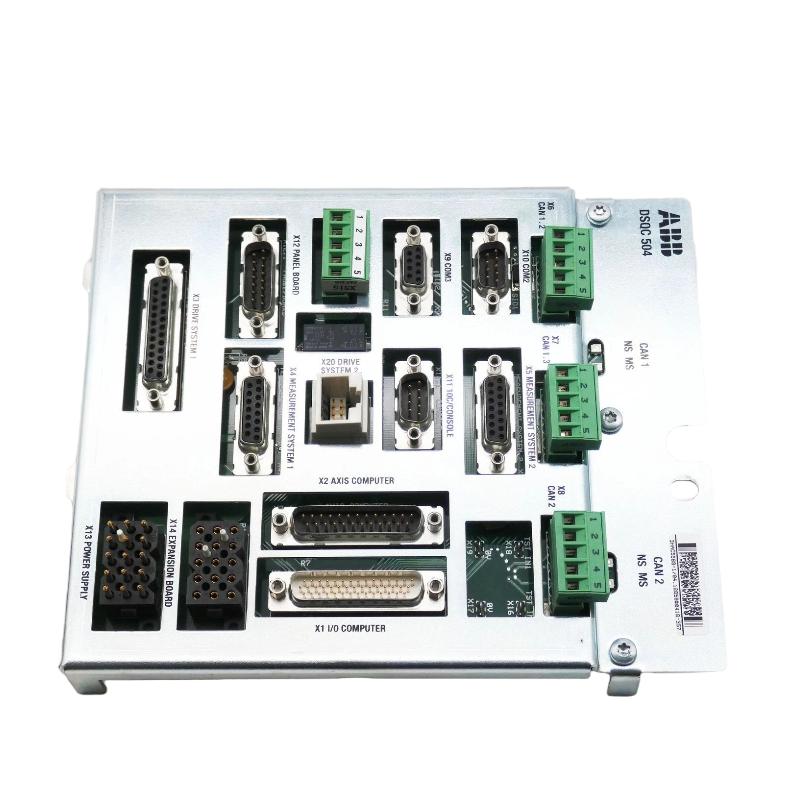
- ABB
- DSQC 504 3HAC5689-1
- Base Connection Unit
- Sweden (SE)
- 200 × 25 × 185 mm
- 0.54 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 4
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
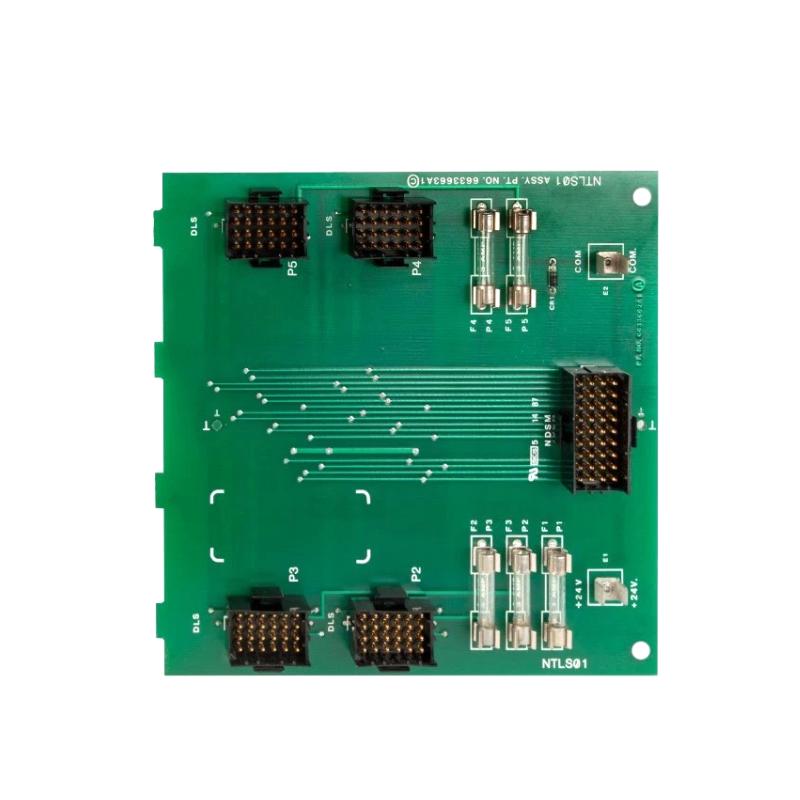
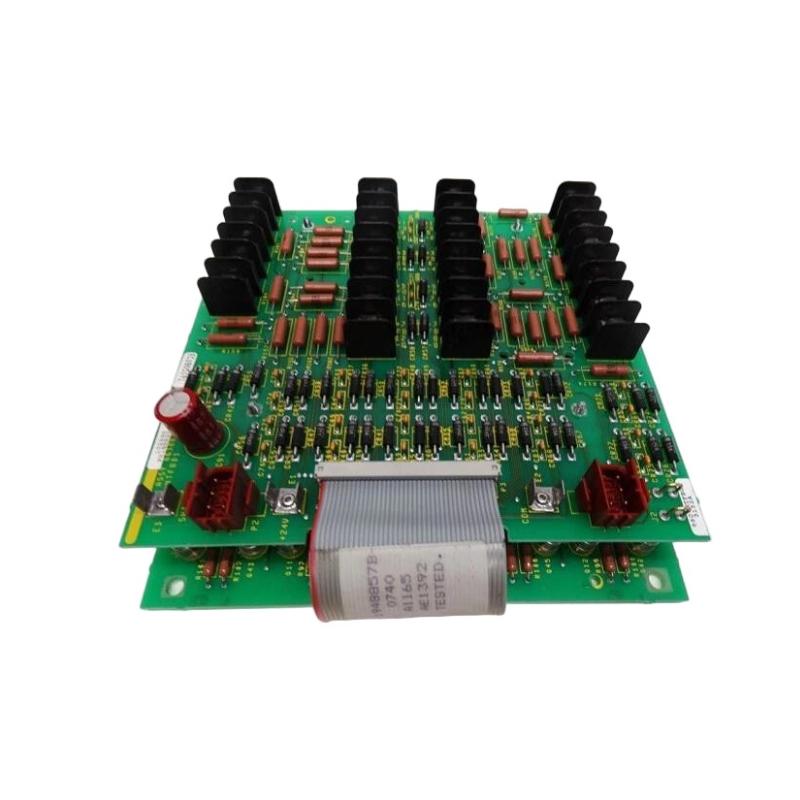
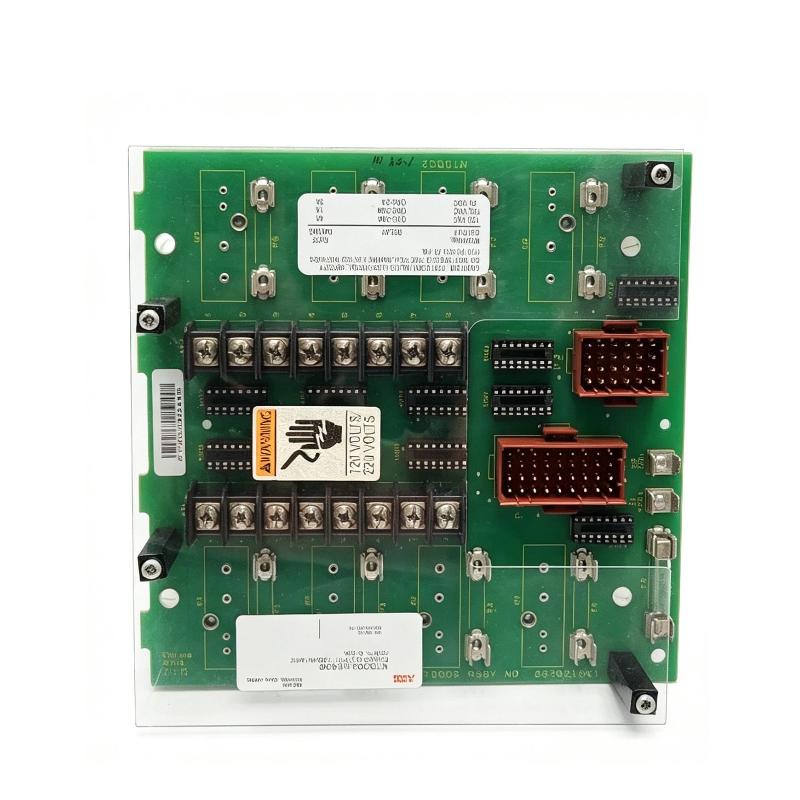
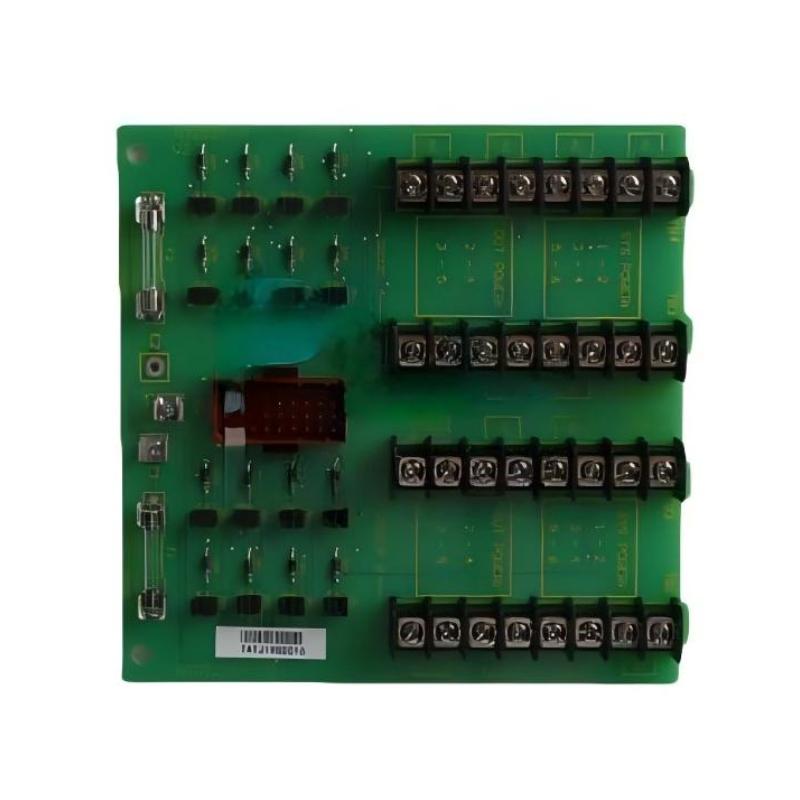
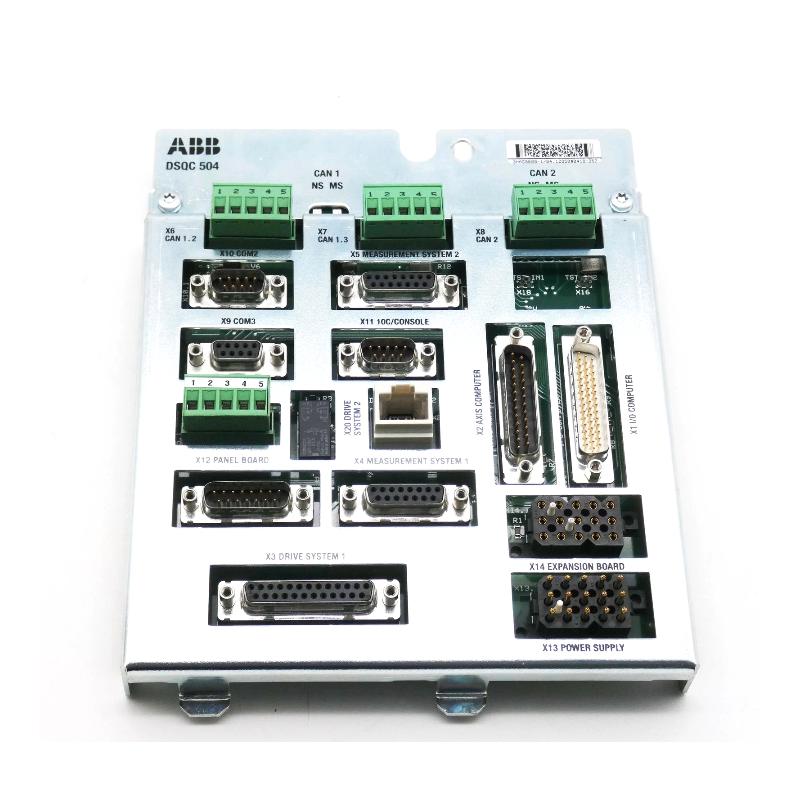
The ABB DSQC 504 3HAC5689-1 Base Connection Unit is an interface component used within ABB robot controller systems to provide the physical connection between controller hardware and associated electrical or signal circuits. It forms part of the controller’s internal connection infrastructure rather than performing robot-control processing itself.
A base connection unit is typically used to organize electrical connections between modules installed within the controller architecture. It can provide the mounting and connection interface required for associated control hardware, helping establish defined signal and power paths inside the robot controller.
The DSQC 504 is relevant to ABB robot controller maintenance where connection faults, module replacement, or cabinet refurbishment requires inspection of the controller’s base-level connection hardware. Its condition can affect the continuity of the circuits passing between connected components.
For service work, the unit should be evaluated together with the modules, connectors, terminal wiring, and controller backplane or internal connection arrangement associated with the specific ABB system.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | DSQC 504 3HAC5689-1 |
| Product Family | ABB Robot Controller |
| Product Type | Base Connection Unit |
| Primary Function | Controller module connection and interface |
| System Role | Internal controller connection infrastructure |
| Application | ABB industrial robot control systems |
| Dimensions | 200 × 25 × 185 mm |
| Weight | 0.54 kg |
Product Features
- Base connection unit for compatible ABB robot controller systems
- Provides an interface for associated controller hardware and electrical connections
- Forms part of the internal controller connection infrastructure
- Supports organized module and circuit interconnection
- Suitable for controller service, refurbishment, and replacement work
- Helps maintain continuity between connected controller components
- Applicable to ABB industrial robot control installations
Working Principle
The DSQC 504 functions as a physical connection point within the robot controller. Electrical signals and associated connections from compatible controller components pass through the base connection arrangement to the corresponding circuits.
Controller Module → DSQC 504 Base Connection Unit → Internal Signal / Power Connections → Associated Controller Hardware
The unit itself does not execute robot programs or perform servo regulation. Its role is to establish the electrical and mechanical connection required for other controller components to exchange signals or receive the appropriate circuit connections.
A poor connection, damaged contact, incorrect installation, or loose mounting condition can interrupt the associated circuit. Troubleshooting should therefore include the connection unit and its interfaces when a connected controller module behaves abnormally.
Role in an ABB Robot Controller Connection Architecture
The DSQC 504 occupies the internal connection layer of the robot controller. It links associated controller hardware through the appropriate physical connection arrangement.
Controller Hardware → DSQC 504 → Internal Connection Network → Control / Drive / I/O Hardware
| System Element | Function |
|---|---|
| ABB Robot Controller | Executes robot-control and system functions |
| Controller Modules | Perform processing, I/O, communication, or drive functions |
| DSQC 504 | Provides the base connection interface |
| Internal Wiring / Contacts | Transfers electrical signals and circuit connections |
| Drive System | Controls robot-axis movement where applicable |
| I/O System | Exchanges signals with external equipment |
| Robot Mechanism | Performs the programmed physical operation |
The base connection unit should be checked as part of the complete controller interconnection path when diagnosing module communication or connection-related faults.
Industrial Applications
| Application | Typical Use |
|---|---|
| ABB Robot Controllers | Internal module and circuit connection |
| Robotic Welding Systems | Controller connection infrastructure |
| Material Handling Robots | Internal control-system interconnection |
| Assembly Robot Cells | Base connection for controller hardware |
| Automotive Production | Controller cabinet connection arrangement |
| Industrial Robot Maintenance | Replacement of connection hardware |
| Controller Refurbishment | Restoration of internal module connections |
Installation and Maintenance
- Confirm that the DSQC 504 3HAC5689-1 matches the intended ABB controller configuration before installation.
- Isolate controller power before accessing the internal connection assembly.
- Document the original module positions and connection arrangement before removing the existing unit.
- Inspect the replacement unit for damaged contacts, connectors, or mounting features.
- Clean the installation area and remove loose contamination before mounting.
- Install the base connection unit in the correct controller position and orientation.
- Ensure that associated modules and connectors are correctly aligned before insertion or connection.
- Avoid excessive mechanical force that could damage contacts or connector interfaces.
- Verify all associated wiring and connection points against the approved controller documentation.
- Restore controller power under controlled commissioning conditions and check system diagnostics.
- Investigate intermittent module operation, communication faults, or unexpected controller behavior if connection-related symptoms remain.
- After replacement, verify the affected controller modules, I/O, drive functions, and robot operation before returning the system to service.
Compatible System Components
| Component | Function |
|---|---|
| ABB Robot Controller | Provides robot-control and system processing |
| DSQC 504 | Provides the base connection interface |
| Controller Modules | Perform associated processing and control functions |
| Internal Wiring | Transfers electrical signals between components |
| Connector Assemblies | Establish electrical connections between modules |
| Robot Drive Components | Support servo-axis motion |
| Robot I/O Components | Interface external machine signals |
| Controller Power System | Supplies electrical power to controller hardware |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| ABB DSQC 504 | Base Connection Unit | Robot controller module connection |
| ABB 3HAC5689 Series | Connection Component | ABB controller internal interconnection |
| ABB S4C+ Connection Components | Controller Connection | S4C+ internal module connections |
| ABB S4Cplus M2000 Components | Controller Hardware | Robot controller infrastructure |
| ABB Robot Controller Base Units | Connection Unit | Internal controller module installation |
| ABB Robot Controller Connector Assemblies | Connector Assembly | Electrical interconnection |
| ABB Robot Controller Service Parts | Service Component | Controller maintenance and refurbishment |
Key Advantages
- Provides a dedicated connection interface for compatible ABB robot controller hardware.
- Supports organized internal electrical interconnection between controller components.
- Helps maintain continuity of associated signal and circuit paths.
- Suitable for controller maintenance and replacement applications.
- Supports the modular connection architecture of compatible ABB robot controllers.
- Useful when restoring damaged or degraded internal controller connections.
Technical FAQs
What is the DSQC 504 used for inside an ABB robot controller?
The DSQC 504 serves as a base connection interface for associated controller hardware. It supports the physical electrical interconnection between compatible modules and circuits rather than performing processing or motion-control functions itself.
Can a connection-unit problem cause intermittent controller faults?
Yes. Poor contact, connector damage, incorrect seating, or mechanical movement can interrupt electrical connections and produce intermittent module or system behavior. The base connection and associated interfaces should be inspected when faults appear inconsistent.
What should be checked before replacing the DSQC 504?
Verify the exact controller configuration, module arrangement, connector locations, and wiring documentation. The replacement unit should match the existing connection architecture before installation.
How should the DSQC 504 be tested after replacement?
After checking all connections, restore controller power and review system diagnostics. Test the affected controller modules and then verify I/O, drive functions, and robot operation to confirm that the complete connection path is functioning correctly.