ProductPRODUCT
Featured products
Contact Us
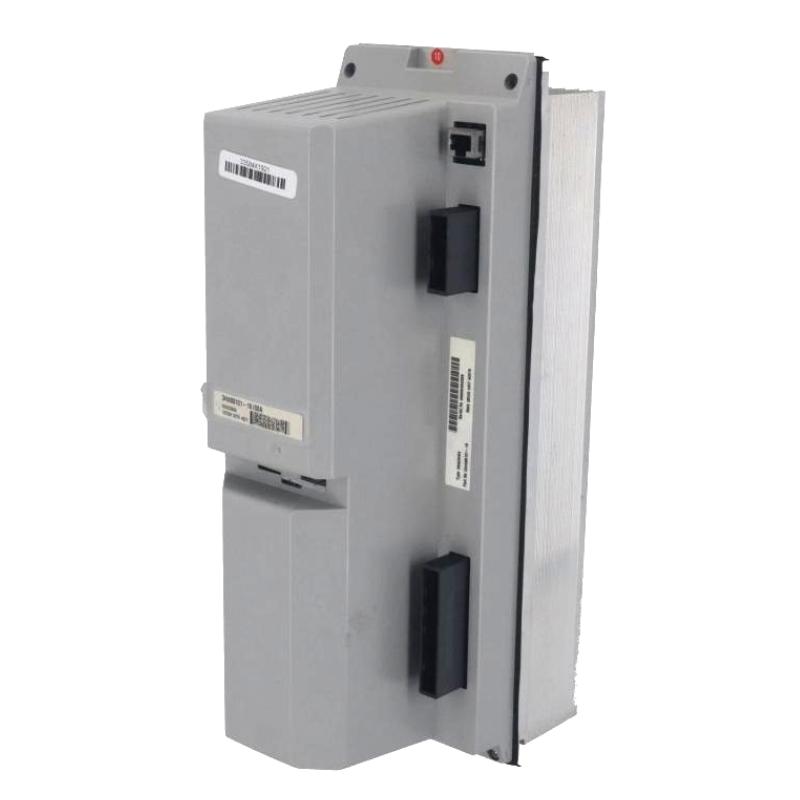
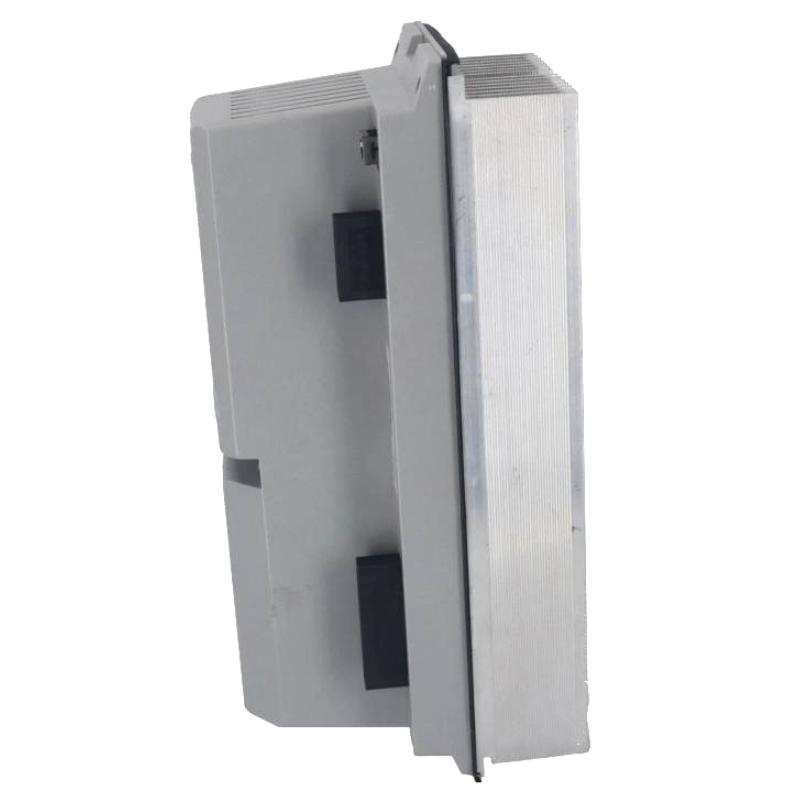
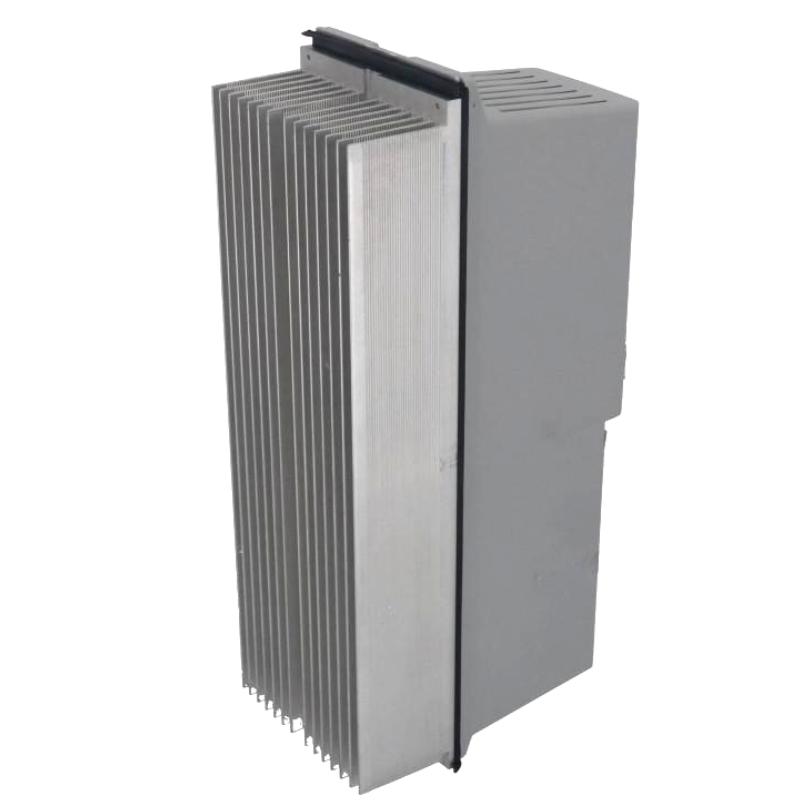
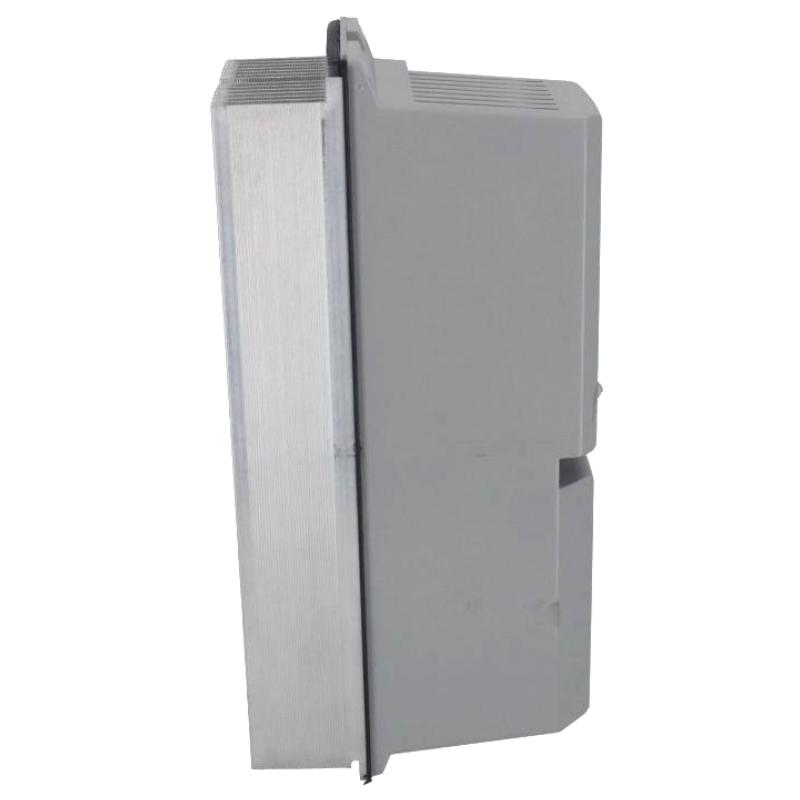
- ABB
- DSQC 546A 3HAB8101-18/09C
- InMotion Drive Unit
- Sweden (SE)
- 285 × 65 × 150 mm
- 4.2 kg
- Xiamen, China
- New & In Stock
- T/T, PayPal, Western Union
- 1 Year
- 1-3 Working Days
- DHL, UPS, TNT, FedEx and EMS.
- 24-Hour Service
- COO
- 5
Our advantage
Global Logistics
We have a 10-year logistics and express cooperation agreement, so our products can be shipped to any place in the world.
Brand new and original
Our products are imported in bulk from the place of origin. Because of the cooperative relationship, our products are all original and 100% new.
24-hour service
We provide 7*24 hours service to our customers. We will be there whenever you need us.
Price advantage
All our products are priced very favorably because we have our own warehouse and supply.
| Company Information | |||
| [email protected] | |||
| Mobile | +8615980777398 | ||
| +8615980777398 | |||
| 15980777398 |
Product Overview
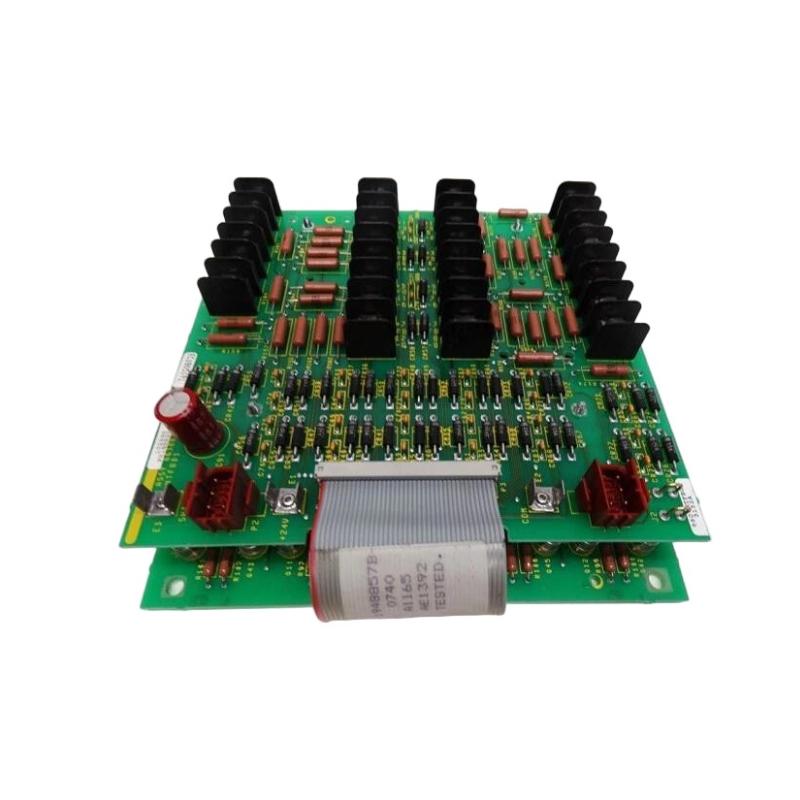
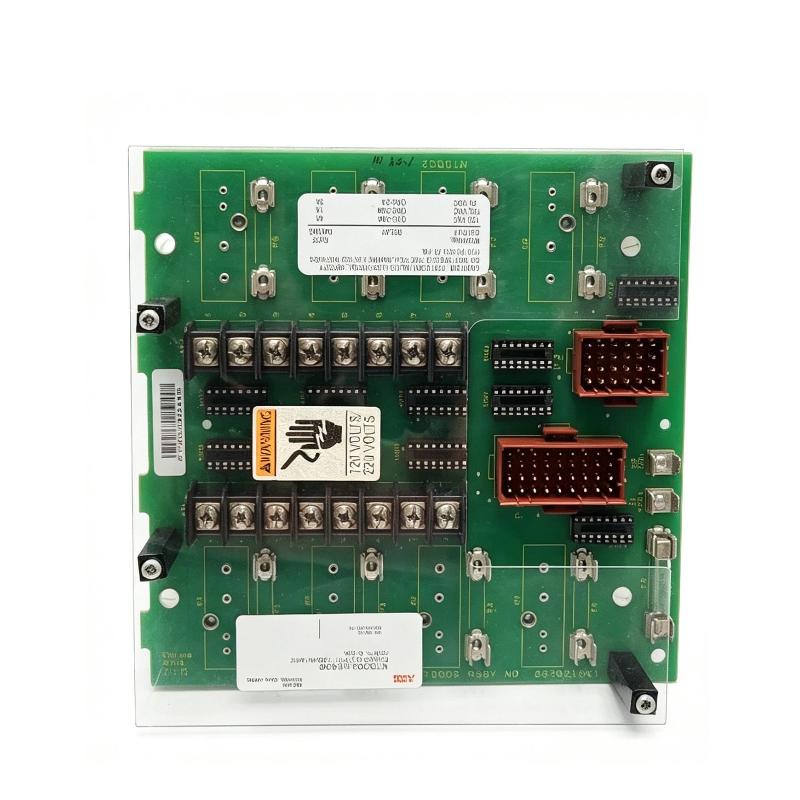
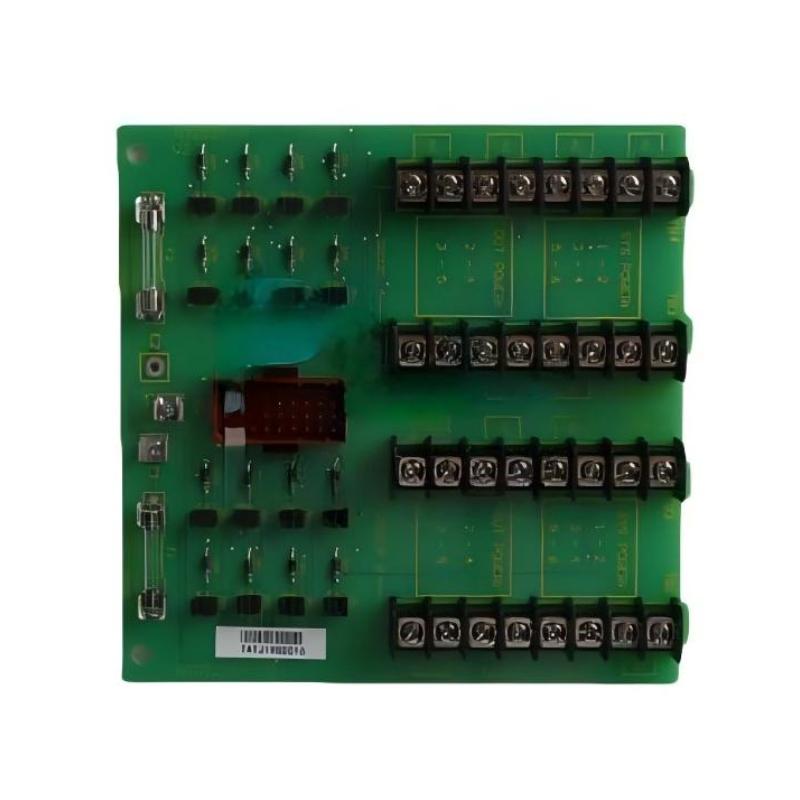
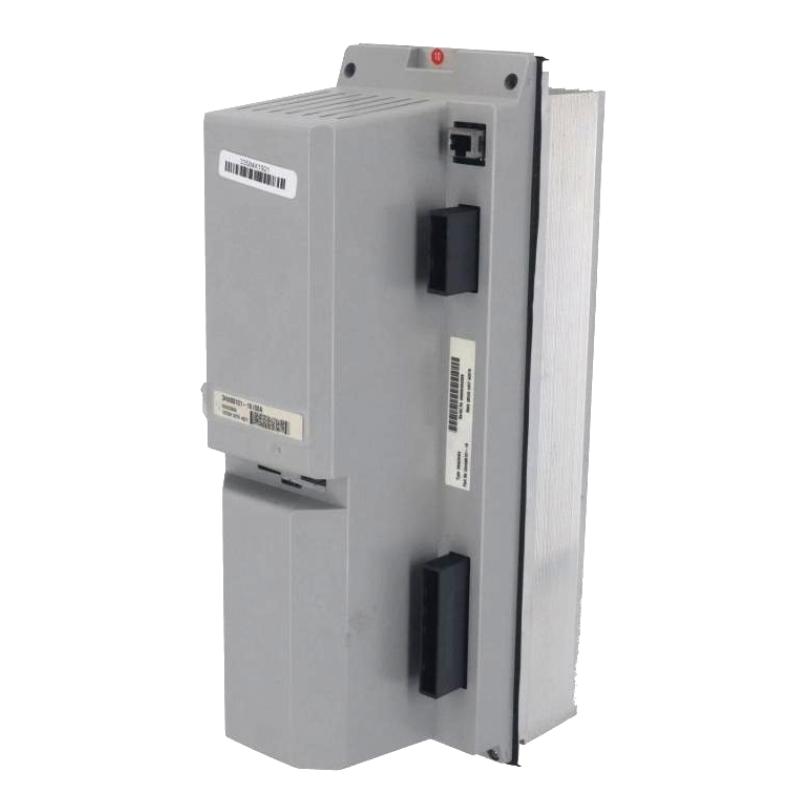
The ABB DSQC 546A 3HAB8101-18/09C InMotion Drive Unit is a drive component used within ABB InMotion robot controller systems to manage the electrical side of robot-axis movement. It forms part of the interface between the robot controller and the servo motor system.
In a multi-axis robot controller, the drive unit receives control information from the motion-control system and works with the associated motor and feedback circuits to produce controlled axis movement. This arrangement allows individual robot axes to follow programmed position, speed, and motion commands.
The DSQC 546A is suited to ABB robotic installations where coordinated servo movement is required, including material handling, welding, assembly, machine tending, and other automated production processes. It is part of the drive infrastructure rather than the robot application software itself.
During maintenance, drive-unit faults should be evaluated together with the controller, motor, feedback system, power supply, and axis wiring. Problems in any of these areas can result in similar symptoms such as axis initialization errors, drive alarms, or loss of controlled movement.
Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | ABB |
| Model | DSQC 546A 3HAB8101-18/09C |
| Product Family | InMotion |
| Product Type | Drive Unit |
| Primary Function | Robot servo drive control |
| System Role | Robot-axis drive interface |
| Application | ABB industrial robot motion-control systems |
| Dimensions | 285 × 65 × 150 mm |
| Weight | 4.2 kg |
Product Features
- InMotion Drive Unit for compatible ABB robot controller systems
- Forms part of the electrical drive path for robot servo axes
- Interfaces controller motion commands with associated drive and motor circuits
- Supports coordinated movement of industrial robot axes
- Works with motor feedback within the overall servo-control system
- Suitable for ABB robot controller maintenance and replacement
- Applicable to multi-axis robotic automation systems
Working Principle
The DSQC 546A operates between the robot controller’s motion-control logic and the associated servo motor circuit. The controller determines the desired axis movement, while the drive unit manages the electrical drive process required to move the motor.
Robot Controller → DSQC 546A Drive Unit → Servo Motor → Robot Axis
Motor Feedback → Servo Control System → Drive / Controller → Motion Correction
During operation, controller commands are translated into electrical drive actions that produce motor torque and rotation. Feedback information from the motor or axis allows the control system to compare actual movement with the commanded motion.
The drive unit therefore forms part of the closed-loop motion system. It does not independently execute the complete robot application program; instead, it performs the drive-side function required to achieve the commanded axis movement.
Role in an ABB InMotion Robot Motion Control Architecture
The DSQC 546A occupies the drive layer between the robot controller and the servo motor and mechanical axis.
Robot Controller → DSQC 546A → Servo Motor → Robot Axis → Mechanical Load
Position / Motion Feedback → Controller / Servo System → DSQC 546A → Motor
| System Element | Function |
|---|---|
| ABB Robot Controller | Executes robot application and motion-control logic |
| DSQC 546A | Provides the drive interface for the robot servo axis |
| Servo Motor | Converts electrical energy into mechanical rotation |
| Feedback System | Reports actual motor or axis movement |
| Motor Power Circuit | Transfers controlled electrical power to the motor |
| Robot Axis | Converts motor rotation into mechanical movement |
| Mechanical Load | Represents the tooling, workpiece, or process load |
Correct operation depends on coordination between the controller, drive unit, motor, feedback circuit, and mechanical axis. A drive-unit replacement should therefore be followed by a complete axis-level functional check.
Industrial Applications
| Application | Typical Use |
|---|---|
| Robotic Welding | Coordinated movement of welding robot axes |
| Material Handling | Controlled robot positioning and axis movement |
| Assembly Automation | Multi-axis positioning during assembly |
| Automotive Manufacturing | Repetitive high-precision robot motion |
| Machine Tending | Robot-axis movement around machine tools |
| Palletizing Systems | Coordinated positioning and trajectory control |
| Industrial Robot Cells | Servo-drive operation within automated cells |
| Robot Controller Service | Replacement of compatible drive-unit hardware |
Installation and Maintenance
- Confirm that the DSQC 546A 3HAB8101-18/09C matches the installed ABB InMotion controller configuration.
- Isolate controller power and servo power before accessing the drive unit.
- Follow the applicable discharge and electrical safety procedures before handling internal drive hardware.
- Record existing power, motor, feedback, and control connections before removing the original unit.
- Inspect the replacement drive unit and connectors for visible damage before installation.
- Verify that the unit is correctly positioned and mechanically secured inside the controller.
- Reconnect motor, feedback, power, and control connections according to the approved system documentation.
- Check connector seating and cable routing before restoring power.
- Energize the controller under controlled commissioning conditions and review system diagnostics.
- Verify drive initialization and investigate any abnormal drive or axis alarms.
- Perform controlled axis movement at reduced operating conditions before normal production speed.
- After replacement, verify feedback, positioning, coordinated motion, and the complete robot operating sequence before returning the system to service.
Compatible System Components
| Component | Function |
|---|---|
| ABB InMotion Controller | Executes robot and motion-control functions |
| DSQC 546A | Provides the robot-axis drive interface |
| Robot Servo Motor | Produces mechanical axis movement |
| Motor Feedback Device | Supplies actual position and motion information |
| Servo Power Circuit | Supplies electrical power to the drive system |
| Motor Power Cable | Transfers controlled electrical power to the motor |
| Feedback Cable | Transfers position and motion signals |
| Robot Mechanical Axis | Converts motor rotation into robot movement |
Recommended Related Models
| Model / Product Family | Product Type | Typical Application |
|---|---|---|
| ABB DSQC 546A | Drive Unit | InMotion robot-axis drive control |
| ABB 3HAB8101 Series | Drive Component | ABB robot controller drive systems |
| ABB InMotion Drive Units | Drive Unit Family | Multi-axis robot motion control |
| ABB S4C+ Drive Components | Robot Drive Component | Robot-axis motion and power control |
| ABB S4Cplus M2000 Drive Components | Drive Component | Industrial robot servo systems |
| ABB Robot Servo Motors | Servo Motor | Robot-axis mechanical movement |
| ABB Robot Feedback Components | Feedback Device | Servo position and motion feedback |
Key Advantages
- Provides the drive-layer interface for compatible ABB InMotion robot axes.
- Supports controlled servo motor operation within the robot motion system.
- Works with controller commands and feedback to support closed-loop axis movement.
- Suitable for coordinated multi-axis industrial robot applications.
- Useful for maintenance and replacement of compatible InMotion drive hardware.
- Integrates with the controller, motor, feedback, and mechanical-axis chain.
Technical FAQs
What role does the DSQC 546A perform in an InMotion robot system?
The DSQC 546A functions at the drive layer, connecting the robot controller’s motion commands with the electrical operation of the associated servo-axis system. It works together with the motor and feedback circuitry rather than replacing the robot controller.
What should be checked if an axis does not initialize after drive replacement?
Check the drive connections, motor power circuit, feedback wiring, controller diagnostics, and configured axis information. A failure to initialize can originate from the drive, feedback path, power circuit, or controller configuration.
Why should the motor and feedback circuits be inspected together with the drive unit?
Servo movement depends on both commanded electrical power and accurate feedback. A damaged feedback connection or motor-side problem can produce drive alarms or abnormal axis behavior even when the drive unit itself is functioning correctly.
What commissioning procedure is appropriate after installing a replacement DSQC 546A?
After verifying wiring and controller diagnostics, initialize the drive under controlled conditions and test the associated axis at reduced operating conditions. Confirm feedback, positioning, and coordinated robot movement before returning the cell to production.